ISSN 1004-132X
CN 42-1294/TH
CN 42-1294/TH
中国机械工程 ›› 2026, Vol. 37 ›› Issue (8): 1889-1899.DOI: 10.3969/j.issn.1004-132X.2026.08.008
• 机械基础工程 • 上一篇
喻曹丰1,2( ), 杨坤1, 沈刚1, 肖志豪1, 王宁1
收稿日期:2025-03-06
出版日期:2026-08-25
发布日期:2026-09-17
通讯作者:
喻曹丰
基金资助:
YU Caofeng1,2(), YANG Kun1, SHEN Gang1, XIAO Zhihao1, WANG Ning1
Received:2025-03-06
Online:2026-08-25
Published:2026-09-17
Contact:
YU Caofeng
摘要:
为满足高端装备制造领域对高性能XY工作台的需求,提出了一种具有大行程和高精度特性的宏微复合驱动XY工作台设计方案。首先设计了一种新型的串并联混合解耦导向机构,并基于键合图理论建立了工作台的动力学模型;然后将有限元法与响应面法相结合,优化了宏微复合驱动器(MMCA)的输出力和宏动误差补偿量;进而通过静力学和模态分析获得了工作台的有效负载能力和振动特性;最后加工了工作台样机,搭建实验测试平台进行测试。结果显示:优化后的MMCA在电流为4 A时,输出力为135 N,宏动误差补偿量为34 μm,较优化前分别增大了32.61 %和12.1 %;工作台的工作范围为49.94 mm×50.04 mm,X方向和Y方向的交叉耦合率分别为0.0511 %和0.0549 %;在未采用微动补偿情况下进行1、20、49 mm宏动大行程定位测试,两方向的稳态位移误差均小于20 μm;当采用微动补偿进行49 mm大行程定位时,X方向与Y方向的最大误差分别为0.25 μm和0.21 μm;在分辨力实验中,X方向与Y方向的分辨力分别达到59 nm和56 nm。研究结果表明,所提宏微复合驱动XY工作台具有大行程、低交叉耦合率和高分辨力等优点,该成果为高端装备制造领域提供高性能XY工作台奠定了理论与技术基础。
中图分类号:
喻曹丰, 杨坤, 沈刚, 肖志豪, 王宁. 宏微复合驱动XY工作台解耦设计与实验研究[J]. 中国机械工程, 2026, 37(8): 1889-1899.
YU Caofeng, YANG Kun, SHEN Gang, XIAO Zhihao, WANG Ning. Decoupling Design and Experimental Research of XY Workbenchs Driven by MMCA[J]. China Mechanical Engineering, 2026, 37(8): 1889-1899.
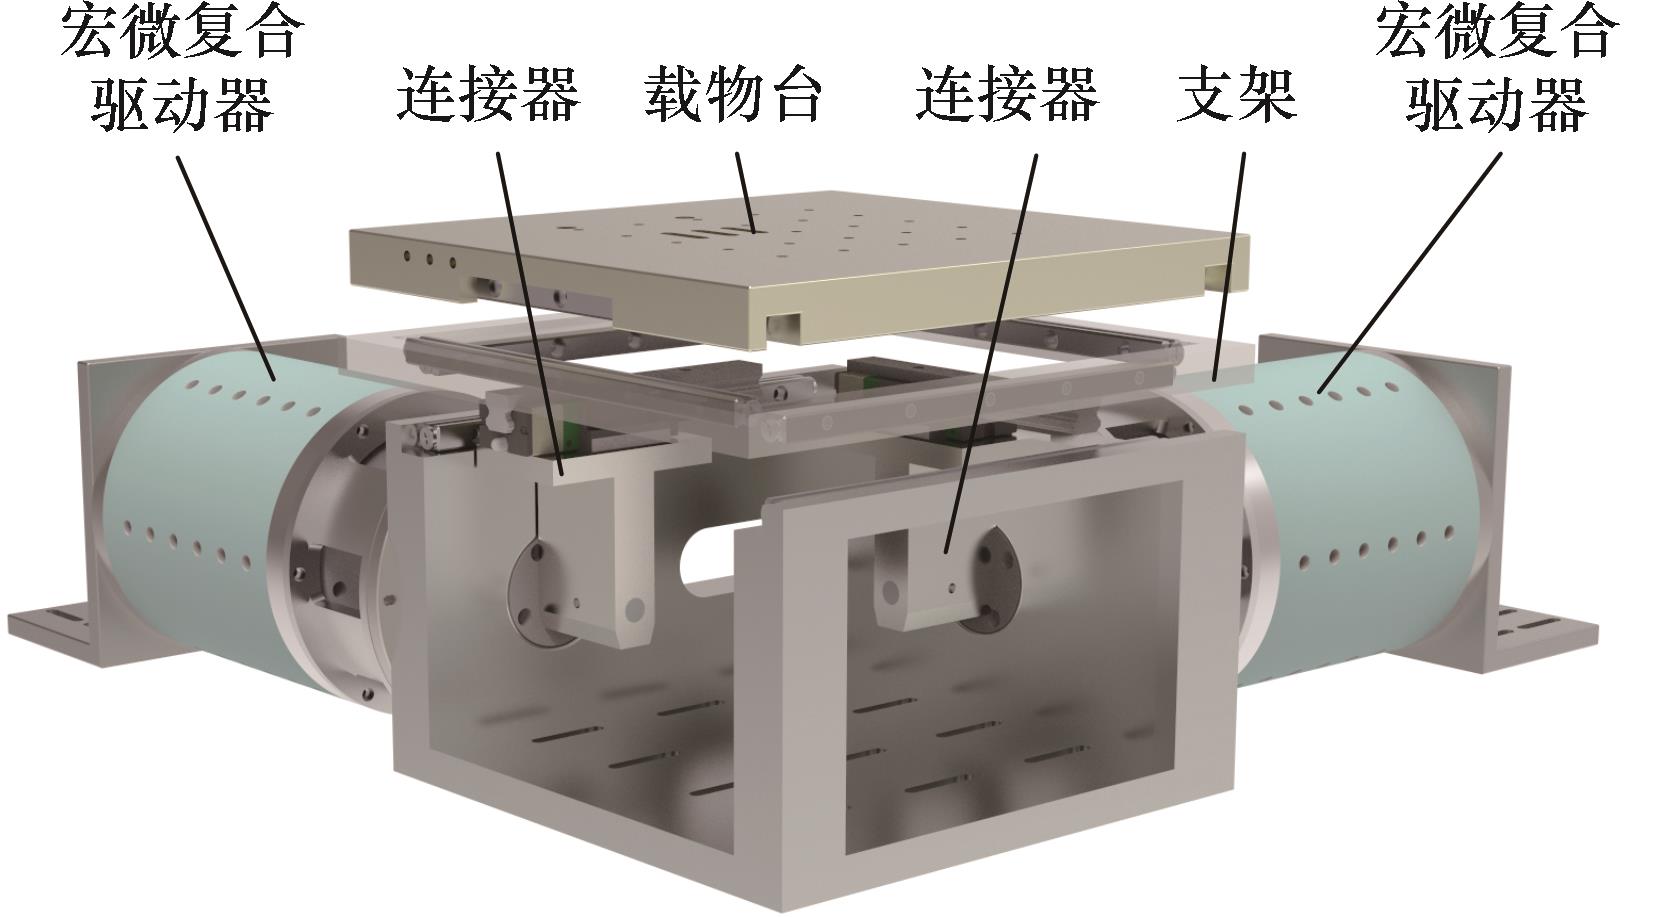
图1 宏微复合驱动XY工作台结构示意图
Fig.1 Schematic diagram of XY worktable driven by macro-micro composite
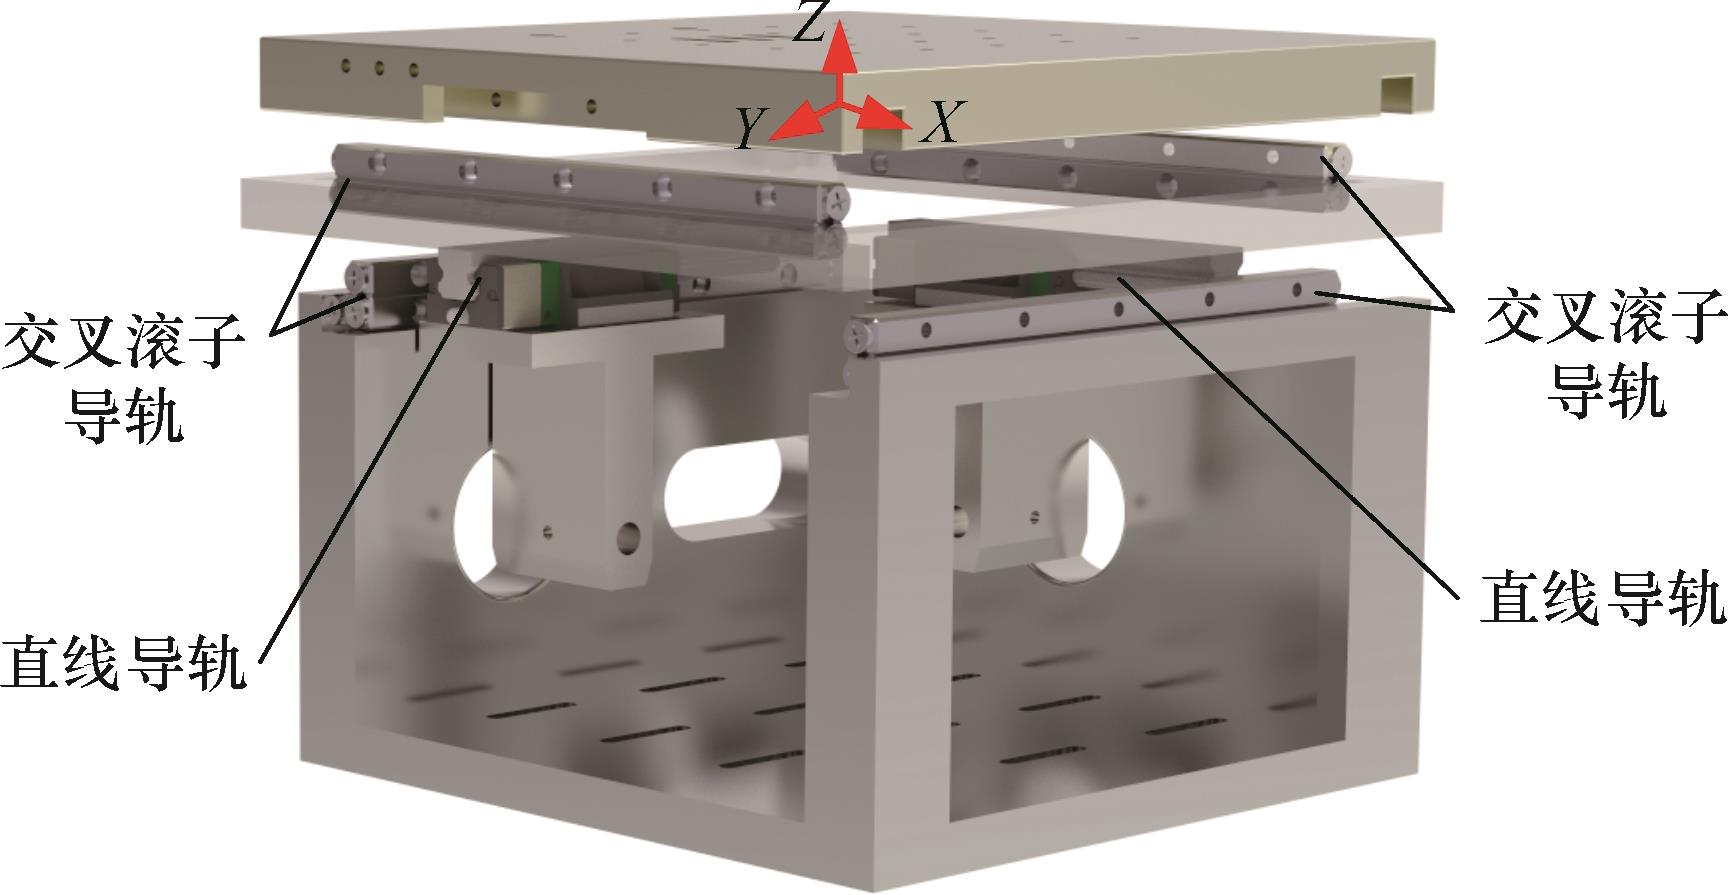
图2 串并联混合解耦导向机构结构示意图
Fig.2 Schematic diagram of the series-parallel hybrid decoupling guidance mechanism structure
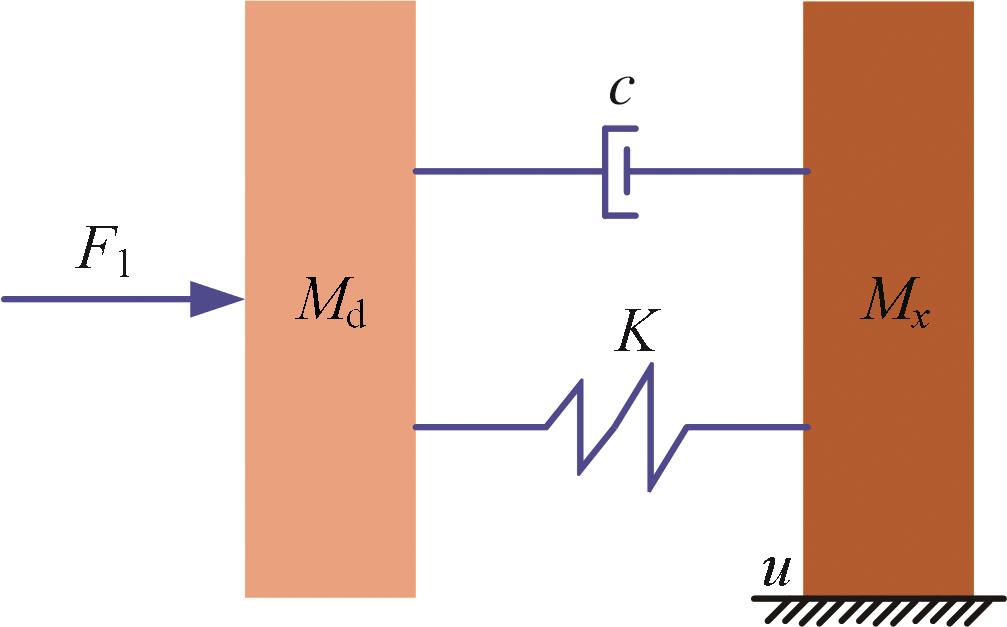
图3 工作台X方向的动力学模型
Fig.3 Dynamic model of the workbench in the X-direction
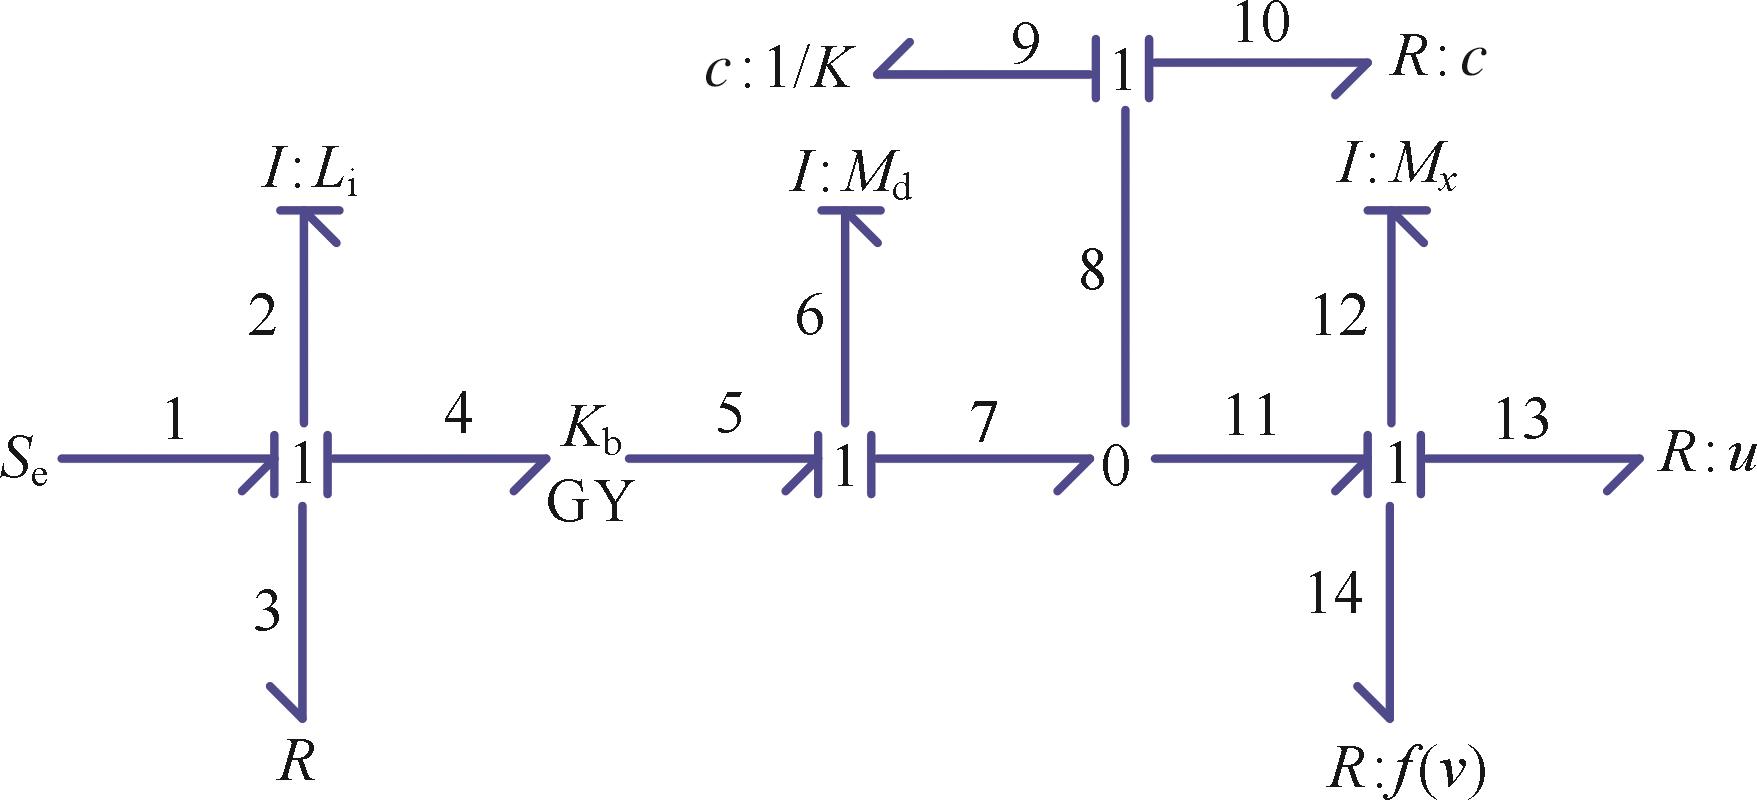
图4 工作台X方向的全局键合图模型
Fig.4 Global bond graph model of the workbench in the X-direction
| 结 | 势变量 | 流变量 |
|---|---|---|
| 1 | e1=e2+e3+e4 | f1=f2=f3=f4 |
| GY | e4=Kb f5, e5=Kb f4 | ⋮ |
| 1 | e5=e6+e7 | f5=f6=f7 |
| 0 | e7=e8=e11 | f7=f8+f11 |
| 1 | e8=e9+e10 | f8=f9=f10 |
| 1 | e11=e12+e13+e14 | f11=f12=f13=f14 |
表1 各结对应的势变量与流变量的关系
Tab.1 Relationship between effort variables and flow variables for each section
| 结 | 势变量 | 流变量 |
|---|---|---|
| 1 | e1=e2+e3+e4 | f1=f2=f3=f4 |
| GY | e4=Kb f5, e5=Kb f4 | ⋮ |
| 1 | e5=e6+e7 | f5=f6=f7 |
| 0 | e7=e8=e11 | f7=f8+f11 |
| 1 | e8=e9+e10 | f8=f9=f10 |
| 1 | e11=e12+e13+e14 | f11=f12=f13=f14 |
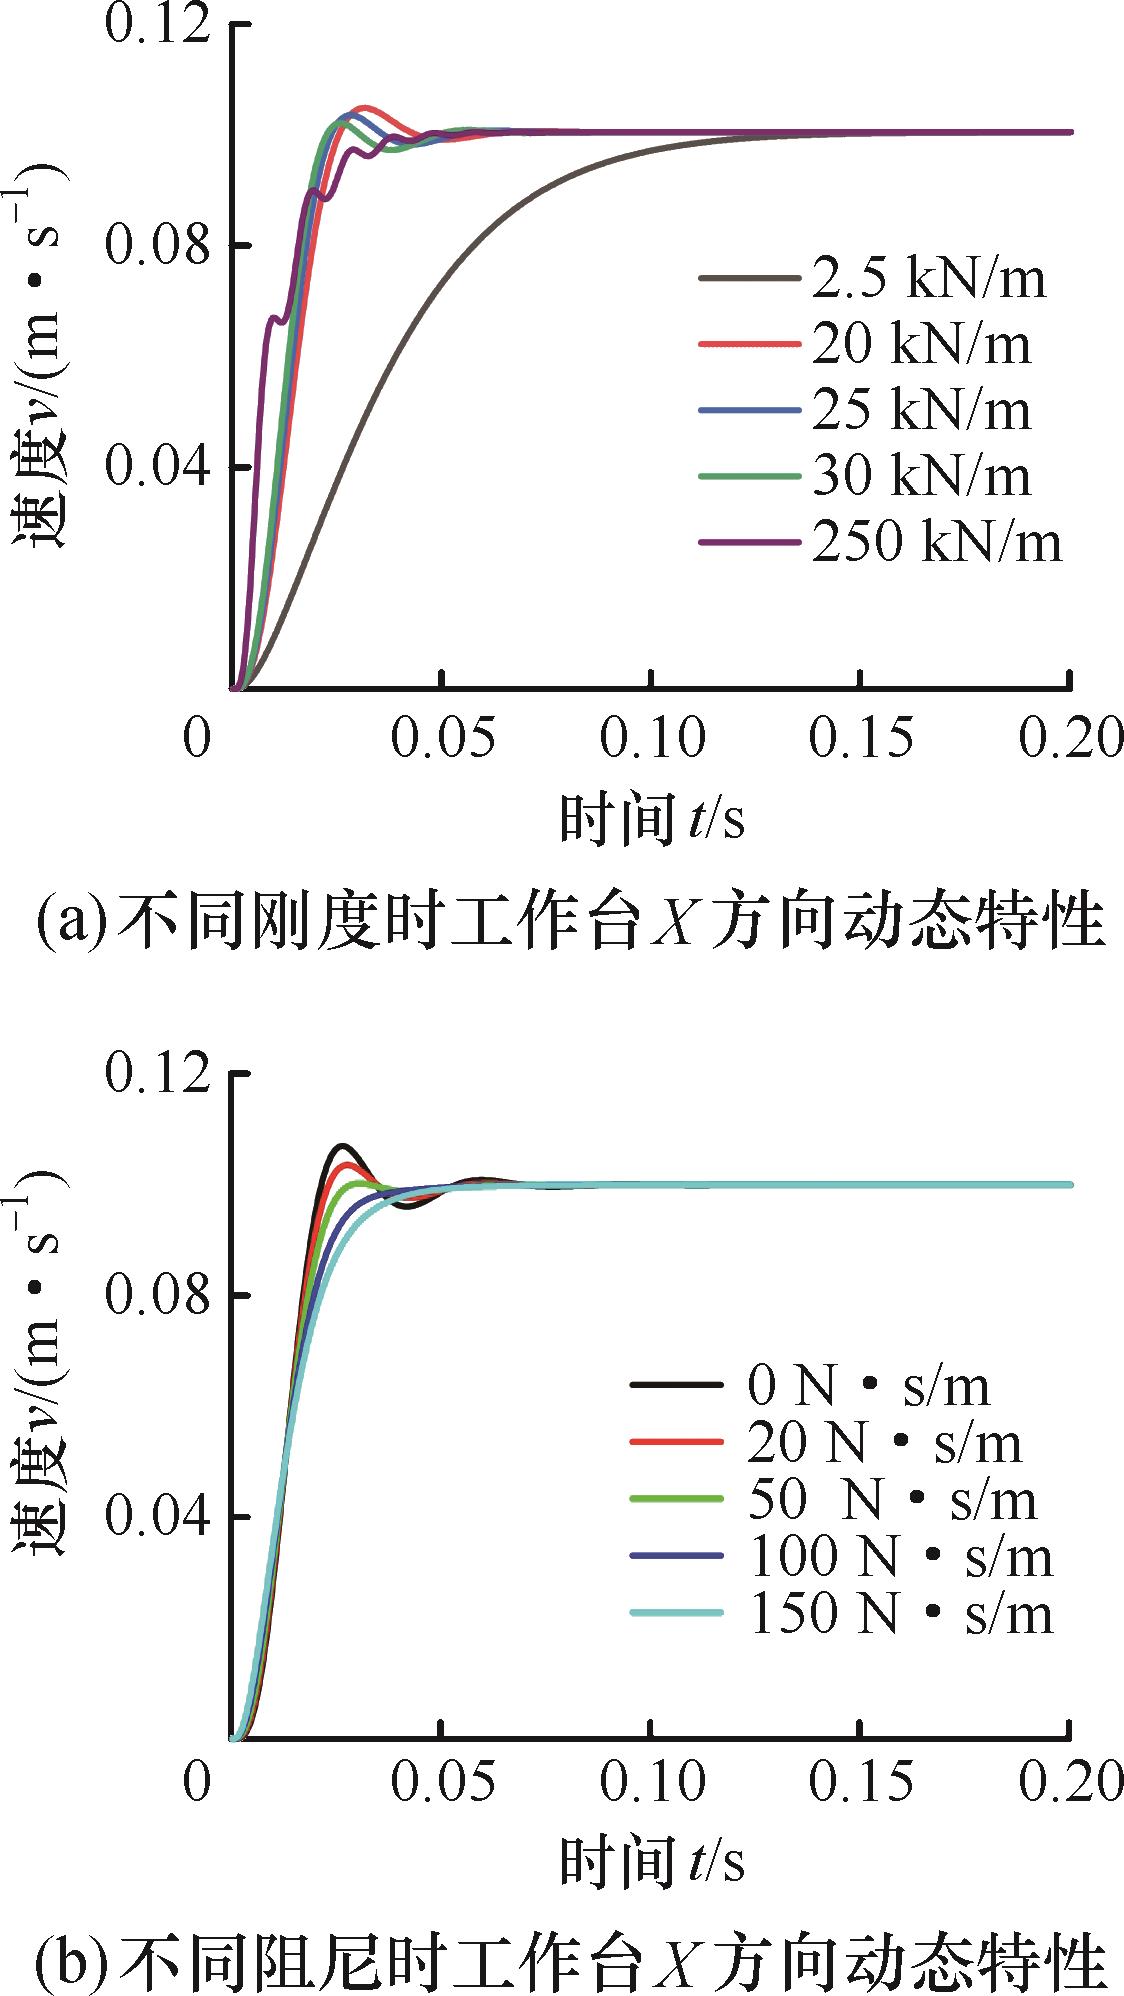
图5 工作台X方向动态特性
Fig.5 Dynamic characteristics of the workbench in the X-direction
| 部件 | 参数 | 值 |
|---|---|---|
| MMCA | 运动部件质量Md/kg | 2 |
| 电感Li/H | 0.017 | |
| 电阻Ri/Ω | 6.7 | |
| 力常数Kb/(N·A | 35.16 | |
| X方向载物台 | 质量MX /kg | 1.5 |
| 黏性摩擦因数μ | 120 |
表2 工作台X方向相关参数
Tab.2 Parameters related to the X-direction of the workbench
| 部件 | 参数 | 值 |
|---|---|---|
| MMCA | 运动部件质量Md/kg | 2 |
| 电感Li/H | 0.017 | |
| 电阻Ri/Ω | 6.7 | |
| 力常数Kb/(N·A | 35.16 | |
| X方向载物台 | 质量MX /kg | 1.5 |
| 黏性摩擦因数μ | 120 |
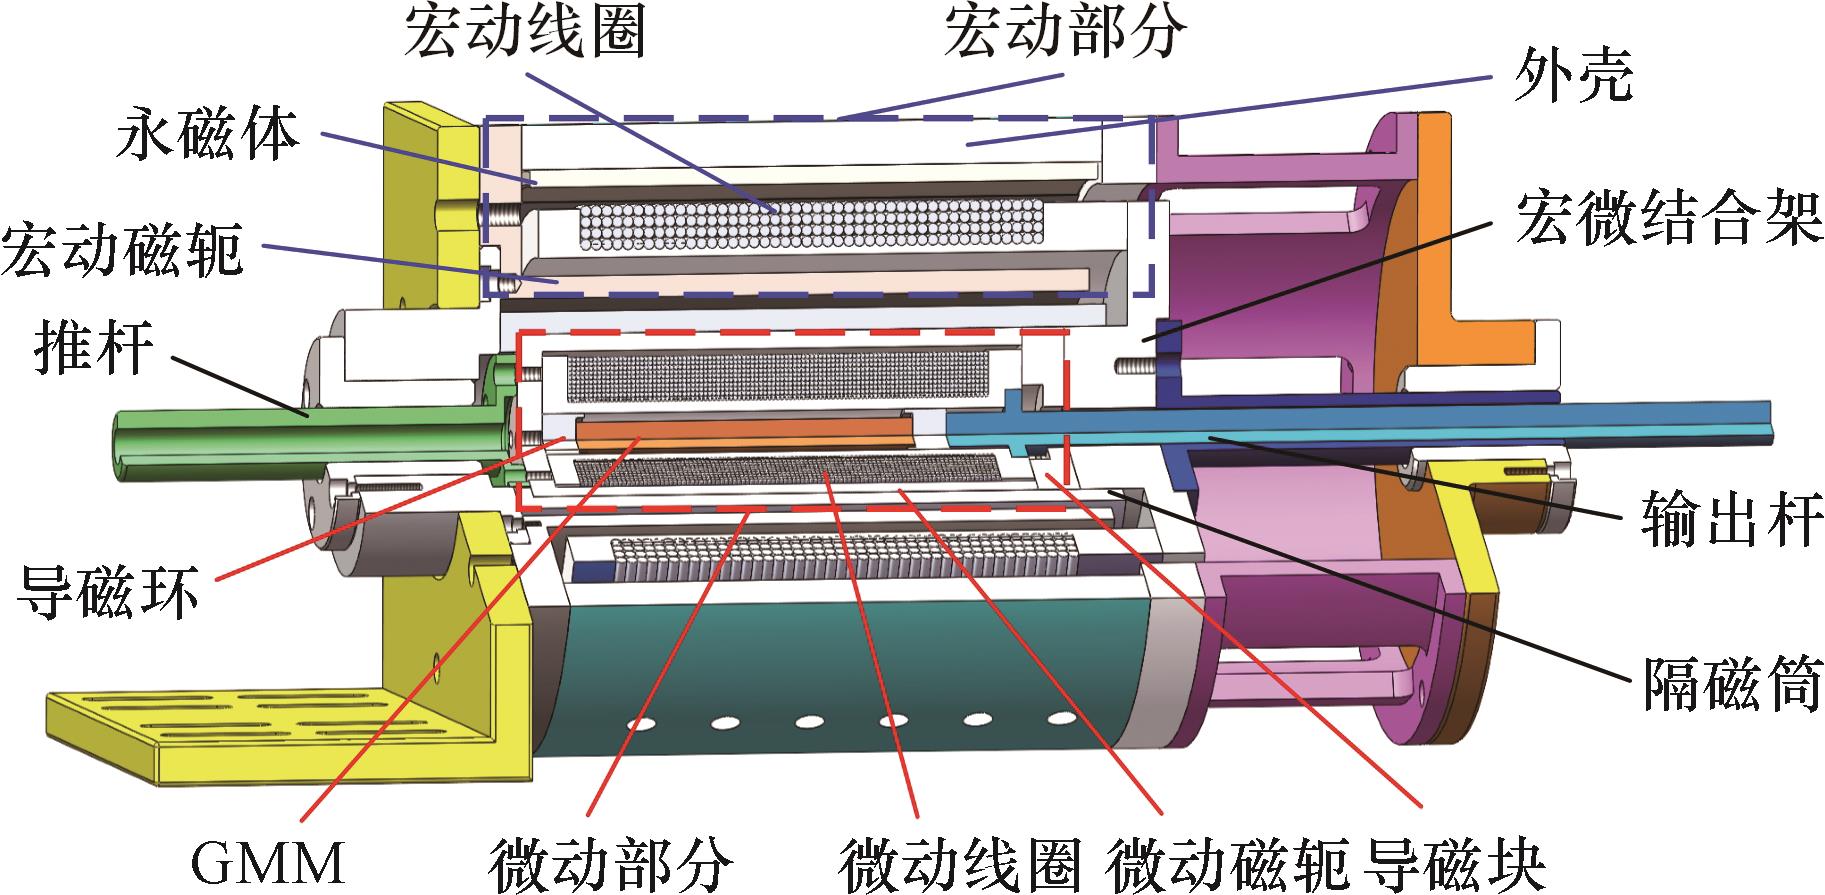
图6 MMCA的结构示意图
Fig6 Schematic diagram of the MMCA structure
| A | B | C | D |
|---|---|---|---|
| 10 | 4 | 5 | 4 |
表3 相关参数的初始值 (mm)
Tab.3 Initial values of related parameters
| A | B | C | D |
|---|---|---|---|
| 10 | 4 | 5 | 4 |
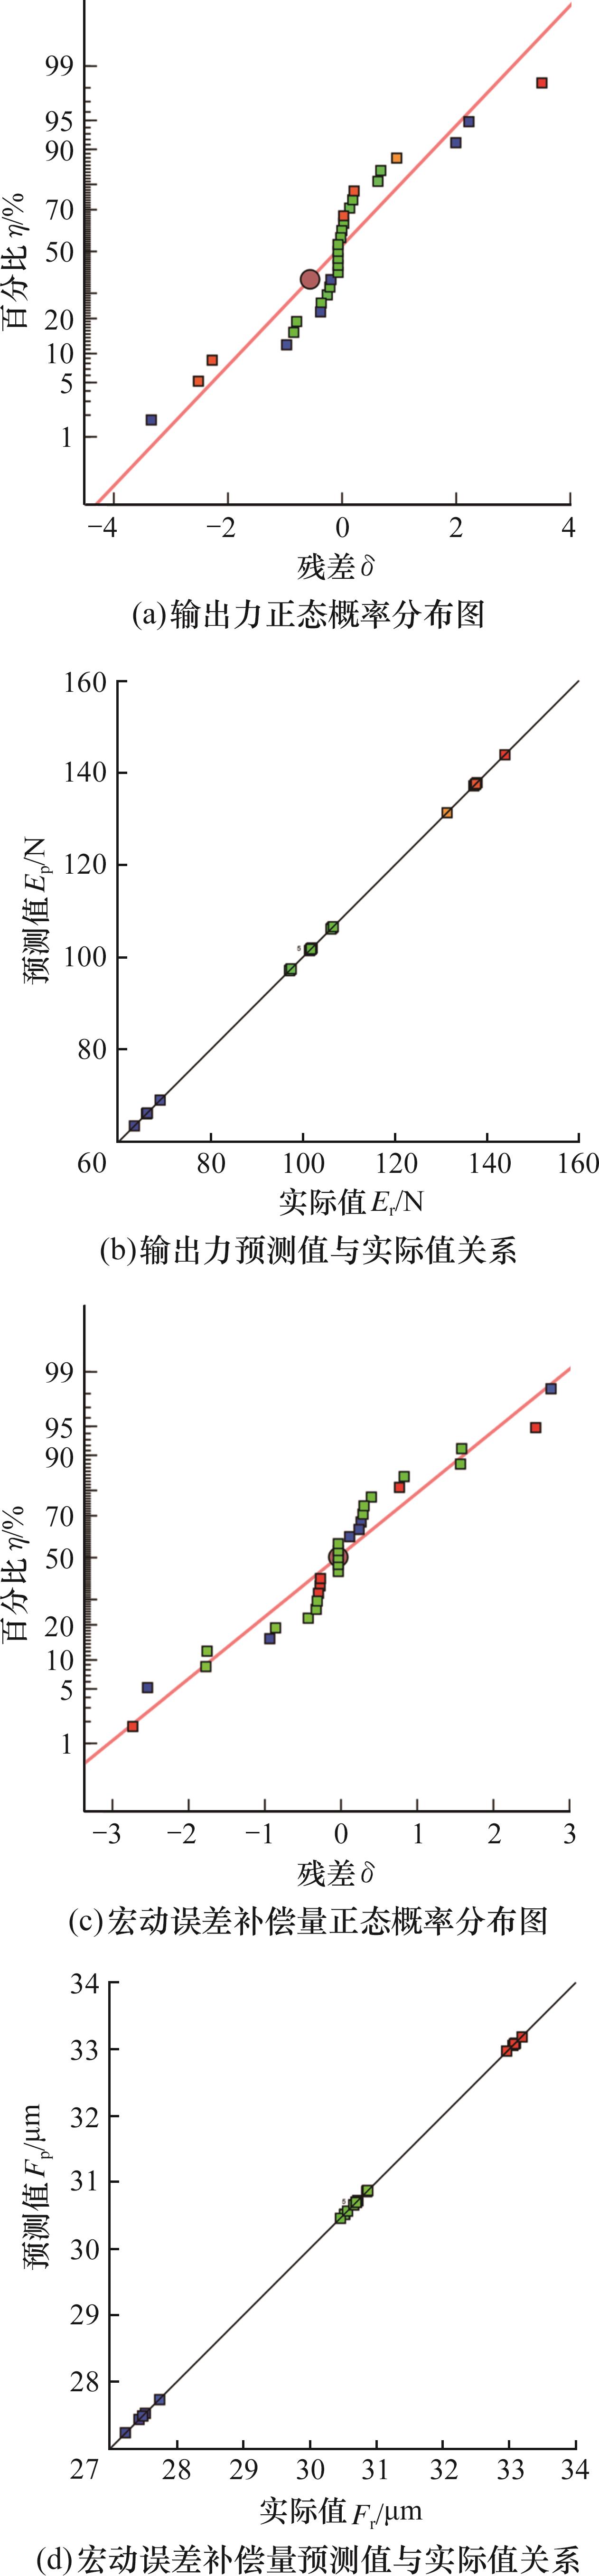
图7 响应面分析图
Fig.7 Response surface analysis plot
| A | B | C | D | E | F | 合意性 | |
|---|---|---|---|---|---|---|---|
| 值 | 9.96 | 5.0 | 5.99 | 5.0 | 143.922 | 33.003 | 0.984 |
| 取整 | 10.0 | 5.0 | 6.0 | 5.0 | |||
| 单位 | mm | mm | mm | mm | N | μm |
表4 Box-Behnke design得出的最优解
Tab.4 Optimal solution derived from Box-Behnken design
| A | B | C | D | E | F | 合意性 | |
|---|---|---|---|---|---|---|---|
| 值 | 9.96 | 5.0 | 5.99 | 5.0 | 143.922 | 33.003 | 0.984 |
| 取整 | 10.0 | 5.0 | 6.0 | 5.0 | |||
| 单位 | mm | mm | mm | mm | N | μm |
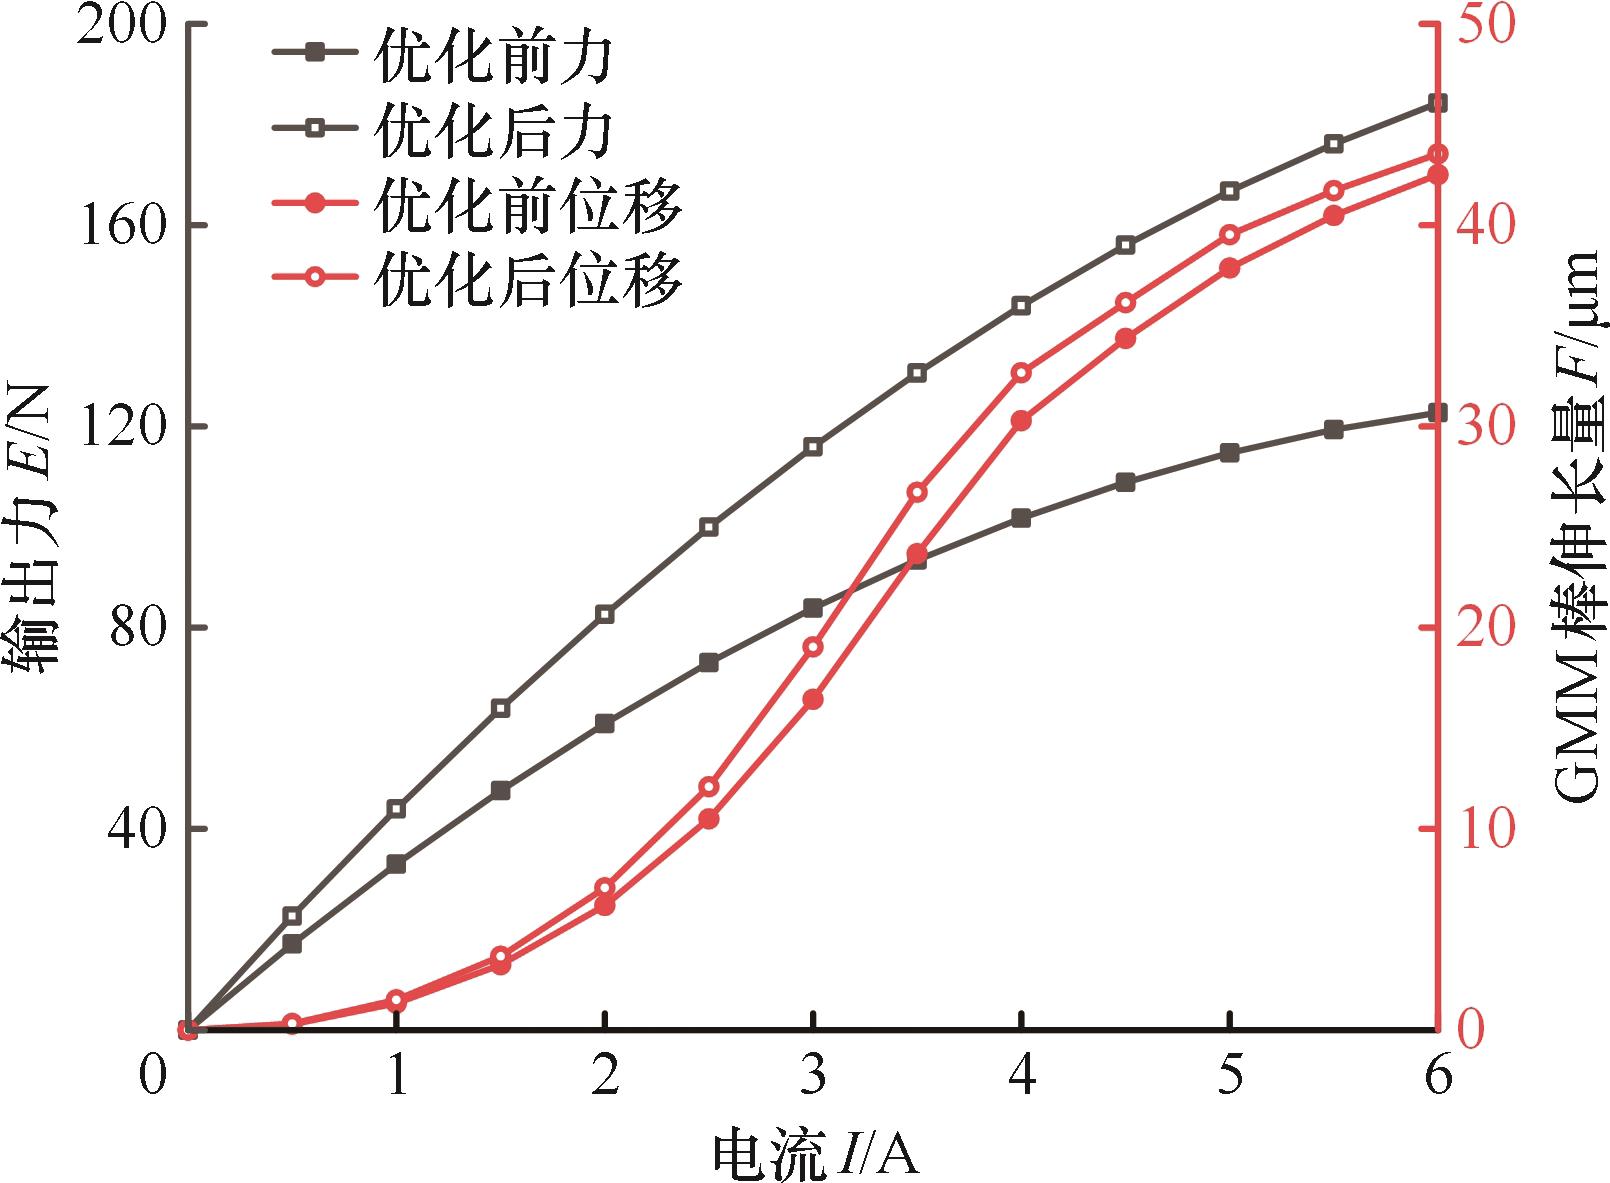
图8 优化前后MMCA性能的对比
Fig.8 Comparison of MMCA performance before and after optimization
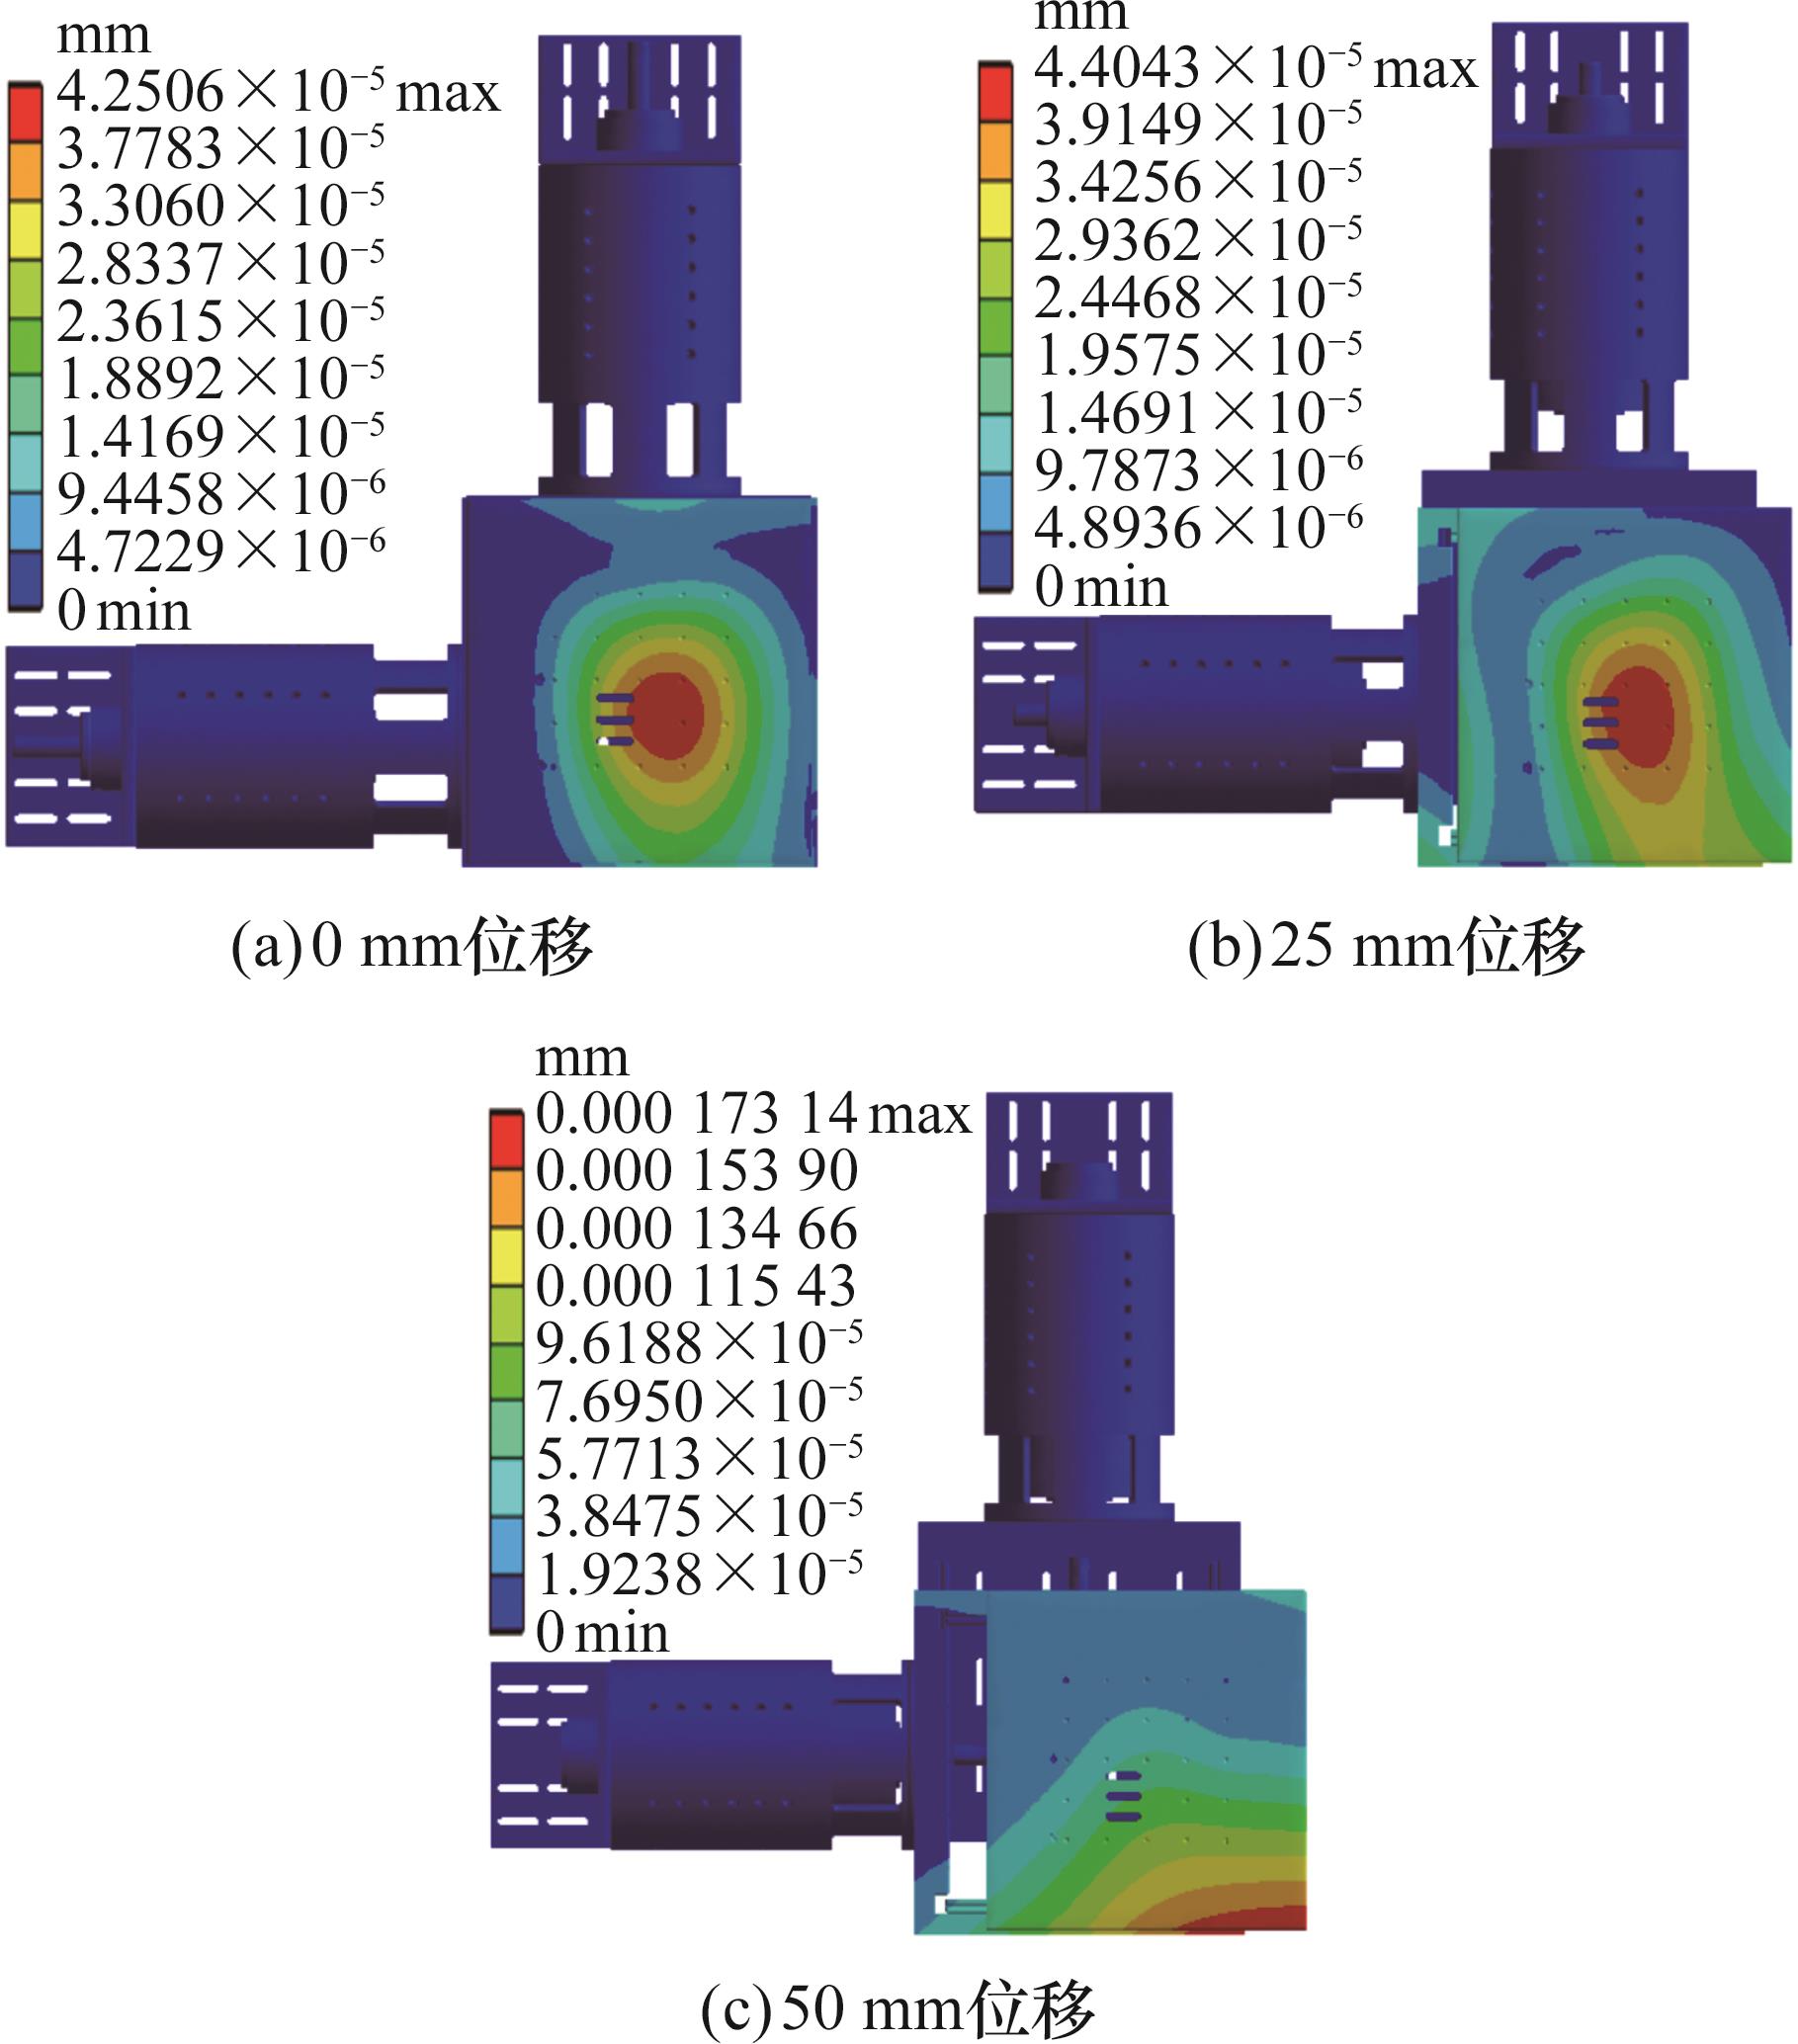
图9 XY工作台在50 N负载下不同位移时的变形
Fig.9 Deformation of the XY workbench under a 50 N load at different displacements
| 负载 | 0 mm位移 | 25 mm位移 | 50 mm位移 | |||
|---|---|---|---|---|---|---|
| X/mm | Y/mm | X/mm | Y/mm | X/mm | Y/mm | |
| 50 N | 5.48×10⁶ | 3.91×10⁶ | 8.63×10⁶ | 8.38×10⁶ | 1.26×10⁵ | 1.11×10⁵ |
| 100 N | 1.09×10⁵ | 7.81×10⁶ | 1.72×10⁵ | 1.68×10⁵ | 2.52×10⁵ | 2.21×10⁵ |
| 150 N | 1.65×10⁵ | 1.17×10⁵ | 2.59×10⁵ | 2.51×10⁵ | 3.78×10⁵ | 3.32×10⁵ |
| 200 N | 2.19×10⁵ | 1.56×10⁵ | 3.45×10⁵ | 3.35×10⁵ | 5.04×10⁵ | 4.42×10⁵ |
| 250 N | 2.74×10⁵ | 1.95×10⁵ | 4.31×10⁵ | 4.19×10⁵ | 6.29×10⁵ | 5.23×10⁵ |
表5 工作台在不同负载下产生位移时的变形
Tab.5 Deformation of the worktable under different loads during displacement
| 负载 | 0 mm位移 | 25 mm位移 | 50 mm位移 | |||
|---|---|---|---|---|---|---|
| X/mm | Y/mm | X/mm | Y/mm | X/mm | Y/mm | |
| 50 N | 5.48×10⁶ | 3.91×10⁶ | 8.63×10⁶ | 8.38×10⁶ | 1.26×10⁵ | 1.11×10⁵ |
| 100 N | 1.09×10⁵ | 7.81×10⁶ | 1.72×10⁵ | 1.68×10⁵ | 2.52×10⁵ | 2.21×10⁵ |
| 150 N | 1.65×10⁵ | 1.17×10⁵ | 2.59×10⁵ | 2.51×10⁵ | 3.78×10⁵ | 3.32×10⁵ |
| 200 N | 2.19×10⁵ | 1.56×10⁵ | 3.45×10⁵ | 3.35×10⁵ | 5.04×10⁵ | 4.42×10⁵ |
| 250 N | 2.74×10⁵ | 1.95×10⁵ | 4.31×10⁵ | 4.19×10⁵ | 6.29×10⁵ | 5.23×10⁵ |
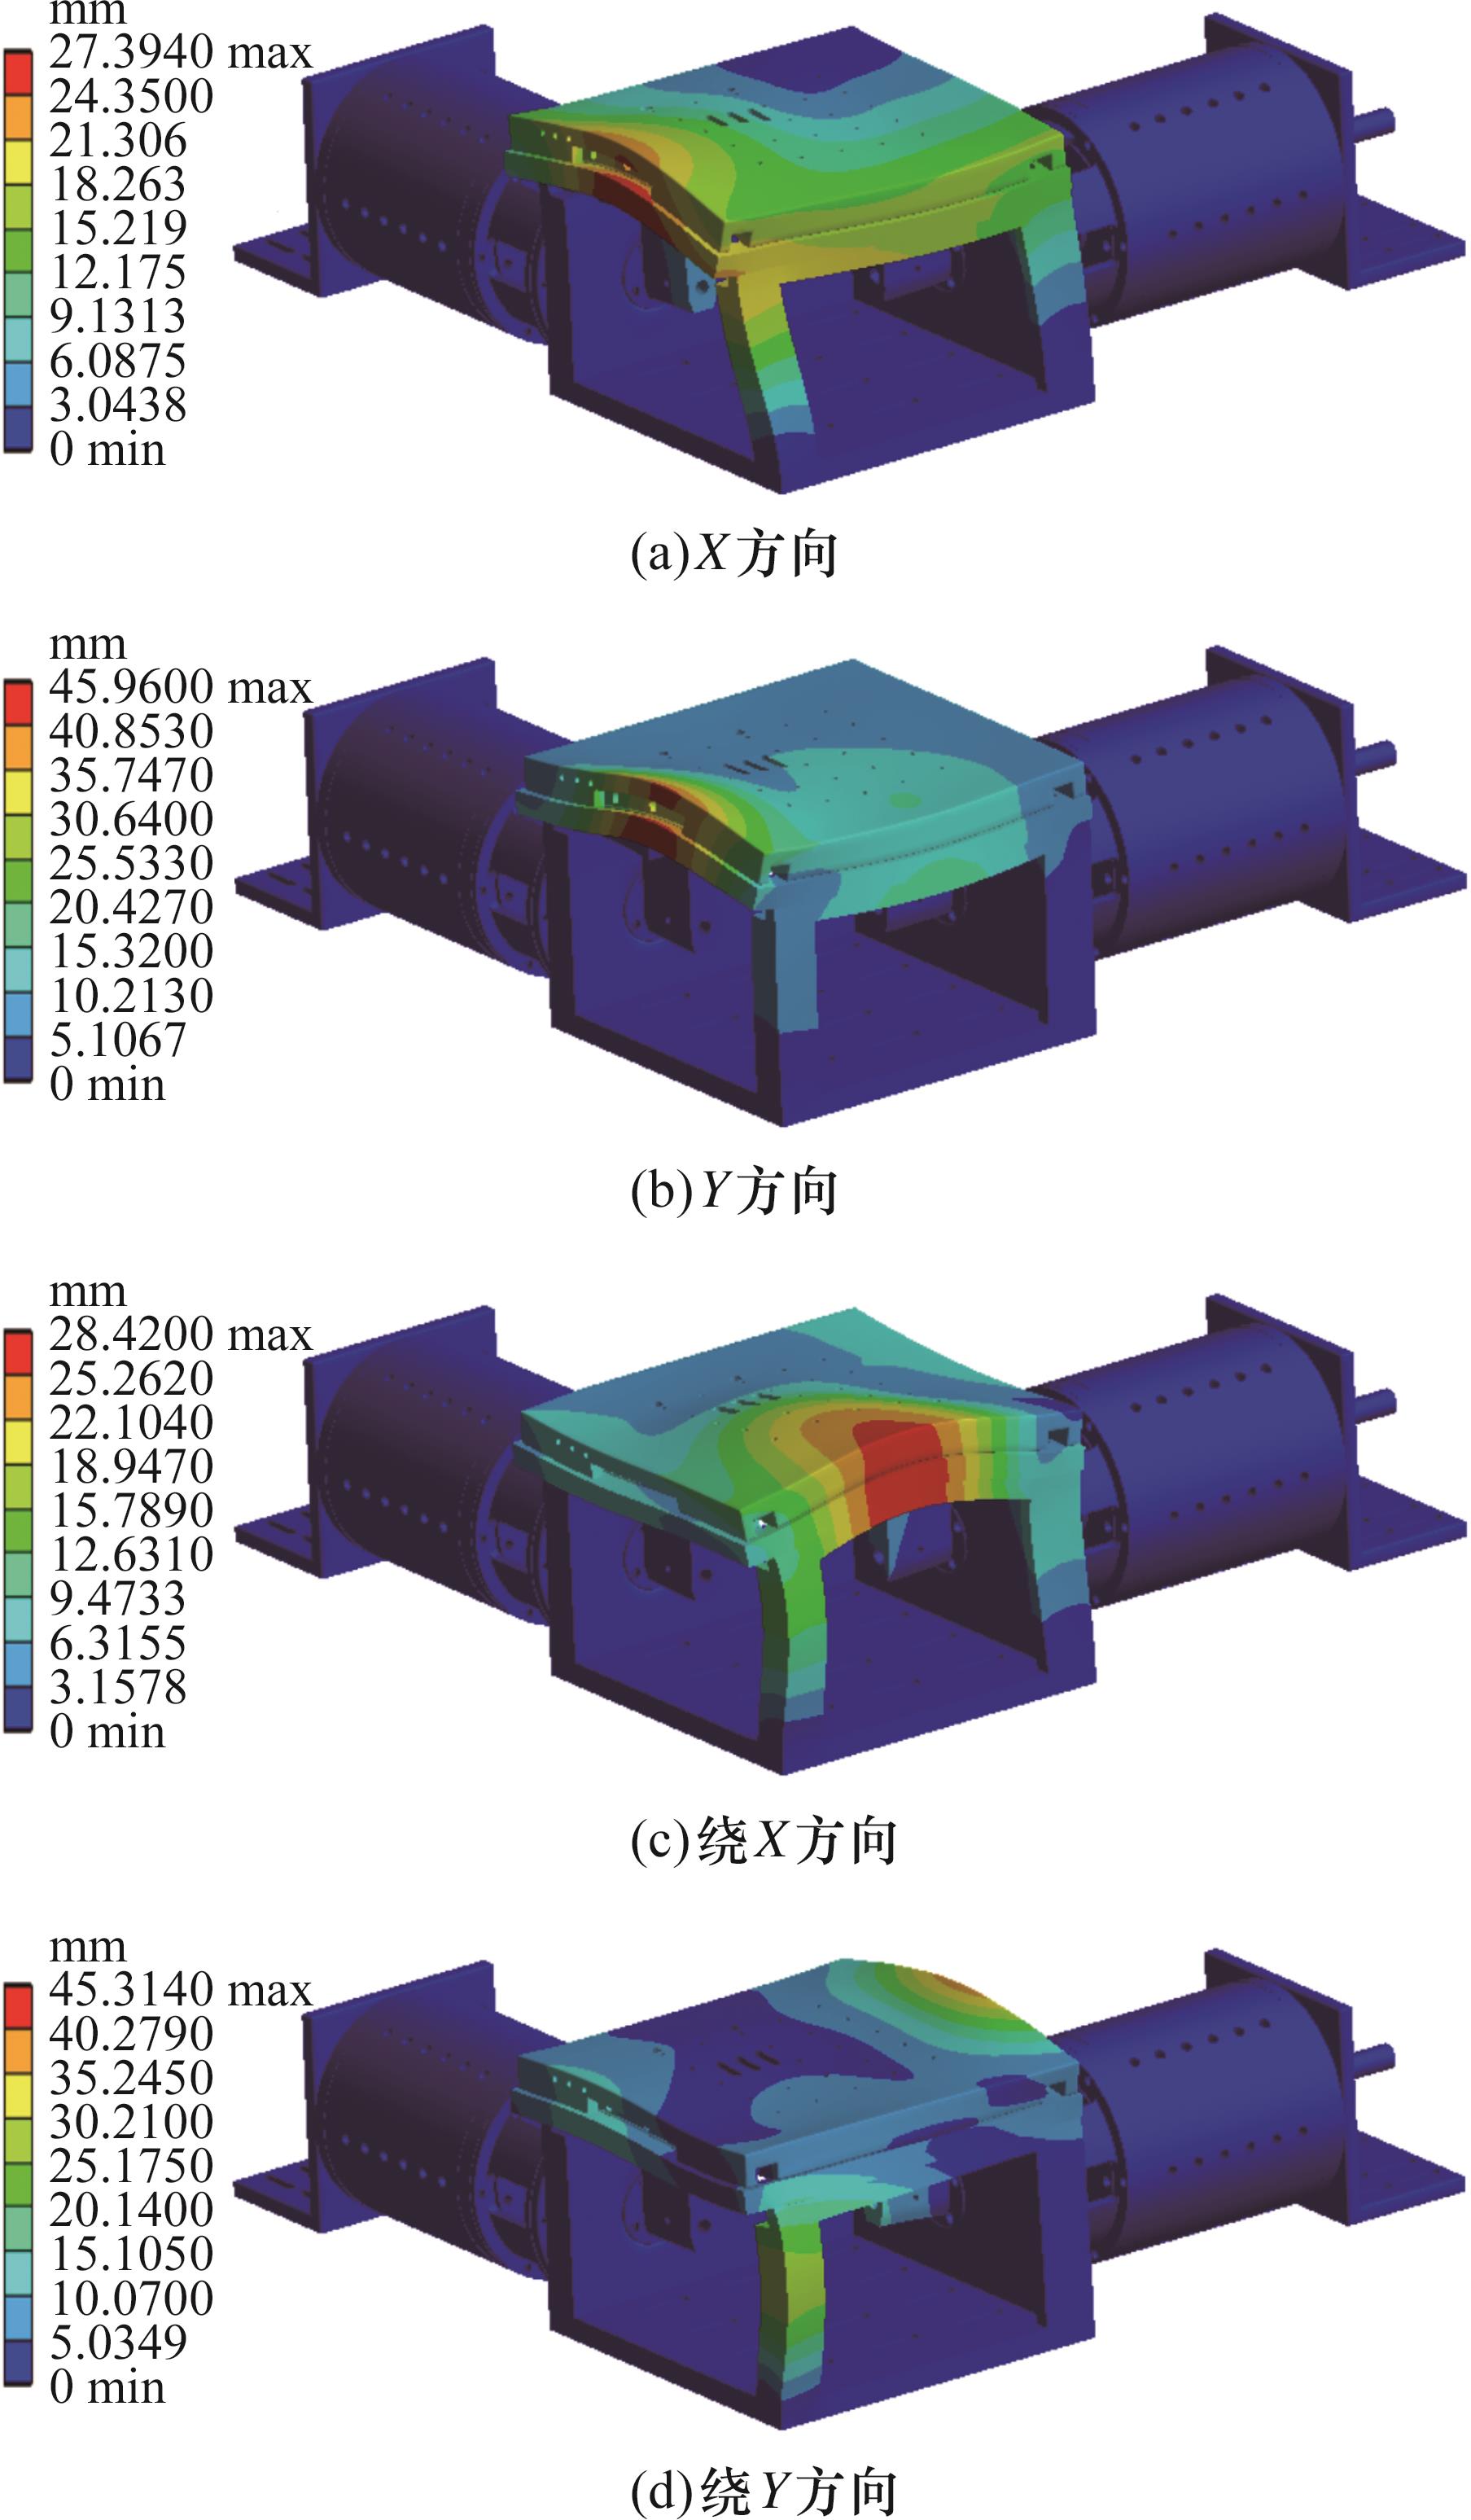
图10 宏微复合驱动XY工作台四种模态振型
Fig.10 Four modal vibration modes of XY workbench driven by macro-micro composite
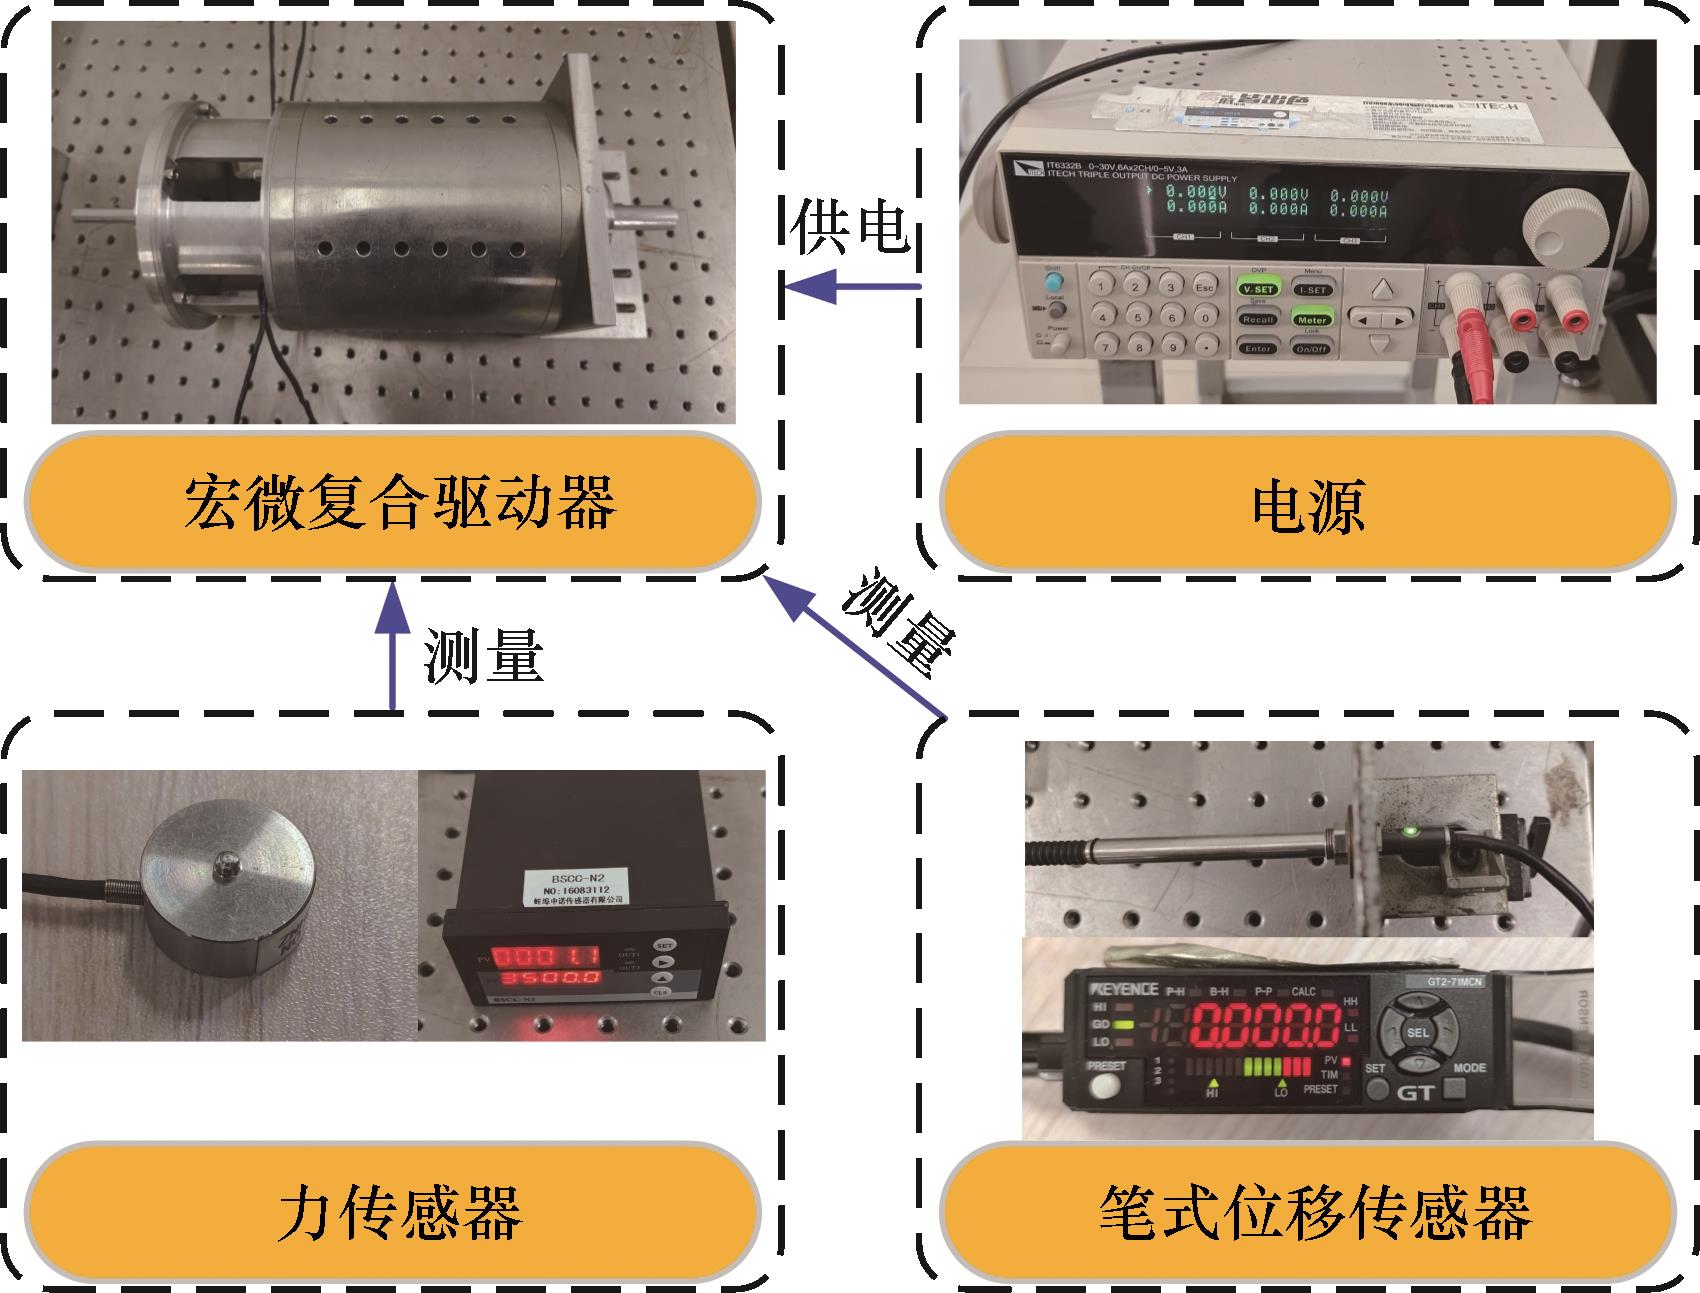
图11 MMCA输出力测试平台
Fig.11 MMCA output force testing platform
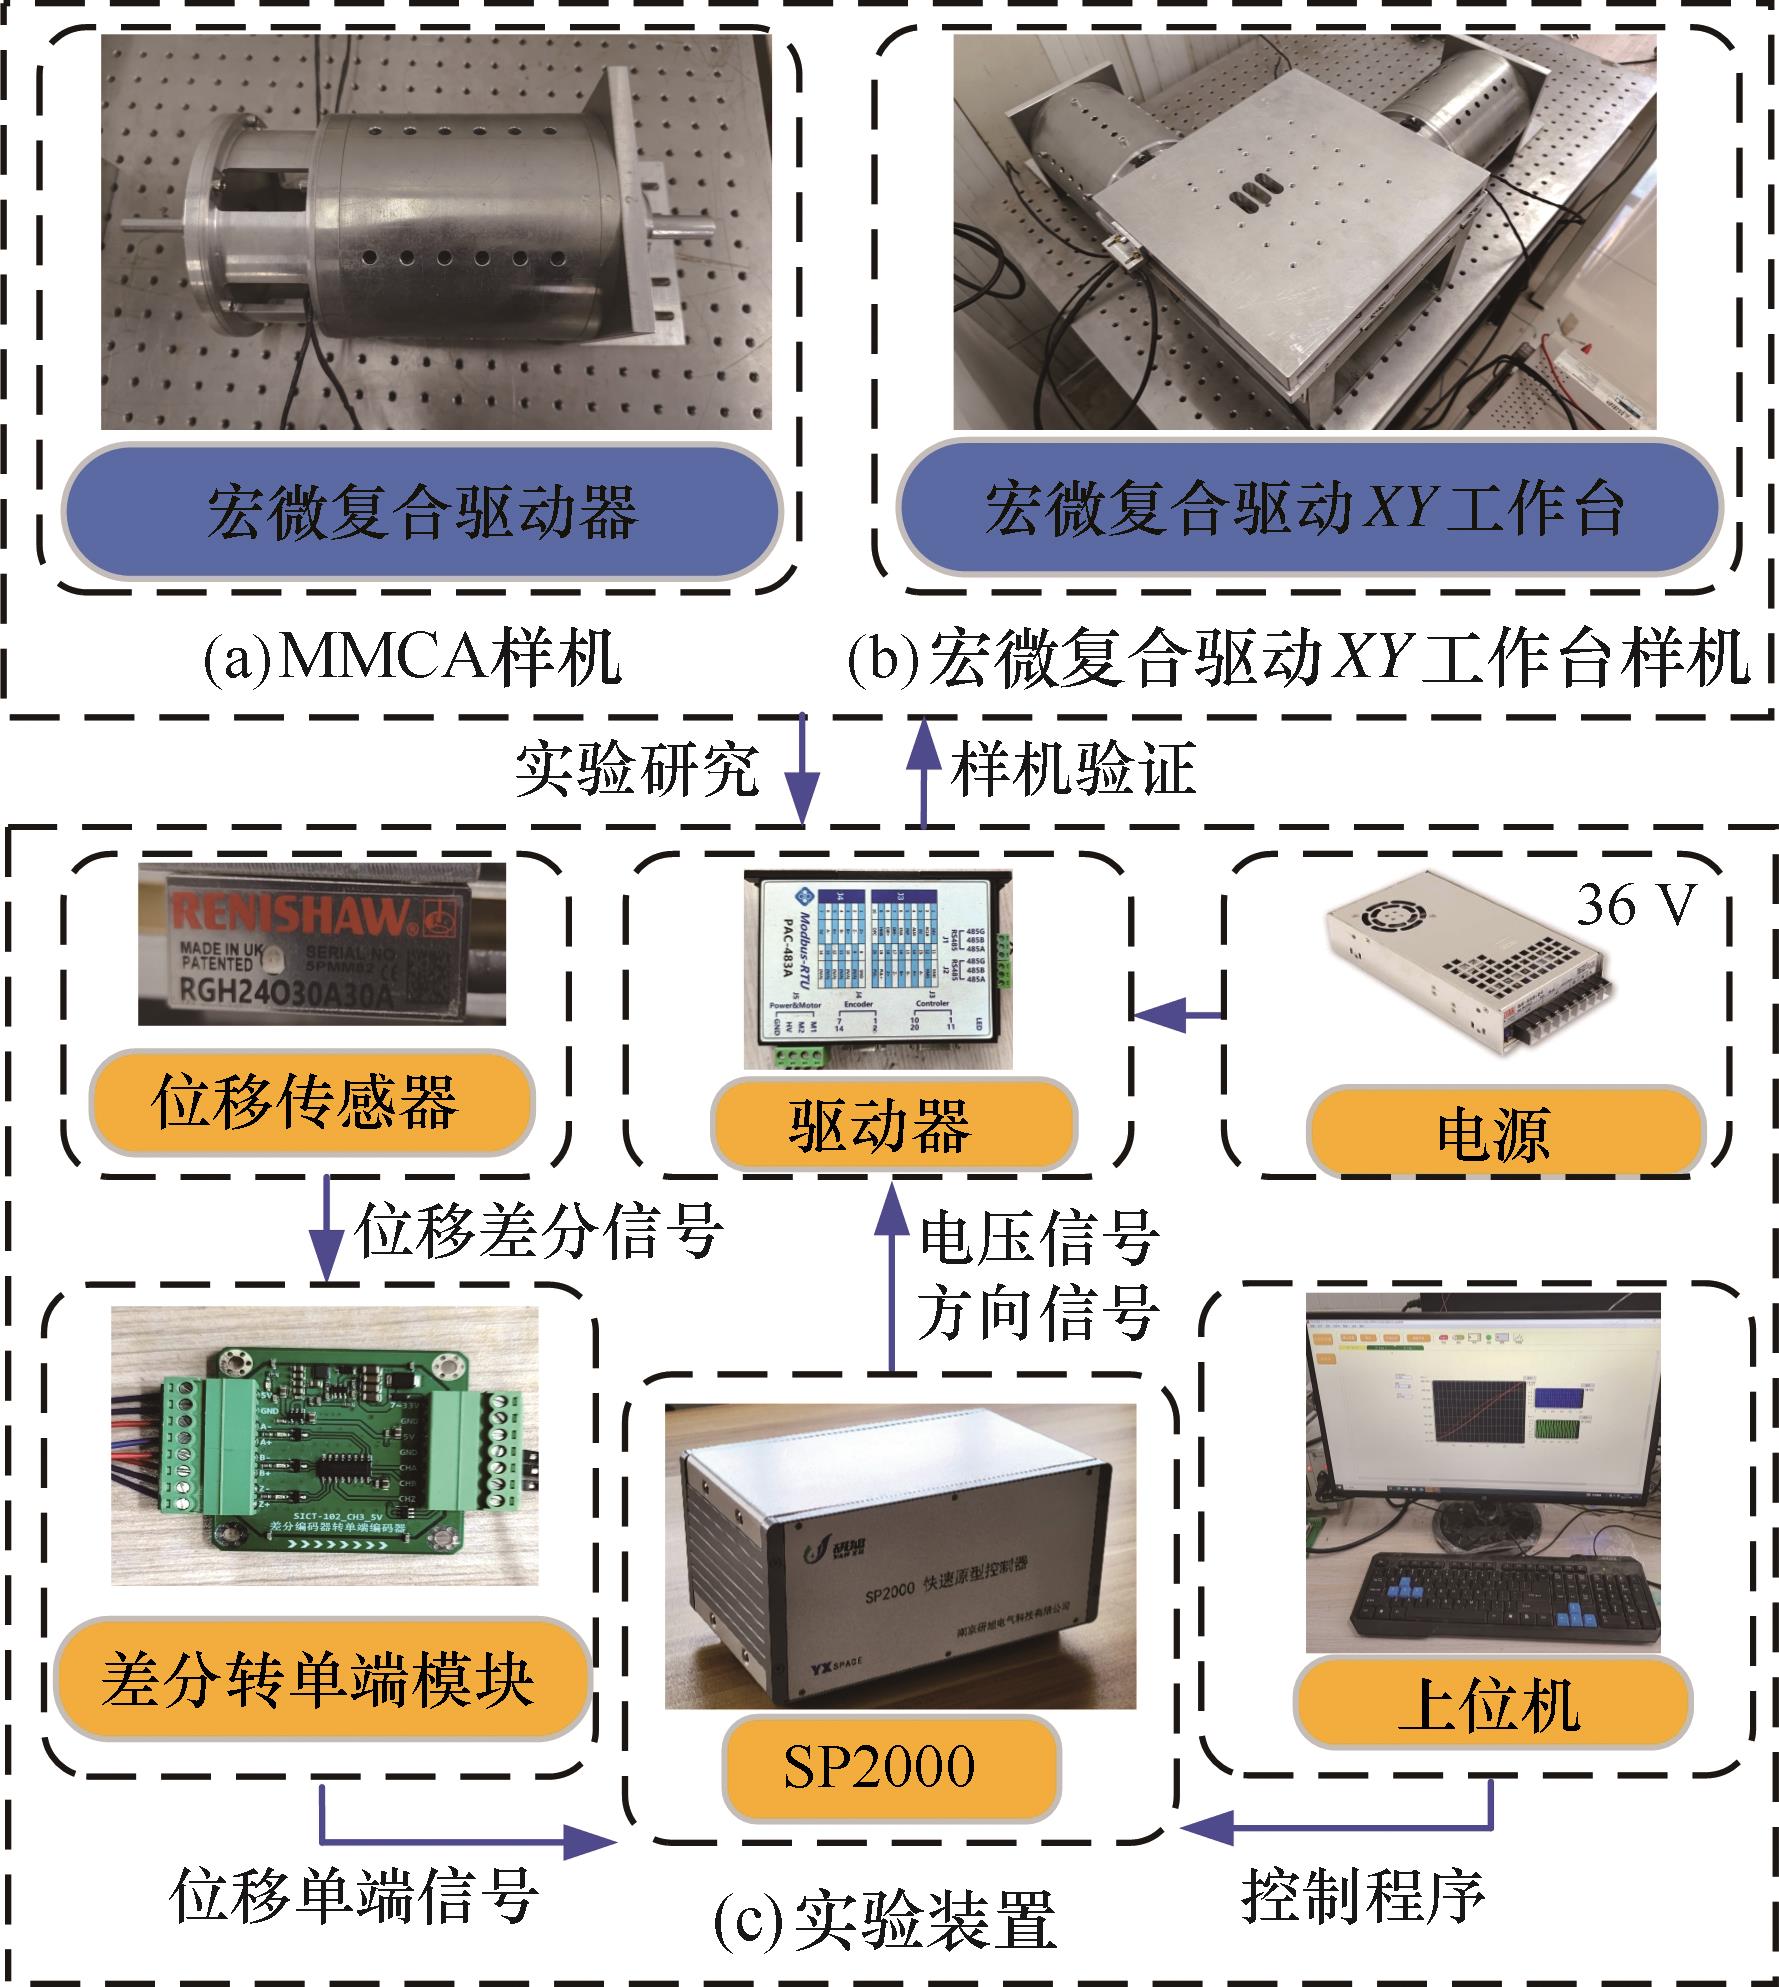
图12 样机和实验装置
Fig.12 Prototype and experimental setup
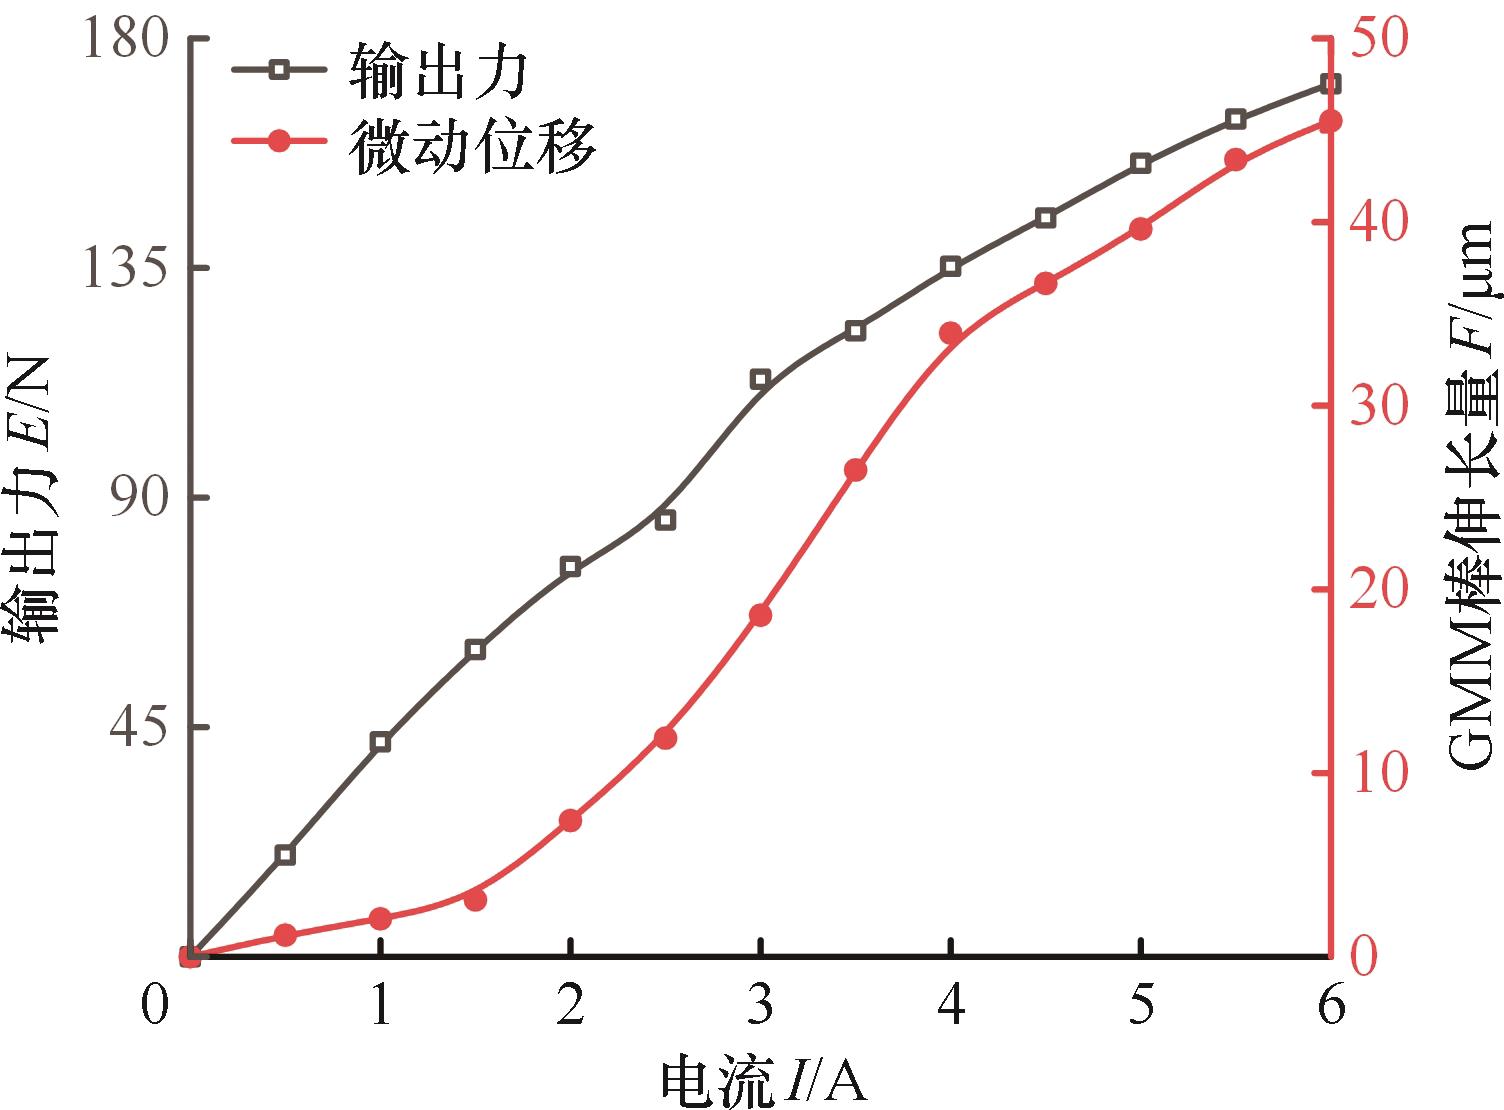
图13 MMCA的优化结果测试
Fig.13 Optimization result testing of the MMCA
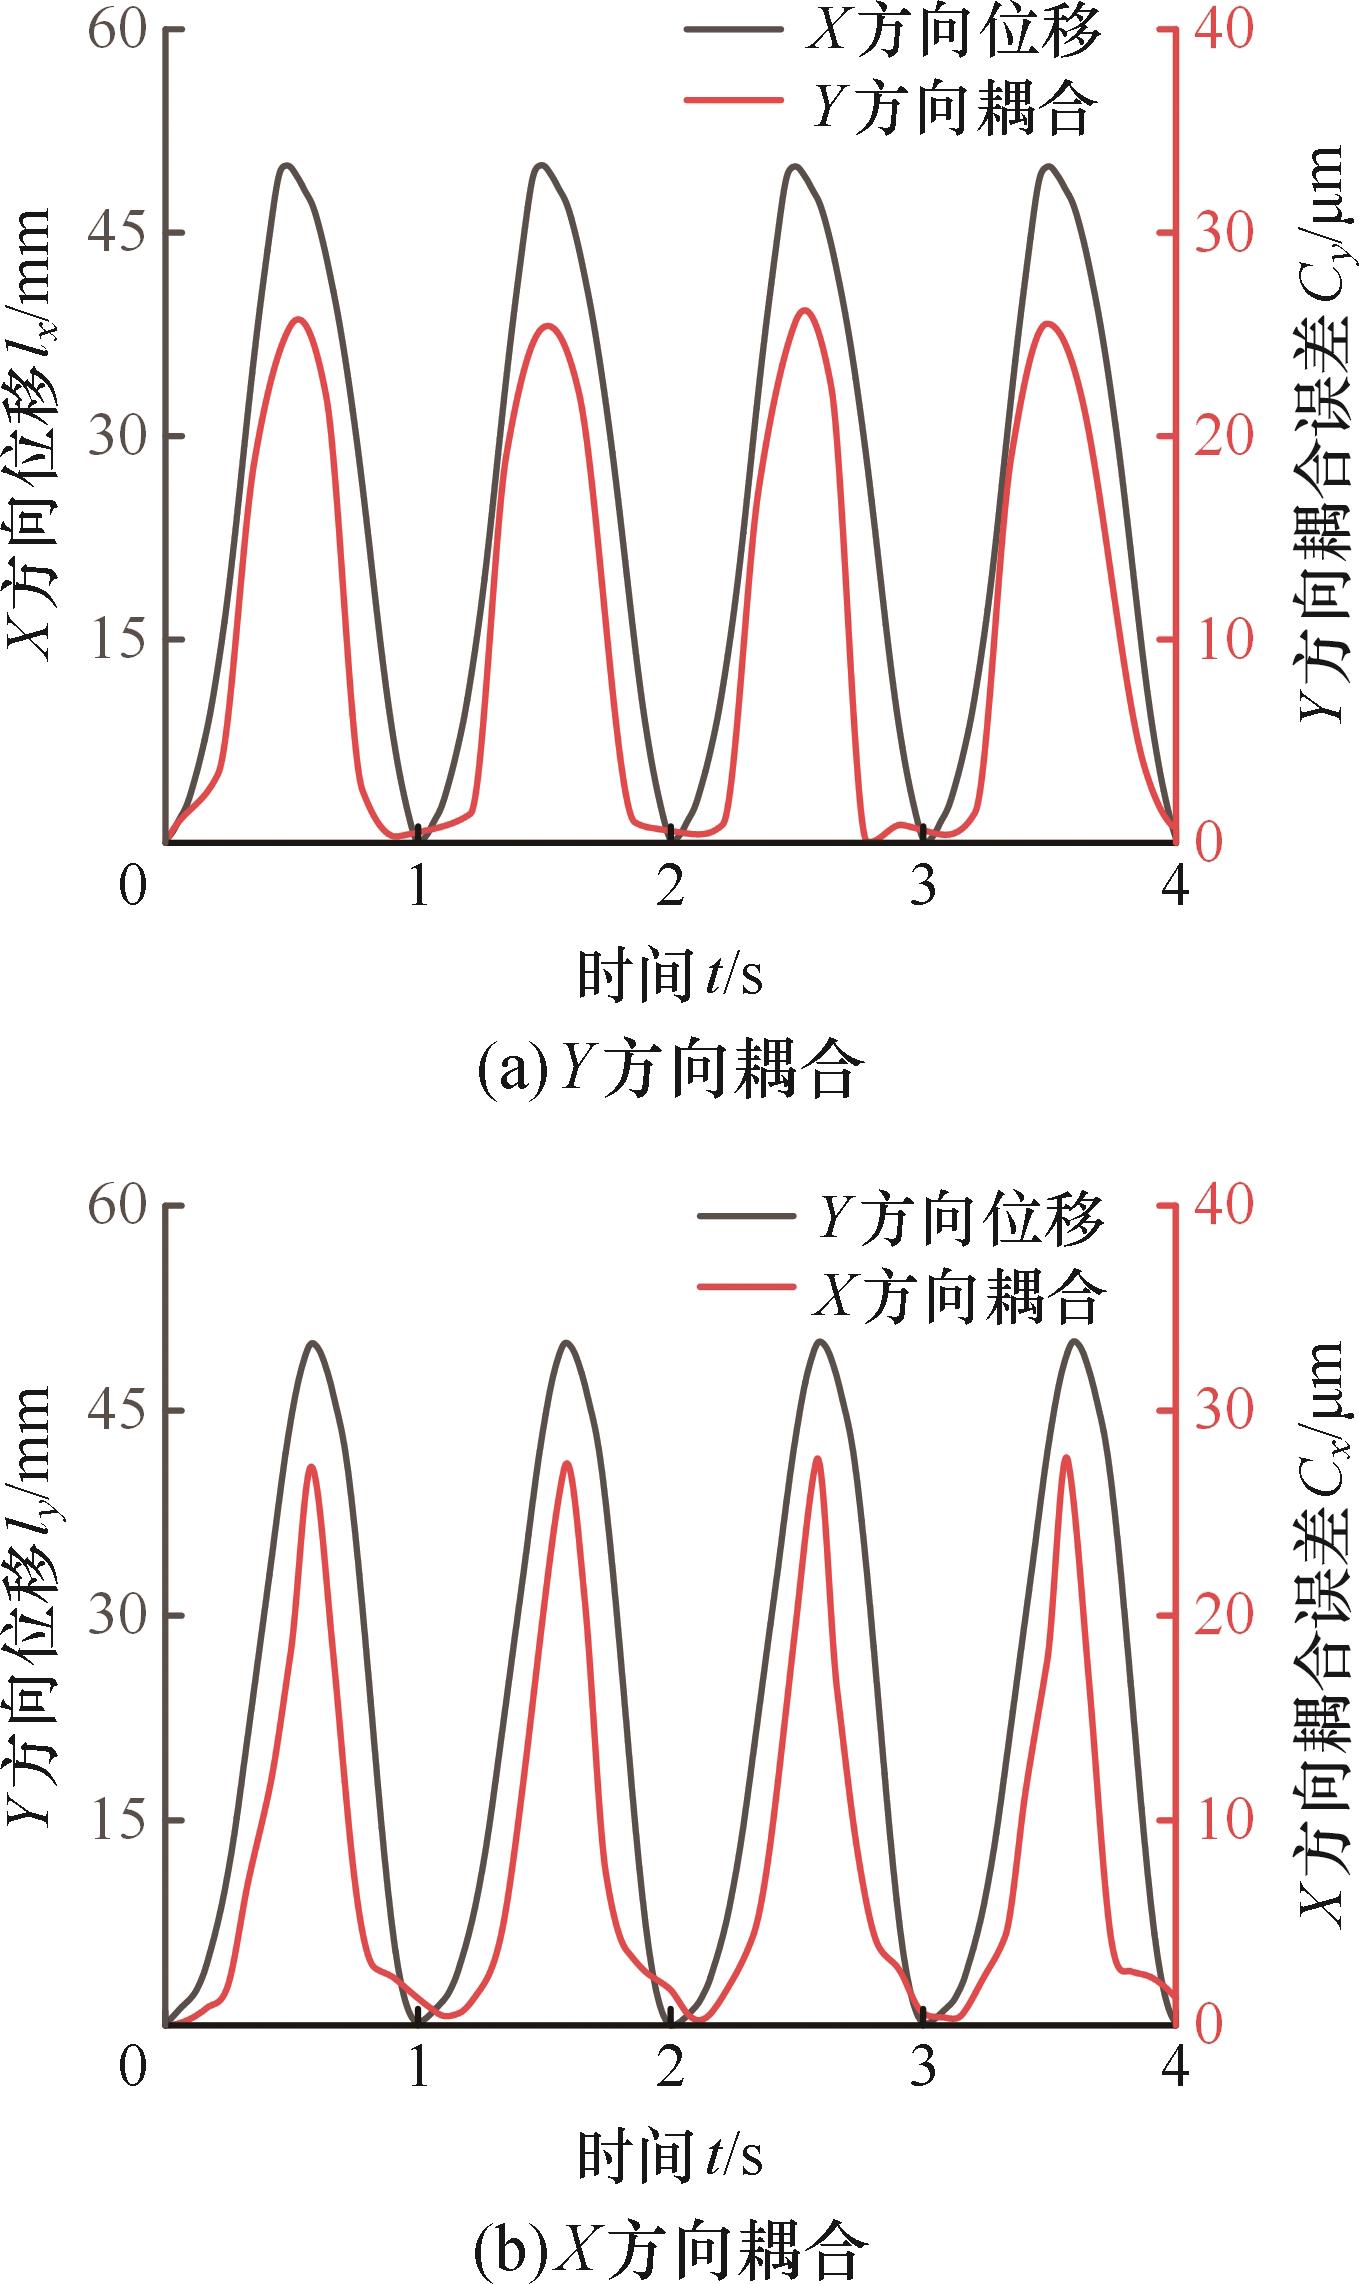
图14 位移耦合测试
Fig.14 Displacement coupling test
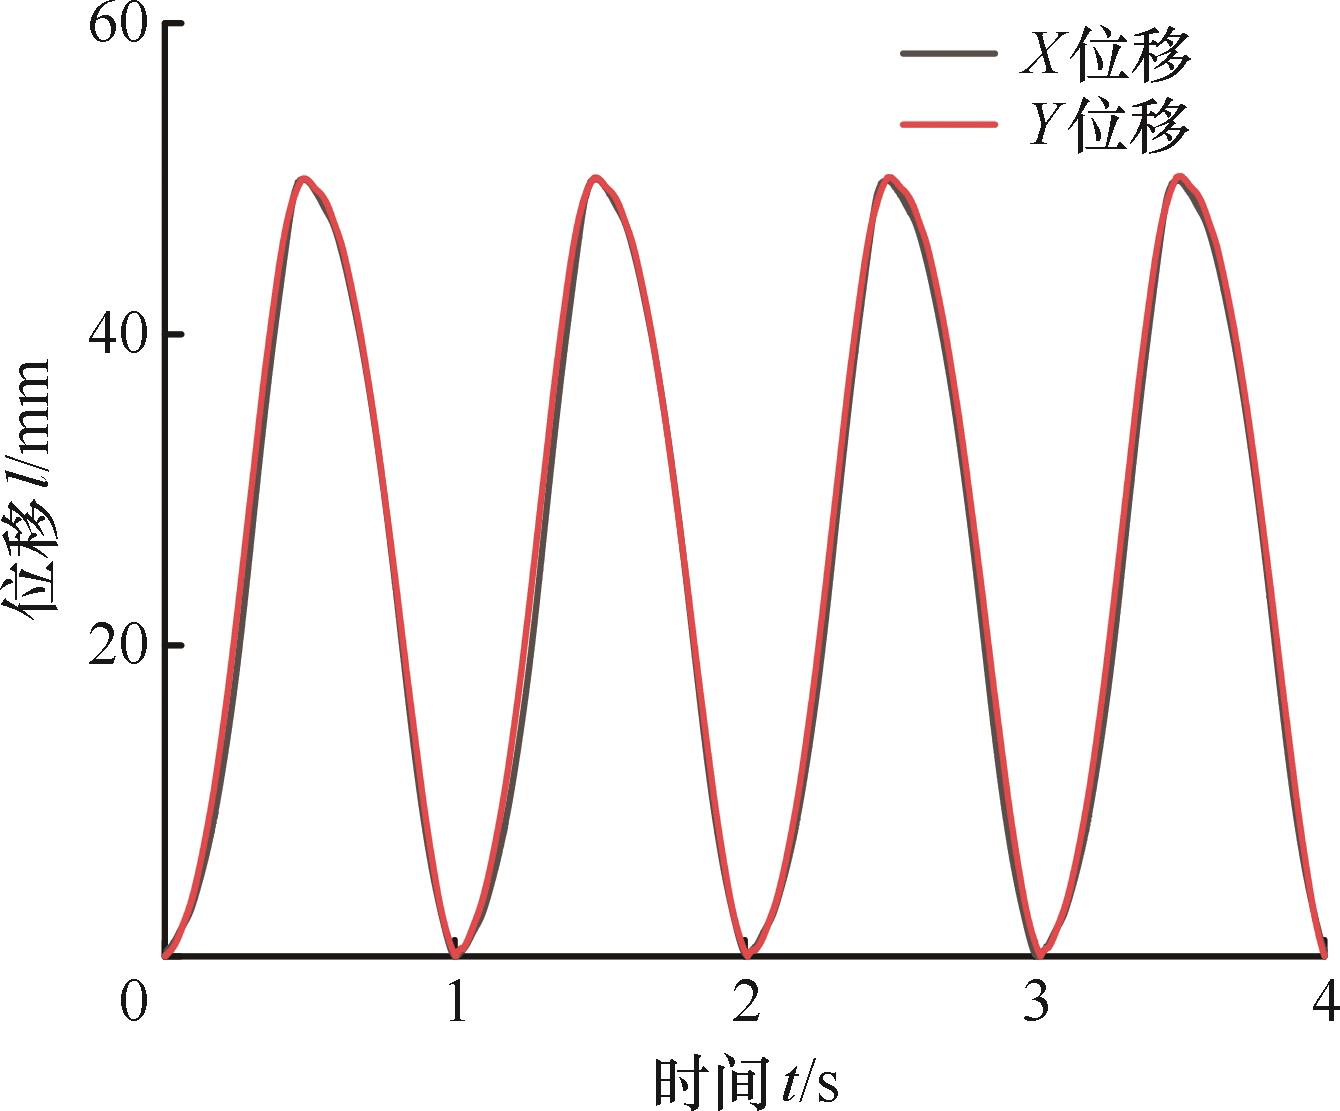
图15 X方向和Y方向同时驱动时的位移曲线
Fig.15 Displacement curves when driving simultaneously in the X and Y directions
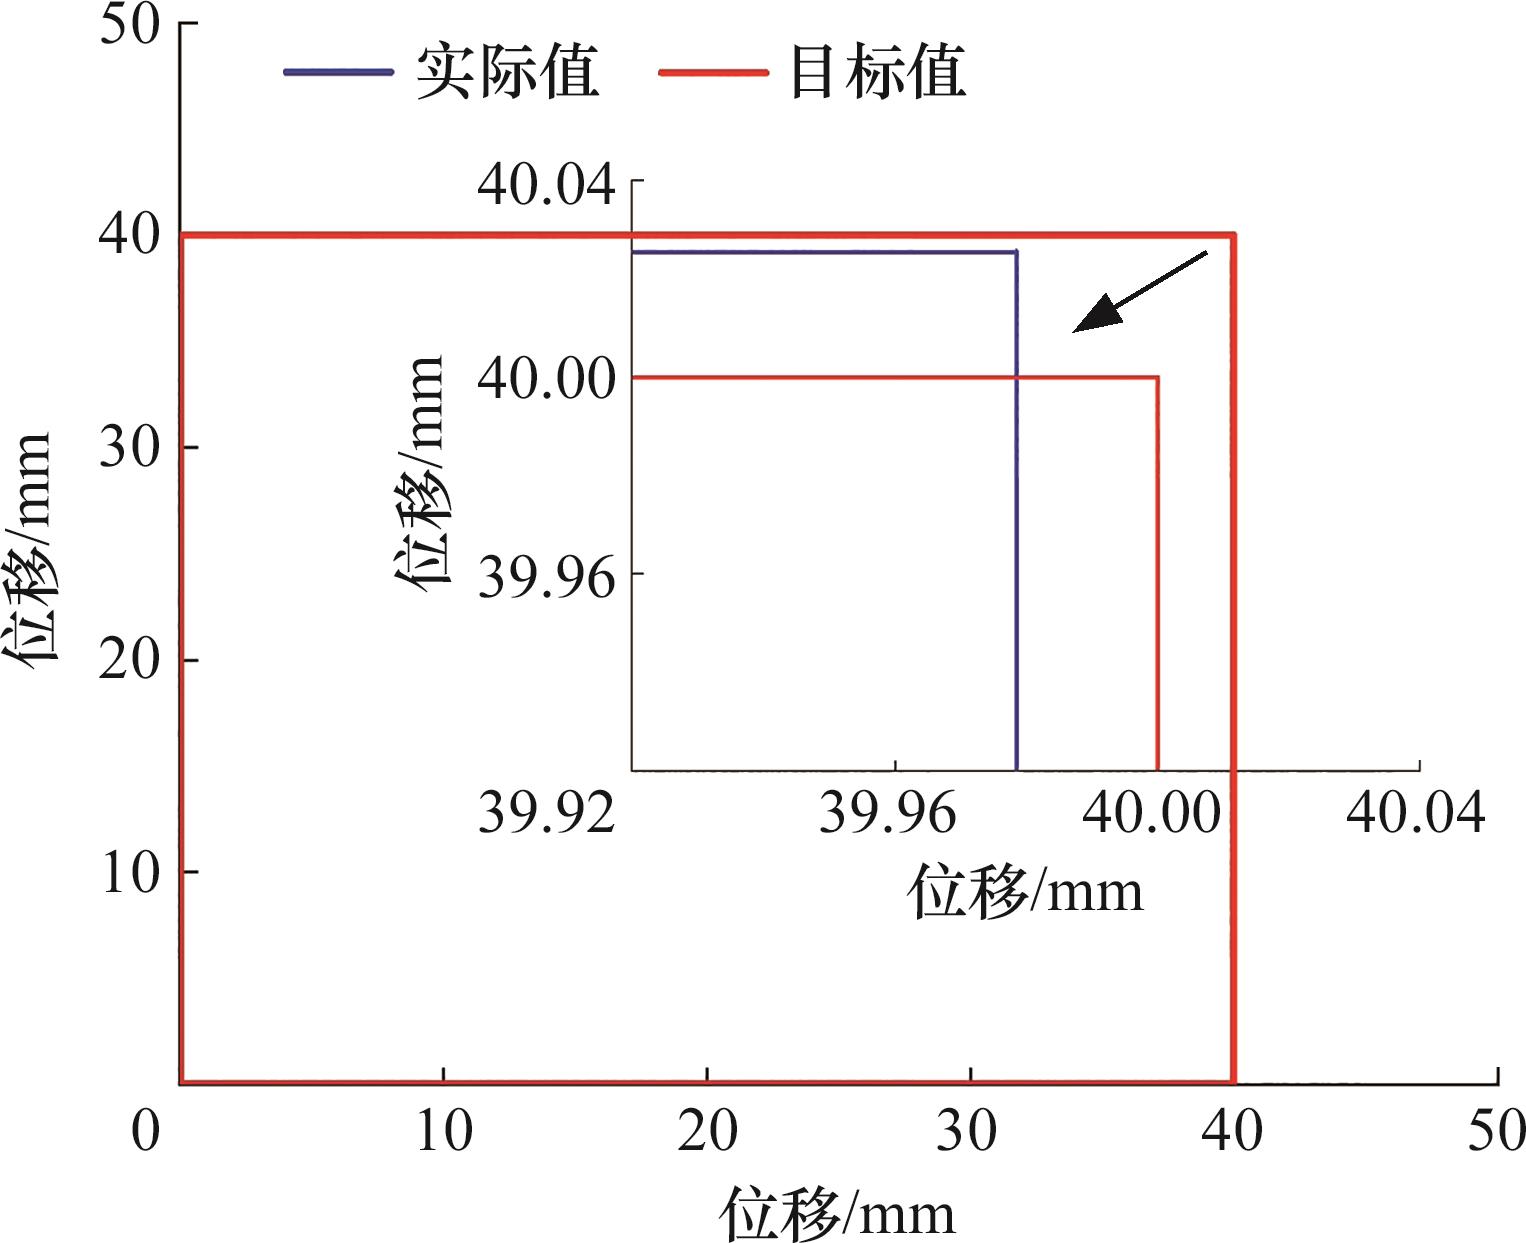
图16 正方形轨迹测试
Fig.16 Square trajectory test
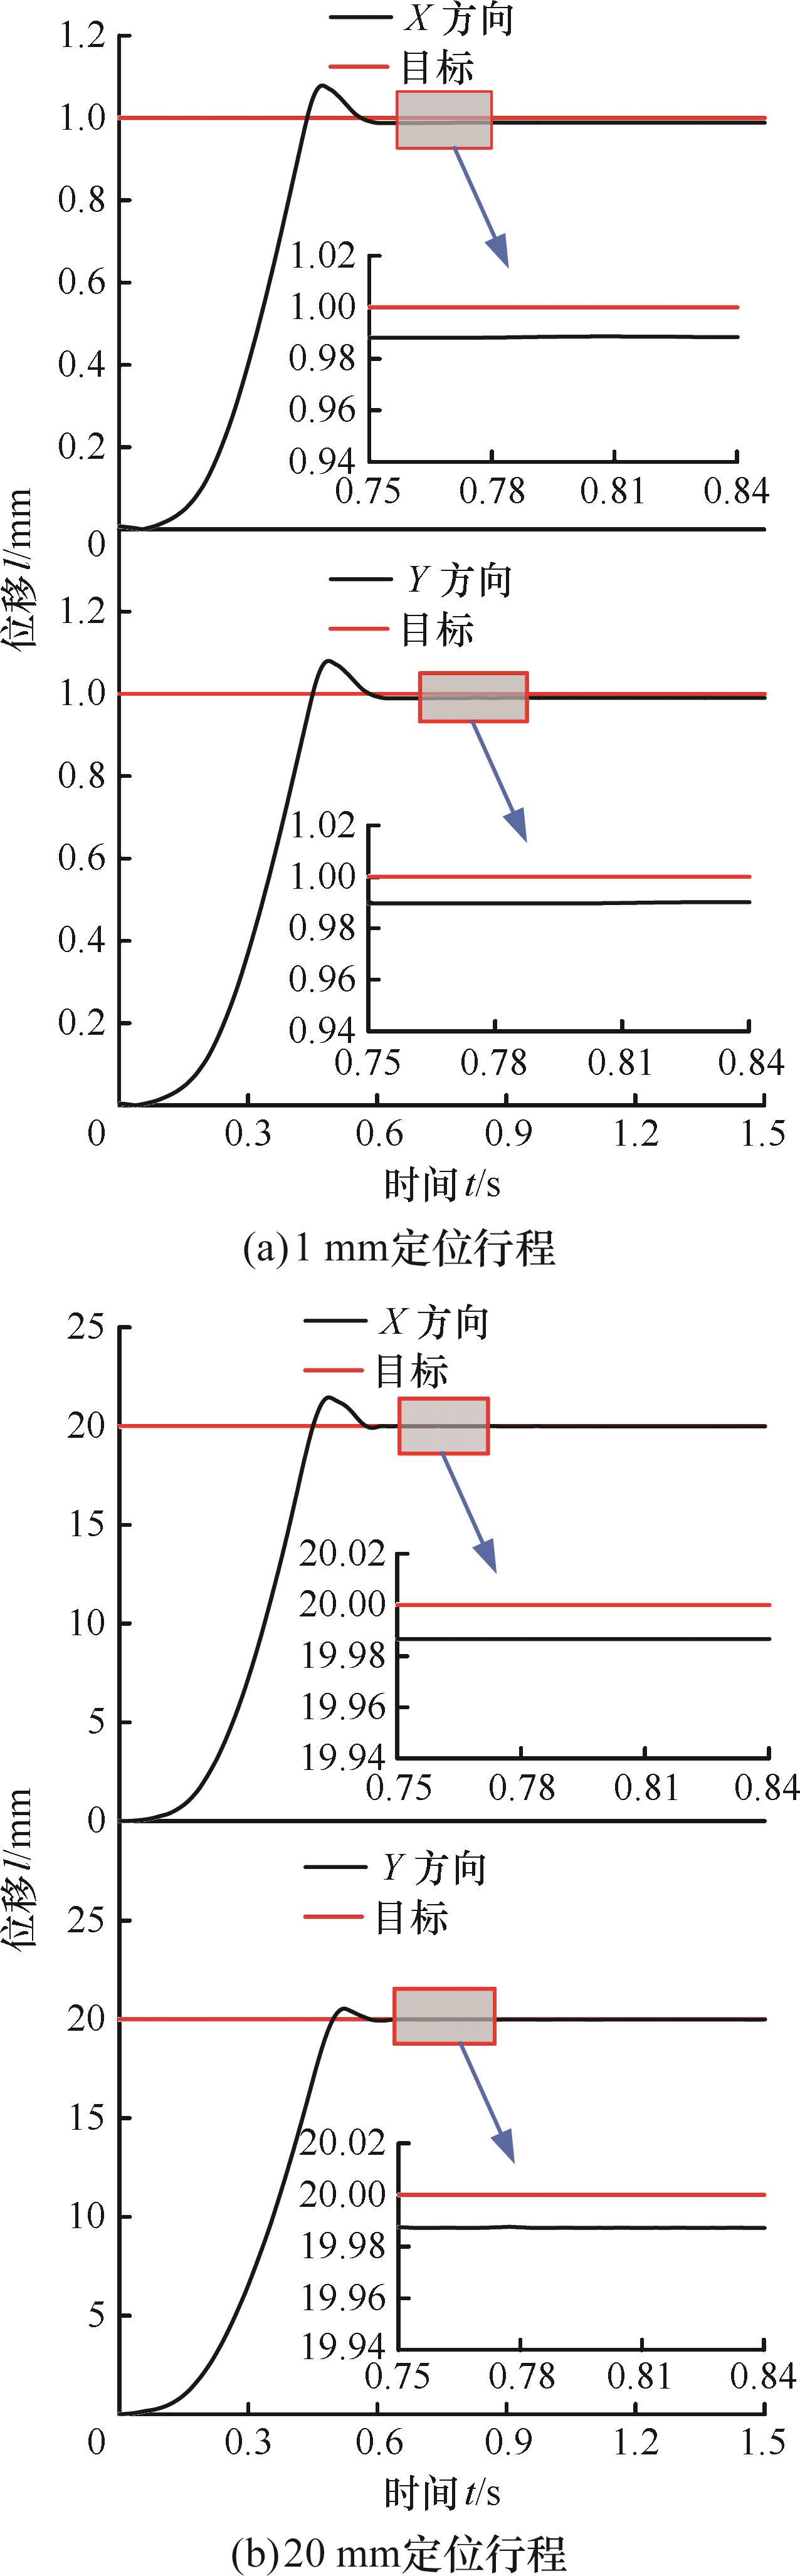
图17 宏动定位误差的测试结果
Fig.17 Test results of macro-motion positioning errors
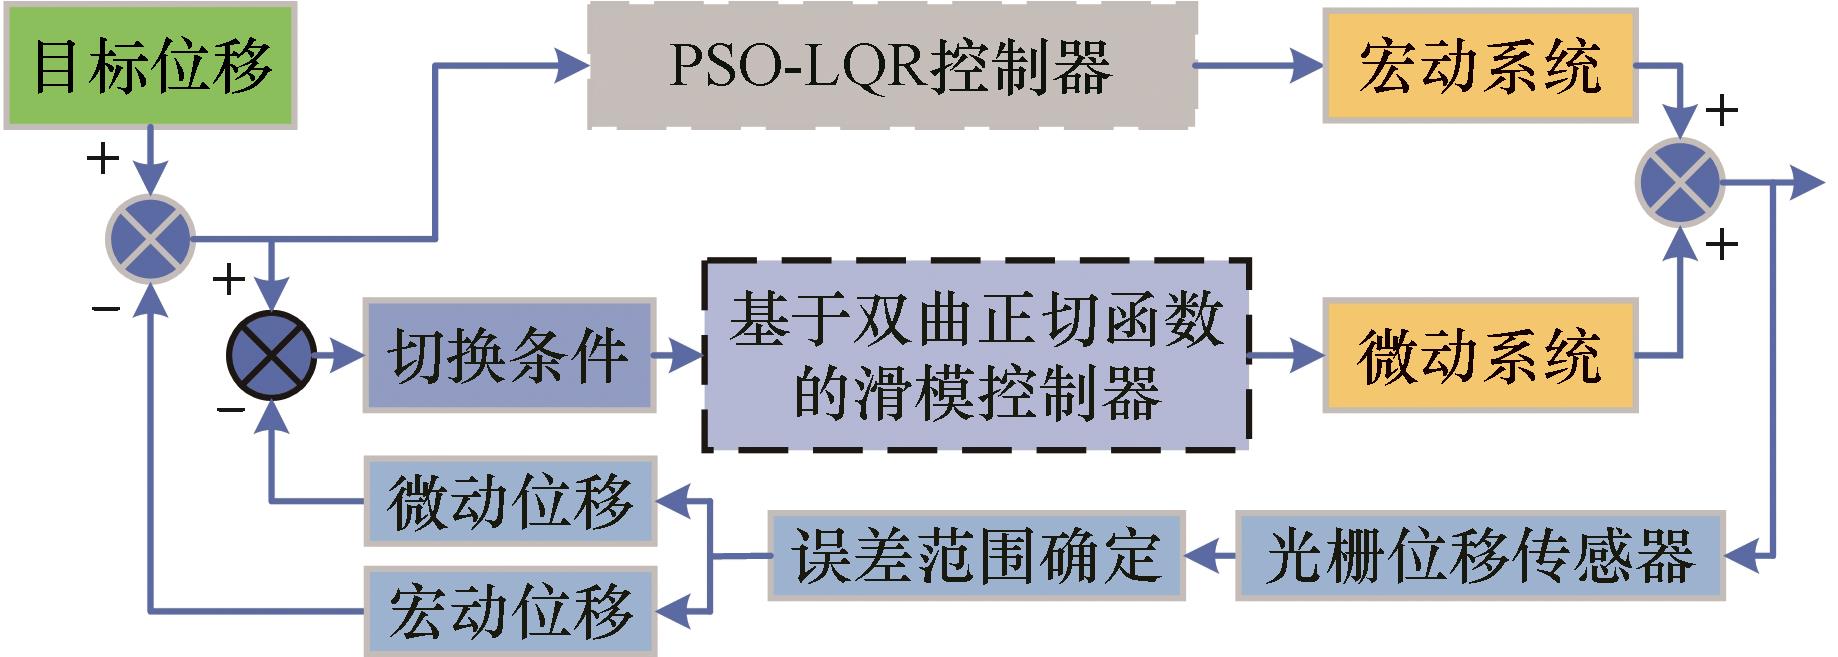
图18 控制策略框图
Fig.18 Control strategy block diagram
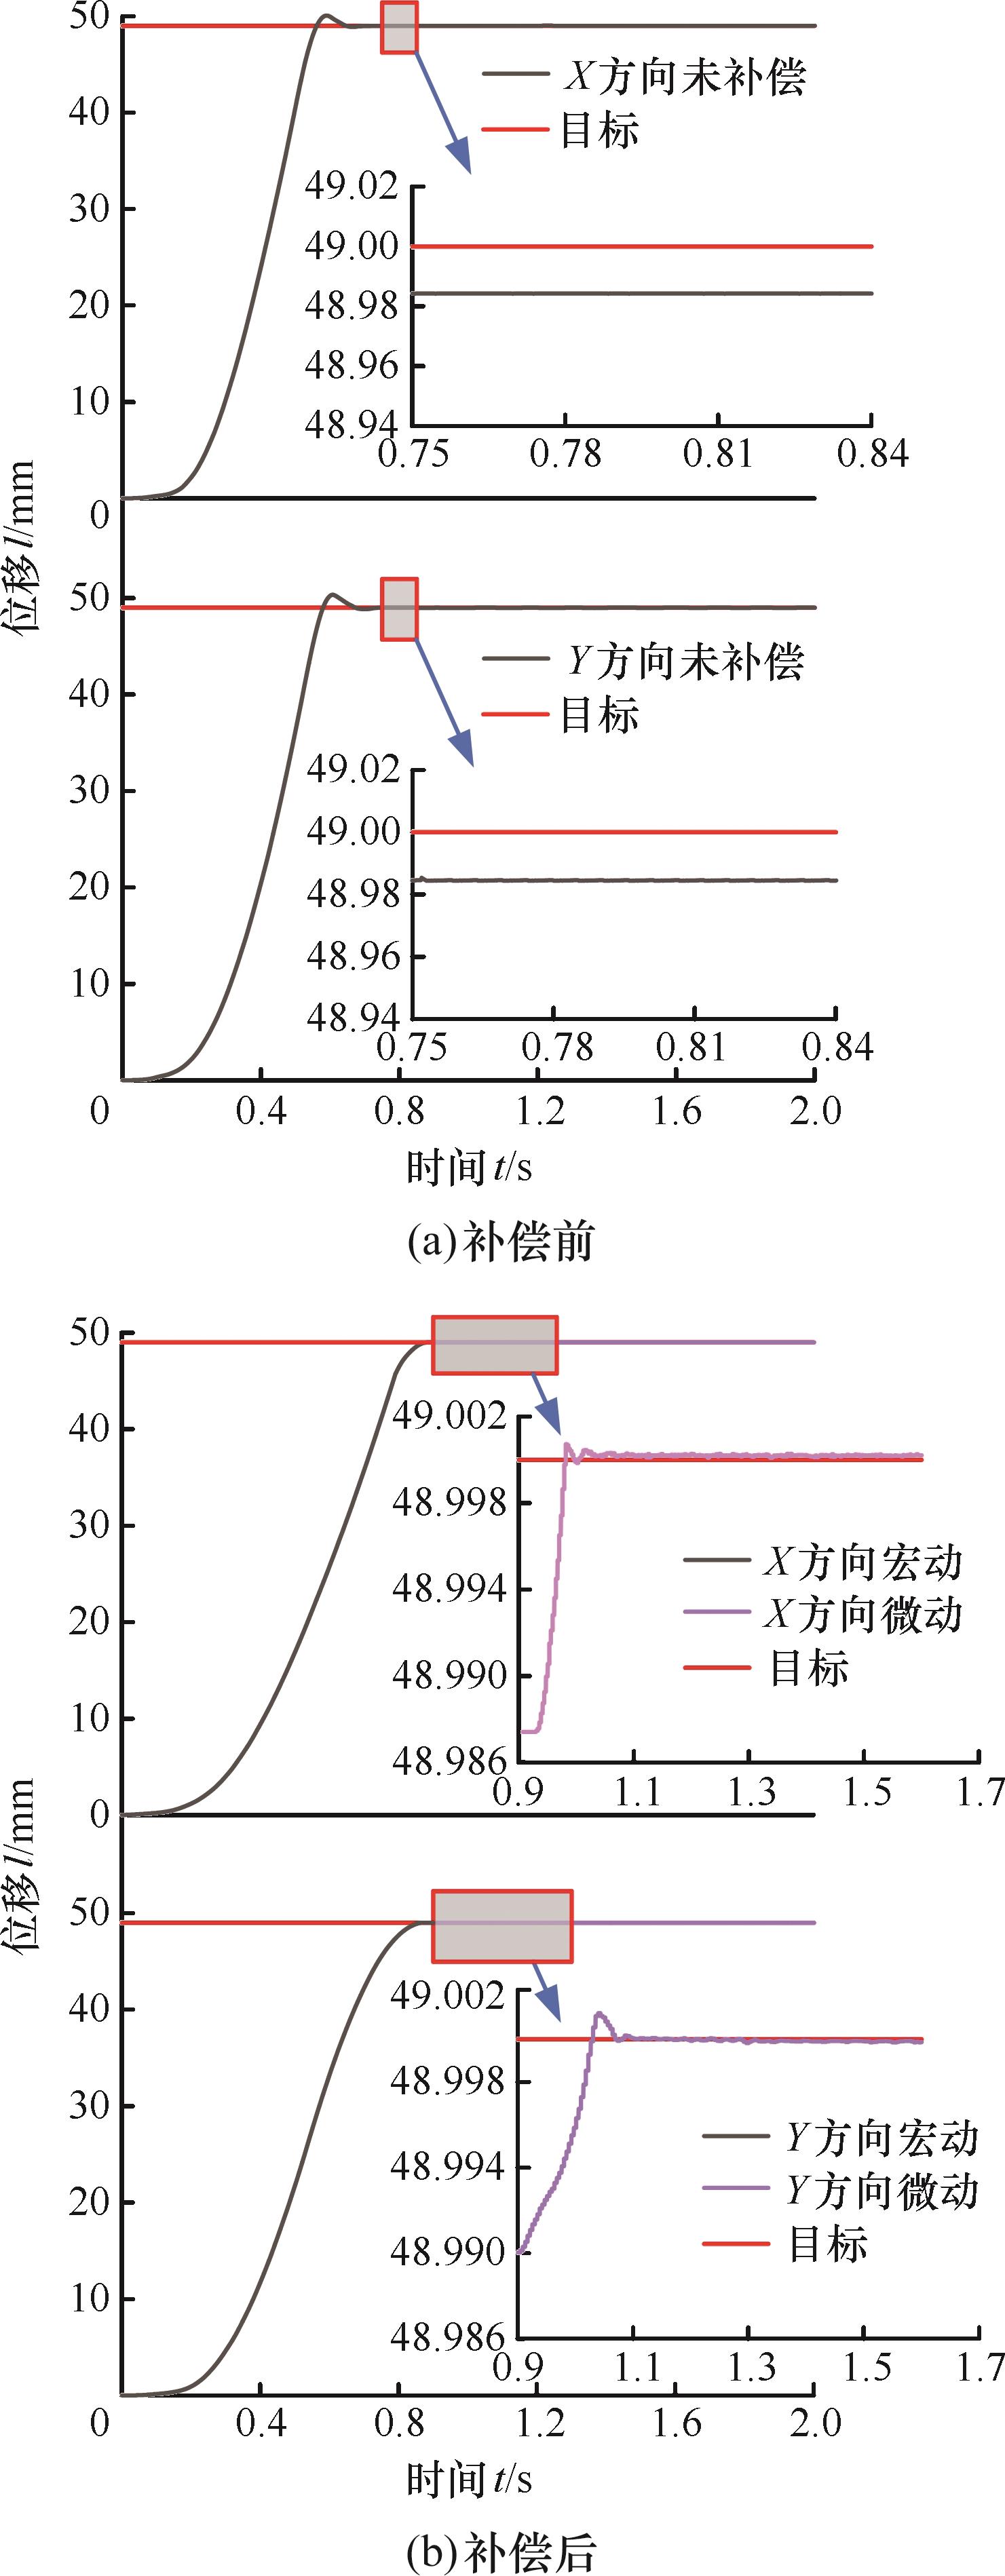
图19 最大行程时的定位误差
Fig.19 Positioning errors at maximum travel
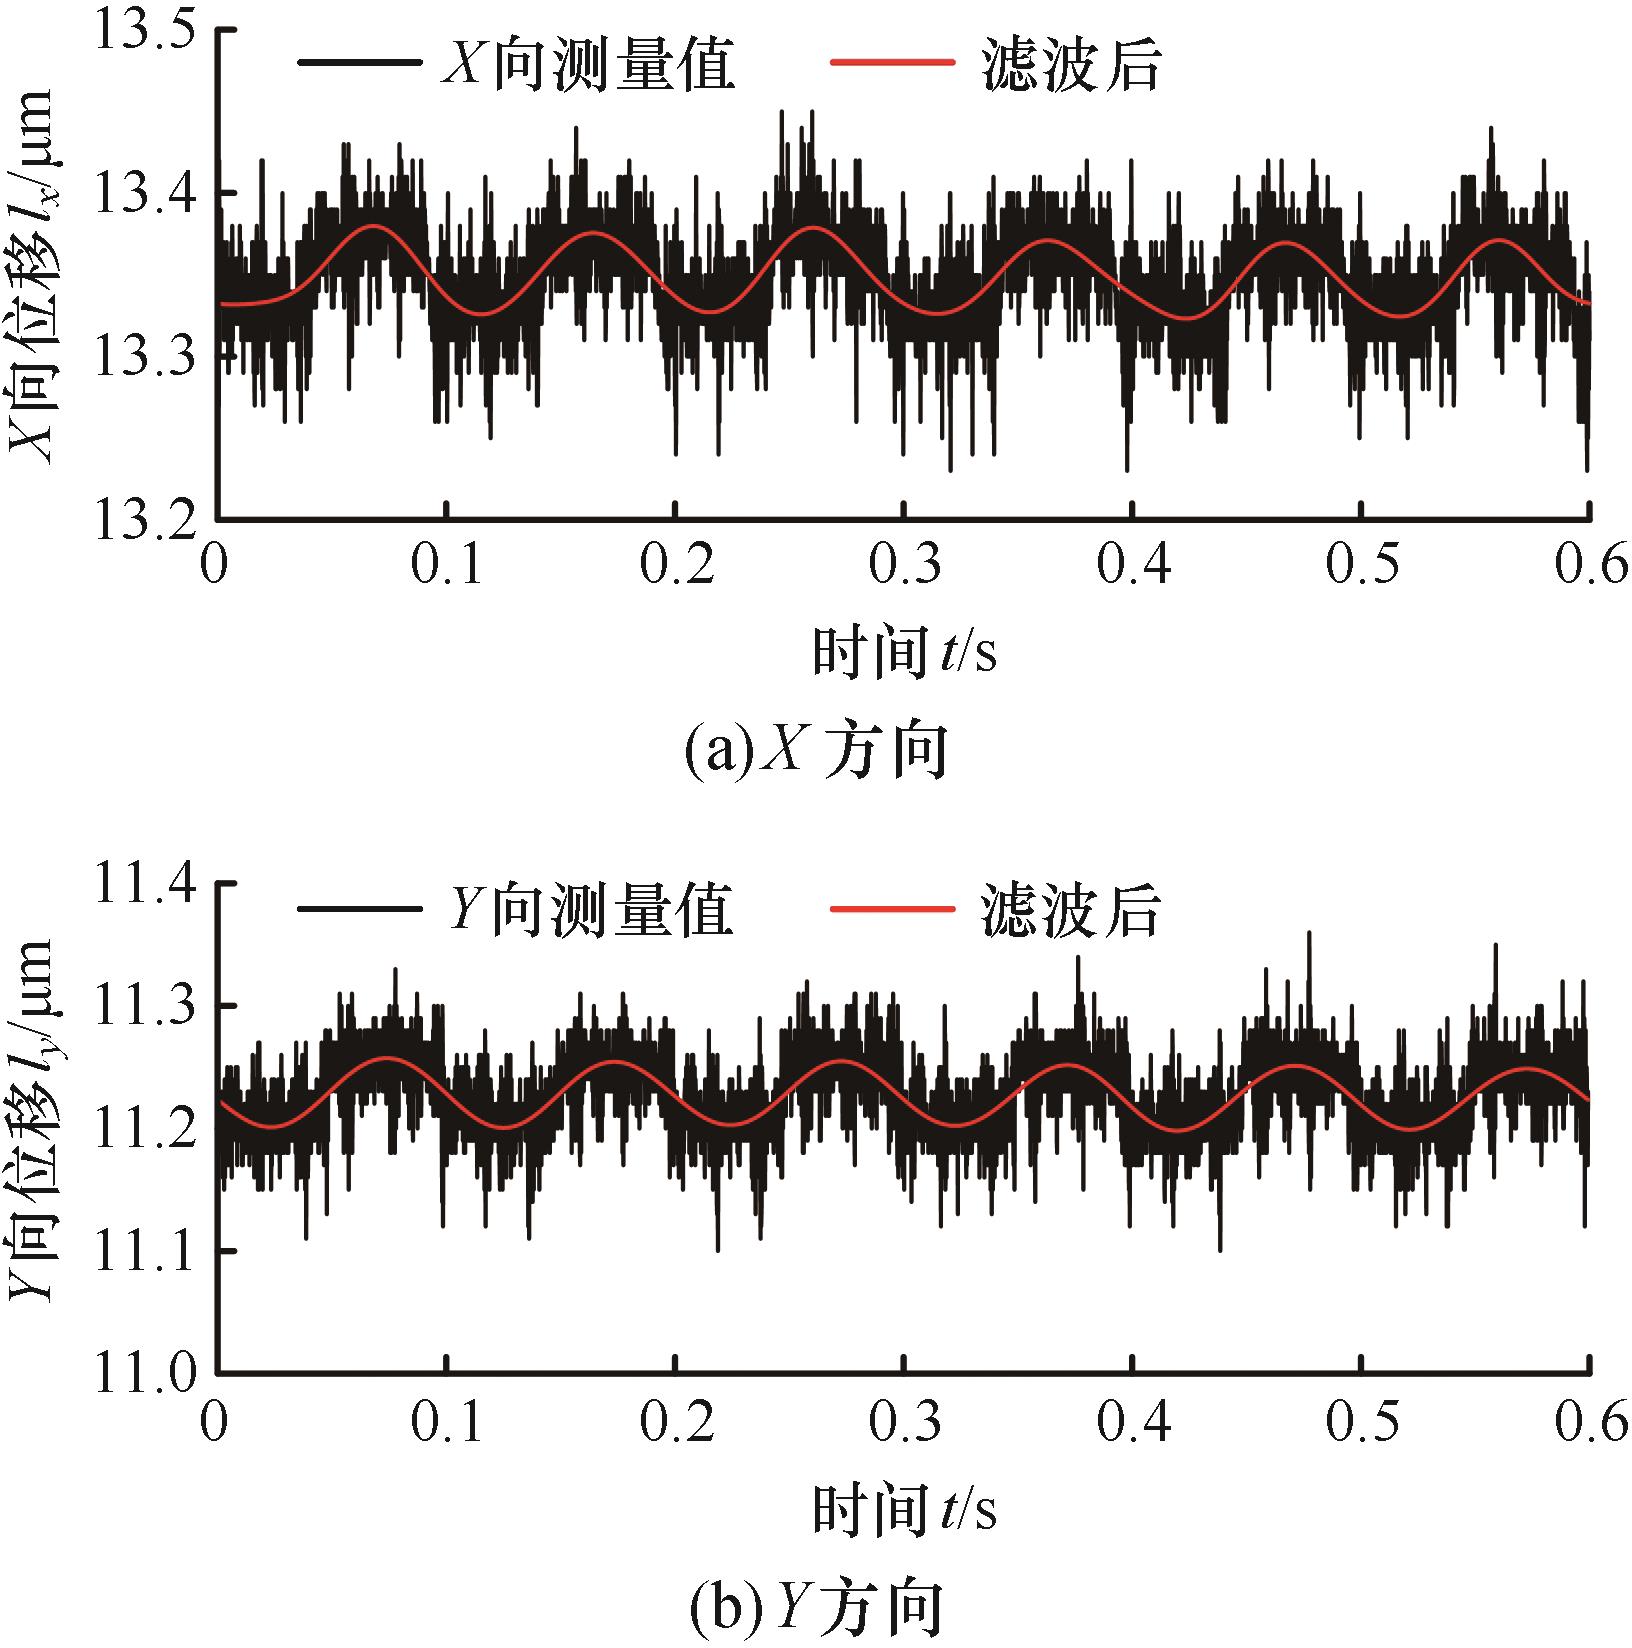
图20 定位分辨力测试
Fig.20 Positioning resolution test
| 参数 | 工作范围 | 分辨力 | 交叉 耦合率/% | 负载 能力/N |
|---|---|---|---|---|
| 本文 | 49.94 mm×50.04 mm | 56 nm | 0.05 | 250 |
| 文献[ | 30.76 μm×29.79 μm | 29.3 nm | 2.02 | 10 |
| 文献[ | 11.3 μm×10.6 μm | 20 nm | 0.07 | 1.2 |
| 文献[ | 20.4 mm×20.6 mm | 100 nm | 无 | 196 |
| 文献[ | 11.75 mm×11.66 mm | 200 nm | 1.3 | 196 |
| 文献[ | 15 mm×15 mm | 0.4 μm | 11.06 | 196 |
表6 XY工作台性能比较
Tab.6 Performance comparison of the XY workbench
| 参数 | 工作范围 | 分辨力 | 交叉 耦合率/% | 负载 能力/N |
|---|---|---|---|---|
| 本文 | 49.94 mm×50.04 mm | 56 nm | 0.05 | 250 |
| 文献[ | 30.76 μm×29.79 μm | 29.3 nm | 2.02 | 10 |
| 文献[ | 11.3 μm×10.6 μm | 20 nm | 0.07 | 1.2 |
| 文献[ | 20.4 mm×20.6 mm | 100 nm | 无 | 196 |
| 文献[ | 11.75 mm×11.66 mm | 200 nm | 1.3 | 196 |
| 文献[ | 15 mm×15 mm | 0.4 μm | 11.06 | 196 |
| [1] | ZHANG Lanyu, GAO Jian, HE Yunbo, et al. A VCM Active Actuation Method for Bonding Time Reduction in Chip Packaging Process[J]. IEEE Transactions on Industrial Electronics, 2021, 68(8): 7252-7262. |
| [2] | 喻曹丰, 王传礼, 解甜, 等. 基于GMM的高性能微定位工作台驱动系统的研制[J]. 机械工程学报, 2019, 55(9): 136-143. |
| YU Caofeng, WANG Chuanli, XIE Tian, et al. Development of Drive System of High Performance Micro Positioning Worktable Based on Giant Magnetostrictive Material[J]. Journal of Mechanical Engineering, 2019, 55(9): 136-143. | |
| [3] | 庄健, 王志武, 廖晓波. 应用于高速离子电导扫描成像的双压电定位平台[J]. 光学精密工程, 2020, 28(10): 2203-2214. |
| ZHUANG Jian, WANG Zhiwu, LIAO Xiaobo. Dual-stage Piezo Nanopositioner for High-speed Ion Conductance Microscopy Imaging[J]. Optics and Precision Engineering, 2020, 28(10): 2203-2214. | |
| [4] | LI Mi, LIU Lianqing, XI Ning, et al. Applications of Micro/Nano Automation Technology in Detecting Cancer Cells for Personalized Medicine[J]. IEEE Transactions on Nanotechnology, 2017, 16(2): 217-229. |
| [5] | YANG Xu, ZHU Wule. Design, Analysis, and Control of an XY Parallel Nanomanipulator with Multiple Actuation Modes[J]. IEEE Transactions on Industrial Electronics, 2020, 67(9): 7639-7648. |
| [6] | YANG Zhixin, ZHOU Xiaoqin, HUANG Hu, et al. On the Suppression of the Backward Motion of a Piezo-driven Precision Positioning Platform Designed by the Parasitic Motion Principle[J]. IEEE Transactions on Industrial Electronics, 2020, 67(5): 3870-3878. |
| [7] | YUAN Lusheng, WANG Liang, QI Rui, et al. A Novel Hollow-type XY Piezoelectric Positioning Platform[J]. International Journal of Mechanical Sciences, 2023, 255: 108496. |
| [8] | GAO Xiang, LIU Yingxiang, ZHANG Shijing, et al. Development of a Novel Flexure-based XY Platform Using Single Bending Hybrid Piezoelectric Actuator[J]. ASME Transactions on Mechatronics, 2022, 27(5): 3977-3987. |
| [9] | LUO Ciyong, LI Xingwang, LIAO Yong, et al. Design of End-iron-free Voice Coil Motor with Appropriate PM Length Ratio[J]. IEEE Transactions on Energy Conversion, 2020, 35(2): 1139-1146. |
| [10] | 柴嘉伟, 贵献国. 音圈电机结构优化及应用综述[J]. 电工技术学报, 2021, 36(6): 1113-1125. |
| CHAI Jiawei, GUI Xianguo. Overview of Structure Optimization and Application of Voice Coil Motor[J]. Transactions of China Electrotechnical Society, 2021, 36(6): 1113-1125. | |
| [11] | 刘鑫, 李新阳, 杜睿. 压电陶瓷驱动器迟滞非线性建模及逆补偿控制[J]. 光电工程, 2019, 46(8): 180328. |
| LIU Xin, LI Xinyang, DU Rui. Hysteresis Nonlinear Modeling and Inverse Compensation of Piezoelectric Actuators[J]. Opto-Electronic Engineering, 2019, 46(8): 180328. | |
| [12] | 赵庆旭, 王一帆, 吴文鹏, 等. 压电陶瓷驱动平台的复合控制方法研究[J]. 电光与控制, 2019, 26(6): 80-84. |
| ZHAO Qingxu, WANG Yifan, WU Wenpeng, et al. On Composite Control Method for Piezoelectric Ceramic Driving Platform[J]. Electronics Optics & Control, 2019, 26(6): 80-84. | |
| [13] | TIAN Yanling, HUO Zhichen, WANG Fujun, et al. A Novel Friction-actuated 2-DOF High Precision Positioning Stage with Hybrid Decoupling Structure[J]. Mechanism and Machine Theory, 2022, 167: 104511. |
| [14] | ZHANG Hanlun, WU Zehao, XU Qingsong. Design of a New XY Flexure Micropositioning Stage with a Large Hollow Platform[J]. Actuators, 2020, 9(3): 65. |
| [15] | LIN Rui, LI Yingzi, ZHANG Yingxu, et al. Design of a Flexure-based Mixed-kinematic XY High-precision Positioning Platform with Large Range[J]. Mechanism and Machine Theory, 2019, 142: 103609. |
| [16] | CAI Kunhai, TIAN Yanling, LIU Xianping, et al. Development and Control Methodologies for 2-DOF Micro/Nano Positioning Stage with High Out-of-plane Payload Capacity[J]. Robotics and Computer-Integrated Manufacturing, 2019, 56: 95-105. |
| [17] | FAN Shixun, LIU Hua, FAN Dapeng. Design and Development of a Novel Monolithic Compliant XY Stage with Centimeter Travel Range and High Payload Capacity[J]. Mechanical Sciences, 2018, 9(1): 161-176. |
| [18] | XU Qingsong. Design and Development of a Compact Flexure-based XY Precision Positioning System with Centimeter Range[J]. IEEE Transactions on Industrial Electronics, 2014, 61(2): 893-903. |
| [19] | 喻曹丰, 王玉, 陈卓, 等. 同轴集成式宏微复合驱动器的磁路建模分析与实验研究[J]. 中国电机工程学报, 2022, 42(16): 6083-6093. |
| YU Caofeng, WANG Yu, CHEN Zhuo, et al. Experimental Study and Magnetic Circuit Modeling Analysis of Coaxial Integrated Macro-micro Composite Actuator[J]. Proceedings of the Chinese Society for Electrical Engineering, 2022, 42(16): 6083-6093. | |
| [20] | 孙立宁, 李腾, 刘延杰. 高加速精密直线电机运动平台键合图建模与分析[J]. 机器人, 2011, 33(4): 467-474. |
| SUN Lining, LI Teng, LIU Yanjie. Modelling and Analysis of a High Acceleration and Precision Linear Motor Direct Drive Motion Stage with Bond Graph Approach[J]. Robot, 2011, 33(4): 467-474. | |
| [21] | 张云峰, 李玲玲, 刘威, 等. 基于键合图的五轴联动数控机床动态特性分析与能耗建模研究[J]. 机械工程学报, 2023, 59(7): 241-251. |
| ZHANG Yunfeng, LI Lingling, LIU Wei, et al. Research on Dynamic Characteristic Analysis and Energy Consumption Modeling of Five-axis CNC Machine Tool Based on Bond Graph[J]. Journal of Mechanical Engineering, 2023, 59(7): 241-251. | |
| [22] | 马志鹏. 基于音圈电机的高速精密定位系统的动力学行为与控制方法[D]. 天津: 天津大学, 2012. |
| MA Zhipeng. Dynamic Behavior and Control of a High-speed Precision Positioning System Driven by Voice Coil Actuators[D]. Tianjin: Tianjin University, 2012. | |
| [23] | DENG Jie, LIU Yingxiang, LI Kai, et al. Design, Modeling, and Experimental Evaluation of a Compact Piezoelectric XY Platform for Large Travel Range[J]. IEEE Transactions on Ultrasonics, Ferroelectrics, and Frequency Control, 2020, 67(4): 863-872. |
| [1] | 郭炯棋, 于攀宇, 刘清涛, 吕景祥, 张义超. 基于响应面法与改进灰狼算法的柔性电路喷墨打印工艺优化[J]. 中国机械工程, 2026, 37(6): 1383-1392. |
| [2] | 欧阳亚文, 赵亦希, 李晓凯, 胡蓝. 大径厚比椭球收口环件回弹分析与模具优化研究[J]. 中国机械工程, 2026, 37(6): 1497-1507. |
| [3] | 陈俊翔1, 2, 齐钒羽1, 姜宏达1, 2, 孔祥东1, 2, 金振林1, 艾超1, 2. 负载口独立双阀芯电液阀的结构优化[J]. 中国机械工程, 2024, 35(10): 1747-1761. |
| [4] | 时强胜, 张小俭, 陈巍, 杨泽源, 严思杰, . 基于灰色关联度分析响应面法的橡胶软模端面抛磨表面粗糙度预测[J]. 中国机械工程, 2021, 32(24): 2967-2974. |
| [5] | 李娟莉, 刘朝阳, 李博, 麻豪洲, 赵保林, . 刮板输送机仿生条纹型中部槽耐磨性试验研究[J]. 中国机械工程, 2021, 32(21): 2542-2551,2561. |
| [6] | 杨旭, 周德俭, 庄功伟, 宋微, 刘潇龙, 佘雨来. 基于改进响应面法的电缆碳纤维增强复合材料集成构件电缆埋置位置优化[J]. 中国机械工程, 2021, 32(16): 2008-2015. |
| [7] | 李博1,2;夏蕊1;王学文1;杨兆建1;席庆祥2. 基于响应面法的多因素交互作用下中部槽磨损试验研究[J]. 中国机械工程, 2019, 30(22): 2764-2771. |
| [8] | 姚梓萌, 李言, 杨明顺, 张敬冲, 张成兴. 基于响应面法的单点增量成形过程变形能优化[J]. 中国机械工程, 2017, 28(07): 862-866. |
| [9] | 王振, 崔亚辉, 刘凯, 徐琳. 装备单环路系统的整车行驶动力学研究[J]. 中国机械工程, 2016, 27(08): 1123-1129. |
| [10] | 李发宗, 童水光, 袁铭鸿. 热流固耦合下增压器涡壳多目标优化[J]. 中国机械工程, 2016, 27(06): 754-760,766. |
| [11] | 汪中厚, 袁可可, 李刚. 基于响应面法的滑动结合面动态特性参数优化识别[J]. 中国机械工程, 2016, 27(05): 622-626. |
| [12] | 余治民, 刘子建, 董思科, 李斯明, 艾彦迪. 基于蒙特卡洛模拟与响应面方法的公差建模[J]. 中国机械工程, 2015, 26(4): 427-434. |
| [13] | 姜丽萍, 陈文亮, 王珉, 刘玉琳, 侯玉昭. 单向压紧制孔工艺的自适应响应面优化方法[J]. 中国机械工程, 2015, 26(23): 3156-3161. |
| [14] | 吴劲松, 周金宇. 隐式功能函数结构体可靠性拓扑优化[J]. 中国机械工程, 2015, 26(16): 2203-2208. |
| [15] | 任福深, 陈素丽, 王威. 基于键合图理论的斜直井管柱上扣/卸扣系统设计与仿真[J]. 中国机械工程, 2014, 25(3): 404-409. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
