ISSN 1004-132X
CN 42-1294/TH
CN 42-1294/TH
中国机械工程 ›› 2026, Vol. 37 ›› Issue (8): 1811-1823.DOI: 10.3969/j.issn.1004-132X.2026.08.001
• 先进流体系统设计与优化(续) •
姜宏达1,2, 陈俊翔1,2, 艾超1,2( ), 孔祥东1,2
收稿日期:2025-05-12
出版日期:2026-08-25
发布日期:2026-09-17
通讯作者:
艾超
作者简介:姜宏达,男,2000年生,博士研究生。研究方向为液压机械臂运动控制。发表论文4篇
基金资助:
JIANG Hongda1,2, CHEN Junxiang1,2, AI Chao1,2(), KONG Xiangdong1,2
Received:2025-05-12
Online:2026-08-25
Published:2026-09-17
Contact:
AI Chao
摘要:
针对液压挖掘机在复杂动态环境中自主作业难以实现高精度路径跟踪的问题,提出一种基于时变引导向量场(GVF)的层级控制架构。构造归一化时变引导向量场作为上层规划器,基于欧氏距离函数设计收敛项以驱动系统全局渐近收敛至参数化目标路径,在此基础上引入动态前馈补偿项,结合零空间投影机制消除时变路径几何形变对机械臂跟踪性能的影响,确保其对目标路径的动态跟踪能力。此外,通过Lyapunov稳定性理论证明系统在模型不确定性与外部扰动下的最终有界性,并推导扰动强度与齿尖轨迹偏差间的定量关系,进一步地,提出奇异点规避机制以确保挖掘机齿尖运动轨迹对应的向量场在全局工作空间解的唯一性和连续性。针对阀口独立液压系统,下层控制器设计进油流量-回油压力协同控制策略,对上层规划器输出指令实现高精度跟踪的同时,提高了系统能效。最后通过仿真验证了所提算法的有效性。
中图分类号:
姜宏达, 陈俊翔, 艾超, 孔祥东. 基于时变引导向量场的阀口独立液压挖掘机路径跟踪控制[J]. 中国机械工程, 2026, 37(8): 1811-1823.
JIANG Hongda, CHEN Junxiang, AI Chao, KONG Xiangdong. Time-varying Guidance Vector Field-based Path Following Control for Hydraulic Excavators with Independent Metering[J]. China Mechanical Engineering, 2026, 37(8): 1811-1823.
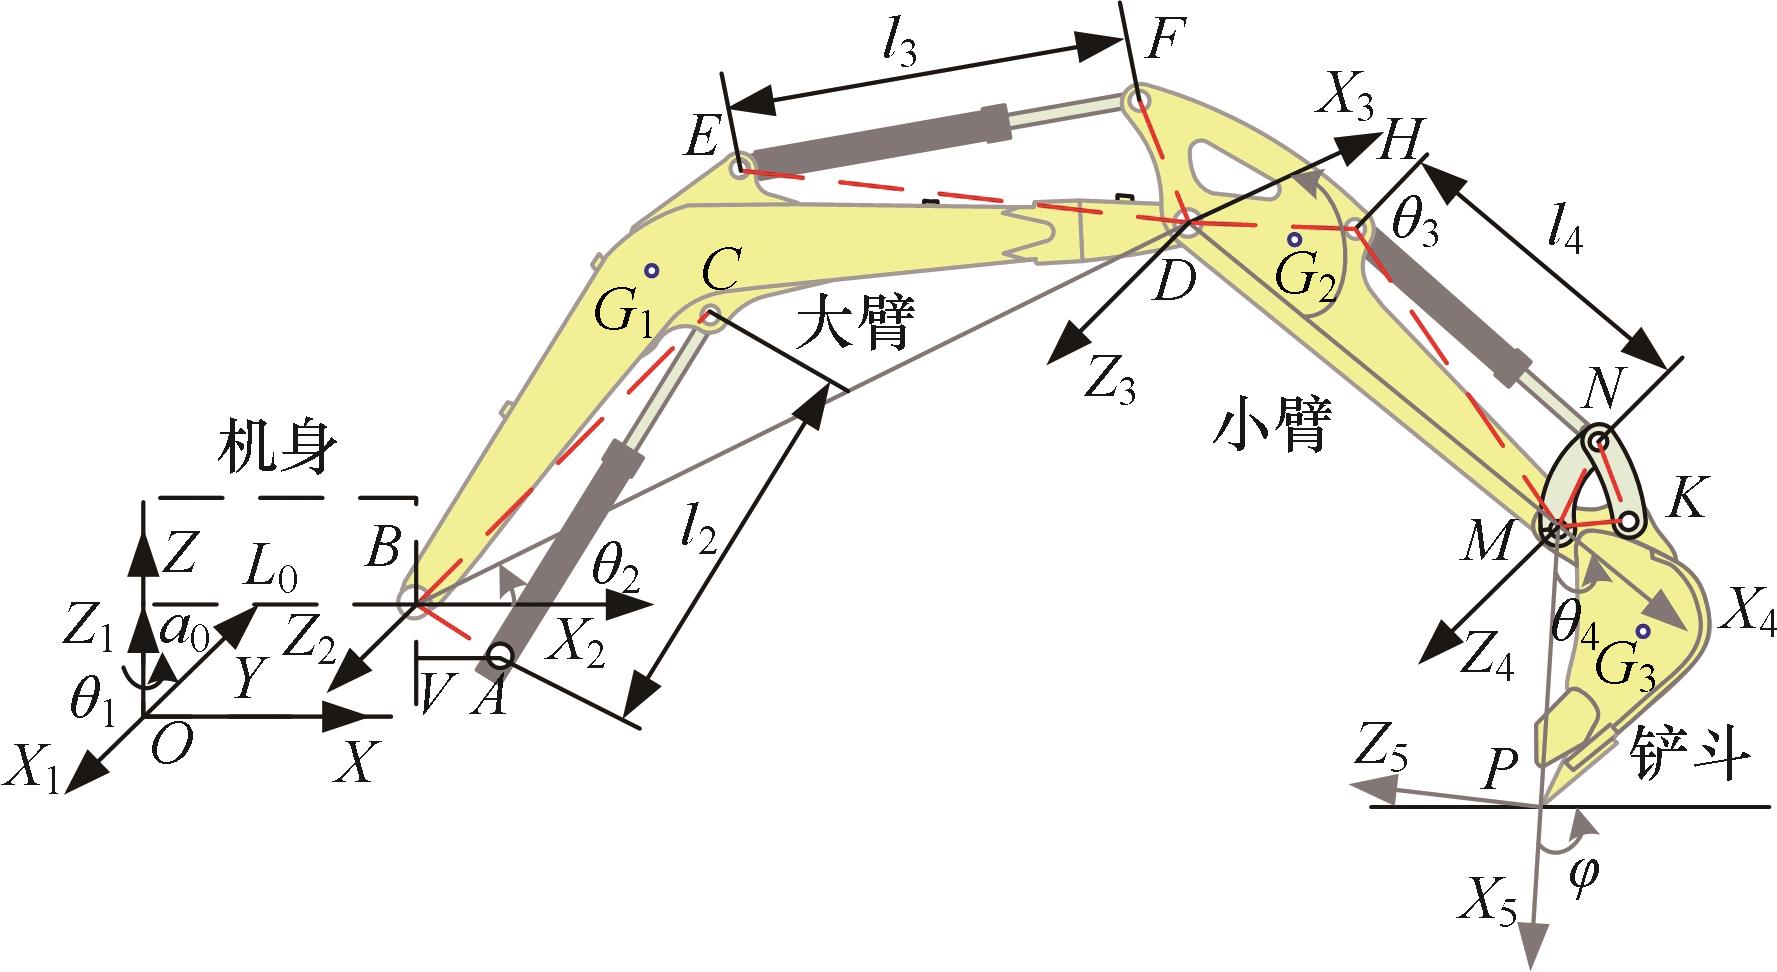
图1 挖掘机运动学模型
Fig.1 Excavator kinematics model
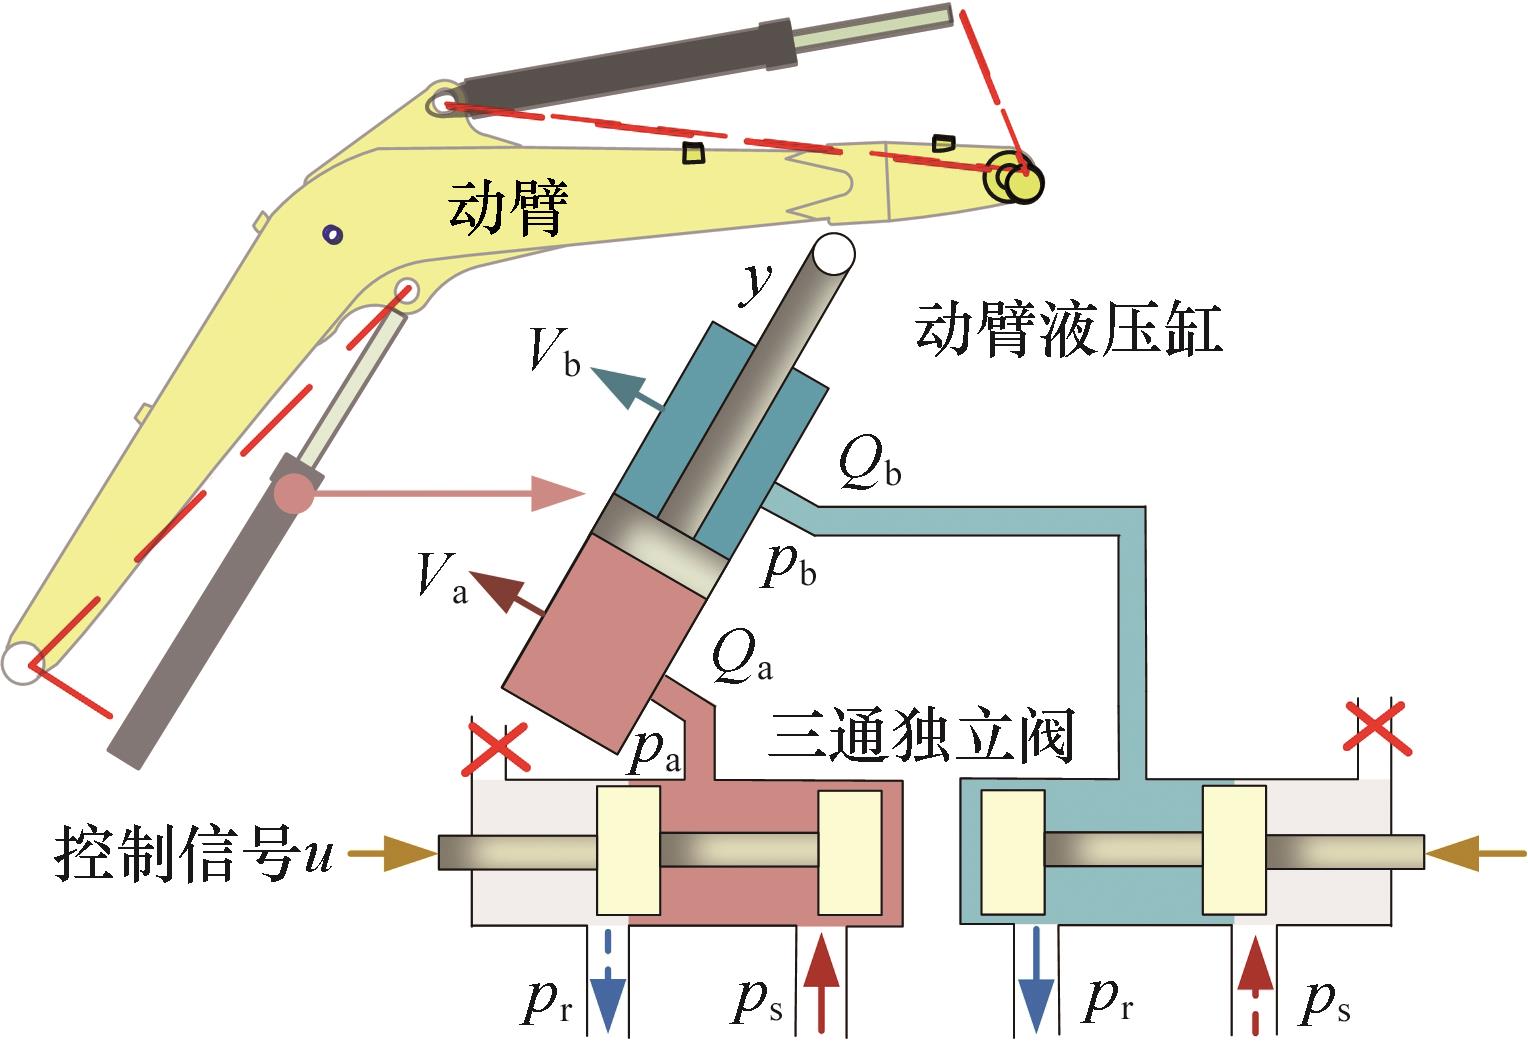
图2 阀口独立液压系统
Fig.2 Independent metering hydraulic system
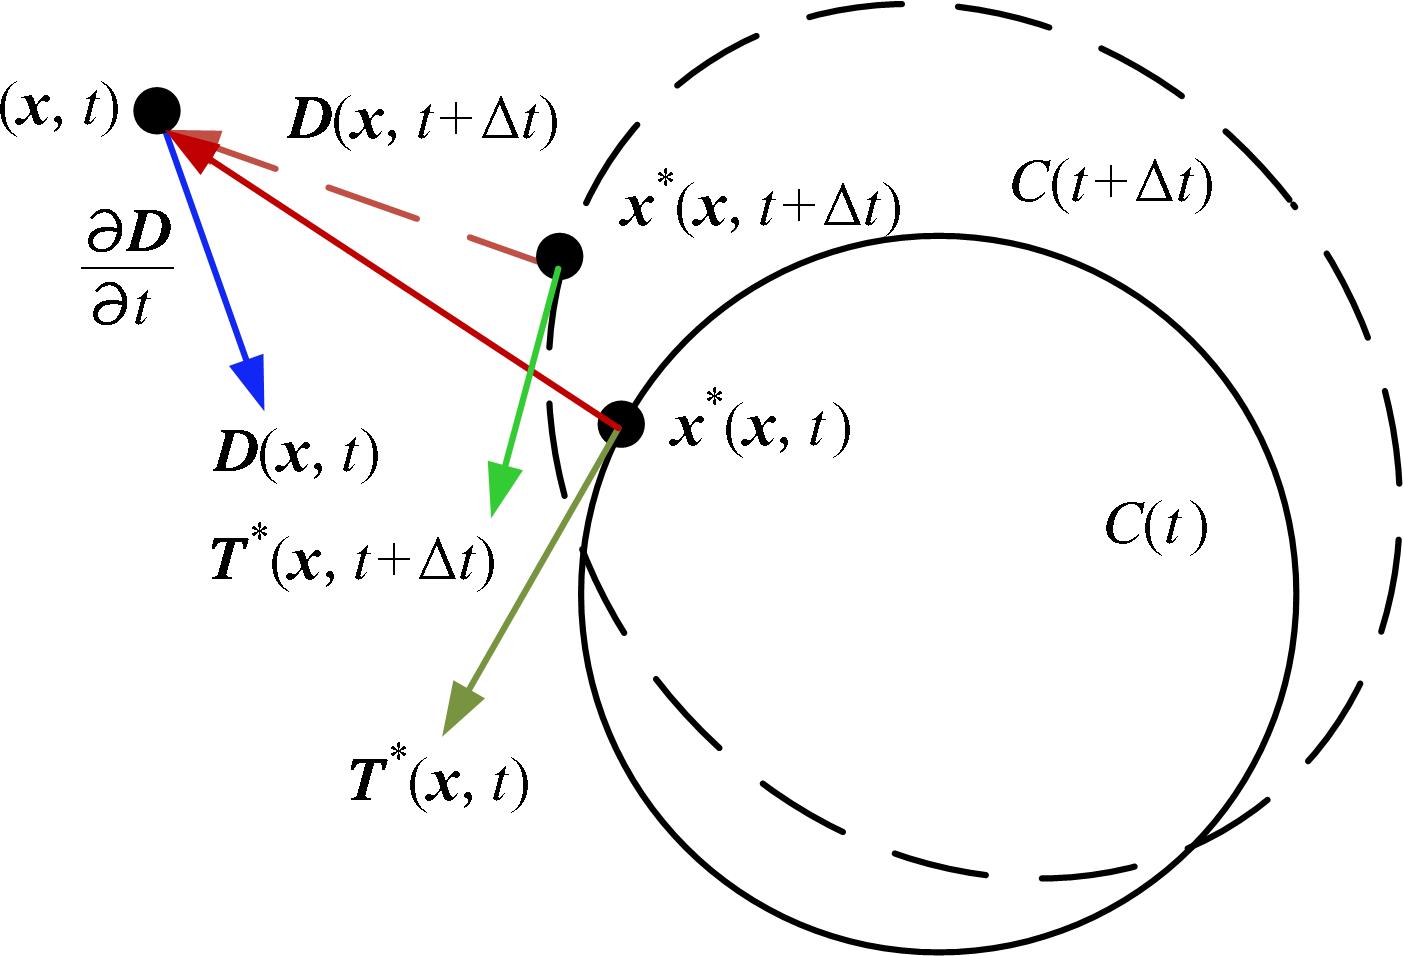
图3 时变向量场基本结构
Fig.3 Basic structure of time-varying vector field
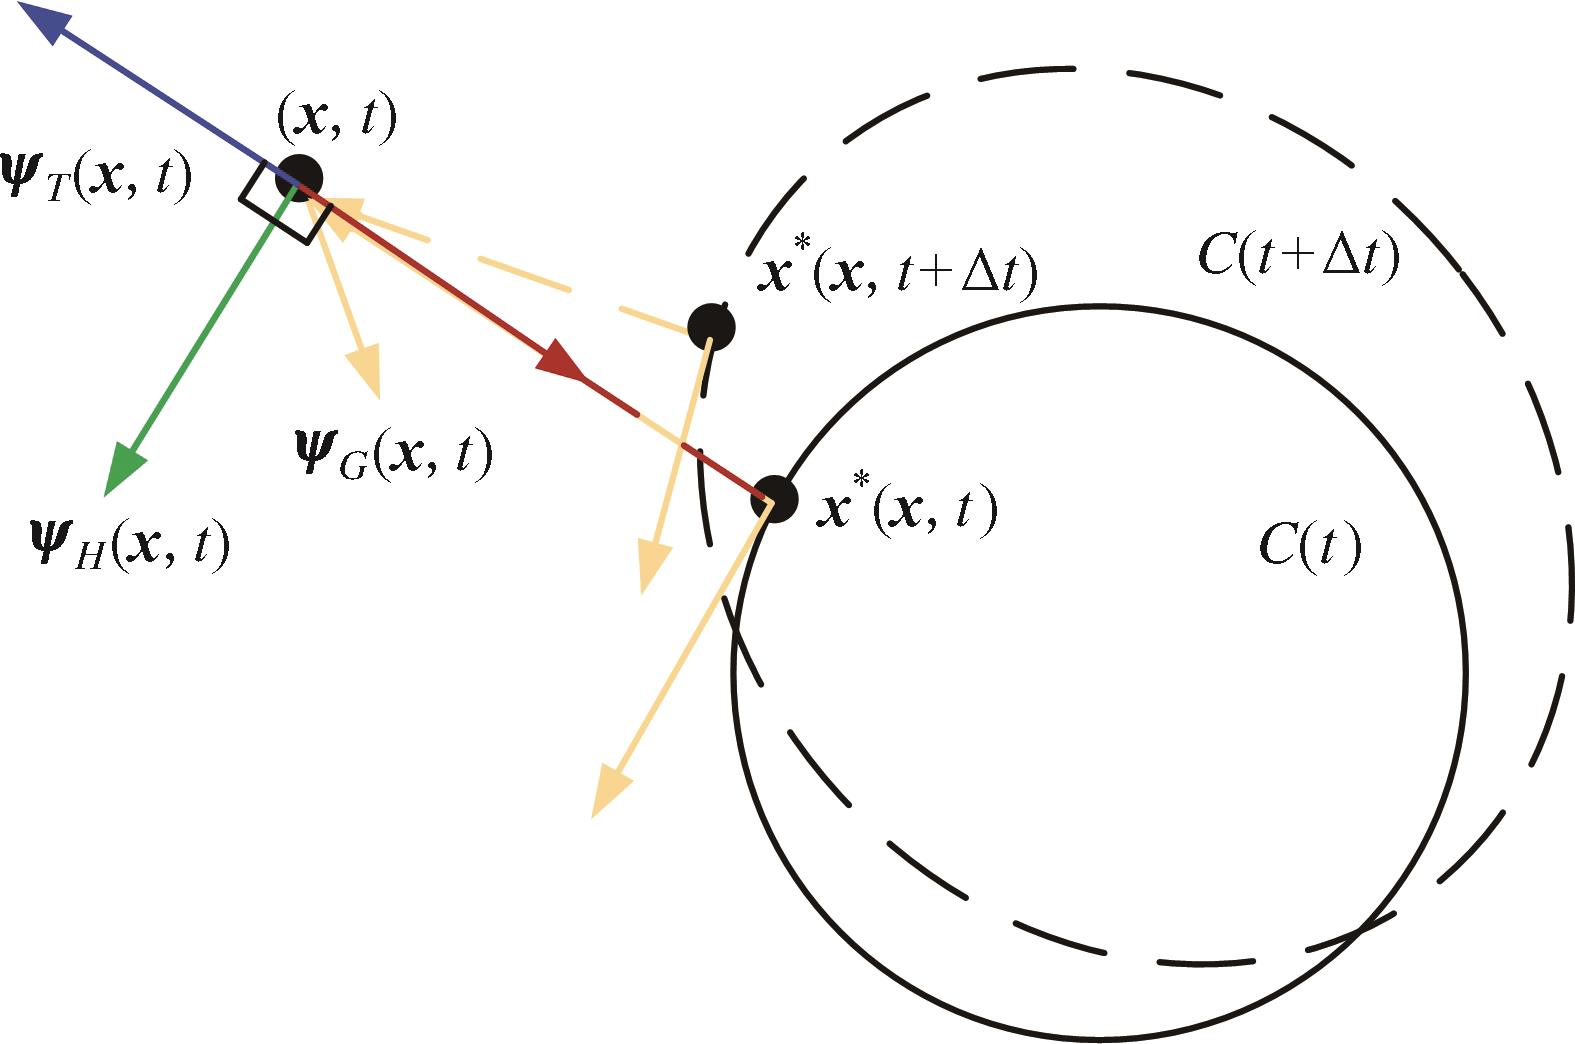
图4 时变引导向量场控制信号组成
Fig.4 Time-varying steering vector field control signal composition
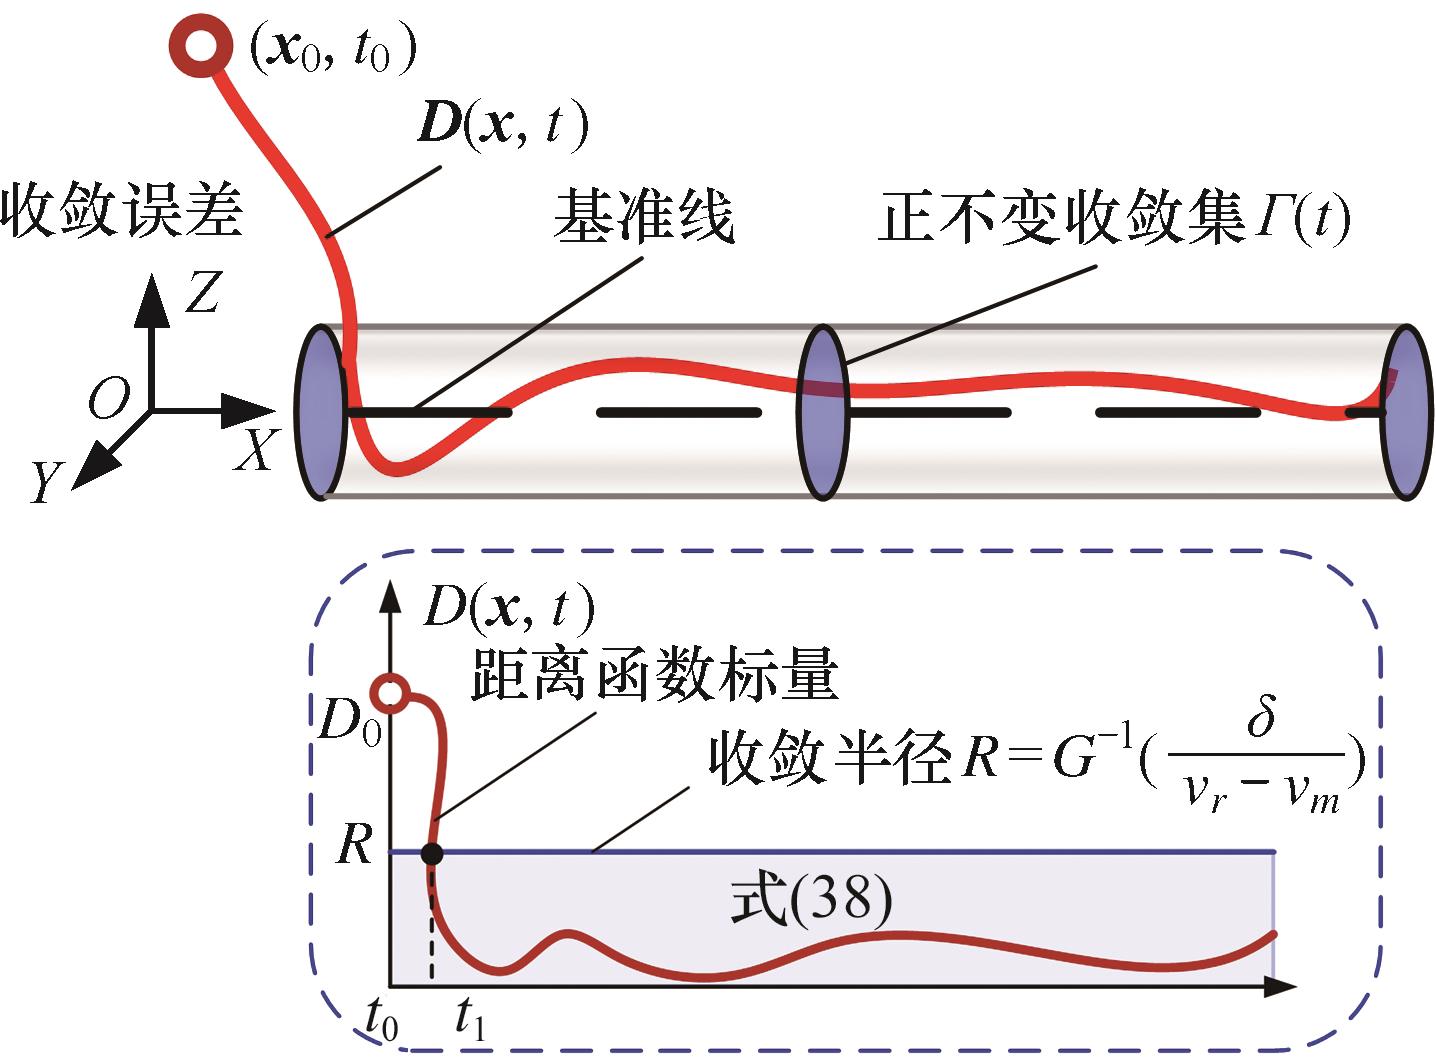
图5 齿尖轨迹收敛的正不变集
Fig.5 Positive invariant set of bucket tip trajectory convergence
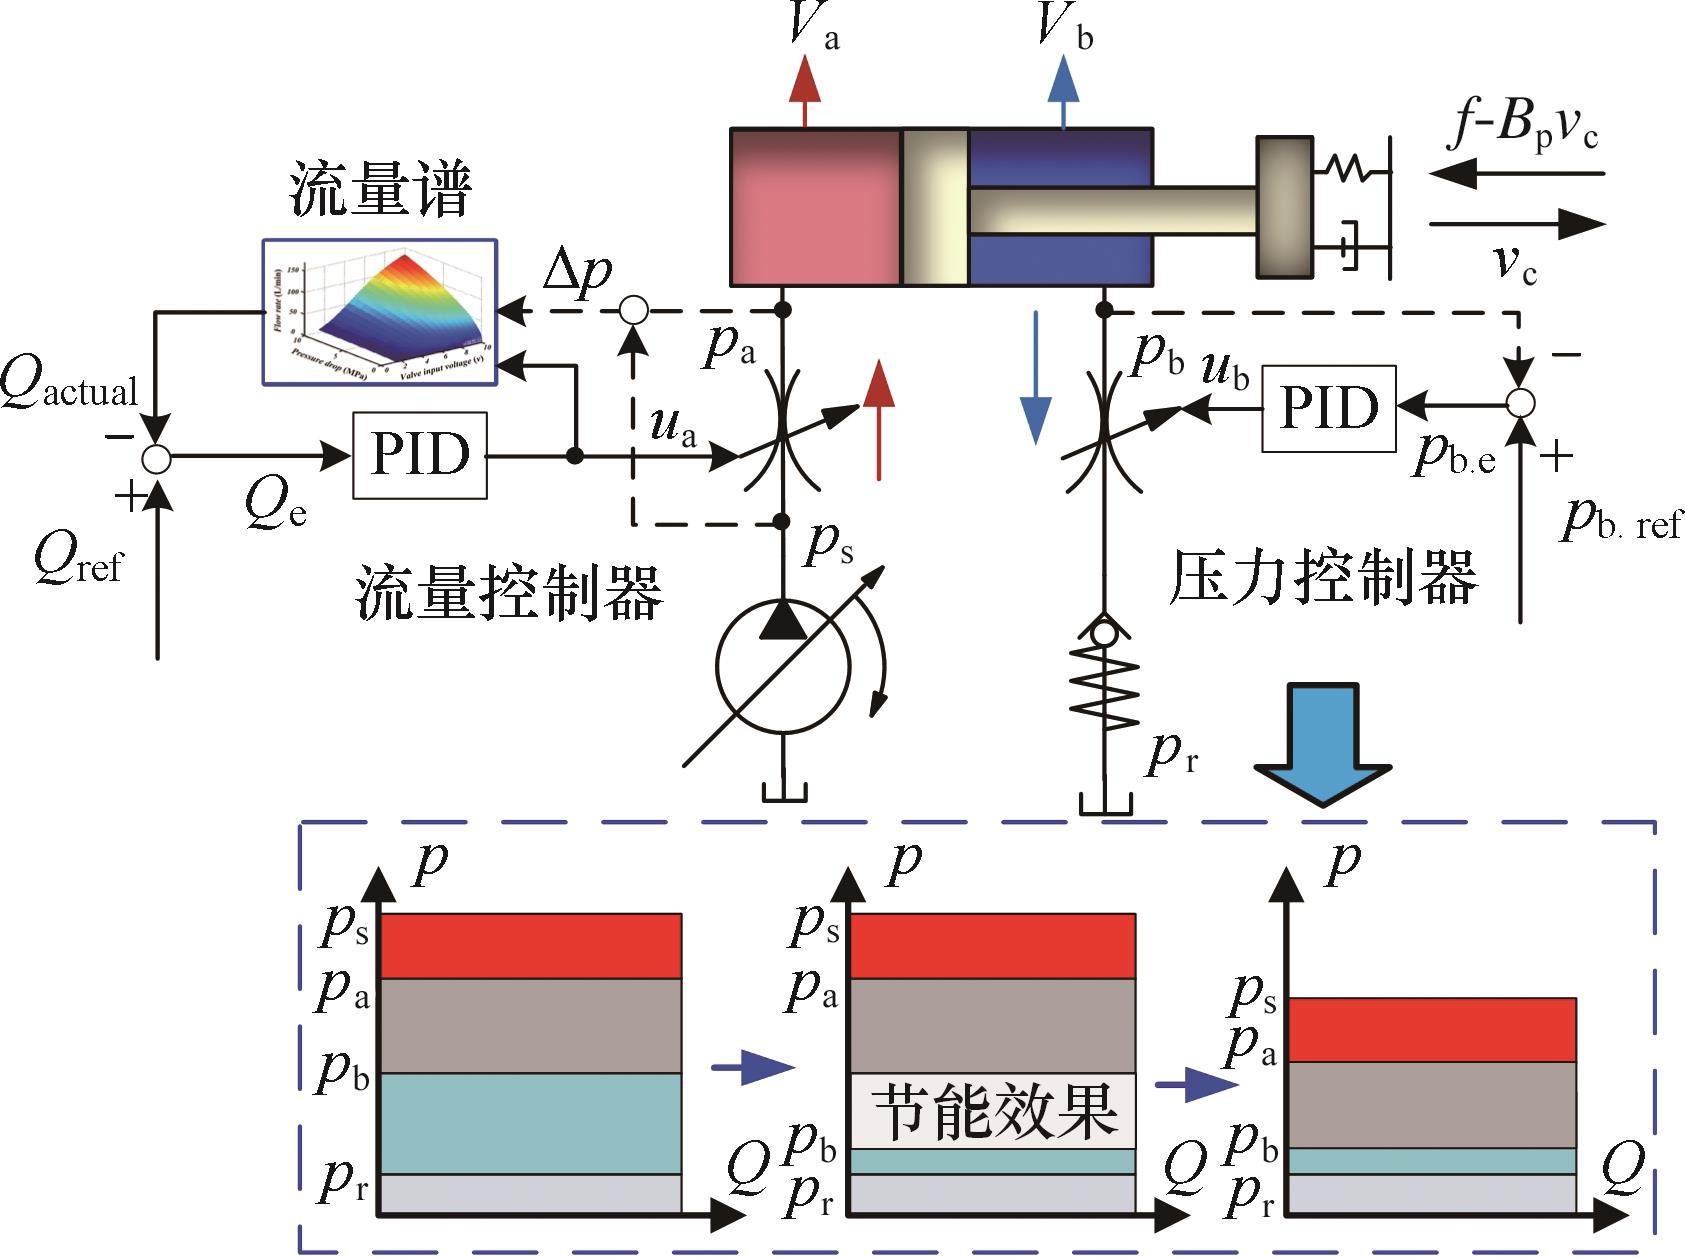
图6 进油流量与回油压力协同调节控制框图
Fig.6 Synergistic regulation control block diagram of oil inlet flow and oil return pressure
| 动臂关节/(°) | 10 | 齿尖速度/(m·s | 0.3 |
|---|---|---|---|
| 斗杆关节角/(°) | -40 | 收敛增益 | 20.5 |
| 铲斗关节角/(°) | -30 | 离散采样点数 | 1000 |
| 固定铰接点 | (0,0) | 定义5 | |
| 轨迹中心 | (2.8,-0.7) | 定义6 | |
| 正方形边长/m | 0.8 | 流量控制器 | (180,15,0) |
| 倒角半径/m | 0.8/7 | 压力控制器 | (120,10,0) |
表1 参数初始值设置
Tab.1 Parameter initial value settings
| 动臂关节/(°) | 10 | 齿尖速度/(m·s | 0.3 |
|---|---|---|---|
| 斗杆关节角/(°) | -40 | 收敛增益 | 20.5 |
| 铲斗关节角/(°) | -30 | 离散采样点数 | 1000 |
| 固定铰接点 | (0,0) | 定义5 | |
| 轨迹中心 | (2.8,-0.7) | 定义6 | |
| 正方形边长/m | 0.8 | 流量控制器 | (180,15,0) |
| 倒角半径/m | 0.8/7 | 压力控制器 | (120,10,0) |
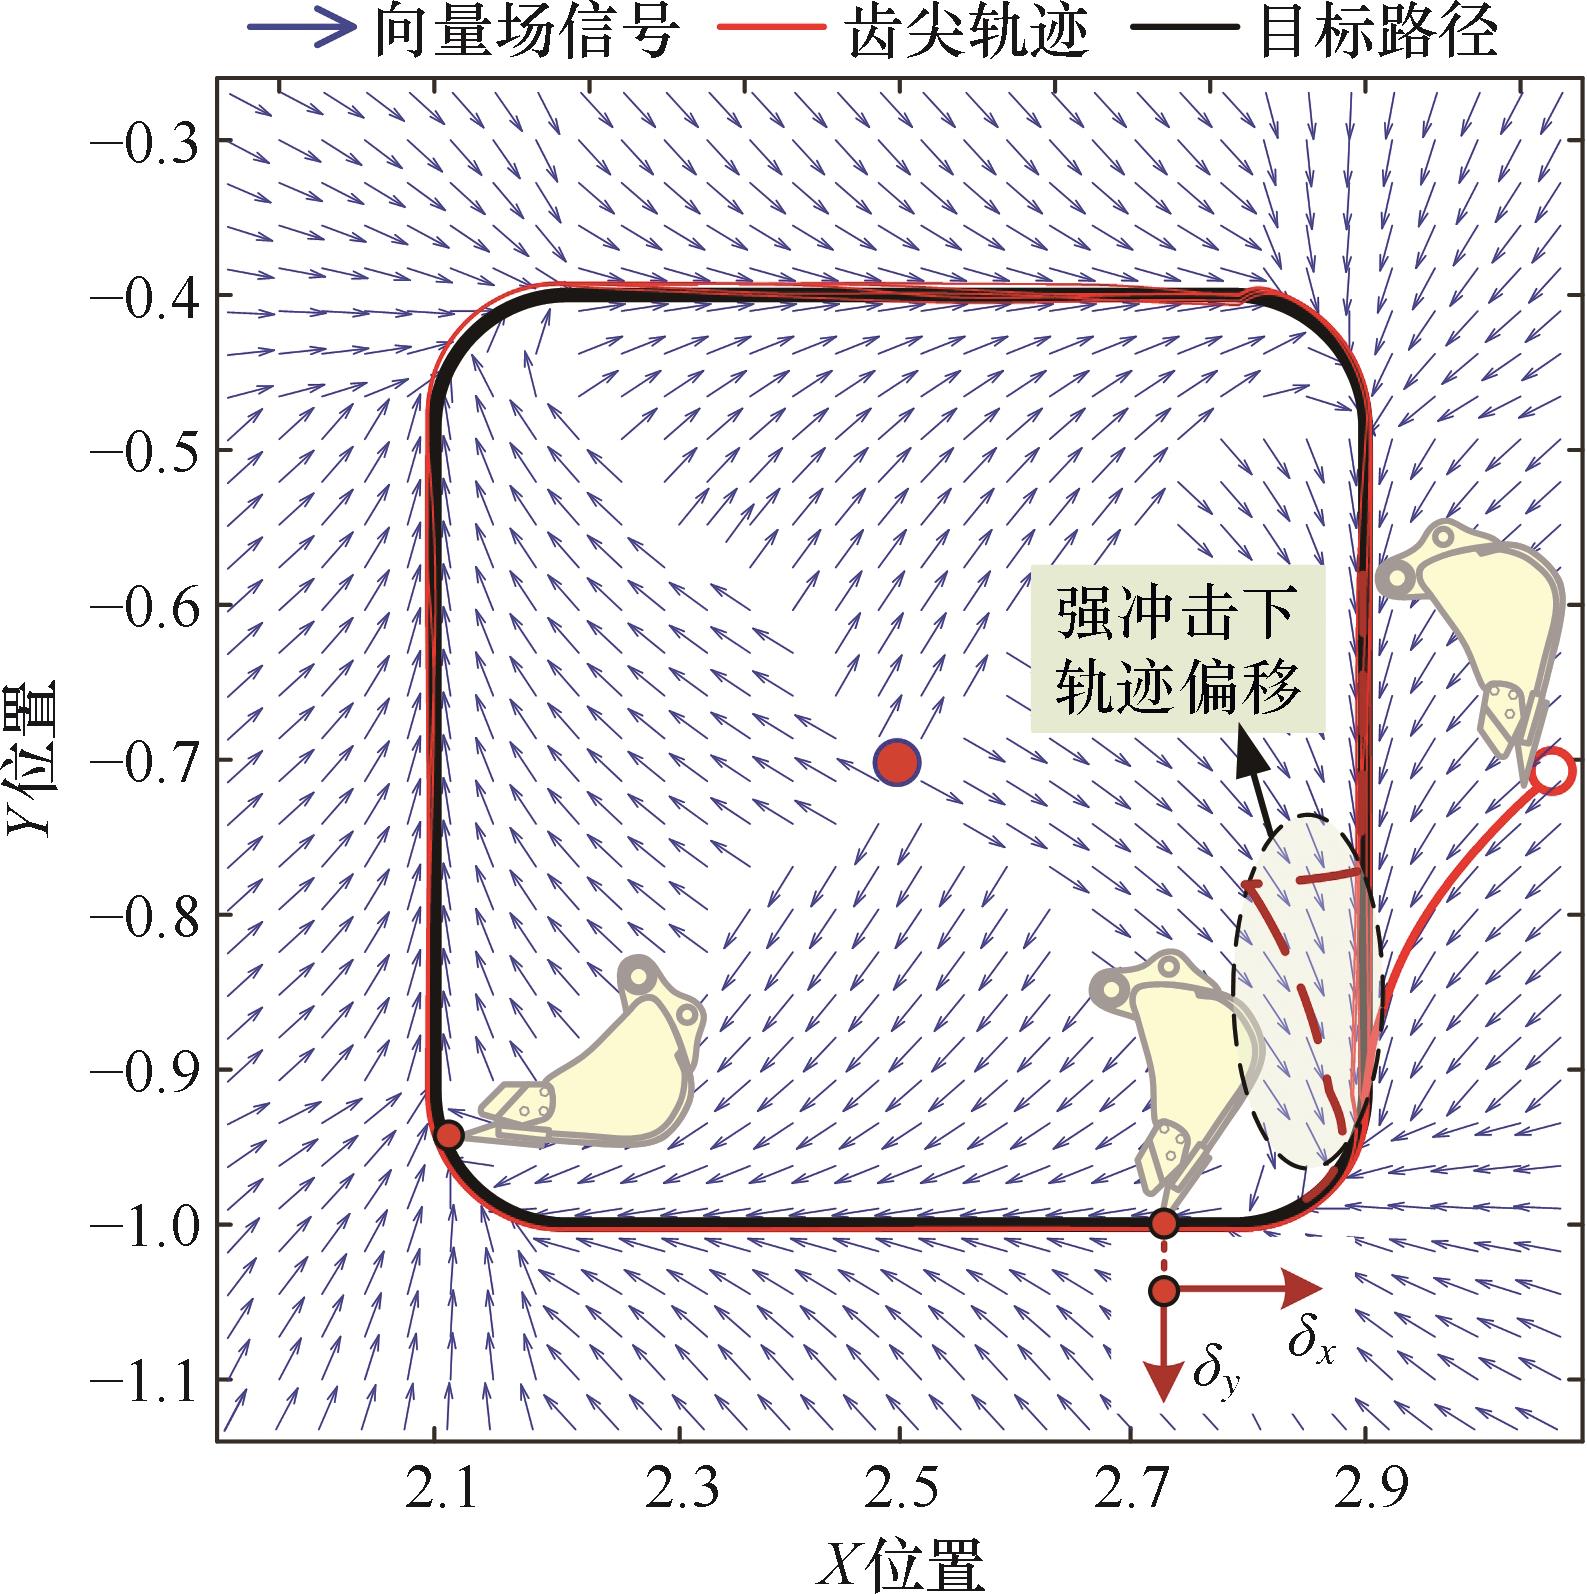
图7 向量场引导下的方形目标路径跟踪挖掘
Fig.7 Square target path tracking mining under the guidance of vector field
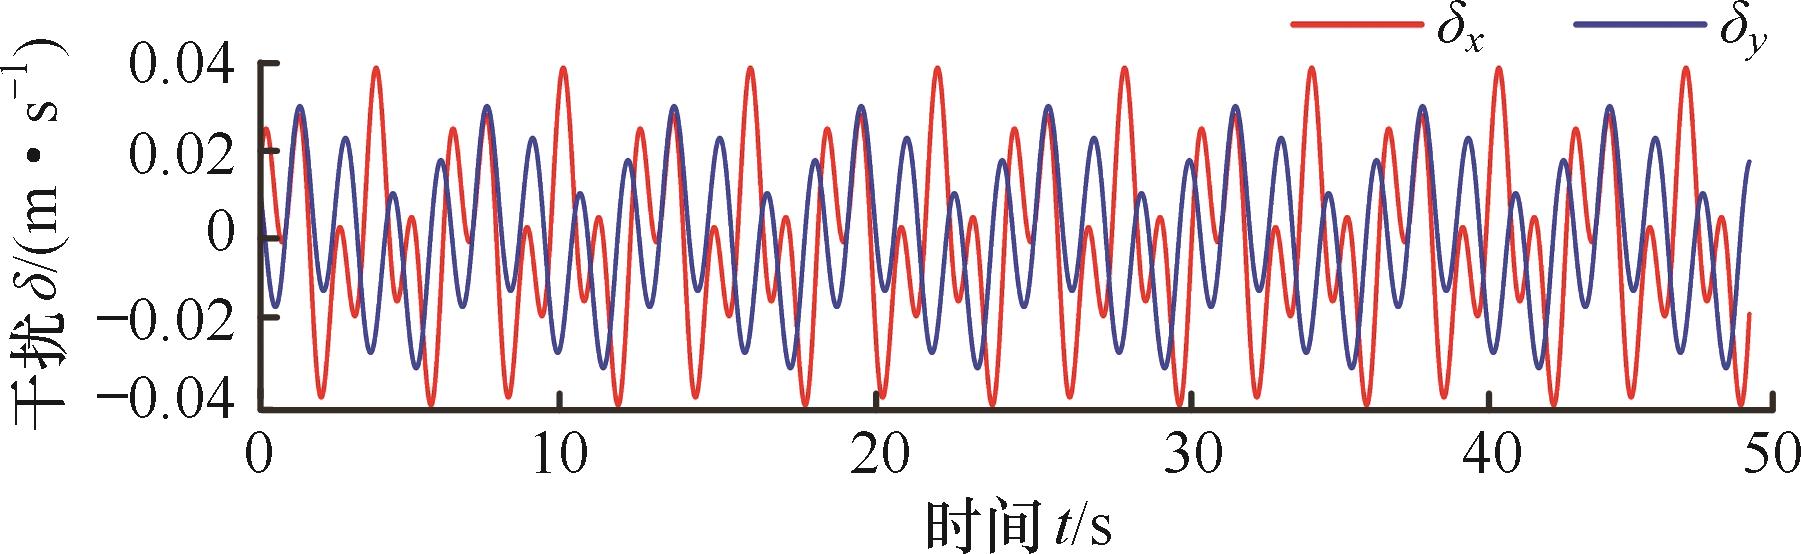
图8 正常挖掘过程齿尖干扰信号模拟
Fig.8 Bucket tip interference signal simulation in normal digging process
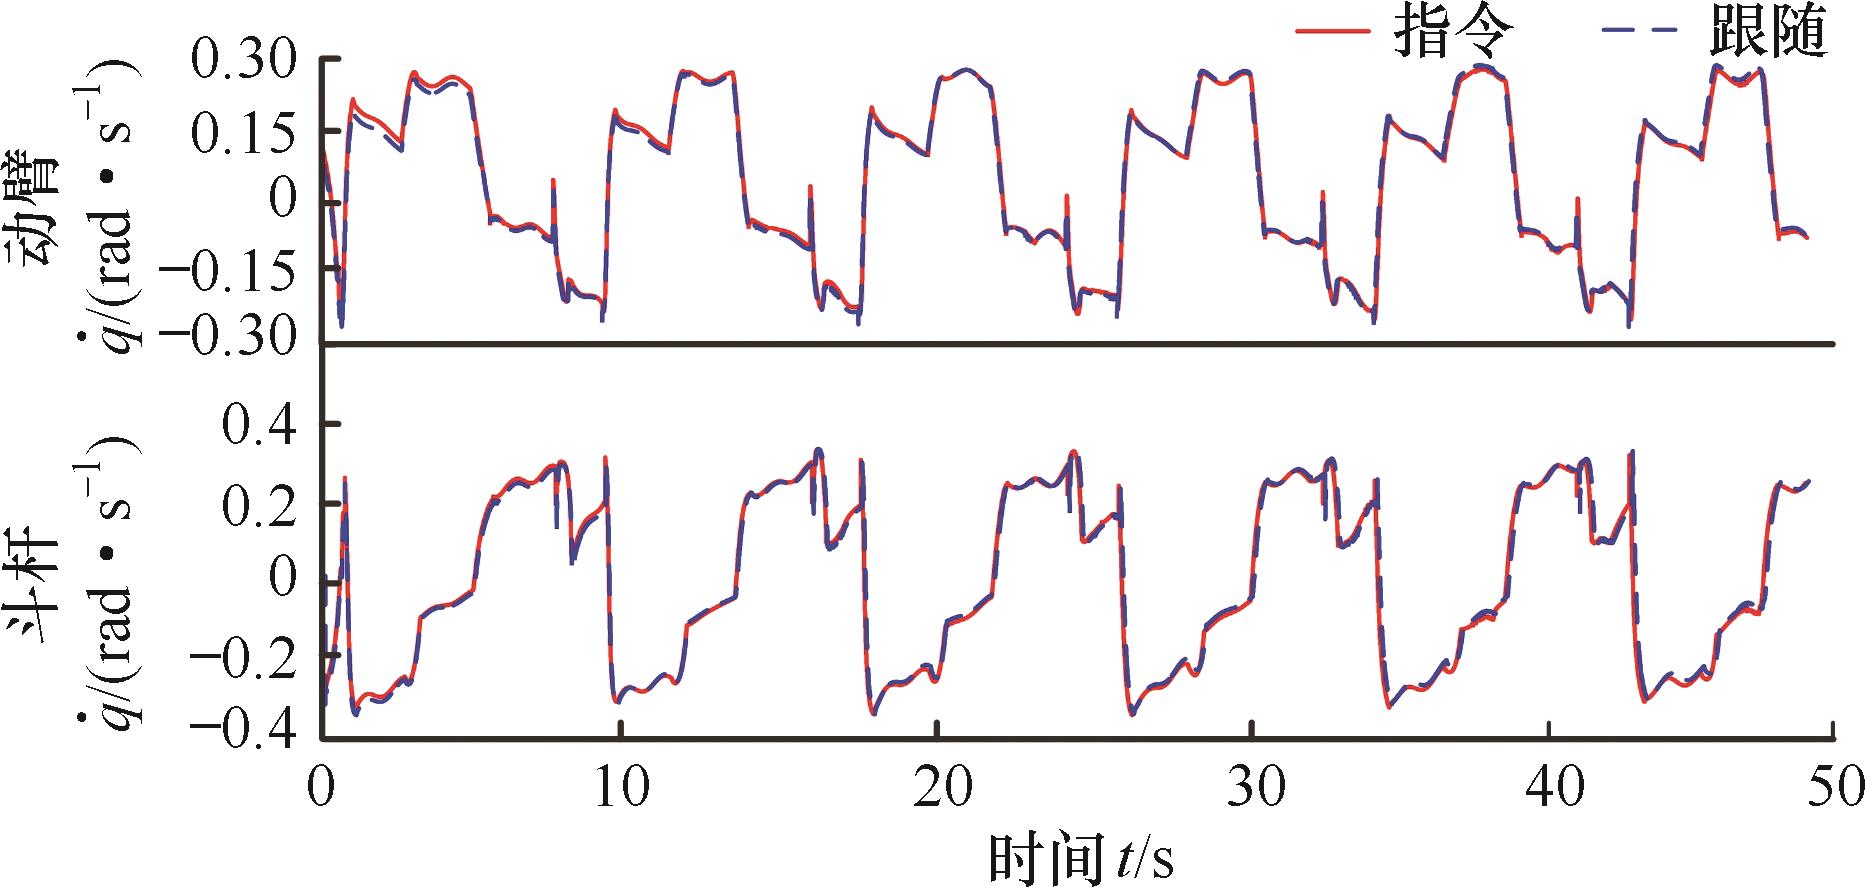
图9 动臂斗杆角速度指令跟踪(方形目标路径)
Fig.9 Boom and arm angular velocity command tracking(square target path)
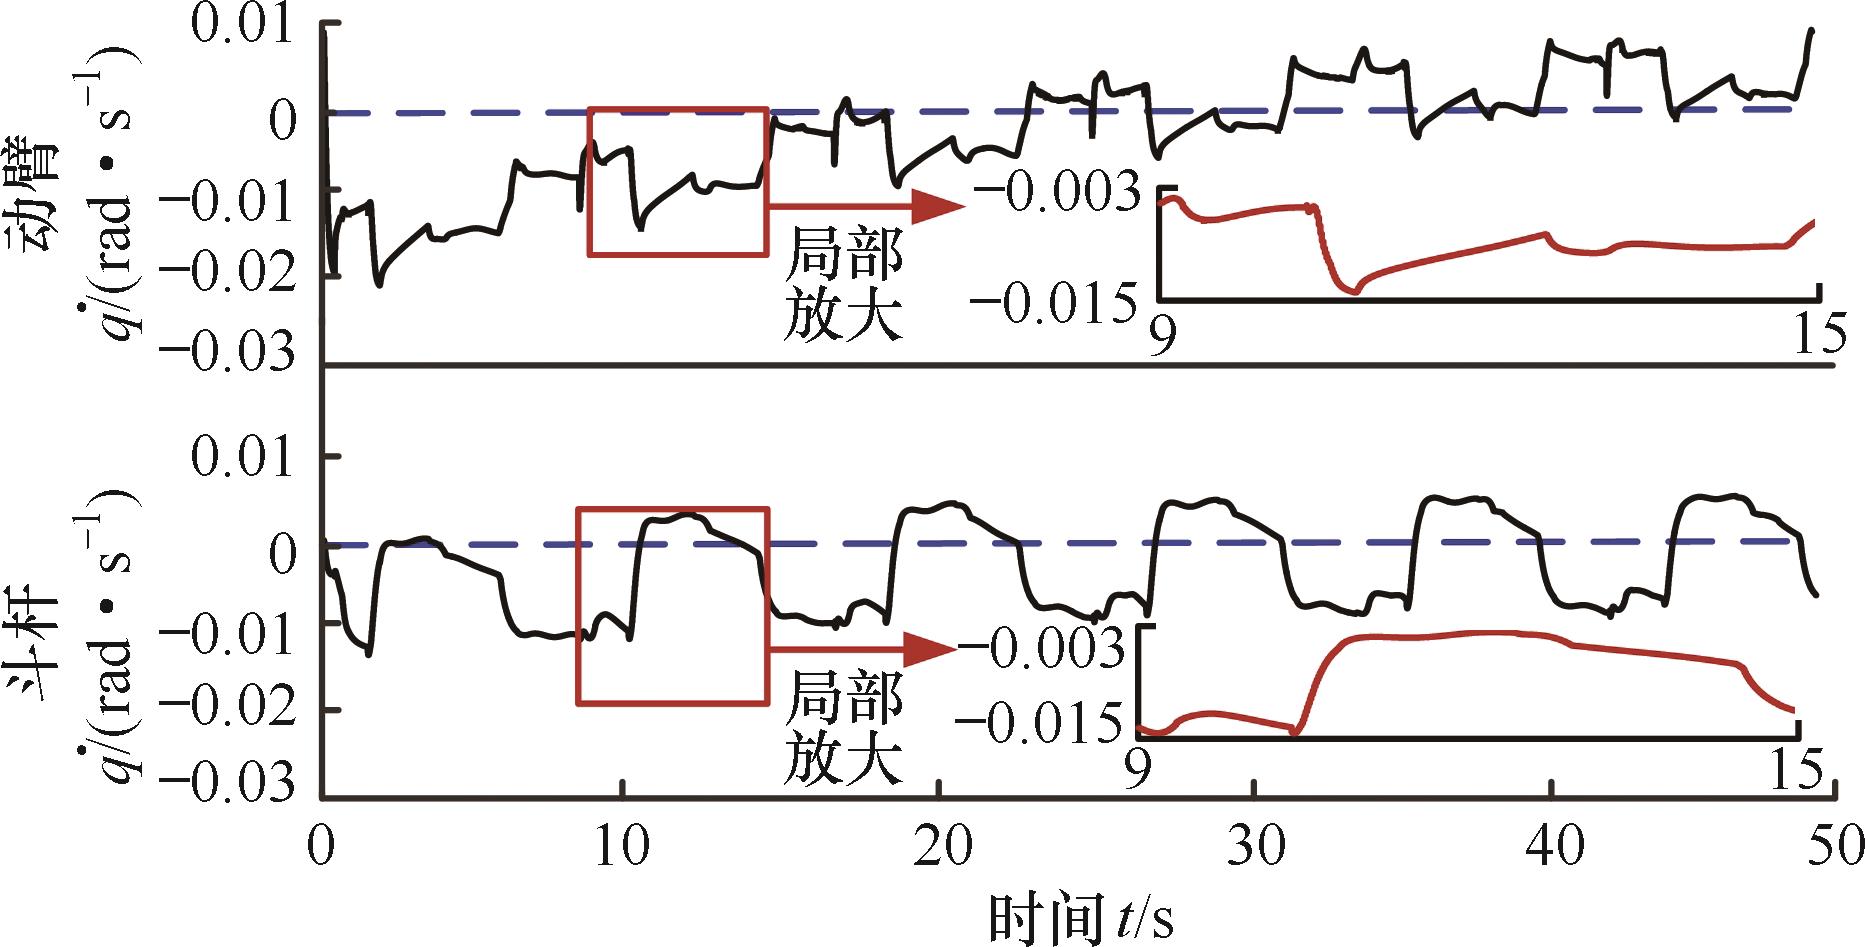
图10 动臂斗杆角速度指令跟踪误差(方形目标路径)
Fig.10 Tracking error of boom and arm angular velocity command(square target path)
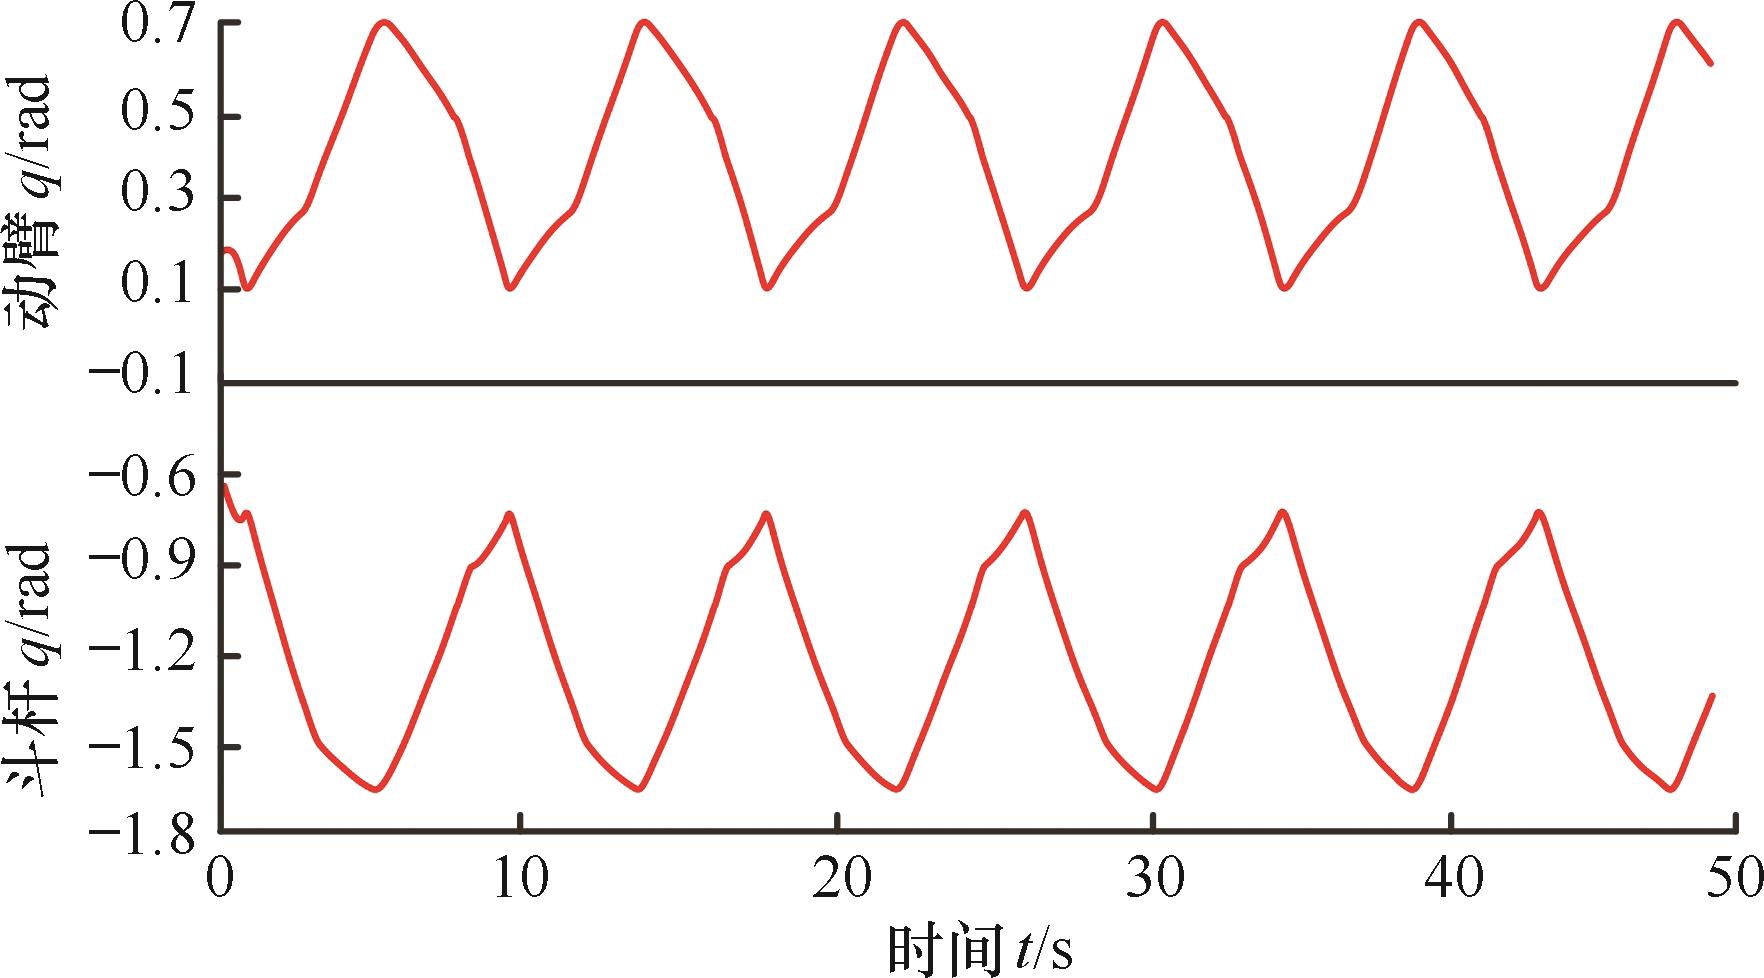
图11 动臂斗杆关节角度(方形目标路径)
Fig.11 Joint angle of boom and arm(square target path)
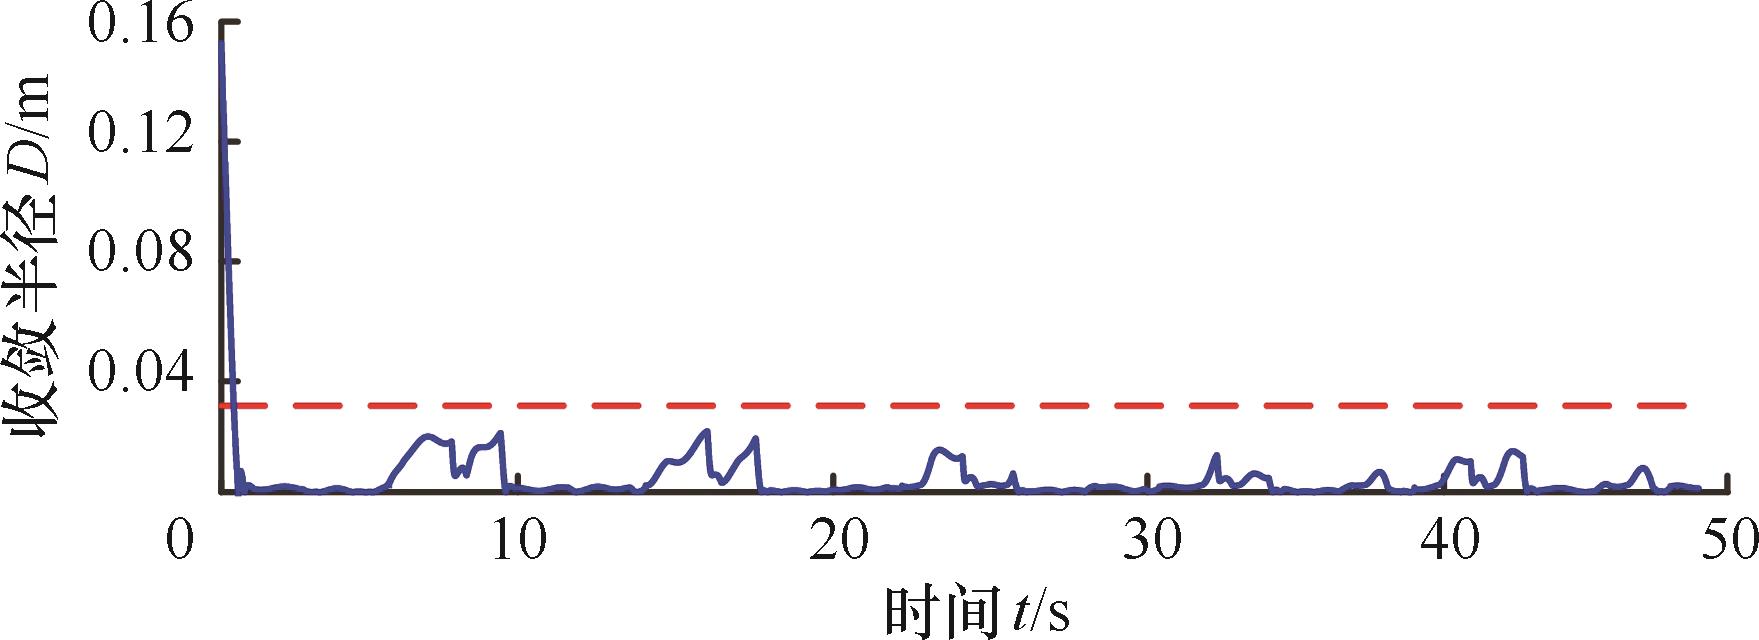
图12 距离函数变化值(方形目标路径)
Fig.12 Change value of distance function(square target path)
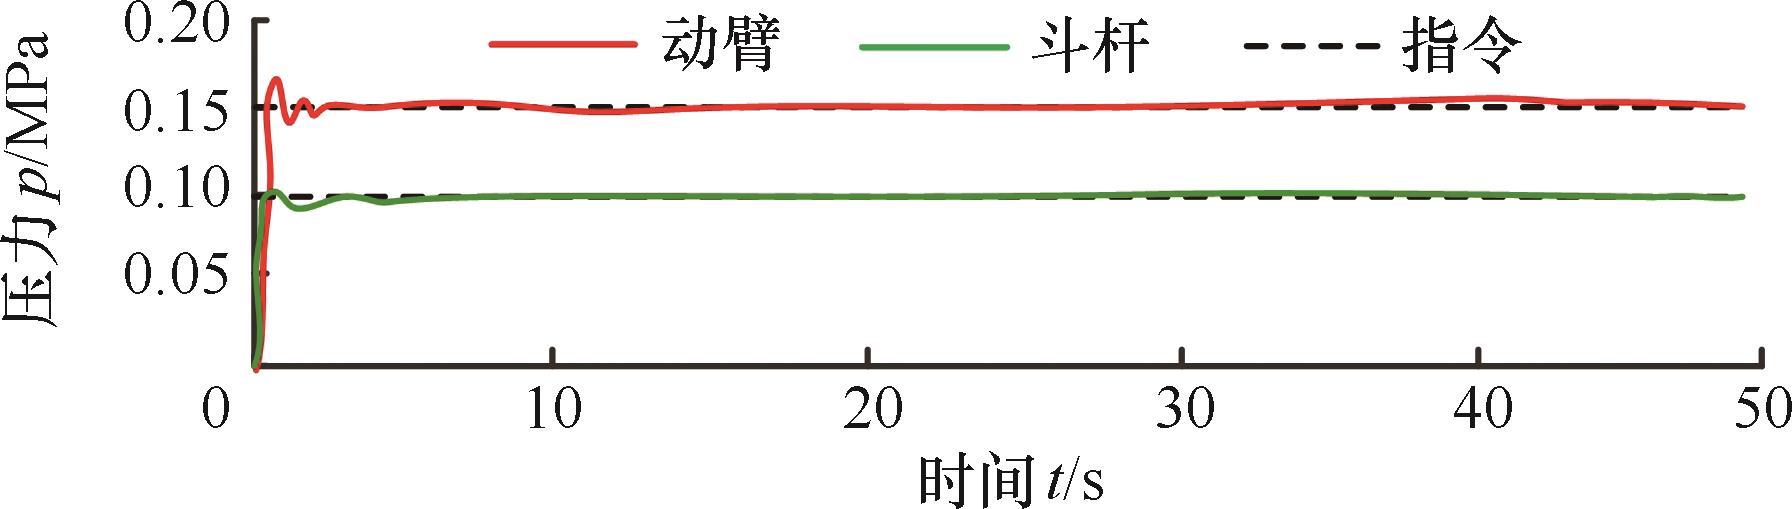
图13 动臂斗杆液压缸回油腔压力指令跟踪
Fig.13 Pressure command tracking of boom and arm hydraulic cylinder return-oil chamber
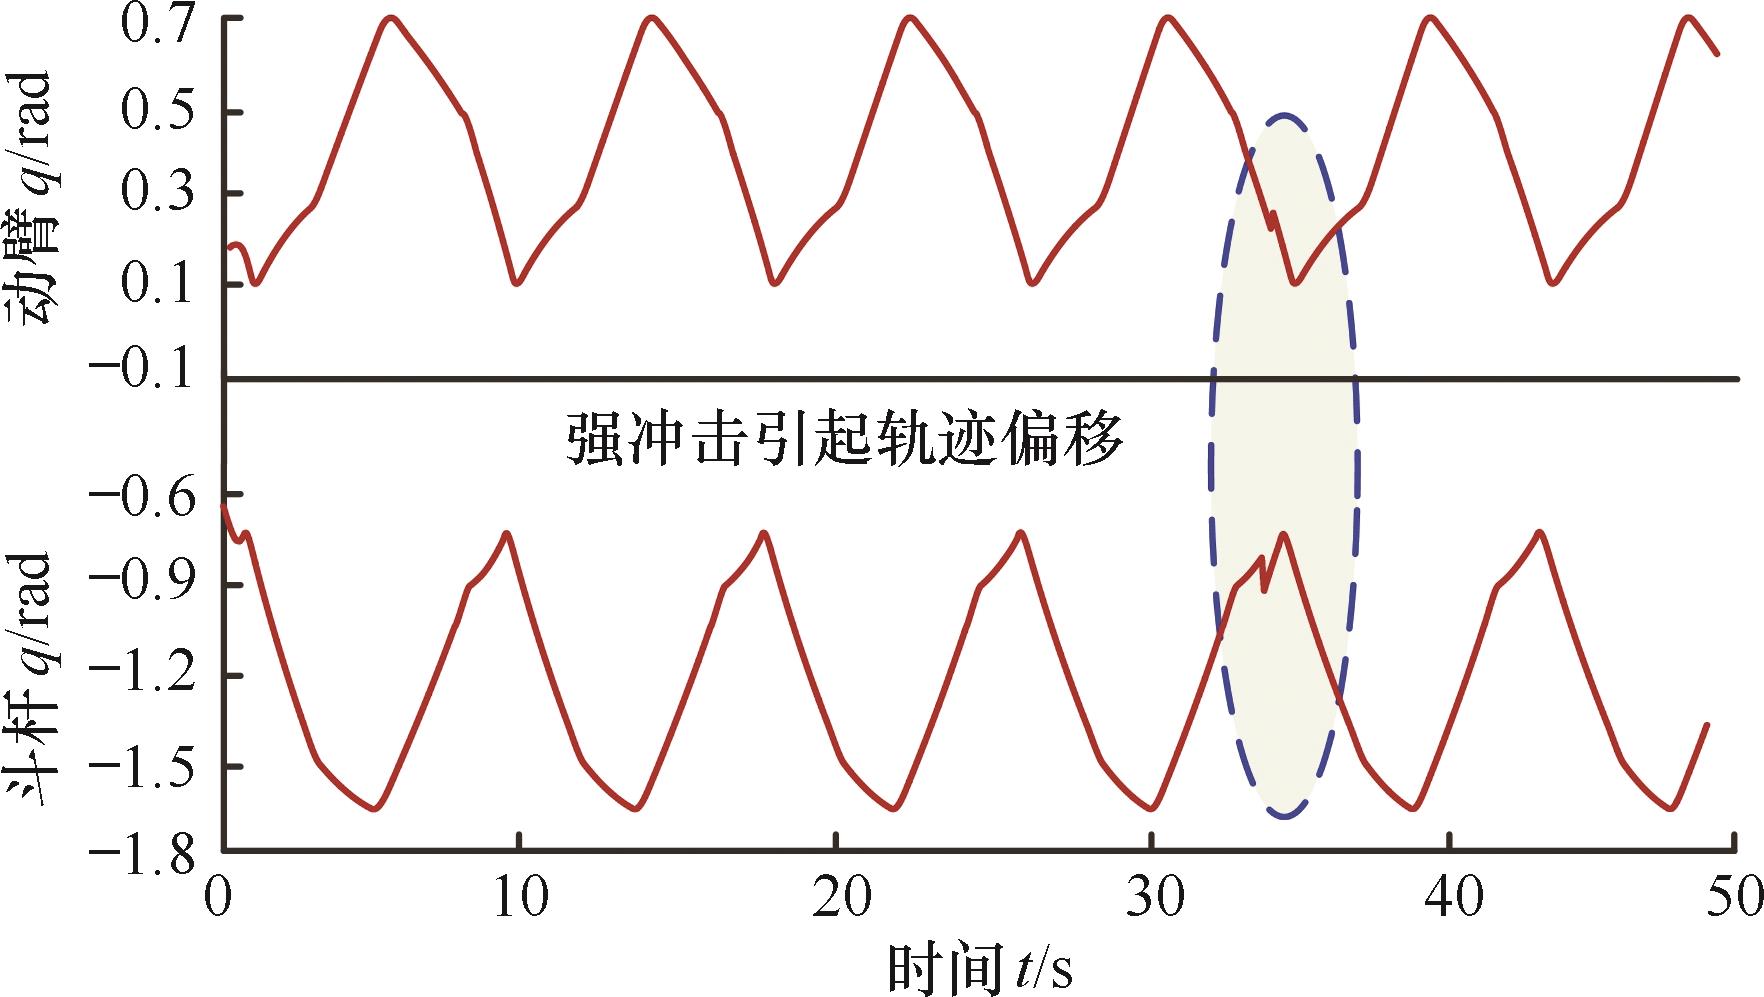
图14 强冲击下动臂斗杆关节角度
Fig.14 Joint angle of boom and arm under strong impact
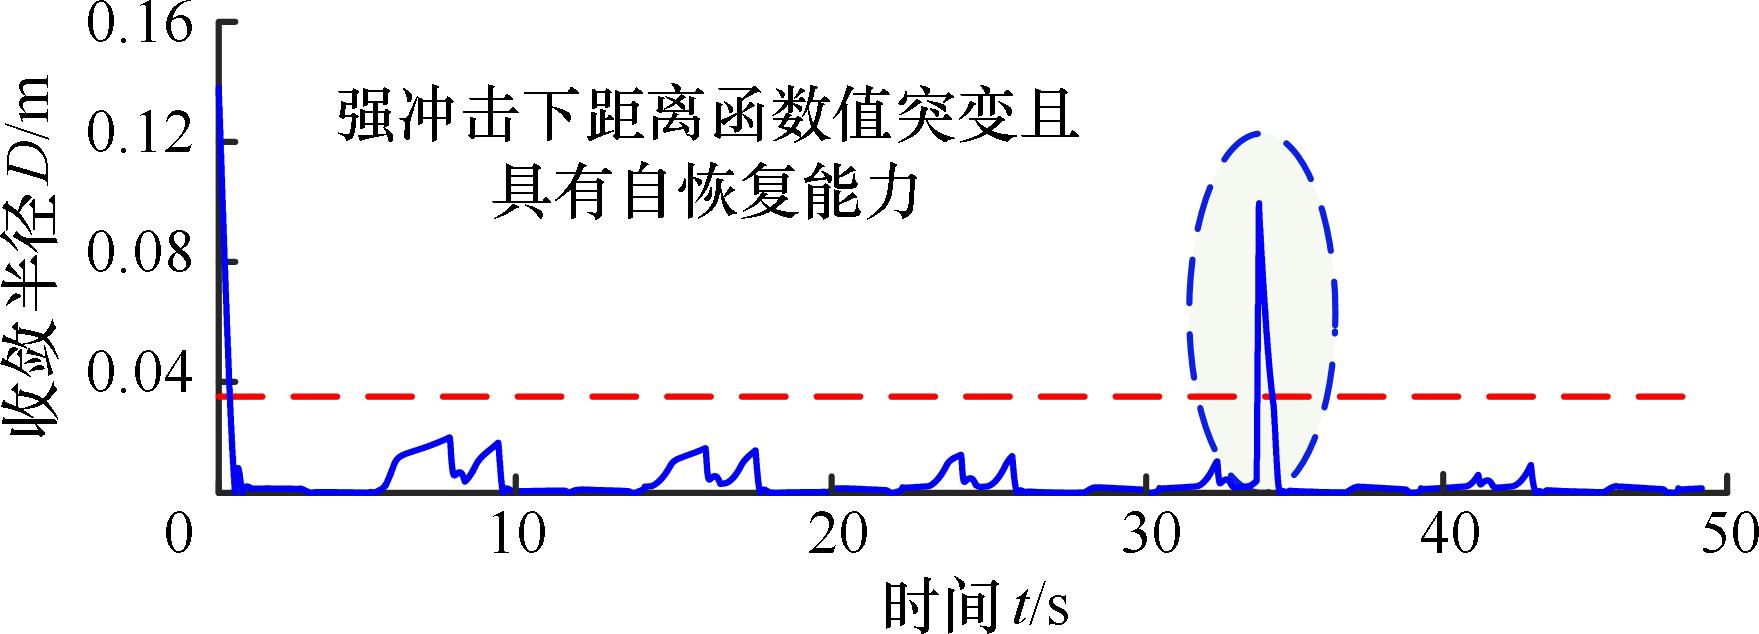
图15 强冲击下距离函数变化值
Fig.15 Change value of distance function under strong impact
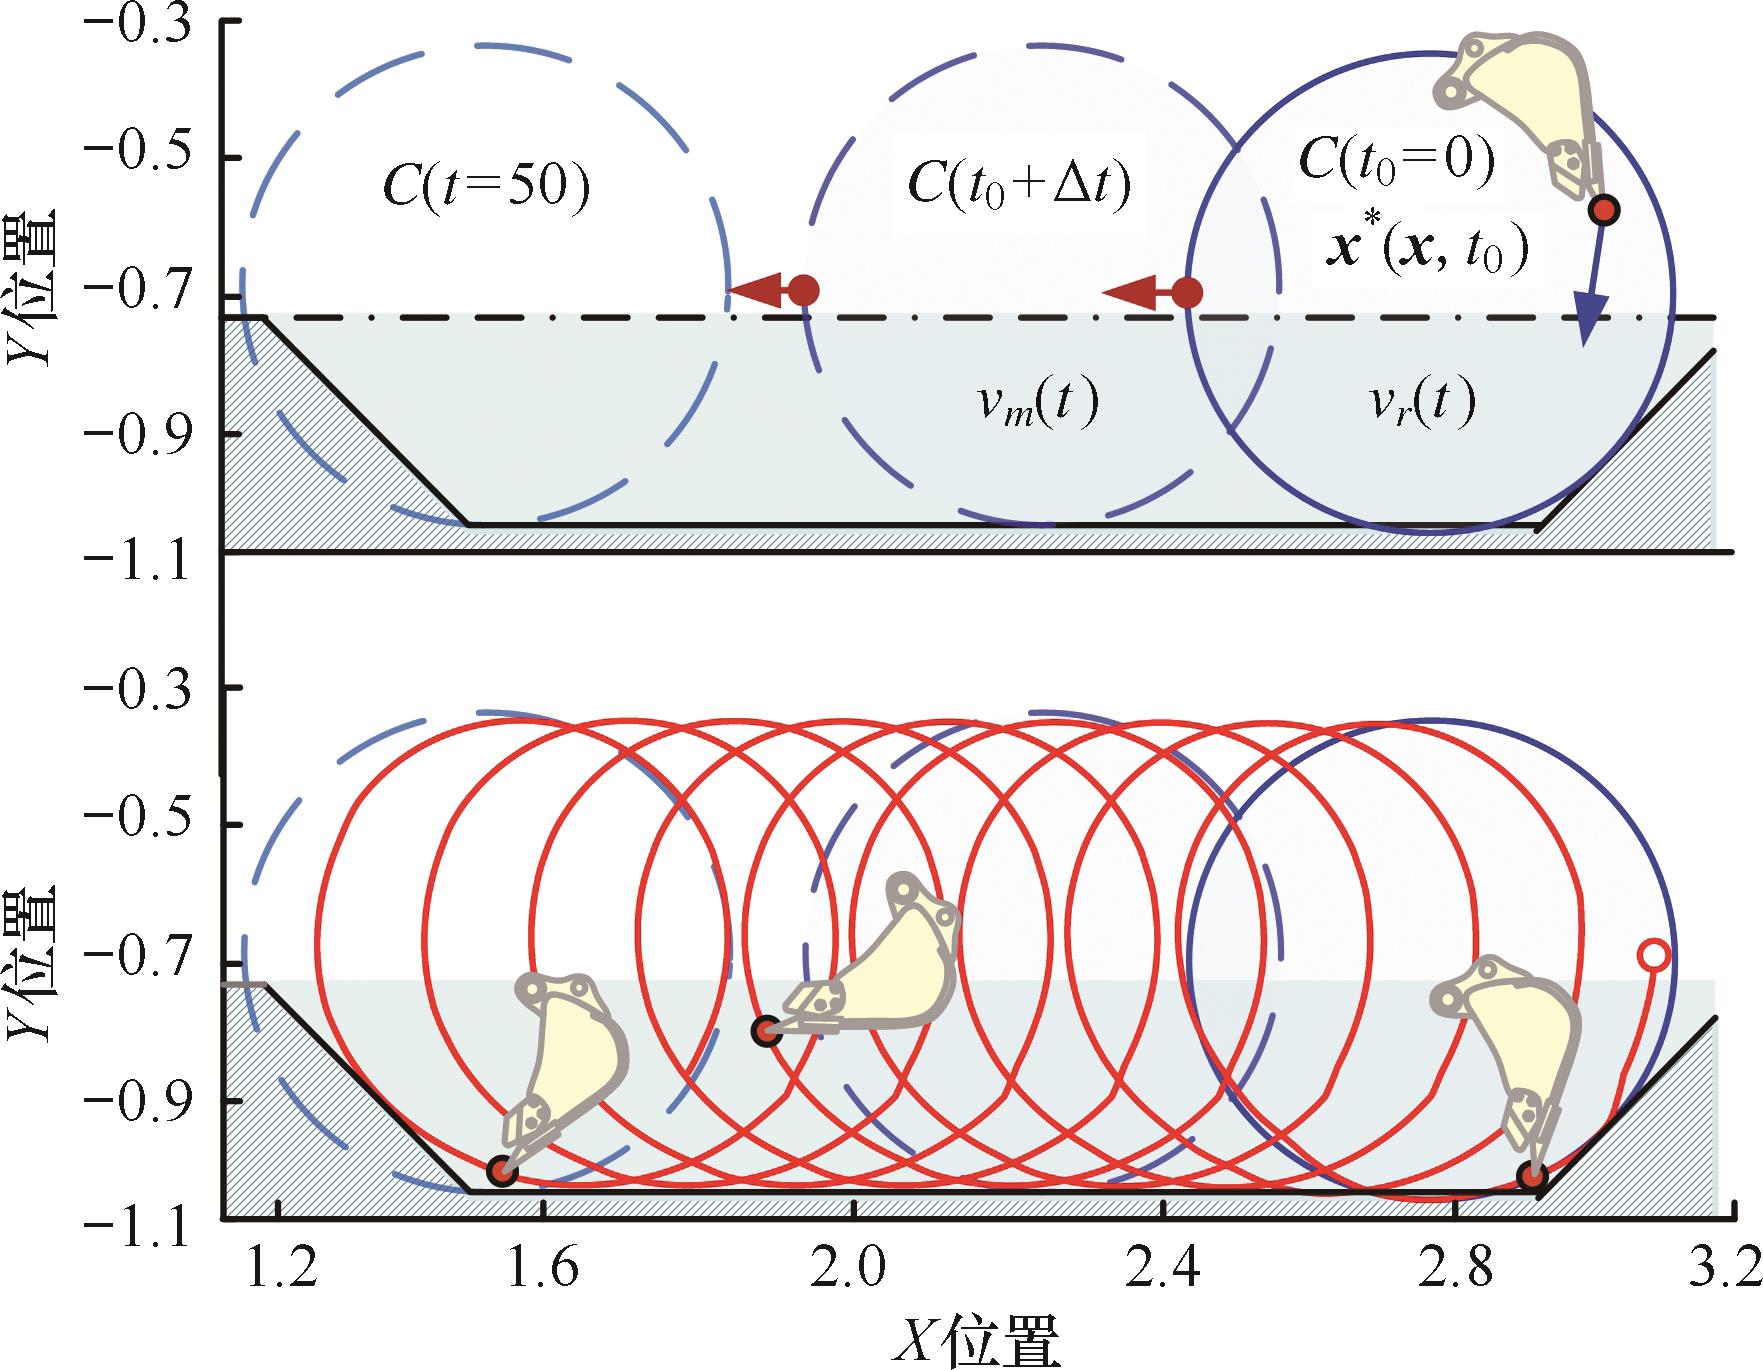
图16 向量场引导下的时变圆形目标路径跟踪挖掘
Fig.16 Time-varying circular target path tracking mining guided by vector field
| 动臂关节角/(°) | 20 | 齿尖速度/(m·s | 0.3 |
|---|---|---|---|
| 斗杆关节角/(°) | -45 | 收敛增益 | 18 |
| 铲斗关节角/(°) | -30 | 离散采样点数 | 2000 |
| 固定铰接点 | (0,0) | 定义5 | |
| 轨迹中心 | (2.8,-0.7) | 定义6 | |
| 圆形半径/m | 0.3 | 流量控制器 | (150,21,0) |
| 路径时变速度/(m·s | 0.025 | 压力控制器 | (115,18,0) |
表2 参数初始值设置
Tab.2 Parameter initial value settings
| 动臂关节角/(°) | 20 | 齿尖速度/(m·s | 0.3 |
|---|---|---|---|
| 斗杆关节角/(°) | -45 | 收敛增益 | 18 |
| 铲斗关节角/(°) | -30 | 离散采样点数 | 2000 |
| 固定铰接点 | (0,0) | 定义5 | |
| 轨迹中心 | (2.8,-0.7) | 定义6 | |
| 圆形半径/m | 0.3 | 流量控制器 | (150,21,0) |
| 路径时变速度/(m·s | 0.025 | 压力控制器 | (115,18,0) |
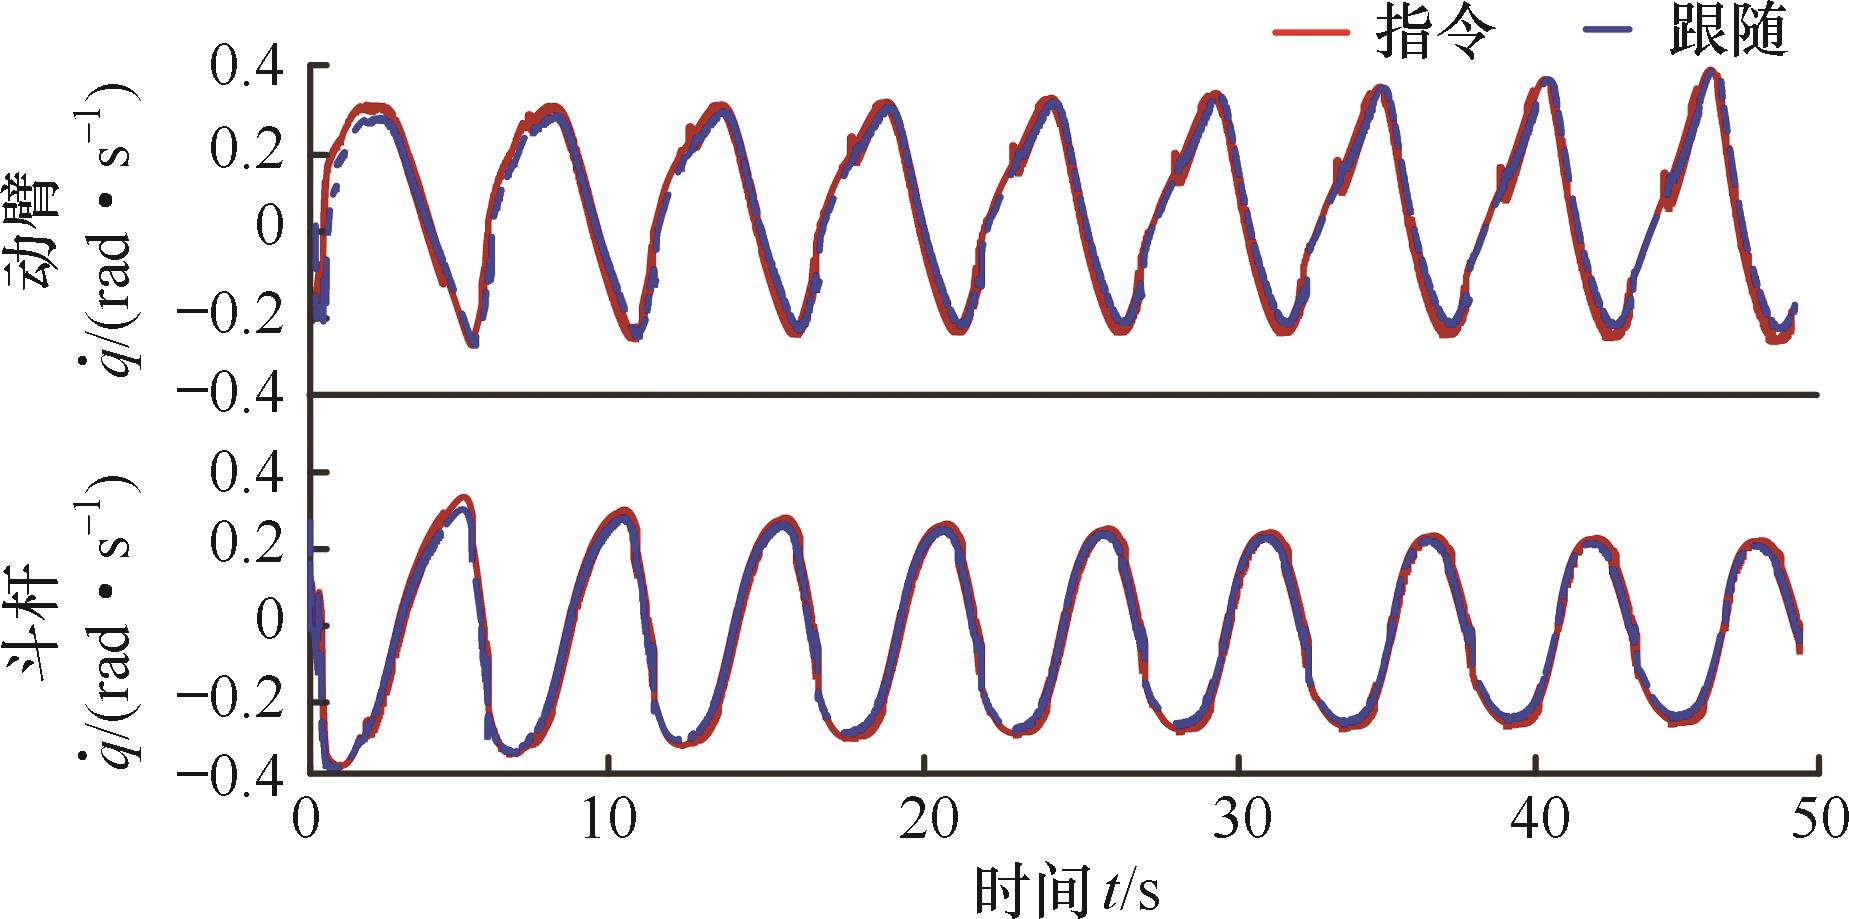
图17 动臂斗杆角速度指令跟踪(圆形目标路径)
Fig.17 Boom and arm angular velocity commandtracking(circular target path)
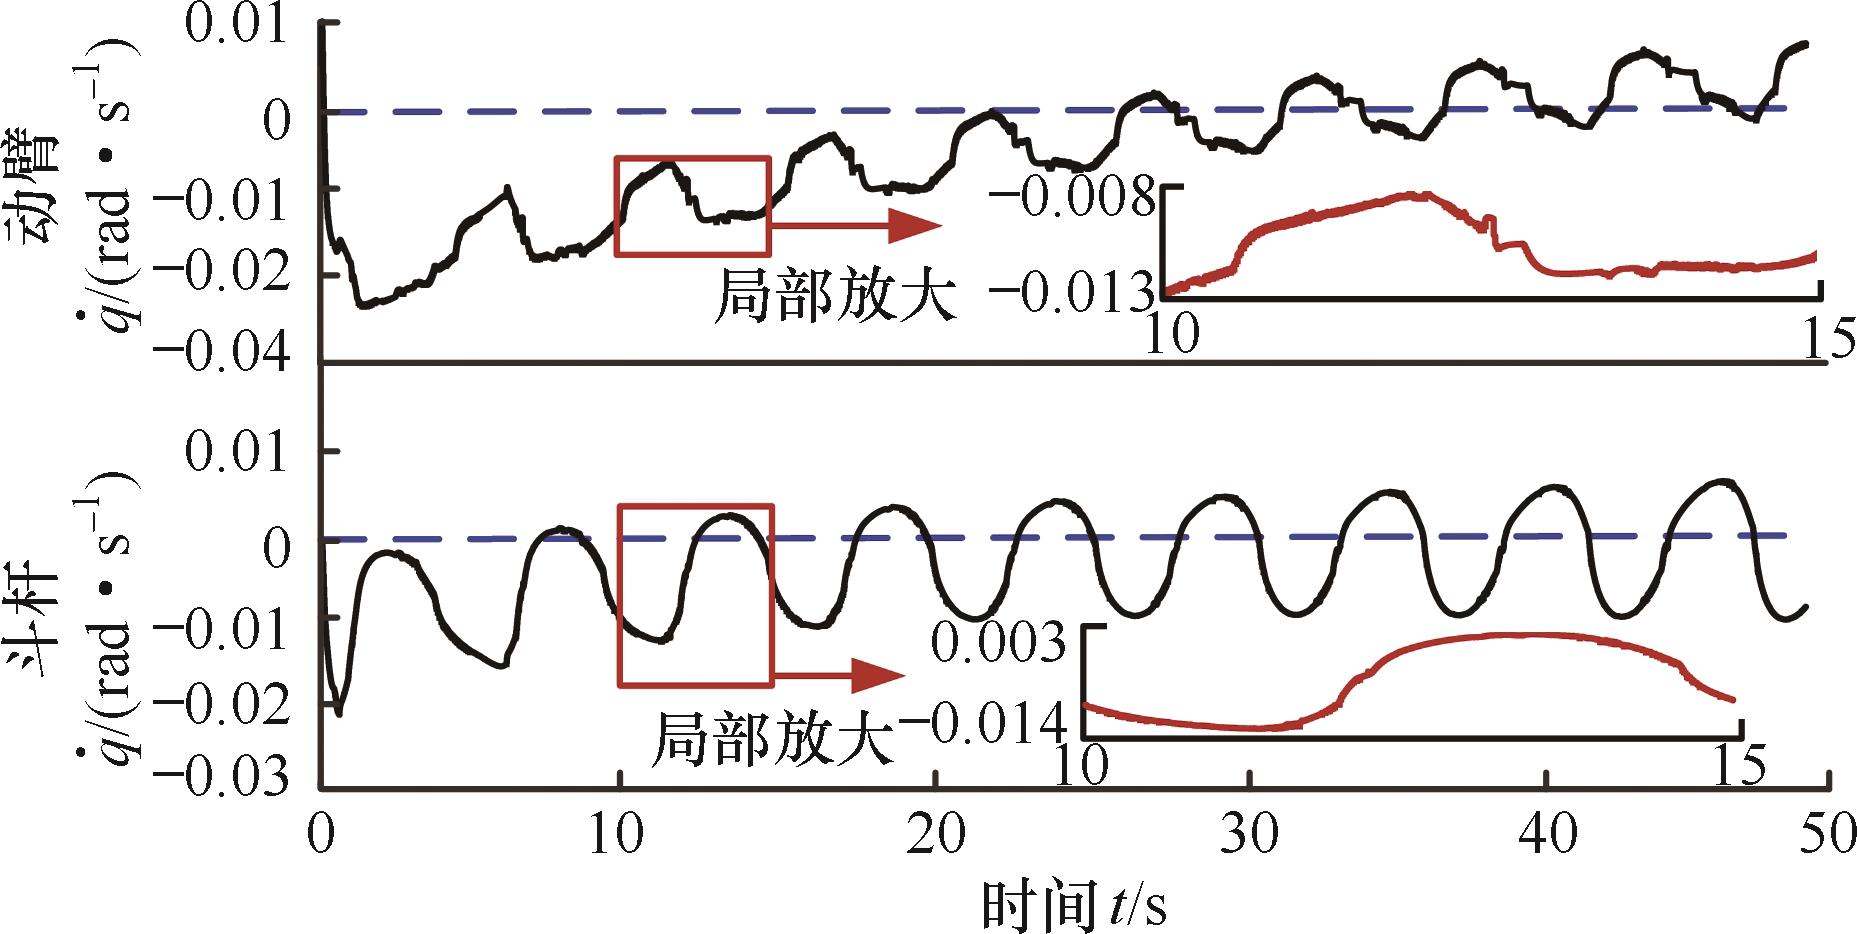
图18 动臂斗杆角速度指令跟踪误差(圆形目标路径)
Fig.18 Tracking error of boom and arm angular velocity command(circular target path)
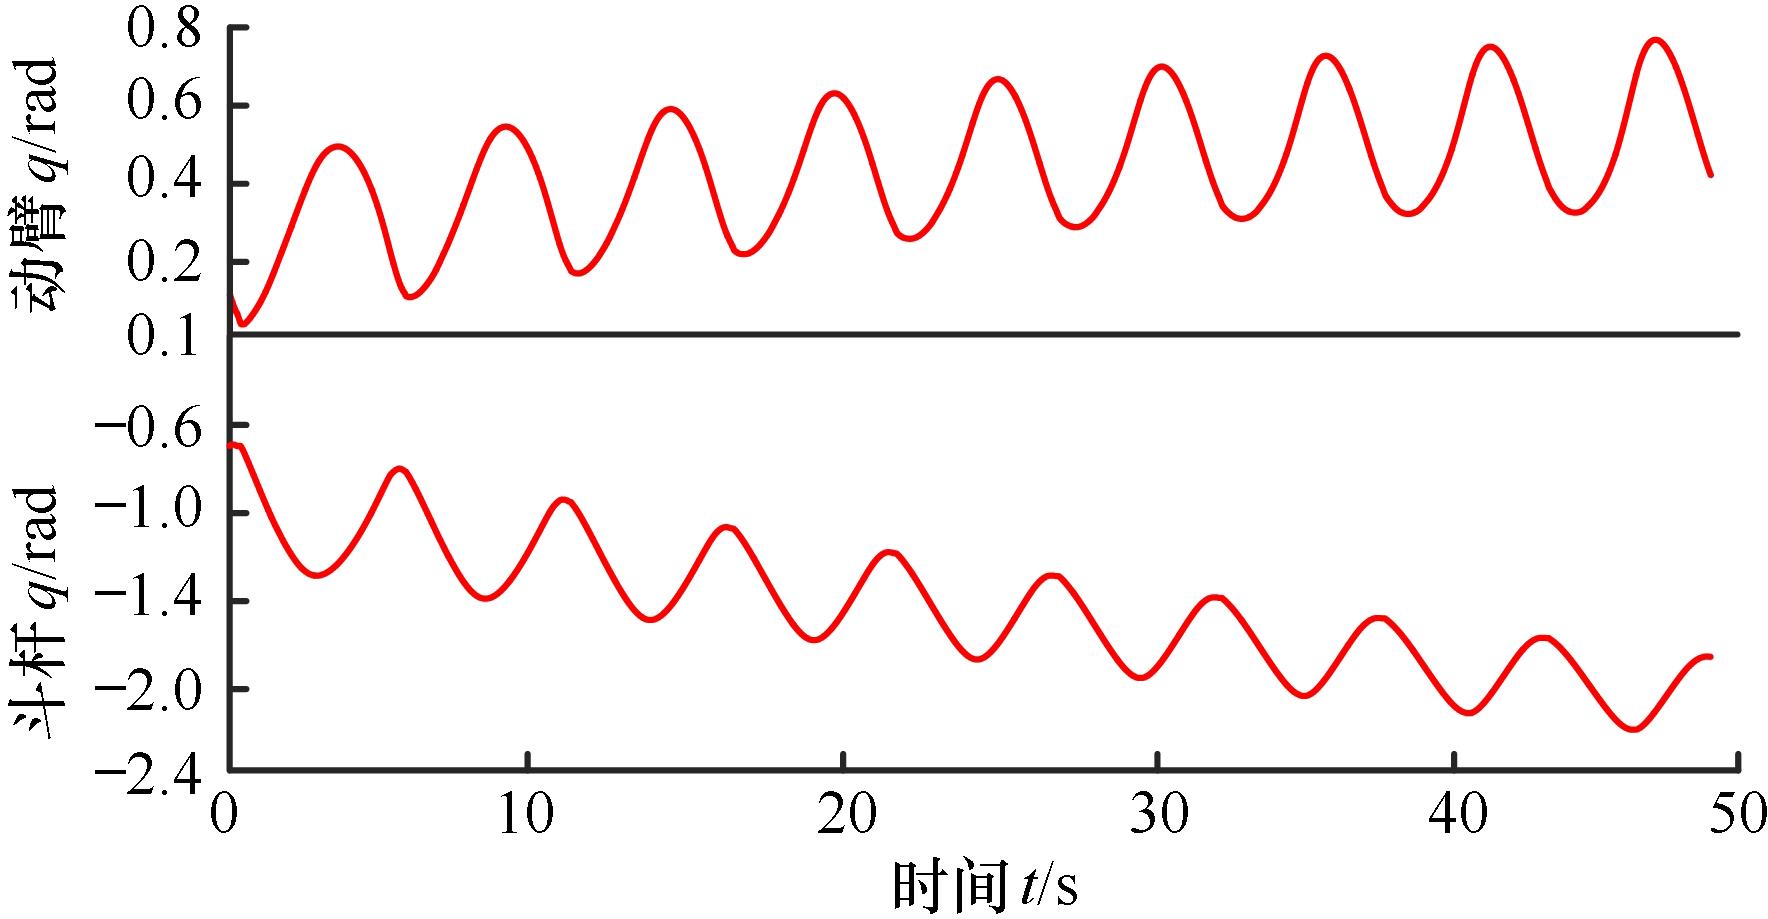
图19 动臂斗杆关节角度(圆形目标路径)
Fig.19 Joint angle of boom and arm(circular target path)
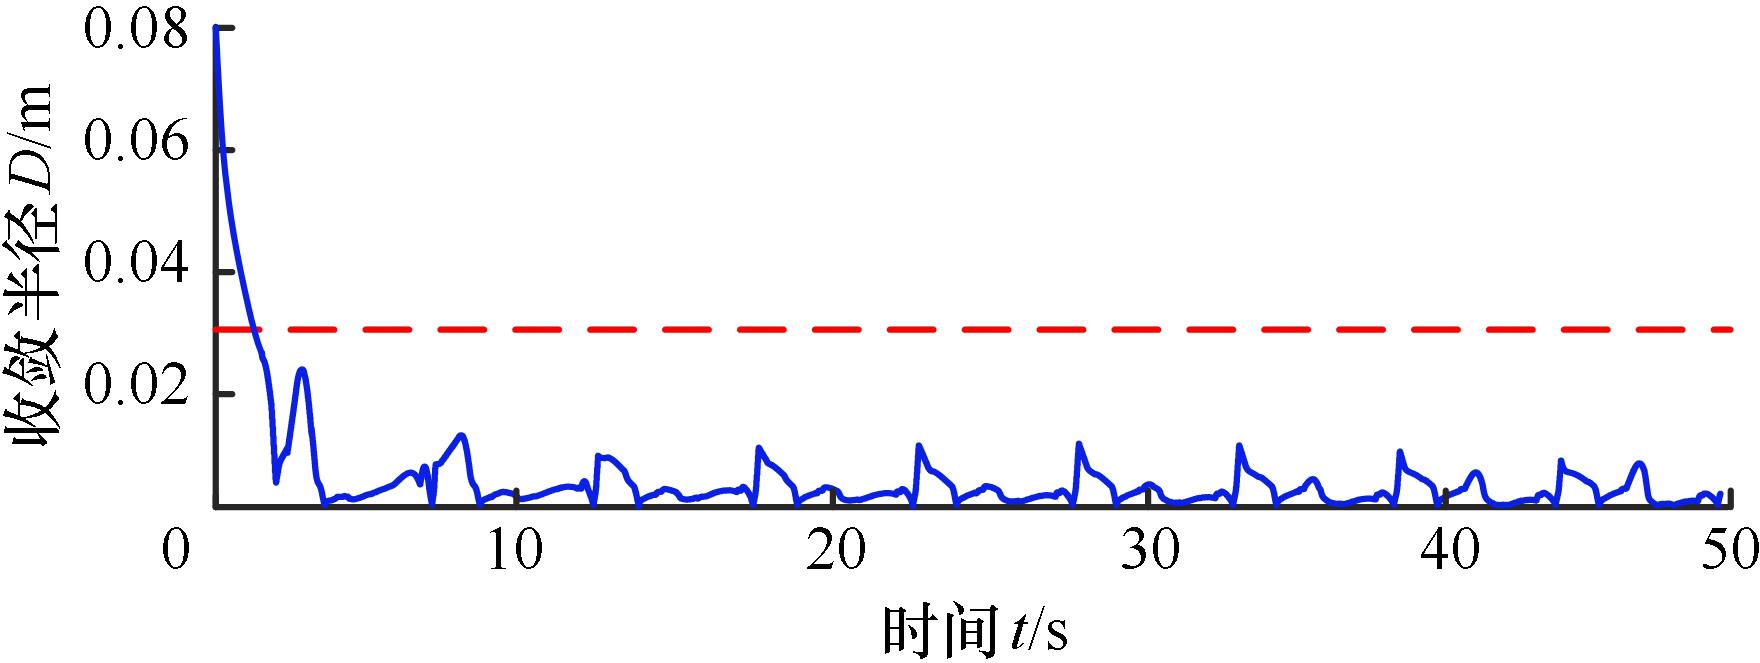
图20 距离函数变化值(圆形目标路径)
Fig. 20 Change value of distance function(circular target path)
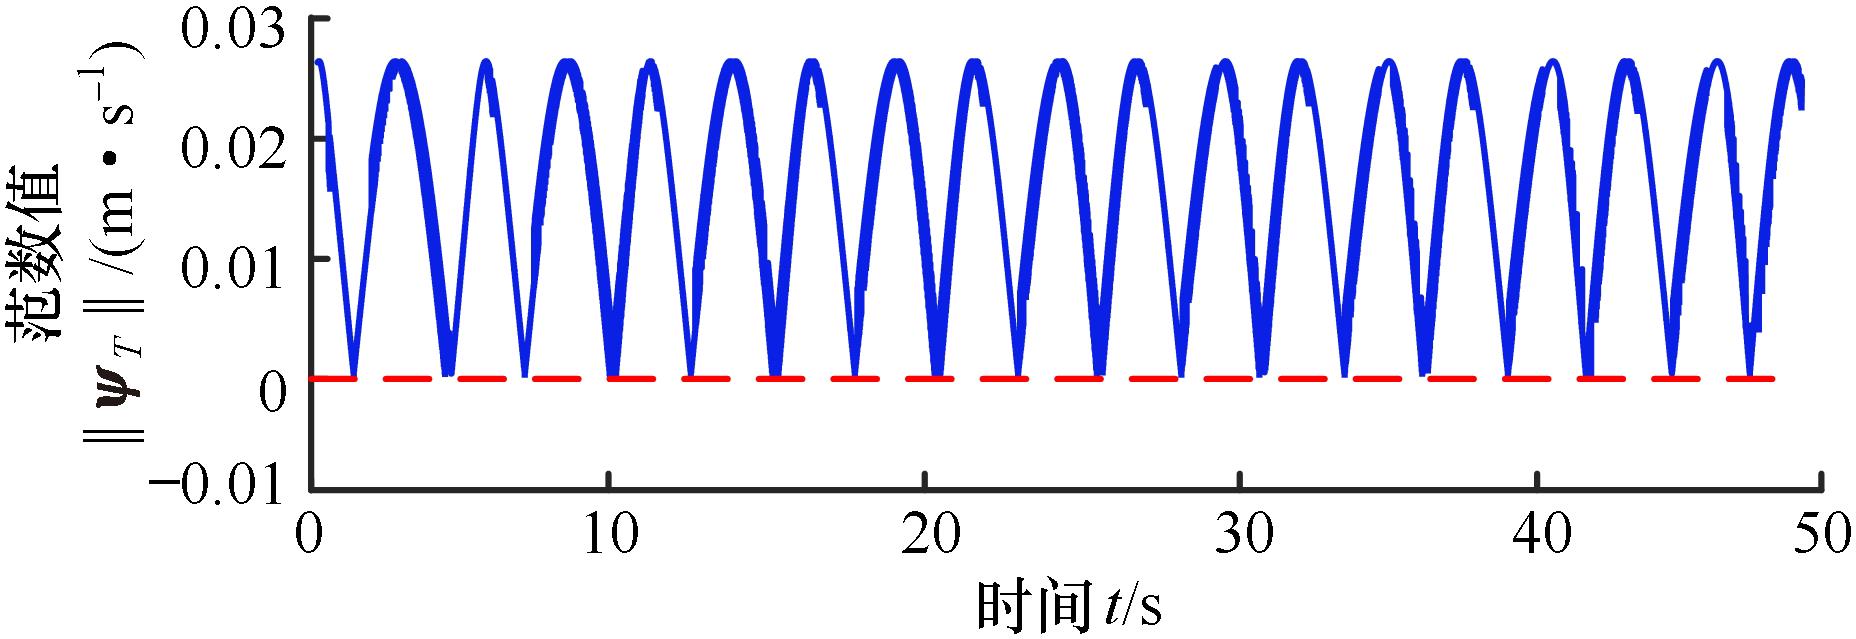
图21 时间前馈补偿项范数值
Fig.21 Time feedforward compensation term value
| [1] | 陈俊翔, 姜宏达, 孔祥东, 等. 考虑时滞因素的负载口独立系统模式切换平稳性研究[J]. 中国机械工程, 2025, 36(3): 414-425. |
| CHEN Junxiang, JIANG Hongda, KONG Xiangdong, et al. Research on Smoothness of Mode Switch of Independent Metering Systems Considering Time-delay Factors[J]. China Mechanical Engineering, 2025, 36(3): 414-425. | |
| [2] | 丁孺琦, 熊文杰, 程敏, 等. 智能化阀口独立电液控制系统安全性能评估[J]. 机械工程学报, 2024, 60(4): 101-112. |
| DING Ruqi, XIONG Wenjie, CHENG Min, et al. Safety Performance Evaluation of the Intelligent Independent-metering Electro-hydraulic Control System[J]. Journal of Mechanical Engineering, 2024, 60(4): 101-112. | |
| [3] | GONCALVES V M, PIMENTA L C A, MAIA C A, et al. Vector Fields for Robot Navigation along Time-varying Curves in $n$ -dimensions[J]. IEEE Transactions on Robotics, 2010, 26(4): 647-659. |
| [4] | REZENDE A M C, GONÇALVES V M, RAFFO G V, et al. Robust Fixed-wing UAV Guidance with Circulating Artificial Vector Fields[C]∥IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Madrid, 2019: 5892-5899. |
| [5] | ZHOU Yu, BAUTISTA J, YAO Weijia, et al. Inverse Kinematics on Guiding Vector Fields for Robot Path Following[C]∥2025 IEEE International Conference on Robotics and Automation (ICRA). Atlanta, 2025: 8635-8641. |
| [6] | ZHU P, ZHOU Z, YAO W, et al. HI-GVF: Shared Control based on Human-influenced Guiding Vector Fields for Human-multi-robot Cooperation[C]∥IEEE International Conference on Robotics and Automation. Atlanta, 2025: 10.48550/arXiv.2502.11370. |
| [7] | HU Binbin, ZHANG Haitao, YAO Weijia, et al. Spontaneous-ordering Platoon Control for Multirobot Path Navigation Using Guiding Vector Fields[C]∥IEEE Transactions on Robotics. IEEE, 2023: 2654-2668. |
| [8] | LAWRENCE D, FREW E, PISANO W. Lyapunov Vector Fields for Autonomous UAV Flight Control[C]∥AIAA Guidance, Navigation and Control Conference and Exhibit. Hilton Head, 2007: AIAA2007-6317. |
| [9] | REZENDE A M C, GONCALVES V M, PIMENTA L C A. Constructive Time-varying Vector Fields for Robot Navigation[J]. IEEE Transactions on Robotics, 2022, 38(2): 852-867. |
| [10] | LIANG Yueqian, JIA Yingmin, DU Junping, et al. Vector Field Guidance for Three-dimensional Curved Path Following with Fixed-wing UAVs[C]∥2015 American Control Conference (ACC). Chicago, 2015: 1187-1192. |
| [11] | LU Yang, LUO Sha, ZHU Pengming, et al. Versatile Distributed Maneuvering with Generalized Formations Using Guiding Vector Fields[C]∥2025 IEEE International Conference on Robotics and Automation (ICRA). Atlanta, 2025: 11370-11376. |
| [12] | HU Binbin, YAO Weijia, ZHOU Yanxin, et al. Concurrent-allocation Task Execution for Multirobot Path-crossing-minimal Navigation in Obstacle Environments[C]∥IEEE Transactions on Robotics. IEEE, 2025: 6287-6306. |
| [13] | YAO Weijia, de MARINA H G, LIN Bohuan, et al. Singularity-free Guiding Vector Field for Robot Navigation[J]. IEEE Transactions on Robotics, 2021, 37(4): 1206-1221. |
| [14] | AGUIAR A P, HESPANHA J P, KOKOTOVIĆ P V. Performance Limitations in Reference Tracking and Path Following for Nonlinear Systems[J]. Automatica, 2008, 44(3): 598-610. |
| [15] | BAUTISTA J, ACUAVIVA A, HINOJOSA J, et al. Fully Distributed and Resilient Source Seeking for Robot Swarms[EB/OL]. 2024: arXiv: 2410.15921. |
| [16] | LU Yang, YAO Weijia, XIAO Yongqian, et al. Vector Field-guided Learning Predictive Control for Motion Planning of Mobile Robots with Uncertain Dynamics[EB/OL]. 2024: arXiv: 2405.08283. |
| [17] | HU Binbin, ZHANG Haitao, YAO Weijia, et al. Coordinated Guiding Vector Field Design for Ordering-flexible Multirobot Surface Navigation[C]∥IEEE Transactions on Automatic Control. IEEE, 2024: 4805-4812. |
| [18] | NAJAFI M, ROSSA C, ADAMS K, et al. Using Potential Field Function with a Velocity Field Controller to Learn and Reproduce the Therapist's Assistance in Robot-assisted Rehabilitation[J]. IEEE/ASME Transactions on Mechatronics, 2020, 25(3): 1622-1633. |
| [19] | TREADWAY E, GILLESPIE R B. Vector Field Control Methods for Discretely Variable Passive Robotic Devices[J]. IEEE Transactions on Robotics, 2021, 37(2): 375-389. |
| [20] | 刘永钦. 基于速度场算法的模切机控制系统设计[D]. 哈尔滨: 哈尔滨工业大学, 2018. |
| LIU Yongqin. Design of Die-cutting Machine Control System Based on Velocity Field[D]. Harbin: Harbin Institute of Technology, 2018. | |
| [21] | 李兵. 基于方向场理论的X-Y平台速度规划与轮廓控制研究[D]. 沈阳: 沈阳工业大学, 2013. |
| LI Bing. Research on Velocity Planning and Contour Control of X-Y Platform Based on Directional Field Theory[D]. Shenyang: Shenyang University of Technology, 2013. | |
| [22] | KIM K, KIM M, KIM D, et al. Modeling and Velocity-field Control of Autonomous Excavator with Main Control Valve[J]. Automatica, 2019, 104: 67-81. |
| [23] | HE Xiaodong, LI Zhongkui. Full-state Planning of Nonholonomic Mobile Robots via Dynamic Velocity Vector Fields[C]∥2023 35th Chinese Control and Decision Conference (CCDC). Yichang, 2023: 1495-1500. |
| [24] | FREW E W, LAWRENCE D. Tracking Dynamic Star Curves Using Guidance Vector Fields[J]. Journal of Guidance, Control, and Dynamics, 2017, 40(6): 1488-1495. |
| [25] | GONÇALVES V M, ADORNO B V, CROSNIER A, et al. Stable-by-design Kinematic Control Based on Optimization[J]. IEEE Transactions on Robotics, 2020, 36(3): 644-656. |
| [26] | TAN X, WEI W, LIU C, et al. Reinforcement Learning-based Trajectory Planning for Continuous Digging of Excavator Working Devices in Trenching Tasks[J]. Computer-Aided Civil and Infrastructure Engineering, 2025, 40(13): 1847-1870. |
| [27] | YAO Zongwei, ZHAO Shichao, TAN Xiaodan, et al. Real-time Task-oriented Continuous Digging Trajectory Planning for Excavator Arms[J]. Automation in Construction, 2023, 152: 104916. |
| [28] | REZENDE A M C, GONÇALVES V M, NUNES A H D, et al. Robust Quadcopter Control with Artificial Vector Fields[C]∥2020 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2020: 6381-6387. |
| [29] | REZENDE A M C, JÚNIOR G P C, FERNANDES R, et al. Indoor Localization and Navigation Control Strategies for a Mobile Robot Designed to Inspect Confined Environments[C]∥2020 IEEE 16th International Conference on Automation Science and Engineering (CASE). IEEE, 2020: 1427-1433. |
| [30] | OLAVO J L G, THUMS G D, JESUS T A, et al. Robust Guidance Strategy for Target Circulation by Controlled UAV[J]. IEEE Transactions on Aerospace and Electronic Systems, 2018, 54(3): 1415-1431. |
| [31] | MINAV T A, LAURILA L I E, PYRHÖNEN J J. Analysis of Electro-hydraulic Lifting System’s Energy Efficiency with Direct Electric Drive Pump Control[J]. Automation in Construction, 2013, 30: 144-150. |
| [32] | 陈俊翔, 齐钒羽, 姜宏达, 等. 负载口独立双阀芯电液阀的结构优化[J]. 中国机械工程, 2024, 35(10): 1747-1761. |
| CHEN Junxiang, QI Fanyu, JIANG Hongda, et al. Structure Optimization of Load Port Independent Double Spool Electro-hydraulic Valves[J]. China Mechanical Engineering, 2024, 35(10): 1747-1761. | |
| [33] | DING Ruqi, XU Bing, ZHANG Junhui, et al. Bumpless Mode Switch of Independent Metering Fluid Power System for Mobile Machinery[J]. Automation in Construction, 2016, 68: 52-64. |
| [34] | CHEN Junxiang, JIANG Hongda, KONG Xiangdong, et al. Mode Switching Control of Independent Metering Fluid Power Systems[J]. ISA Transactions, 2025, 158: 735-748. |
| [35] | XU Bing, DING Ruqi, ZHANG Junhui, et al. Pump/Valves Coordinate Control of the Independent Metering System for Mobile Machinery[J]. Automation in Construction, 2015, 57: 98-111. |
| [1] | 郭煜杰, 陈俊翔, 艾超, 孔祥东. 基于模型标定与泵阀动态匹配的液压挖掘机启动压力冲击改善[J]. 中国机械工程, 2026, 37(7): 1784-1793. |
| [2] | 陈俊翔1, 2, 姜宏达1, 2, 孔祥东1, 2, 艾超1, 2. 考虑时滞因素的负载口独立系统模式切换平稳性研究[J]. 中国机械工程, 2025, 36(03): 414-425. |
| [3] | 陈俊翔, 孔祥东, 许克龙, 艾超, . 高压螺纹插装式溢流阀综合性能优化[J]. 中国机械工程, 2023, 34(24): 2909-2919,2926. |
| [4] | 耿丽萍;周静伟;陶容;. 基于柯恩达效应的自激旋进射流流动特性研究[J]. J4, 2009, 20(10): 0-1162. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
