ISSN 1004-132X
CN 42-1294/TH
CN 42-1294/TH
中国机械工程 ›› 2026, Vol. 37 ›› Issue (8): 1900-1908.DOI: 10.3969/j.issn.1004-132X.2026.08.009
• 机械基础工程 • 上一篇
时培成1( ), 孙雨辰1, CHAKIR Chadia1, 孙羽2
收稿日期:2025-03-26
出版日期:2026-08-25
发布日期:2026-09-17
通讯作者:
时培成
基金资助:
SHI Peicheng1(), SUN Yuchen1, CHAKIR Chadia1, SUN Yu2
Received:2025-03-26
Online:2026-08-25
Published:2026-09-17
Contact:
SHI Peicheng
摘要:
针对智能车辆横向控制中传统动力学模型在复杂工况下精度不足的问题,提出了一种物理-学习混合动力学建模方法,并结合学习型模型预测控制方法以提高横向控制的精度与鲁棒性。首先以单轨模型为基础物理模型,引入门控循环单元(GRU)补偿未建模动态,构建混合物理学习模型,兼具物理可解释性与数据驱动自适应性;然后将混合模型作为预测模型嵌入模型预测控制(MPC)框架,设计考虑轨迹跟踪误差与控制量约束的优化目标函数,实时求解最优前轮转向角指令。CarSim/Simulink联合仿真结果表明,在双移线与蛇形工况下,相较于对比方法,所提方法有效降低了横向跟踪误差均方根,同时减小了前轮转角幅值,有效抑制了单轨模型中的部分未建模动态的影响。所提方法实现了车辆在复杂工况下控制量的精确输出,同步提升了智能车辆的横向控制精度和稳定性,具有良好的横向控制效果。
中图分类号:
时培成, 孙雨辰, CHAKIR Chadia, 孙羽. 基于物理-学习混合动力学建模的智能车辆横向控制研究[J]. 中国机械工程, 2026, 37(8): 1900-1908.
SHI Peicheng, SUN Yuchen, CHAKIR Chadia, SUN Yu. Research on Lateral Control of Intelligent Vehicles Based on Physics-Learning Hybrid Dynamics Modeling[J]. China Mechanical Engineering, 2026, 37(8): 1900-1908.
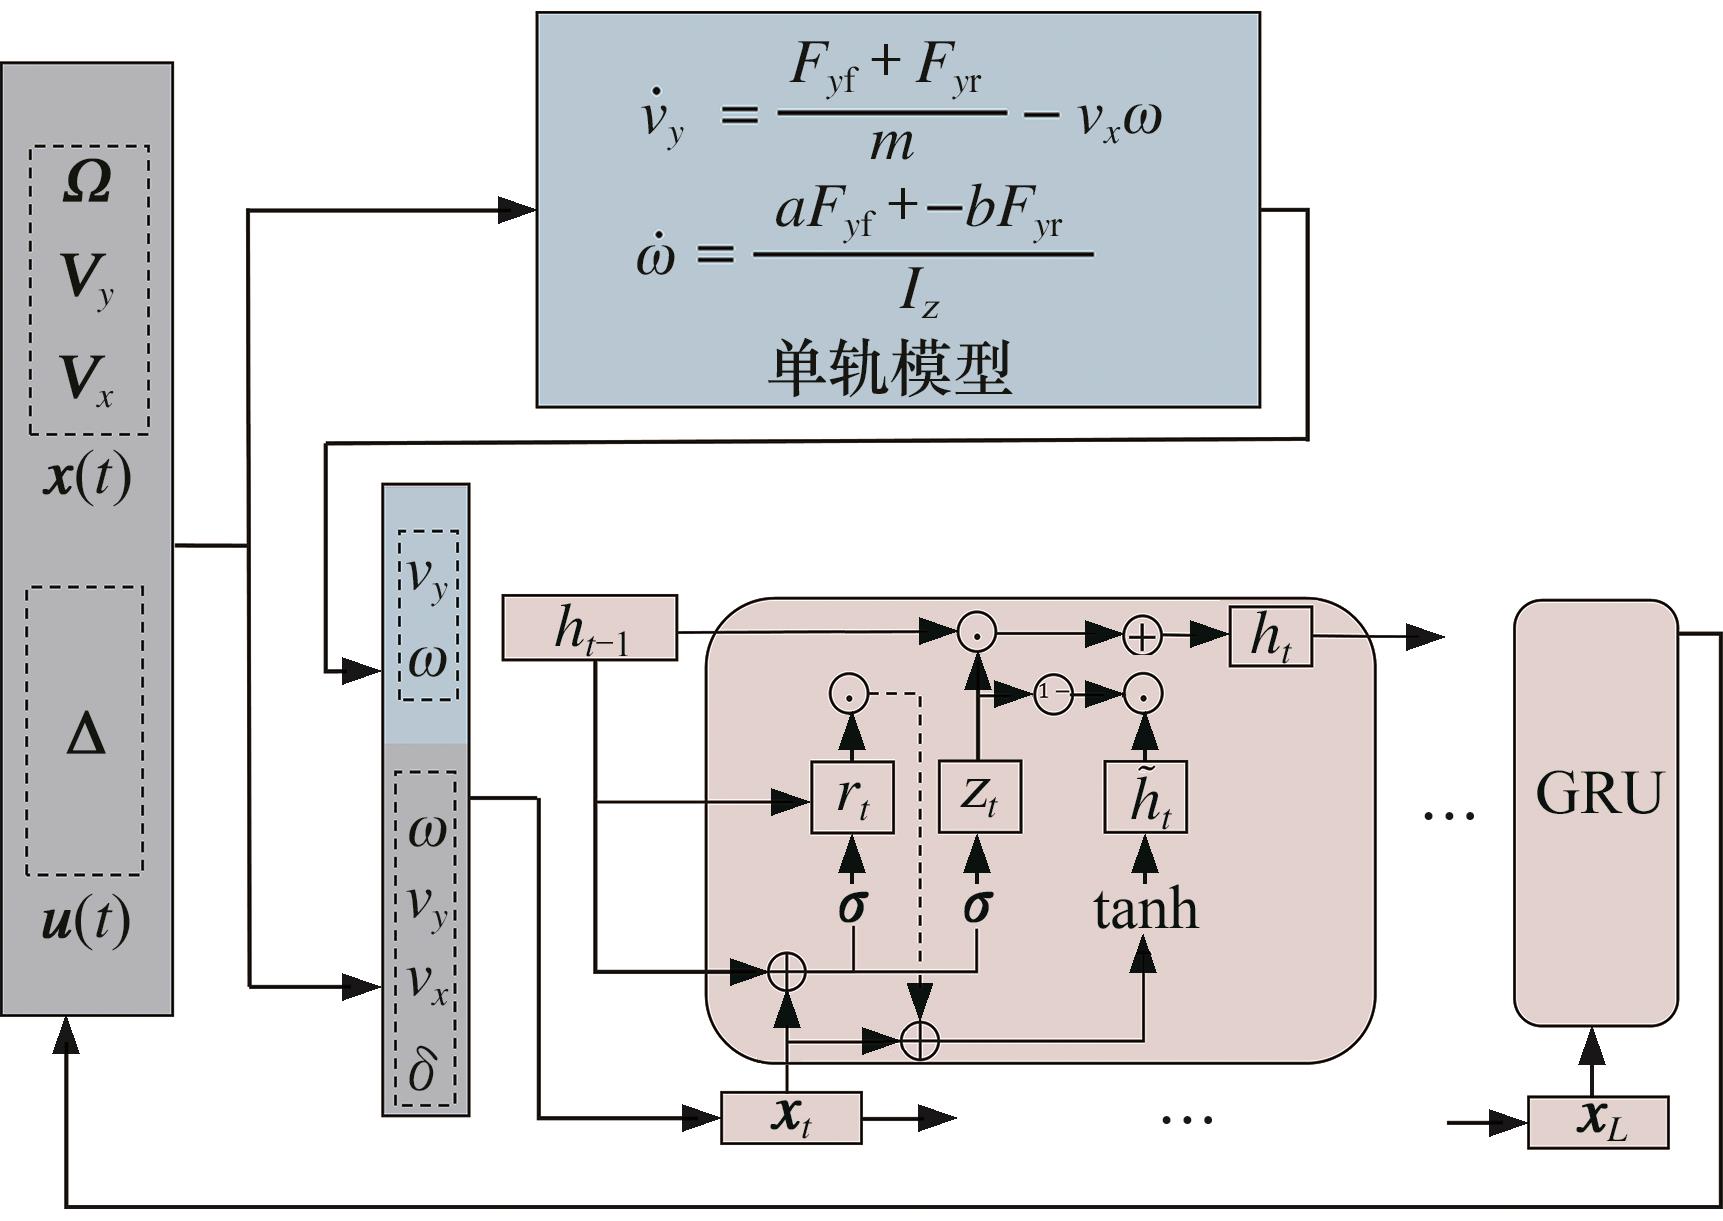
图1 混合物理-数据驱动建模架构
Fig.1 Architecture of hybrid physics-data-driven modeling
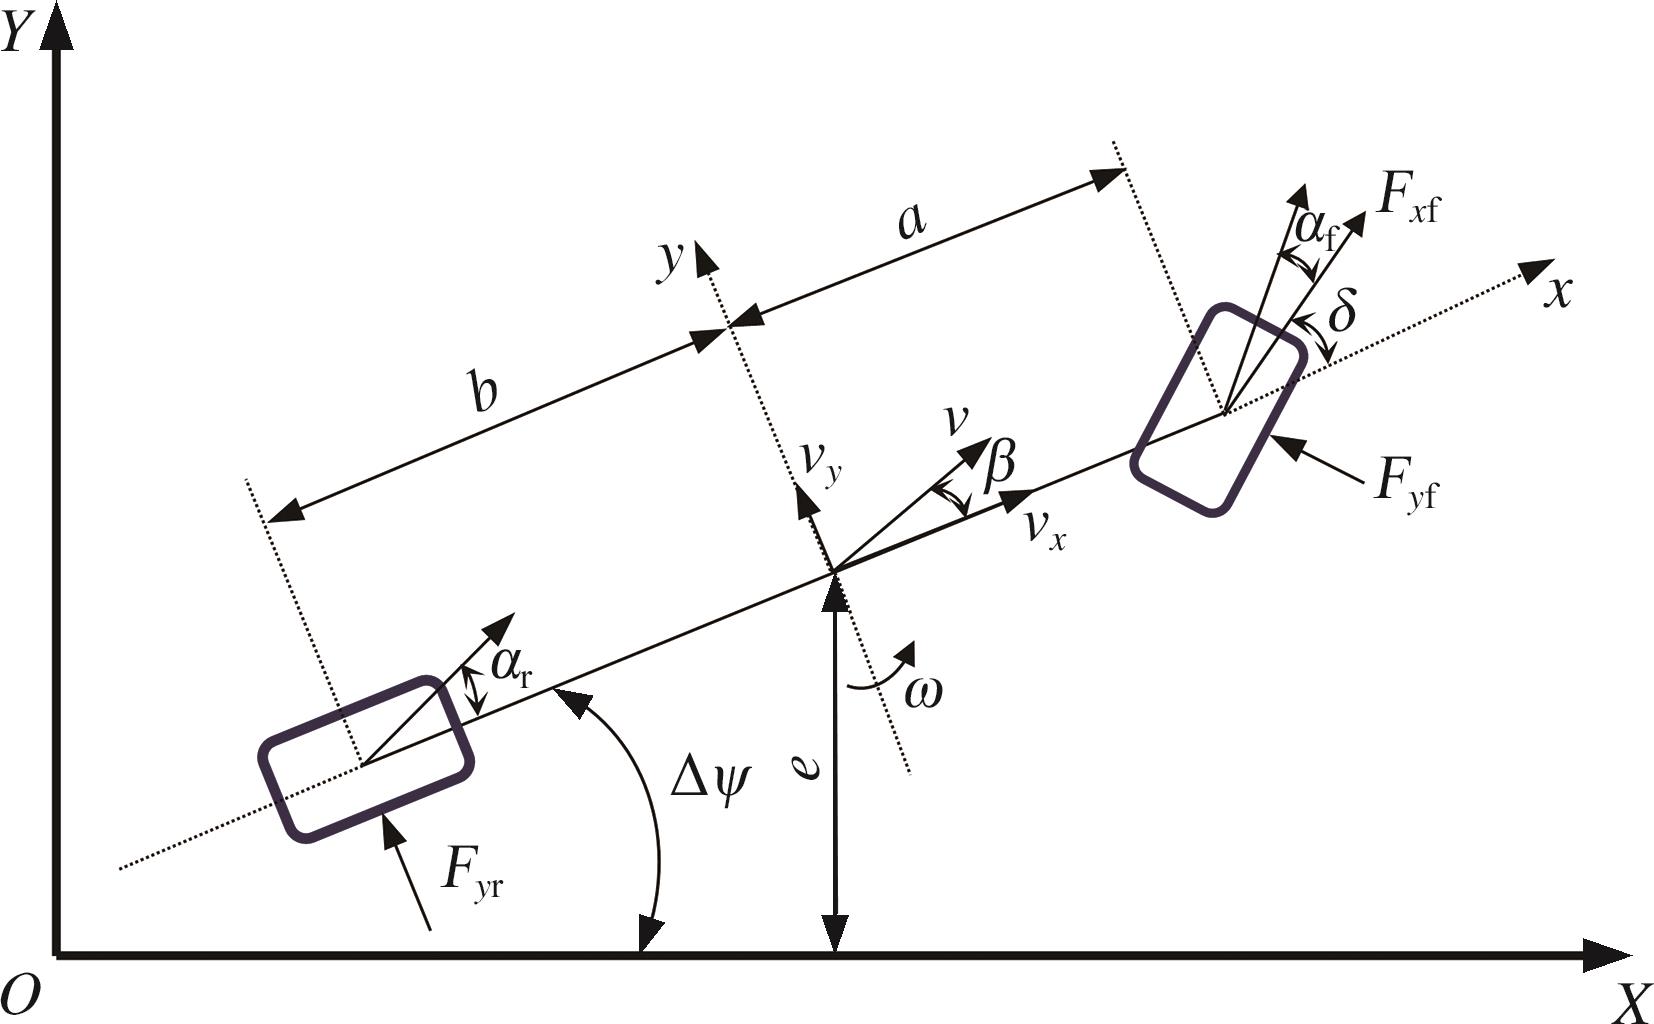
图2 单轨模型
Fig.2 Single-track vehicle model
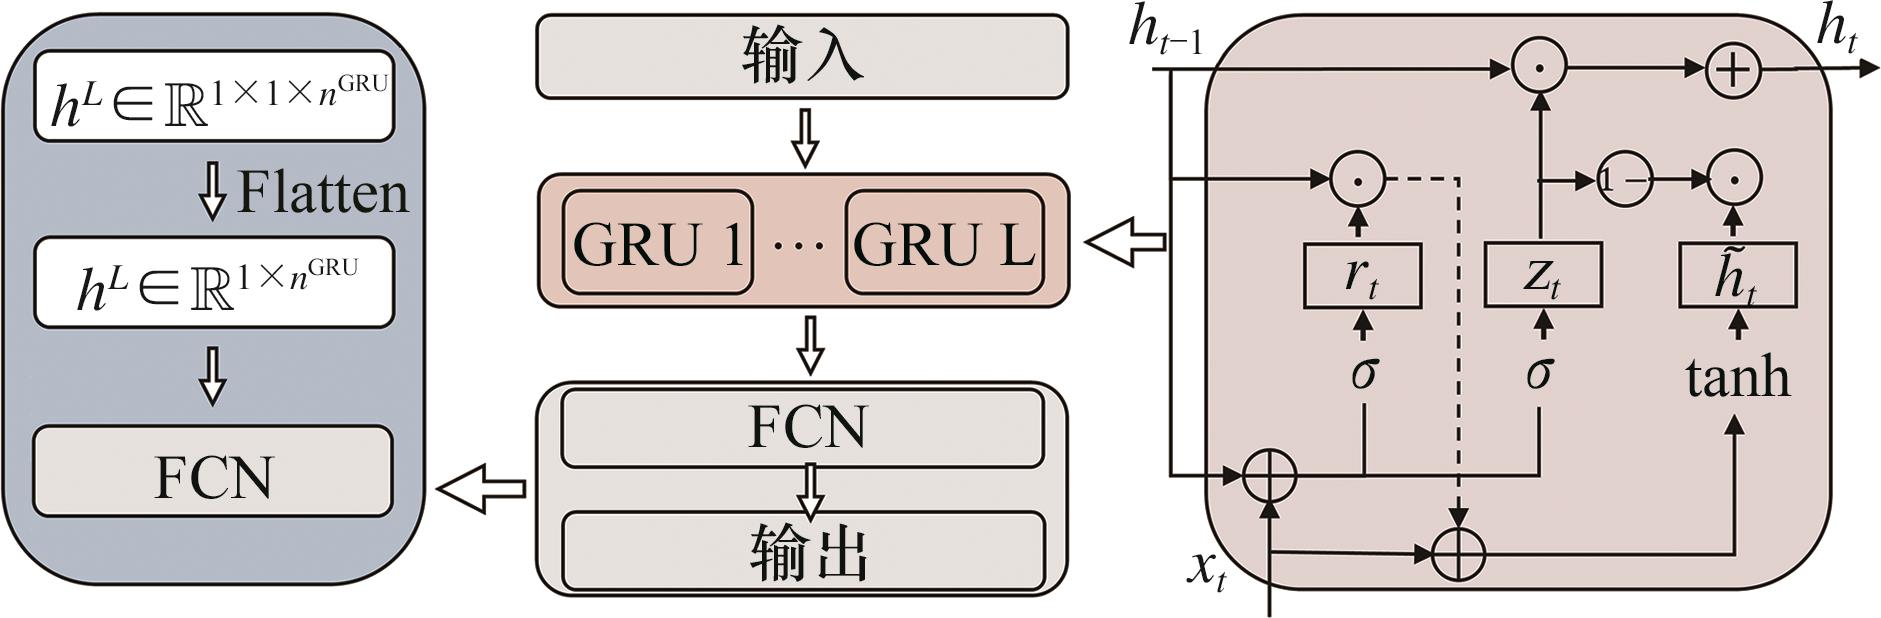
图3 基于GRU的数据驱动模型
Fig.3 GRU-based data-driven model
| 场景类型 | 道路特征 | 车速范围/(km·h | 附着系数 |
|---|---|---|---|
| 城市道路 | 密集路口, 启停工况 | 30~50 | 0.85/0.5/0.3 |
| 高速公路 | 长直道 | 90~120 | 0.85/0.5 |
| 公路 | 连续缓弯 | 50~70 | 0.85/0.5/0.3 |
| 赛道 | S形急弯 | 70~90 | 0.85 |
表1 智能车辆驾驶场景设计
Tab.1 Intelligent vehicle driving scenario design
| 场景类型 | 道路特征 | 车速范围/(km·h | 附着系数 |
|---|---|---|---|
| 城市道路 | 密集路口, 启停工况 | 30~50 | 0.85/0.5/0.3 |
| 高速公路 | 长直道 | 90~120 | 0.85/0.5 |
| 公路 | 连续缓弯 | 50~70 | 0.85/0.5/0.3 |
| 赛道 | S形急弯 | 70~90 | 0.85 |
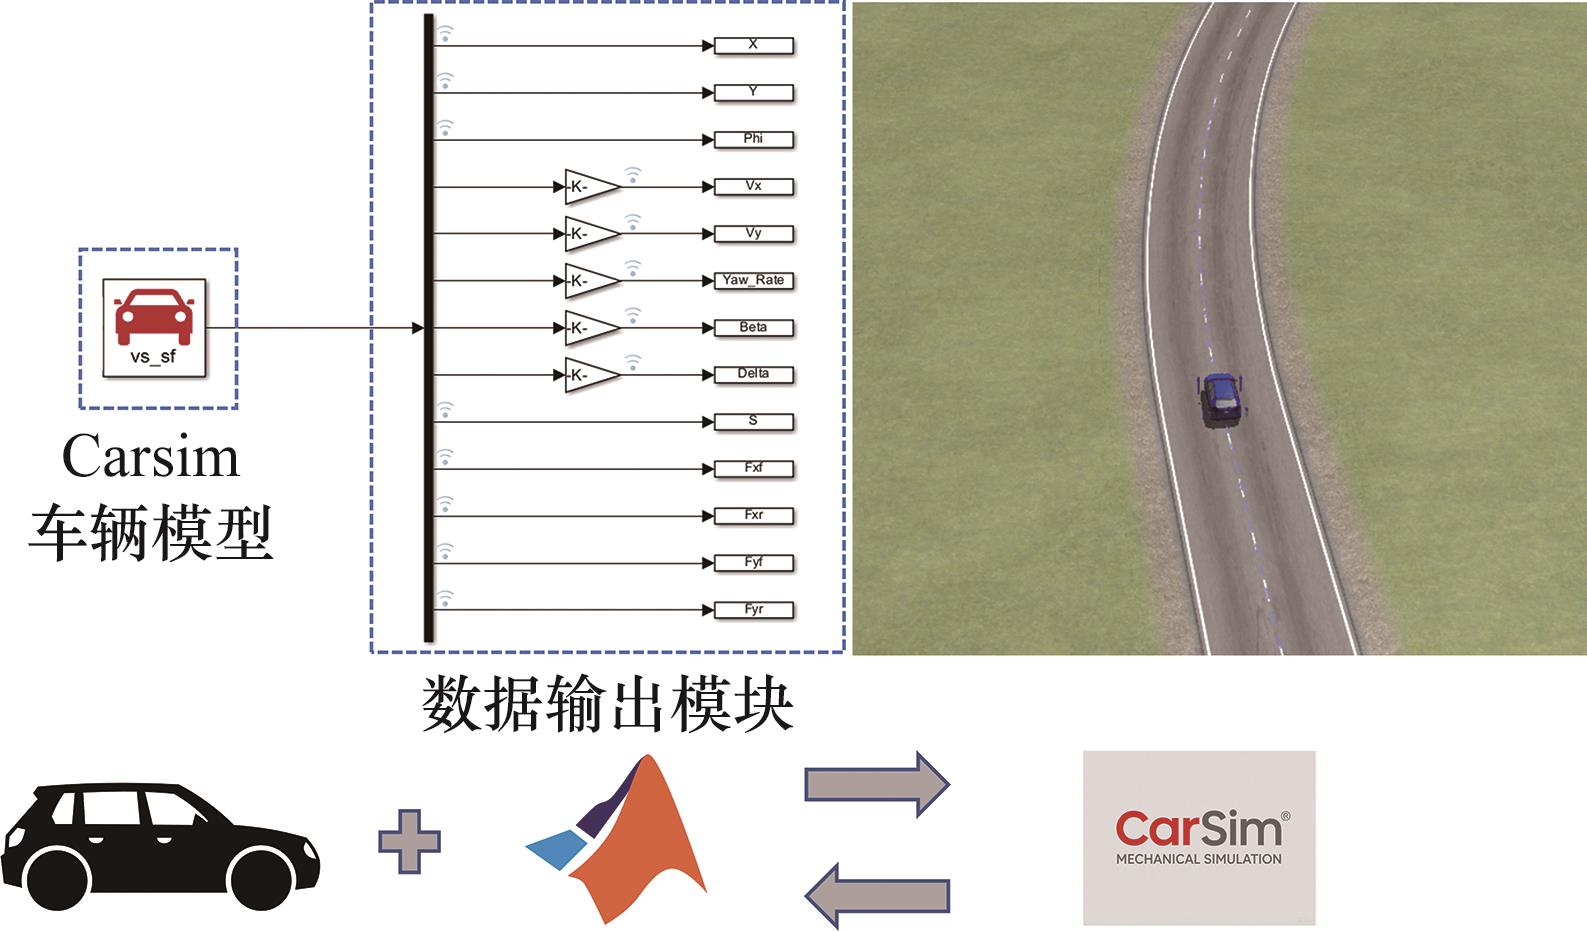
图4 仿真数据采集系统
Fig.4 Simulation data collection system
| 变量 | 模型 | 平均绝对误差 | 均方根误差 |
|---|---|---|---|
| 混合模型 | 0.0352 | 0.0437 | |
| 单轨模型 | 0.0673 | 0.0812 | |
| 混合模型 | 0.0239 | 0.0383 | |
| 单轨模型 | 0.0385 | 0.0576 |
表2 混合模型与单轨模型测试结果对比
Tab.2 Comparison of test results between hybrid model and single-track model
| 变量 | 模型 | 平均绝对误差 | 均方根误差 |
|---|---|---|---|
| 混合模型 | 0.0352 | 0.0437 | |
| 单轨模型 | 0.0673 | 0.0812 | |
| 混合模型 | 0.0239 | 0.0383 | |
| 单轨模型 | 0.0385 | 0.0576 |
| 整车质量m/kg | 1270 |
|---|---|
| 轴距l/m | 2.91 |
| 质心到前轴距离a/m | 1.015 |
| 质心到后轴距离b/m | 1.895 |
| 转动惯量 | 1536 |
| 前轴侧偏刚度 | 61 120 |
| 后轴侧偏刚度 | 51 160 |
表3 仿真车辆参数
Tab.3 Vehicle parameters for simulation
| 整车质量m/kg | 1270 |
|---|---|
| 轴距l/m | 2.91 |
| 质心到前轴距离a/m | 1.015 |
| 质心到后轴距离b/m | 1.895 |
| 转动惯量 | 1536 |
| 前轴侧偏刚度 | 61 120 |
| 后轴侧偏刚度 | 51 160 |
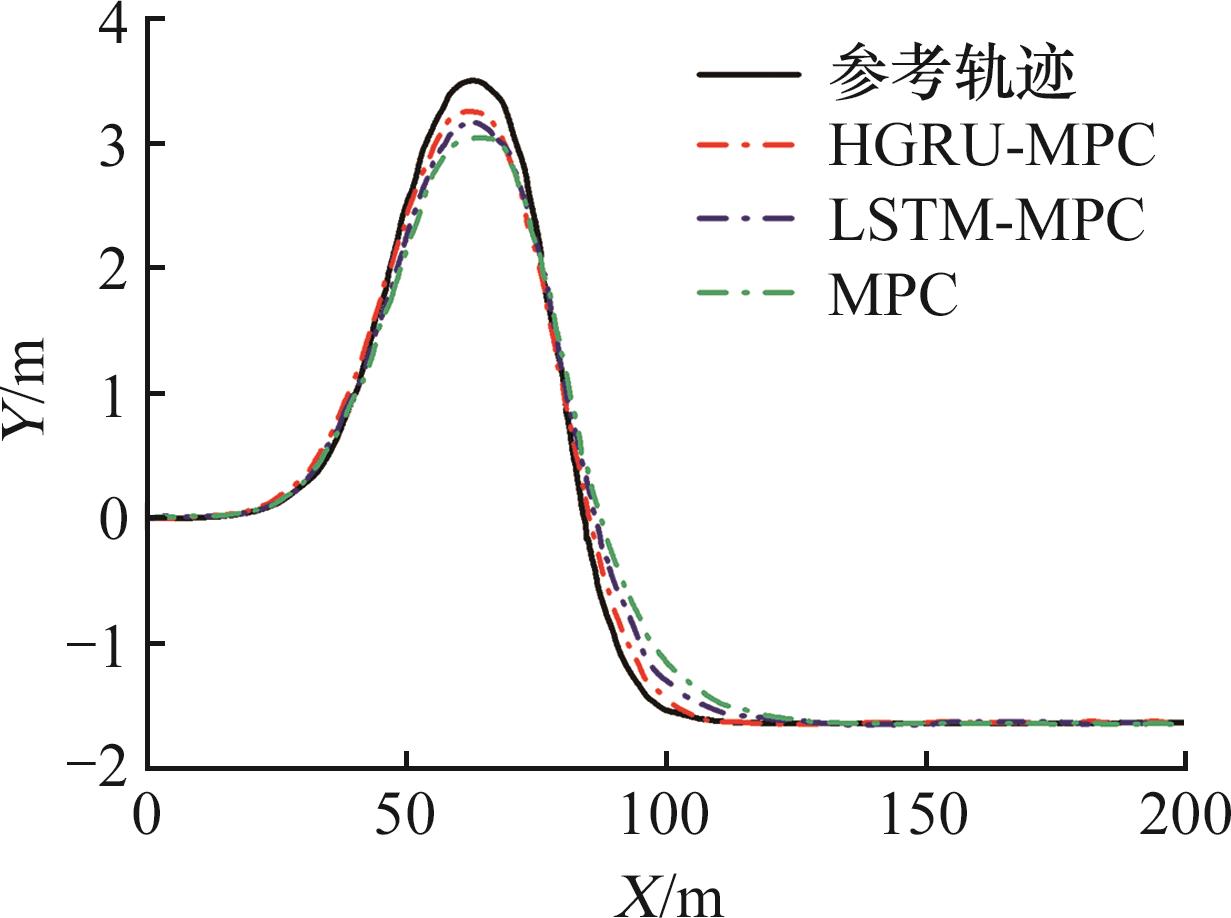
图5 双移线工况下轨迹跟踪效果对比
Fig.5 Trajectory tracking performance comparison under double lane change scenario
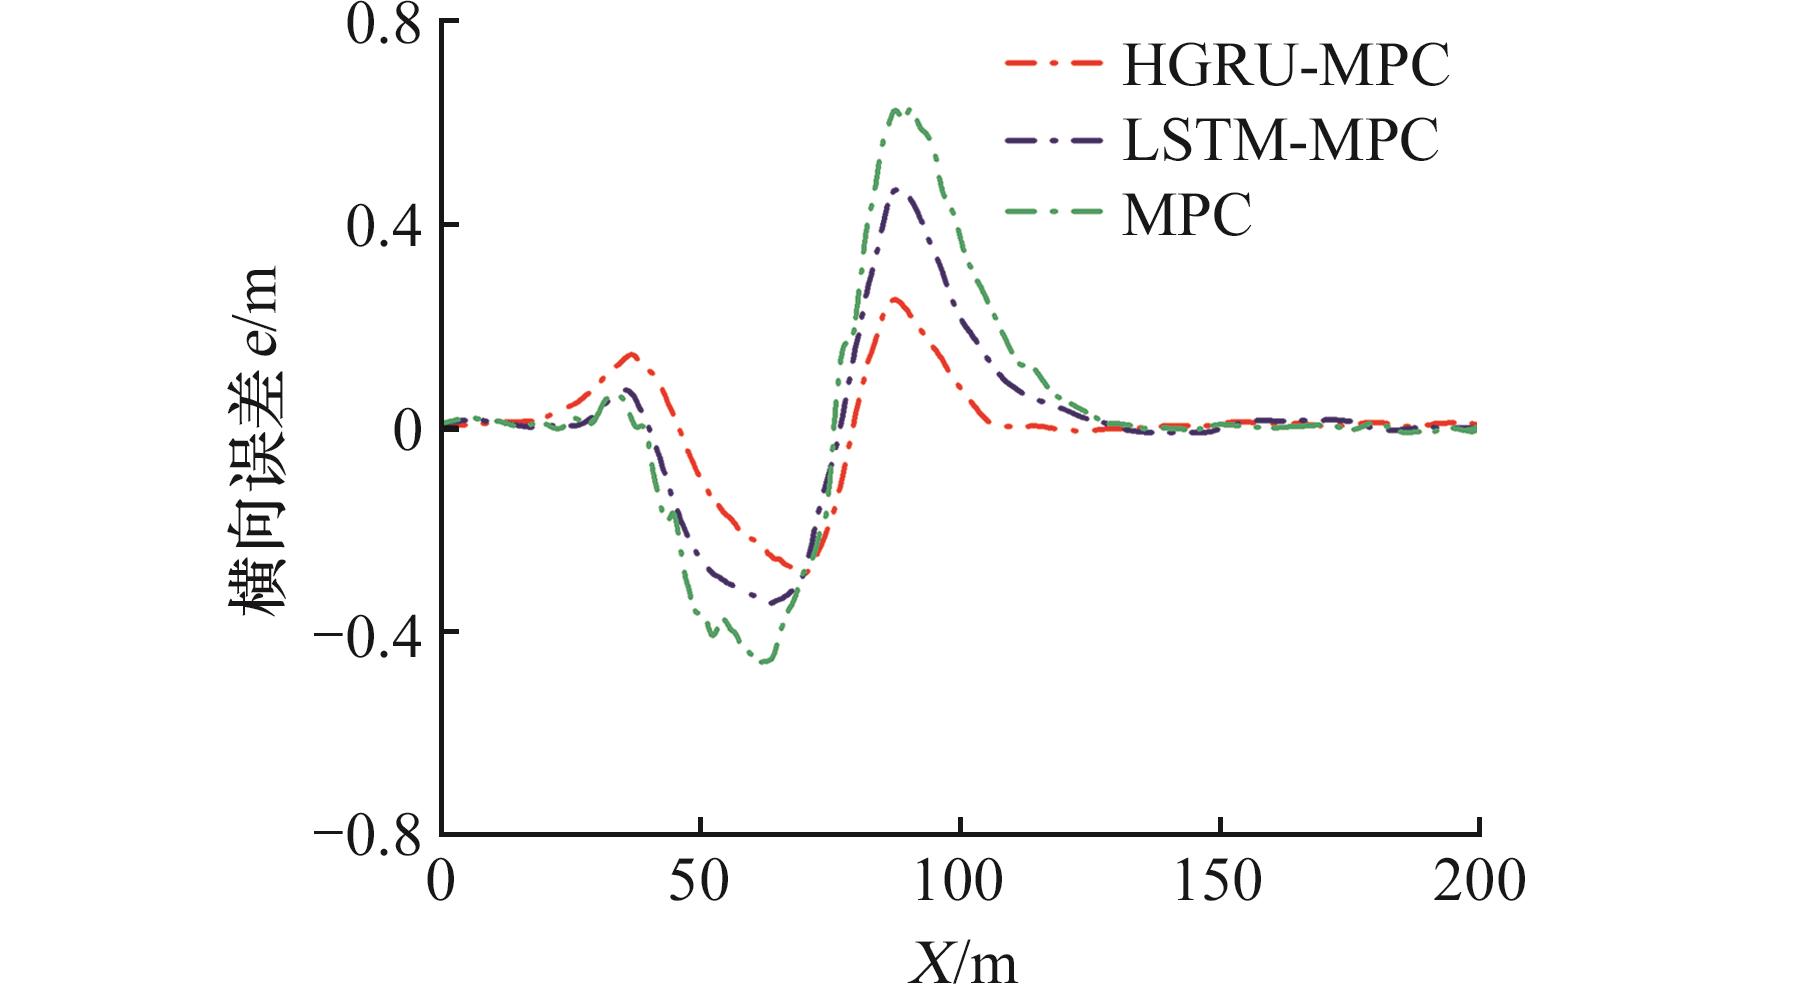
图6 双移线工况下横向误差
Fig.6 Lateral tracking error under double lane change scenario
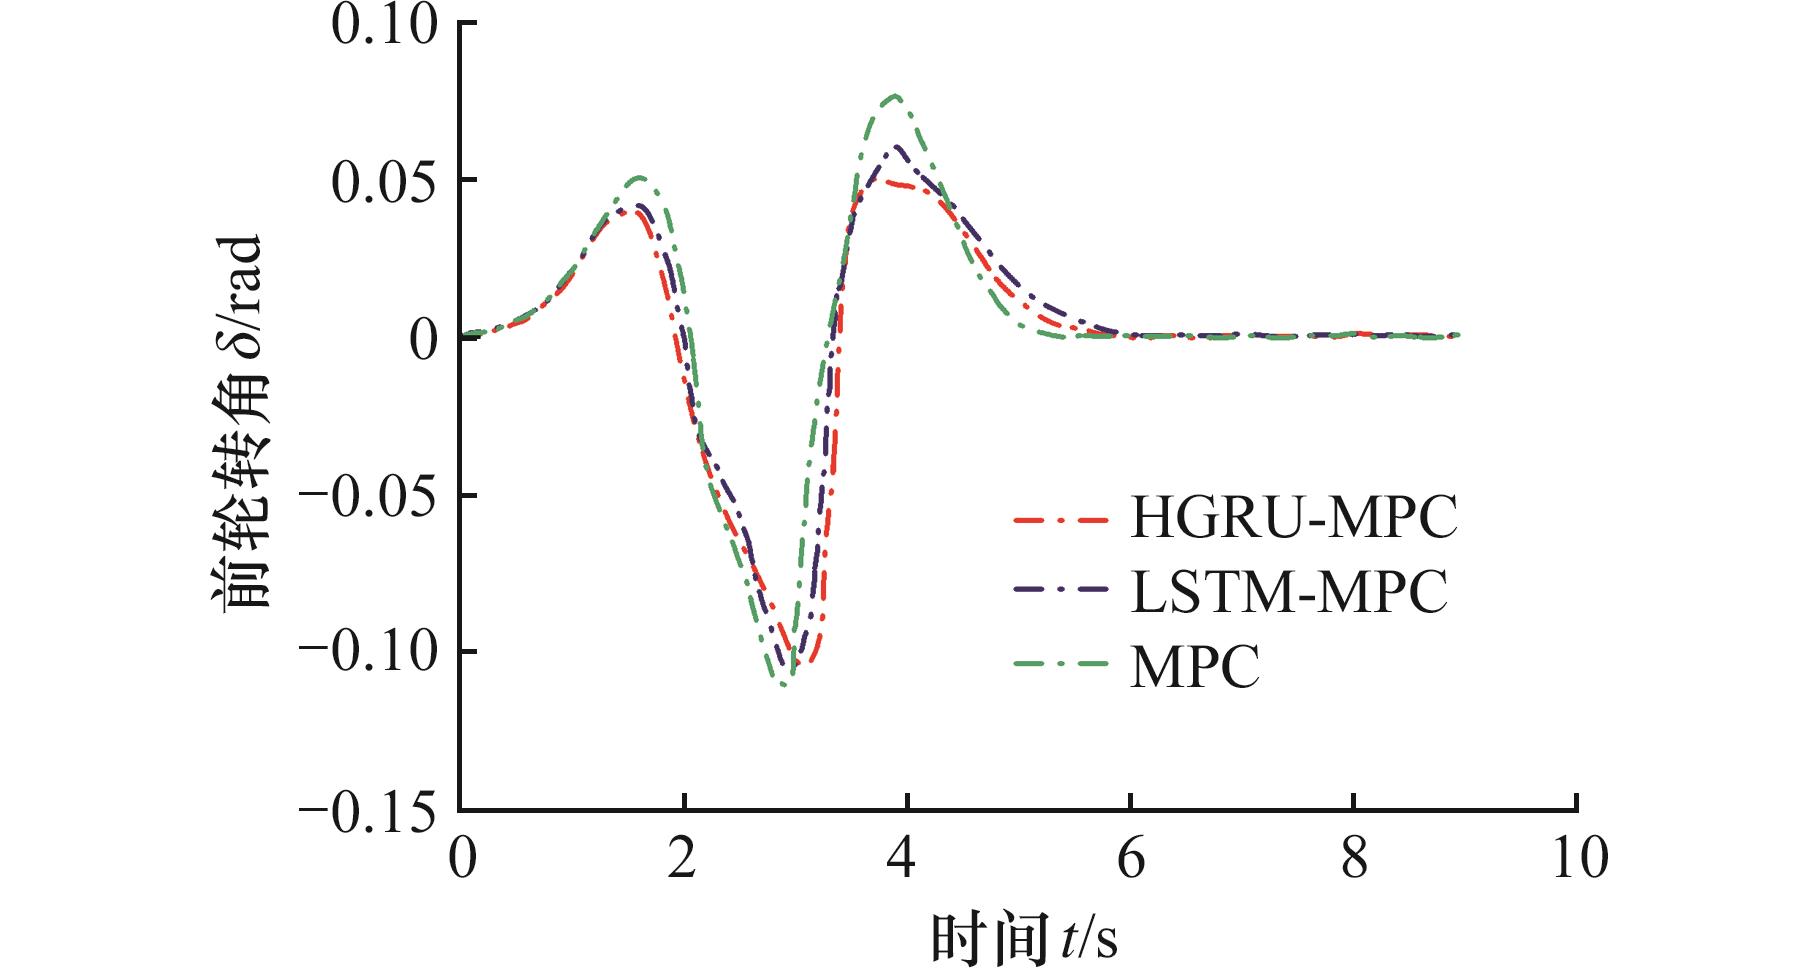
图7 双移线工况前轮转角控制量
Fig.7 Front wheel steering angle control input under double lane change scenario
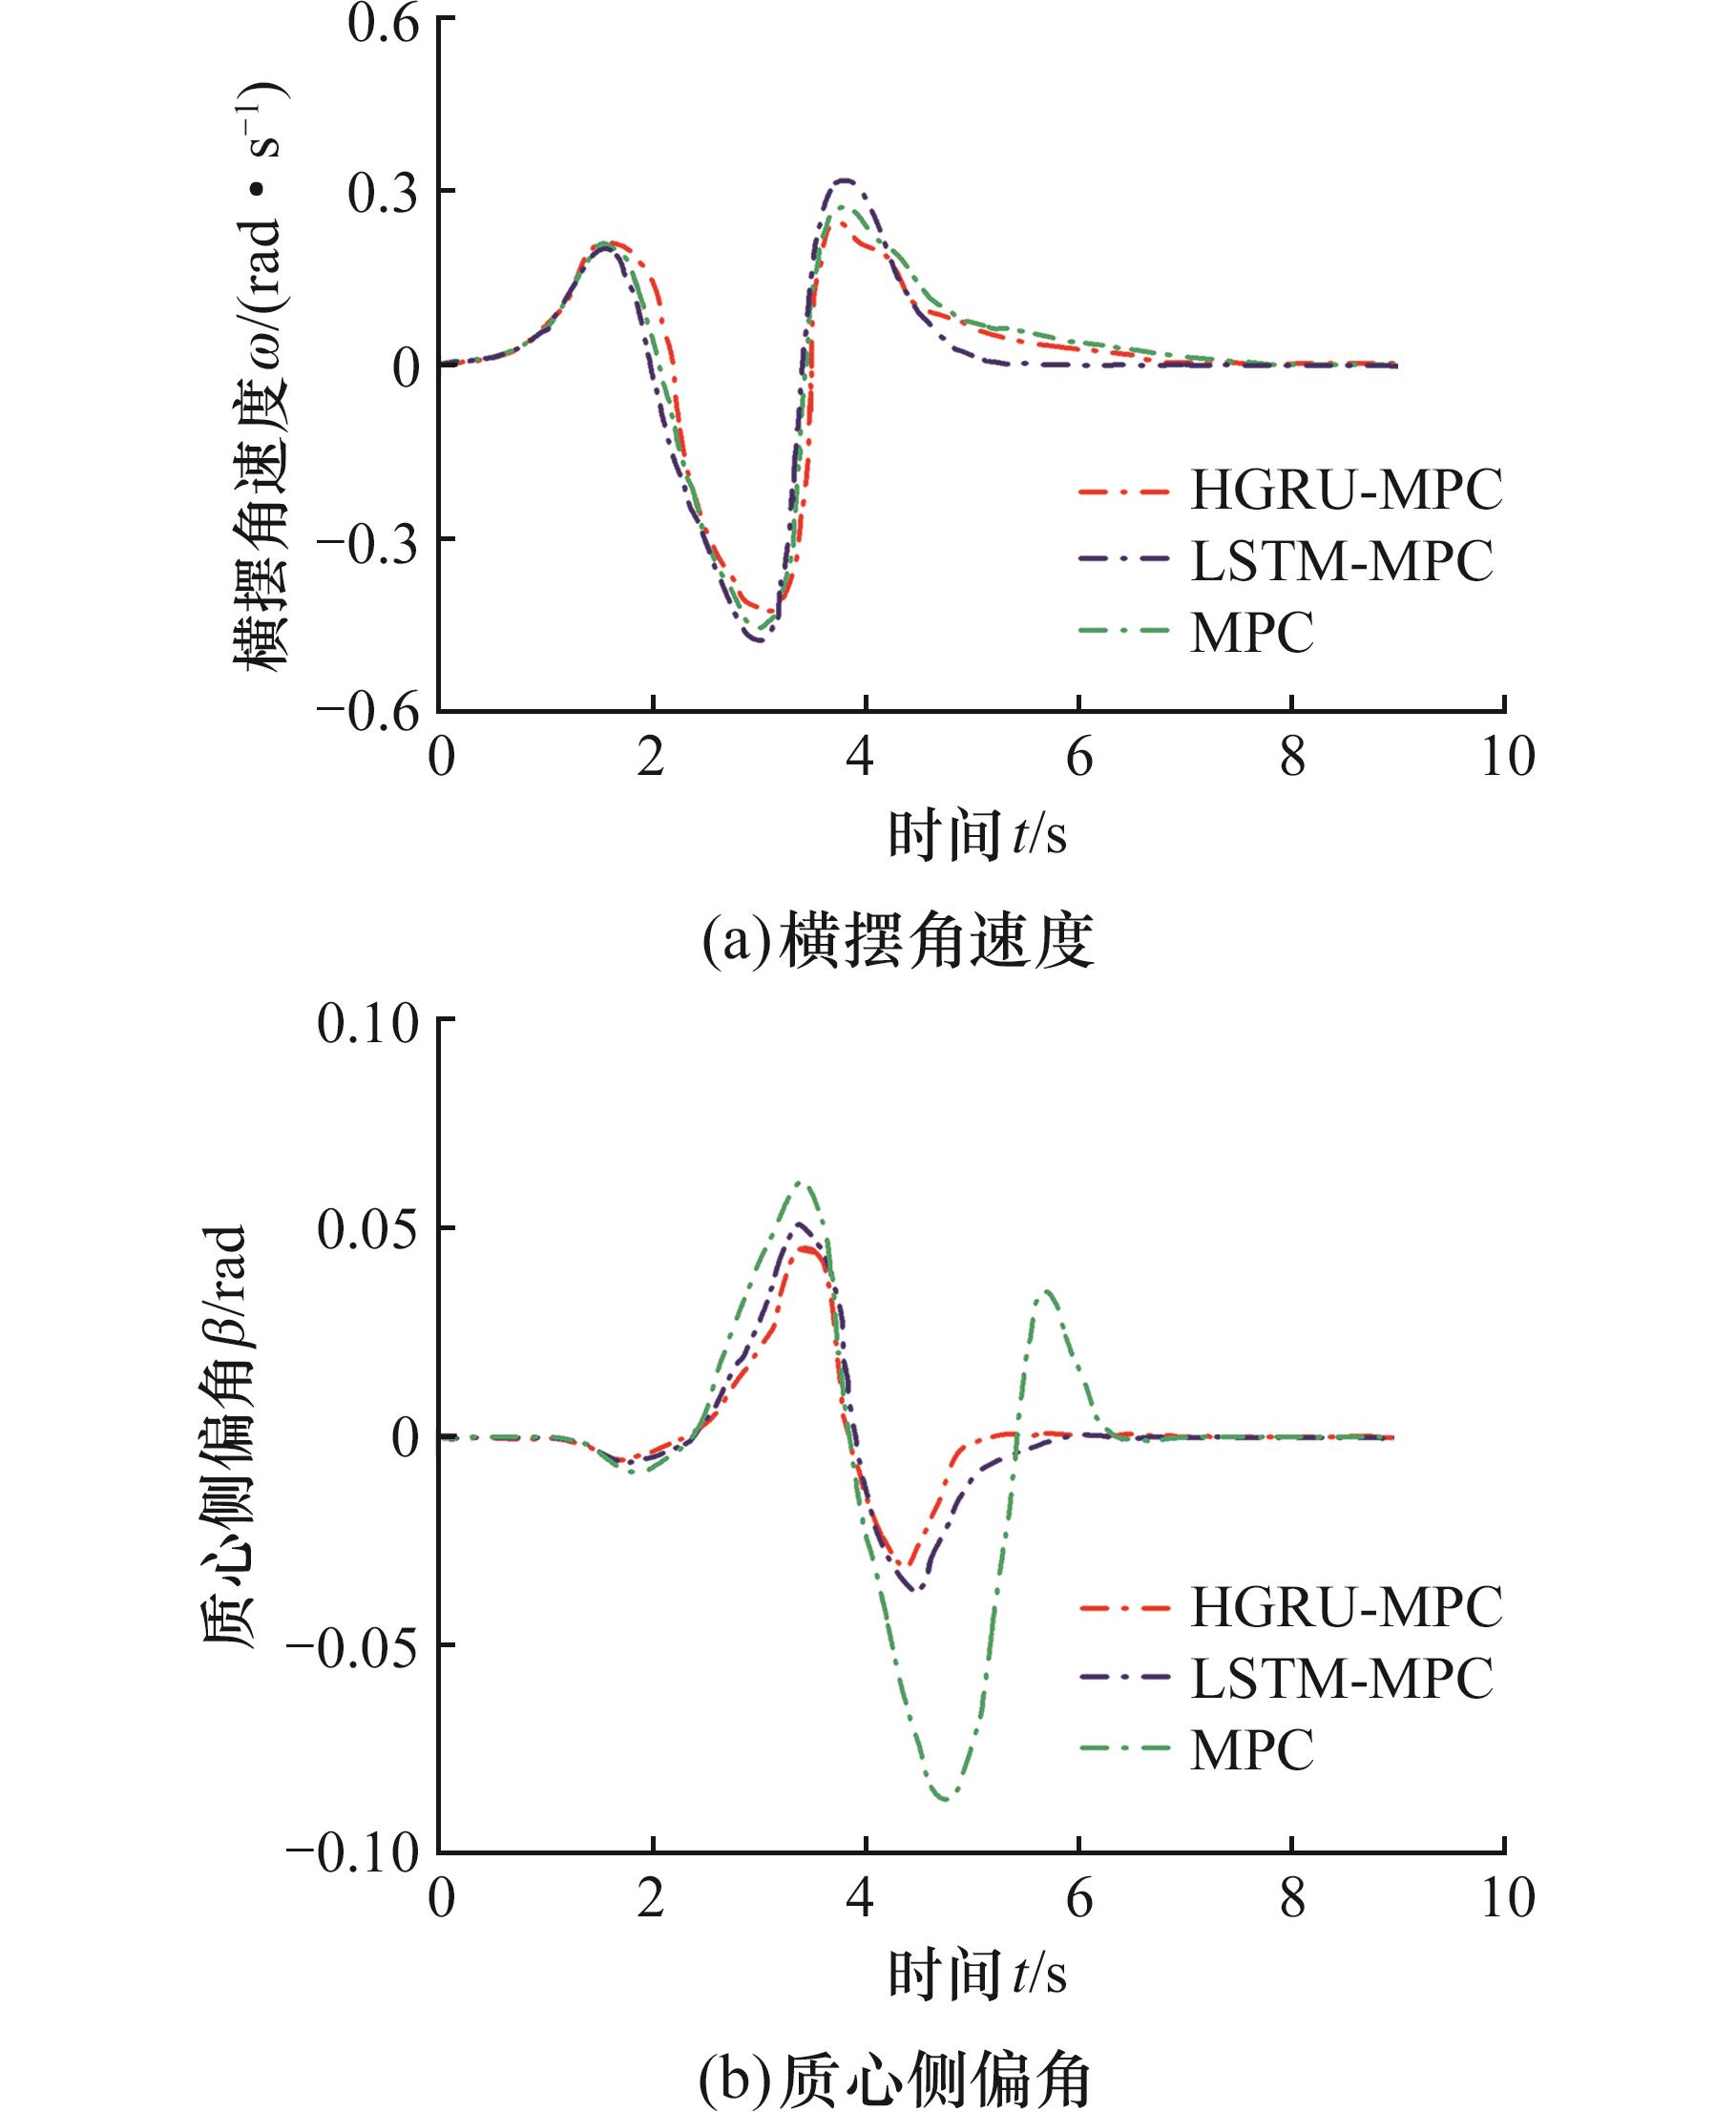
图8 双移线工况下车辆动力学状态响应
Fig.8 Vehicle dynamic state responses under double lane change scenario
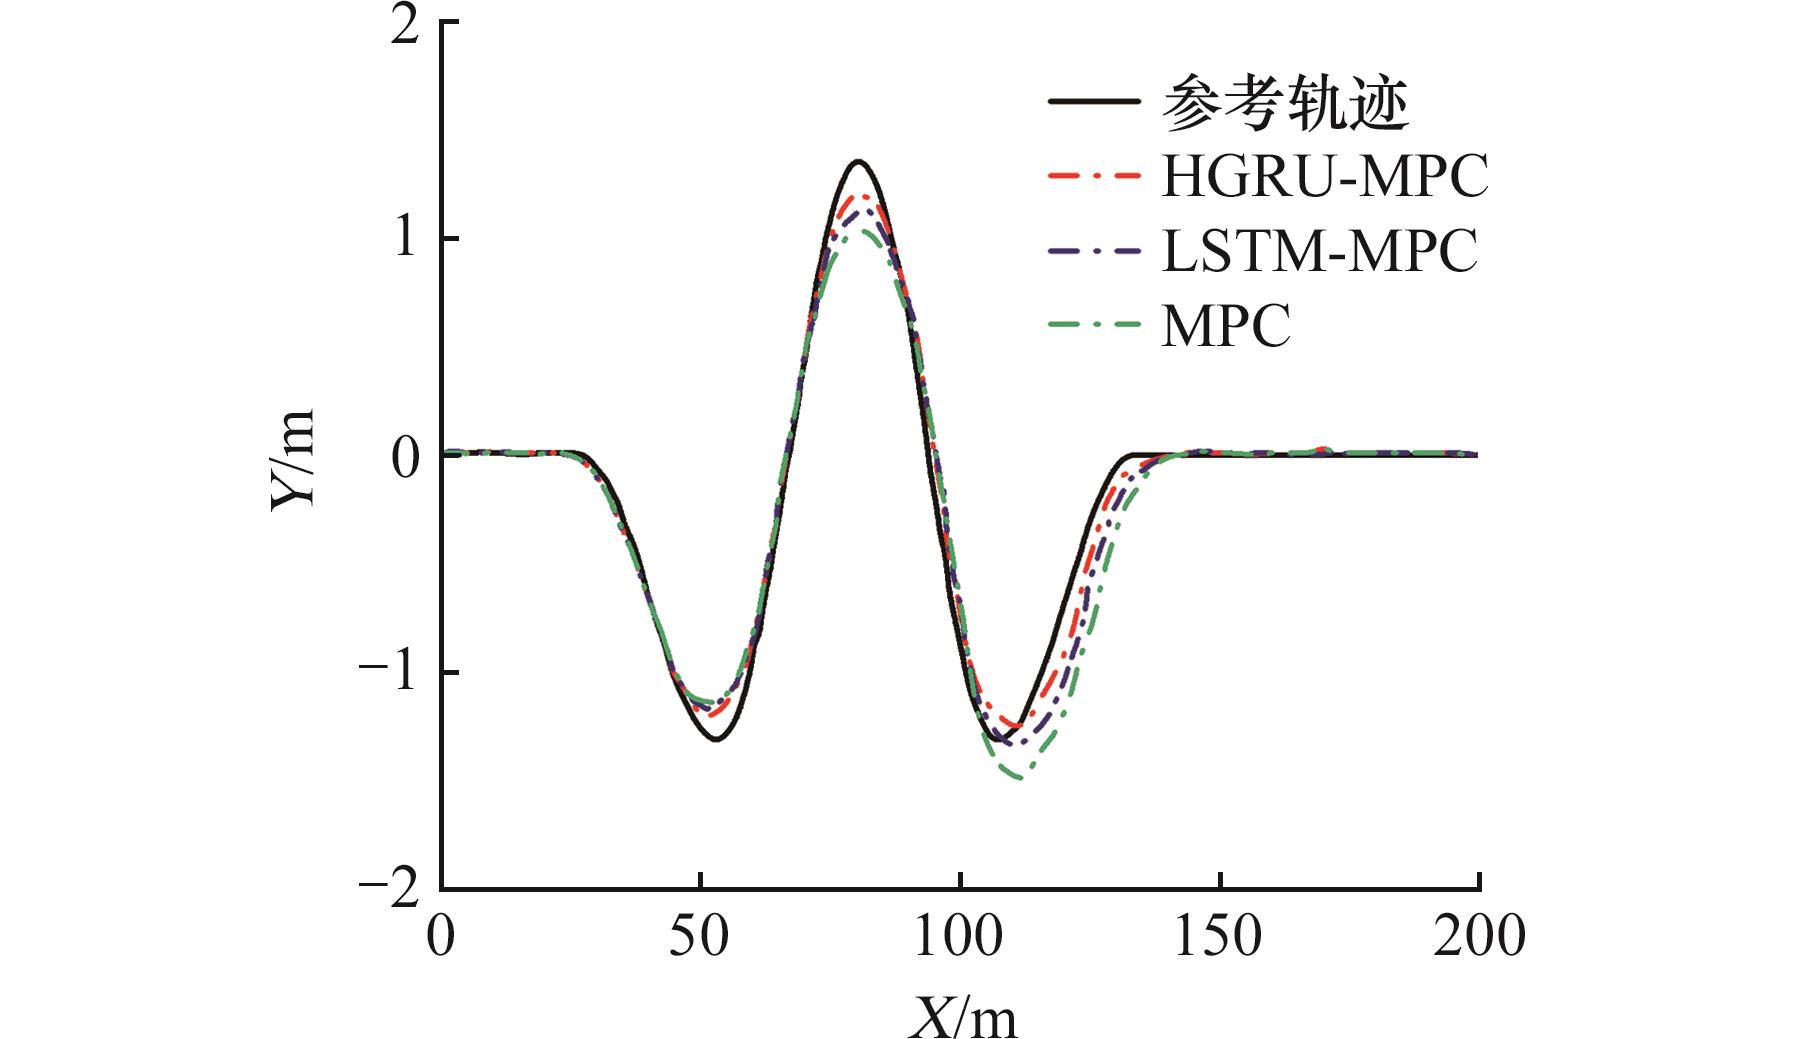
图9 蛇形工况下轨迹跟踪效果对比
Fig.9 Trajectory tracking performance comparison under slalom scenario
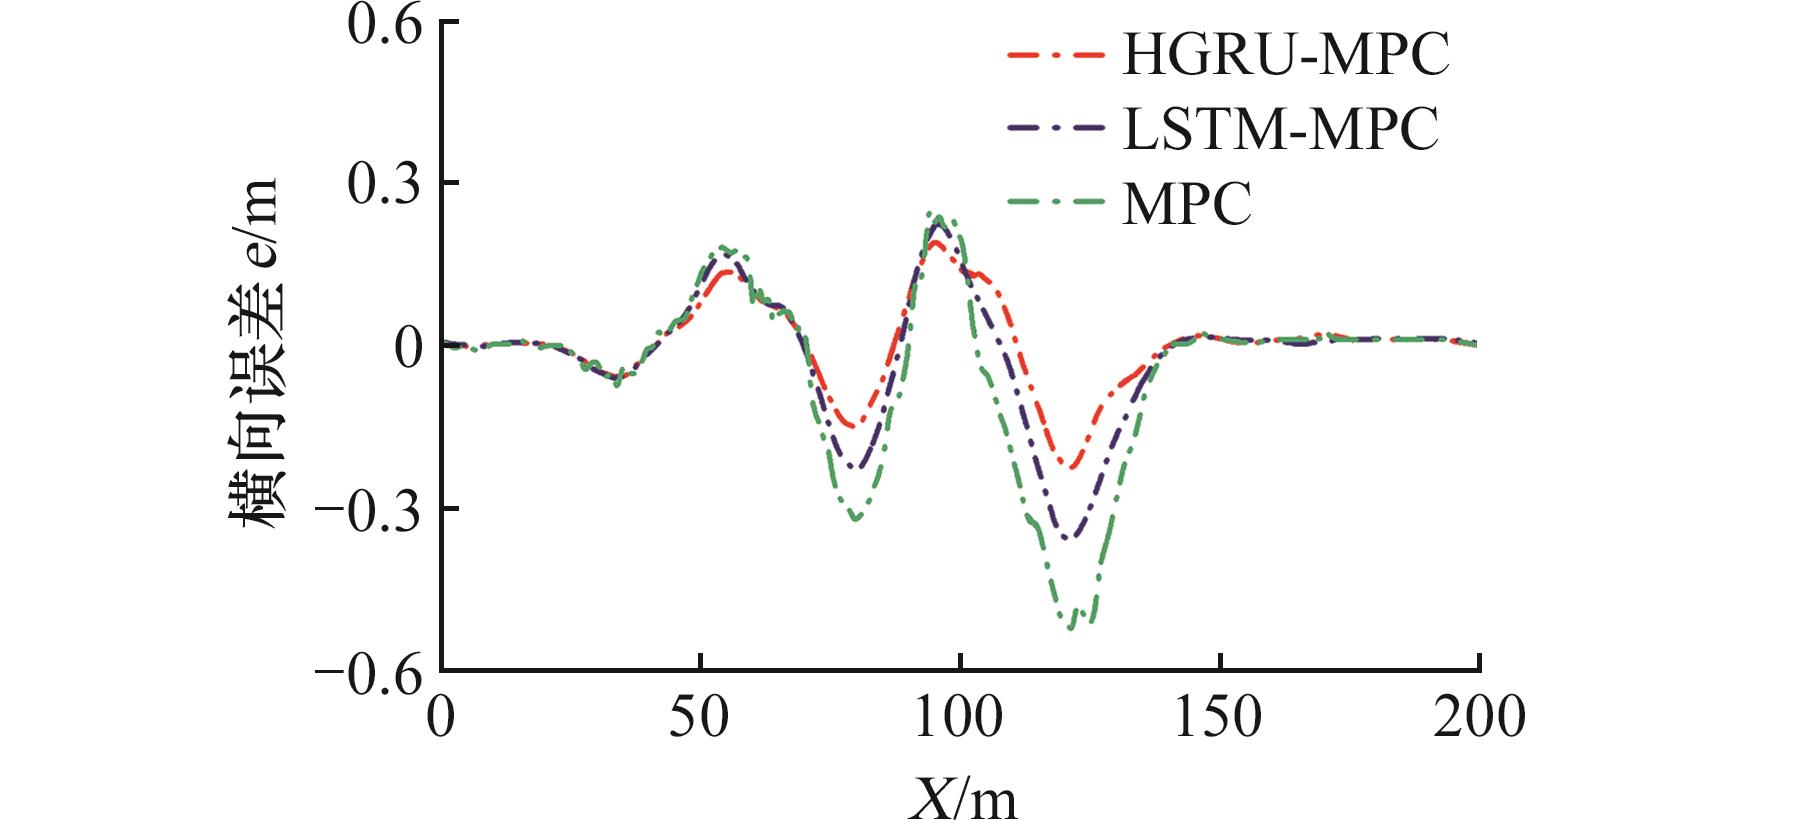
图10 蛇形工况下横向误差
Fig.10 Lateral tracking error under slalom scenario
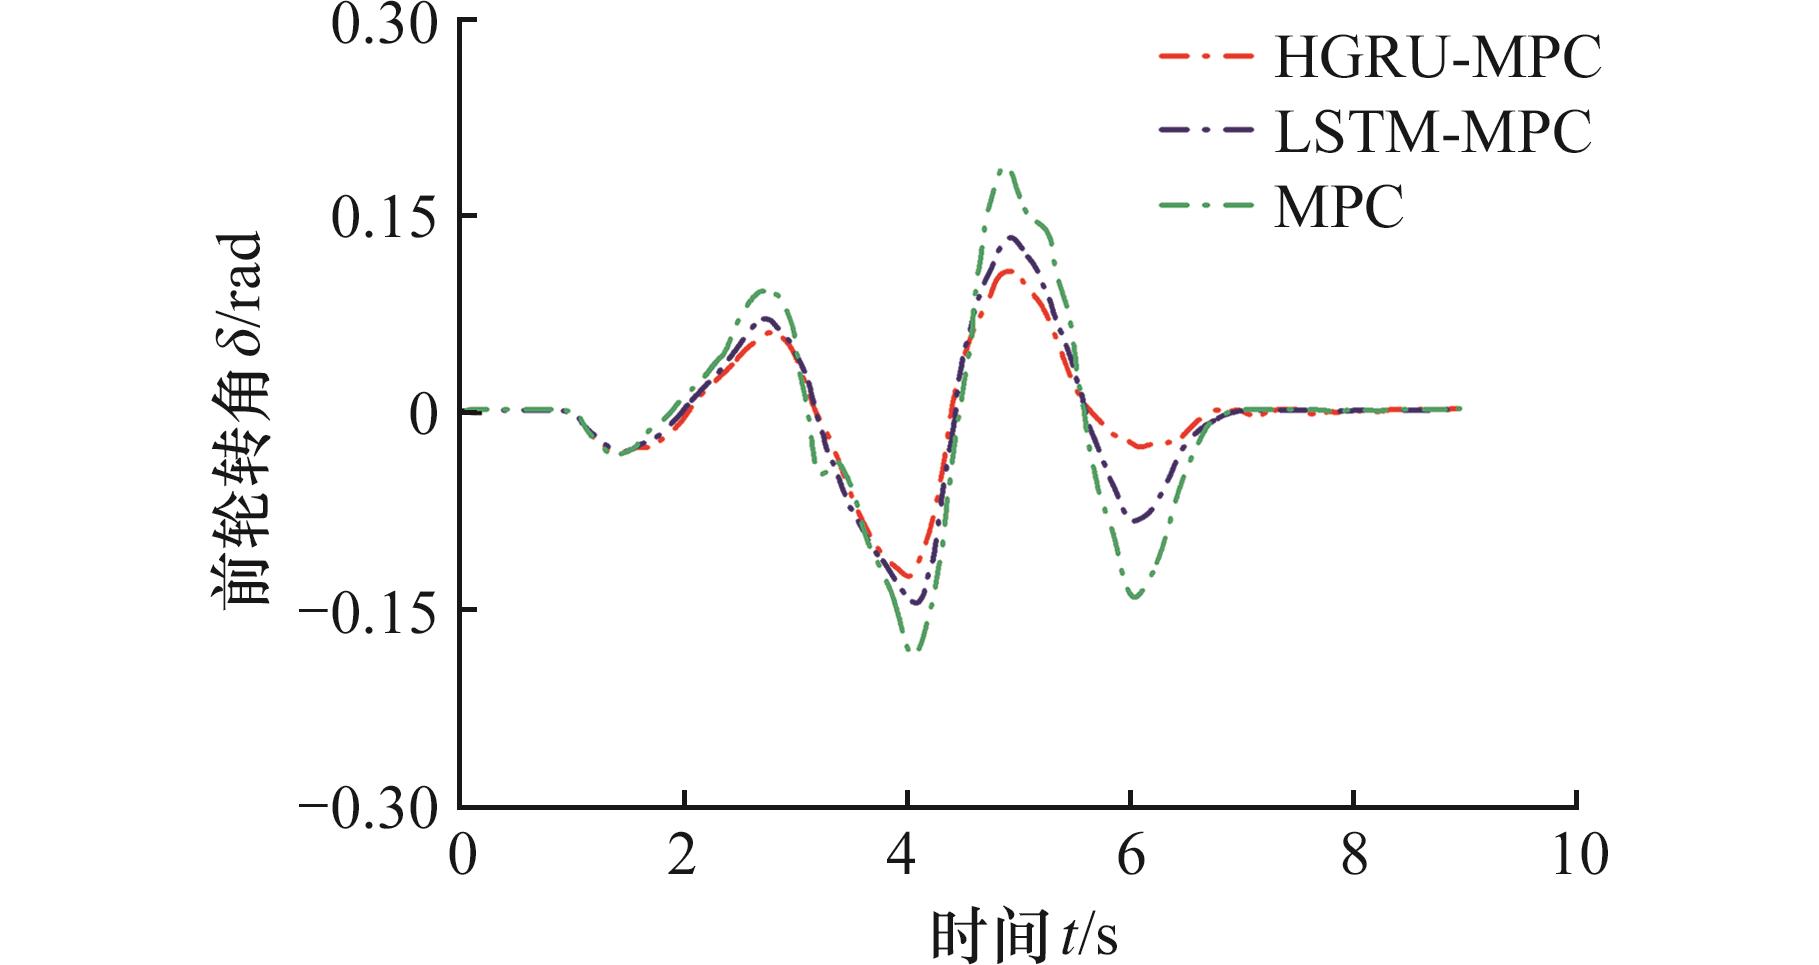
图11 蛇形工况下前轮转角控制量
Fig.11 Front wheel steering angle control input under slalom scenario
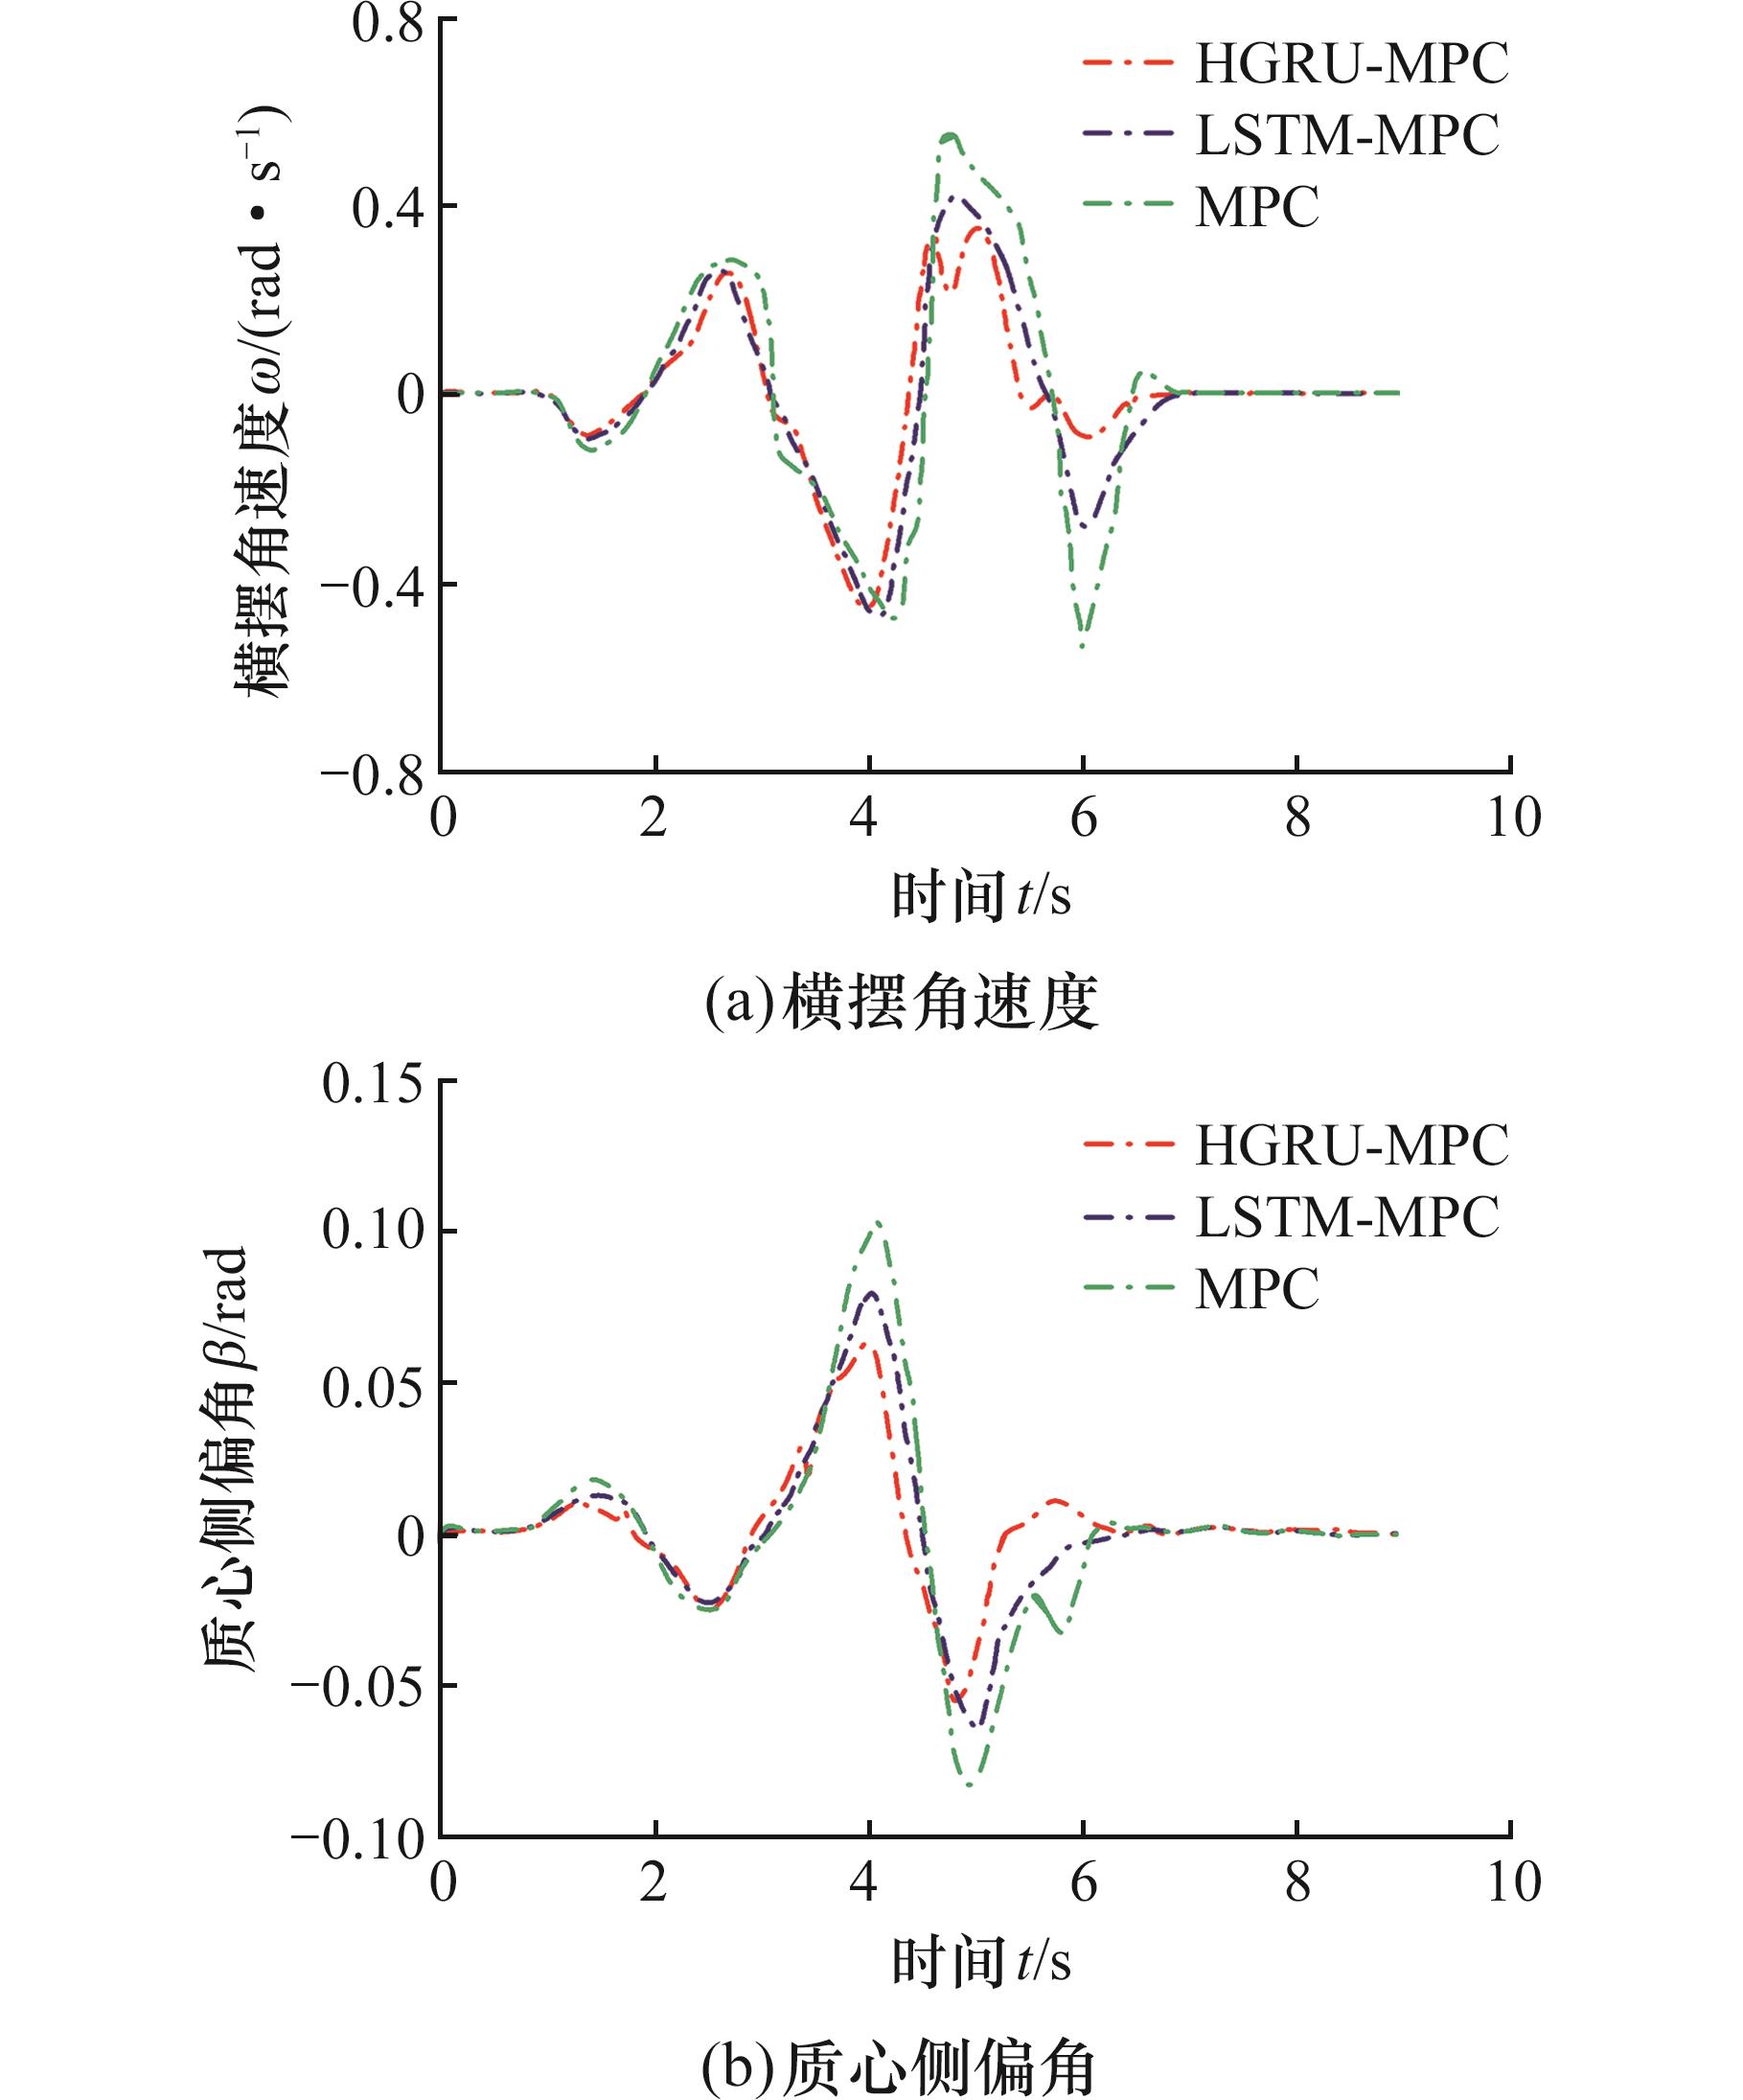
图12 蛇形工况下车辆动力学状态响应
Fig.12 Vehicle dynamic state responses under slalom scenario
| [1] | ZHANG Tantan, SUN Yueshuo, WANG Yazhou, et al. A Survey of Vehicle Dynamics Modeling Methods for Autonomous Racing: Theoretical Models, Physical/Virtual Platforms, and Perspectives[J]. IEEE Transactions on Intelligent Vehicles, 2024, 9(3): 4312-4334. |
| [2] | LU Shengyang, XU Xiaojun, WANG Wenhao. Coupling Dynamic Model of Vehicle-wheel-ground for All-terrain Distributed Driving Unmanned Ground Vehicle[J]. Simulation Modelling Practice and Theory, 2023, 128: 102817. |
| [3] | XU Shaobing, PENG Huei. Design, Analysis, and Experiments of Preview Path Tracking Control for Autonomous Vehicles[J]. IEEE Transactions on Intelligent Transportation Systems, 2020, 21(1): 48-58. |
| [4] | GUO Shuo, ZHAO Youqun, LIN Fen, et al. Steady-state Rolling Resistance Prediction Model of Non-pneumatic Tyres Considering Tread Temperature: Theory and Experiment[J]. Vehicle System Dynamics, 2025, 63(5): 876-896. |
| [5] | YANG Shaopu, LU Yongjie, LI Shaohua. An Overview on Vehicle Dynamics[J]. International Journal of Dynamics and Control, 2013, 1(4): 385-395. |
| [6] | KOUMURA S, OHKITA T. Ride Comfort Evaluation through Analysis of Roll and Lateral Vehicle Behaviors Due to Road Input[J]. SAE International Journal of Passenger Cars - Mechanical Systems, 2008, 1(1): 472-479. |
| [7] | KAZEMI R, KESHAVARZ BAHAGHIGHAT M, PANAHI K. Yaw Moment Control of Four Wheel Steering Vehicle by Fuzzy Approach[C]//2008 IEEE International Conference on Industrial Technology. Chengdu, 2008: 1-7. |
| [8] | 陈慧岩, 陈舒平, 龚建伟. 智能汽车横向控制方法研究综述[J]. 兵工学报, 2017, 38(6): 1203-1214. |
| CHEN Huiyan, CHEN Shuping, GONG Jianwei. A Review on the Research of Lateral Control for Intelligent Vehicles[J]. Acta Armamentarii, 2017, 38(6): 1203-1214. | |
| [9] | QIN Zhaobo, CHEN Liang, HU Manjiang, et al. A Lateral and Longitudinal Dynamics Control Framework of Autonomous Vehicles Based on Multi-parameter Joint Estimation[J]. IEEE Transactions on Vehicular Technology, 2022, 71(6): 5837-5852. |
| [10] | VICENTE B A H, JAMES S S, ANDERSON S R. Linear System Identification versus Physical Modeling of Lateral–Longitudinal Vehicle Dynamics[J]. IEEE Transactions on Control Systems Technology, 2021, 29(3): 1380-1387. |
| [11] | ARBABZADEH N, JAFARI M. A Data-driven Approach for Driving Safety Risk Prediction Using Driver Behavior and Roadway Information Data[J]. IEEE Transactions on Intelligent Transportation Systems, 2018, 19(2): 446-460. |
| [12] | YUE Baifan, CHE Weiwei. Data-driven Dynamic Event-triggered Fault-tolerant Platooning Control[J]. IEEE Transactions on Industrial Informatics, 2023, 19(7): 8418-8426. |
| [13] | DONG Jiachen, LI Jianqiu, GAO Qinhe, et al. Optimal Coordinated Control of Active Steering and Direct Yaw Moment for Distributed-driven Electric Vehicles[J]. Control Engineering Practice, 2023, 134: 105486. |
| [14] | JI Xuewu, HE Xiangkun, Chen LÜ, et al. Adaptive-neural-network-based Robust Lateral Motion Control for Autonomous Vehicle at Driving Limits[J]. Control Engineering Practice, 2018, 76: 41-53. |
| [15] | WU Jingda, HUANG Zhiyu, Chen LÜ. Uncertainty-aware Model-based Reinforcement Learning: Methodology and Application in Autonomous Driving[J]. IEEE Transactions on Intelligent Vehicles, 2023, 8(1): 194-203. |
| [16] | Da LIO M, BORTOLUZZI D, ROSATI PAPINI G P. Modelling Longitudinal Vehicle Dynamics with Neural Networks[J]. Vehicle System Dynamics, 2020, 58(11): 1675-1693. |
| [17] | RAI R, SAHU C K. Driven by Data or Derived through Physics? A Review of Hybrid Physics Guided Machine Learning Techniques with Cyber-physical System (CPS) Focus[J]. IEEE Access, 2020, 8: 71050-71073. |
| [18] | GRÄBER T, LUPBERGER S, UNTERREINER M, et al. A Hybrid Approach to Side-slip Angle Estimation with Recurrent Neural Networks and Kinematic Vehicle Models[J]. IEEE Transactions on Intelligent Vehicles, 2019, 4(1): 39-47. |
| [19] | YANG Da, ZHU Liling, LIU Yalong, et al. A Novel Car-following Control Model Combining Machine Learning and Kinematics Models for Automated Vehicles[J]. IEEE Transactions on Intelligent Transportation Systems, 2019, 20(6): 1991-2000. |
| [20] | ZHOU Zhisong, WANG Yafei, ZHOU Guofeng, et al. Vehicle Lateral Dynamics-inspired Hybrid Model Using Neural Network for Parameter Identification and Error Characterization[J]. IEEE Transactions on Vehicular Technology, 2024, 73(11): 16173-16186. |
| [21] | 方培俊, 蔡英凤, 陈龙, 等. 基于车辆动力学混合模型的智能汽车轨迹跟踪控制方法[J]. 汽车工程, 2022, 44(10): 1469-1483. |
| FANG Peijun, CAI Yingfeng, CHEN Long, et al. Trajectory Tracking Control Method Based on Vehicle Dynamics Hybrid Model for Intelligent Vehicle[J]. Automotive Engineering, 2022, 44(10): 1469-1483. | |
| [22] | WANG Jie, JIANG Zhihao, PANT Y V. Improving Safety in Mixed Traffic: a Learning-based Model Predictive Control for Autonomous and Human-driven Vehicle Platooning[J]. Knowledge-Based Systems, 2024, 293: 111673. |
| [23] | HUANG Keke, WEI Ke, LI Fanbiao, et al. LSTM-MPC: a Deep Learning Based Predictive Control Method for Multimode Process Control[J]. IEEE Transactions on Industrial Electronics, 2023, 70(11): 11544-11554. |
| [24] | CHEN Jianwei, YU Chuanqiang, WANG Yafei, et al. Hybrid Modeling for Vehicle Lateral Dynamics via AGRU with a Dual-attention Mechanism under Limited Data[J]. Control Engineering Practice, 2024, 151: 106015. |
| [25] | SALZMANN T, KAUFMANN E, ARRIZABALAGA J, et al. Real-time Neural MPC: Deep Learning Model Predictive Control for Quadrotors and Agile Robotic Platforms[J]. IEEE Robotics and Automation Letters, 2023, 8(4): 2397-2404. |
| [26] | 韩陌, 何洪文, 石曼, 等. 基于学习的无人驾驶车辆模型预测路径跟踪控制研究[J]. 汽车工程, 2024, 46(7): 1197-1207. |
| HAN Mo, HE Hongwen, SHI Man, et al. Research on Learning-based Model Predictive Path Tracking Control for Autonomous Vehicles[J]. Automotive Engineering, 2024, 46(7): 1197-1207. | |
| [27] | REN Lichuan, XI Zhimin. Bias-learning-based Model Predictive Controller Design for Reliable Path Tracking of Autonomous Vehicles under Model and Environmental Uncertainty[J]. Journal of Mechanical Design, 2022, 144(9): 091706. |
| [1] | 林歆悠, 金忠伟, 唐云亮. 融合道路曲率前馈的车辆横向控制策略[J]. 中国机械工程, 2025, 36(11): 2774-2782. |
| [2] | 孔慧芳, 王晨顺, 张倩, 刘田阔. 基于时空风险场的智能车辆轨迹规划[J]. 中国机械工程, 2025, 36(10): 2463-2471. |
| [3] | 阚小博1, 赵又群1, 李丹阳1, 林棻1, 何鲲鹏1, 2, 尤庆伸2. 基于非线性模型预测控制的分布式驱动电动汽车多目标扭矩协调控制[J]. 中国机械工程, 2025, 36(05): 1123-1131. |
| [4] | 张玮1, 高爱云1, 付主木2, 赵恩会1, 陈芊安1. 计及质心侧偏角动态自适应的无人驾驶汽车横坡弯道跟踪控制[J]. 中国机械工程, 2024, 35(06): 962-972. |
| [5] | 何智成1, 王煜凡1, 韦宝侣1, 2, 李智1, 卜腾辰1. 基于优化动力学模型的路径跟踪控制研究[J]. 中国机械工程, 2024, 35(06): 1000-1009. |
| [6] | 刘俊玲, 冯港辉, 张俊江, 杨凯. 无人驾驶混合动力汽车轨迹跟踪节能控制融合研究[J]. 中国机械工程, 2024, 35(04): 678-690. |
| [7] | 屈小章, 张加贝, 翟方志. 非随机载荷不确定的机车侧墙过滤系统两相流可靠性分析[J]. 中国机械工程, 2023, 34(15): 1881-1889. |
| [8] | 张荣珅, 王玉田, 胡荣权, 杨灵芳, 黄智. 名义代价期望目标下的智能车辆困境避险规划[J]. 中国机械工程, 2022, 33(15): 1849-1856. |
| [9] | 雷超凡, 初秀民, 柳晨光, 吴文祥, 李松龙, . 船闸水域船舶列队协同停船预测控制器[J]. 中国机械工程, 2022, 33(04): 421-431. |
| [10] | 夏光, 李嘉诚, 唐希雯, 张洋, 陈无畏. 平衡重式叉车防侧翻模型预测控制研究[J]. 中国机械工程, 2021, 32(08): 987-996. |
| [11] | 李茂月;吕虹毓;王飞;贾冬开. 基于机器视觉的智能车辆鲁棒车道线识别方法[J]. 中国机械工程, 2021, 32(02): 242-251. |
| [12] | 韩玲, 刘鸿祥, 曹越, 任磊磊. 基于模型预测控制的无级变速起步优化控制策略[J]. 中国机械工程, 2020, 31(15): 1765-1771. |
| [13] | 白国星1;孟宇1,2;刘立1;顾青1;罗维东1;甘鑫1. 基于可变预测时域及速度的车辆路径跟踪控制[J]. 中国机械工程, 2020, 31(11): 1277-1284. |
| [14] | 蔡英凤1;李健2;孙晓强1;陈龙1;江浩斌2;何友国1;陈小波1. 智能汽车路径跟踪混合控制策略研究[J]. 中国机械工程, 2020, 31(03): 289-298. |
| [15] | 詹君1;程龙生1;彭宅铭1;胡多海2. 基于混合模型与改进多分类马田系统的控制图模式识别[J]. 中国机械工程, 2019, 30(22): 2716-2724. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
