中国机械工程 ›› 2026, Vol. 37 ›› Issue (9): 2259-2267.DOI: 10.3969/j.issn.1004-132X.2026.09.018

• 机械基础工程 • 上一篇    

基于分层种群策略的机器人静刚度位姿优化

潘彬晖(), 杨建中, 黄思(), 吴浩天, 宁晓   

  1. 华中科技大学机械科学与工程学院国家智能设计与数控技术创新中心, 武汉, 430074
  • 收稿日期:2025-03-19 出版日期:2026-09-25 发布日期:2026-10-21
  • 通讯作者: 黄思
  • 作者简介:潘彬晖,男,2001年生,硕士研究生。研究方向为机器人刚度。E-mail: panbinhui@hust.edu.cn
    黄思*(通信作者),女,1988年生,工程师。研究方向为机器人刚度。E-mail: huangsi@hust.edu.cn。
  • 基金资助:
    湖北省重大科技攻关项目(2023BAA010)

Robot Static Stiffness Pose Optimization Based on Hierarchical Population Strategy

PAN Binhui(), YANG Jianzhong, HUANG Si(), WU Haotian, NING Xiao   

  1. National Intelligent Design and Numerical Control Technology Innovation Center,School of Mechanical Science and Engineering,Huazhong University of Science and Technology,Wuhan,430074
  • Received:2025-03-19 Online:2026-09-25 Published:2026-10-21
  • Contact: HUANG Si

摘要:

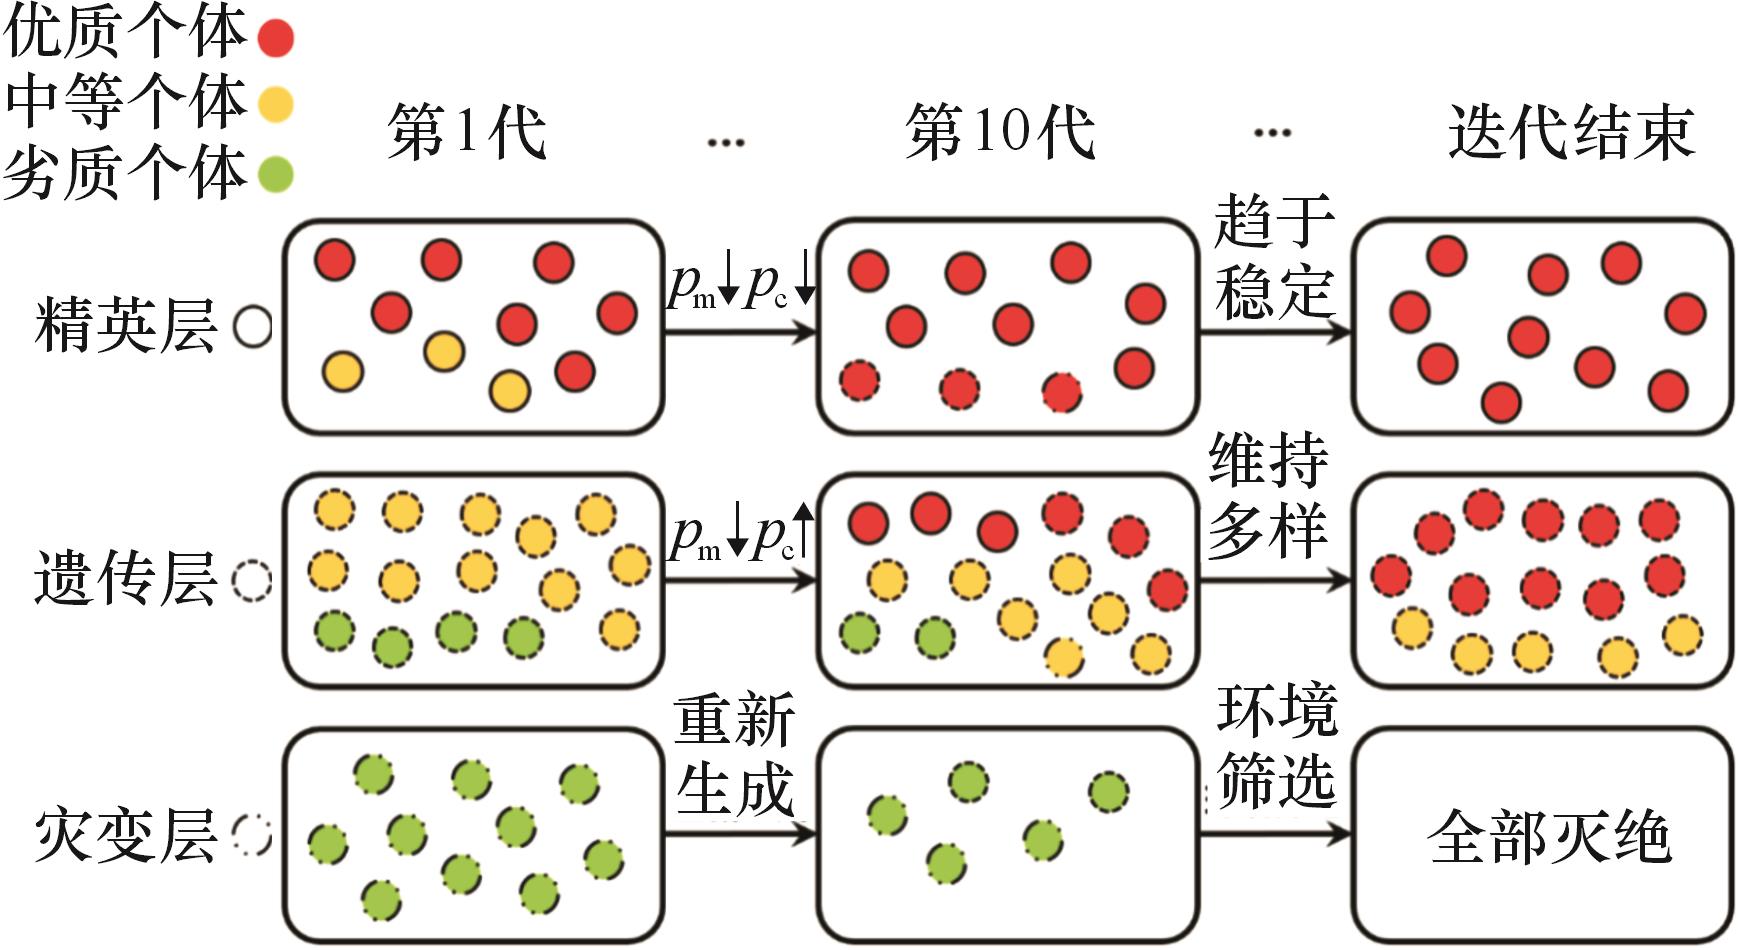
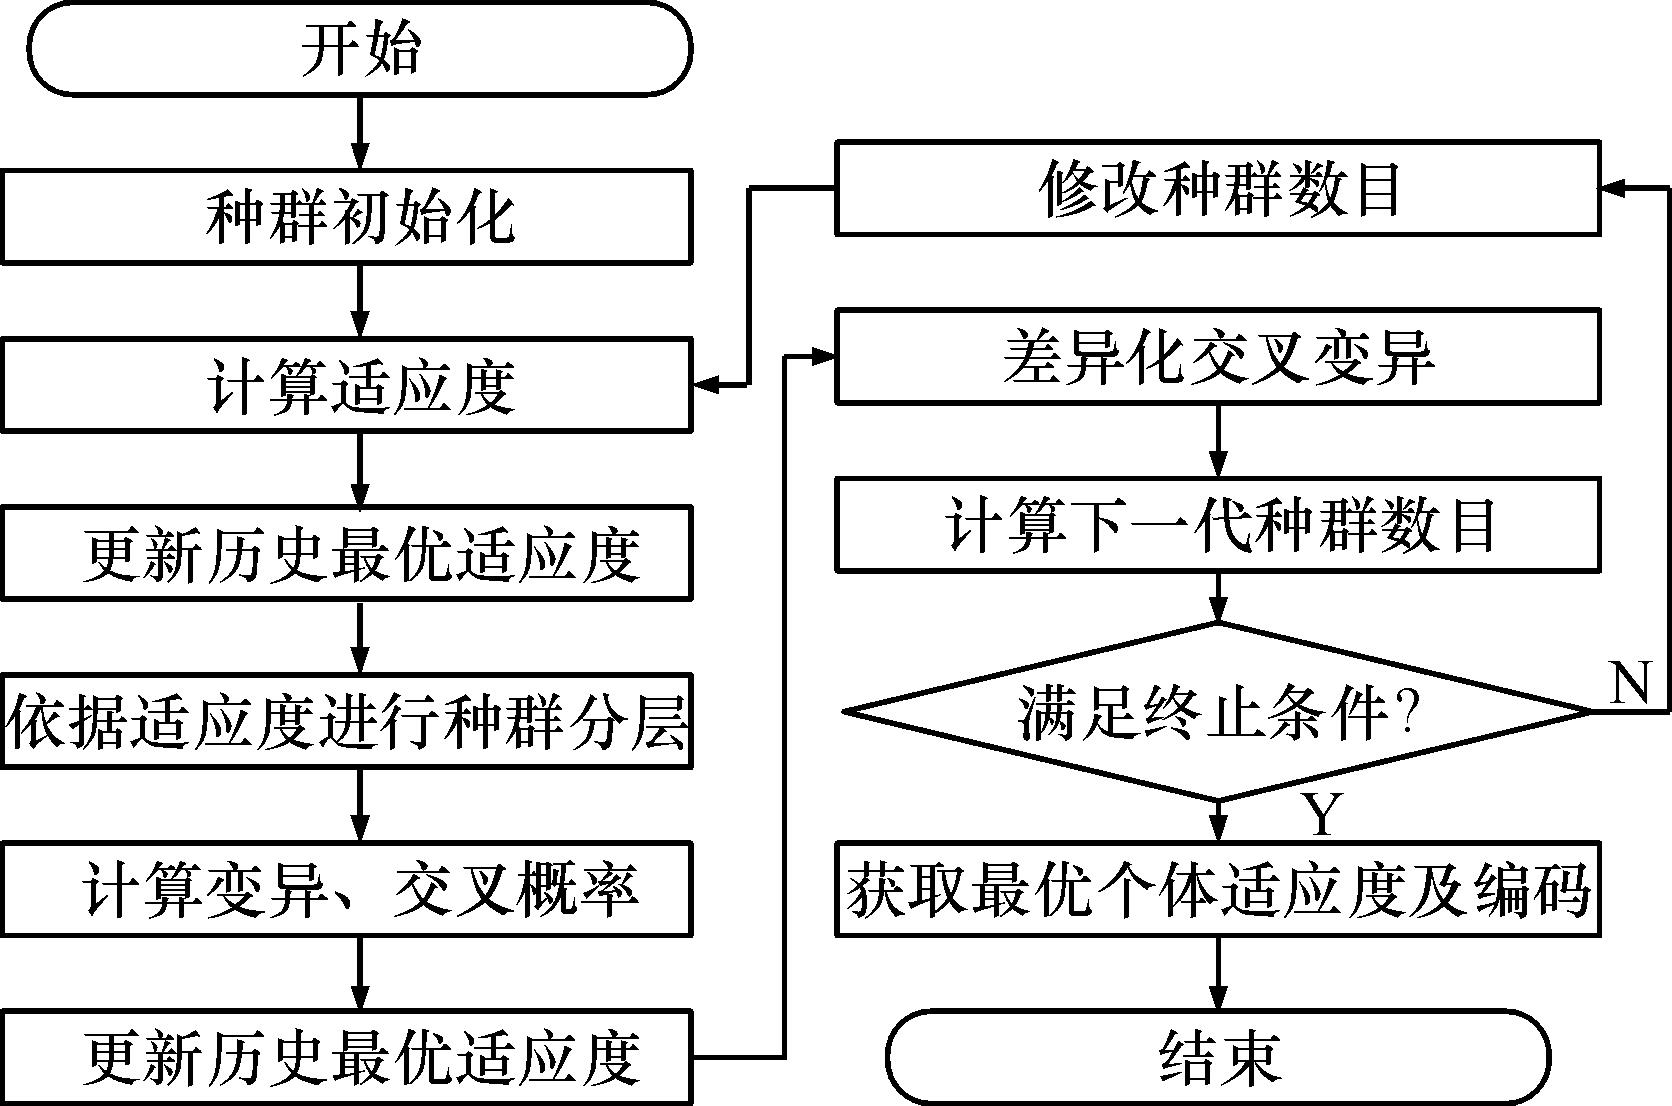
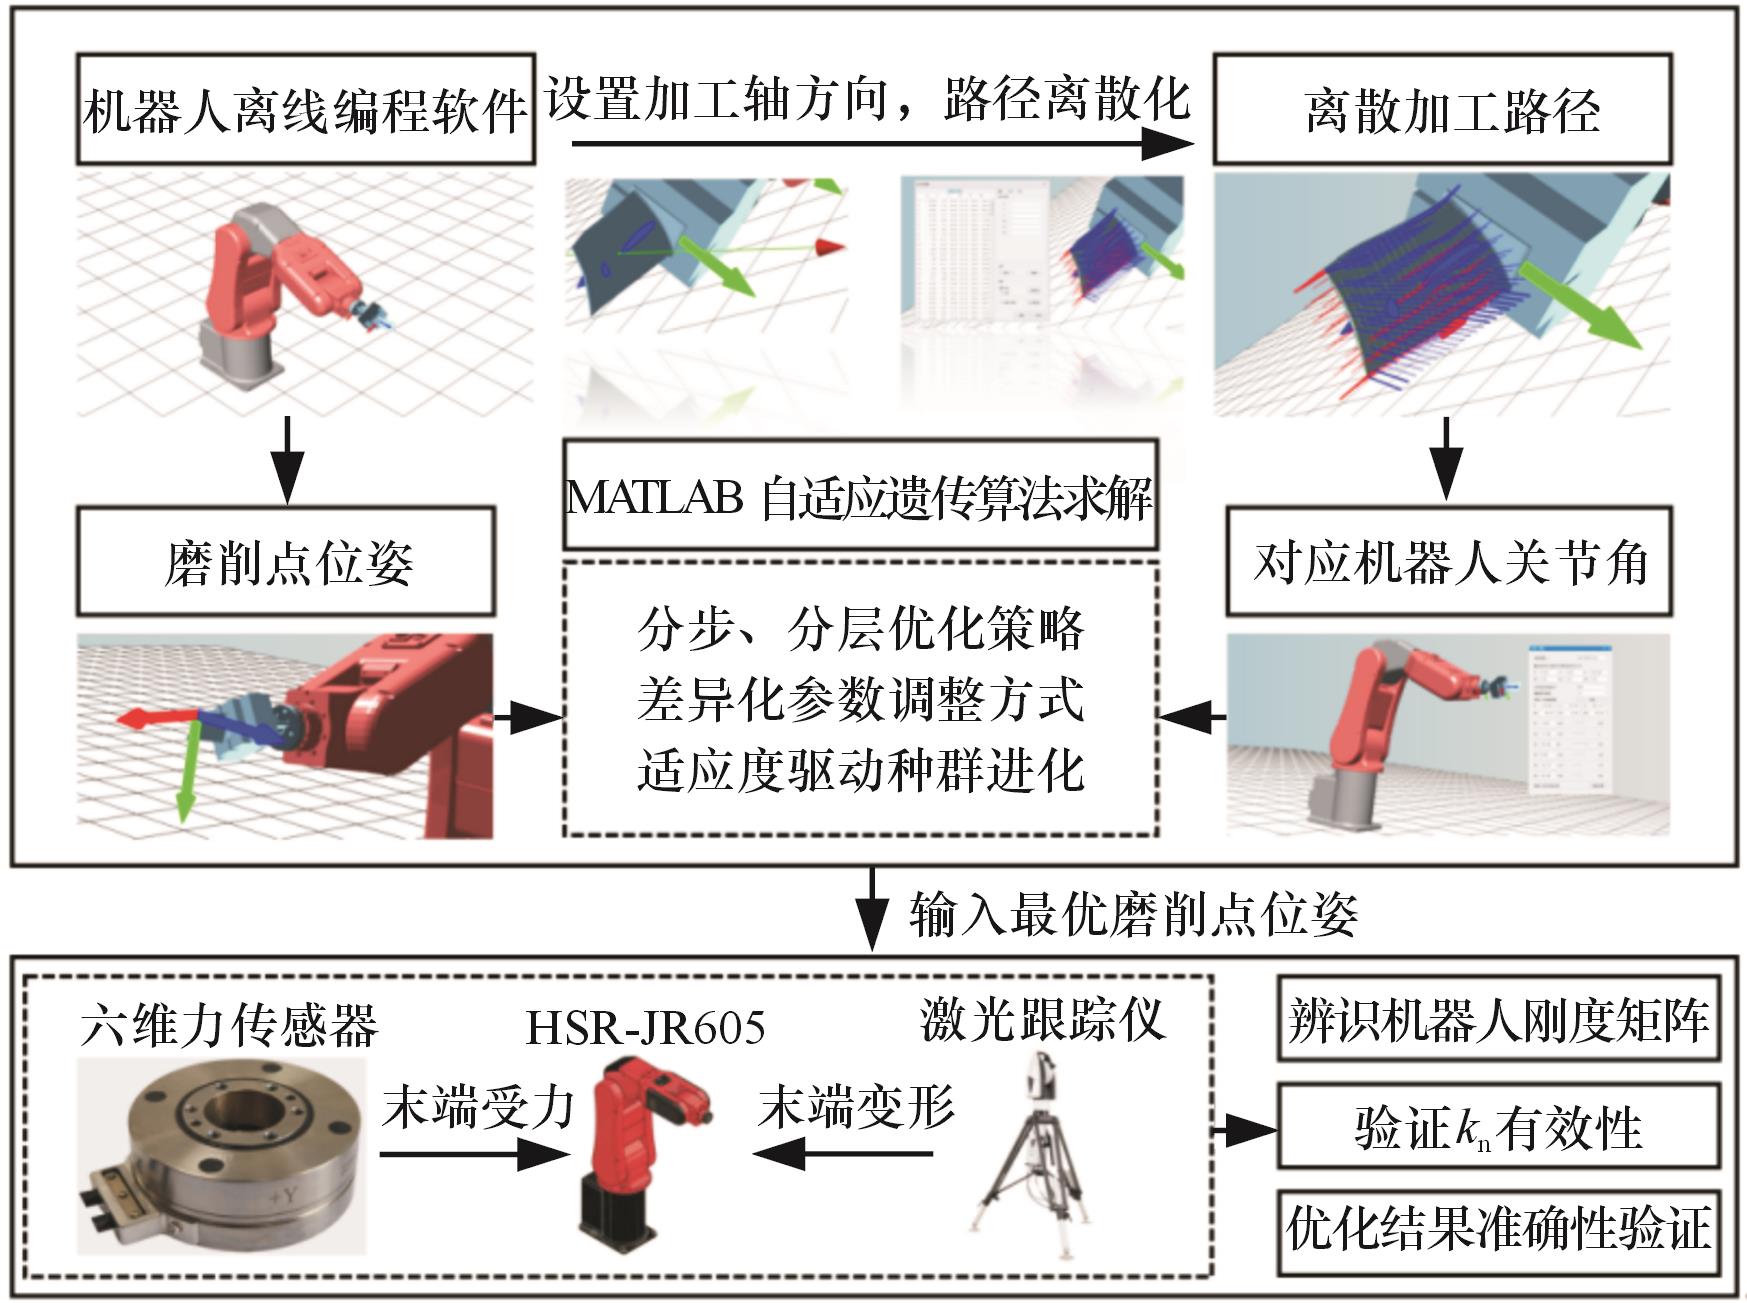
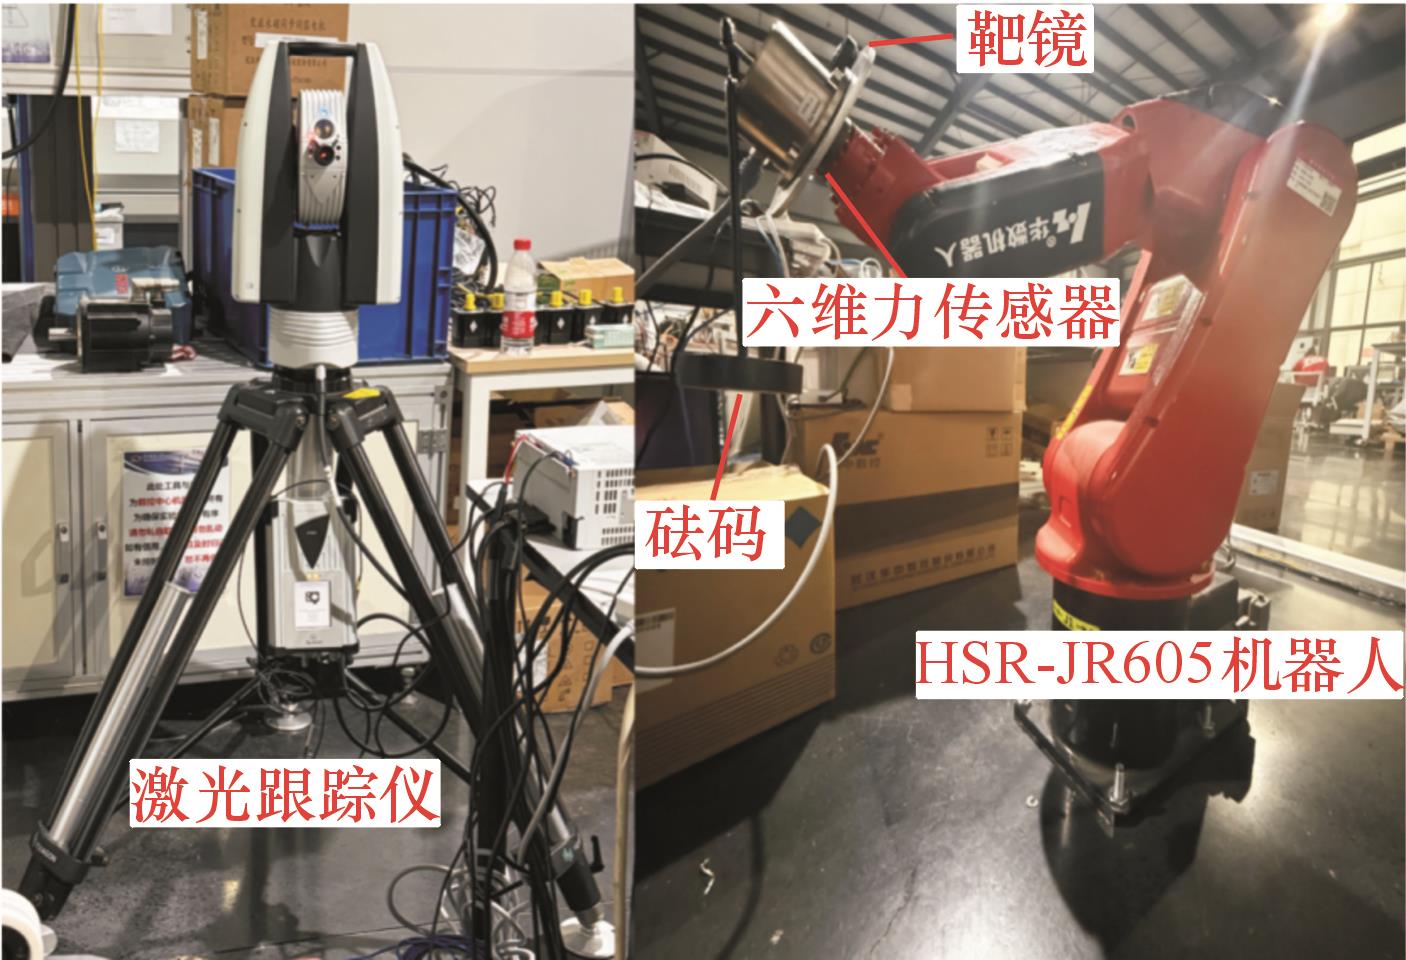
提出了一种面向精密磨抛场景的刚度性能指标,基于分层自适应遗传算法优化位姿以提高机器人刚度。构建了机器人运动学与静刚度模型,并通过关节刚度辨识实验获取操作刚度矩阵;以机器人磨削点处的柔度椭球为依据,结合磨抛路径上的机器人刚度及其稳定性,设计了适用于磨抛工况的综合刚度性能指标;引入适应度驱动的参数调整和种群分层机制,针对种群不同层使用差异化遗传策略,对磨削点位姿进行优化。实验结果表明,在不改变机器人结构和材料的情况下,变形量降低了约80%,机器人刚度得到有效提高。

关键词: 机器人磨抛, 刚度辨识, 综合刚度性能指标, 分层种群策略, 磨削点位姿优化

Abstract:

A stiffness performance index for precision grinding and polishing scene was proposed, and the robot stiffness was improved based on hierarchical adaptive genetic algorithm. The kinematics and static stiffness models of the robots were constructed, and the operational stiffness matrix was obtained through the joint stiffness identification experiments. Based on the flexibility ellipsoid at the grinding points of the robots, combined with the stiffness and stability of the robots on the grinding and polishing paths, a comprehensive stiffness performance index was designed for grinding and polishing conditions. Fitness-driven parameter adjustment and population stratification mechanism were introduced, and differentiated genetic strategies were used to optimize the grinding point posture for different layers of the population. The experimental results show that, without changing the structure and material of the robots, the deformation amounts reduce by 80%, and the robot stiffness is effectively improved.

Key words: robot grinding and polishing, stiffness identification, comprehensive stiffness performance index, hierarchical population strategy, grinding point posture optimization

中图分类号: