ISSN 1004-132X
CN 42-1294/TH
CN 42-1294/TH
中国机械工程 ›› 2026, Vol. 37 ›› Issue (9): 2185-2193.DOI: 10.3969/j.issn.1004-132X.2026.09.011
• 机械基础工程 • 上一篇
朱佳怡1( ), 高杰1(), 高亮2, 曹淮2
收稿日期:2025-04-11
出版日期:2026-09-25
发布日期:2026-10-21
通讯作者:
高杰
作者简介:朱佳怡,女,2000 年生,博士研究生。研究方向为拓扑优化。 E-mail:zhujiayi@hust.edu.cn基金资助:
ZHU Jiayi1(), GAO Jie1(), GAO Liang2, CAO Huai2
Received:2025-04-11
Online:2026-09-25
Published:2026-10-21
Contact:
GAO Jie
摘要:
目前在双足机器人轻量化设计过程中,许多零件的优化设计仍未能获得理想的结构形态,最终只能依靠设计者的经验进行后续的调整和修正。基于此,对现有的拓扑优化方法进行了系统梳理,并将其引入机械大腿的结构设计中。通过构建机械大腿轻量化优化设计的数学模型,并按照拓扑优化的流程对机械大腿的初始设计几何模型进行了不同单元密度和优化最小尺寸的减重设计,最终获得了四种拓扑结构,分别使质量减小了535.4 g、494.3 g、423.8 g和569.2 g。根据实际工况和机加工工艺的要求,选择了第三种方案进行强度仿真校核,仿真结果表明,与已加工构型相比,在设定分布力的工况下,优化设计的最大位移变形量为0.9012 mm,明显小于原设计的最大位移变形量1.188 mm;在设定分布力及力矩合力的工况下,最大位移变形量为1.799 mm,也小于原设计的最大位移变形量2.377 mm。部件质量减小了38.45%,优化设计的性能表现优于原设计,验证了有限元模型的准确性及优化设计的有效性。
中图分类号:
朱佳怡, 高杰, 高亮, 曹淮. 轻量化液压双足机器人机械腿拓扑优化设计[J]. 中国机械工程, 2026, 37(9): 2185-2193.
ZHU Jiayi, GAO Jie, GAO Liang, CAO Huai. Topology Optimization for Lightweight Design of Mechanical Legs of Hydraulic Bipedal Robots[J]. China Mechanical Engineering, 2026, 37(9): 2185-2193.
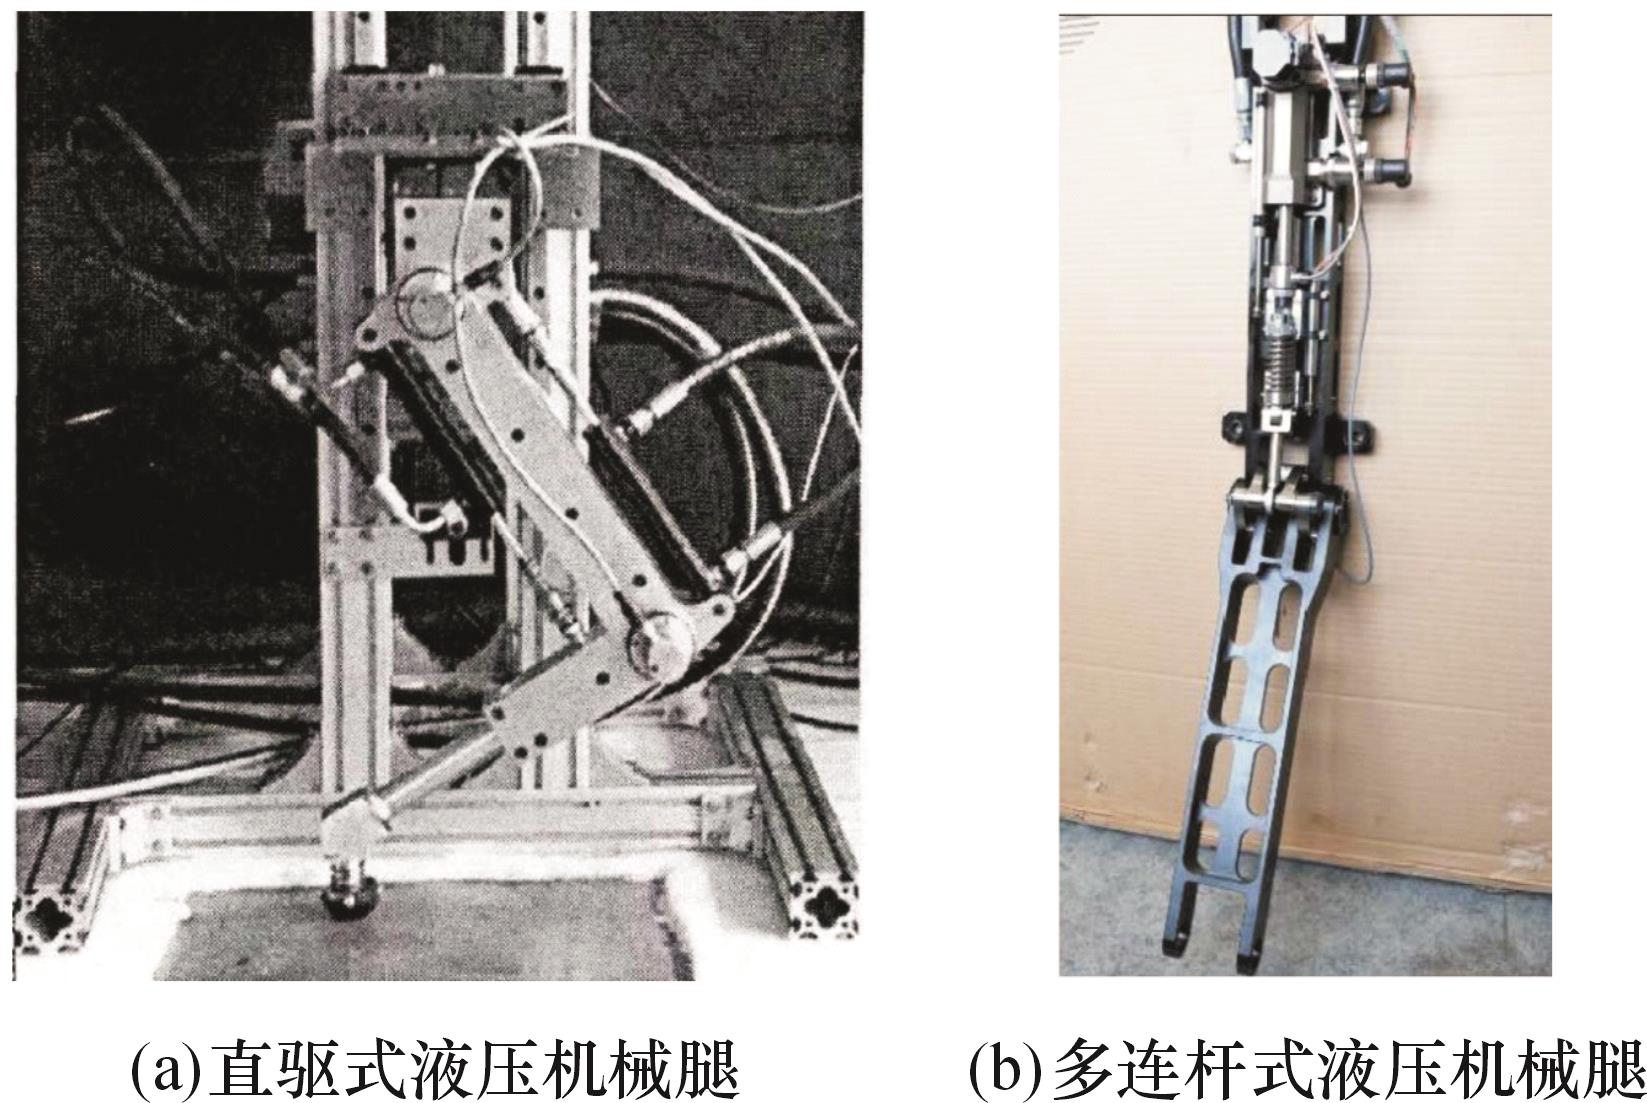
图1 液压机械腿
Fig.1 Hydraulic mechanical leg
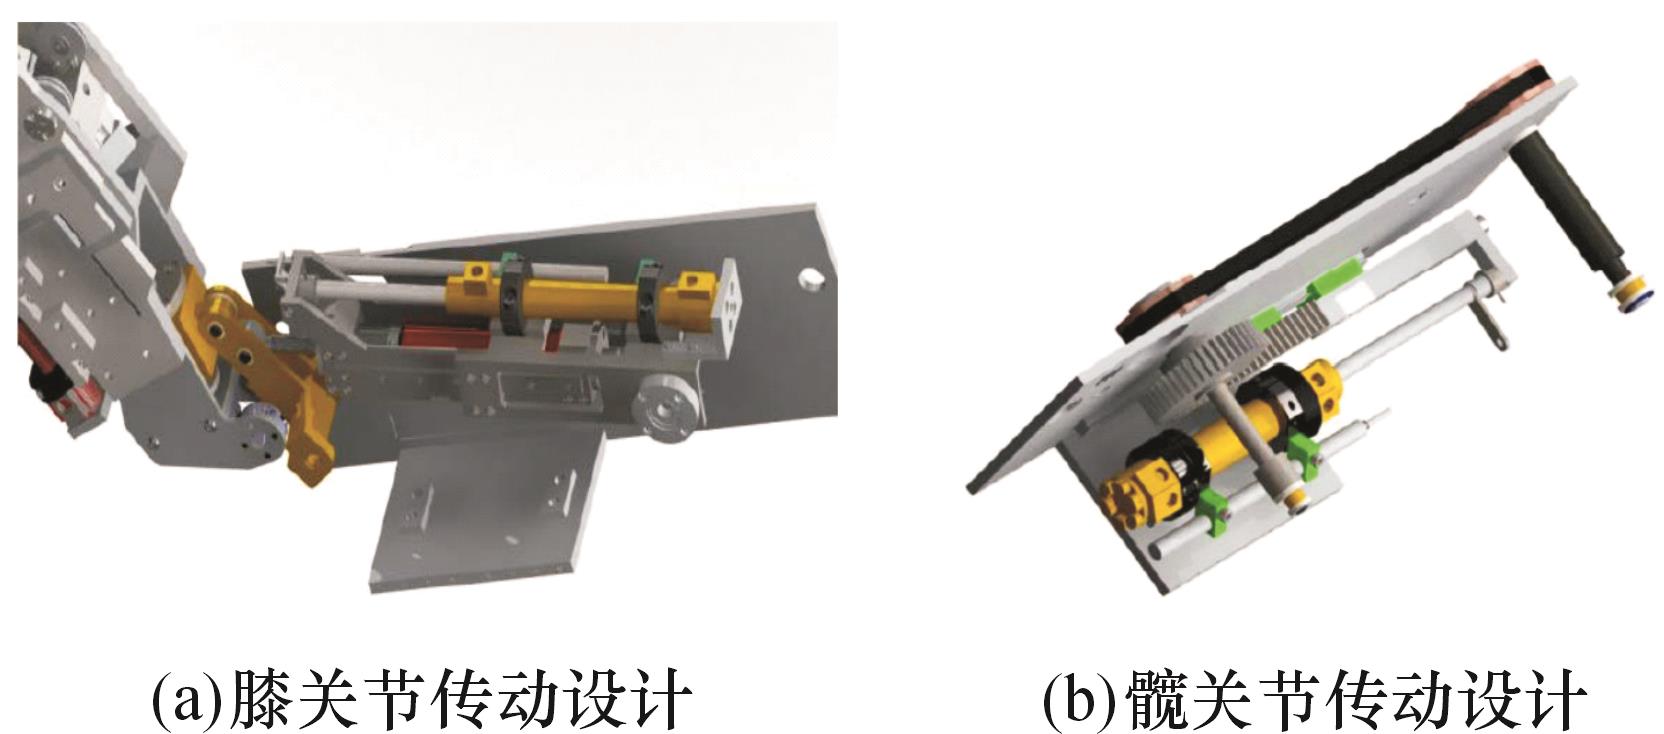
图2 机械腿结构设计
Fig.2 Design of mechanical leg
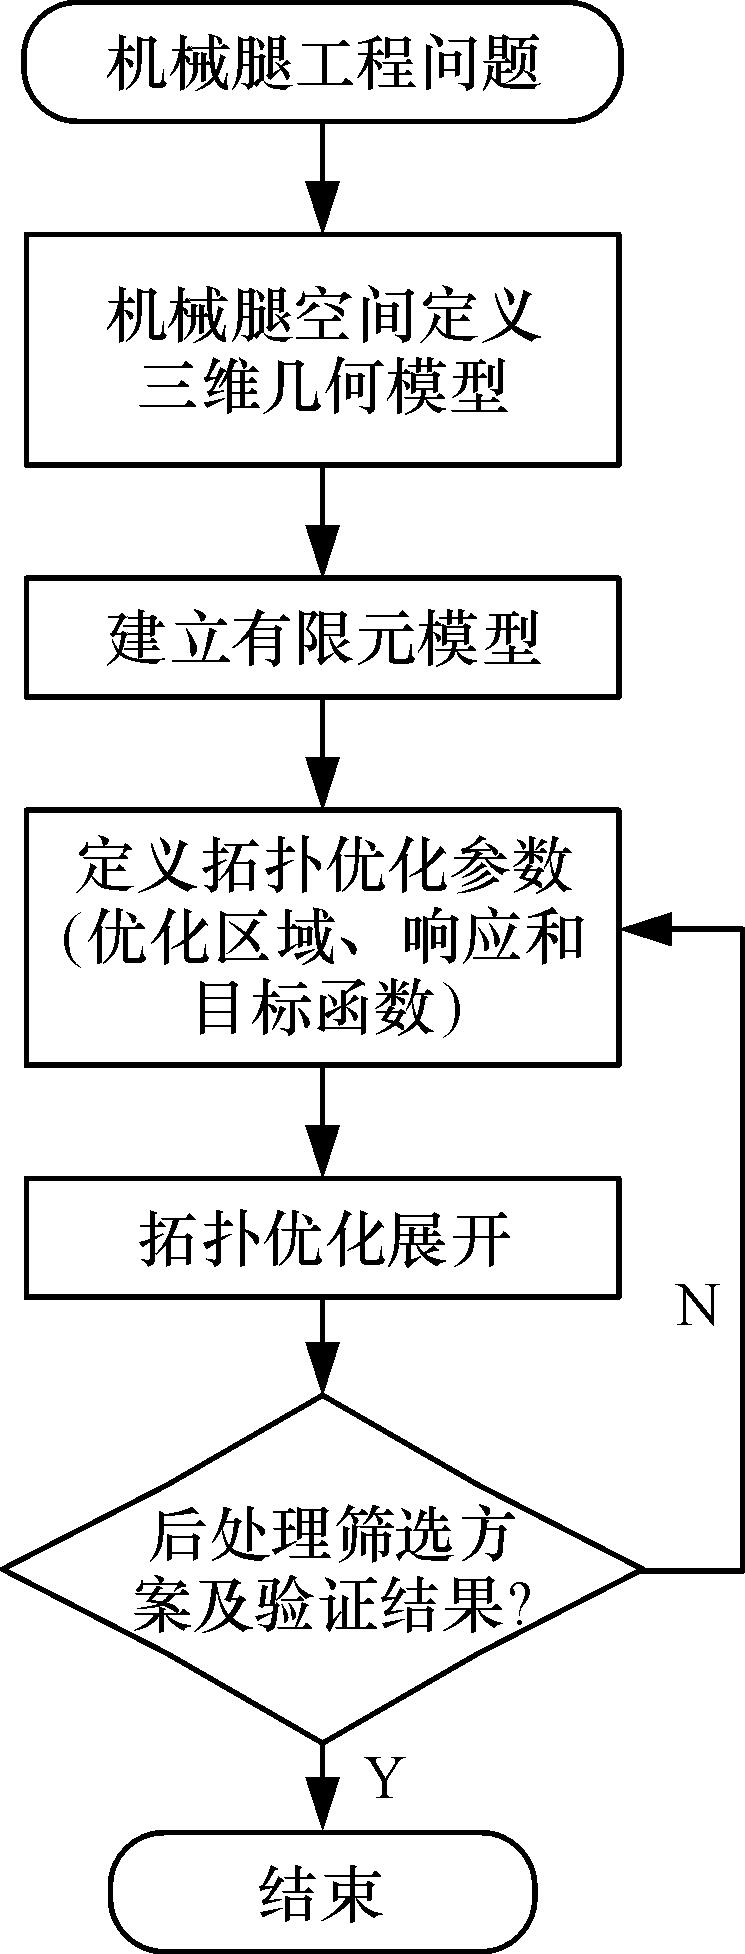
图3 机械腿拓扑优化流程图
Fig.3 Flow chart of robot leg topology optimization
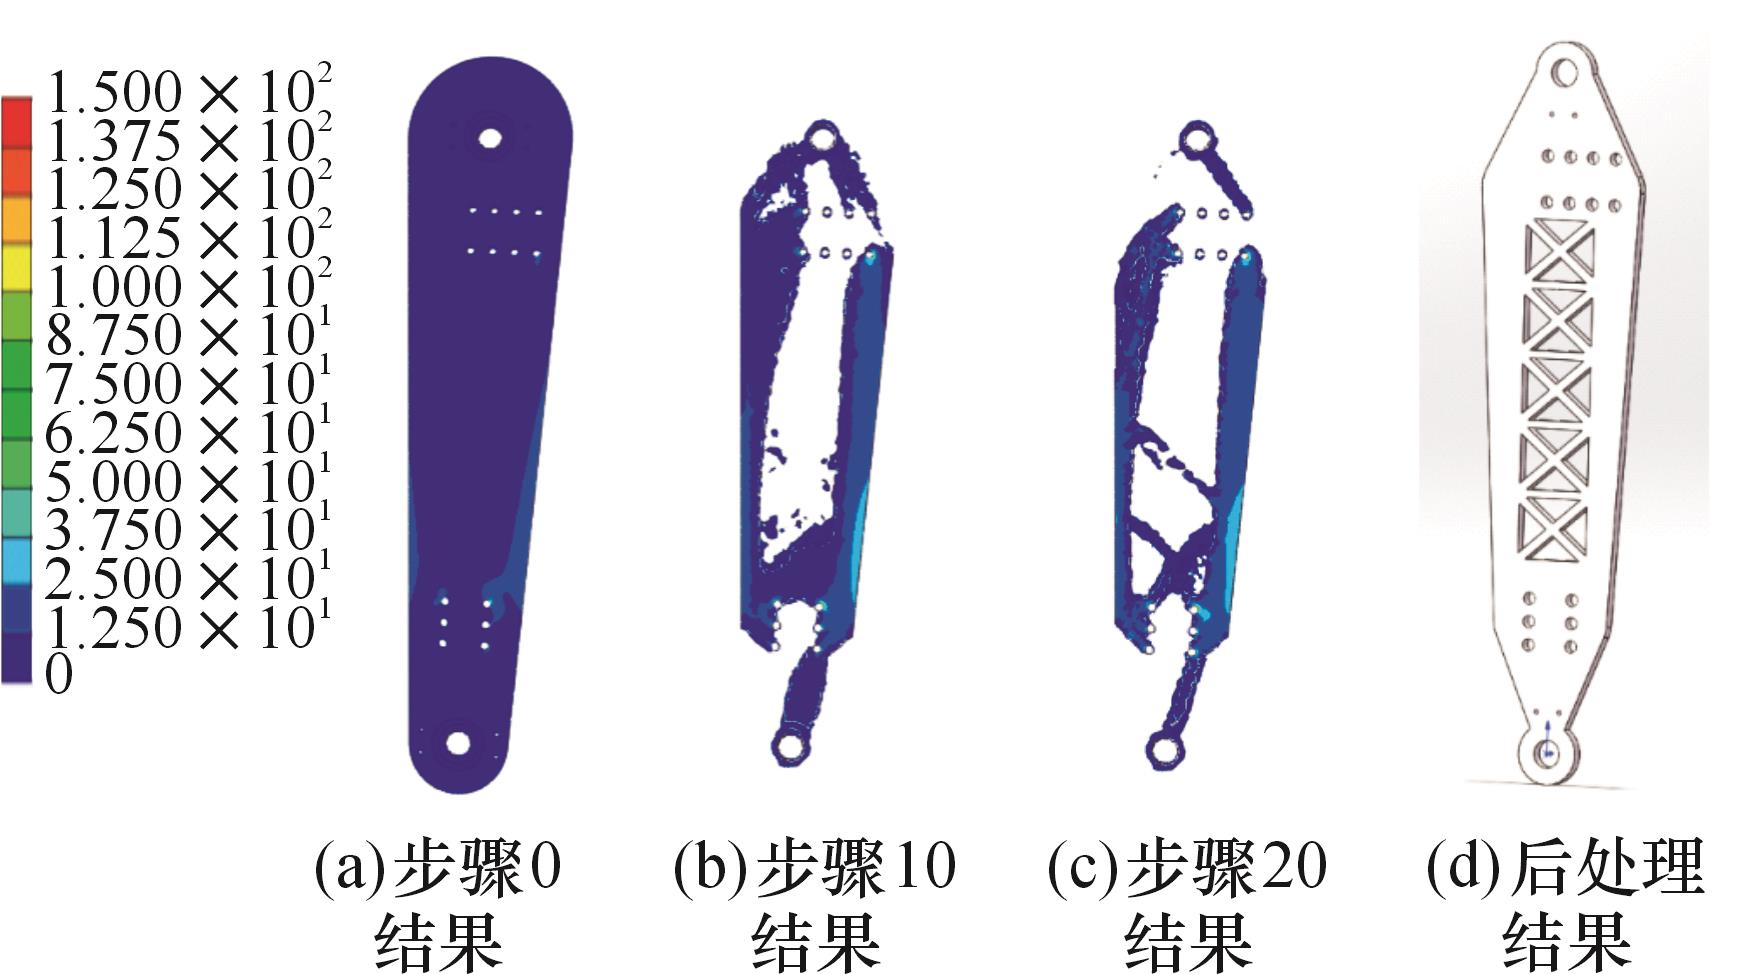
图4 已加工设计配置过程
Fig.4 Process of the processed design configuration
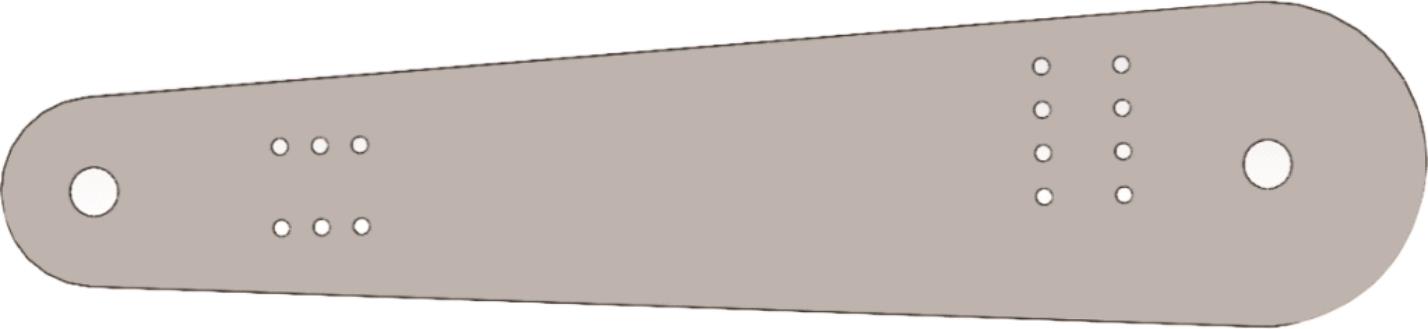
图5 初始构型样式
Fig.5 Initial configuration style
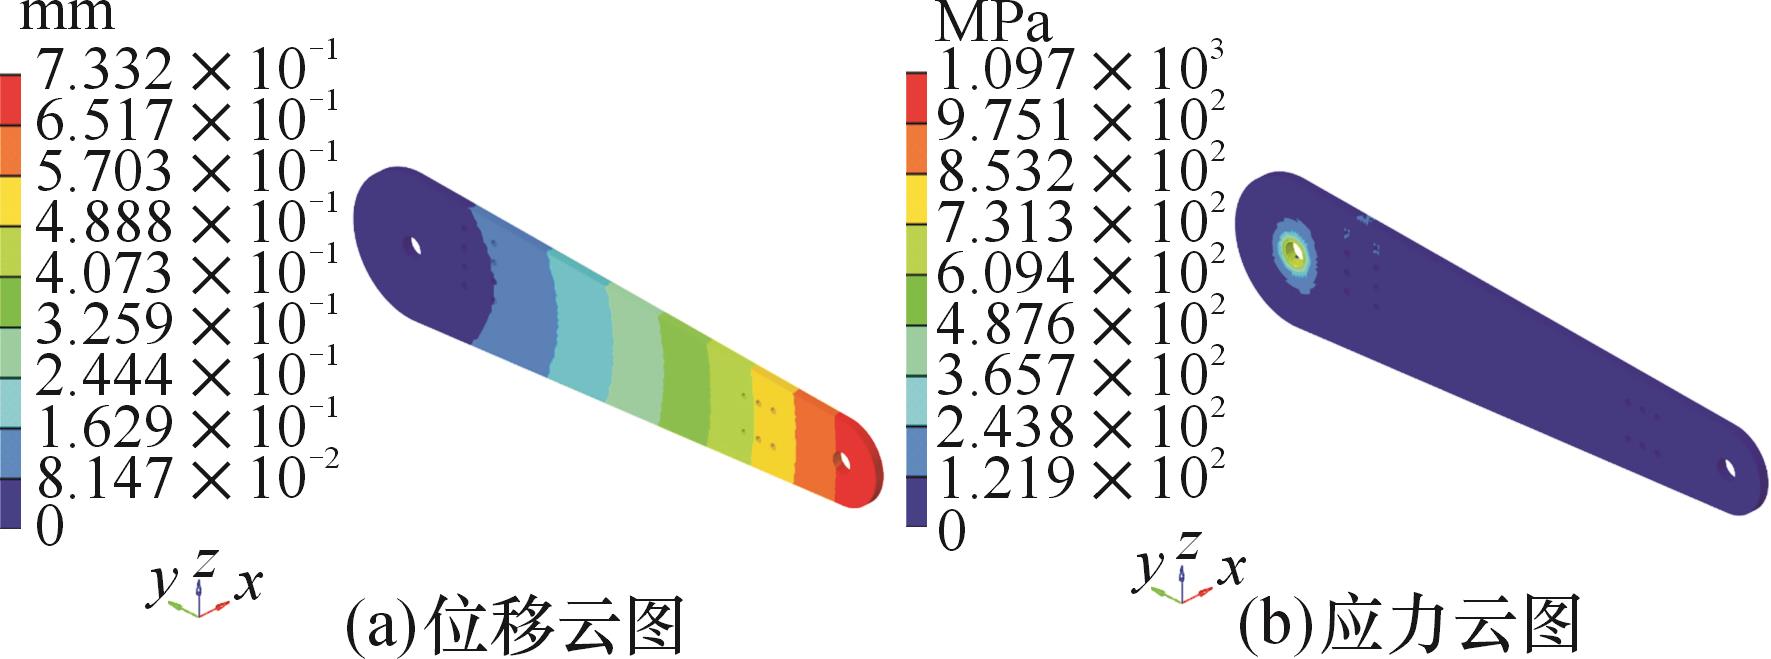
图6 机械大腿初始构型分析结果
Fig.6 Analysis results of the initial configuration of the mechanical thigh
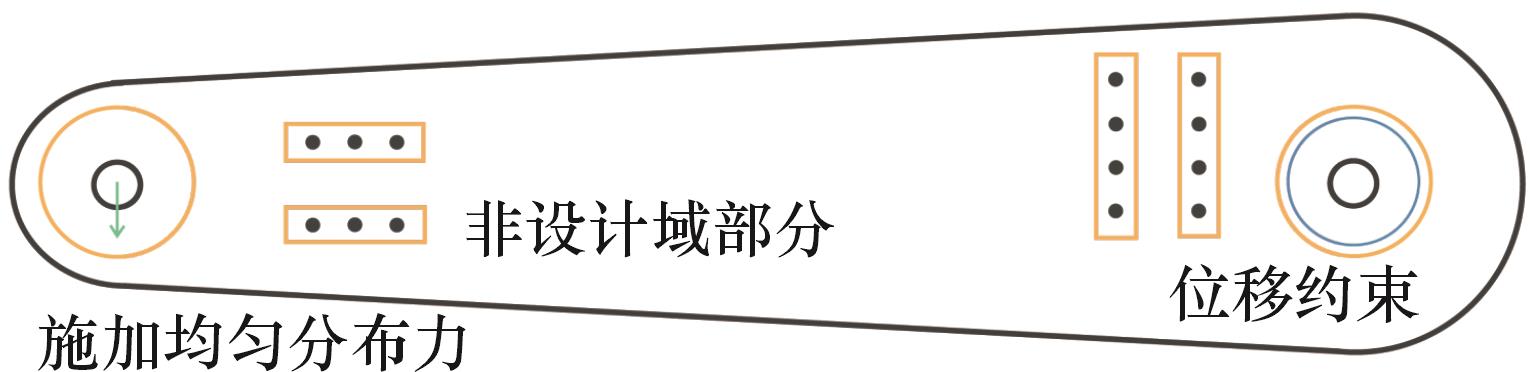
图7 拓扑结构优化区域设置
Fig.7 Topology optimization area settings
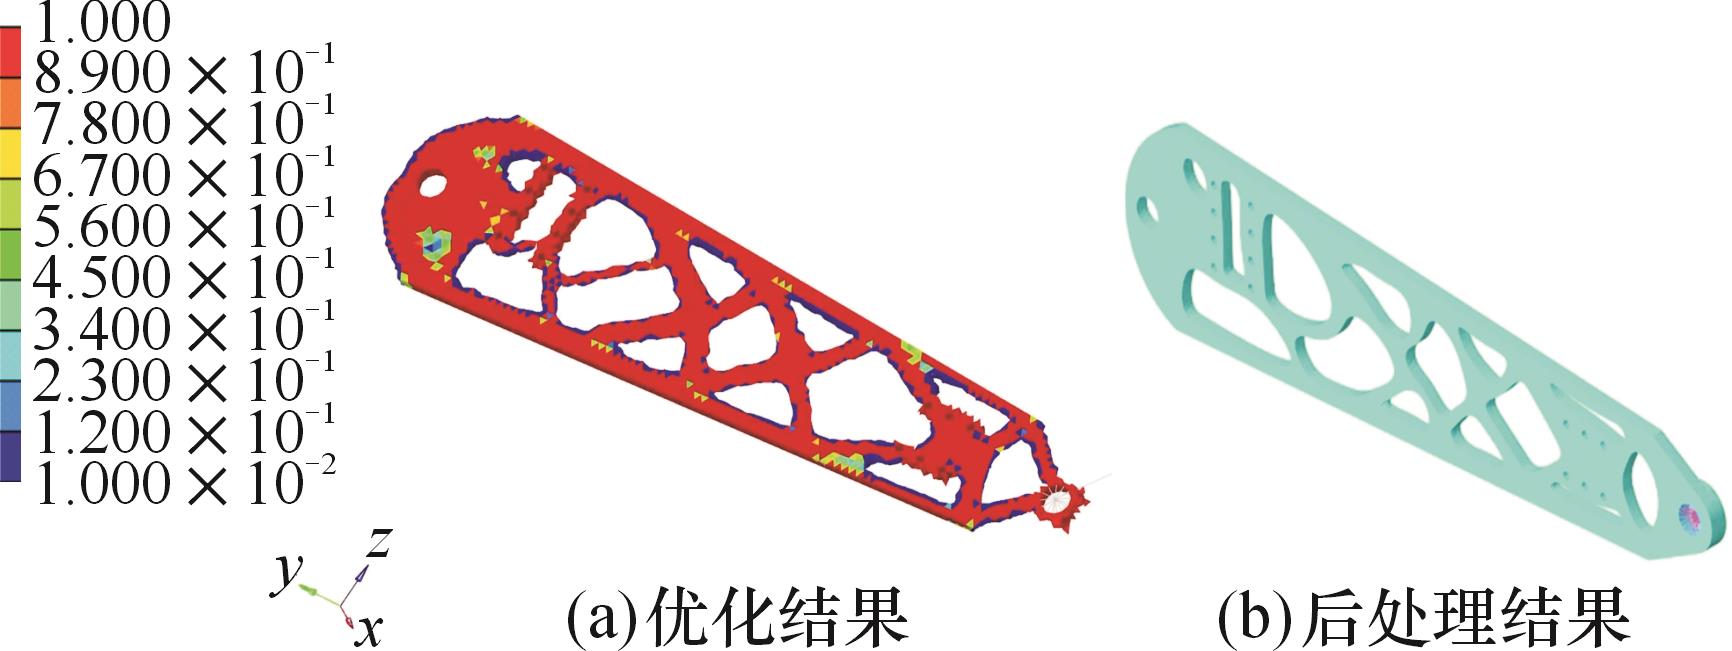
图8 方案一拓扑优化设计结果
Fig.8 Topology optimization design results of scheme 1
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 566.8 | 48.58 |
| 设定分布力的工况情况下位移变形量/mm | 1.188 | 1.035 | 12.88 |
| 设定分布力及力矩合力的工况下位移变形量/mm | 2.337 | 2.171 | 7.11 |
表1 方案一机器人机械腿拓扑优化结果对比
Tab.1 Comparison of topology optimization results of robot legs in scheme 1
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 566.8 | 48.58 |
| 设定分布力的工况情况下位移变形量/mm | 1.188 | 1.035 | 12.88 |
| 设定分布力及力矩合力的工况下位移变形量/mm | 2.337 | 2.171 | 7.11 |
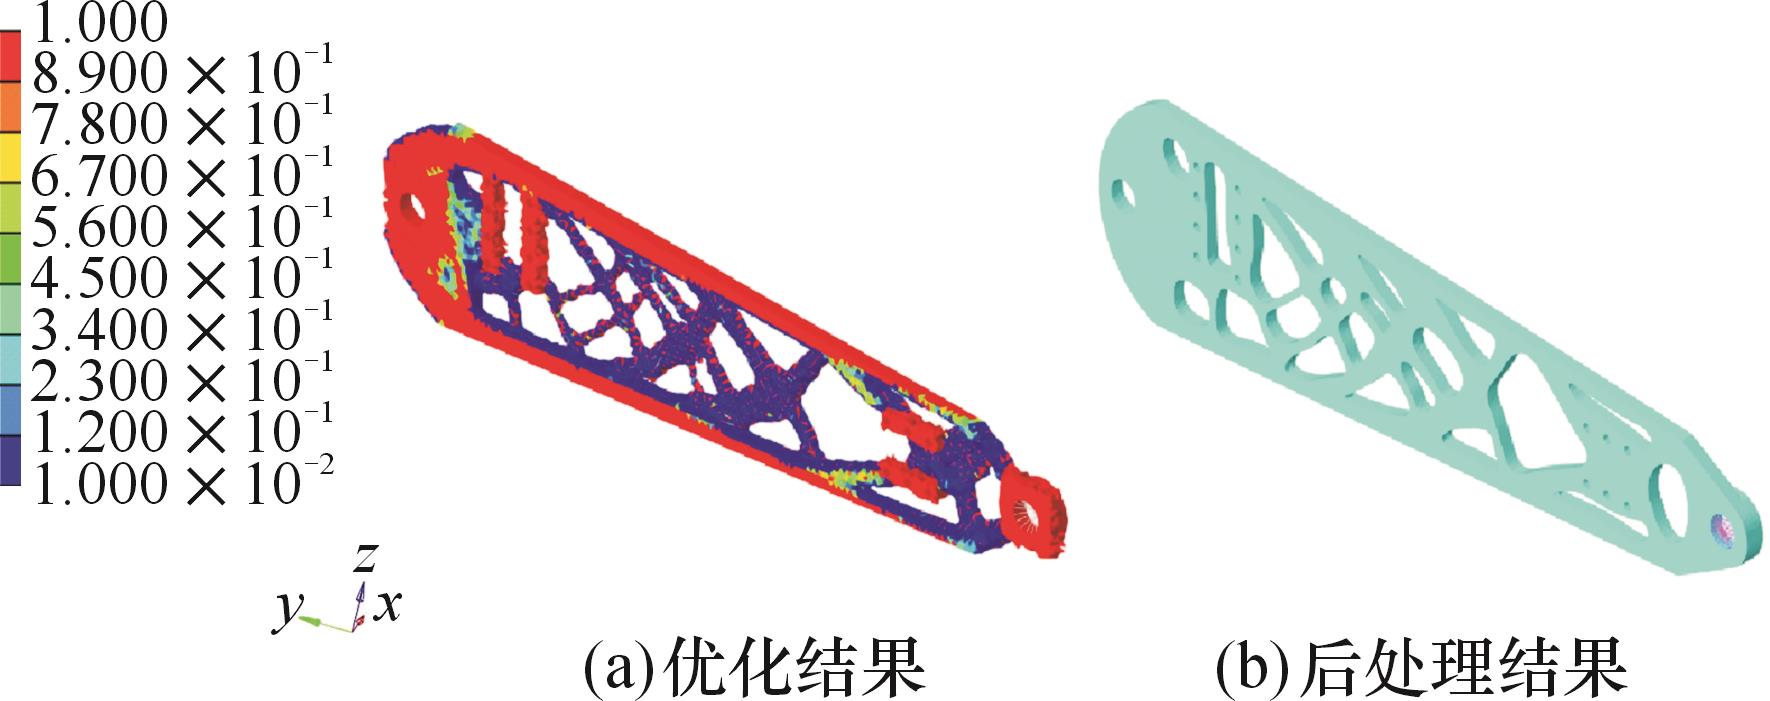
图9 方案二拓扑优化设计结果
Fig.9 Topology optimization design results of scheme 2
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 607.9 | 44.85 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 1.017 | 14.4 |
设定分布力及力矩合力的工况下位移变 形量/mm | 2.337 | 2.034 | 12.97 |
表2 方案二机器人机械腿拓扑优化结果对比
Tab.2 Comparison of topology optimization results of robot legs in scheme 2
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 607.9 | 44.85 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 1.017 | 14.4 |
设定分布力及力矩合力的工况下位移变 形量/mm | 2.337 | 2.034 | 12.97 |
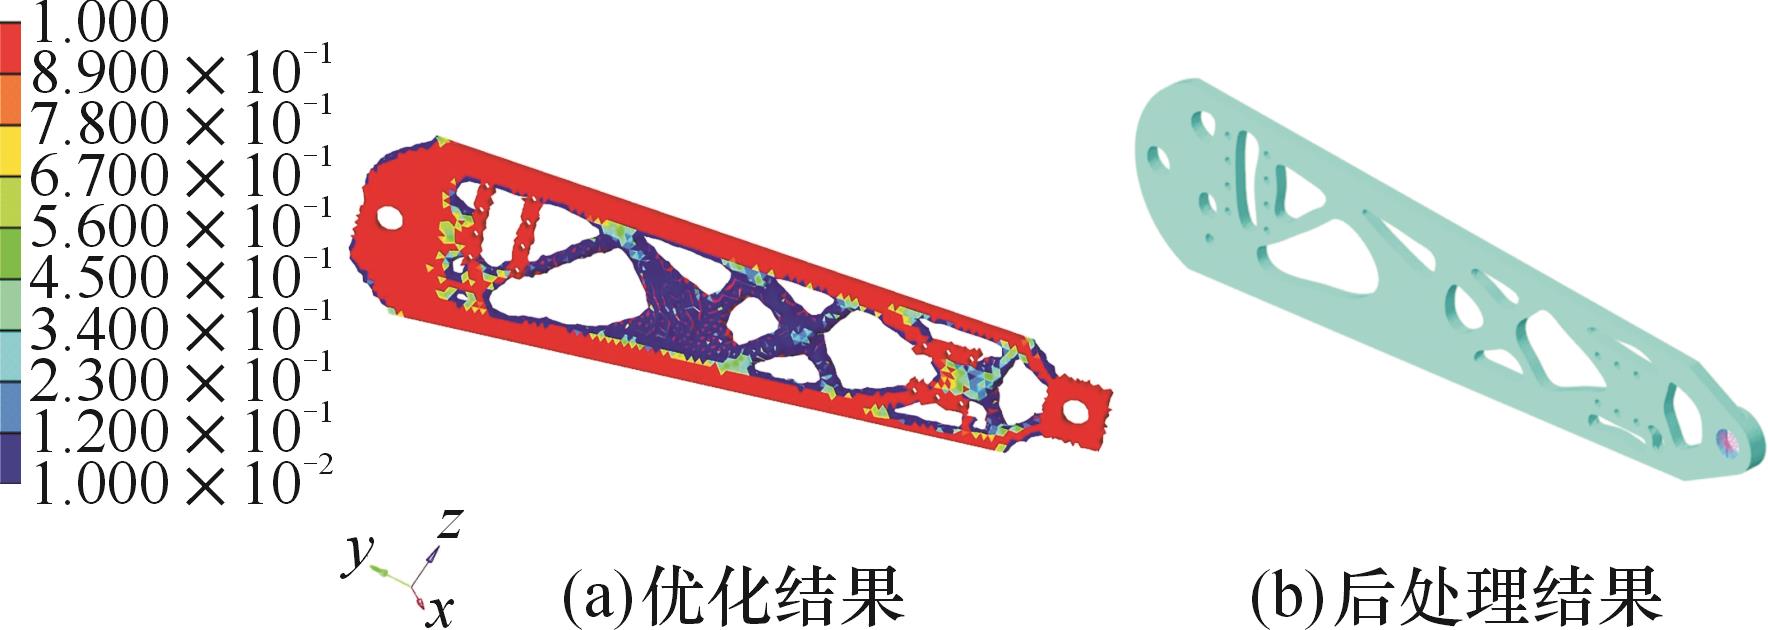
图10 方案三拓扑优化设计结果
Fig.10 Topology optimization design results of scheme 3
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 678.4 | 38.45 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 0.9012 | 23.02 |
| 设定分布力及力矩合力的工况下位移变形量/mm | 2.337 | 1.799 | 24.14 |
表3 方案三机器人机械腿拓扑优化结果对比
Tab.3 Comparison of topology optimization results of robot legs in scheme 3
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 678.4 | 38.45 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 0.9012 | 23.02 |
| 设定分布力及力矩合力的工况下位移变形量/mm | 2.337 | 1.799 | 24.14 |
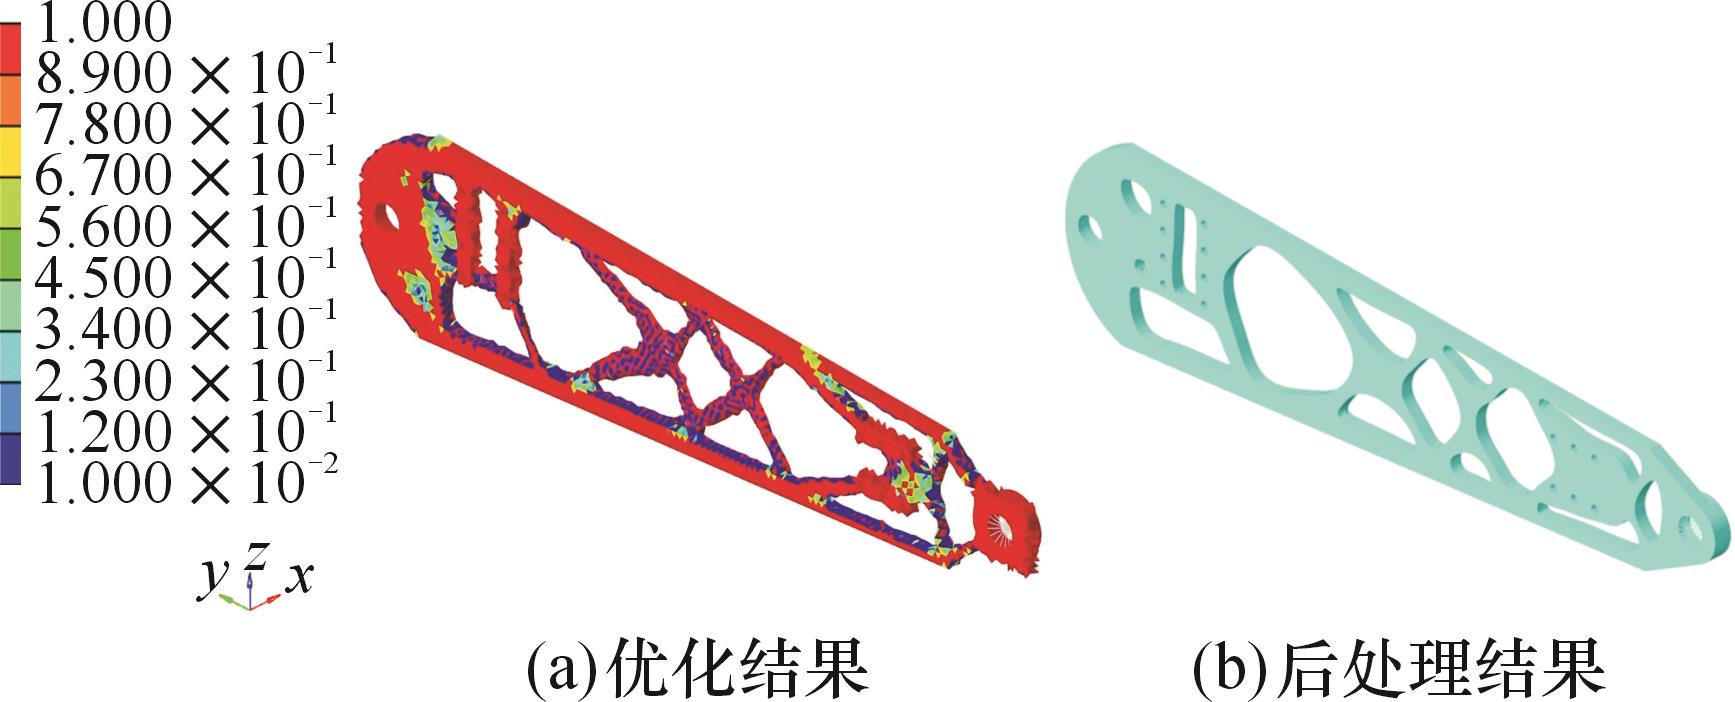
图11 方案四拓扑优化设计结果
Fig.11 Topology optimization design results of scheme 4
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 533 | 51.64 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 1.103 | 7.15 |
设定分布力及力矩合力的工况下位移变 形量/mm | 2.337 | 2.206 | 5.61 |
表4 方案四机器人机械腿拓扑优化结果对比
Tab.4 Comparison of topology optimization results of robot legs in scheme 4
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 533 | 51.64 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 1.103 | 7.15 |
设定分布力及力矩合力的工况下位移变 形量/mm | 2.337 | 2.206 | 5.61 |
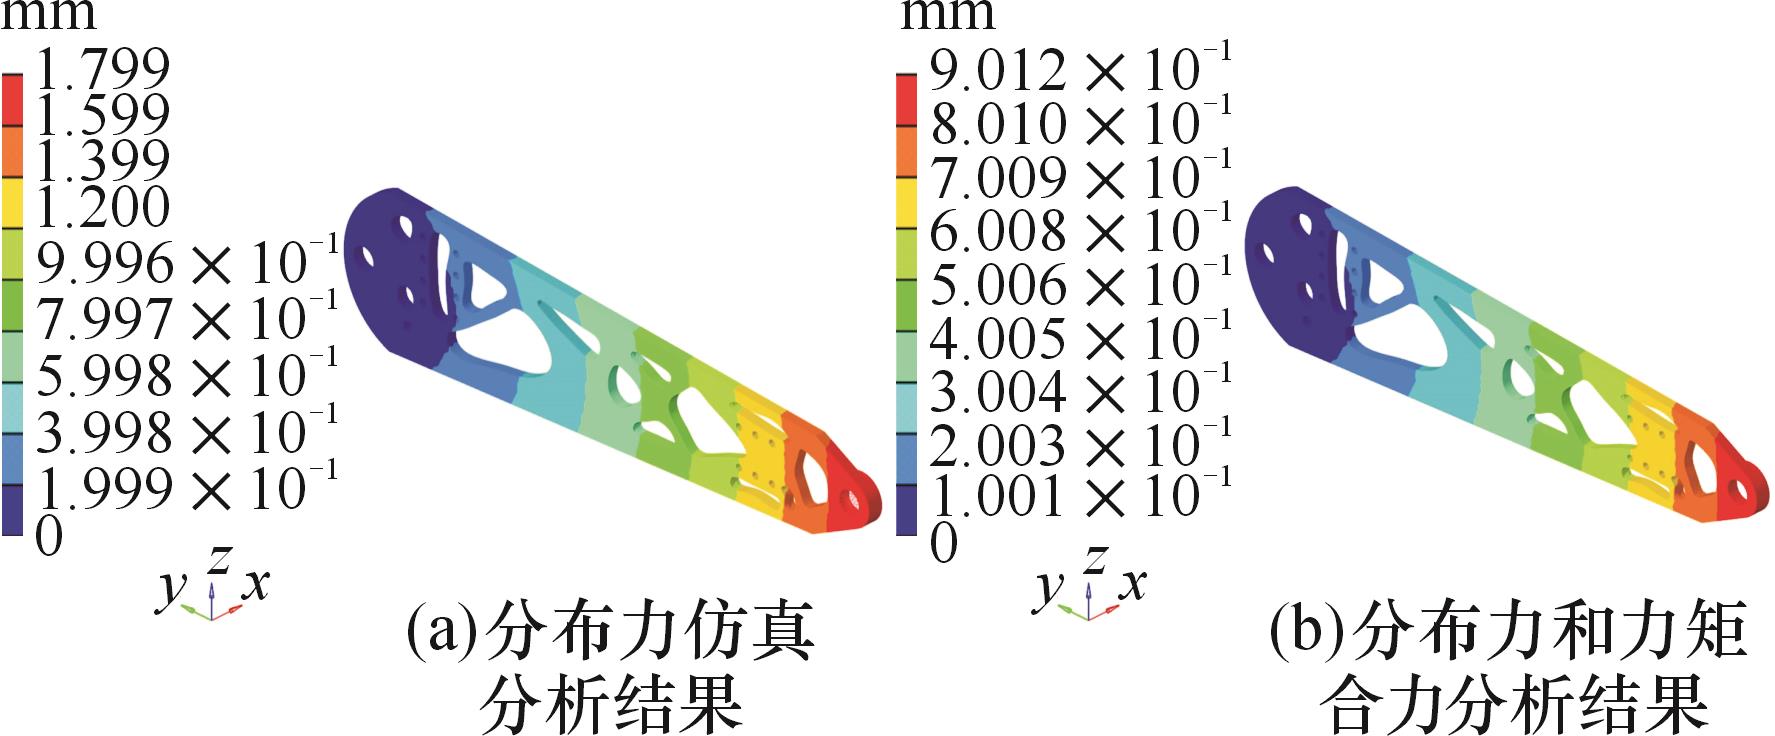
图12 仿真分析结果
Fig.12 Simulation analysis results
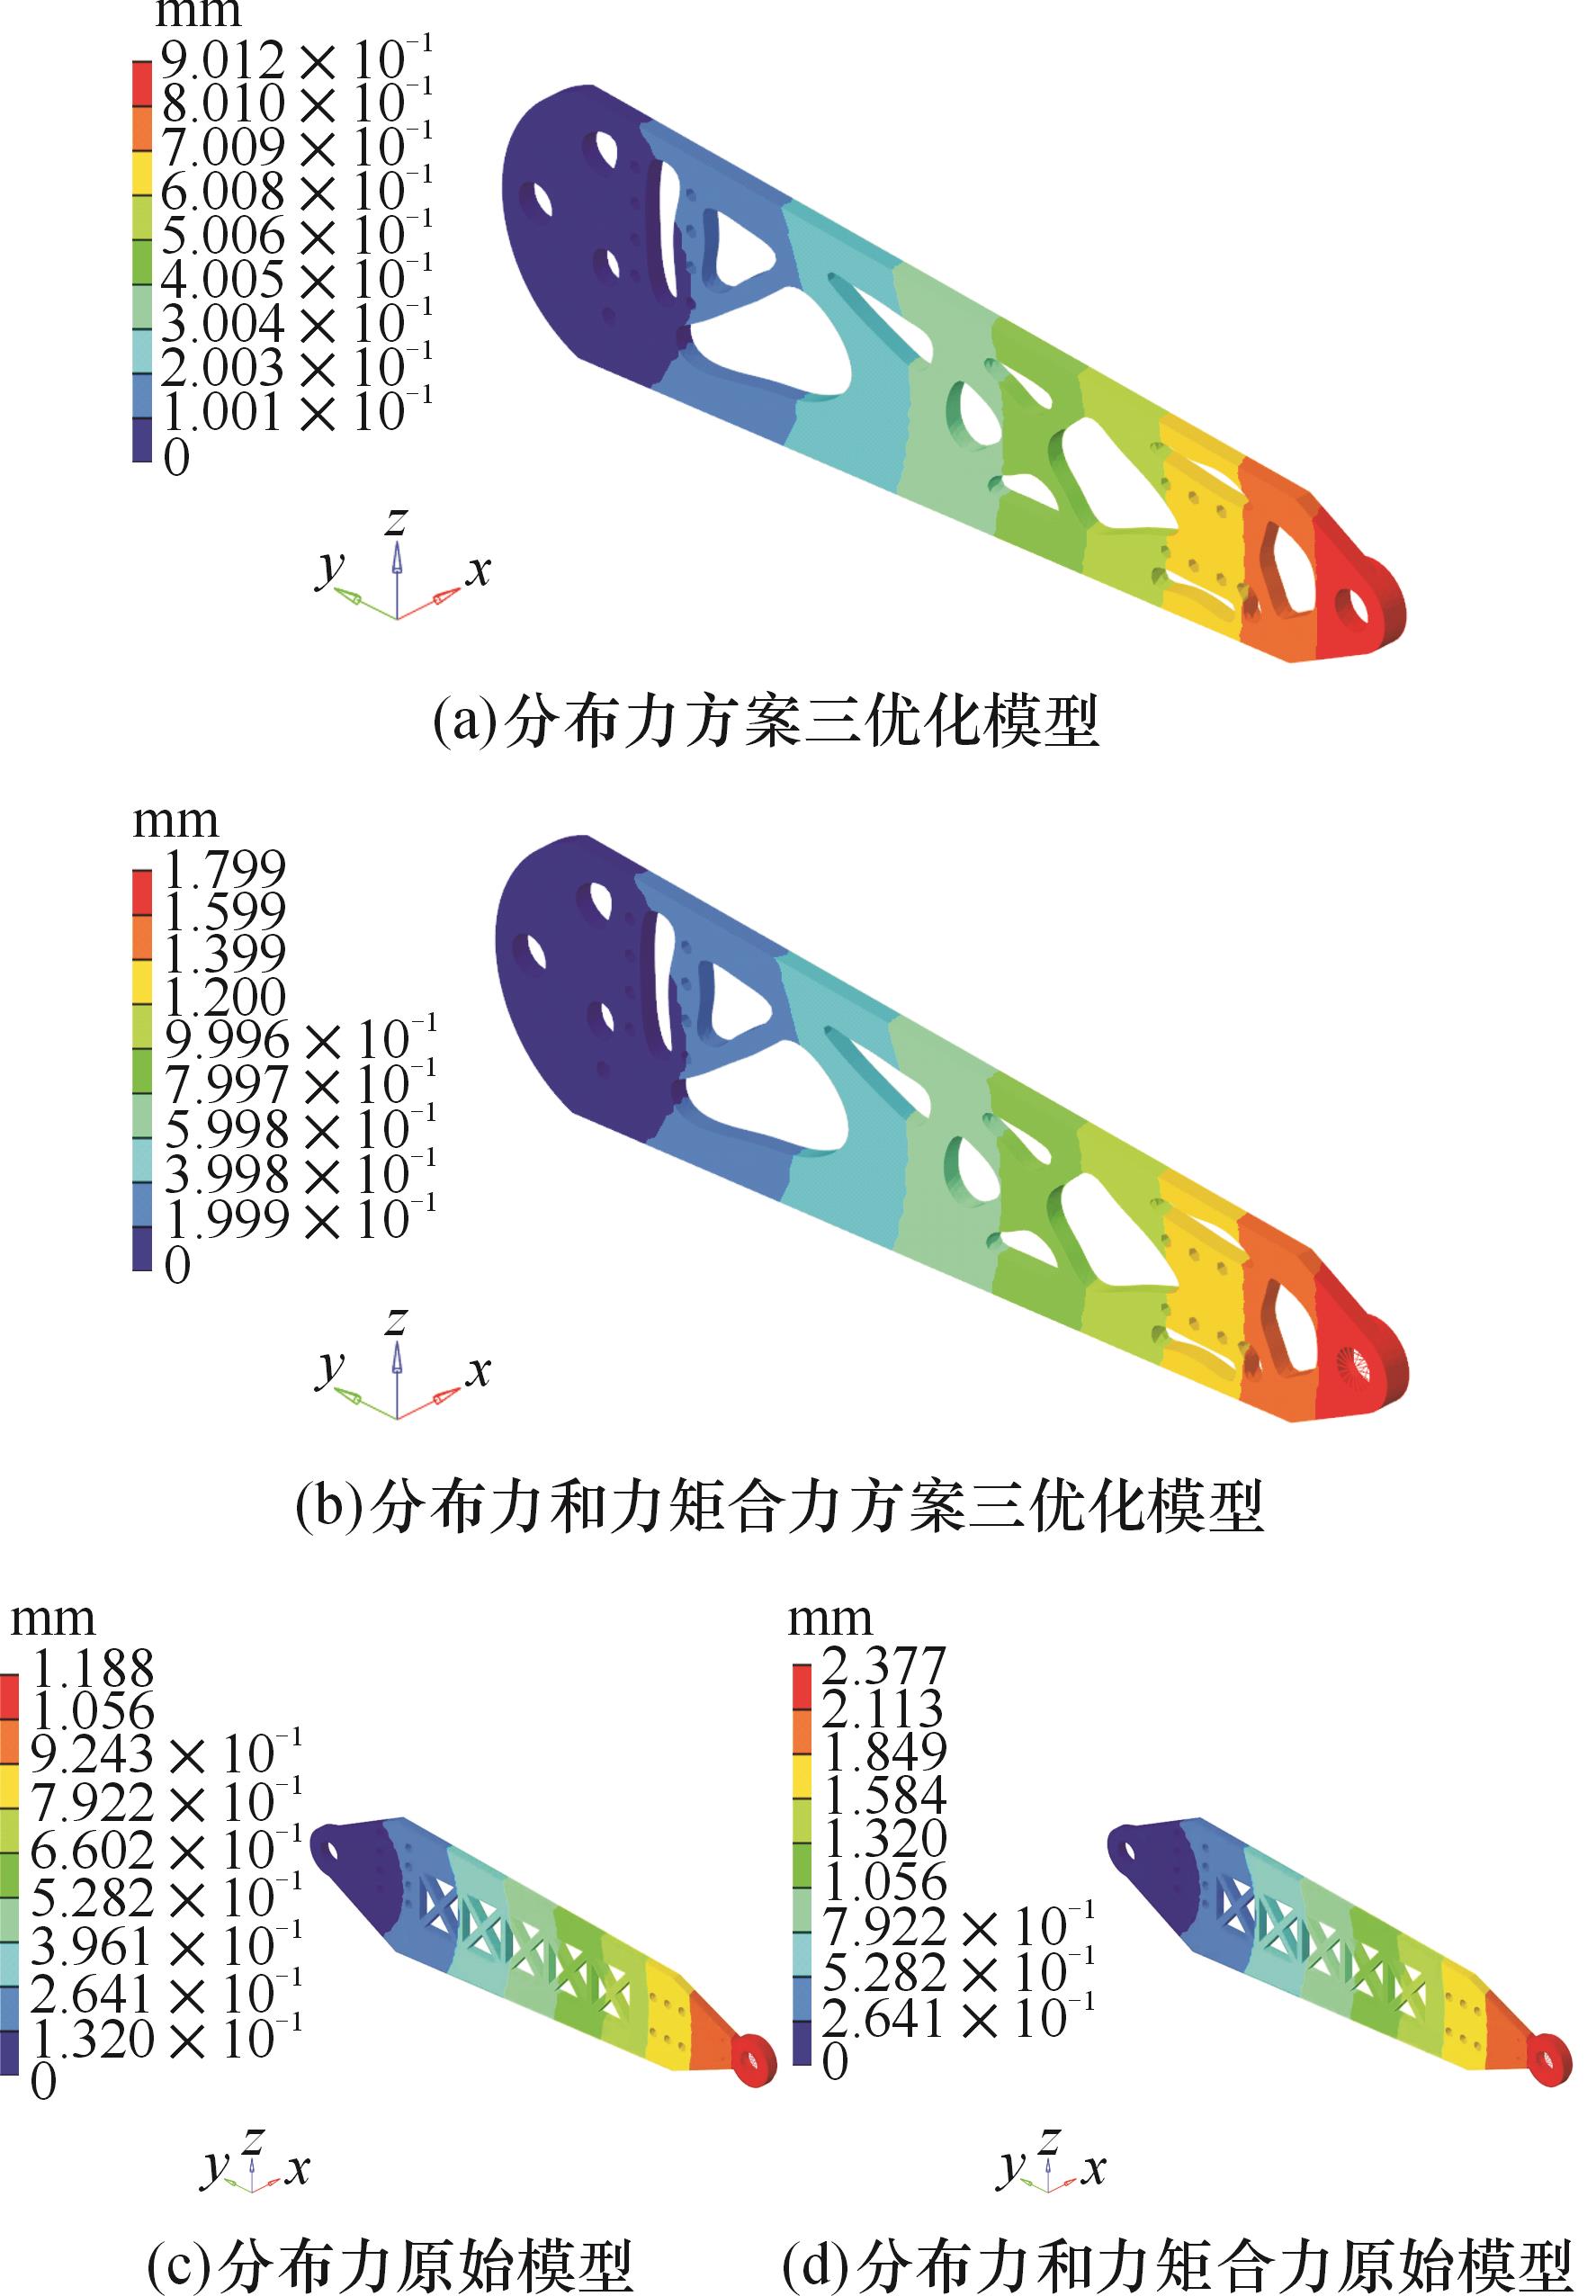
图13 设计优化位移云图
Fig.13 Design optimization displacement cloud diagram
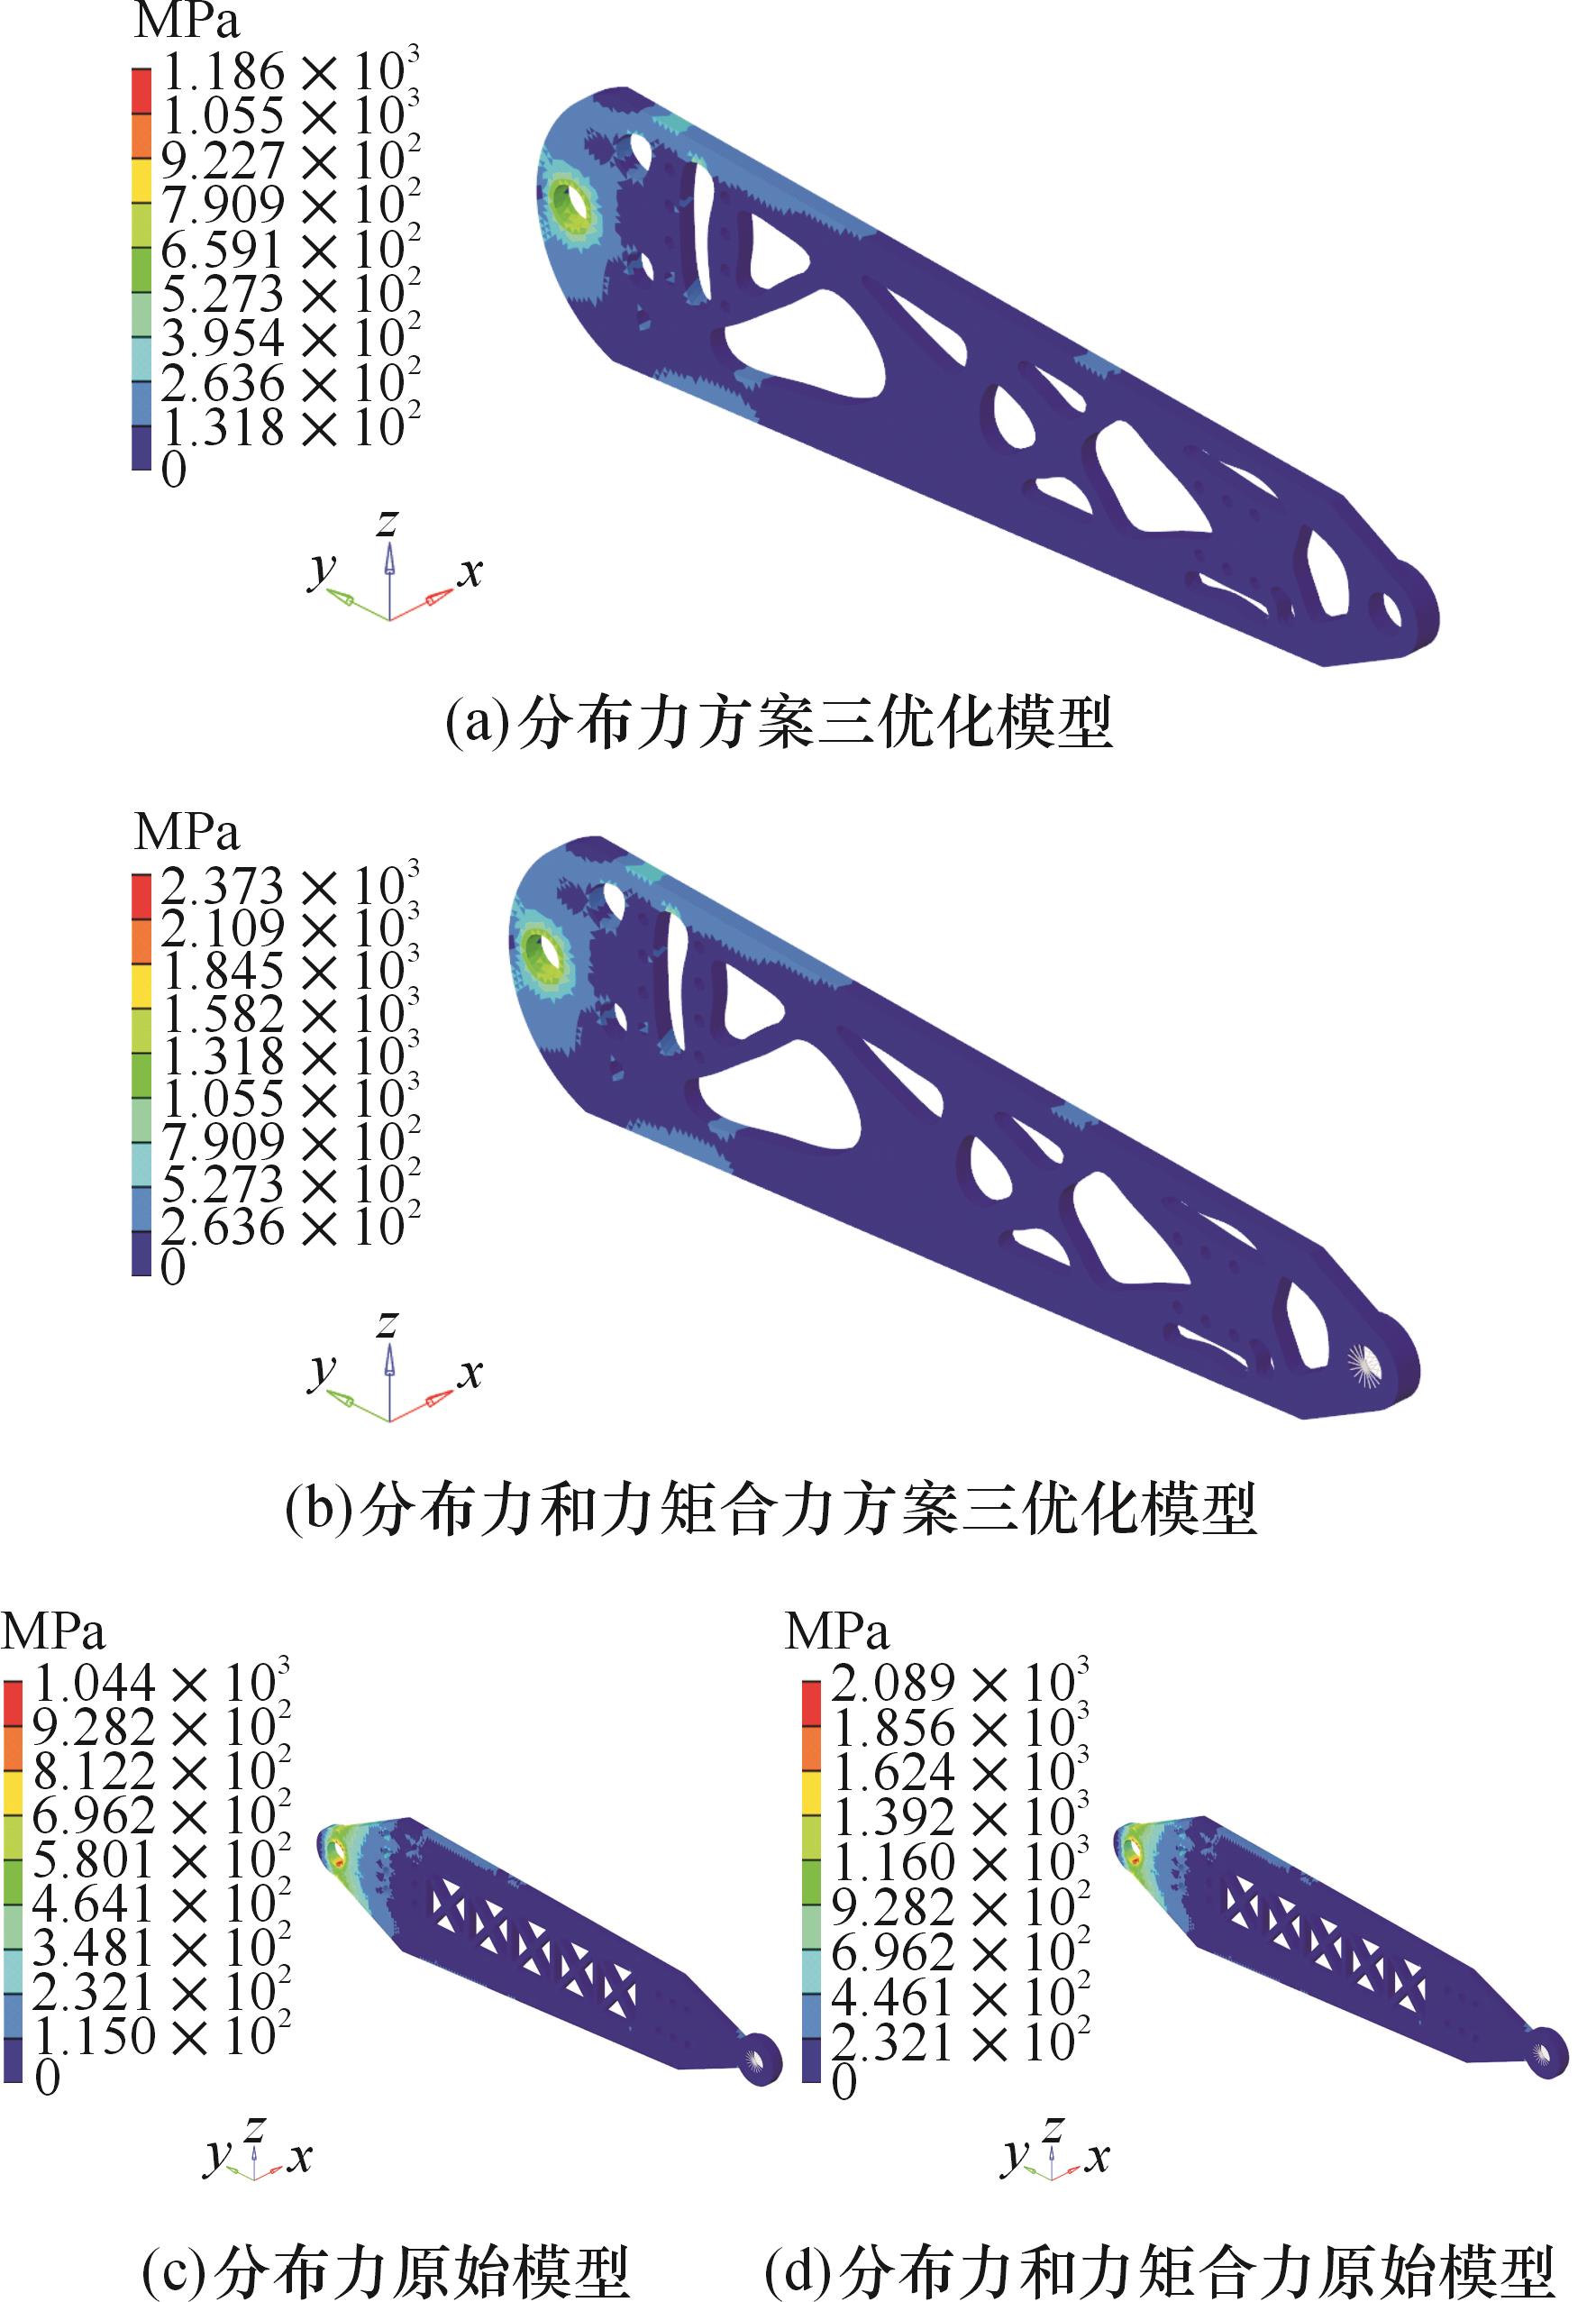
图14 设计优化应力云图
Fig.14 Design optimization stress cloud diagram
| 阶数 | 原始设计 | 方案三 |
|---|---|---|
| 一阶 | 3.103 10×10-2 | 3.259 70×10-2 |
| 二阶 | 0.169 14 | 0.191 54 |
| 三阶 | 0.242 25 | 0.284 98 |
| 四阶 | 0.266 28 | 0.300 92 |
| 五阶 | 0.450 64 | 0.527 40 |
| 六阶 | 0.710 55 | 0.756 10 |
| 七阶 | 0.864 98 | 0.958 02 |
| 八阶 | 1.2801 | 1.2923 |
| 九阶 | 1.3956 | 1.4811 |
| 十阶 | 1.5418 | 1.7636 |
表5 方案三与原始设计结果十阶频率数据对比
Tab. 5 Comparison of the tenth-order frequency data between scheme 3 and the original design results
| 阶数 | 原始设计 | 方案三 |
|---|---|---|
| 一阶 | 3.103 10×10-2 | 3.259 70×10-2 |
| 二阶 | 0.169 14 | 0.191 54 |
| 三阶 | 0.242 25 | 0.284 98 |
| 四阶 | 0.266 28 | 0.300 92 |
| 五阶 | 0.450 64 | 0.527 40 |
| 六阶 | 0.710 55 | 0.756 10 |
| 七阶 | 0.864 98 | 0.958 02 |
| 八阶 | 1.2801 | 1.2923 |
| 九阶 | 1.3956 | 1.4811 |
| 十阶 | 1.5418 | 1.7636 |
| [1] | 陈阳, 王洪玺, 张兰勇. 轮腿式平衡机器人控制[J]. 信息与控制, 2023, 52(5): 648-659. |
| CHEN Yang, WANG Hongxi, ZHANG Lanyong. Control of Wheel-legged Balancing Robot[J]. Information and Control, 2023, 52(5): 648-659. | |
| [2] | 王田苗, 陶永, 陈阳. 服务机器人技术研究现状与发展趋势[J]. 中国科学: 信息科学, 2012, 42(9): 1049-1066. |
| WANG Tianmiao, TAO Yong, CHEN Yang. Research Status and Development Trends of the Service Robotic Technology[J]. Scientia Sinica (Informationis), 2012, 42(9): 1049-1066. | |
| [3] | 刘松, 柴汇, 李贻斌, 等. 电动力液压驱动四足双臂机器人的设计与实现[J]. 机器人, 2022, 44(6): 649-659. |
| LIU Song, CHAI Hui, LI Yibin, et al. Design and Implementation of an Electro-hydraulic Quadruped Robot with Dual-arm[J]. Robot, 2022, 44(6): 649-659. | |
| [4] | OH H J, KIM K D, CHUNG H S, et al. Evolution of Humanoid Robots: Technological Milestones and Future Challenges[J]. Electronics and Telecommunications Trends, 2025, 40(3): 82-92. |
| [5] | TSAGARAKIS N G, CALDWELL D G, NEGRELLO F, et al. WALK-MAN: a High-performance Humanoid Platform for Realistic Environments[J]. Journal of Field Robotics, 2017, 34(7): 1225-1259. |
| [6] | ZHOU Chengxu, TSAGARAKIS N. On the Comprehensive Kinematics Analysis of a Humanoid Parallel Ankle Mechanism[J]. Journal of Mechanisms and Robotics, 2018, 10(5): 051015. |
| [7] | MIKOLAJCZYK T, MIKOŁAJEWSKA E, AL-SHUKA H F N, et al. Recent Advances in Bipedal Walking Robots: Review of Gait, Drive, Sensors and Control Systems[J]. Sensors, 2022, 22(12): 4440. |
| [8] | REHER J, COUSINEAU E A, HEREID A, et al. Realizing Dynamic and Efficient Bipedal Locomotion on the Humanoid Robot DURUS[C]∥2016 IEEE International Conference on Robotics and Automation (ICRA). Stockholm, 2016: 1794-1801. |
| [9] | 钟浩然. 基于液压串联弹性驱动器的双足机器人运动控制方法[D]. 武汉: 华中科技大学, 2021. |
| ZHONG Haoran. Bipedal Robot Motion Control Based on Hydraulic Series Elastic Actuator[D]. Wuhan: Huazhong University of Science and Technology, 2021. | |
| [10] | GIM K G, KIM J, YAMANE K. Design and Fabrication of a Bipedal Robot Using Serial-parallel Hybrid Leg Mechanism[C]∥2018 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Madrid, 2019: 5095-5100. |
| [11] | 蔡润铭, 张爱民, 周仁义. 双轮足机器人运动模式切换规划算法与仿真[J]. 机床与液压, 2024, 52(23): 26-31. |
| CAI Runming, ZHANG Aimin, ZHOU Renyi. Planning Algorithm and Simulation of Locomotion Mode Switching with a Biped Wheel-legged Robot[J]. Machine Tool & Hydraulics, 2024, 52(23): 26-31. | |
| [12] | 潘露, 张恒华, 刘桐, 等. 仿人机器人小腿的拓扑优化和激光增材制造[J]. 应用激光, 2023, 43(2): 47-55. |
| PAN Lu, ZHANG Henghua, LIU Tong, et al. Topological Optimization and Laser Additive Manufacturing of the Humanoid Robot Calf[J]. Applied Laser, 2023, 43(2): 47-55. | |
| [13] | LIU Bin, SHA Liansen, HUANG Kun, et al. A Topology Optimization Method for Collaborative Robot Lightweight Design Based on Orthogonal Experiment and Its Applications[J]. International Journal of Advanced Robotic Systems, 2022, 19: 17298814211056143. |
| [14] | ZHU Jiayi, XU Jie, ZHOU Xiaoqiang, et al. Principal Stress Lines (PSLS)-guided Discrete Topology Designs for Self-similar Porous Infills in Shell Structures with Fractal Geometry[J]. Thin-Walled Structures, 2025, 210: 112915. |
| [15] | ZHANG Xiao, GAO Liang, XIAO Mi, et al. T-splines-based Panel Method for Aerodynamic Topology Optimization of Engineering Shell Structures Using Isogeometric Analysis[J]. Computer Methods in Applied Mechanics and Engineering, 2025, 444: 118154. |
| [16] | 祝海林, 周扬驰, 何宜玖, 等. 外骨骼机器人膝部三铰点零件轻量化研究[J]. 常州大学学报(自然科学版), 2023, 35(3): 71-77. |
| ZHU Hailin, ZHOU Yangchi, HE Yijiu, et al. Research on Lightweight of Three Hinge Parts of Exoskeleton Robot Knee[J]. Journal of Changzhou University (Natural Science Edition), 2023, 35(3): 71-77. | |
| [17] | 莫彦彬, 单科臻, 陈肖媛. 下肢外骨骼机器人大腿护板轻量化设计[J]. 机械研究与应用, 2024, 37(6): 60-62. |
| MO Yanbin, SHAN Kezhen, CHEN Xiaoyuan. Lightweight Design of Thigh Guard for Lower Limb Exoskeleton Robot[J]. Mechanical Research & Application, 2024, 37(6): 60-62. | |
| [18] | 董昊臻. 双足机器人步态仿真及腿部设计与控制研究[D]. 武汉: 华中科技大学, 2021. |
| DONG Haozhen. Research on Gait Simulation with Design and Control of Leg for Biped Robot[D]. Wuhan: Huazhong University of Science and Technology, 2021. | |
| [19] | 许文琼, 杨芳艳, 李清都. 基于角动量的双足机器人稳定行走规划[J]. 电子科技, 2025, 38(8): 87-93. |
| XU Wenqiong, YANG Fangyan, LI Qingdu. Research on Stable Walking Planning of Biped Robot Based on Angular Momentum[J]. Electronic Science and Technology, 2025, 38(8): 87-93. | |
| [20] | 张彦凯, 王雪松, 金雨斌, 等. 基于虚拟样机的双足机器人多目标步态规划研究[J]. 系统仿真学报, 2024, 36(12): 2984-2992. |
| ZHANG Yankai, WANG Xuesong, JIN Yubin, et al. Research on Multi-objective Gait Planning of Biped Robot Based on Virtual Prototype[J]. Journal of System Simulation, 2024, 36(12): 2984-2992. | |
| [21] | 郭凯. 模型预测控制下四足机器人的地形适应性优化[J]. 建模与仿真, 2024, 13(6): 6537-6551. |
| GUO Kai. Optimization of Terrain Adaptability for Quadruped Robots under Model Predictive Control[J]. Modeling and Simulation, 2024, 13(6): 6537-6551. | |
| [22] | XU Zhen, XIE Jianan, HASHIMOTO K, et al. Human-inspired Gait and Jumping Motion Generation for Bipedal Robots Using Model Predictive Control[J]. Biomimetics, 2025, 10(1):17. |
| [23] | 王森, 姚燕安, 武建昫. 一种新型可调整闭链多足机器人的设计与分析[J]. 机械工程学报, 2020, 56(19): 191-199. |
| WANG Sen, YAO Yan’an, WU Jianxu. Design and Analysis of a Novel Adjustable Closed-chain Multi-legged Robot[J]. Journal of Mechanical Engineering, 2020, 56(19): 191-199. | |
| [24] | 高惟鹰. 面向高机敏双足机器人的腿部设计与柔顺控制研究[D]. 重庆: 重庆邮电大学, 2020. |
| GAO Weiying. Research on Leg Design and Compliance Control for Highly Sensitive Biped Robots[D]. Chongqing: Chongqing University of Posts and Telecommunications, 2020. | |
| [25] | 石照耀, 丁宏钰, 汪文广, 等. 双足机器人腿部新构型设计与试验研究[J]. 机械工程学报, 2023, 59(1): 103-112. |
| SHI Zhaoyao, DING Hongyu, WANG Wenguang, et al. Design and Experimental Research on the Novel Leg Configuration of Bipedal Robot[J]. Journal of Mechanical Engineering, 2023, 59(1): 103-112. | |
| [26] | CHENG Feiteng, ZHAO Qinghai, MAO Zibin, et al. Mechanical Response of Gradient Lattice Structures Based on Topology Optimization[J]. Advanced Engineering Materials, 2024, 26(8): 2301887. |
| [27] | LIN Daji, GAO Liang, GAO Jie. The Lagrangian-Eulerian Described Particle Flow Topology Optimization (PFTO) Approach with Isogeometric Material Point Method[J]. Computer Methods in Applied Mechanics and Engineering, 2025, 440: 117892. |
| [28] | ZHANG Xiao, XIAO Mi, GAO Liang, et al. A T-splines-oriented Isogeometric Topology Optimization for Plate and Shell Structures with Arbitrary Geometries Using Bézier Extraction[J]. Computer Methods in Applied Mechanics and Engineering, 2024, 425: 116929. |
| [1] | 杨浩秦, 单忠德, 闫丹丹, 吴润谋, 孔祥浩. 航空发动机涡轮叶片光固化增材制造陶瓷型芯轻量化结构力学性能研究[J]. 中国机械工程, 2026, 37(6): 1353-1361. |
| [2] | 姜礼杰, 杨航, 韩冬, 孙颜明, 王一新, 吴乾坤, 贾连辉. 盾构换刀机器人设计与应用[J]. 中国机械工程, 2026, 37(5): 1037-1044. |
| [3] | 李昀龙, 张大海, 陆方舟, 李彦杰, 徐培飞, 费庆国. 基于铁氧体磁路优化的感应加热效率提升方法[J]. 中国机械工程, 2026, 37(5): 1141-1149. |
| [4] | 王浩, 罗浩东, 施亚中, 王立文, 张威, 王忠. 基于端到端深度学习模型TOPO-U型网的结构拓扑优化方法[J]. 中国机械工程, 2026, 37(1): 174-183. |
| [5] | 王旭浩, 盛卧龙, 吴孟丽, 许贻龙, 赵晓巍, 曹轶然. 可伸缩蛇形臂机器人的设计及运动学建模[J]. 中国机械工程, 2025, 36(12): 2885-2893. |
| [6] | 何昆, 周和超, 张济民. 列车防爬吸能器负泊松比超材料填充结构设计[J]. 中国机械工程, 2025, 36(12): 3040-3046. |
| [7] | 陈武超, 俞翔栋, 何昆, 张济民. 模块化多胞元永磁推力轴承的承载特性[J]. 中国机械工程, 2025, 36(10): 2300-2305. |
| [8] | 黄昊1, 王曾2, 李波2, 卢泽华1, 刘怀举1. 基于折衷规划法的航发齿轮传动壳体结构热柔度协同拓扑优化[J]. 中国机械工程, 2025, 36(07): 1471-1478. |
| [9] | 尚欣1, 陈宇2. 刚强约束的主轴结构设计研究[J]. 中国机械工程, 2025, 36(05): 995-1007. |
| [10] | 苏珂1, 王颖1, 梁腾腾1, 魏义礼2, 张楠楠2. 基于知情构造理论的单材料柔性机构拓扑优化[J]. 中国机械工程, 2025, 36(04): 873-881. |
| [11] | 林家辉, 李壮壮, 李学霖, 李军. 一种路径吞噬拓扑优化新方法[J]. 中国机械工程, 2025, 36(03): 504-514. |
| [12] | 王书亭1, 谢晴天1, 杨奥迪1, 李小兵2, 熊体凡1, 谢贤达2. 等几何拓扑优化非齐次边界条件施加技术研究[J]. 中国机械工程, 2025, 36(03): 525-535. |
| [13] | 刘敏1, 2, 卢飞扬1, 占金青1, 2, 吴剑1, 朱本亮3. 考虑最小尺寸约束的内嵌可移动压电驱动柔顺机构拓扑优化设计[J]. 中国机械工程, 2025, 36(02): 255-264. |
| [14] | 王浩1, 2, 王江北3, 罗浩东3, 王立文4. 基于改进四叉树和比例边界有限元法的自适应设计域拓扑优化方法[J]. 中国机械工程, 2024, 35(05): 904-915,927. |
| [15] | 杨峰, 罗世杰, 杨江鸿, 王英俊, . 基于GPU加速的等几何拓扑优化高效多重网格求解方法[J]. 中国机械工程, 2024, 35(04): 602-613. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
