ISSN 1004-132X
CN 42-1294/TH
CN 42-1294/TH
中国机械工程 ›› 2026, Vol. 37 ›› Issue (9): 2092-2100.DOI: 10.3969/j.issn.1004-132X.2026.09.002
• 智能诊断与运维专栏 • 上一篇
邓书朝1,2( ), 胡奥康1, 童宝宏1,2(), 郑近德1, 王璐1
收稿日期:2025-09-11
出版日期:2026-09-25
发布日期:2026-10-21
通讯作者:
童宝宏
作者简介:邓书朝,男,1989年生,讲师。研究方向为机电装备运动控制。E-mail: dengsc@ahut.edu.cn基金资助:
DENG Shuchao1,2(), HU Aokang1, TONG Baohong1,2(), ZHENG Jinde1, WANG Lu1
Received:2025-09-11
Online:2026-09-25
Published:2026-10-21
Contact:
TONG Baohong
摘要:
针对光刻及类似精密装备中,微米级精密运动平台误差校准存在的精度不足、操作复杂且高成本方法普及难的问题,提出了一种基于A-Zernike矩(自适应梯度Zernike矩)的高性价比视觉校准方法。依据靶标形态特征筛选边缘初值,通过线性渐变模型、梯度采样与高斯拟合实现亚像素边缘的自适应提取,精确获取靶标中心位置。依据误差变化规律建立系统参数与靶标位置变化的关联模型,实现多参数联合标定。基于标定结果构建图像坐标与平台位移的转换关系,完成定位误差的解算与补偿。实验结果表明:A-Zernike矩边缘检测精度较传统方法的边缘检测精度提高了47.41%,校准后平台最大定位误差由15.601 μm降至0.783 μm。该方法显著提高了微米级运动平台的校准效率与可靠性。
中图分类号:
邓书朝, 胡奥康, 童宝宏, 郑近德, 王璐. 基于A-Zernike矩的精密运动平台定位误差校准方法[J]. 中国机械工程, 2026, 37(9): 2092-2100.
DENG Shuchao, HU Aokang, TONG Baohong, ZHENG Jinde, WANG Lu. A-Zernike Moment Based Calibration Method for Positioning Errors of Precision Motion Stages[J]. China Mechanical Engineering, 2026, 37(9): 2092-2100.
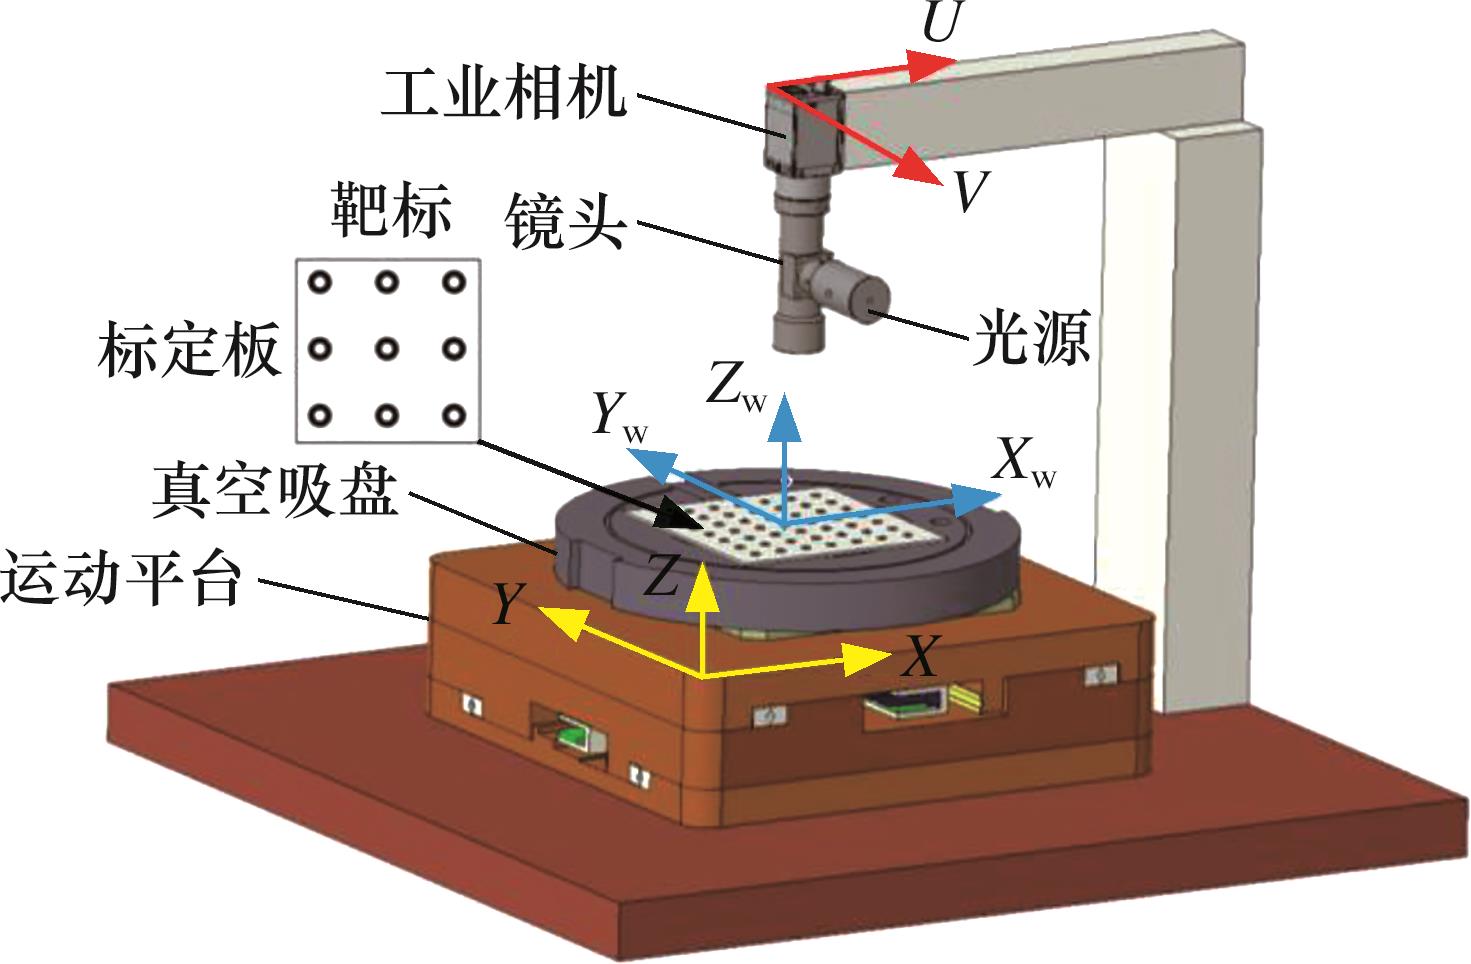
图1 精密运动平台定位误差视觉校准系统
Fig.1 Visual calibration system of precision motion stage positioning error
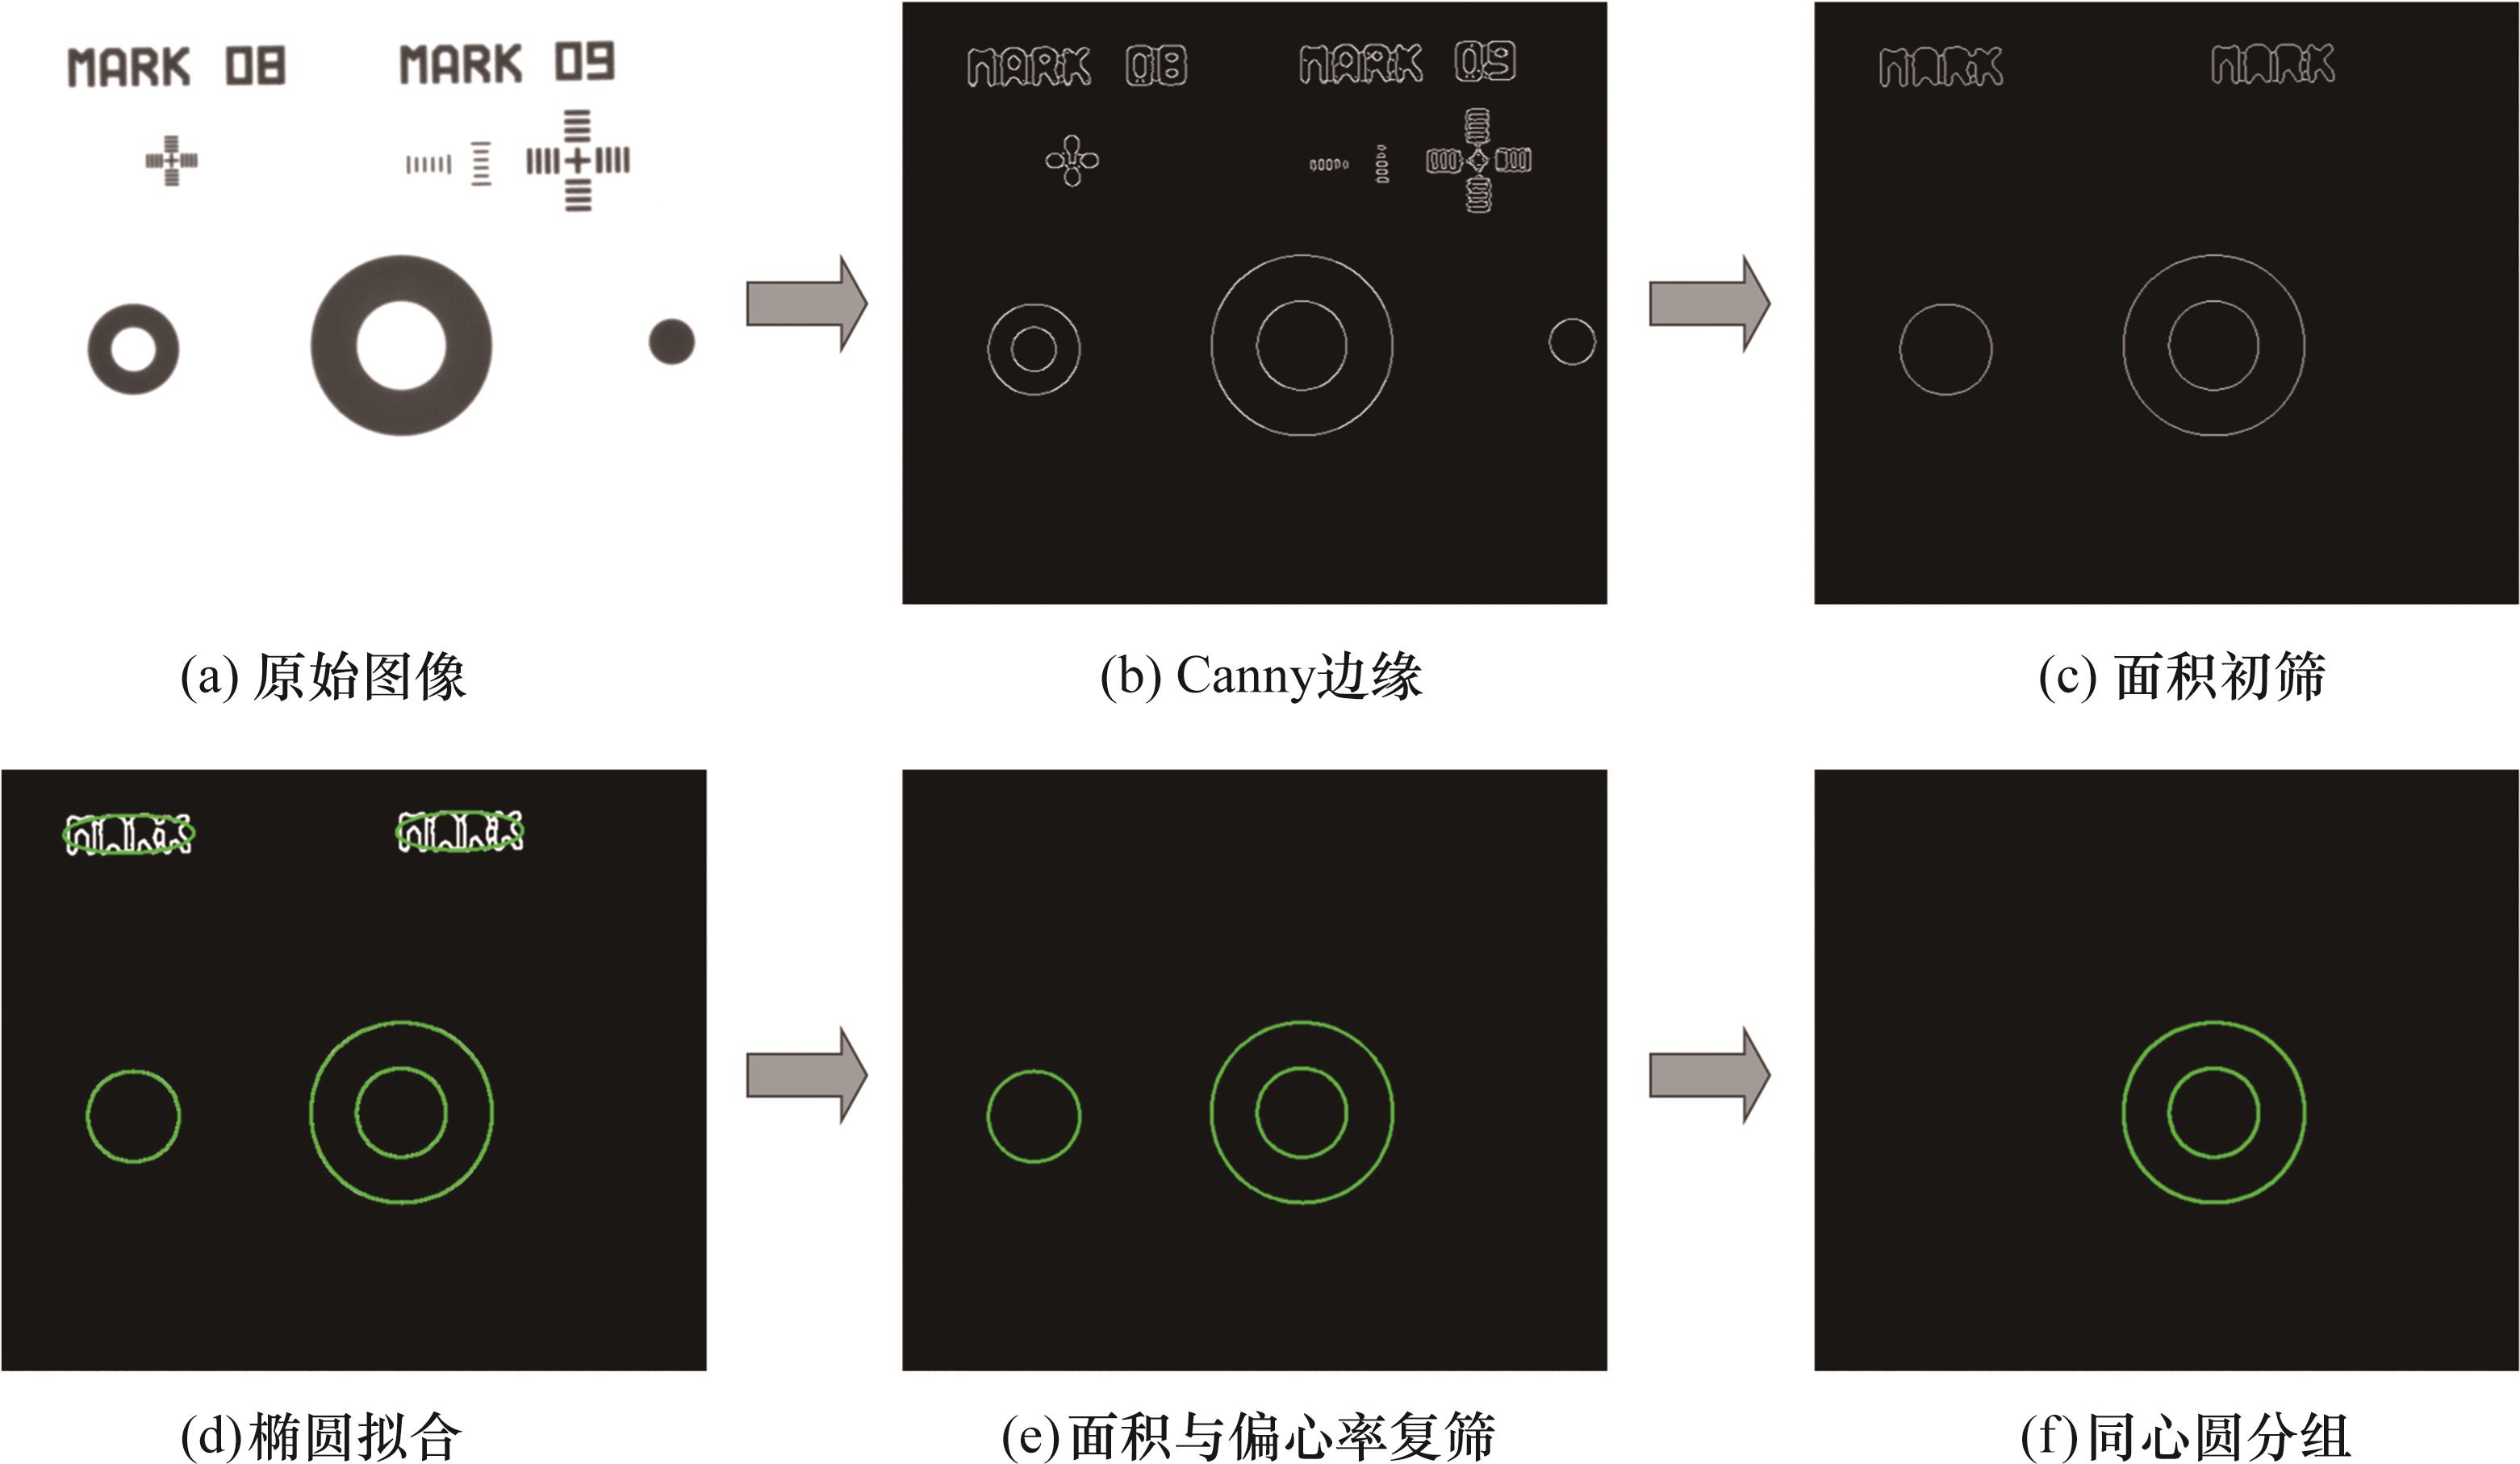
图2 靶标轮廓提取流程
Fig.2 Target contour extraction process
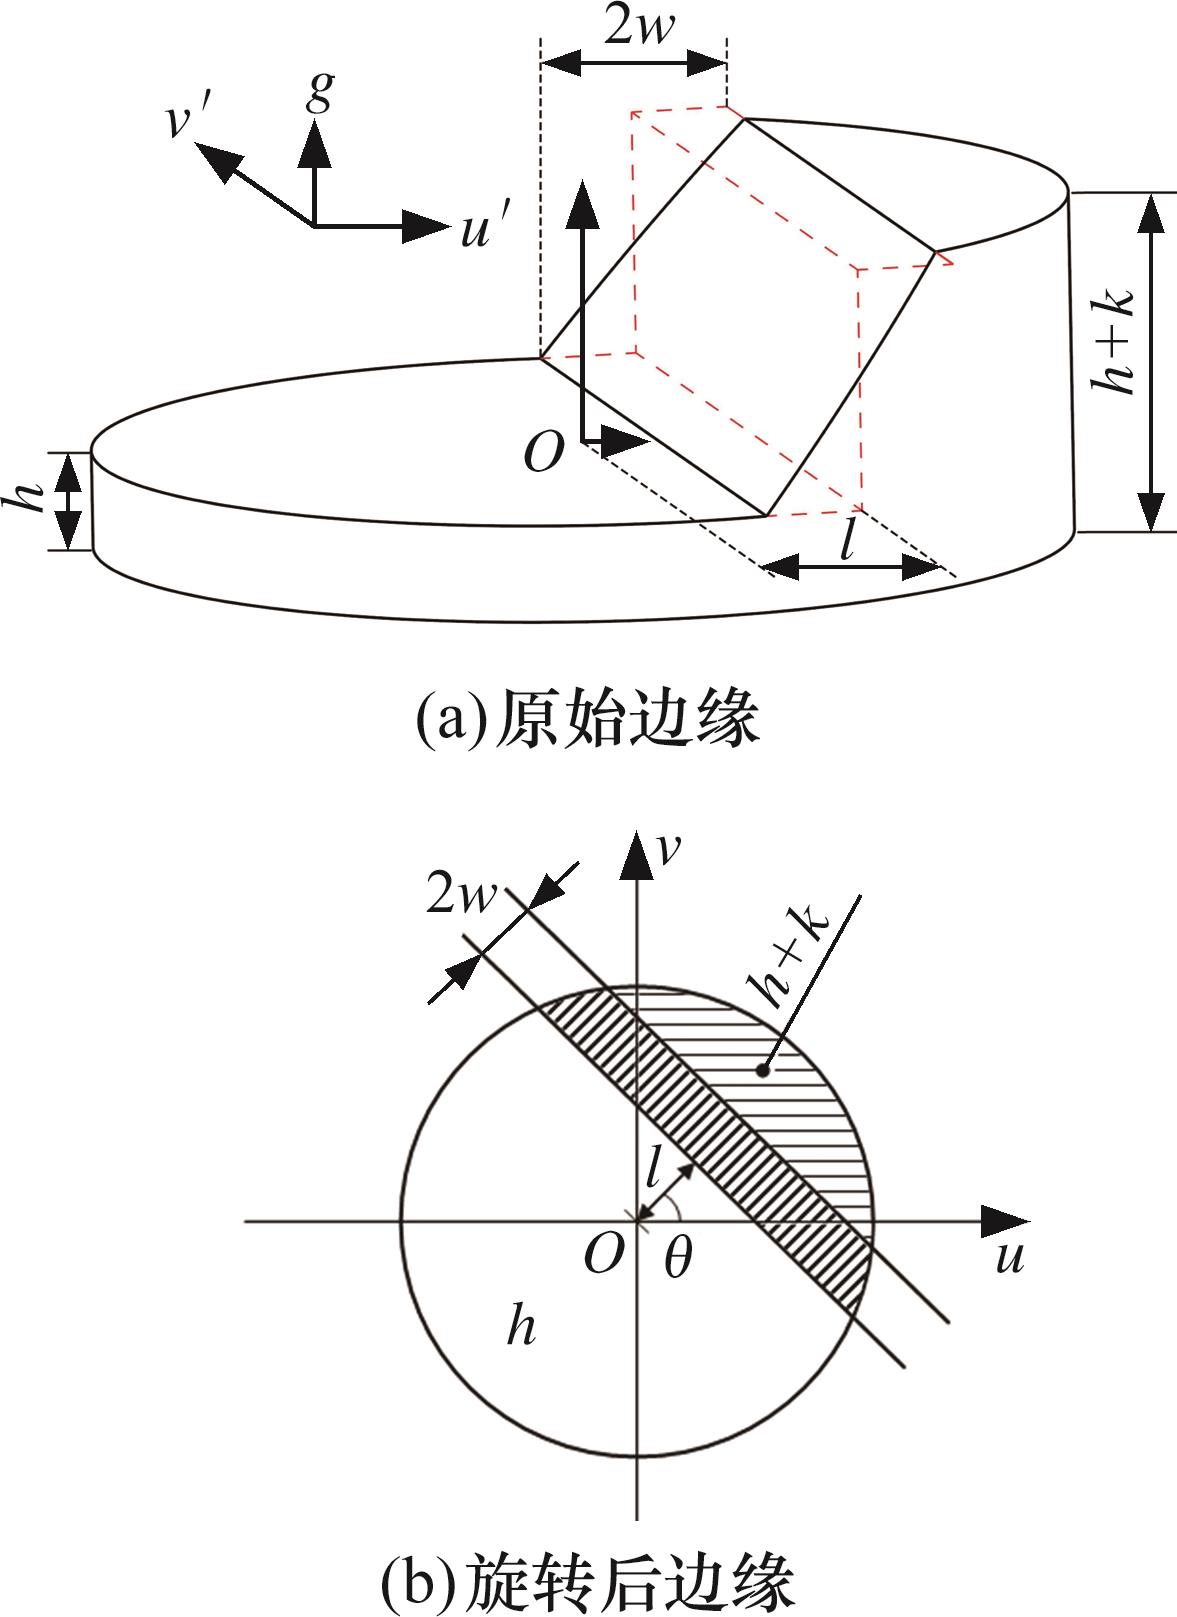
图3 线性渐变边缘模型
Fig.3 Linear gradient edge modeling
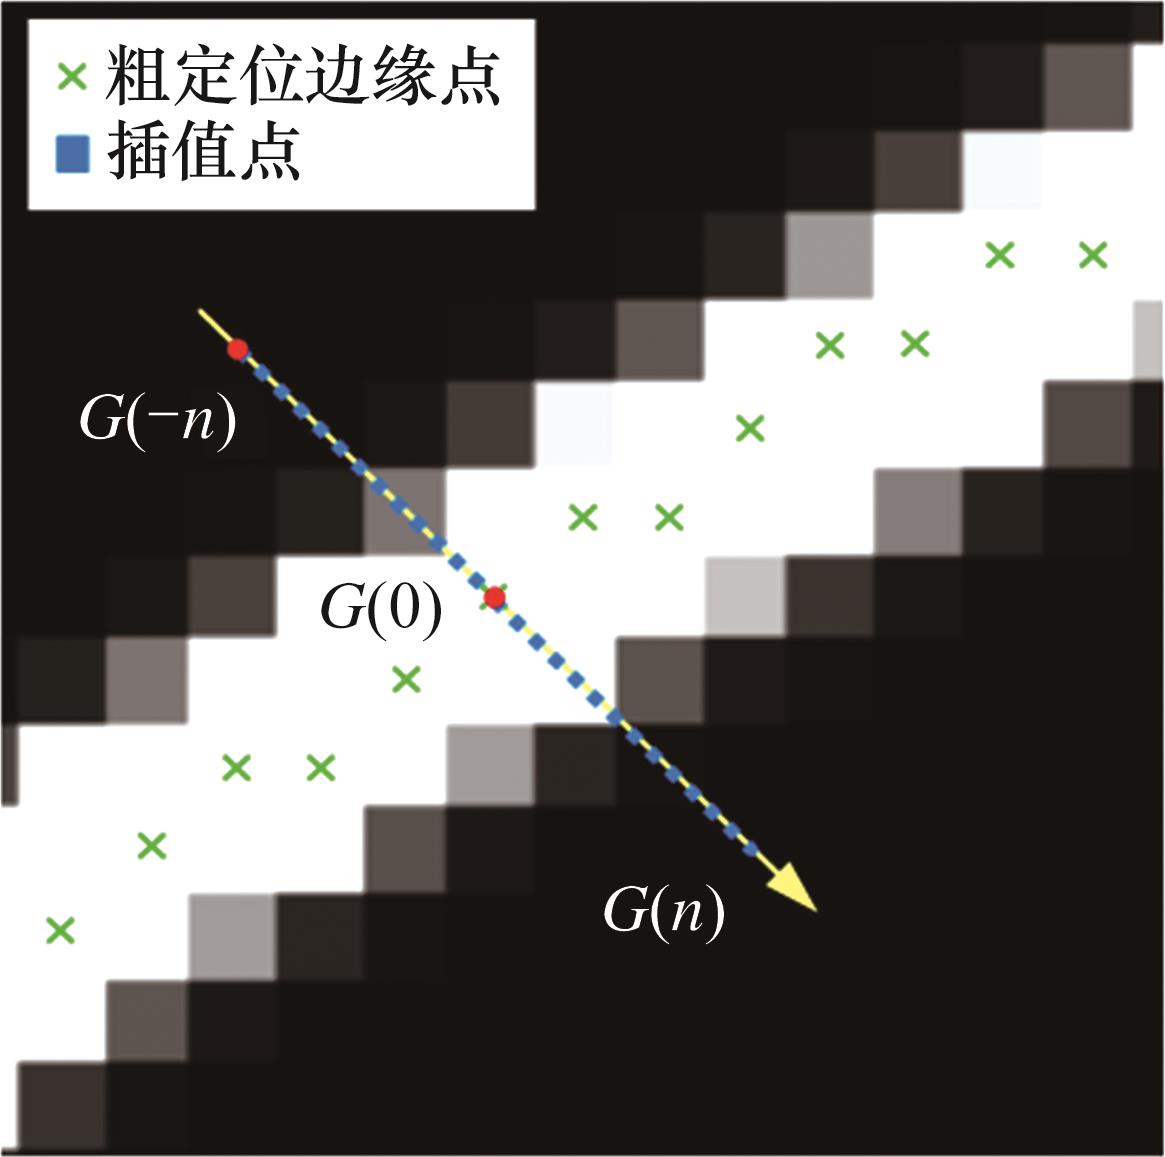
图4 边缘点梯度方向采样
Fig.4 Edge point gradient direction sampling
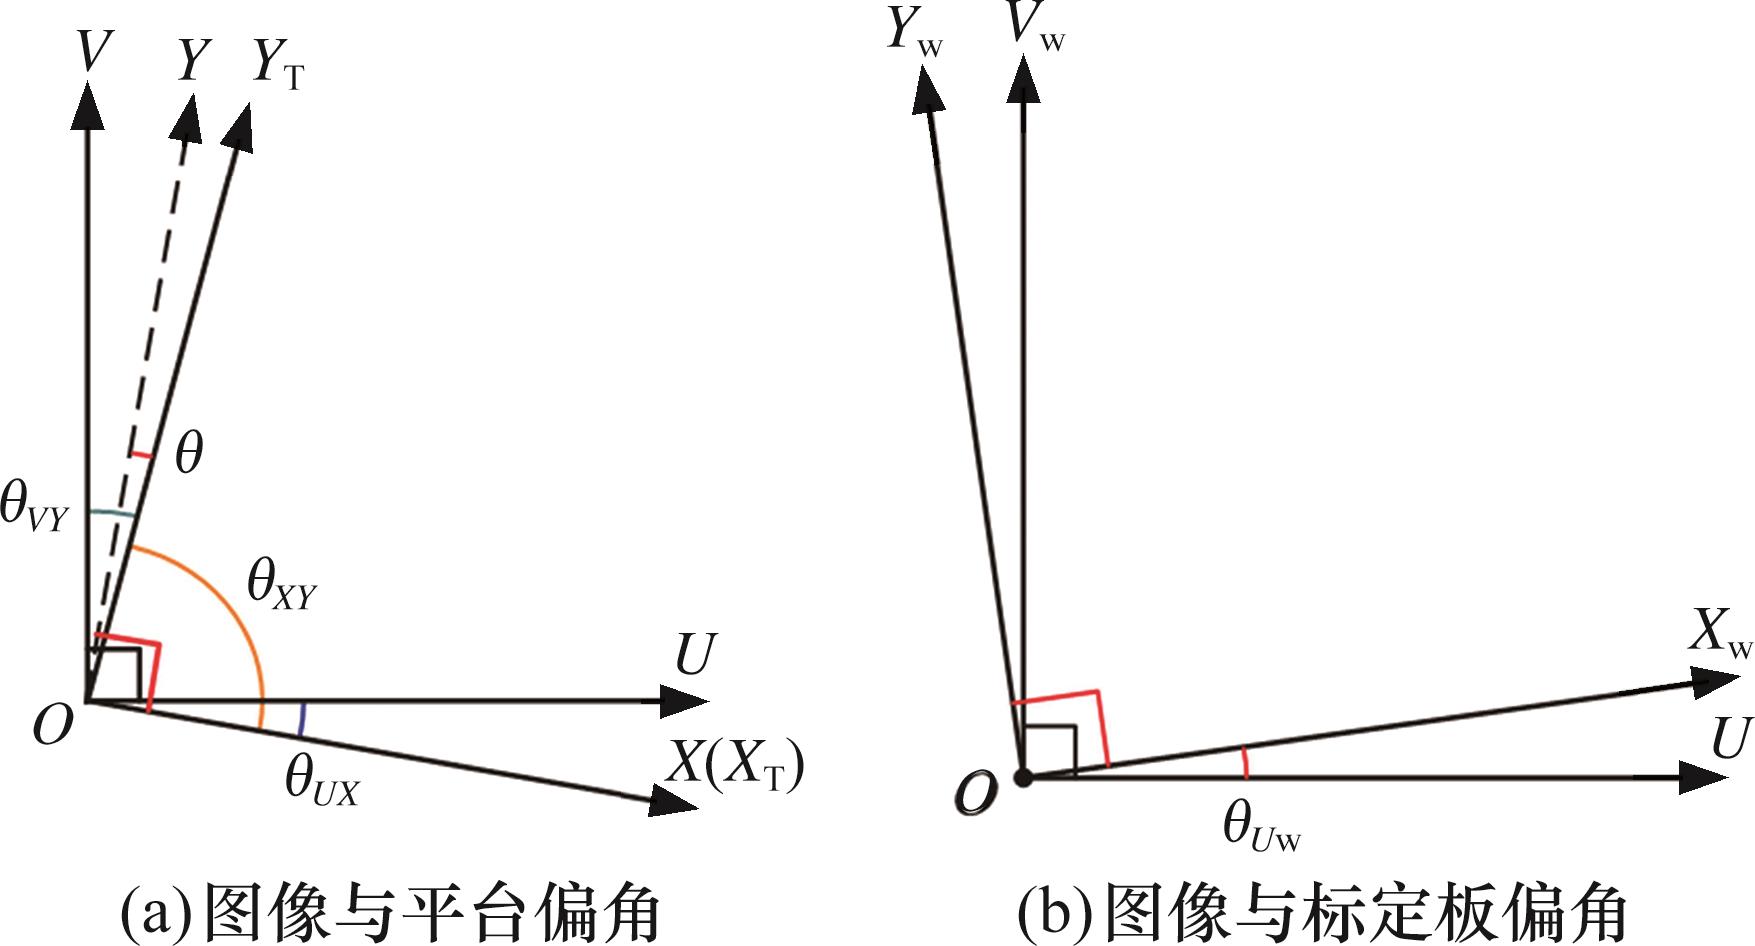
图5 待标定系统参数示意图
Fig.5 Schematic diagram of the parameters of the system to be calibrated
| 序号 | 参数 | 量符号 |
|---|---|---|
| 1 | 图像坐标系U方向像素当量 | |
| 2 | 图像坐标系V方向像素当量 | |
| 3 | 图像坐标系与标定板间的夹角 | |
| 4 | 图像坐标系与平台基准轴(X轴)夹角 | |
| 5 | 图像坐标系与平台Y轴夹角 | |
| 6 | 平台正交性误差值 |
表1 待标定系统参数
Tab.1 System parameters to be calibrated
| 序号 | 参数 | 量符号 |
|---|---|---|
| 1 | 图像坐标系U方向像素当量 | |
| 2 | 图像坐标系V方向像素当量 | |
| 3 | 图像坐标系与标定板间的夹角 | |
| 4 | 图像坐标系与平台基准轴(X轴)夹角 | |
| 5 | 图像坐标系与平台Y轴夹角 | |
| 6 | 平台正交性误差值 |
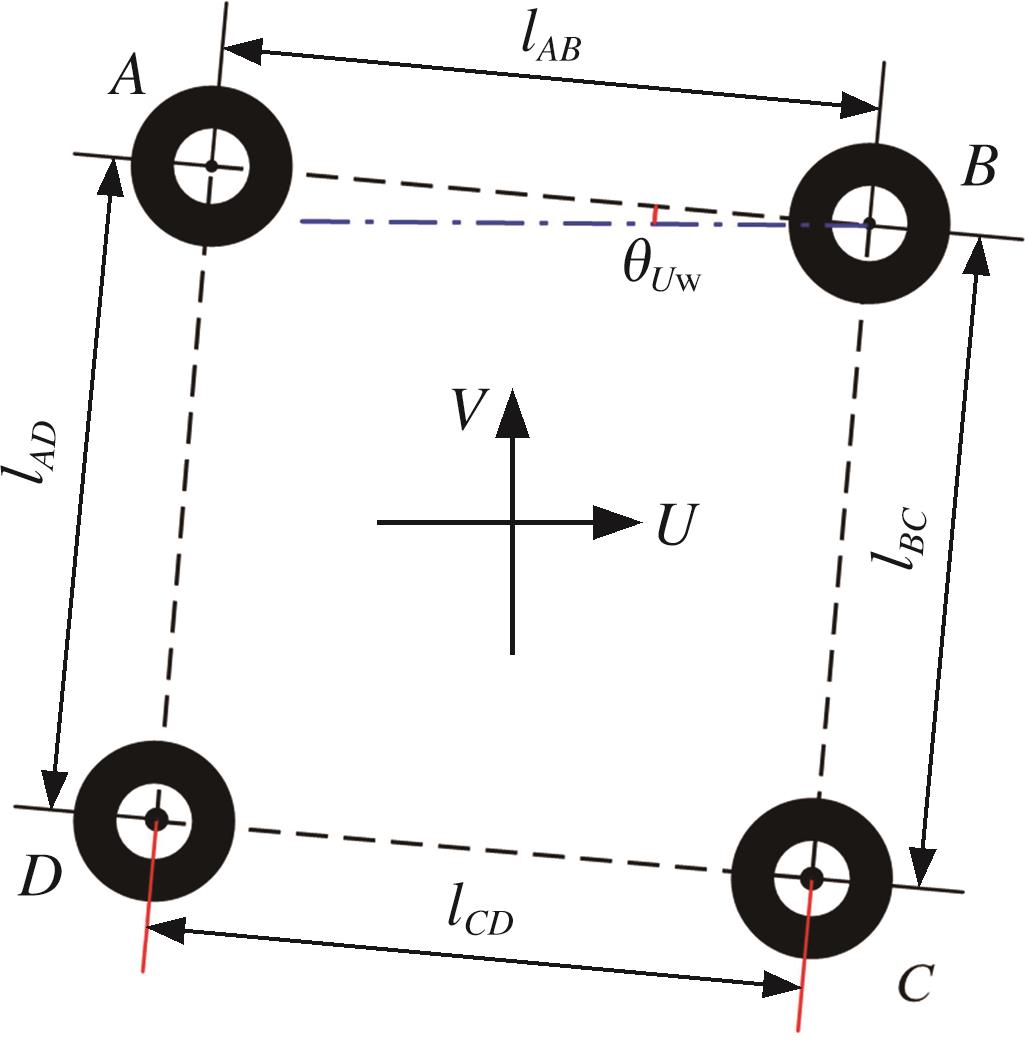
图6 偏角θUw及像素当量标定
Fig.6 Declination θUw and pixel equivalent calibration
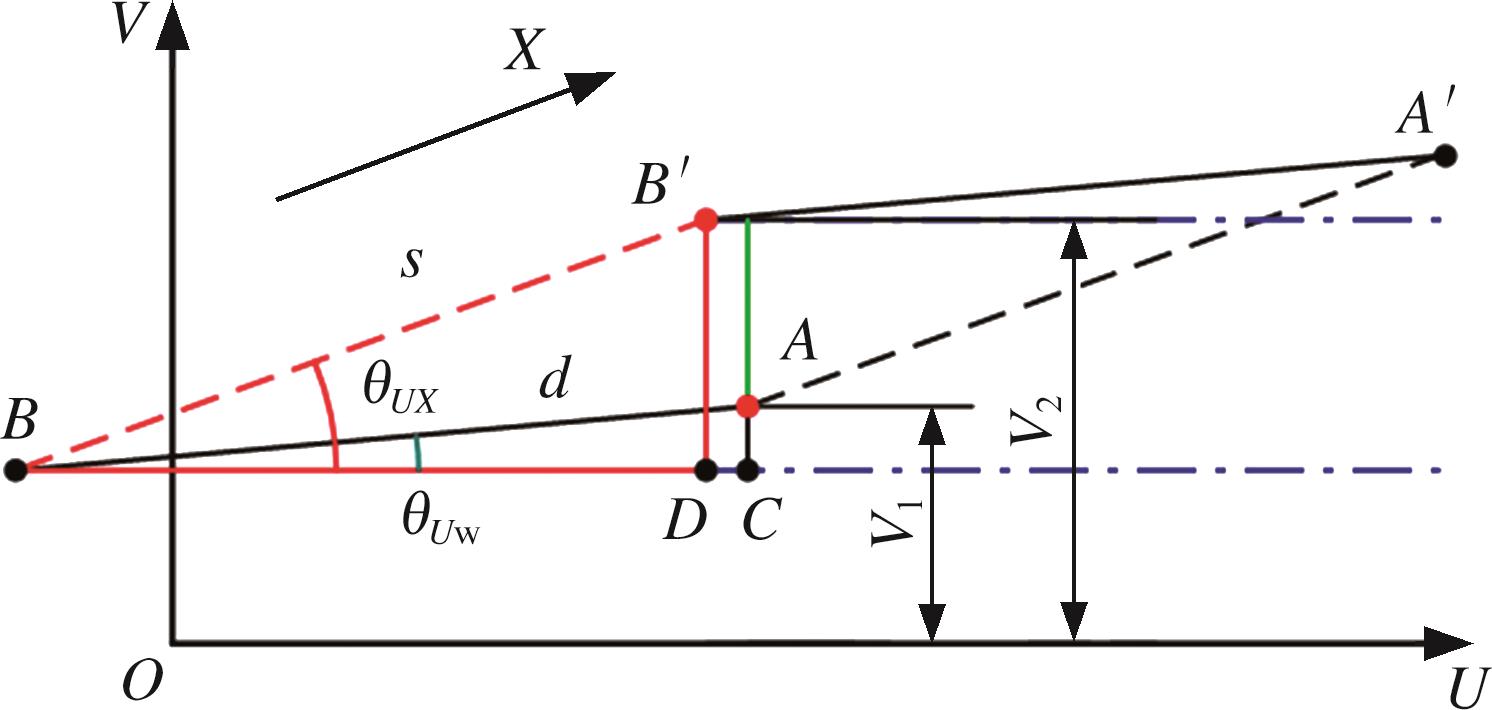
图7 偏角θUX标定
Fig.7 Declination θUX calibration
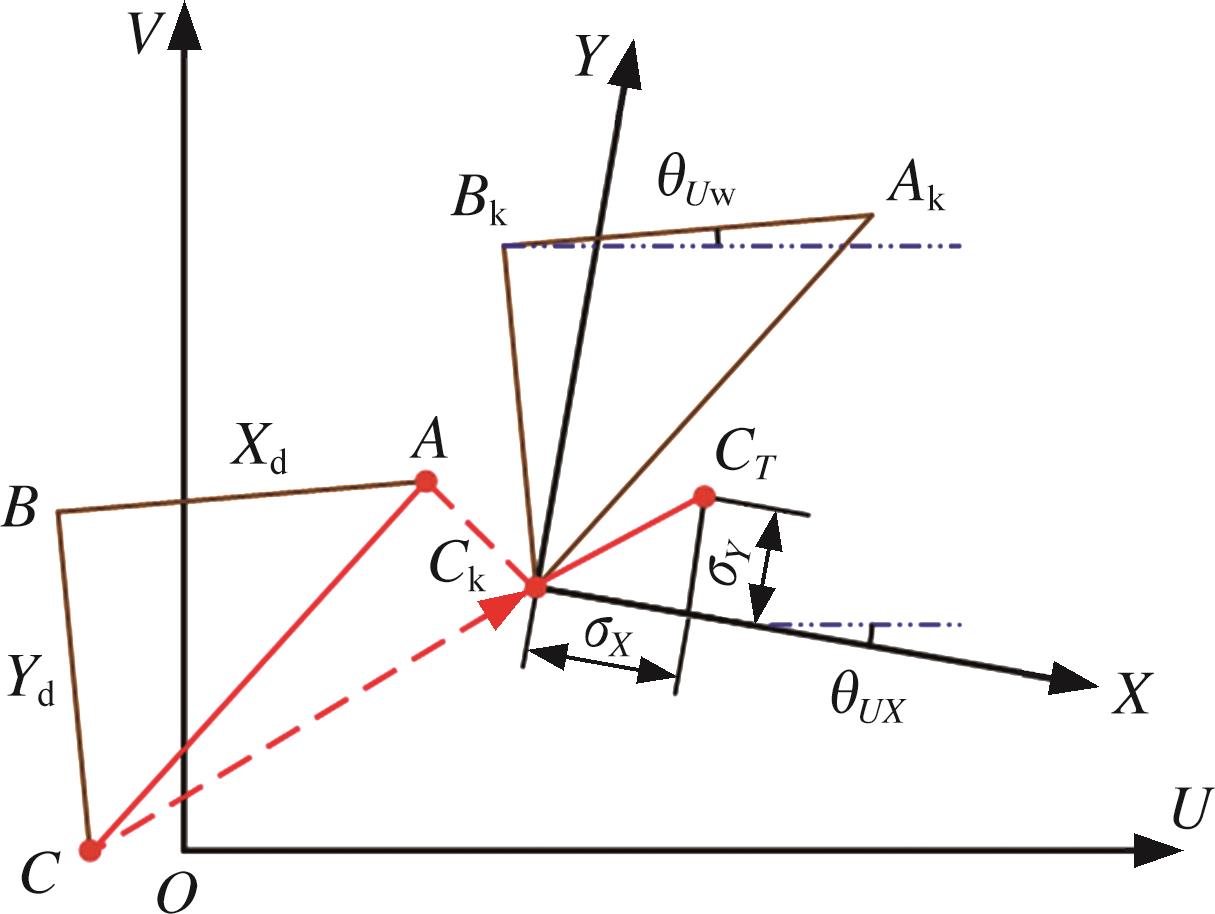
图8 平台移动时靶标位置变化示意图
Fig.8 Schematic diagram of the change of target position when the platform is moving
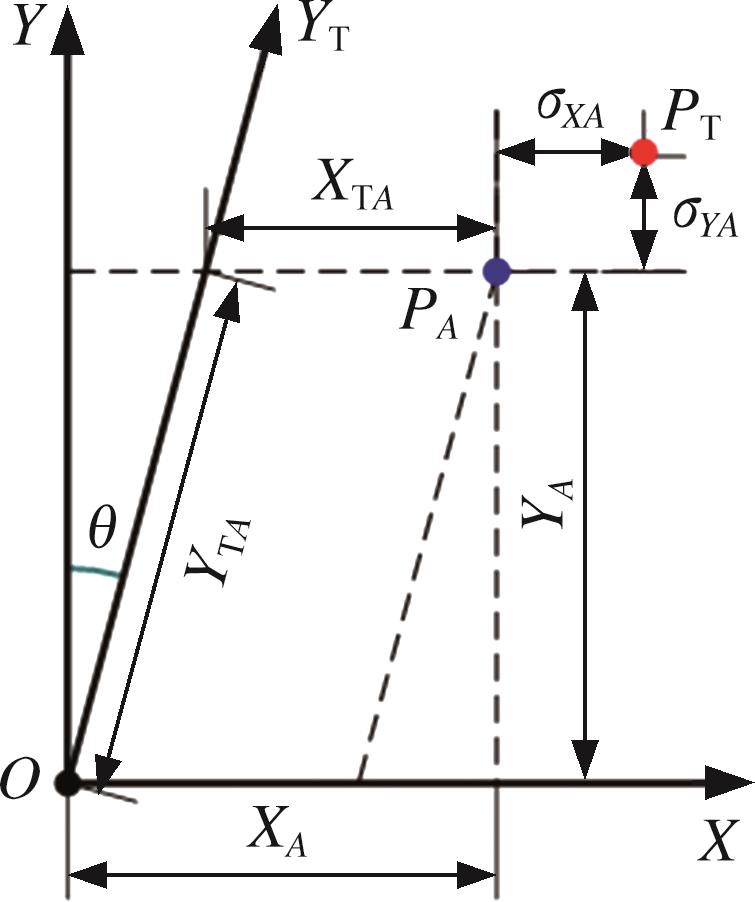
图9 误差补偿原理示意图
Fig.9 Schematic diagram of error compensation principle
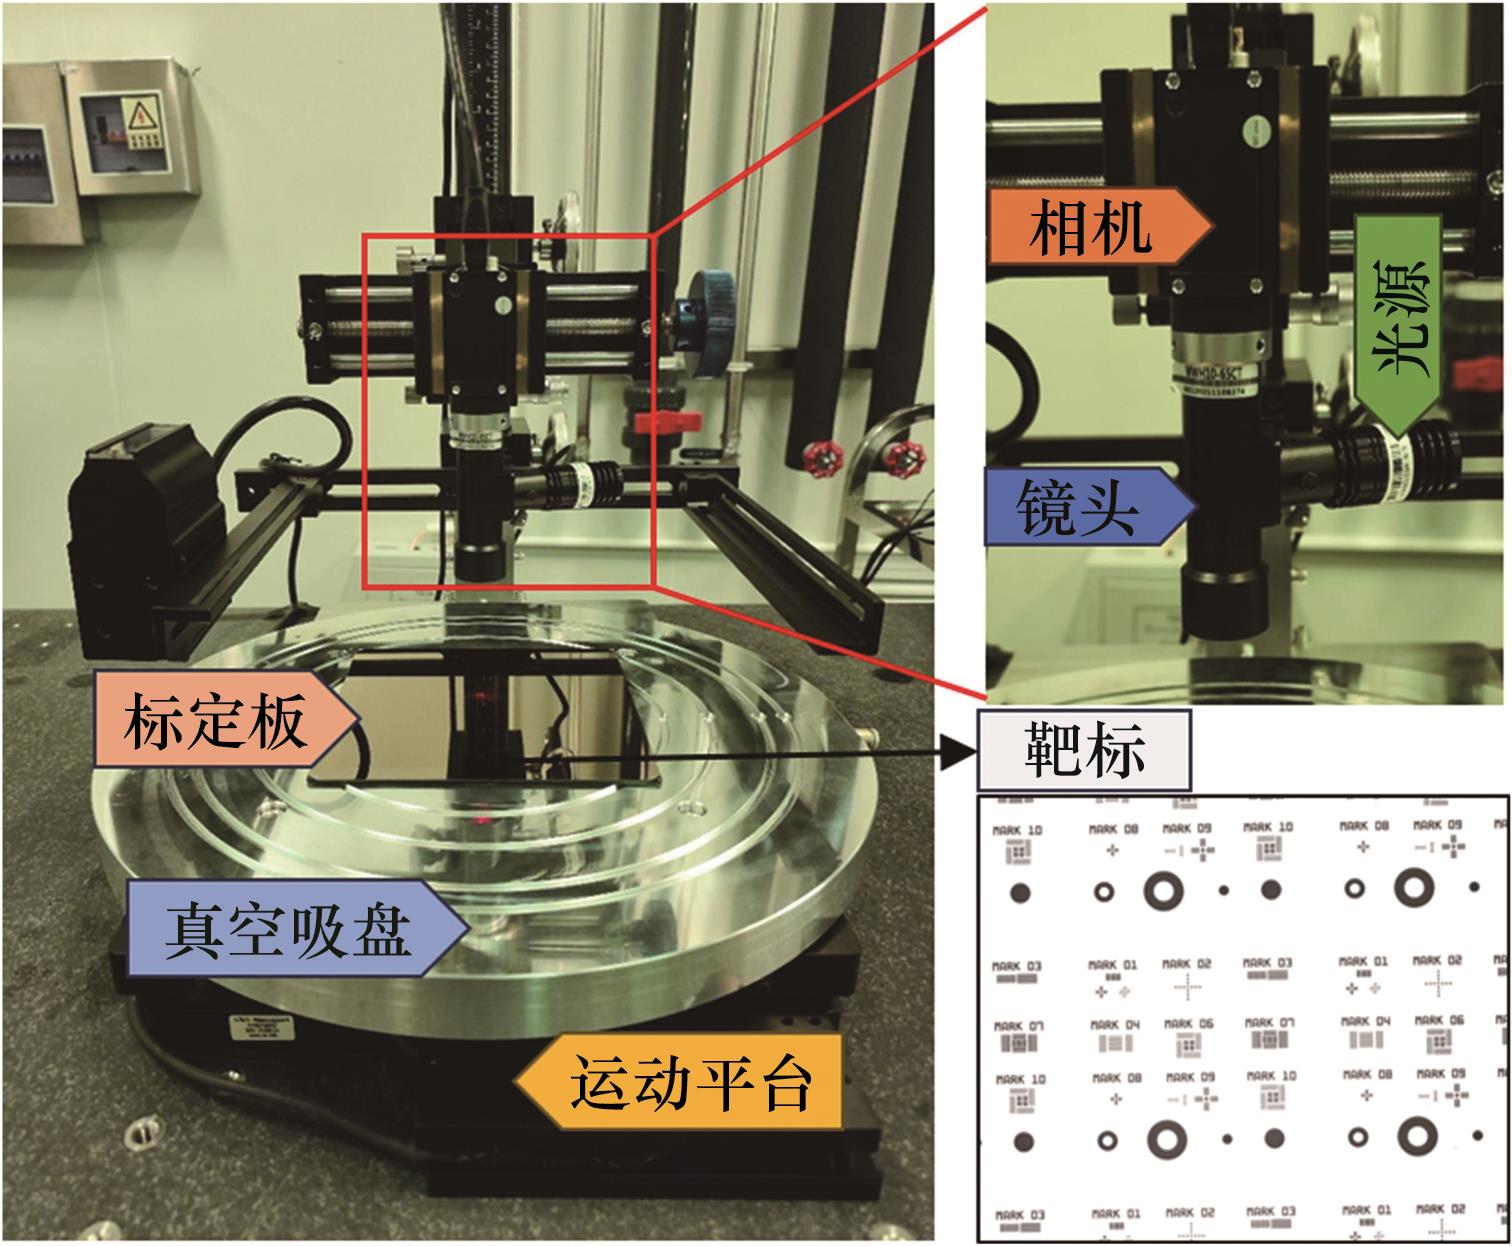
图10 视觉测量实验系统
Fig.10 Experimental setup of the vision measurement system
| 数值 | 2.5048 | 2.5068 | 0.6763 | 0.9509 | 0.9499 |
表2 标定实验数据
Tab.2 Calibration experimental data
| 数值 | 2.5048 | 2.5068 | 0.6763 | 0.9509 | 0.9499 |
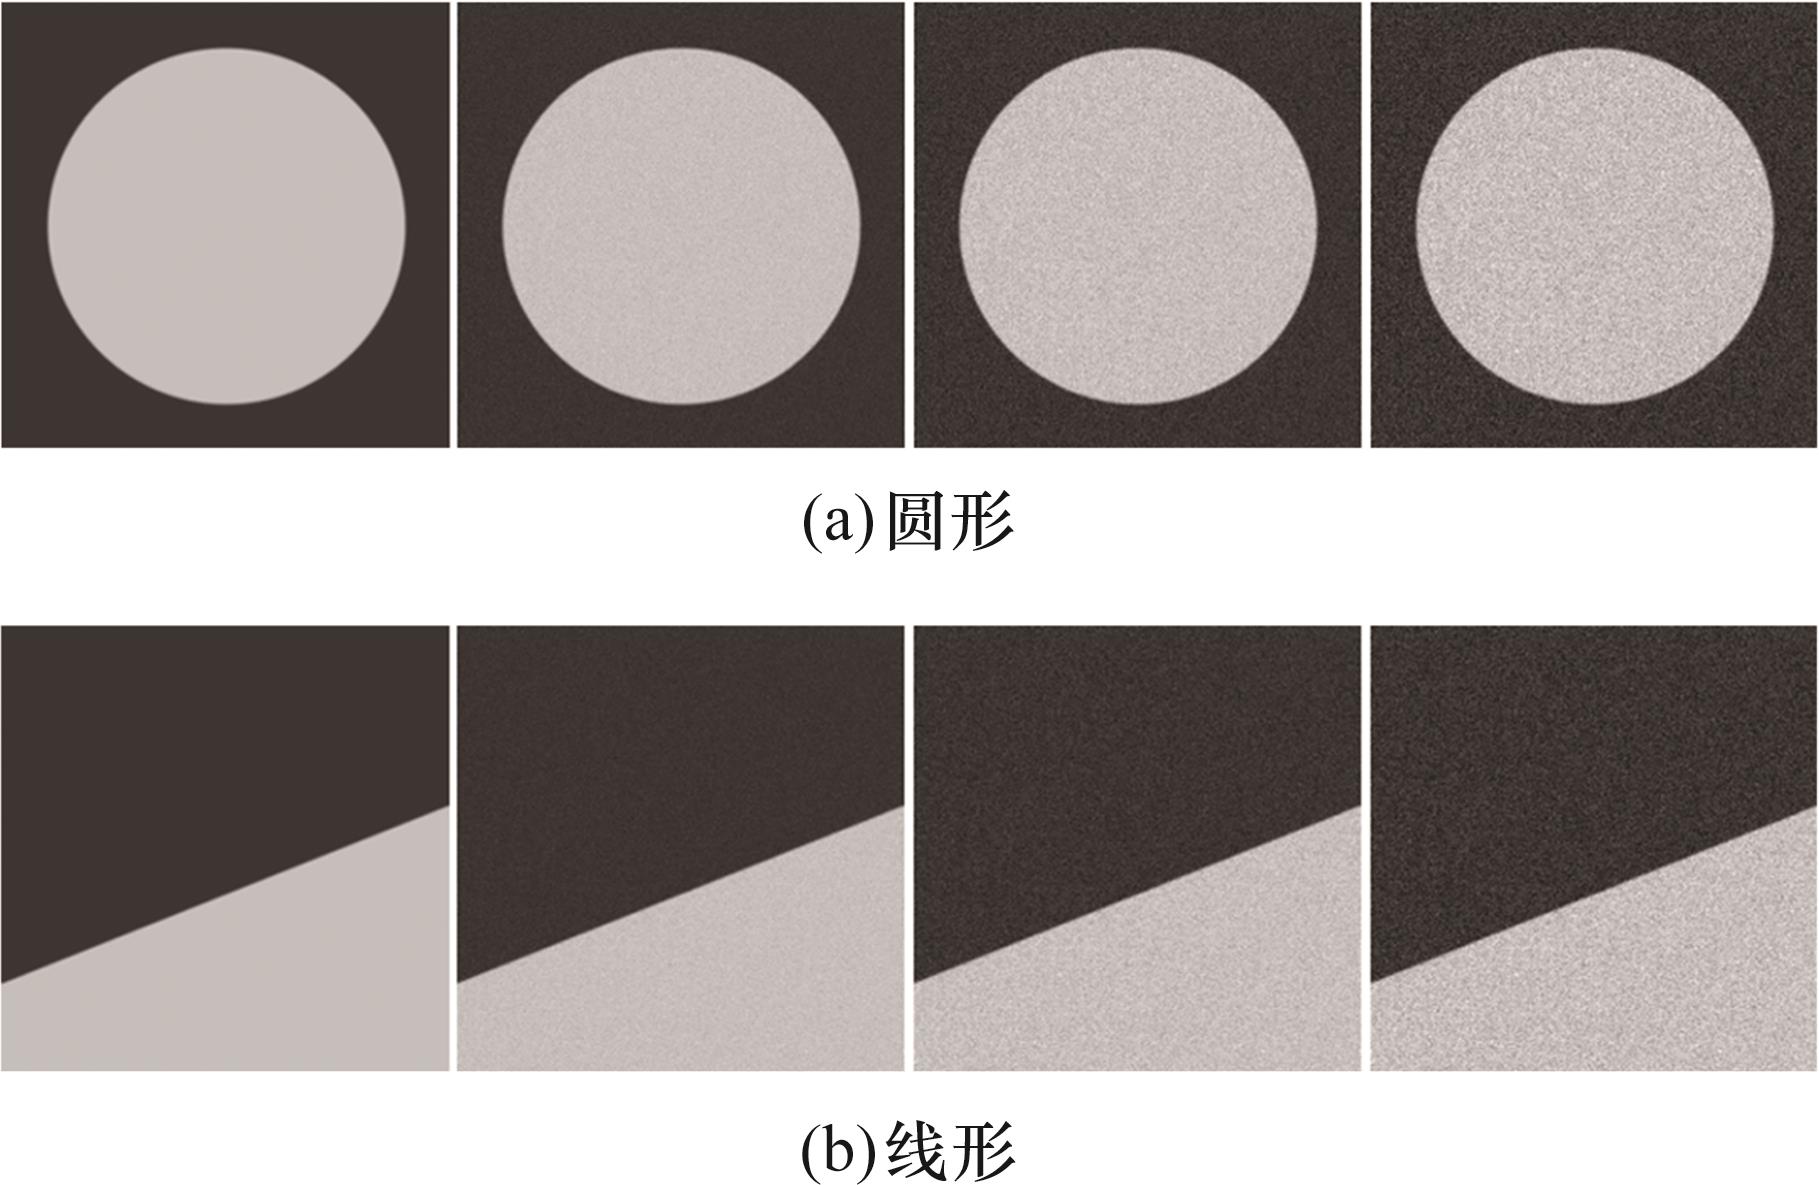
图11 仿真图像
Fig.11 Simulation images
| 方法 | 噪声 标准差 | 圆形 平均值 | 圆形 标准差 | 线形 平均值 | 线形 标准差 |
|---|---|---|---|---|---|
| Zernike | 0 | 0.101 | 0.077 | 0.063 | 0.040 |
| 10 | 0.116 | 0.079 | 0.081 | 0.057 | |
| 20 | 0.147 | 0.099 | 0.129 | 0.093 | |
| 30 | 0.206 | 0.146 | 0.207 | 0.153 | |
| C-Zernike | 0 | 0.079 | 0.063 | 0.043 | 0.028 |
| 10 | 0.097 | 0.064 | 0.065 | 0.047 | |
| 20 | 0.138 | 0.088 | 0.117 | 0.086 | |
| 30 | 0.194 | 0.138 | 0.198 | 0.147 | |
| A-Zernike | 0 | 0.048 | 0.035 | 0.009 | 0.007 |
| 10 | 0.061 | 0.043 | 0.052 | 0.041 | |
| 20 | 0.091 | 0.065 | 0.096 | 0.074 | |
| 30 | 0.148 | 0.115 | 0.167 | 0.133 |
表3 边缘检测结果对比(像素)
Tab.3 Comparison of edge detection results(pixel)
| 方法 | 噪声 标准差 | 圆形 平均值 | 圆形 标准差 | 线形 平均值 | 线形 标准差 |
|---|---|---|---|---|---|
| Zernike | 0 | 0.101 | 0.077 | 0.063 | 0.040 |
| 10 | 0.116 | 0.079 | 0.081 | 0.057 | |
| 20 | 0.147 | 0.099 | 0.129 | 0.093 | |
| 30 | 0.206 | 0.146 | 0.207 | 0.153 | |
| C-Zernike | 0 | 0.079 | 0.063 | 0.043 | 0.028 |
| 10 | 0.097 | 0.064 | 0.065 | 0.047 | |
| 20 | 0.138 | 0.088 | 0.117 | 0.086 | |
| 30 | 0.194 | 0.138 | 0.198 | 0.147 | |
| A-Zernike | 0 | 0.048 | 0.035 | 0.009 | 0.007 |
| 10 | 0.061 | 0.043 | 0.052 | 0.041 | |
| 20 | 0.091 | 0.065 | 0.096 | 0.074 | |
| 30 | 0.148 | 0.115 | 0.167 | 0.133 |
| 序号 | 位置1 | 位置2 | 位置3 |
|---|---|---|---|
| 1 | (1333.761,1091.306) | (1382.557,1105.202) | (1331.457,1088.581) |
| 2 | (1333.744,1091.231) | (1382.525,1105.118) | (1331.484,1088.525) |
| 3 | (1333.750,1091.260) | (1382.553,1105.185) | (1331.475,1088.609) |
| 4 | (1333.754,1091.273) | (1382.535,1105.147) | (1331.468,1088.525) |
| 5 | (1333.759,1091.271) | (1382.544,1105.154) | (1331.473,1088.555) |
| 6 | (1333.747,1091.266) | (1382.540,1105.167) | (1331.469,1088.557) |
| 7 | (1333.749,1091.245) | (1382.550,1105.154) | (1331.471,1088.563) |
| 8 | (1333.756,1091.319) | (1382.533,1105.177) | (1331.470,1088.543) |
| 9 | (1333.764,1091.246) | (1382.548,1105.209) | (1331.450,1088.527) |
| 10 | (1333.742,1091.291) | (1382.534,1105.111) | (1331.491,1088.579) |
| 极差 | 0.091 | 0.102 | 0.094 |
表4 靶标中心测量结果(像素)
Tab.4 Target center measurement results(pixel)
| 序号 | 位置1 | 位置2 | 位置3 |
|---|---|---|---|
| 1 | (1333.761,1091.306) | (1382.557,1105.202) | (1331.457,1088.581) |
| 2 | (1333.744,1091.231) | (1382.525,1105.118) | (1331.484,1088.525) |
| 3 | (1333.750,1091.260) | (1382.553,1105.185) | (1331.475,1088.609) |
| 4 | (1333.754,1091.273) | (1382.535,1105.147) | (1331.468,1088.525) |
| 5 | (1333.759,1091.271) | (1382.544,1105.154) | (1331.473,1088.555) |
| 6 | (1333.747,1091.266) | (1382.540,1105.167) | (1331.469,1088.557) |
| 7 | (1333.749,1091.245) | (1382.550,1105.154) | (1331.471,1088.563) |
| 8 | (1333.756,1091.319) | (1382.533,1105.177) | (1331.470,1088.543) |
| 9 | (1333.764,1091.246) | (1382.548,1105.209) | (1331.450,1088.527) |
| 10 | (1333.742,1091.291) | (1382.534,1105.111) | (1331.491,1088.579) |
| 极差 | 0.091 | 0.102 | 0.094 |
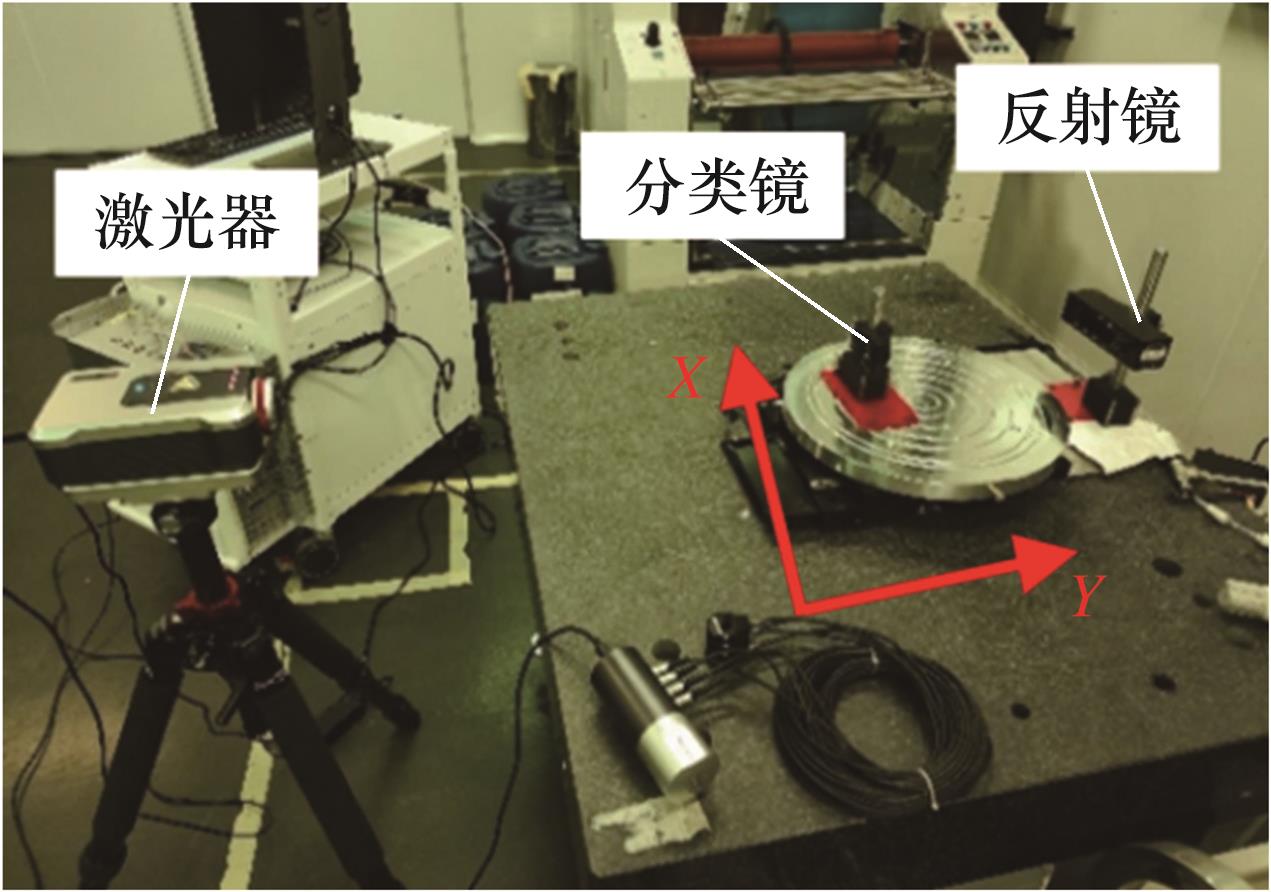
图12 激光干涉仪测量
Fig.12 Laser interferometer measurements
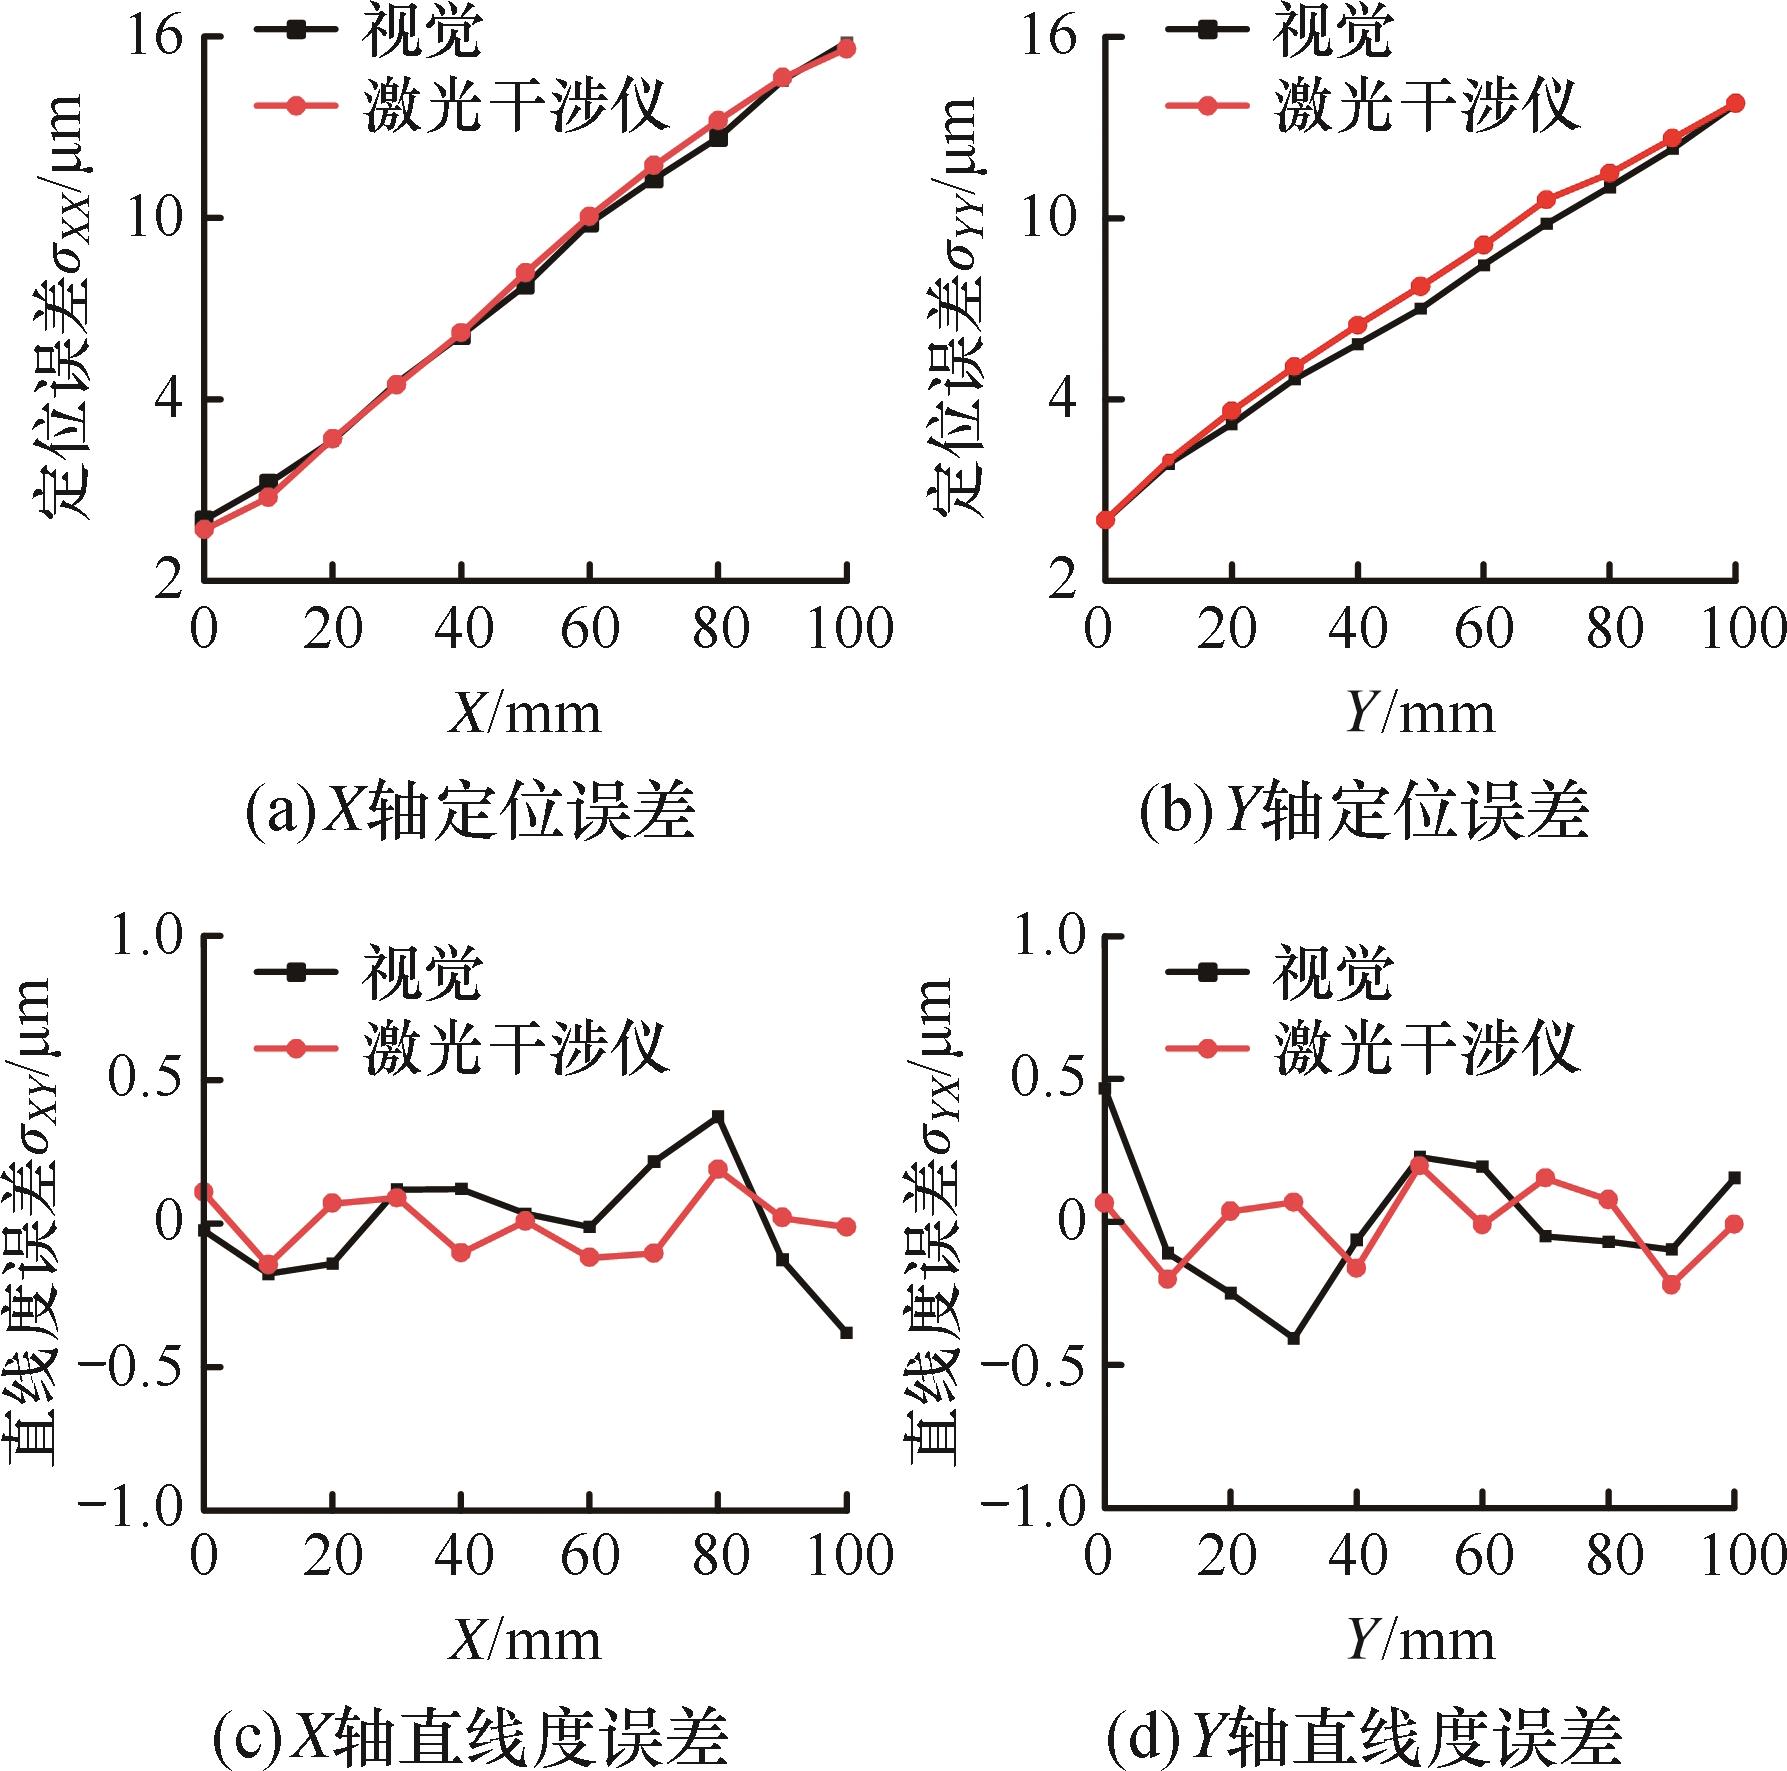
图13 X和Y轴误差测量实验结果
Fig13 Experimental results of X-axis and Y-axis error measurements
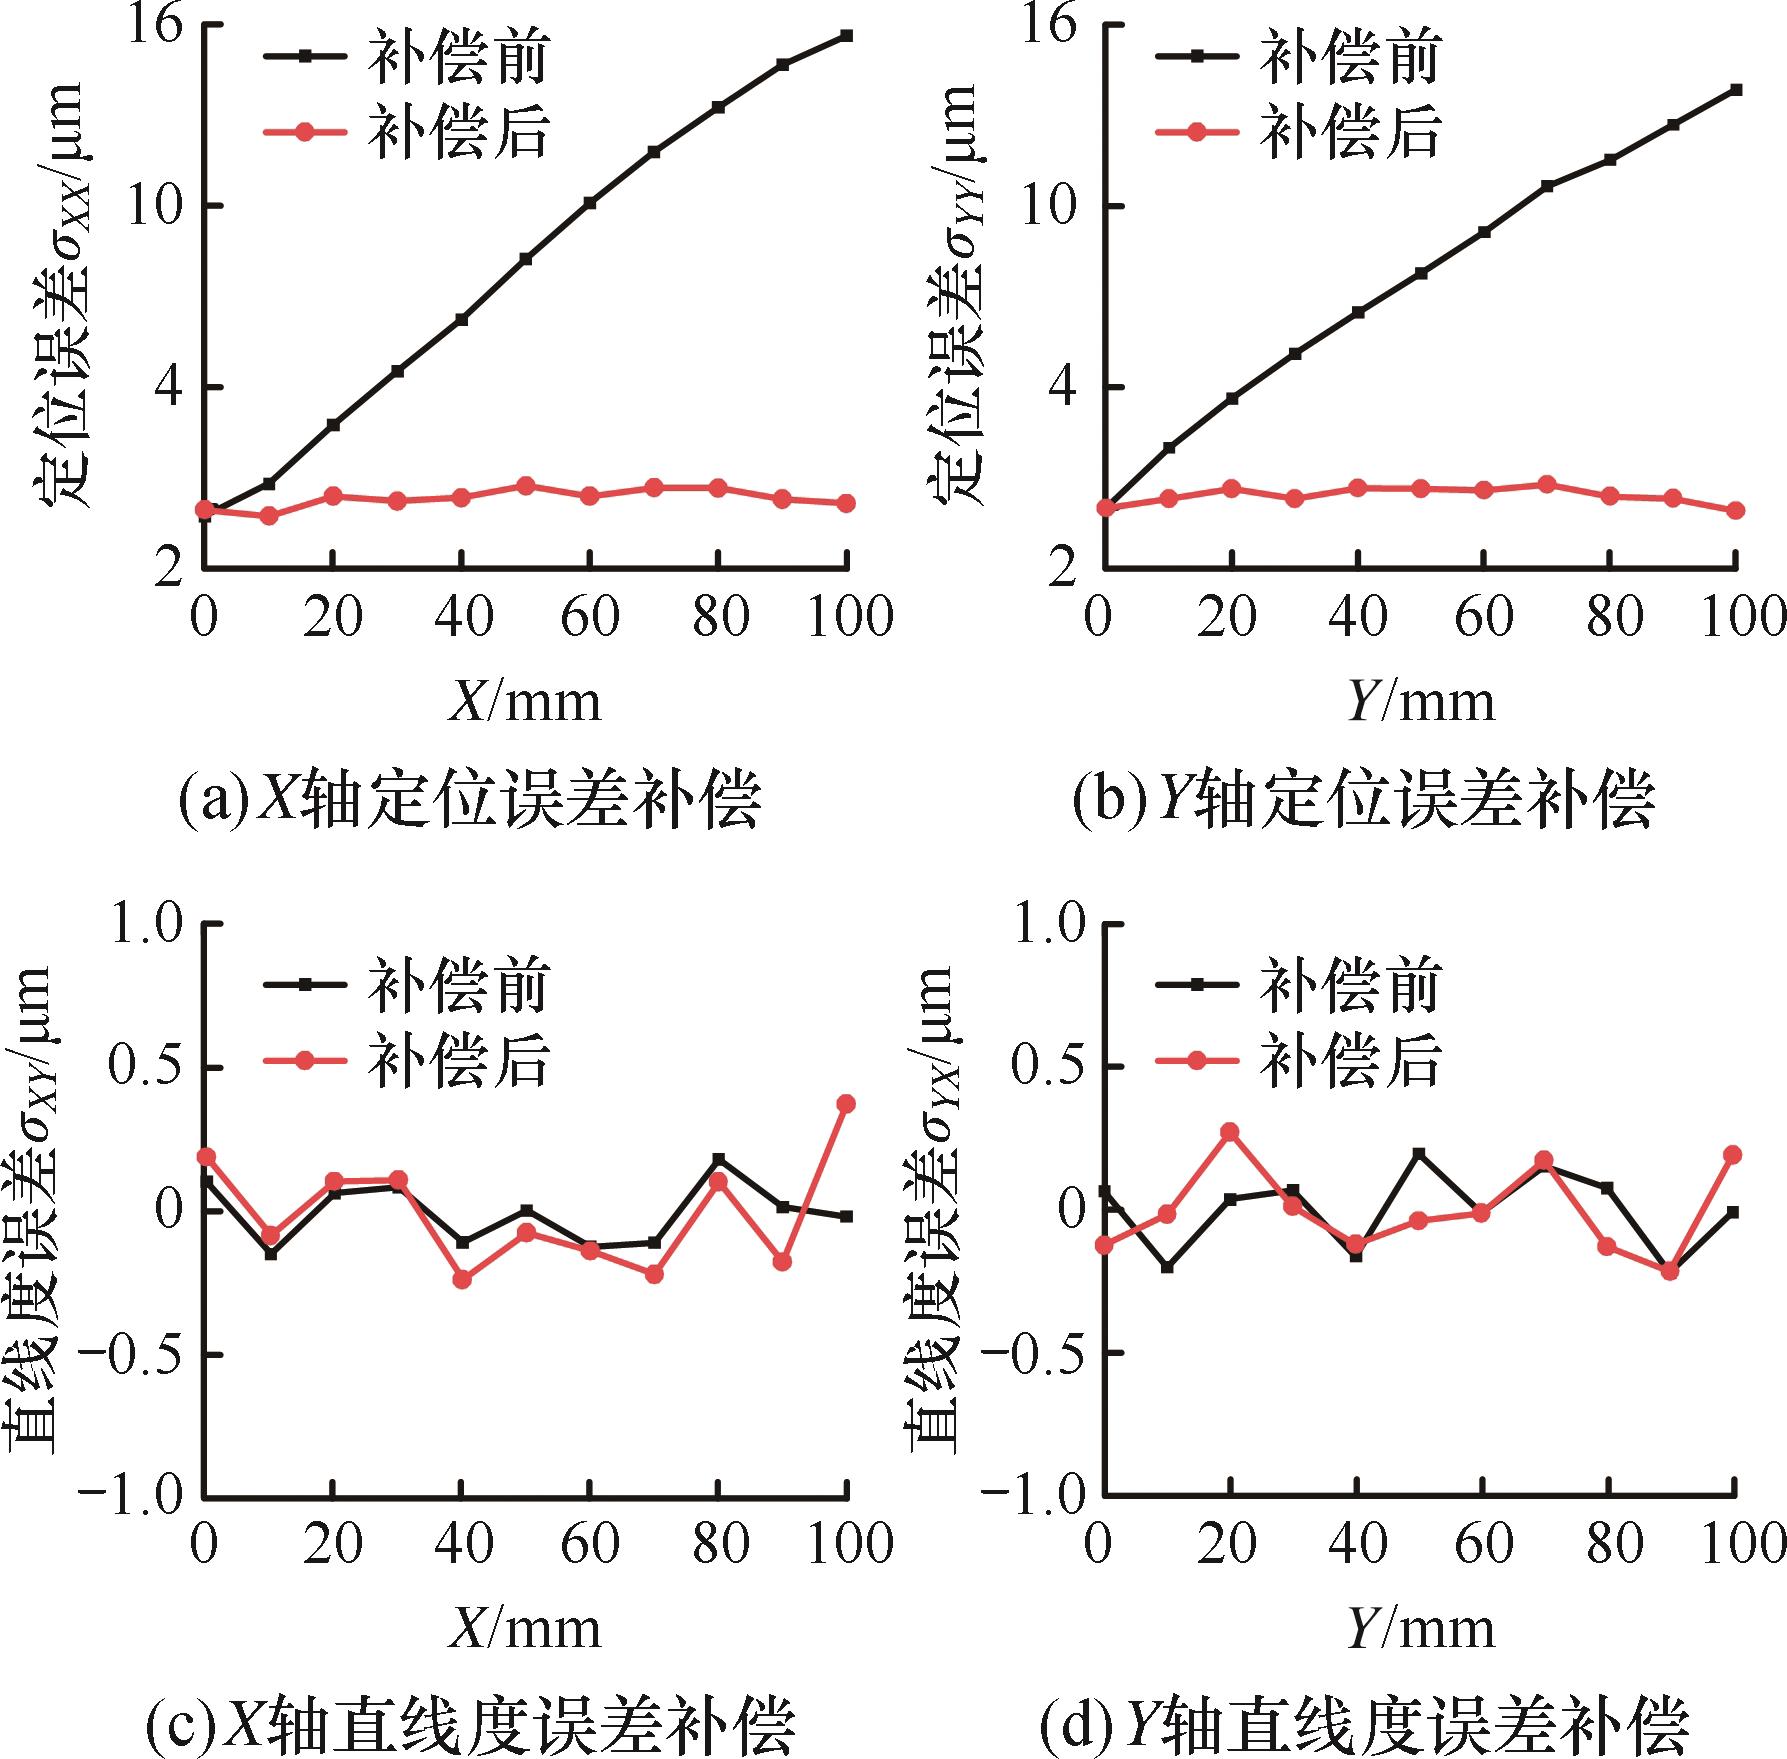
图14 X和Y轴误差补偿实验结果
Fig.14 Experimental results of X-axis and Y-axis error compensation
| [1] | HE Sifeng, TANG Hui, ZHANG Kaifu, et al. A Flip-chip Alignment System with the Property of Deviation Self-correction at the Nanoscale[J]. IEEE Transactions on Industrial Electronics, 2021, 68(3): 2345-2355. |
| [2] | WANG Yutian, WANG Dong, ZHANG Shizhen, et al. Design and Development of a Five-axis Machine Tool with High Accuracy, Stiffness and Efficiency for Aero-engine Casing Manufacturing[J]. Chinese Journal of Aeronautics, 2022, 35(4): 485-496. |
| [3] | 戴一帆, 彭小强, 薛帅, 等. 高性能光学制造[J]. 机械工程学报, 2023, 59(21): 1-14. |
| DAI Yifan, PENG Xiaoqiang, XUE Shuai, et al. High-performance Optical Manufacturing[J]. Journal of Mechanical Engineering, 2023, 59(21): 1-14. | |
| [4] | 张金迪, 高健, 谭宇韬, 等. 高速宏微运动平台及精密定位方法[J]. 制造技术与机床, 2019(8): 117-121. |
| ZHANG Jindi, GAO Jian, TAN Yutao, et al. High Speed Macro-Micro Motion Stage and Precision Positioning Method[J]. Manufacturing Technology & Machine Tool, 2019(8): 117-121. | |
| [5] | 马榕苓. 数控机床误差补偿关键技术及其应用研究[J]. 现代制造技术与装备, 2023, 59(8): 114-116. |
| MA Rongling. Research on the Key Technology and Application of Error Compensation for CNC Machine Tools[J]. Modern Manufacturing Technology and Equipment, 2023, 59(8): 114-116. | |
| [6] | 赵晨阳, 向捷, 卞凯, 等. 基于光学显微视觉的精密定位测量综述(特邀)[J]. 激光与光电子学进展, 2024, 61(2): 0211021. |
| ZHAO Chenyang, XIANG Jie, BIAN Kai, et al. Review of Optical Microvision-based Precision Positioning Measurement(Invited)[J]. Laser & Optoelectronics Progress, 2024, 61(2): 0211021. | |
| [7] | LEE C, LEE S K. Multi-degree-of-freedom Motion Error Measurement in an Ultraprecision Machine Using Laser Encoder—Review[J]. Journal of Mechanical Science and Technology, 2013, 27(1): 141-152. |
| [8] | 邹华东, 贾瑞清, 张畅. 基于机器视觉的影像测量仪工作台定位误差精密补偿方法[J]. 激光与光电子学进展, 2018, 55(9): 202-209. |
| ZOU Huadong, JIA Ruiqing, ZHANG Chang. Precision Compensation Method for Positioning Error of Working Table of Vision Measuring Machine Based on Machine Vision[J]. Laser & Optoelectronics Progress, 2018, 55(9): 202-209. | |
| [9] | EKBERG P, STIBLERT L, MATTSSON L. A New General Approach for Solving the Self-calibration Problem on Large Area 2D Ultra-precision Coordinate Measurement Machines[J]. Measurement Science and Technology, 2014, 25(5): 055001. |
| [10] | QIAO Xiaoyue, CHEN Xin, EKBERG P, et al. Self-calibration for the 2D Stage Based on Weighted Least Squares[J]. Measurement Science and Technology, 2019, 30(12): 125015. |
| [11] | 刘源泂, 程管, 汤勃, 等. 单目球形靶标球心成像坐标求解方法[J]. 激光与光电子学进展, 2023, 60(12): 1211005. |
| LIU Yuanjiong, CHENG Guan, TANG Bo, et al. Spherical Center Imaging Location Solution Method for Monocular Spherical Target[J]. Laser & Optoelectronics Progress, 2023, 60(12): 1211005. | |
| [12] | HUANG Cheng, JIN Wei, XU Qian, et al. Sub-pixel Edge Detection Algorithm Based on Canny–Zernike Moment Method[J]. Journal of Circuits, Systems and Computers, 2020, 29(15): 2050238. |
| [13] | 巢渊, 唐寒冰, 刘文汇, 等. 基于改进Zernike矩的轴类零件尺寸测量方法[J]. 电子测量技术, 2022, 45(3): 169-176. |
| CHAO Yuan, TANG Hanbing, LIU Wenhui, et al. Improved Zernike Moment-based Dimensional Measurement Method for Shaft Parts[J]. Electronic Measurement Technology, 2022, 45(3): 169-176. | |
| [14] | 刘明佩, 朱维斌, 叶树亮. 基于改进Zernike矩的小模数齿轮亚像素边缘检测[J]. 仪器仪表学报, 2018, 39(8): 259-267. |
| LIU Mingpei, ZHU Weibin, YE Shuliang. Sub-pixel Edge Detection Based on Improved Zernike Moment in the Small Modulus Gear Image[J]. Chinese Journal of Scientific Instrument, 2018, 39(8): 259-267. | |
| [15] | MO Jiadi, YAN He, LIU Jihong. An Adaptive Sub-pixel Edge Detection Method Based on Improved Zernike Moment[J]. International Journal of Wireless and Mobile Computing, 2022, 22(2): 140. |
| [16] | RENSHAW D T, CHRISTIAN J A. Subpixel Localization of Isolated Edges and Streaks in Digital Images[J]. Journal of Imaging, 2020, 6(5): 33. |
| [17] | 刘国栋, 刘炳国, 陈凤东, 等. 亚像素定位算法精度评价方法的研究[J]. 光学学报, 2009, 29(12): 3446-3451. |
| LIU Guodong, LIU Bingguo, CHEN Fengdong, et al. Study on the Method of the Accuracy Evaluation of Sub-pixel Location Operators[J]. Acta Optica Sinica, 2009, 29(12): 3446-3451. | |
| [18] | CHRISTIAN J A. Accurate Planetary Limb Localization for Image-based Spacecraft Navigation[J]. Journal of Spacecraft and Rockets, 2017, 54(3): 708-730. |
| [19] | 安晶晶, 高楠, 陈超, 等. 圆环标识的离心偏差校正方法与评价[J]. 激光与光电子学进展, 2017, 54(4): 165-173. |
| AN Jingjing, GAO Nan, CHEN Chao, et al. Correcting Method and Evaluation of Eccentricity Error of Circle Target[J]. Laser & Optoelectronics Progress, 2017, 54(4): 165-173. | |
| [20] | 张杰, 施露露, 史振志, 等. 相差细胞图像的光照均衡与分割计数方法研究[J]. 电子测量与仪器学报, 2022, 36(5): 136-145. |
| ZHANG Jie, SHI Lulu, SHI Zhenzhi, et al. Study of Light Equalization and Segmentation Counting Method for Cell Phase Contrast Images[J]. Journal of Electronic Measurement and Instrumentation, 2022, 36(5): 136-145. |
| [1] | 丁涛1, 2, 吴浩1, 2, 朱大虎1, 2. 异常点云干扰下的车身构件鲁棒性配准方法[J]. 中国机械工程, 2024, 35(06): 1074-1085. |
| [2] | 易怀安, 赵欣佳, 唐乐, 陈永伦. 基于彩色图像奇异值熵指标的磨削表面粗糙度视觉测量方法[J]. 中国机械工程, 2021, 32(13): 1577-1583. |
| [3] | 李永泉1,2;王皓辰2, 3;张阳1,2;张岩1,2;张立杰2, 3. 一种基于手眼视觉的并联机器人标定方法[J]. 中国机械工程, 2020, 31(06): 722-730,755. |
| [4] | 刘坚;王媛媛. 一种面向球姿态检测的图像透视畸变校正方法[J]. 中国机械工程, 2019, 30(18): 2242-2249,2256. |
| [5] | 黎桥, 朱援祥, 周立武, 周兵. 细丝微细磨削中的轮廓成形研究[J]. 中国机械工程, 2017, 28(01): 35-40. |
| [6] | 张旭, 郑泽龙. 主动光立体标靶检测及其在工业机器人位姿测量中的应用[J]. 中国机械工程, 2016, 27(19): 2594-2601. |
| [7] | 喻其炳, 尹爱军, 薛磊, 张泉. 基于单目离面视觉的结构振动检测[J]. 中国机械工程, 2016, 27(17): 2367-2371,2378. |
| [8] | 熊维;李文龙;尹周平. 双目PMP视觉测量中立体匹配方法的设计与实现[J]. 中国机械工程, 2013, 24(19): 2635-2640,2646. |
| [9] | 唐皓, 段吉安, 郑煜, 祝孟鹏. 平面光波导精密对准平台运动误差的敏感性分析[J]. 中国机械工程, 2012, 23(8): 888-892,896. |
| [10] | 夏瑞雪, 卢荣胜. 数控机床视觉在位测量CAI系统[J]. 中国机械工程, 2012, 23(17): 2041-2047. |
| [11] | 刘琼;秦现生;应申舜;贺峰. 双目视觉测量系统结构参数设计及精度分析[J]. J4, 2008, 19(22): 0-2649. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
