China Mechanical Engineering ›› 2026, Vol. 37 ›› Issue (8): 1999-2008.DOI: 10.3969/j.issn.1004-132X.2026.08.019
WU Xing1(
), LYU Peng1, SHA Jinlong2, LI Yangzhi1, Meng Zhaoxu2
Received:2025-08-18
Online:2026-08-25
Published:2026-09-17
Contact:
WU Xing
通讯作者:
武星
基金资助:CLC Number:
WU Xing, LYU Peng, SHA Jinlong, LI Yangzhi, Meng Zhaoxu. Docking Trajectory Planning Based on Improved Multi-objective Particle Swarm Optimization for Mobile Robots[J]. China Mechanical Engineering, 2026, 37(8): 1999-2008.
武星, 吕鹏, 沙金龙, 李杨志, 孟昭旭. 基于改进多目标粒子群优化的移动机器人对接轨迹规划[J]. 中国机械工程, 2026, 37(8): 1999-2008.
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.cmemo.org.cn/EN/10.3969/j.issn.1004-132X.2026.08.019
| 算法 | HSAGM-MOPSO | MOPSO | NSGA-Ⅱ | IAMOPSO |
|---|---|---|---|---|
| 种群规模 | 200 | 200 | 200 | 200 |
| 迭代次数 | 500 | 500 | 500 | 500 |
| 外部档案库大小 | 200 | 200 | 200 | 200 |
| 惯性权重衰减系数 | 0.95 | 0.95 | 0.95 | |
| 交叉率 | 0.4 | |||
| 变异率 | 0.1 | 0.1 | 0.1 |
Tab.1 Parameter settings for each algorithm
| 算法 | HSAGM-MOPSO | MOPSO | NSGA-Ⅱ | IAMOPSO |
|---|---|---|---|---|
| 种群规模 | 200 | 200 | 200 | 200 |
| 迭代次数 | 500 | 500 | 500 | 500 |
| 外部档案库大小 | 200 | 200 | 200 | 200 |
| 惯性权重衰减系数 | 0.95 | 0.95 | 0.95 | |
| 交叉率 | 0.4 | |||
| 变异率 | 0.1 | 0.1 | 0.1 |
| 算法 | GD | SP | HV |
|---|---|---|---|
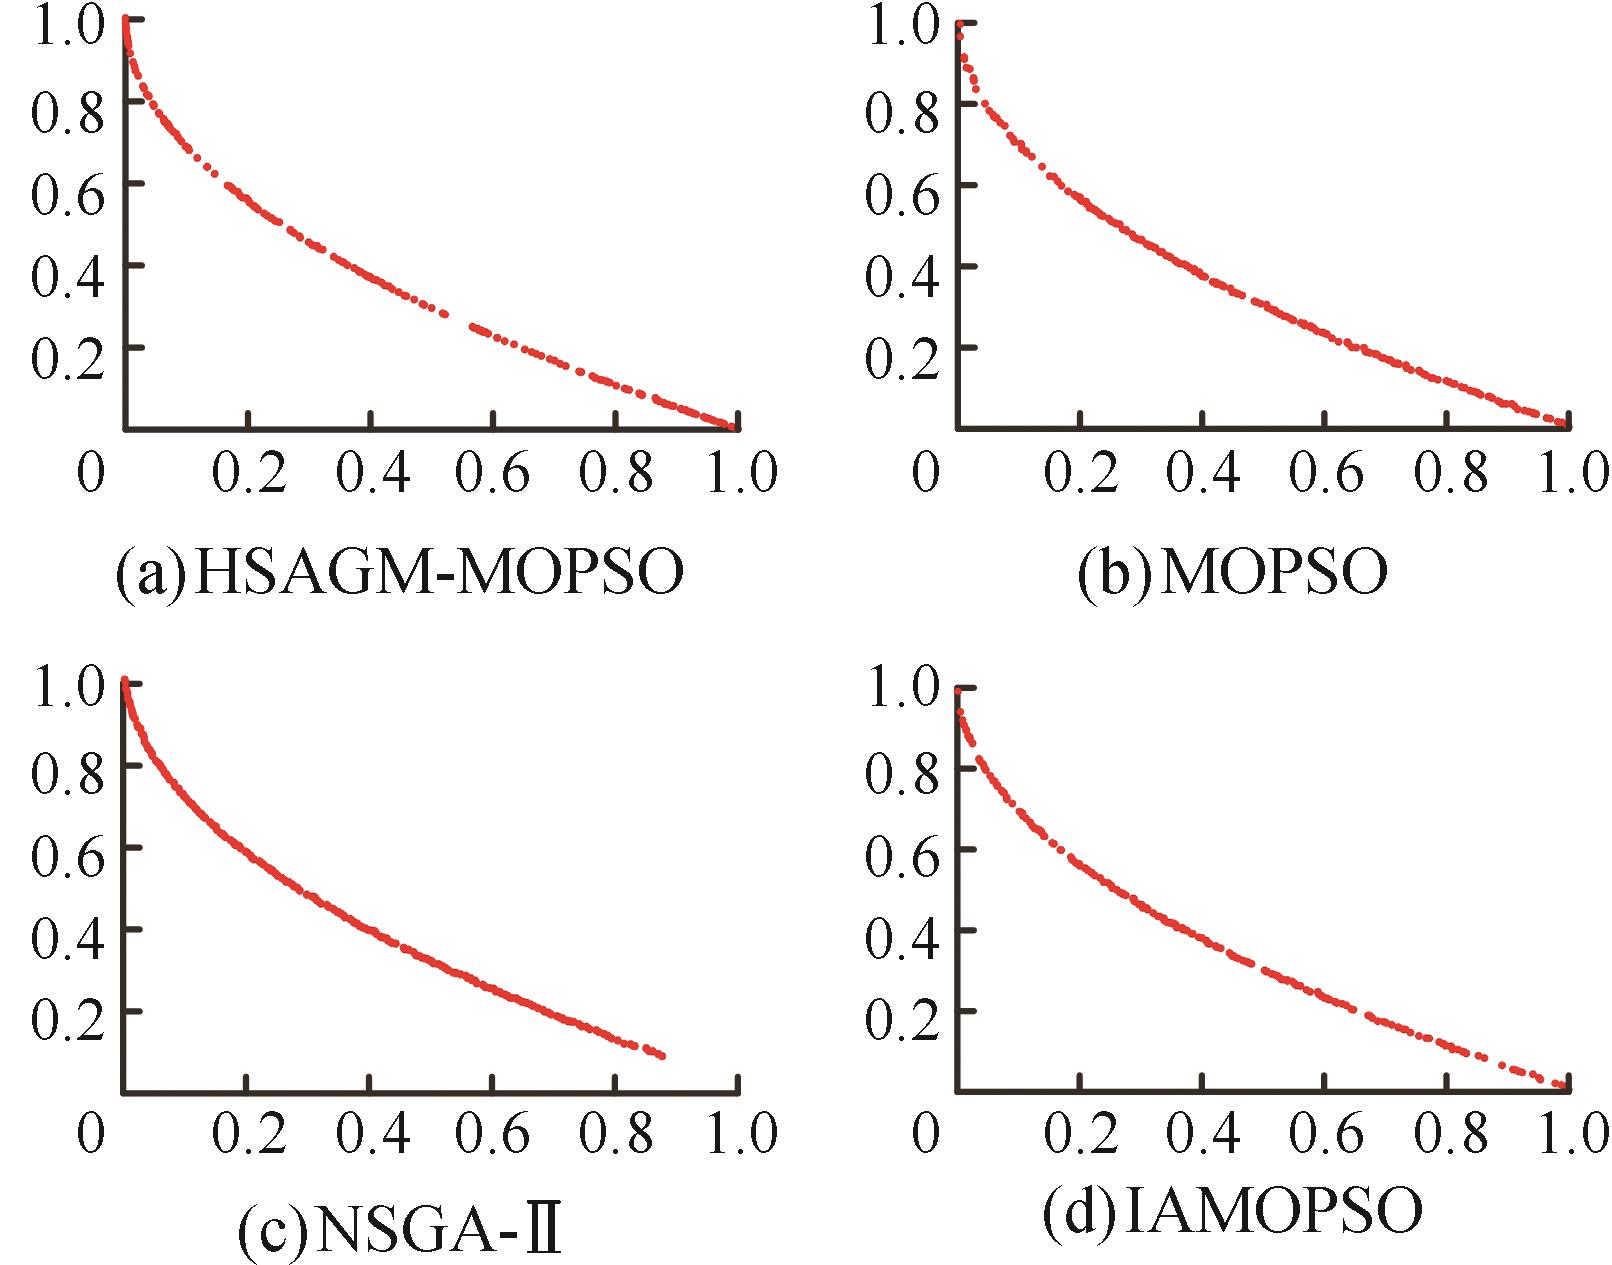
| HSAGM-MOPSO | 0.0048 | 0.0040 | 0.6592 |
| MOPSO | 0.0129 | 0.0051 | 0.6461 |
| NSGA-Ⅱ | 0.0310 | 0.0041 | 0.6307 |
| IAMOPSO | 0.0083 | 0.0047 | 0.6527 |
Tab.2 Comparison of performance metrics on ZDT1 problems
| 算法 | GD | SP | HV |
|---|---|---|---|
| HSAGM-MOPSO | 0.0048 | 0.0040 | 0.6592 |
| MOPSO | 0.0129 | 0.0051 | 0.6461 |
| NSGA-Ⅱ | 0.0310 | 0.0041 | 0.6307 |
| IAMOPSO | 0.0083 | 0.0047 | 0.6527 |
| 算法 | GD | SP | HV |
|---|---|---|---|
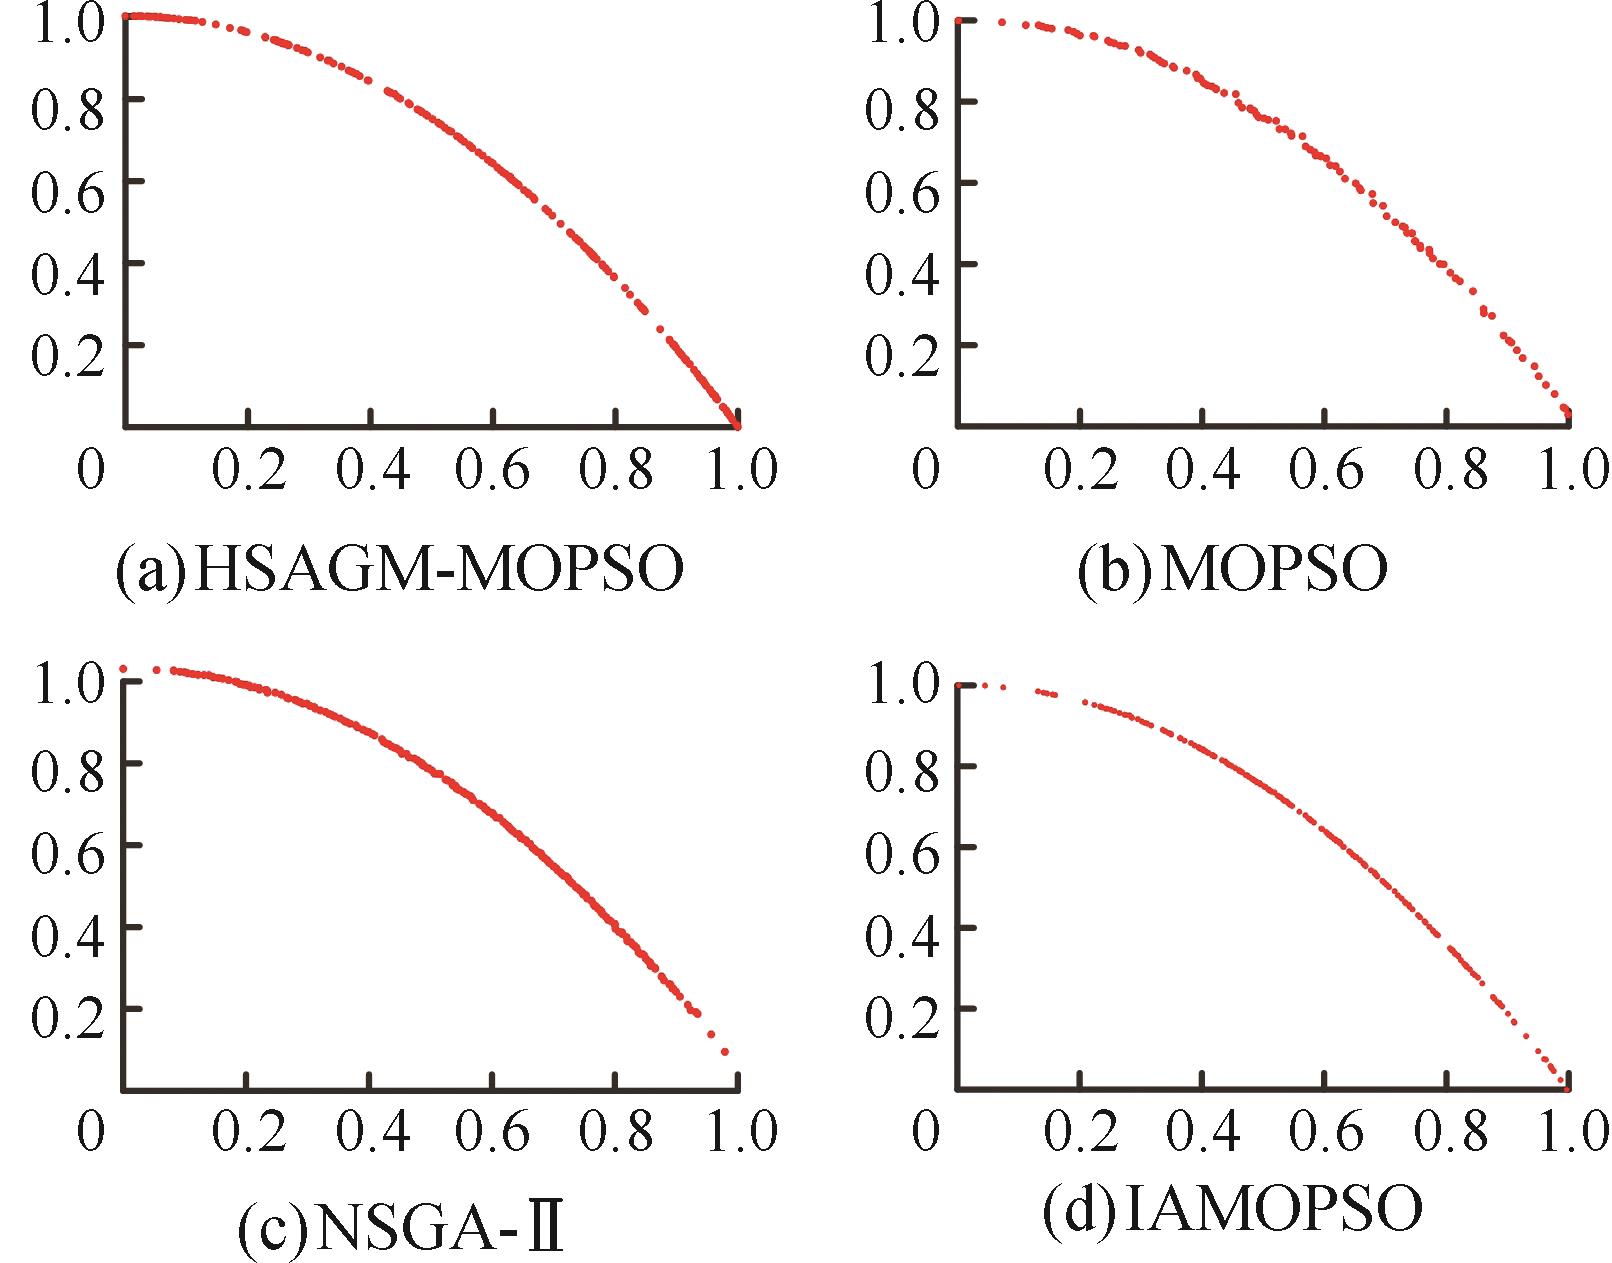
| HSAGM-MOPSO | 0.0046 | 0.0043 | 0.3269 |
| MOPSO | 0.0068 | 0.0063 | 0.3133 |
| NSGA-Ⅱ | 0.0233 | 0.0061 | 0.2976 |
| IAMOPSO | 0.0054 | 0.0059 | 0.3262 |
Tab.3 Comparison of performance metrics on ZDT2 problems
| 算法 | GD | SP | HV |
|---|---|---|---|
| HSAGM-MOPSO | 0.0046 | 0.0043 | 0.3269 |
| MOPSO | 0.0068 | 0.0063 | 0.3133 |
| NSGA-Ⅱ | 0.0233 | 0.0061 | 0.2976 |
| IAMOPSO | 0.0054 | 0.0059 | 0.3262 |
| 算法 | GD | SP | HV |
|---|---|---|---|
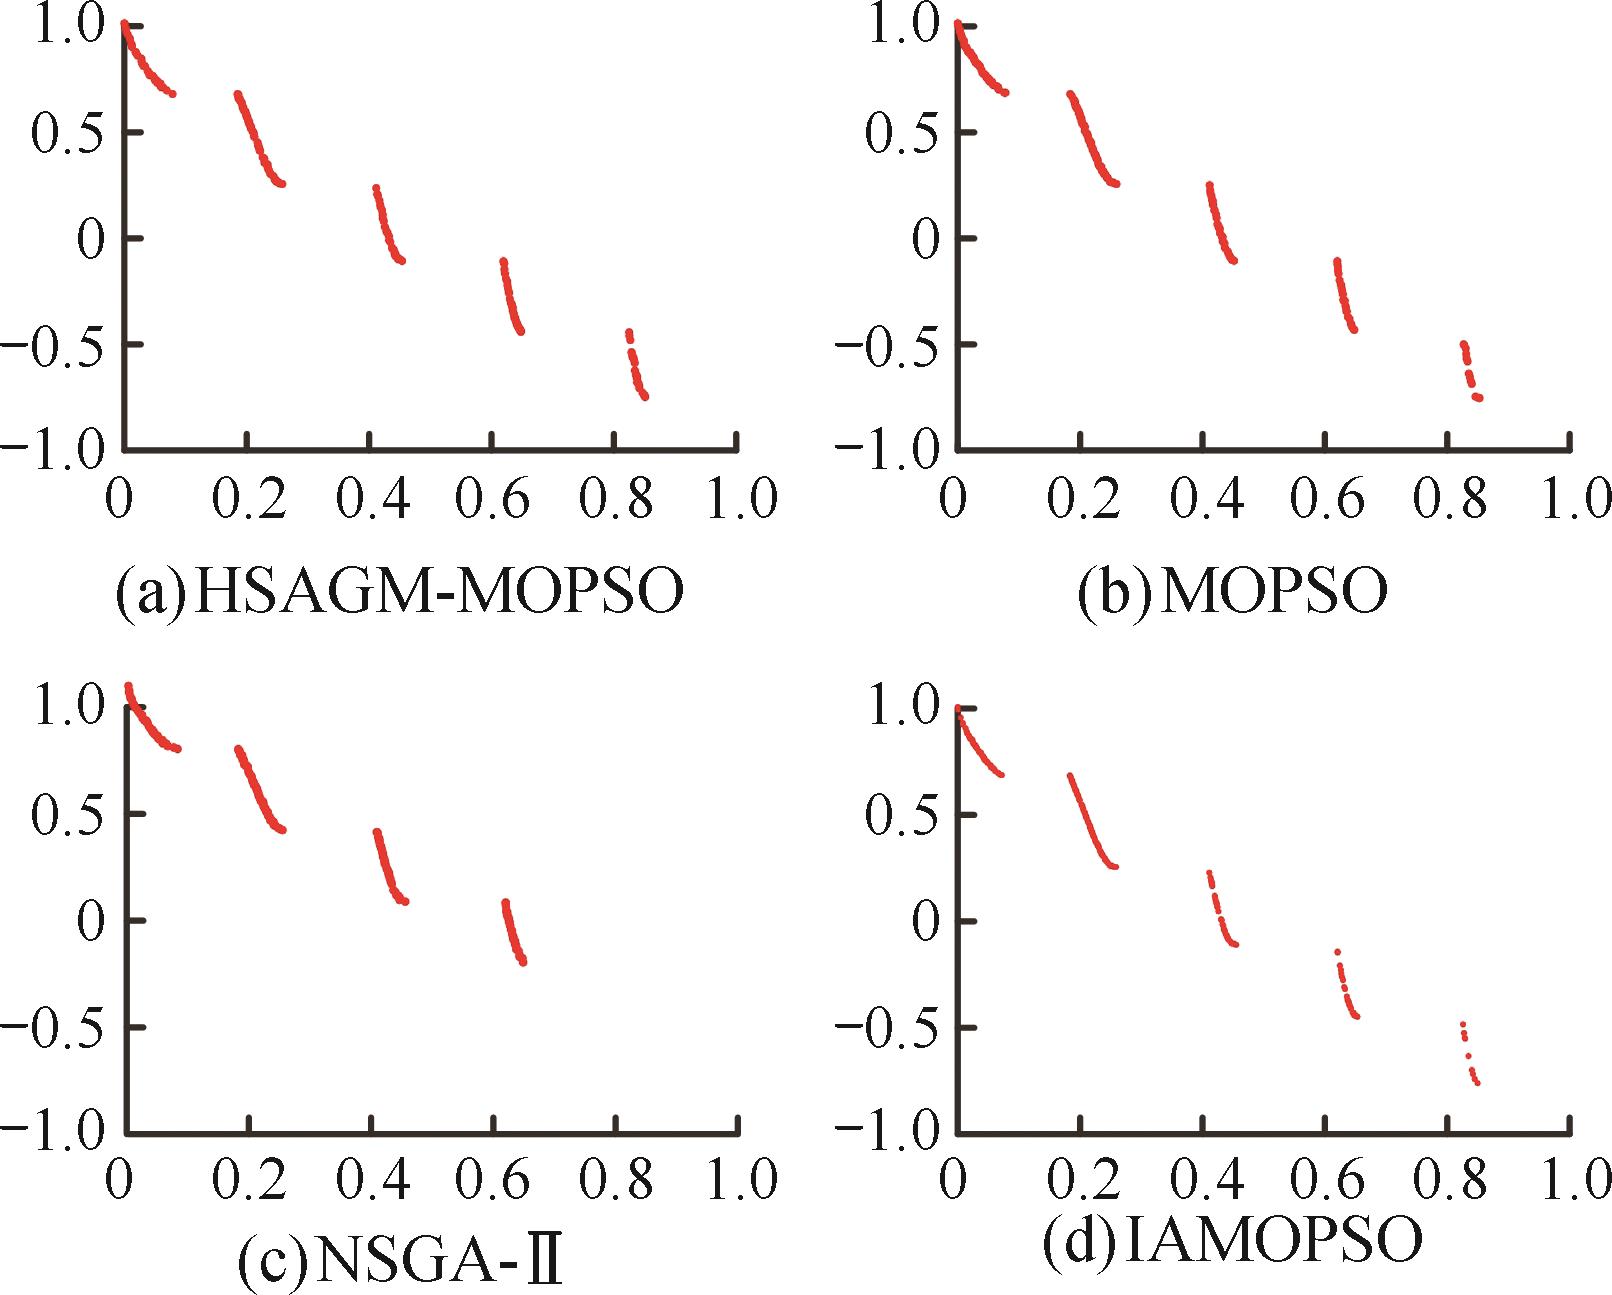
| HSAGM-MOPSO | 0.0106 | 0.0058 | 1.0187 |
| MOPSO | 0.0117 | 0.0071 | 1.0168 |
| NSGA-Ⅱ | 0.0751 | 0.0056 | 0.8987 |
| IAMOPSO | 0.0110 | 0.0069 | 1.0188 |
Tab.4 Comparison of performance metrics on ZDT3 problems
| 算法 | GD | SP | HV |
|---|---|---|---|
| HSAGM-MOPSO | 0.0106 | 0.0058 | 1.0187 |
| MOPSO | 0.0117 | 0.0071 | 1.0168 |
| NSGA-Ⅱ | 0.0751 | 0.0056 | 0.8987 |
| IAMOPSO | 0.0110 | 0.0069 | 1.0188 |
| 算法 | 对接时间/s | 最大加速度/ (mm·s | 最大急动度/ (mm·s |
|---|---|---|---|
| HSAGM-MOPSO | 15.17 | 3.45 | 3.88 |
| MOPSO | 15.42 | 5.10 | 6.79 |
| NSGA-Ⅱ | 19.35 | 3.53 | 3.84 |
| IAMOPSO | 14.52 | 4.51 | 5.79 |
Tab.5 Parameter comparison of docking trajectory
| 算法 | 对接时间/s | 最大加速度/ (mm·s | 最大急动度/ (mm·s |
|---|---|---|---|
| HSAGM-MOPSO | 15.17 | 3.45 | 3.88 |
| MOPSO | 15.42 | 5.10 | 6.79 |
| NSGA-Ⅱ | 19.35 | 3.53 | 3.84 |
| IAMOPSO | 14.52 | 4.51 | 5.79 |
| [1] | 赵欢, 葛东升, 罗来臻, 等. 大型构件自动化柔性对接装配技术综述[J]. 机械工程学报, 2023, 59(14): 277-297. |
| ZHAO Huan, GE Dongsheng, LUO Laizhen, et al. Survey of Automated Flexible Docking Assembly Technology for Large-scale Components[J]. Journal of Mechanical Engineering, 2023, 59(14): 277-297. | |
| [2] | 杜兆才, 邹方. 多机器人协调操作系统实现飞机大型部件对接的轨迹规划[J]. 航空制造技术, 2009, 52(24): 88-91. |
| DU Zhaocai, ZOU Fang. Trajectory Planning of Large Part Merging with a Multi-robot Coordinated Manipulation System[J]. Aeronautical Manufacturing Technology, 2009, 52(24): 88-91. | |
| [3] | 牛启臣, 张弓, 张功学, 等. 多机器人轨迹规划研究综述及发展趋势[J]. 机床与液压, 2021, 49(12): 184-189. |
| NIU Qichen, ZHANG Gong, ZHANG Gongxue, et al. Review and Development Trend of Multi-robot Trajectory Planning[J]. Machine Tool & Hydraulics, 2021, 49(12): 184-189. | |
| [4] | GAO Mingyu, CHEN Da, YANG Yuxiang, et al. A Fixed-distance Planning Algorithm for 6-DOF Manipulators[J]. Industrial Robot, 2015, 42(6): 586-599. |
| [5] | 崔学良, 韩先国, 陈五一. 大尺寸弱刚性构件对接装配系统轨迹规划[J]. 计算机集成制造系统, 2011, 17(5): 908-914. |
| CUI Xueliang, HAN Xianguo, CHEN Wuyi. Trajectory Planning for a Large Scale Weak Rigid Component Docking Assembling System[J]. Computer Integrated Manufacturing Systems, 2011, 17(5): 908-914. | |
| [6] | ZHU Yongguo, HUANG Xiang, FANG Wei, et al. Trajectory Planning Algorithm Based on Quaternion for 6-DOF Aircraft Wing Automatic Position and Pose Adjustment Method[J]. Chinese Journal of Aeronautics, 2010, 23(6): 707-714. |
| [7] | JAHANPOUR J, MOTALLEBI M, PORGHOVEH M. A Novel Trajectory Planning Scheme for Parallel Machining Robots Enhanced with NURBS Curves[J]. Journal of Intelligent & Robotic Systems, 2016, 82(2): 257-275. |
| [8] | 荣誉, 陈刚, 豆天赐. 一种多指标综合最优的抗冲击轨迹规划方法[J]. 中国机械工程, 2024, 35(2): 305-316. |
| RONG Yu, CHEN Gang, DOU Tianci. A Multi Index Comprehensive Optimal Anti Impact Trajectory Planning Method[J]. China Mechanical Engineering, 2024, 35(2): 305-316. | |
| [9] | CAO Xiaoman, YAN Hansheng, HUANG Zhengyan, et al. A Multi-objective Particle Swarm Optimization for Trajectory Planning of Fruit Picking Manipulator[J]. Agronomy, 2021, 11(11): 2286. |
| [10] | 訾斌, 徐锋, 唐锴, 等. 基于机器视觉的喷涂机器人轨迹规划与涂装质量检测研究综述[J]. 控制与决策, 2023, 38(1): 1-21. |
| ZI Bin, XU Feng, TANG Kai, et al. Trajectory Planning for Spray-painting Robot and Quality Detection of Paint Film Based on Machine Vision: a Review[J]. Control and Decision, 2023, 38(1): 1-21. | |
| [11] | 王伟, 徐泽铨. 基于多目标约束的机器人复杂轨迹优化方法[J]. 农业机械学报, 2023, 54(11): 431-439. |
| WANG Wei, XU Zequan. Multi-objectives Optimization-based Method for Complex Trajectory Planning of Manipulators[J]. Transactions of the Chinese Society for Agricultural Machinery, 2023, 54(11): 431-439. | |
| [12] | 王科峰, 张彦斌, 黄建伟. 基于改进NSGA-Ⅱ算法的机械臂多目标轨迹规划[J]. 中国工程机械学报, 2023, 21(3): 215-220. |
| WANG Kefeng, ZHANG Yanbin, HUANG Jianwei. Multi-objective Trajectory Planning of Manipulator Based on Improved NSGA-Ⅱ Algorithm[J]. Chinese Journal of Construction Machinery, 2023, 21(3): 215-220. | |
| [13] | LI Shuanggao, CHU Wenmin, HUANG Xiang, et al. Trajectory Planning Method for Docking of Large Aircraft Components[J]. Robotic Intelligence and Automation, 2023, 43(3): 235-253. |
| [14] | 刘建林, 黄海松, 范青松, 等. 基于改进樽海鞘群算法的机械臂多目标轨迹规划研究[J]. 中国机械工程, 2025, 36(9): 2047-2056. |
| LIU Jianlin, HUANG Haisong, FAN Qingsong, et al. Multi-objective Trajectory Planning of Manipulators Based on Improved SSA[J]. China Mechanical Engineering, 2025, 36(9): 2047-2056. | |
| [15] | 金光, 李若琪, 郑强仁. 基于改进MOPSO和多目标的SCARA并联机器人的食品分拣轨迹优化[J]. 食品与机械, 2025, 41(8): 85-92. |
| JIN Guang, LI Ruoqi, ZHENG Qiangren. Trajectory Optimization for Food Sorting Based on Improved MOPSO and Multi-objective SCARA Parallel Robots[J]. Food and Machinery, 2025, 41(8): 85-92. | |
| [16] | LIU Cheng, CAO Guohua, QU Yongyin, et al. An Improved PSO Algorithm for Time-optimal Trajectory Planning of Delta Robot in Intelligent Packaging[J]. The International Journal of Advanced Manufacturing Technology, 2020, 107(3): 1091-1099. |
| [17] | 陶治同, 陶建峰, 覃程锦, 等. 基于时间冲击最优的TBM换刀机器人轨迹规划[J]. 浙江大学学报(工学版), 2023, 57(1): 1-9. |
| TAO Zhitong, TAO Jianfeng, QIN Chengjin, et al. Trajectory Planning of TBM Disc Cutter Changing Robot Based on Time-jerk Optimization[J]. Journal of Zhejiang University (Engineering Science), 2023, 57(1): 1-9. | |
| [18] | 王桂荣, 倪志强, 周坤, 等. 多策略改进粒子群算法的机械臂时间最优轨迹规划[J]. 中国机械工程, 2025, 36(5): 1044-1053. |
| WANG Guirong, NI Zhiqiang, ZHOU Kun, et al. Time-optimal Trajectory Planning of Robotic Arms Based on MIPSO Algorithm[J]. China Mechanical Engineering, 2025, 36(5): 1044-1053. | |
| [19] | 武星, 杨俊杰, 汤凯, 等. 面向复合地图的移动机器人分层路径规划[J]. 中国机械工程, 2023, 34(5): 563-575. |
| WU Xing, YANG Junjie, TANG Kai, et al. Hierarchical Path Planning for Mobile Robots Based on Hybrid Map[J]. China Mechanical Engineering, 2023, 34(5): 563-575. | |
| [20] | 李黎, 尚俊云, 冯艳丽, 等. 关节型工业机器人轨迹规划研究综述[J]. 计算机工程与应用, 2018, 54(5): 36-50. |
| LI Li, SHANG Junyun, FENG Yanli, et al. Research of Trajectory Planning for Articulated Industrial Robot: a Review[J]. Computer Engineering and Applications, 2018, 54(5): 36-50. | |
| [21] | 龙樟, 李显涛, 帅涛, 等. 工业机器人轨迹规划研究现状综述[J]. 机械科学与技术, 2021, 40(6): 853-862. |
| LONG Zhang, LI Xiantao, SHUAI Tao, et al. Review of Research State of Trajectory Planning for Industrial Robots[J]. Mechanical Science and Technology for Aerospace Engineering, 2021, 40(6): 853-862. | |
| [22] | 周辰昊, 刘中华, 吴新烨. 基于5阶B样条的避障泊车路径规划[J]. 厦门大学学报(自然科学版), 2024, 63(4): 670-678. |
| ZHOU Chenhao, LIU Zhonghua, WU Xinye. Obstacle Avoidance Parking Path Planning Based on 5th Order B-spline[J]. Journal of Xiamen University (Natural Science), 2024, 63(4): 670-678. | |
| [23] | de BOOR C. On Calculating with B-splines[J]. Journal of Approximation Theory, 1972, 6(1): 50-62. |
| [24] | COX M G. The Numerical Evaluation of B-Splines[J]. IMA Journal of Applied Mathematics, 1972, 10(2): 134-149. |
| [25] | 陈栋. 舱段对接并联机构的轨迹规划及运动控制技术[D]. 武汉: 华中科技大学, 2020. |
| CHEN Dong. Trajectory Planning and Motion Control Technology of Cabin Docking Parallel Mechanism[D]. Wuhan: Huazhong University of Science and Technology, 2020. | |
| [26] | 左国玉, 李宓, 郑榜贵. 基于改进自适应多目标粒子群算法的机械臂最优轨迹规划方法[J]. 实验技术与管理, 2024, 41(3): 184-191. |
| ZUO Guoyu, LI Mi, ZHENG Banggui. Optimal Trajectory Planning for Robotic Arms Based on an Improved Adaptive Multiobjective Particle Swarm Algorithm[J]. Experimental Technology and Management, 2024, 41(3): 184-191. | |
| [27] | 党旭, 刘涛, 闫敏, 等. 变截面涡旋盘精密铣削参数多目标优化[J]. 中国机械工程, 2025, 36(12): 2854-2861. |
| DANG Xu, LIU Tao, YAN Min, et al. Multi-objective Optimization of Precision Milling Parameters for Variable Cross-section Scrolls[J]. China Mechanical Engineering, 2025, 36(12): 2854-2861. |
| [1] |
LI Meng-Lei, GU Yo-Qin, ZHANG Hua-Liang, LIU Li-Qin, DU Juan, WEN Chu-Hua, LAN Guo-Sheng.
Parallel Mechanism Structure Optimization Design Based on Multi-objective Differential Evolution Algorithm
[J]. J4, 201016, 21(16): 1915-1920.
|
| [2] | PAN Zhirong, SUN Hao, YAO Bin, CAI Zhiqin, LAN Qixin, ZHANG Jinhui. Prediction of Cutting Forces and Processing Parameter Optimization in C60 Minimum Quantity Lubrication Milling of GH4169 [J]. China Mechanical Engineering, 2026, 37(7): 1562-1571. |
| [3] | WANG Cong, WEI Lixin, SUN Hao, HU Ziyu, CUI Huihui. Dynamic Flexible Job Shop Scheduling Problem Considering Transportation Resource Constraints and Adaptive Competitive Reconfiguration Algorithm [J]. China Mechanical Engineering, 2026, 37(7): 1708-1716. |
| [4] | LIU She, LI Jiaxin, TIAN Zhiqiang, ZHANG Shiman. Fuzzy Flexible Job-shop Scheduling Optimization Approach Considering Customer Satisfaction [J]. China Mechanical Engineering, 2026, 37(7): 1734-1745. |
| [5] | LIU Jinfeng, GU Shimin, ZHANG Zhanhu, LI Su, CHEN Yu, WANG Xuemin, QIAN Tianlong. Trajectory Optimization Method for Portable Robots in Confined Spaces Based on Multi-objective Constraints [J]. China Mechanical Engineering, 2026, 37(6): 1508-1517. |
| [6] | LI Huan, GAO Zhenze, ZENG Caiyou, WANG Leilei, LI Yinyin, ZENG Yun. Trajectory Planning and Verification for Wire Arc Additive Manufacturing of 316L Stainless Steels [J]. China Mechanical Engineering, 2026, 37(6): 1318-1324. |
| [7] | FU Haocheng, WU Shaowei, JIANG Chao. Radiation Shielding Structure Multi-objective Optimization of Imagine Sensors Based on Monte-Carlo Variance Reduction Method [J]. China Mechanical Engineering, 2026, 37(5): 1045-1053. |
| [8] | WANG Bingxu, GAO Tong, WAN Min, JIAO Longfei, YU Fei, ZHANG Weihong. Analysis for Influences of Joints on Dynamic Characteristics of Precision Machine Tools [J]. China Mechanical Engineering, 2026, 37(5): 1111-1121. |
| [9] | CAO Weidong, WANG Yuanshuo, LI Minrong, CHEN Fuqi, CHEN Xingzheng, WU Dianjian, HU Kexin. Hyper-heuristic Optimization and Decision-making of Hobs and Control Parameters [J]. China Mechanical Engineering, 2026, 37(4): 846-854. |
| [10] | ZHANG Lei, ZHANG Zhen, LIU Runze. A Low-carbon Process Optimization Method for Parts Driven by Intelligent Parsing of Manufacturing Features [J]. China Mechanical Engineering, 2026, 37(4): 929-938. |
| [11] | YANG Jie, JIANG Zhigang, ZHU Shuo, CHEN Xin, ZHANG Hua. Research Progresses on Reliability Design of Remanufactured Electromechanical Products with Multi-life Characteristics across Whole Working Ranges [J]. China Mechanical Engineering, 2026, 37(4): 987-998. |
| [12] | ZHAO Dingxuan, GUO Rui, WANG Shuo, YAN Changchang, WANG Zihe, ZHANG Tianci. Body Posture Planning Method for Unmanned Walking Excavators under Complex Terrain Environments [J]. China Mechanical Engineering, 2026, 37(1): 233-242. |
| [13] | DANG Xu, LIU Tao, YAN Min, XU Zhiwei. Multi-objective Optimization of Precision Milling Parameters for Variable Cross-section Scrolls [J]. China Mechanical Engineering, 2025, 36(12): 2854-2861. |
| [14] | Huifang KONG, Chenshun WANG, Qian ZHANG, Tiankuo LIU. Intelligent Vehicle Trajectory Planning Based on Spatio-temporal Risk Fields [J]. China Mechanical Engineering, 2025, 36(10): 2463-2471. |
| [15] | Jianlin LIU, Haisong HUANG, Qingsong FAN, Chi MA, Langlang ZHANG. Multi-objective Trajectory Planning of Manipulators Based on Improved SSA [J]. China Mechanical Engineering, 2025, 36(09): 2047-2056. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||