China Mechanical Engineering ›› 2026, Vol. 37 ›› Issue (9): 2185-2193.DOI: 10.3969/j.issn.1004-132X.2026.09.011
ZHU Jiayi1(
), GAO Jie1(
), GAO Liang2, CAO Huai2
Received:2025-04-11
Online:2026-09-25
Published:2026-10-21
Contact:
GAO Jie
通讯作者:
高杰
作者简介:朱佳怡,女,2000 年生,博士研究生。研究方向为拓扑优化。 E-mail:zhujiayi@hust.edu.cn基金资助:CLC Number:
ZHU Jiayi, GAO Jie, GAO Liang, CAO Huai. Topology Optimization for Lightweight Design of Mechanical Legs of Hydraulic Bipedal Robots[J]. China Mechanical Engineering, 2026, 37(9): 2185-2193.
朱佳怡, 高杰, 高亮, 曹淮. 轻量化液压双足机器人机械腿拓扑优化设计[J]. 中国机械工程, 2026, 37(9): 2185-2193.
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.cmemo.org.cn/EN/10.3969/j.issn.1004-132X.2026.09.011
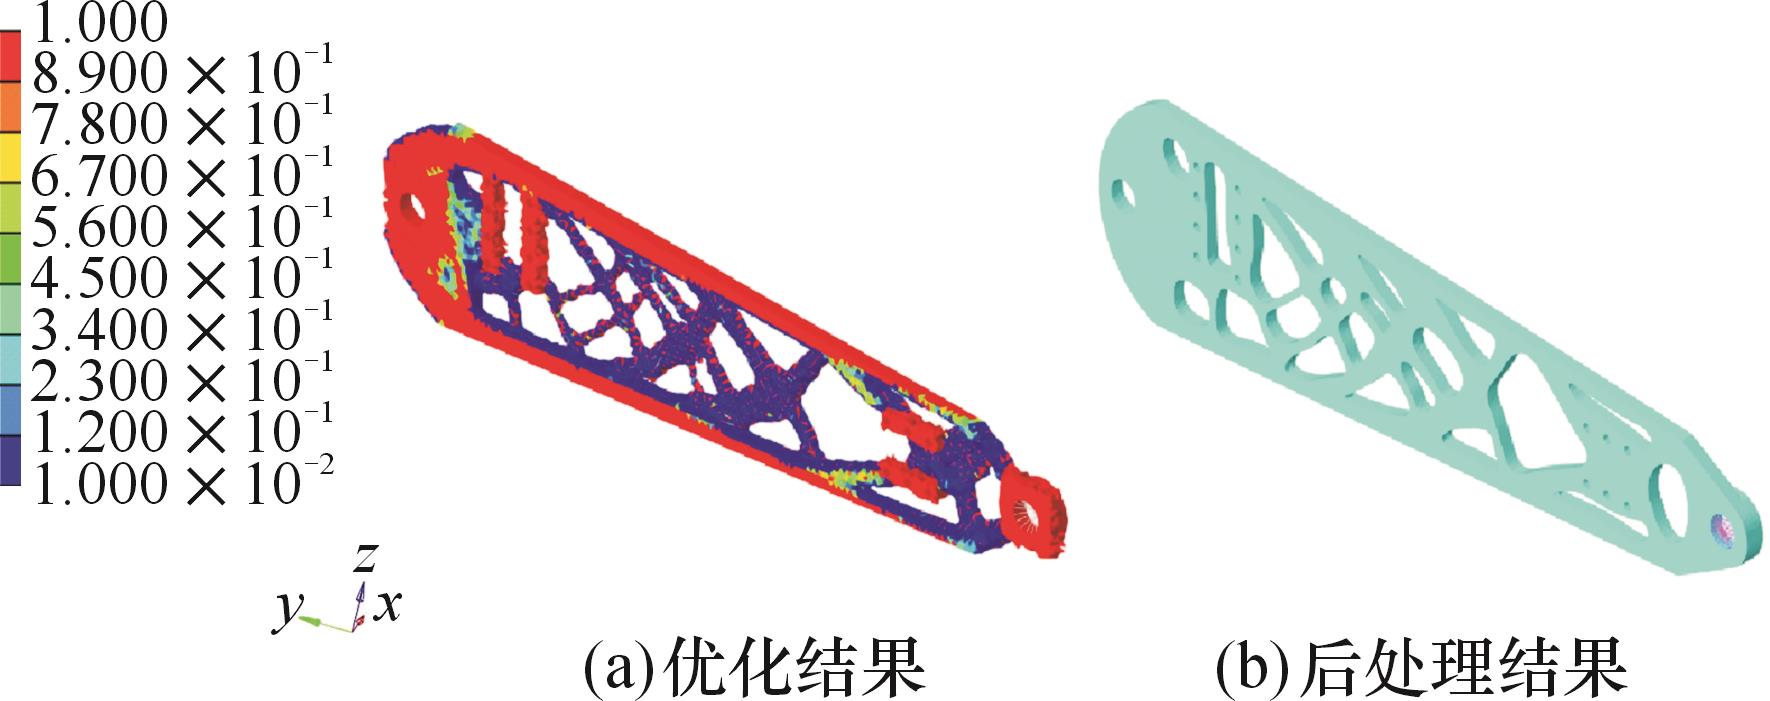
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 566.8 | 48.58 |
| 设定分布力的工况情况下位移变形量/mm | 1.188 | 1.035 | 12.88 |
| 设定分布力及力矩合力的工况下位移变形量/mm | 2.337 | 2.171 | 7.11 |
Tab.1 Comparison of topology optimization results of robot legs in scheme 1
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 566.8 | 48.58 |
| 设定分布力的工况情况下位移变形量/mm | 1.188 | 1.035 | 12.88 |
| 设定分布力及力矩合力的工况下位移变形量/mm | 2.337 | 2.171 | 7.11 |
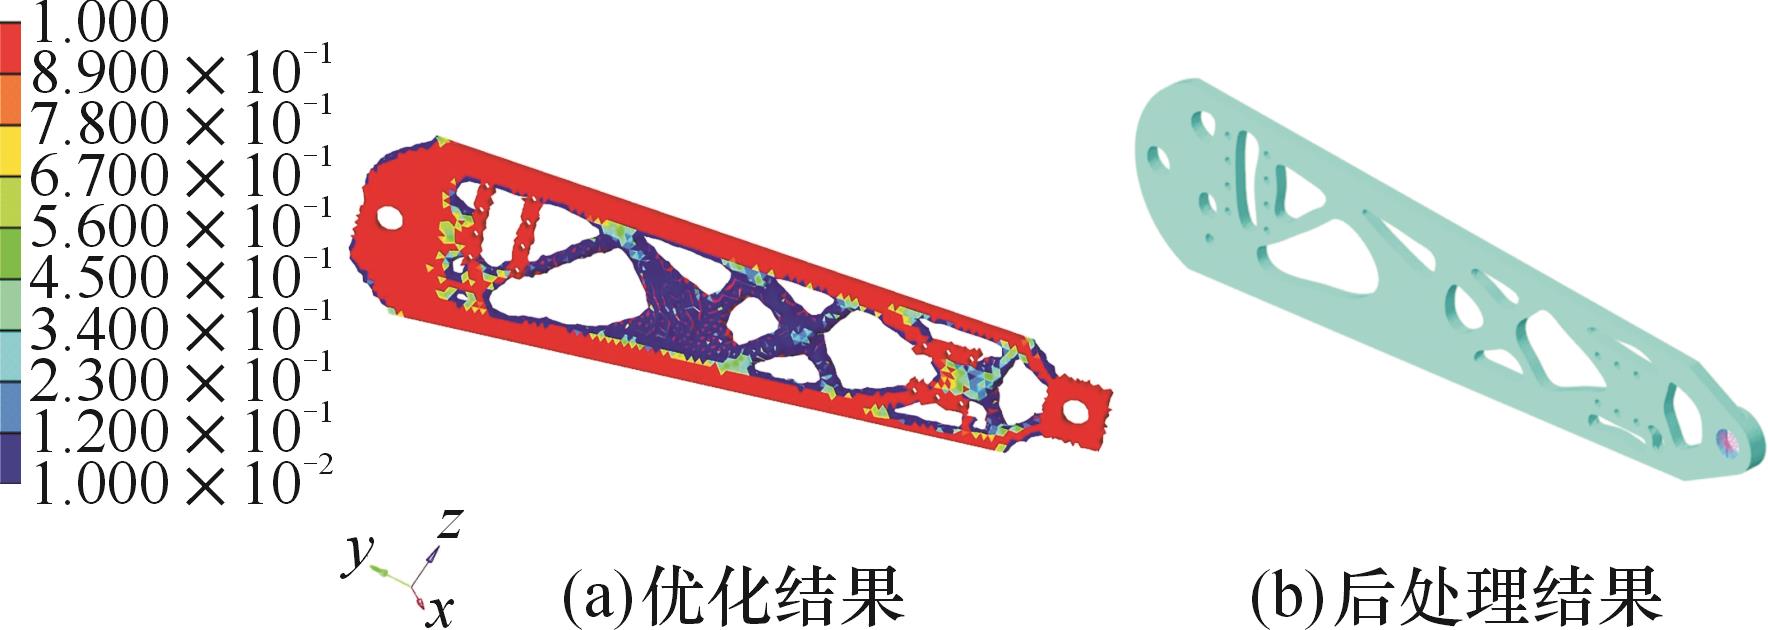
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 607.9 | 44.85 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 1.017 | 14.4 |
设定分布力及力矩合力的工况下位移变 形量/mm | 2.337 | 2.034 | 12.97 |
Tab.2 Comparison of topology optimization results of robot legs in scheme 2
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 607.9 | 44.85 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 1.017 | 14.4 |
设定分布力及力矩合力的工况下位移变 形量/mm | 2.337 | 2.034 | 12.97 |
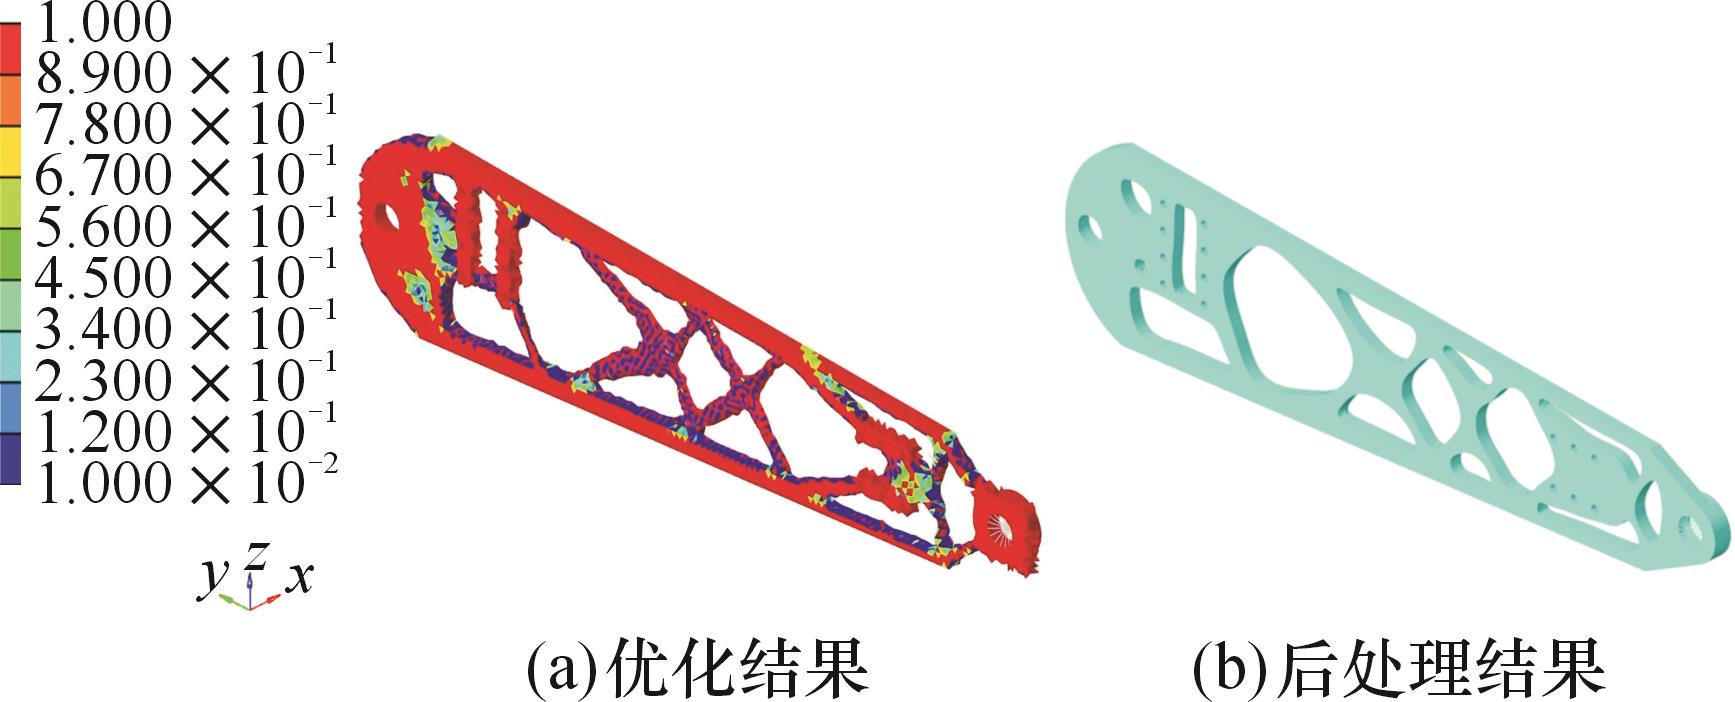
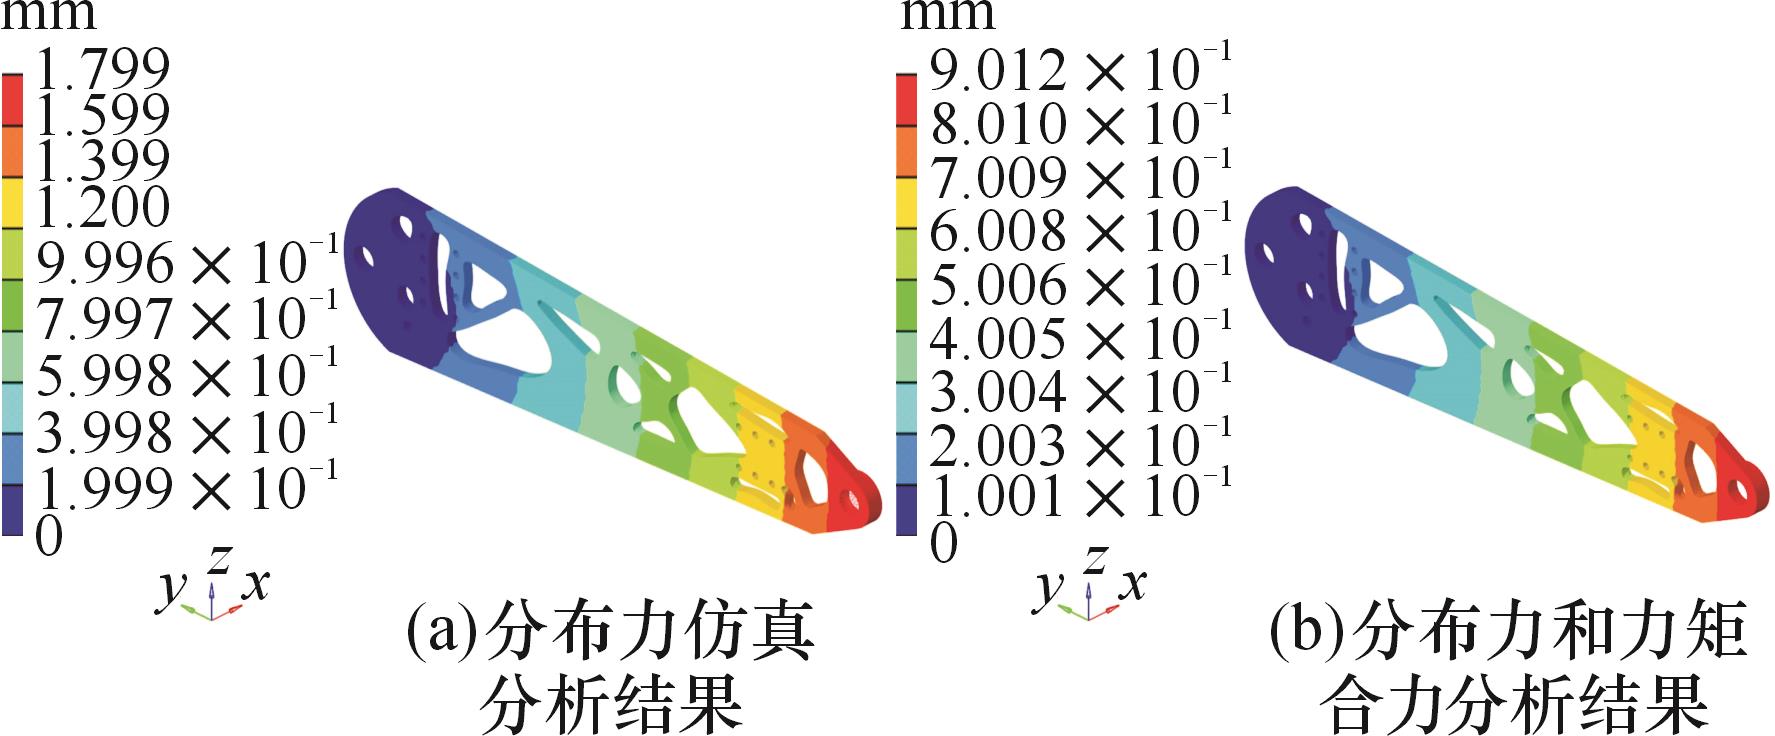
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
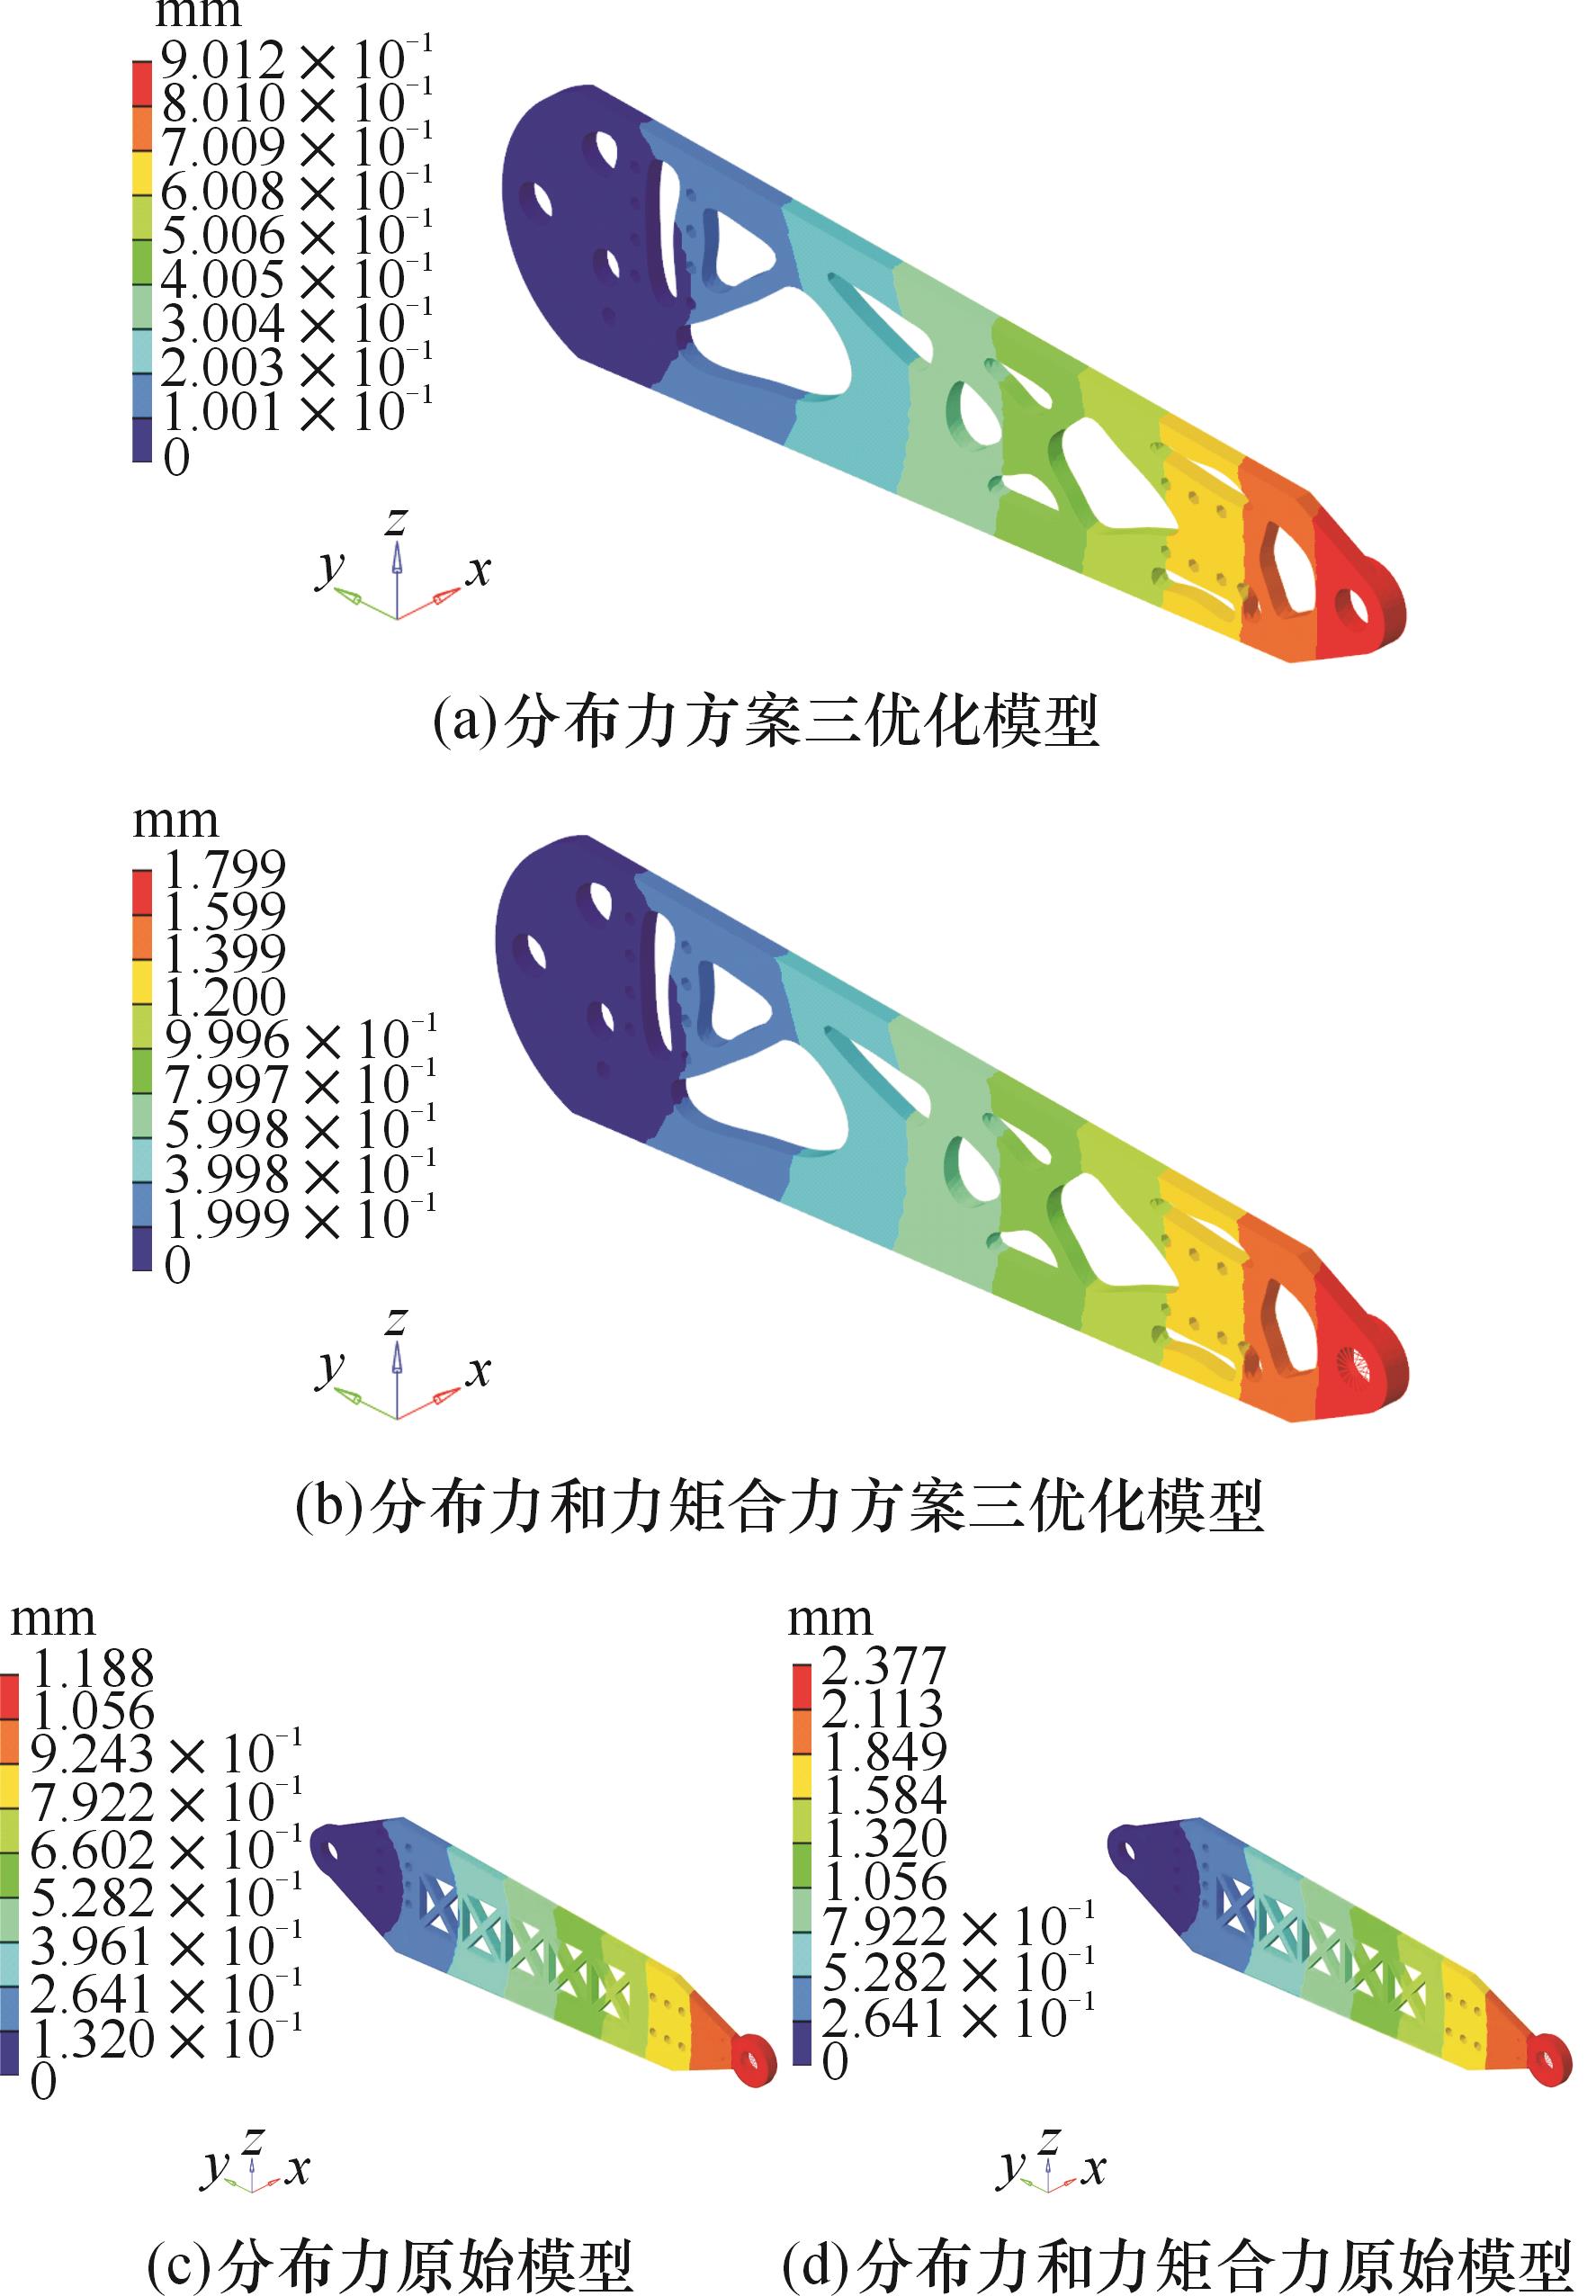
| 质量/g | 1102.2 | 678.4 | 38.45 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 0.9012 | 23.02 |
| 设定分布力及力矩合力的工况下位移变形量/mm | 2.337 | 1.799 | 24.14 |
Tab.3 Comparison of topology optimization results of robot legs in scheme 3
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 678.4 | 38.45 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 0.9012 | 23.02 |
| 设定分布力及力矩合力的工况下位移变形量/mm | 2.337 | 1.799 | 24.14 |
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 533 | 51.64 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 1.103 | 7.15 |
设定分布力及力矩合力的工况下位移变 形量/mm | 2.337 | 2.206 | 5.61 |
Tab.4 Comparison of topology optimization results of robot legs in scheme 4
| 参数 | 初始结构 | 优化结构 | 优化比重/% |
|---|---|---|---|
| 质量/g | 1102.2 | 533 | 51.64 |
| 设定分布力的工况下位移变形量/mm | 1.188 | 1.103 | 7.15 |
设定分布力及力矩合力的工况下位移变 形量/mm | 2.337 | 2.206 | 5.61 |
| 阶数 | 原始设计 | 方案三 |
|---|---|---|
| 一阶 | 3.103 10×10-2 | 3.259 70×10-2 |
| 二阶 | 0.169 14 | 0.191 54 |
| 三阶 | 0.242 25 | 0.284 98 |
| 四阶 | 0.266 28 | 0.300 92 |
| 五阶 | 0.450 64 | 0.527 40 |
| 六阶 | 0.710 55 | 0.756 10 |
| 七阶 | 0.864 98 | 0.958 02 |
| 八阶 | 1.2801 | 1.2923 |
| 九阶 | 1.3956 | 1.4811 |
| 十阶 | 1.5418 | 1.7636 |
Tab. 5 Comparison of the tenth-order frequency data between scheme 3 and the original design results
| 阶数 | 原始设计 | 方案三 |
|---|---|---|
| 一阶 | 3.103 10×10-2 | 3.259 70×10-2 |
| 二阶 | 0.169 14 | 0.191 54 |
| 三阶 | 0.242 25 | 0.284 98 |
| 四阶 | 0.266 28 | 0.300 92 |
| 五阶 | 0.450 64 | 0.527 40 |
| 六阶 | 0.710 55 | 0.756 10 |
| 七阶 | 0.864 98 | 0.958 02 |
| 八阶 | 1.2801 | 1.2923 |
| 九阶 | 1.3956 | 1.4811 |
| 十阶 | 1.5418 | 1.7636 |
| [1] | 陈阳, 王洪玺, 张兰勇. 轮腿式平衡机器人控制[J]. 信息与控制, 2023, 52(5): 648-659. |
| CHEN Yang, WANG Hongxi, ZHANG Lanyong. Control of Wheel-legged Balancing Robot[J]. Information and Control, 2023, 52(5): 648-659. | |
| [2] | 王田苗, 陶永, 陈阳. 服务机器人技术研究现状与发展趋势[J]. 中国科学: 信息科学, 2012, 42(9): 1049-1066. |
| WANG Tianmiao, TAO Yong, CHEN Yang. Research Status and Development Trends of the Service Robotic Technology[J]. Scientia Sinica (Informationis), 2012, 42(9): 1049-1066. | |
| [3] | 刘松, 柴汇, 李贻斌, 等. 电动力液压驱动四足双臂机器人的设计与实现[J]. 机器人, 2022, 44(6): 649-659. |
| LIU Song, CHAI Hui, LI Yibin, et al. Design and Implementation of an Electro-hydraulic Quadruped Robot with Dual-arm[J]. Robot, 2022, 44(6): 649-659. | |
| [4] | OH H J, KIM K D, CHUNG H S, et al. Evolution of Humanoid Robots: Technological Milestones and Future Challenges[J]. Electronics and Telecommunications Trends, 2025, 40(3): 82-92. |
| [5] | TSAGARAKIS N G, CALDWELL D G, NEGRELLO F, et al. WALK-MAN: a High-performance Humanoid Platform for Realistic Environments[J]. Journal of Field Robotics, 2017, 34(7): 1225-1259. |
| [6] | ZHOU Chengxu, TSAGARAKIS N. On the Comprehensive Kinematics Analysis of a Humanoid Parallel Ankle Mechanism[J]. Journal of Mechanisms and Robotics, 2018, 10(5): 051015. |
| [7] | MIKOLAJCZYK T, MIKOŁAJEWSKA E, AL-SHUKA H F N, et al. Recent Advances in Bipedal Walking Robots: Review of Gait, Drive, Sensors and Control Systems[J]. Sensors, 2022, 22(12): 4440. |
| [8] | REHER J, COUSINEAU E A, HEREID A, et al. Realizing Dynamic and Efficient Bipedal Locomotion on the Humanoid Robot DURUS[C]∥2016 IEEE International Conference on Robotics and Automation (ICRA). Stockholm, 2016: 1794-1801. |
| [9] | 钟浩然. 基于液压串联弹性驱动器的双足机器人运动控制方法[D]. 武汉: 华中科技大学, 2021. |
| ZHONG Haoran. Bipedal Robot Motion Control Based on Hydraulic Series Elastic Actuator[D]. Wuhan: Huazhong University of Science and Technology, 2021. | |
| [10] | GIM K G, KIM J, YAMANE K. Design and Fabrication of a Bipedal Robot Using Serial-parallel Hybrid Leg Mechanism[C]∥2018 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Madrid, 2019: 5095-5100. |
| [11] | 蔡润铭, 张爱民, 周仁义. 双轮足机器人运动模式切换规划算法与仿真[J]. 机床与液压, 2024, 52(23): 26-31. |
| CAI Runming, ZHANG Aimin, ZHOU Renyi. Planning Algorithm and Simulation of Locomotion Mode Switching with a Biped Wheel-legged Robot[J]. Machine Tool & Hydraulics, 2024, 52(23): 26-31. | |
| [12] | 潘露, 张恒华, 刘桐, 等. 仿人机器人小腿的拓扑优化和激光增材制造[J]. 应用激光, 2023, 43(2): 47-55. |
| PAN Lu, ZHANG Henghua, LIU Tong, et al. Topological Optimization and Laser Additive Manufacturing of the Humanoid Robot Calf[J]. Applied Laser, 2023, 43(2): 47-55. | |
| [13] | LIU Bin, SHA Liansen, HUANG Kun, et al. A Topology Optimization Method for Collaborative Robot Lightweight Design Based on Orthogonal Experiment and Its Applications[J]. International Journal of Advanced Robotic Systems, 2022, 19: 17298814211056143. |
| [14] | ZHU Jiayi, XU Jie, ZHOU Xiaoqiang, et al. Principal Stress Lines (PSLS)-guided Discrete Topology Designs for Self-similar Porous Infills in Shell Structures with Fractal Geometry[J]. Thin-Walled Structures, 2025, 210: 112915. |
| [15] | ZHANG Xiao, GAO Liang, XIAO Mi, et al. T-splines-based Panel Method for Aerodynamic Topology Optimization of Engineering Shell Structures Using Isogeometric Analysis[J]. Computer Methods in Applied Mechanics and Engineering, 2025, 444: 118154. |
| [16] | 祝海林, 周扬驰, 何宜玖, 等. 外骨骼机器人膝部三铰点零件轻量化研究[J]. 常州大学学报(自然科学版), 2023, 35(3): 71-77. |
| ZHU Hailin, ZHOU Yangchi, HE Yijiu, et al. Research on Lightweight of Three Hinge Parts of Exoskeleton Robot Knee[J]. Journal of Changzhou University (Natural Science Edition), 2023, 35(3): 71-77. | |
| [17] | 莫彦彬, 单科臻, 陈肖媛. 下肢外骨骼机器人大腿护板轻量化设计[J]. 机械研究与应用, 2024, 37(6): 60-62. |
| MO Yanbin, SHAN Kezhen, CHEN Xiaoyuan. Lightweight Design of Thigh Guard for Lower Limb Exoskeleton Robot[J]. Mechanical Research & Application, 2024, 37(6): 60-62. | |
| [18] | 董昊臻. 双足机器人步态仿真及腿部设计与控制研究[D]. 武汉: 华中科技大学, 2021. |
| DONG Haozhen. Research on Gait Simulation with Design and Control of Leg for Biped Robot[D]. Wuhan: Huazhong University of Science and Technology, 2021. | |
| [19] | 许文琼, 杨芳艳, 李清都. 基于角动量的双足机器人稳定行走规划[J]. 电子科技, 2025, 38(8): 87-93. |
| XU Wenqiong, YANG Fangyan, LI Qingdu. Research on Stable Walking Planning of Biped Robot Based on Angular Momentum[J]. Electronic Science and Technology, 2025, 38(8): 87-93. | |
| [20] | 张彦凯, 王雪松, 金雨斌, 等. 基于虚拟样机的双足机器人多目标步态规划研究[J]. 系统仿真学报, 2024, 36(12): 2984-2992. |
| ZHANG Yankai, WANG Xuesong, JIN Yubin, et al. Research on Multi-objective Gait Planning of Biped Robot Based on Virtual Prototype[J]. Journal of System Simulation, 2024, 36(12): 2984-2992. | |
| [21] | 郭凯. 模型预测控制下四足机器人的地形适应性优化[J]. 建模与仿真, 2024, 13(6): 6537-6551. |
| GUO Kai. Optimization of Terrain Adaptability for Quadruped Robots under Model Predictive Control[J]. Modeling and Simulation, 2024, 13(6): 6537-6551. | |
| [22] | XU Zhen, XIE Jianan, HASHIMOTO K, et al. Human-inspired Gait and Jumping Motion Generation for Bipedal Robots Using Model Predictive Control[J]. Biomimetics, 2025, 10(1):17. |
| [23] | 王森, 姚燕安, 武建昫. 一种新型可调整闭链多足机器人的设计与分析[J]. 机械工程学报, 2020, 56(19): 191-199. |
| WANG Sen, YAO Yan’an, WU Jianxu. Design and Analysis of a Novel Adjustable Closed-chain Multi-legged Robot[J]. Journal of Mechanical Engineering, 2020, 56(19): 191-199. | |
| [24] | 高惟鹰. 面向高机敏双足机器人的腿部设计与柔顺控制研究[D]. 重庆: 重庆邮电大学, 2020. |
| GAO Weiying. Research on Leg Design and Compliance Control for Highly Sensitive Biped Robots[D]. Chongqing: Chongqing University of Posts and Telecommunications, 2020. | |
| [25] | 石照耀, 丁宏钰, 汪文广, 等. 双足机器人腿部新构型设计与试验研究[J]. 机械工程学报, 2023, 59(1): 103-112. |
| SHI Zhaoyao, DING Hongyu, WANG Wenguang, et al. Design and Experimental Research on the Novel Leg Configuration of Bipedal Robot[J]. Journal of Mechanical Engineering, 2023, 59(1): 103-112. | |
| [26] | CHENG Feiteng, ZHAO Qinghai, MAO Zibin, et al. Mechanical Response of Gradient Lattice Structures Based on Topology Optimization[J]. Advanced Engineering Materials, 2024, 26(8): 2301887. |
| [27] | LIN Daji, GAO Liang, GAO Jie. The Lagrangian-Eulerian Described Particle Flow Topology Optimization (PFTO) Approach with Isogeometric Material Point Method[J]. Computer Methods in Applied Mechanics and Engineering, 2025, 440: 117892. |
| [28] | ZHANG Xiao, XIAO Mi, GAO Liang, et al. A T-splines-oriented Isogeometric Topology Optimization for Plate and Shell Structures with Arbitrary Geometries Using Bézier Extraction[J]. Computer Methods in Applied Mechanics and Engineering, 2024, 425: 116929. |
| [1] | YANG Haoqin, SHAN Zhongde, YAN Dandan, WU Runmou, KONG Xianghao. Study on Mechanics Properties of Lightweight Ceramic Core Structure Made of Photopolymerization for Aeroengine Turbine Blades [J]. China Mechanical Engineering, 2026, 37(6): 1353-1361. |
| [2] | LI Yunlong, ZHANG Dahai, LU Fangzhou, LI Yanjie, XU Peifei, FEI Qingguo. An Enhancement Method for Induction Heating Efficiency Based on Ferrite Magnetic Circuit Optimization [J]. China Mechanical Engineering, 2026, 37(5): 1141-1149. |
| [3] | WANG Hao, LUO Haodong, SHI Yazhong, WANG Liwen, ZHANG Wei, WANG Zhong. A Topology Optimization Method Based on End-to-end Deep Learning Framework TOPO-U-Net [J]. China Mechanical Engineering, 2026, 37(1): 174-183. |
| [4] | HE Kun, ZHOU Hechao, ZHANG Jimin. Design of Negative Poisson's Ratio Metamaterial Filling Structures for Train Anti-climb Energy Absorbers [J]. China Mechanical Engineering, 2025, 36(12): 3040-3046. |
| [5] | Wuchao CHEN, Xiangdong YU, Kun HE, Jimin ZHANG. Load Carrying Characteristics of Permanent Magnetic Thrust Bearings with Modularized Multi-cellular Elements [J]. China Mechanical Engineering, 2025, 36(10): 2300-2305. |
| [6] | HUANG Hao1, WANG Zeng2, LI Bo2, LU Zehua1, LIU Huaiju1. Structure-thermal Compliance Collaborative Topology Optimization of Aero-engine Gears Transmission Case Based on Compromise Programming Method [J]. China Mechanical Engineering, 2025, 36(07): 1471-1478. |
| [7] | SHANG Xin1, CHEN Yu2. Research on Spindle Structure Design with Stiffness-Strength Constraints [J]. China Mechanical Engineering, 2025, 36(05): 995-1007. |
| [8] | SU Ke1, WANG Ying1, LIANG Tengteng1, WEI Yili2, ZHANG Nannan2. Topology Optimization of Single Material Flexible Mechanisms Based on Informed Tectonics Theory [J]. China Mechanical Engineering, 2025, 36(04): 873-881. |
| [9] | LIN Jiahui, LI Zhuangzhuang, LI Xuelin, LI Jun. A New Method for Path-engulfment Topology Optimization [J]. China Mechanical Engineering, 2025, 36(03): 504-514. |
| [10] | WANG Shuting1, XIE Qingtian1, YANG Aodi1, LI Xiaobing2, XIONG Tifan1, XIE Xianda2. Research on Non-homogeneous Boundary Condition Imposing Techniques for Isogeometric Topology Optimization [J]. China Mechanical Engineering, 2025, 36(03): 525-535. |
| [11] | LIU Min1, 2, LU Feiyang1, ZHAN Jinqing1, 2, WU Jian1, ZHU Benliang3. Topology Optimization of Compliant Mechanisms with Embedded MovablePiezoelectric Actuator Considering Minimum Length Constraints [J]. China Mechanical Engineering, 2025, 36(02): 255-264. |
| [12] | WANG Hao1, 2, WANG Jiangbei3, LUO Haodong3, WANG Liwen4. An Adaptive Design Domain Topology Optimization Method Based on Improved Quadtree and SBFEM [J]. China Mechanical Engineering, 2024, 35(05): 904-915,927. |
| [13] | YANG Feng, LUO Shijie, YANG Jianghong, WANG Yingjun, . A GPU-accelerated High-efficient Multi-grid Algorithm for ITO [J]. China Mechanical Engineering, 2024, 35(04): 602-613. |
| [14] | SU Yonglei, ZHANG Zhifei. Integrated Casting Triangular Beam Lightweight Improving with Multi-performance Constraints of Body Systems [J]. China Mechanical Engineering, 2024, 35(04): 691-699. |
| [15] | LI Rongqi, YAN Tao, HE Zhicheng, MI Dong, JIANG Chao, ZHENG Jing. A Topology Optimized Design Method for High-performance Structures with Fluid-thermal-mechanics Coupling [J]. China Mechanical Engineering, 2024, 35(03): 487-497. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||