ISSN 1004-132X
CN 42-1294/TH
CN 42-1294/TH
中国机械工程 ›› 2026, Vol. 37 ›› Issue (9): 2101-2114.DOI: 10.3969/j.issn.1004-132X.2026.09.003
• 智能诊断与运维专栏 • 上一篇
李蓉( ), 金子源, 王华建, 刘坚, 尹韶辉
收稿日期:2024-08-22
修回日期:2026-08-06
出版日期:2026-09-25
发布日期:2026-10-21
通讯作者:
李蓉
作者简介:李蓉*(通信作者),女,1976年生,副教授。研究方向为视觉检测与质量控制、故障诊断与信号处理。E-mail:jyylirong@hnu.edu.cn。
基金资助:
LI Rong(), JIN Ziyuan, WANG Huajian, LIU Jian, YIN Shaohui
Received:2024-08-22
Revised:2026-08-06
Online:2026-09-25
Published:2026-10-21
Contact:
LI Rong
摘要:
为保障复杂轴类零件内孔表面缺陷检测的内窥成像质量并避免内窥镜与工件碰撞划伤,提出了一种轴孔类零件单目内窥成像位姿检测方法。针对单目内窥成像干扰轮廓多的特点,提出一种基于长度约束与最小包络圆约束的干扰轮廓去除方法。基于改进最大类间方差阈值分割方法对图像进行阈值分割,采用Suzuki轮廓提取算法进行边缘轮廓提取,采用所提出的干扰轮廓去除方法进行目标轮廓筛选并采用径向搜索提取目标内孔轮廓点集。针对轮廓点集离散且存在误差点,以及内窥光源位姿偏移较大时光照不均导致目标轮廓不完整的问题,提出了一种基于轮廓恢复的椭圆检测算法。针对位姿求解的二义性问题,基于成像仅有圆特征、灰度信息丰富且位姿检测时由机械臂移动工件、内孔中心靠近光轴的特点,提出一种基于角度约束与灰度分布的二义性去除方法。实验结果验证了提出的轴孔类零件单目内窥成像视觉位姿检测方法的有效性,该方法在X、Y轴方向上的位置检测精度为0.062 mm,绕X、Y轴旋转的姿态检测精度在1.4°以内,均达到了企业的要求。
中图分类号:
李蓉, 金子源, 王华建, 刘坚, 尹韶辉. 轴孔类零件单目内窥成像位姿检测研究[J]. 中国机械工程, 2026, 37(9): 2101-2114.
LI Rong, JIN Ziyuan, WANG Huajian, LIU Jian, YIN Shaohui. Research on Pose Detection of Shaft and Hole Parts Based on Monocular Endoscopic Imaging[J]. China Mechanical Engineering, 2026, 37(9): 2101-2114.
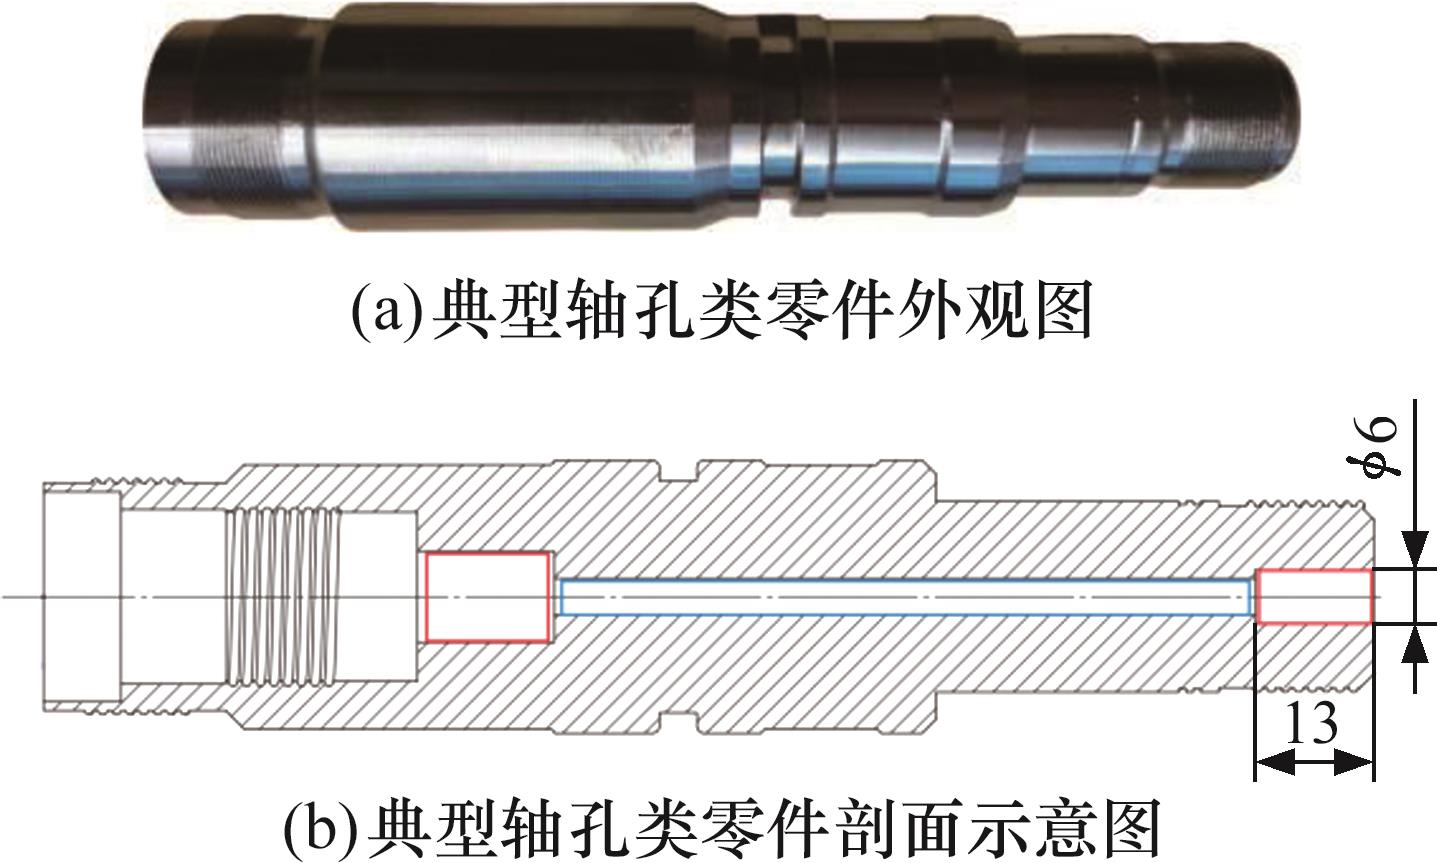
图1 某轴孔类零件外观及剖面示意图
Fig.1 Appearance and profile of shaft part
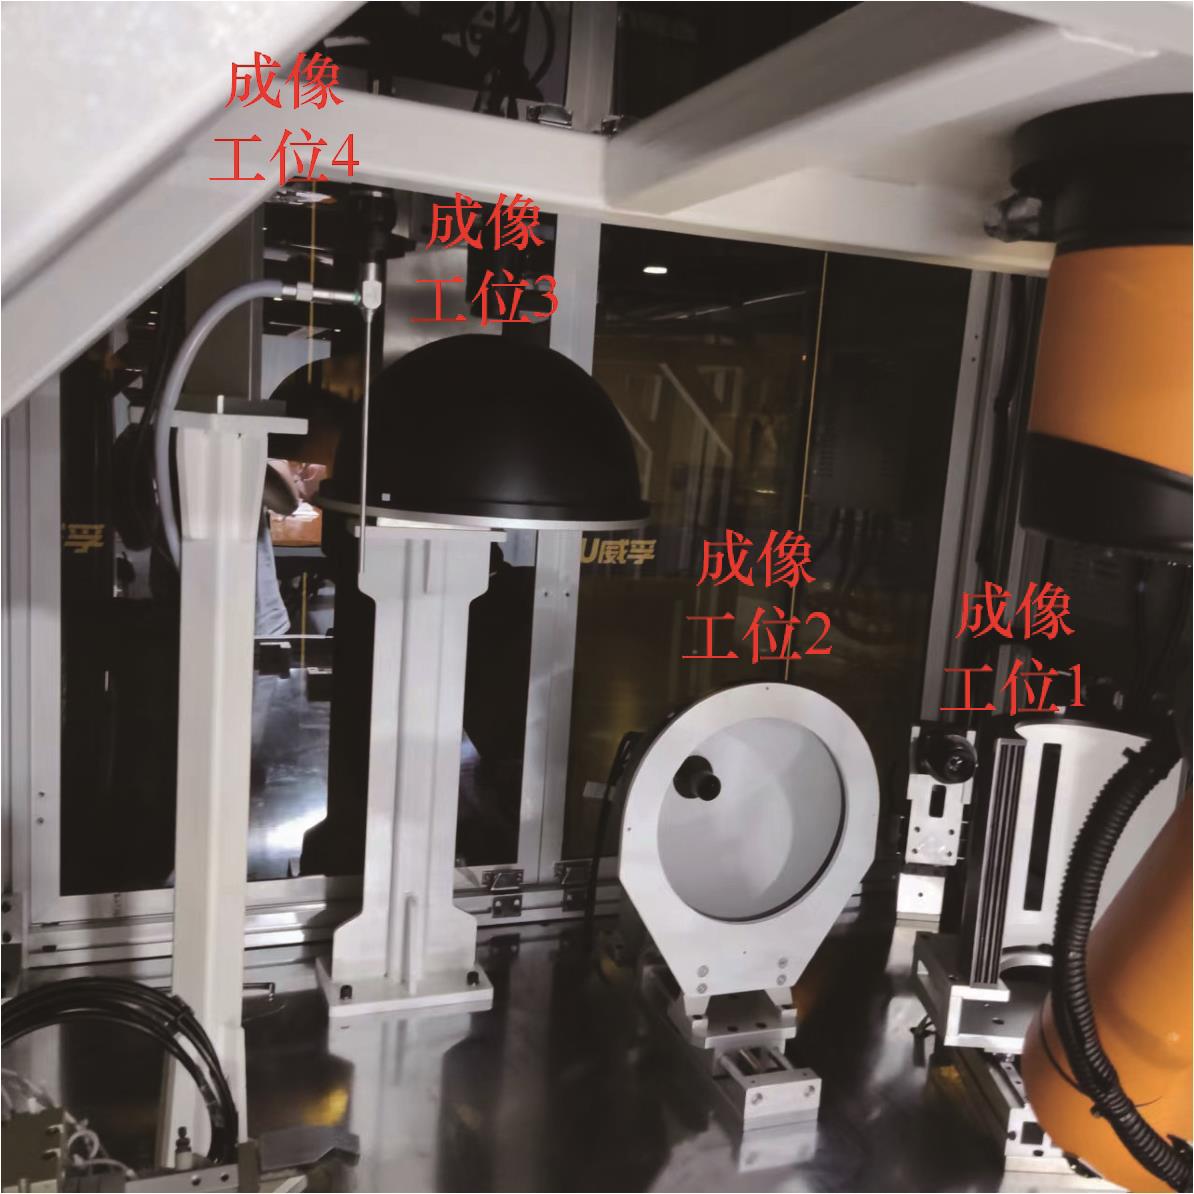
图2 基于机器视觉的某轴孔类零件表面缺陷检测设备及其成像方案
Fig.2 Surface defect detection equipment & imaging scheme of the shaft-hole part based on machine vision
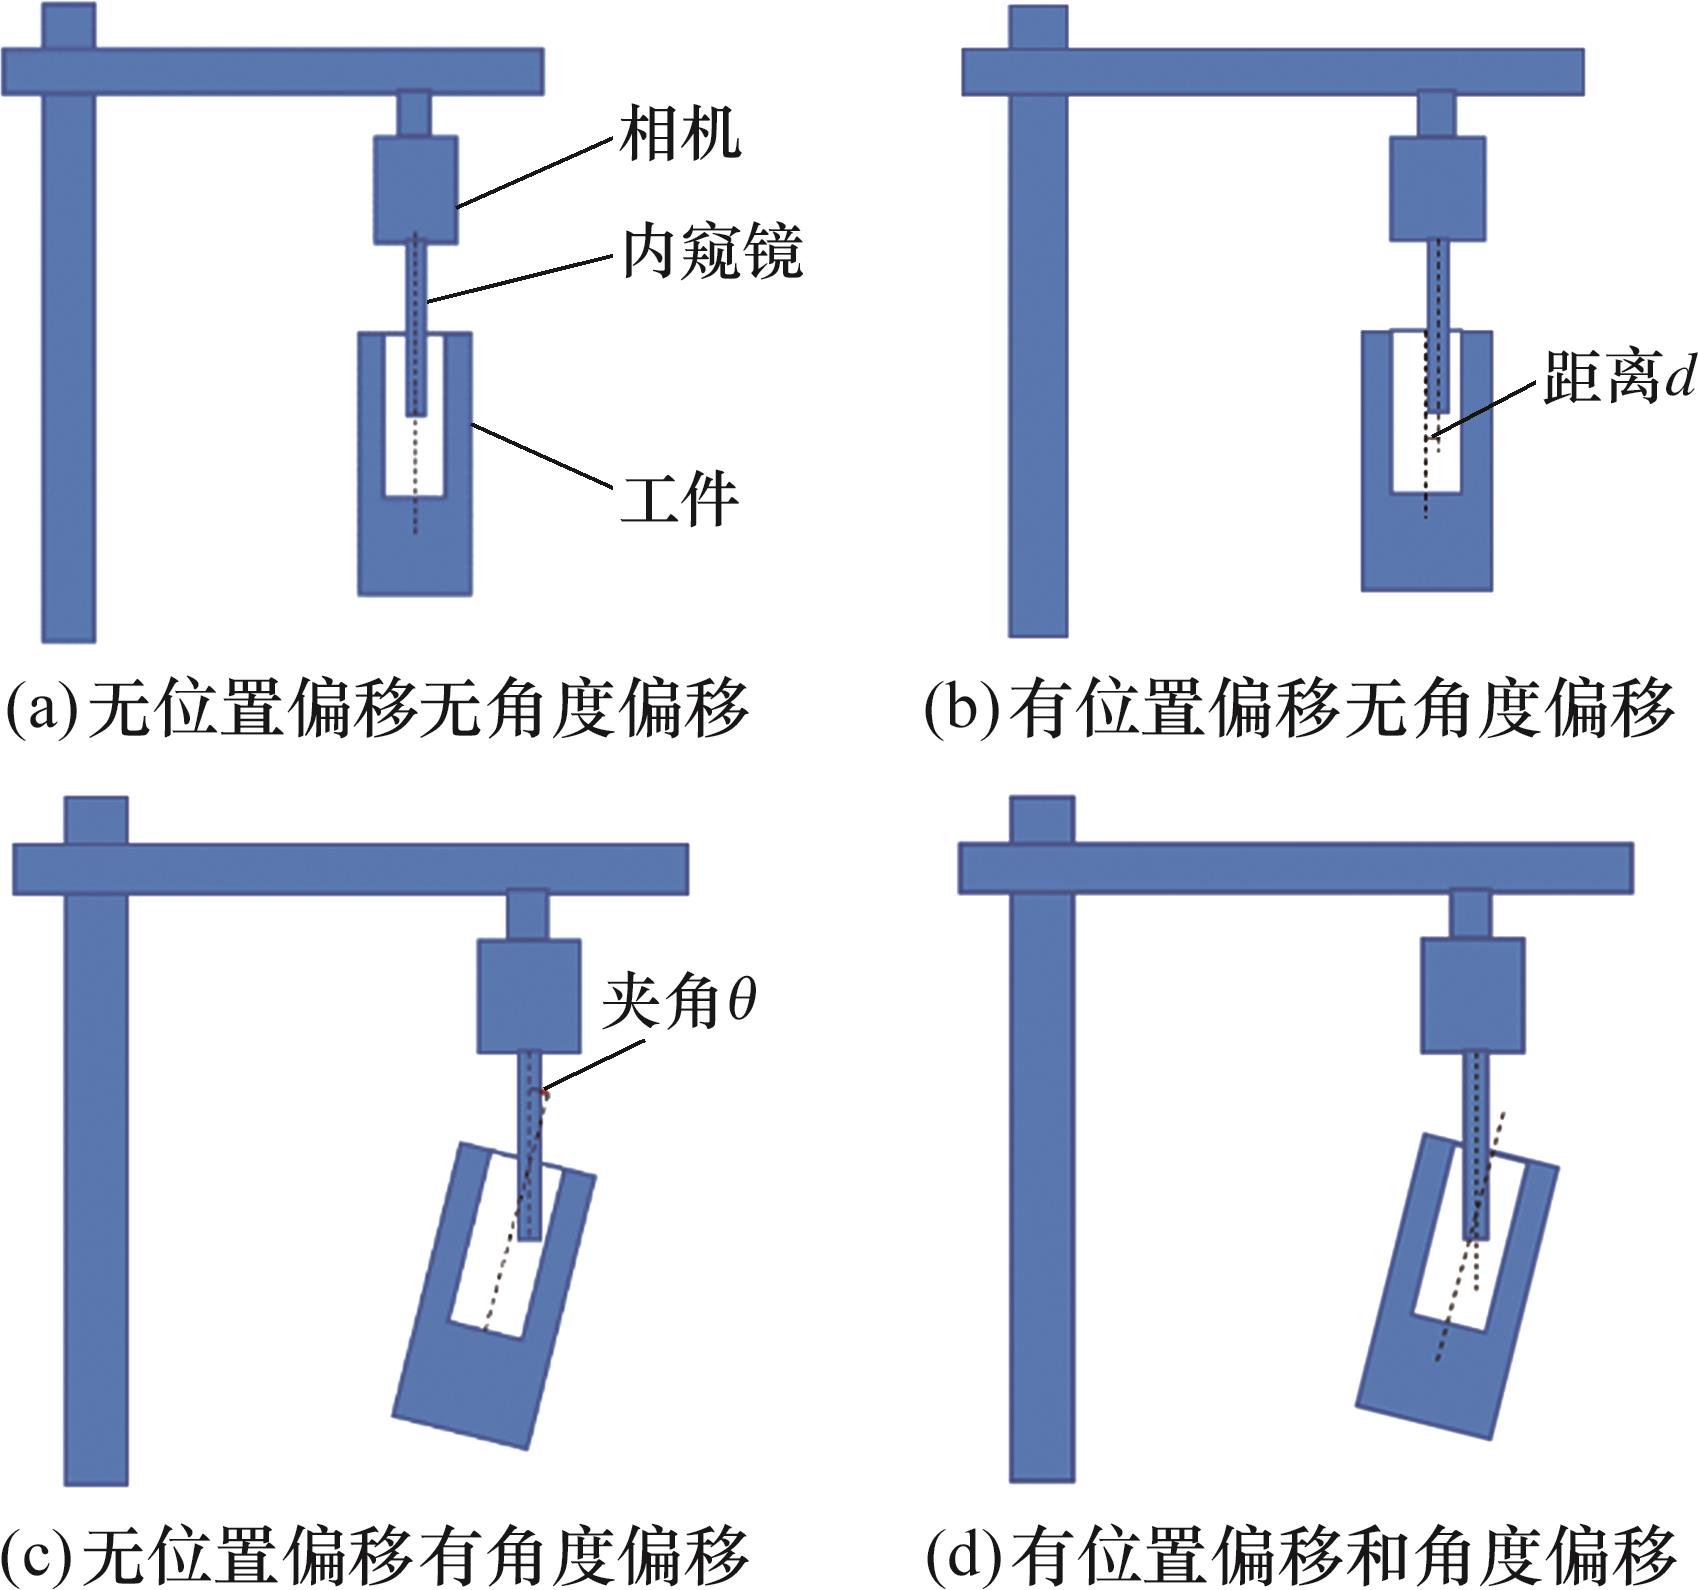
图3 4种典型位姿
Fig.3 Four typical postures
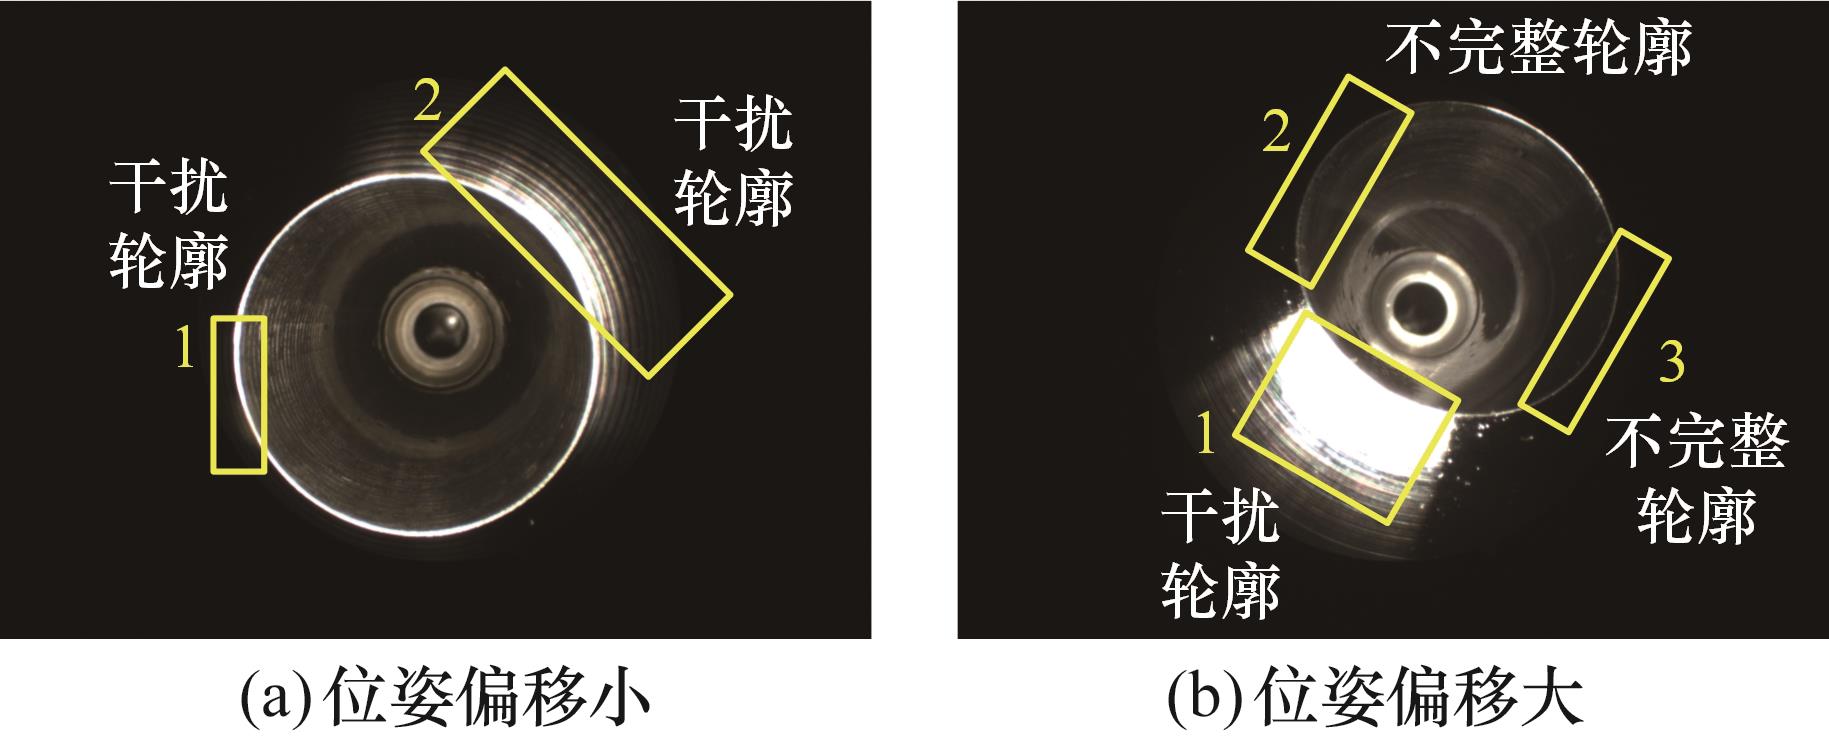
图4 不同位姿偏移下的小端面成像
Fig.4 Small end-face imaging with different posture offset
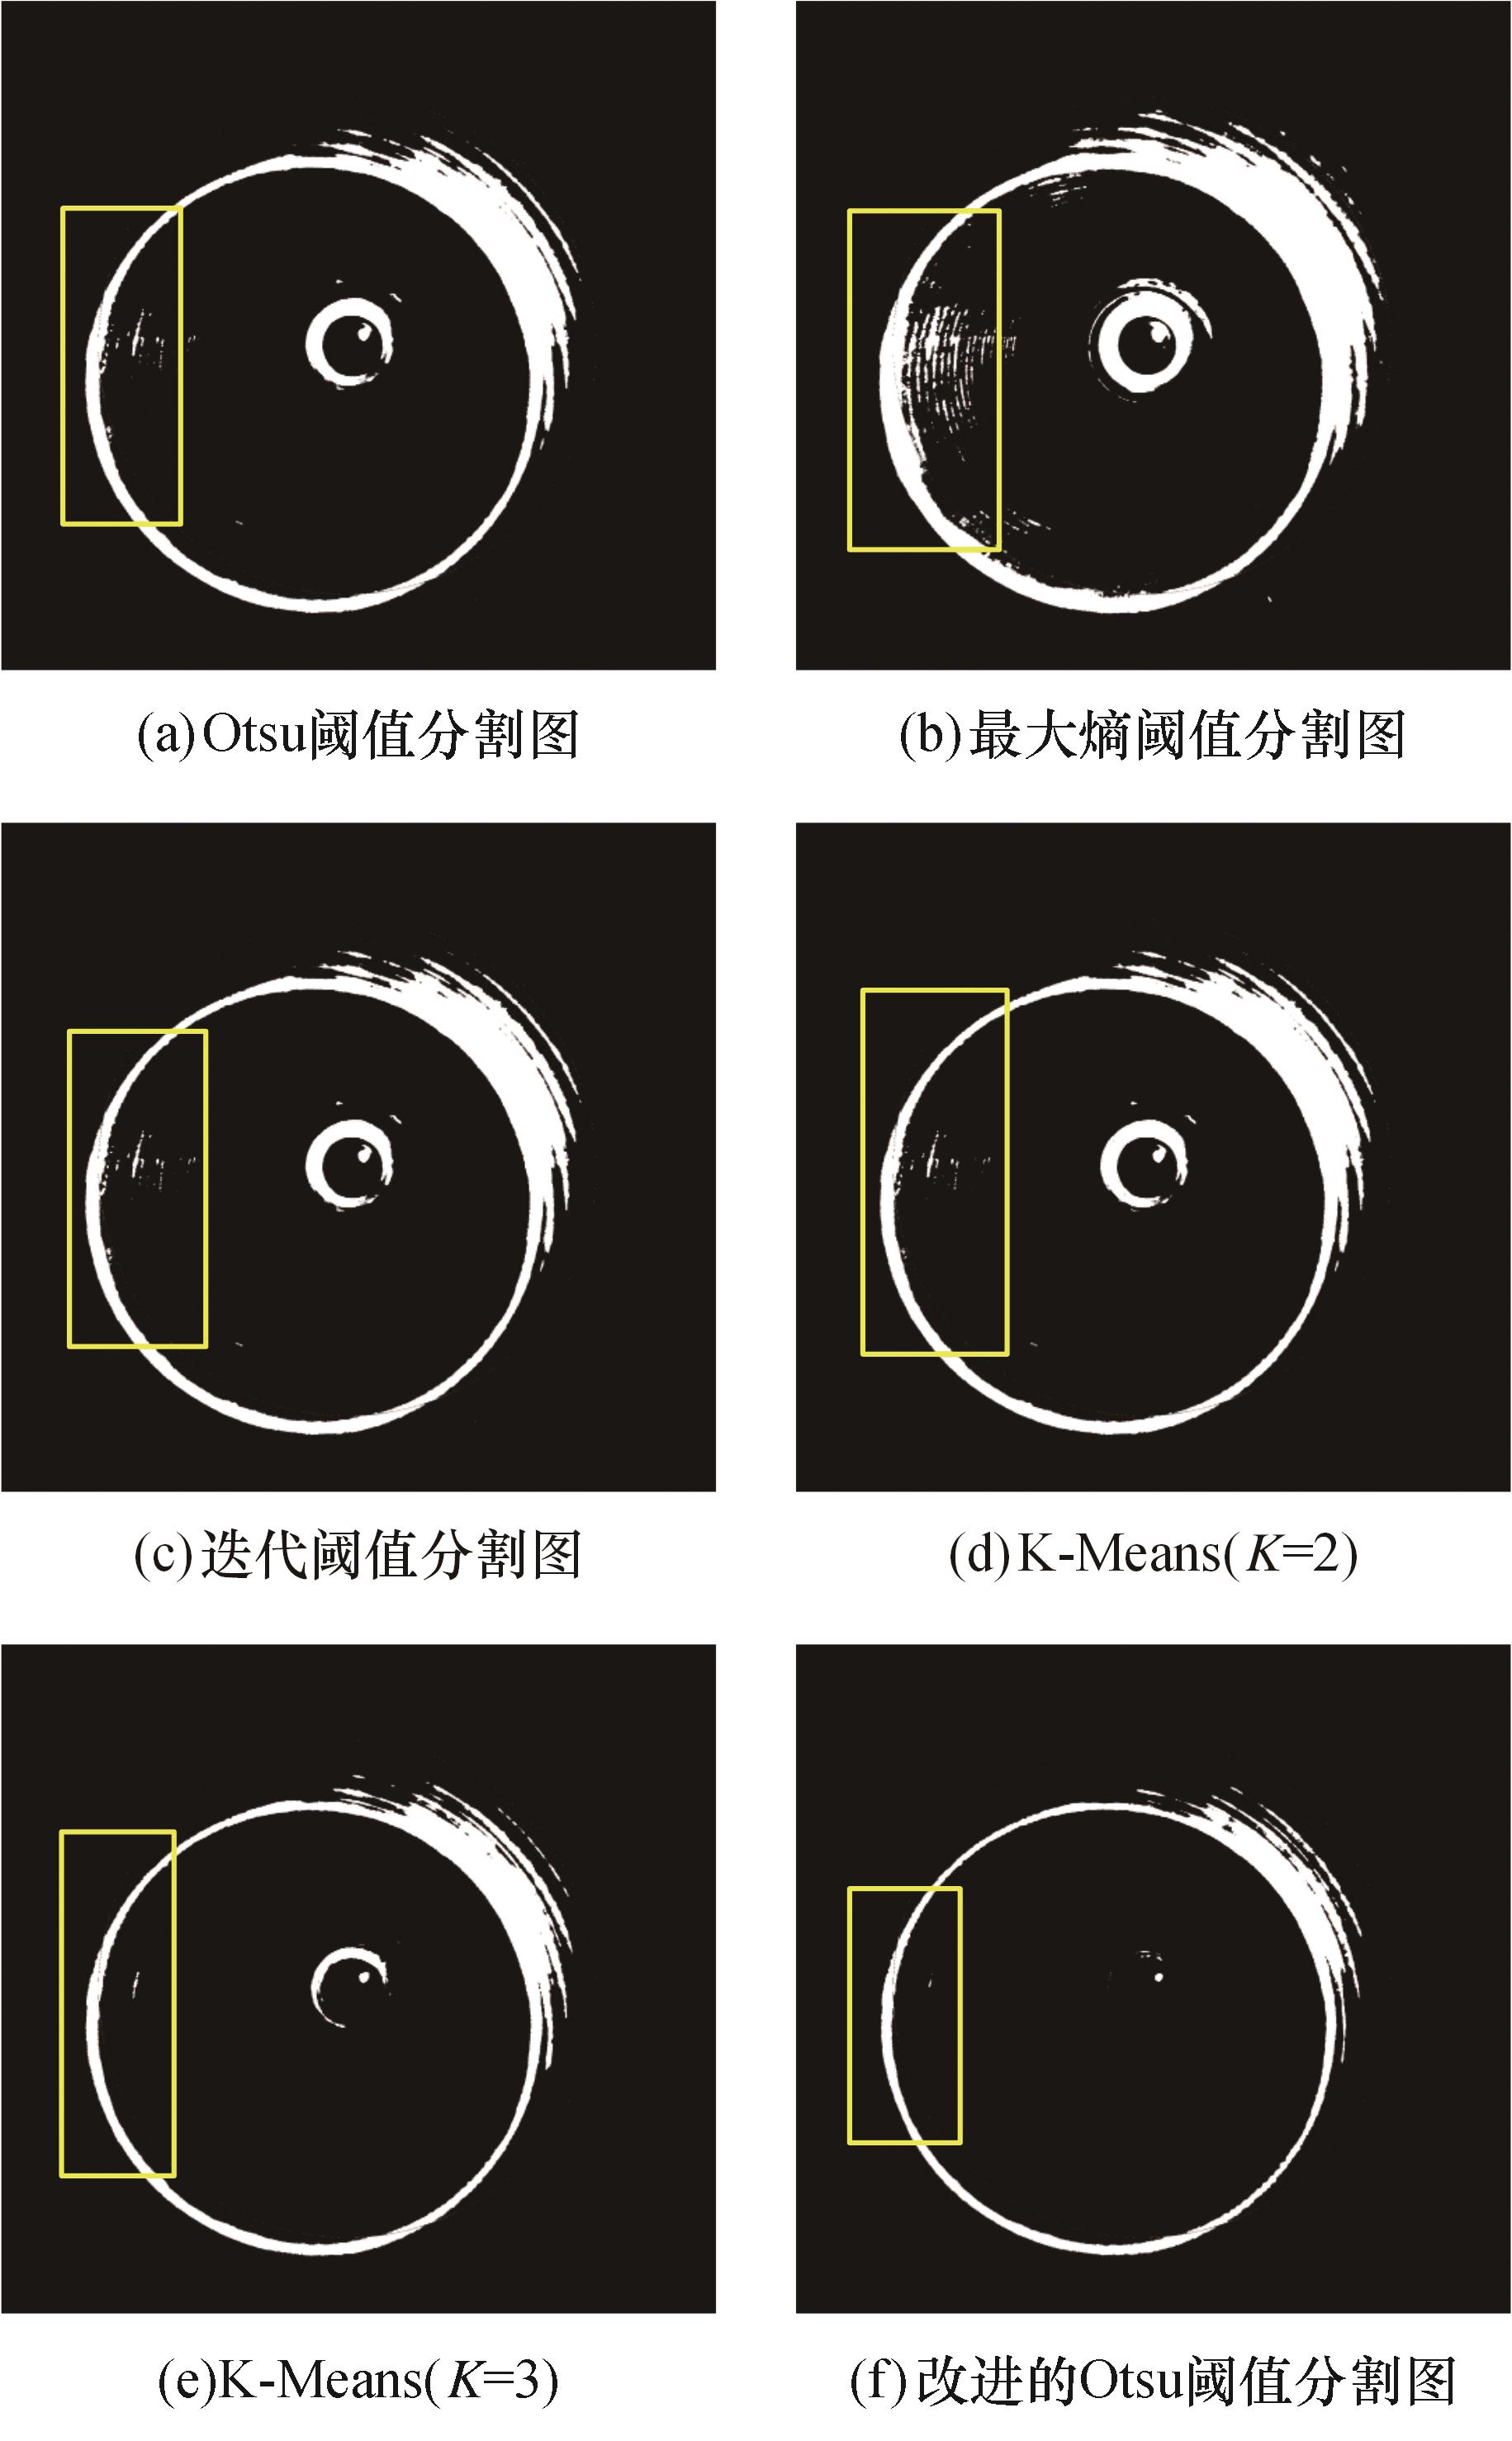
图5 不同分割算法的分割结果对比
Fig.5 Comparison results of different segmentation algorithms
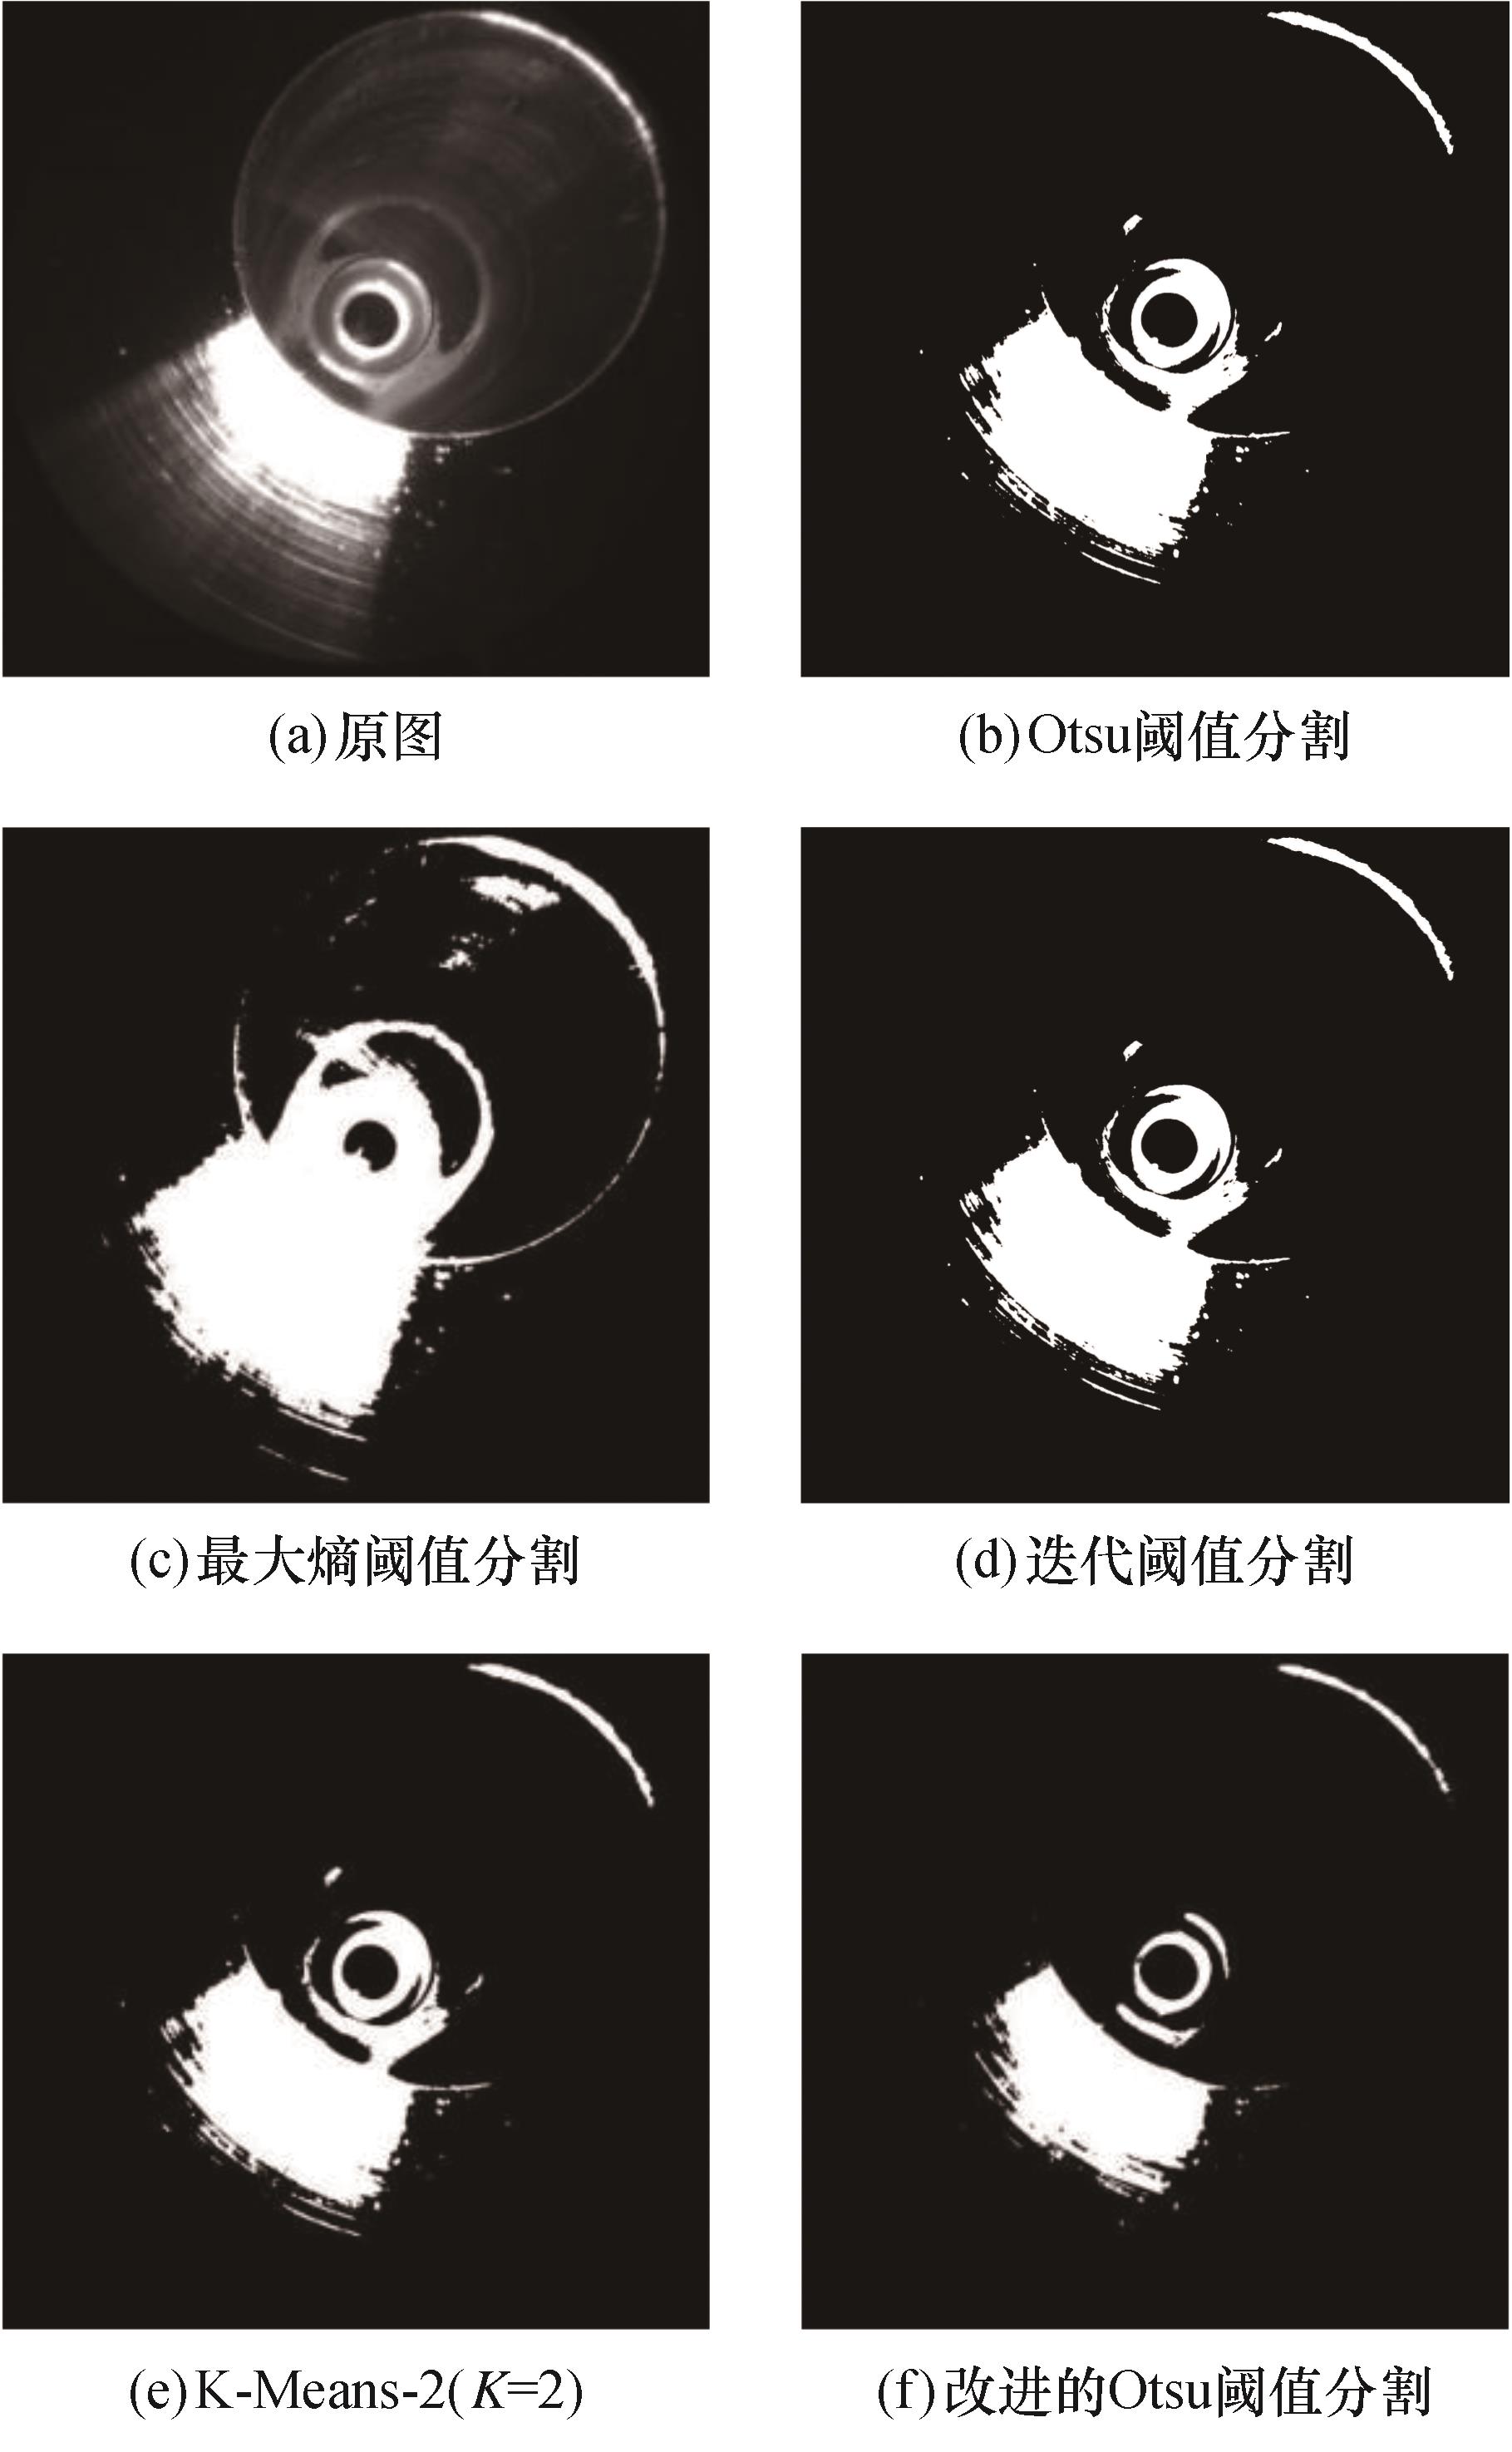
图6 内孔轮廓缺失下的不同阈值分割算法结果对比图
Fig.6 Comparison results of different threshold segmentation algorithms for inner hole with partially missing contour
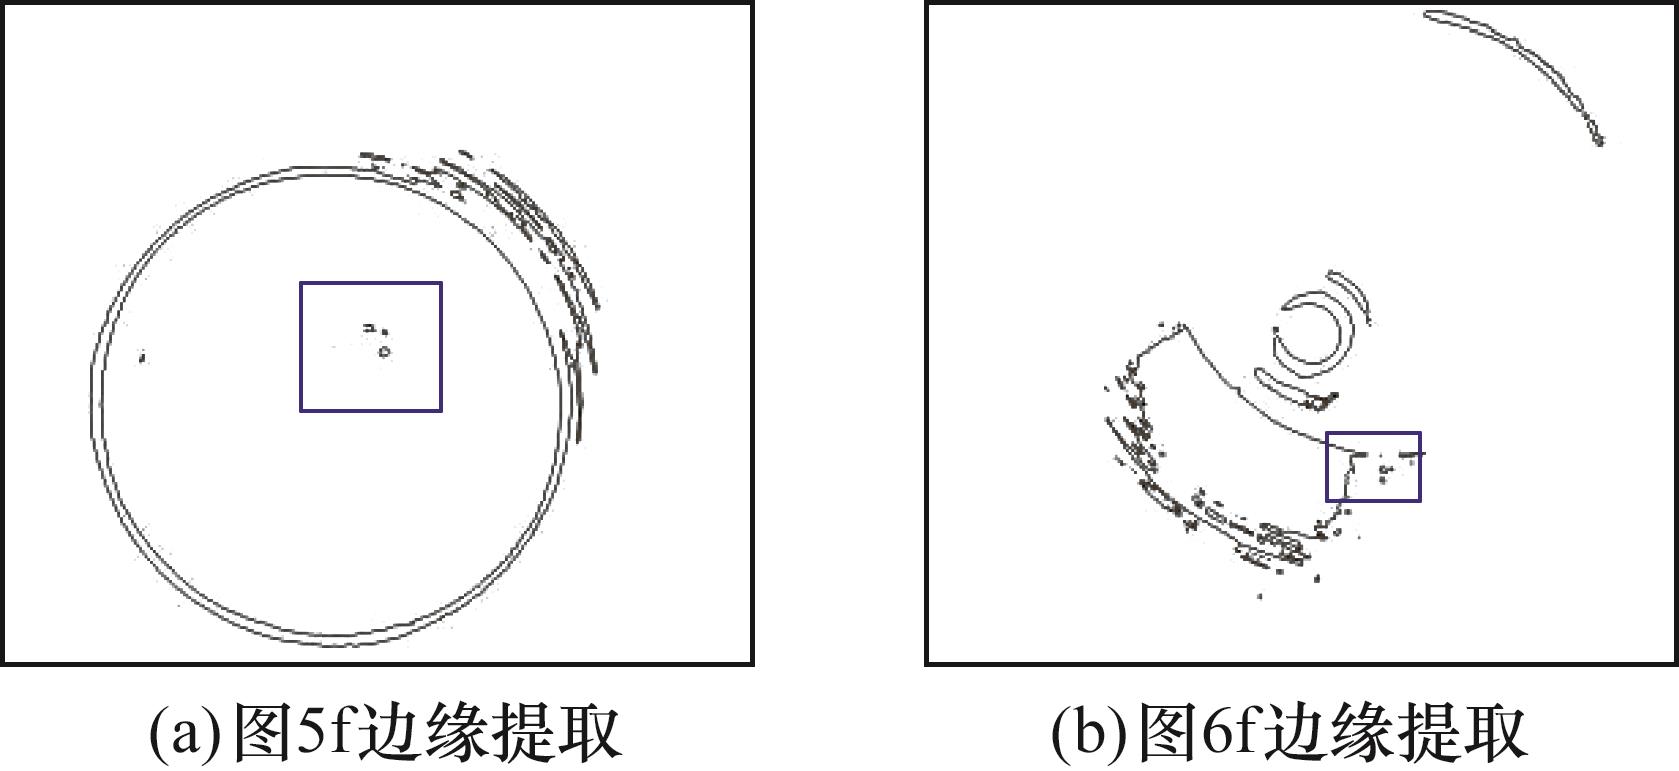
图7 基于Suzuki的边缘轮廓提取图
Fig.7 Edge contour extraction result using Suzuki
| 轮廓提取方法 | 耗时/s |
|---|---|
| Canny算法 | 0.0055 |
| 形态学算法 | 0.0030 |
| Suzuki算法 | 0.0020 |
表1 不同轮廓提取算法效率对比
Tab.1 Efficiency comparison of different contour extraction algorithms
| 轮廓提取方法 | 耗时/s |
|---|---|
| Canny算法 | 0.0055 |
| 形态学算法 | 0.0030 |
| Suzuki算法 | 0.0020 |
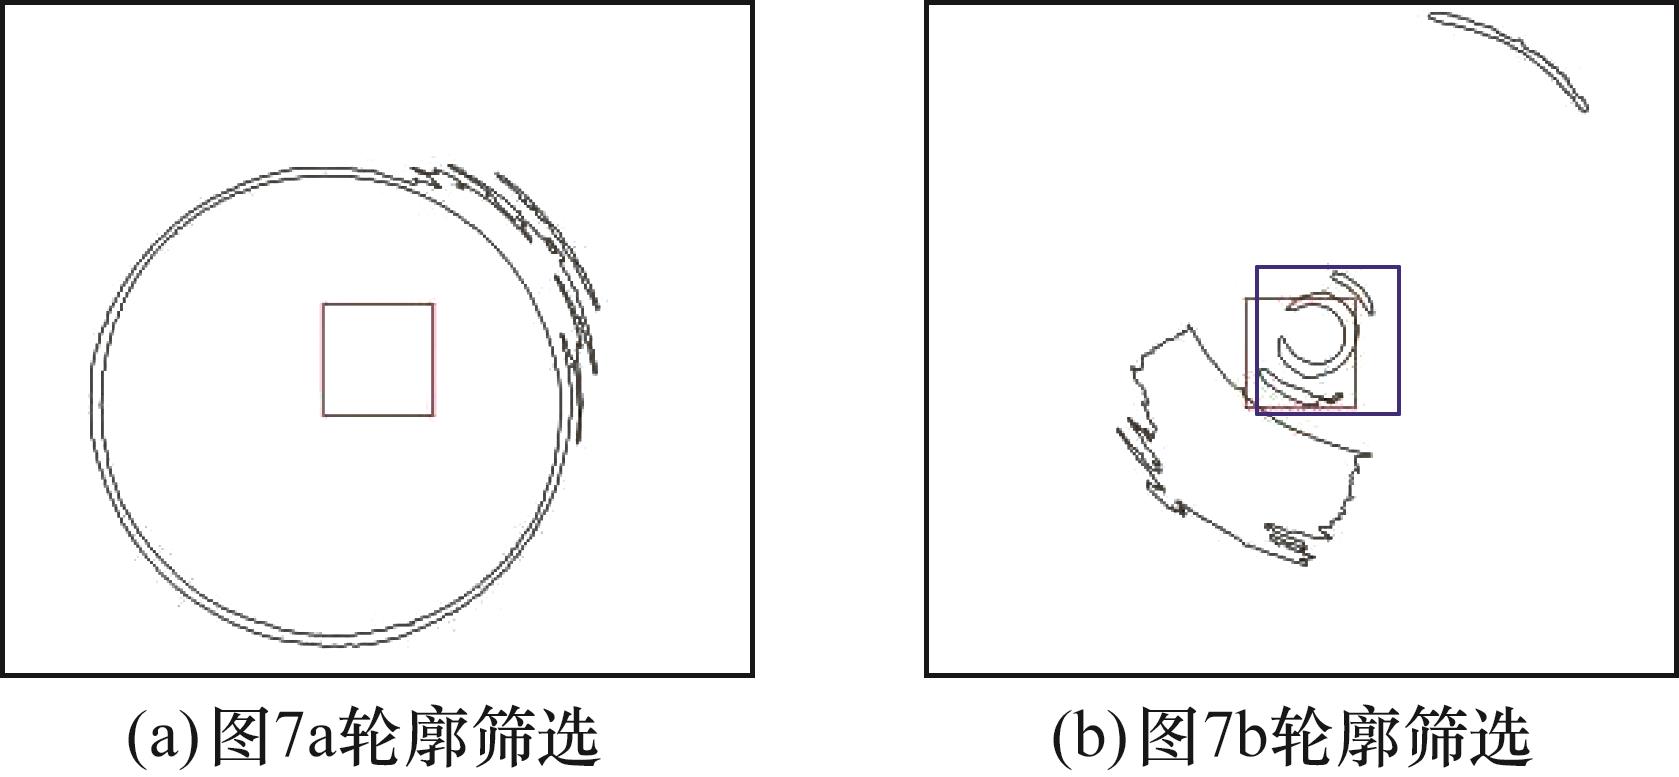
图8 基于长度约束的干扰轮廓去除结果
Fig.8 Removal results of interference contour based on length constraint
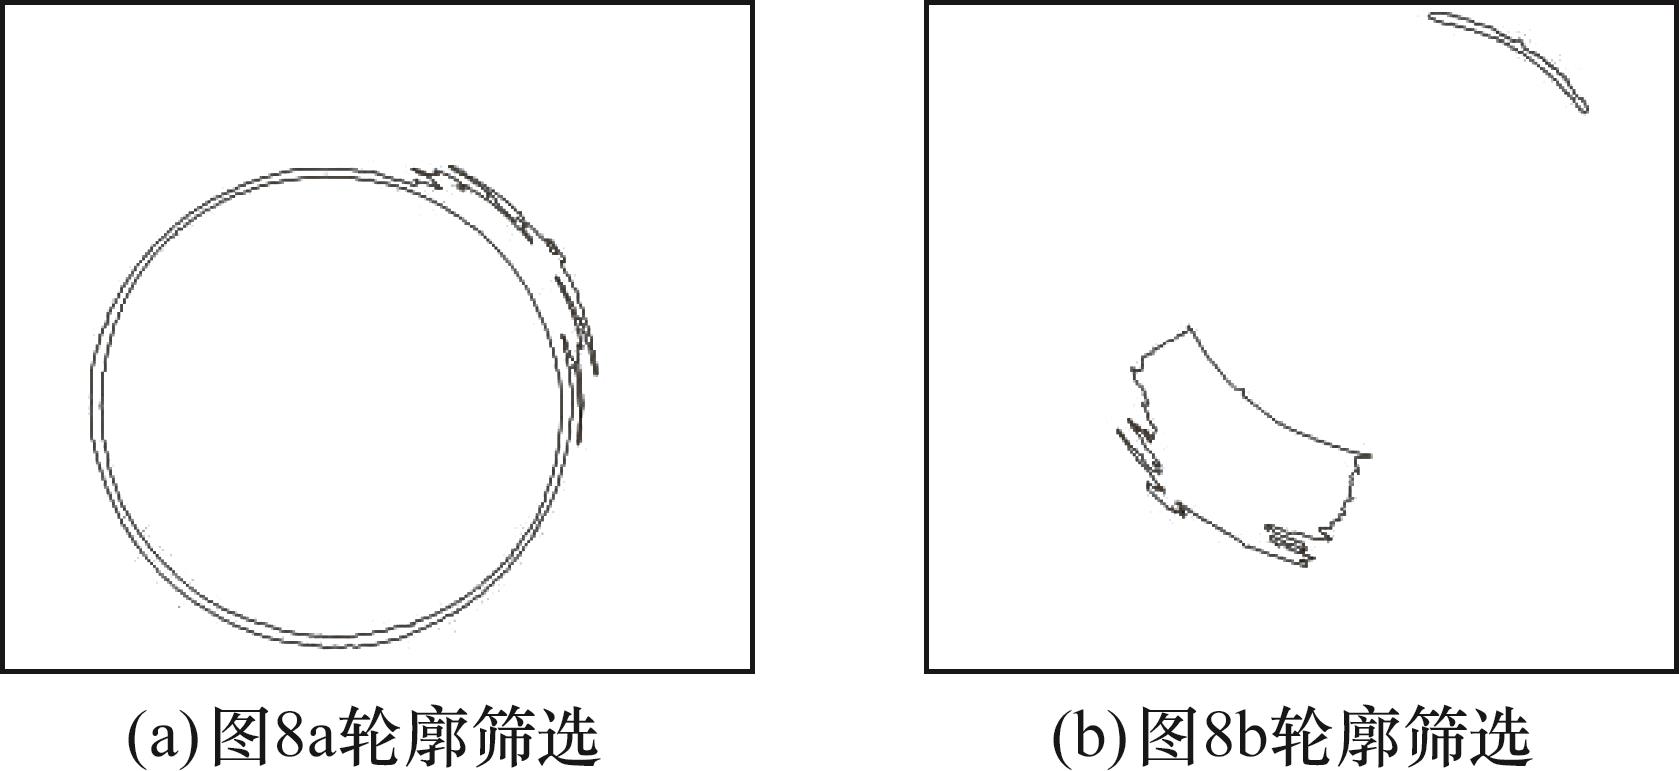
图9 基于长度约束和最小包络圆约束的干扰轮廓去除
Fig.9 Removal results of interference contour based on length constraint and minimum envelope circle constraint
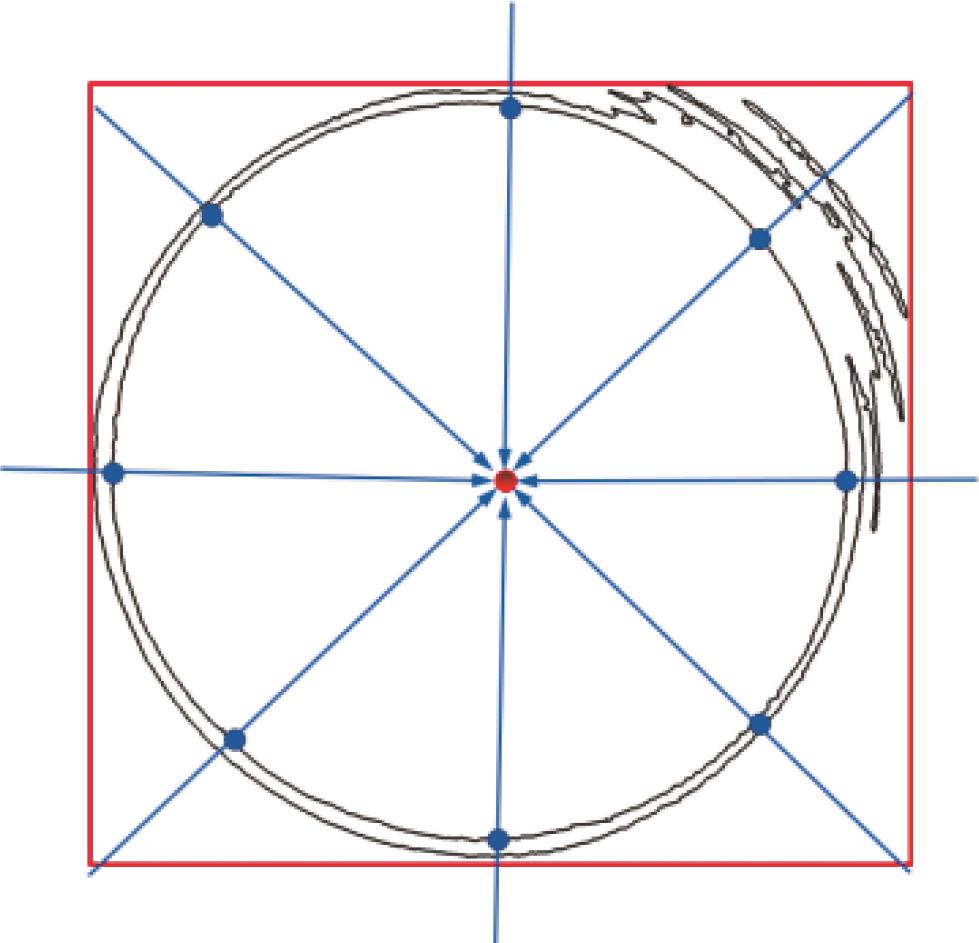
图10 基于径向搜索的内孔目标轮廓点提取方法
Fig.10 Extraction of object contour points based on radial search
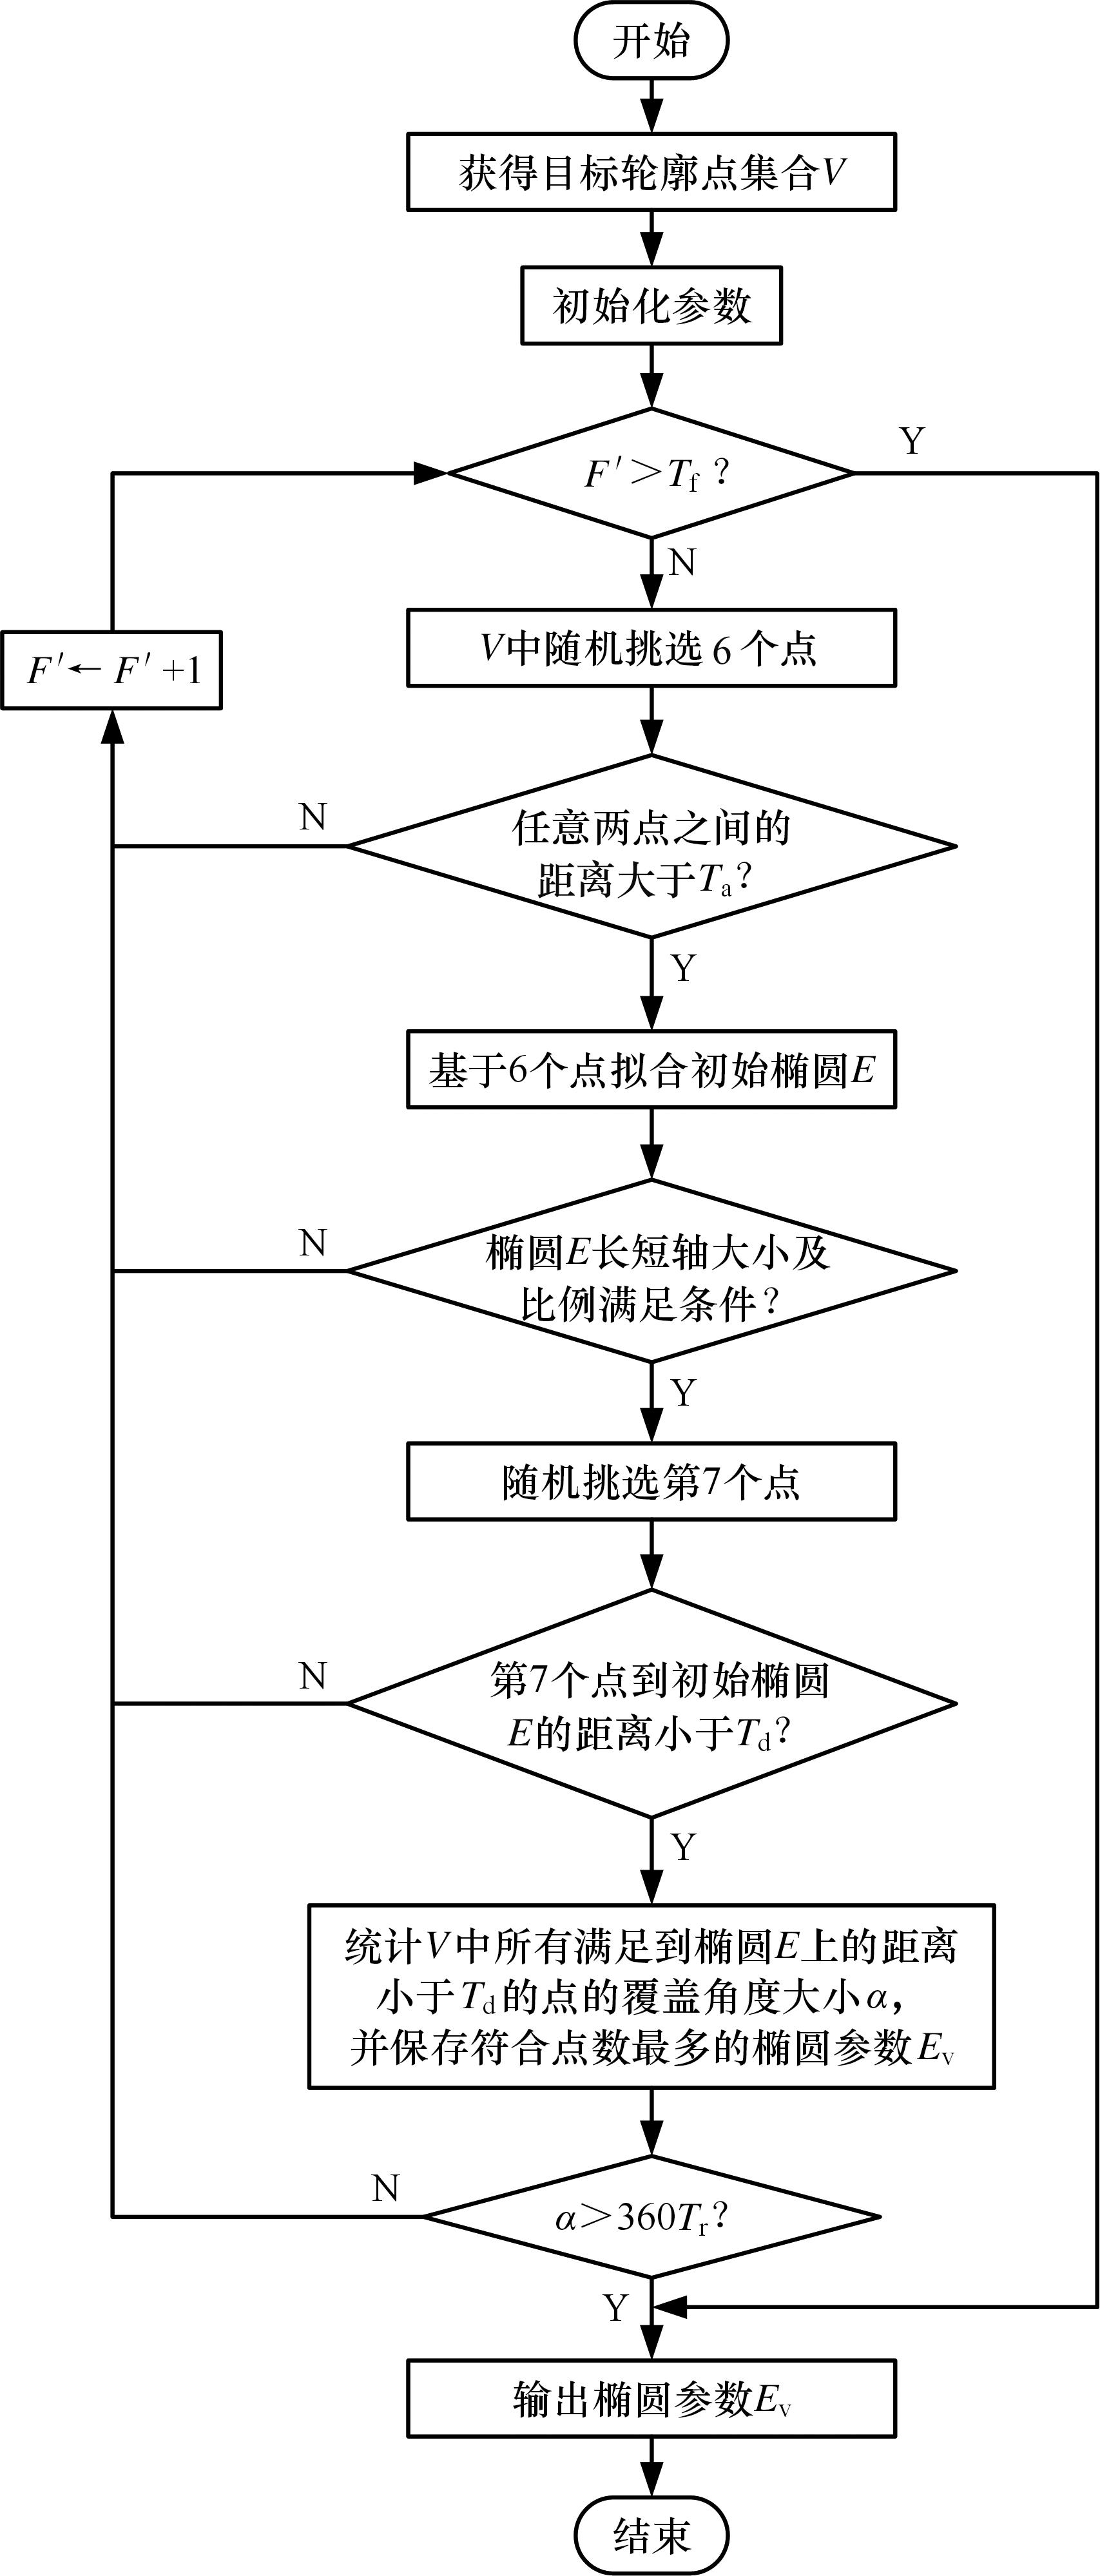
图11 改进RED算法的椭圆检测流程图
Fig.11 Ellipse detection flowchart of improved RED algorithm
| 参数 | 数值 |
|---|---|
| 最大迭代次数 | 100 |
| 用于初始椭圆拟合的6个边缘点每两个点应达到的最小距离 | 30 |
| 边缘点到初始拟合椭圆边界的最大距离 | 0.03 |
| 椭圆的完整度 | 0.8 |
表2 改进RED算法的参数设置
Tab. 2 Parameter settings of improved RED algorithm
| 参数 | 数值 |
|---|---|
| 最大迭代次数 | 100 |
| 用于初始椭圆拟合的6个边缘点每两个点应达到的最小距离 | 30 |
| 边缘点到初始拟合椭圆边界的最大距离 | 0.03 |
| 椭圆的完整度 | 0.8 |
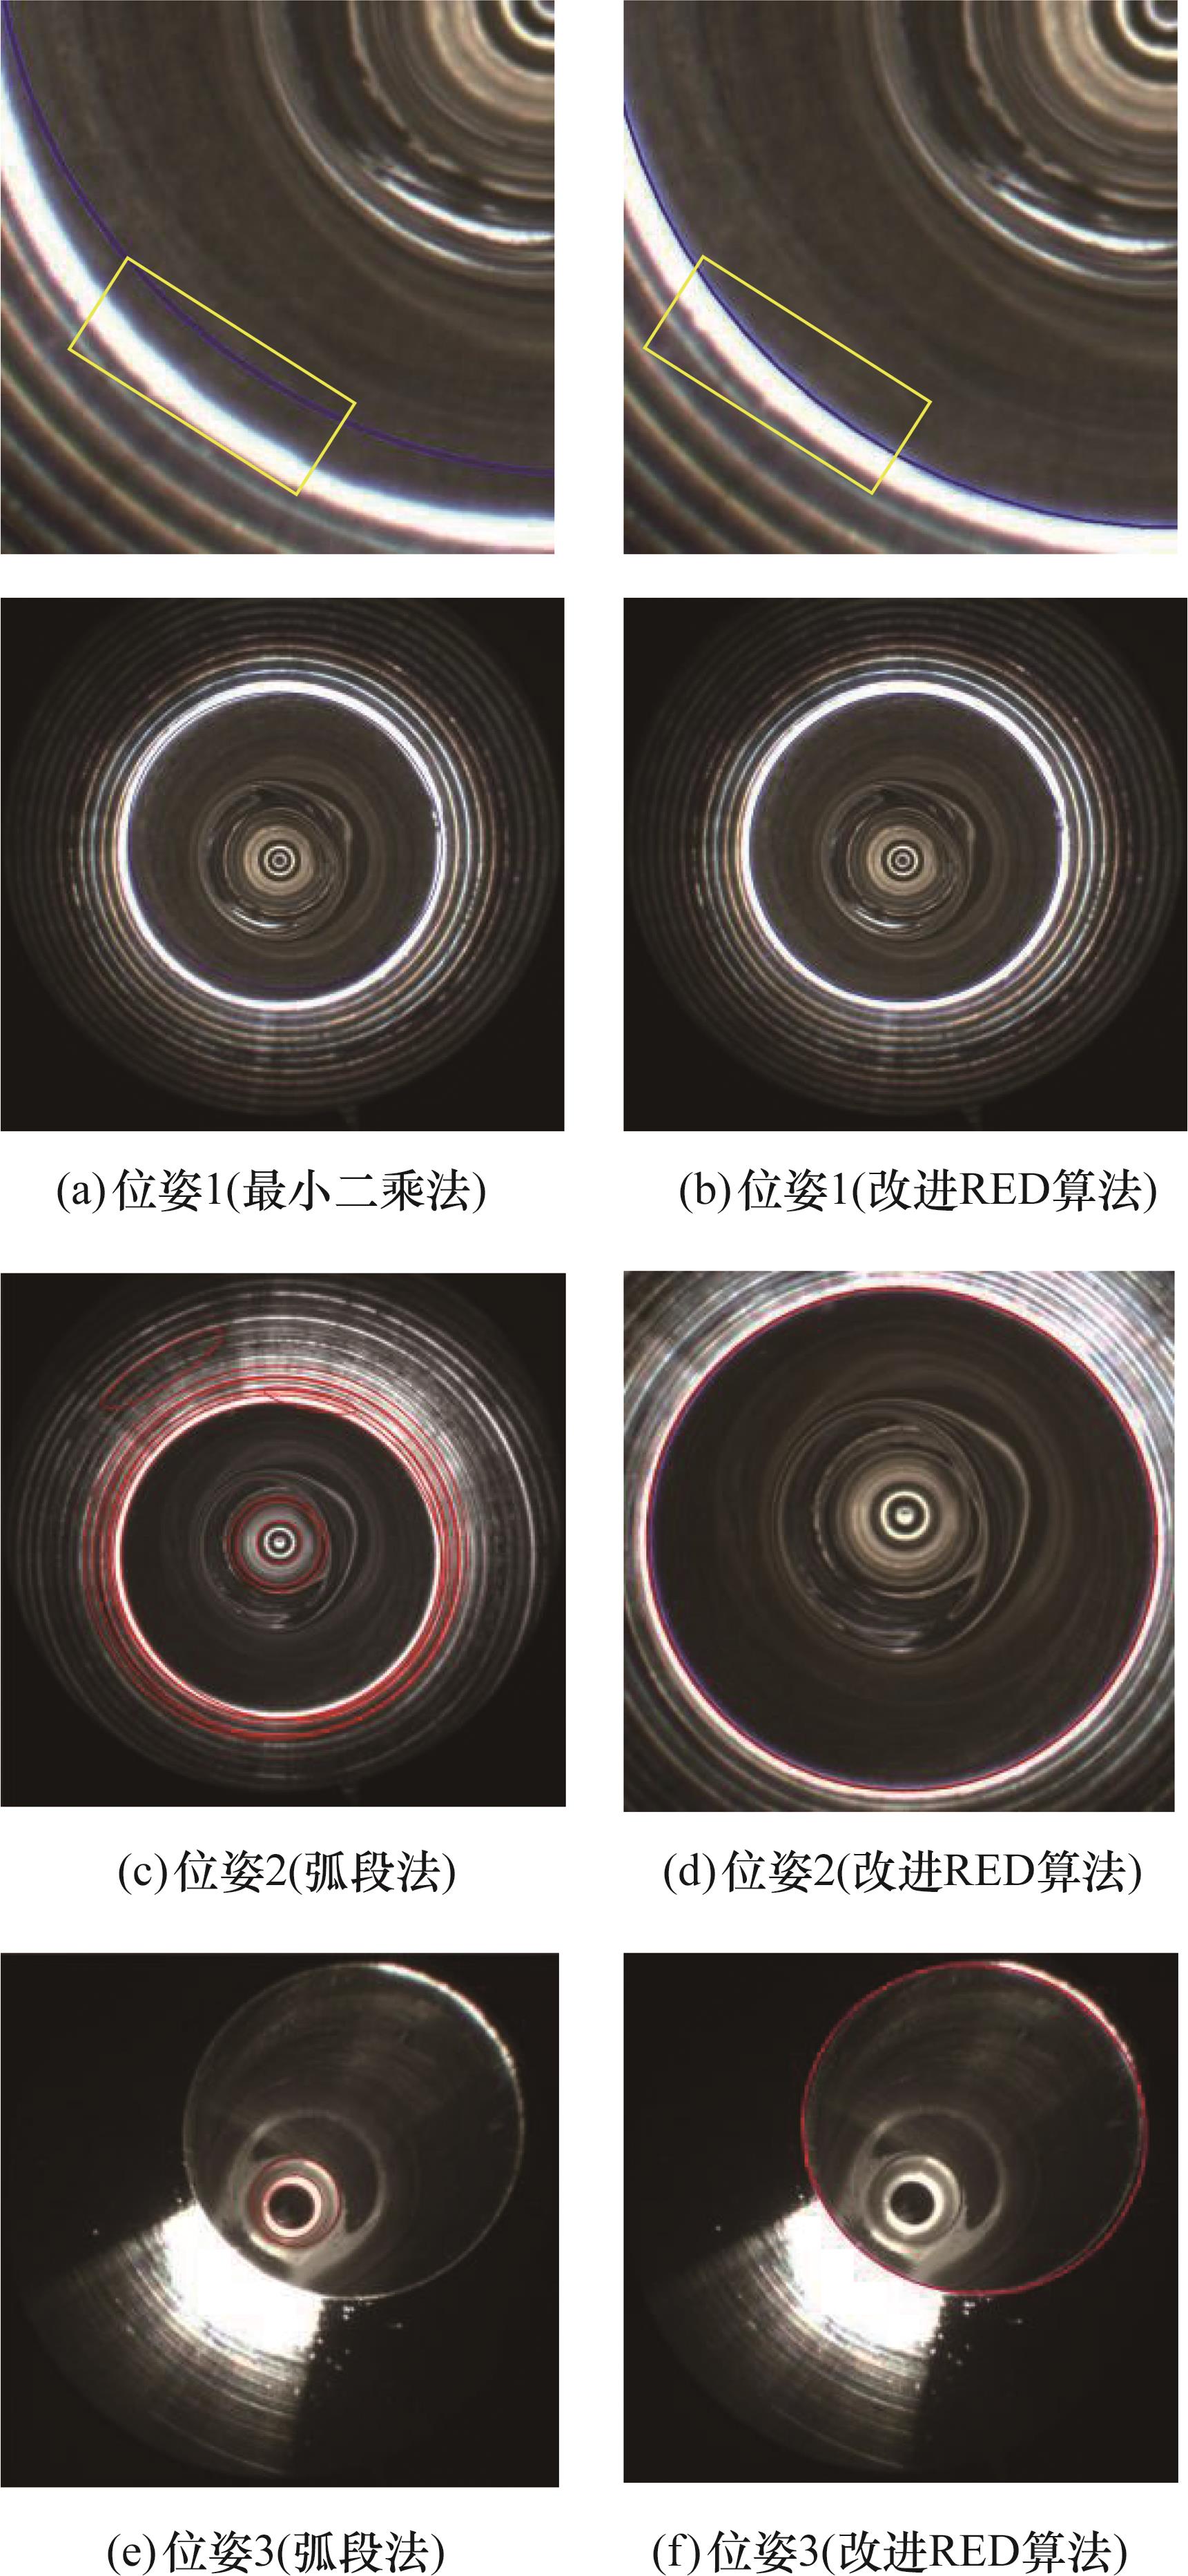
图12 不同椭圆检测方法的检测结果
Fig.12 Detection results of different ellipse detection methods
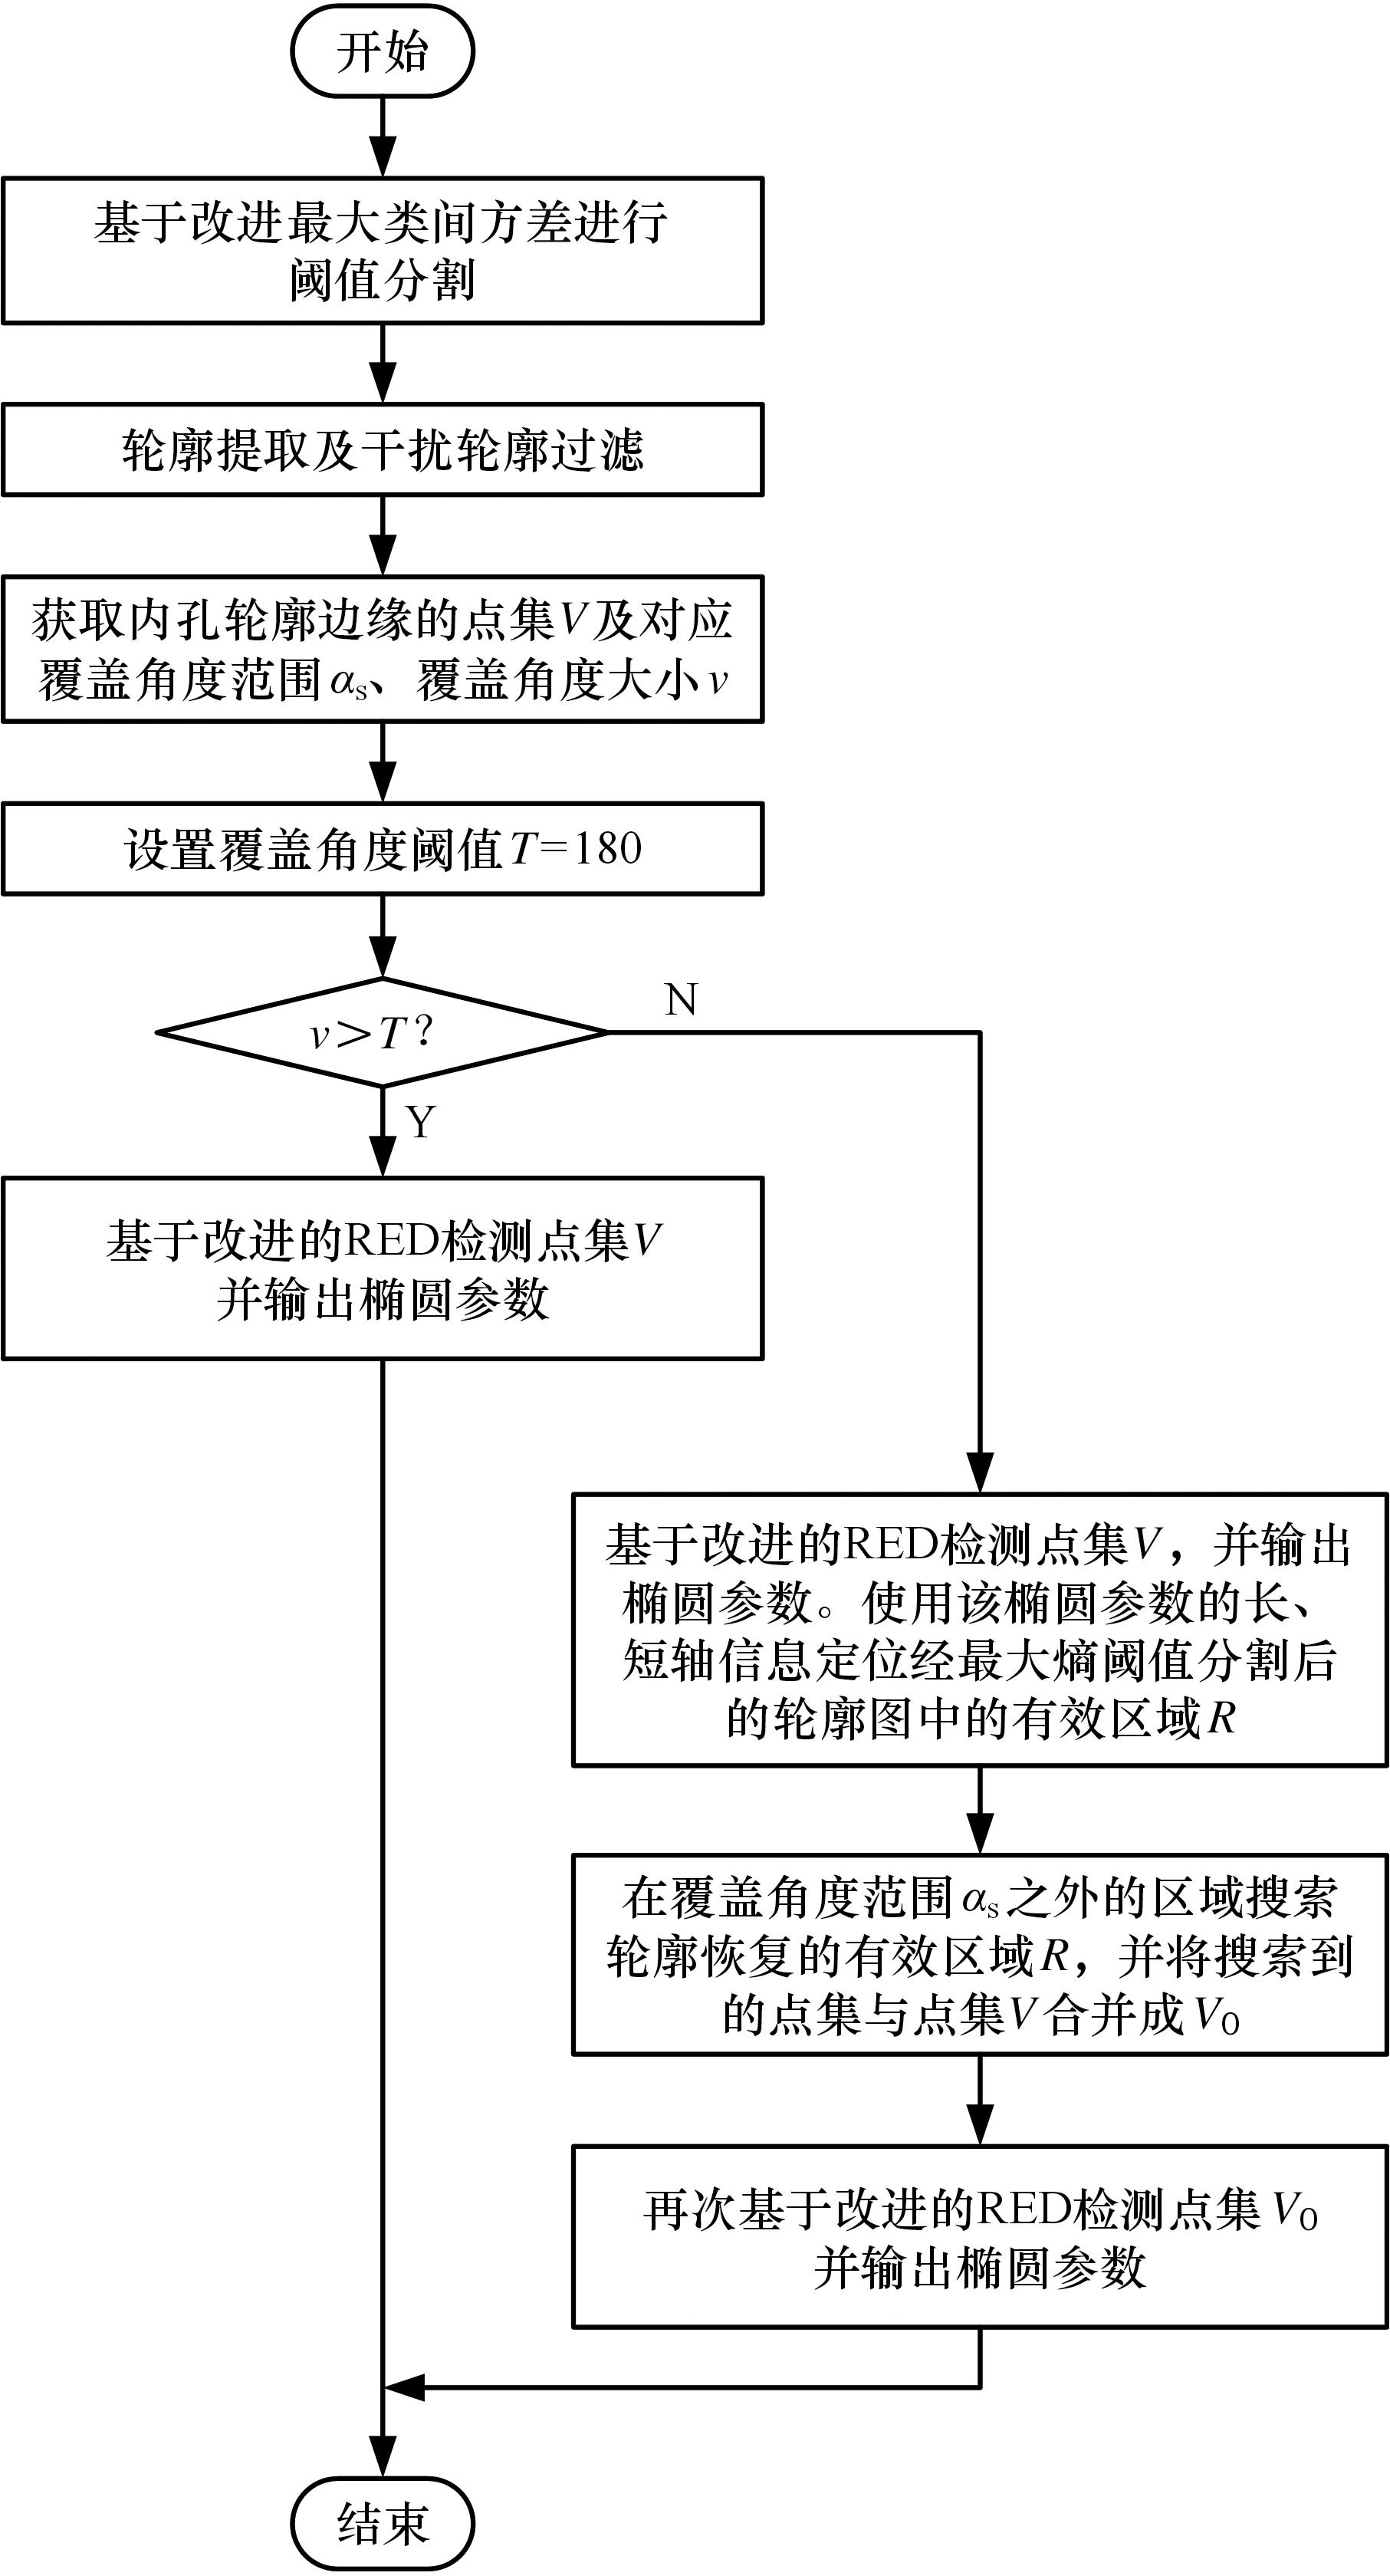
图13 基于轮廓恢复的椭圆检测算法流程图
Fig.13 Flow chart of ellipse detection algorithm based on contour restoration
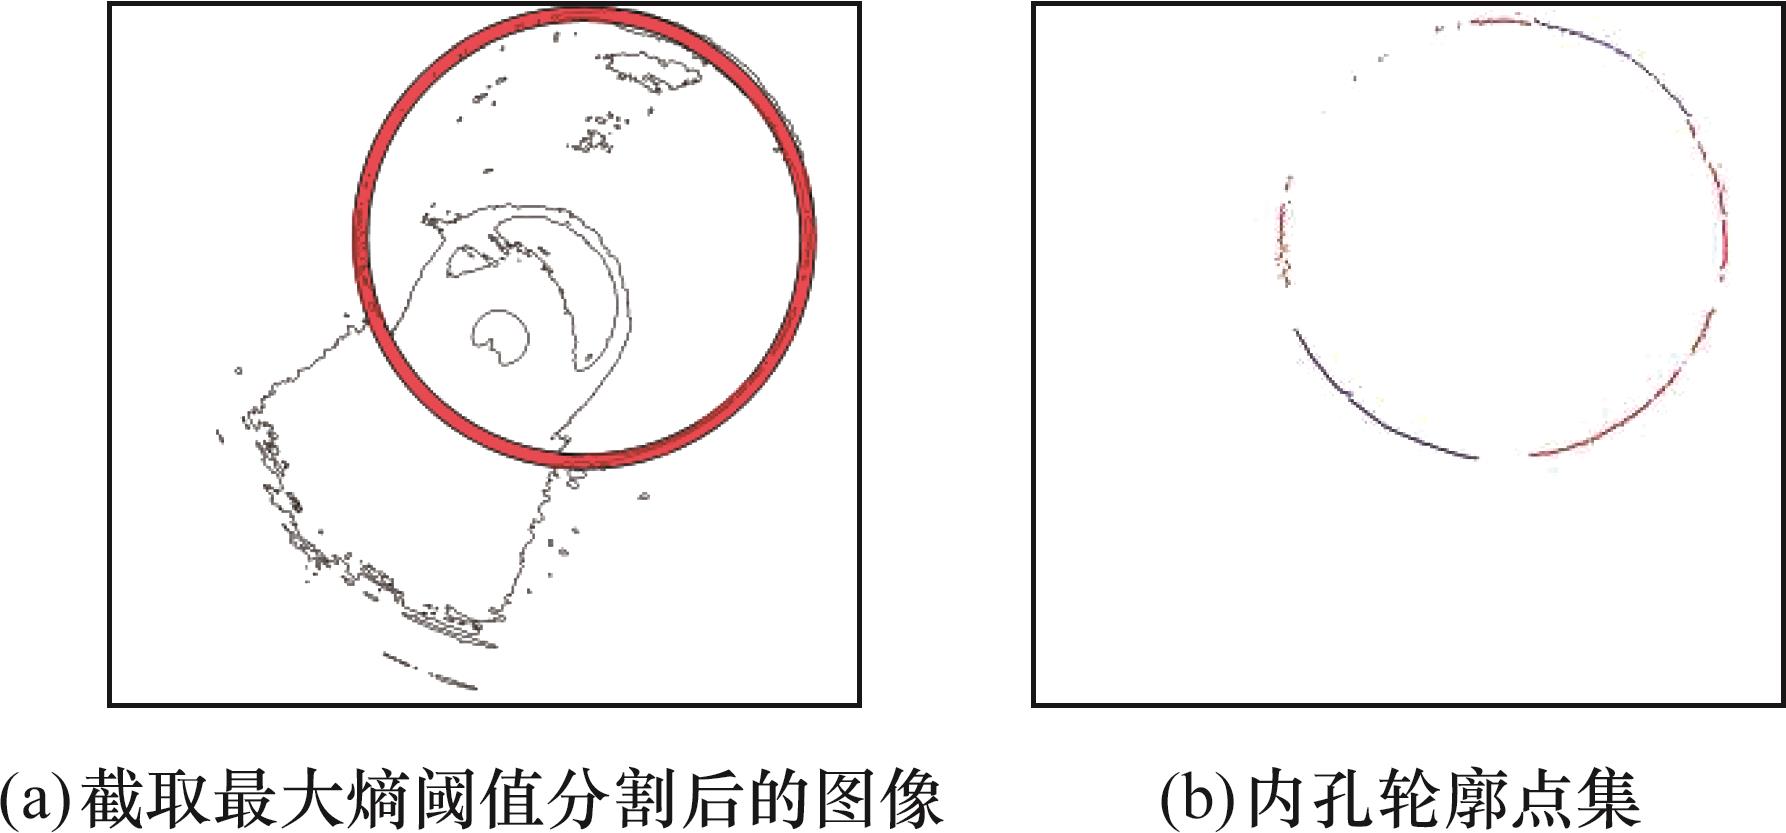
图14 轮廓恢复图
Fig.14 Contour restoration result
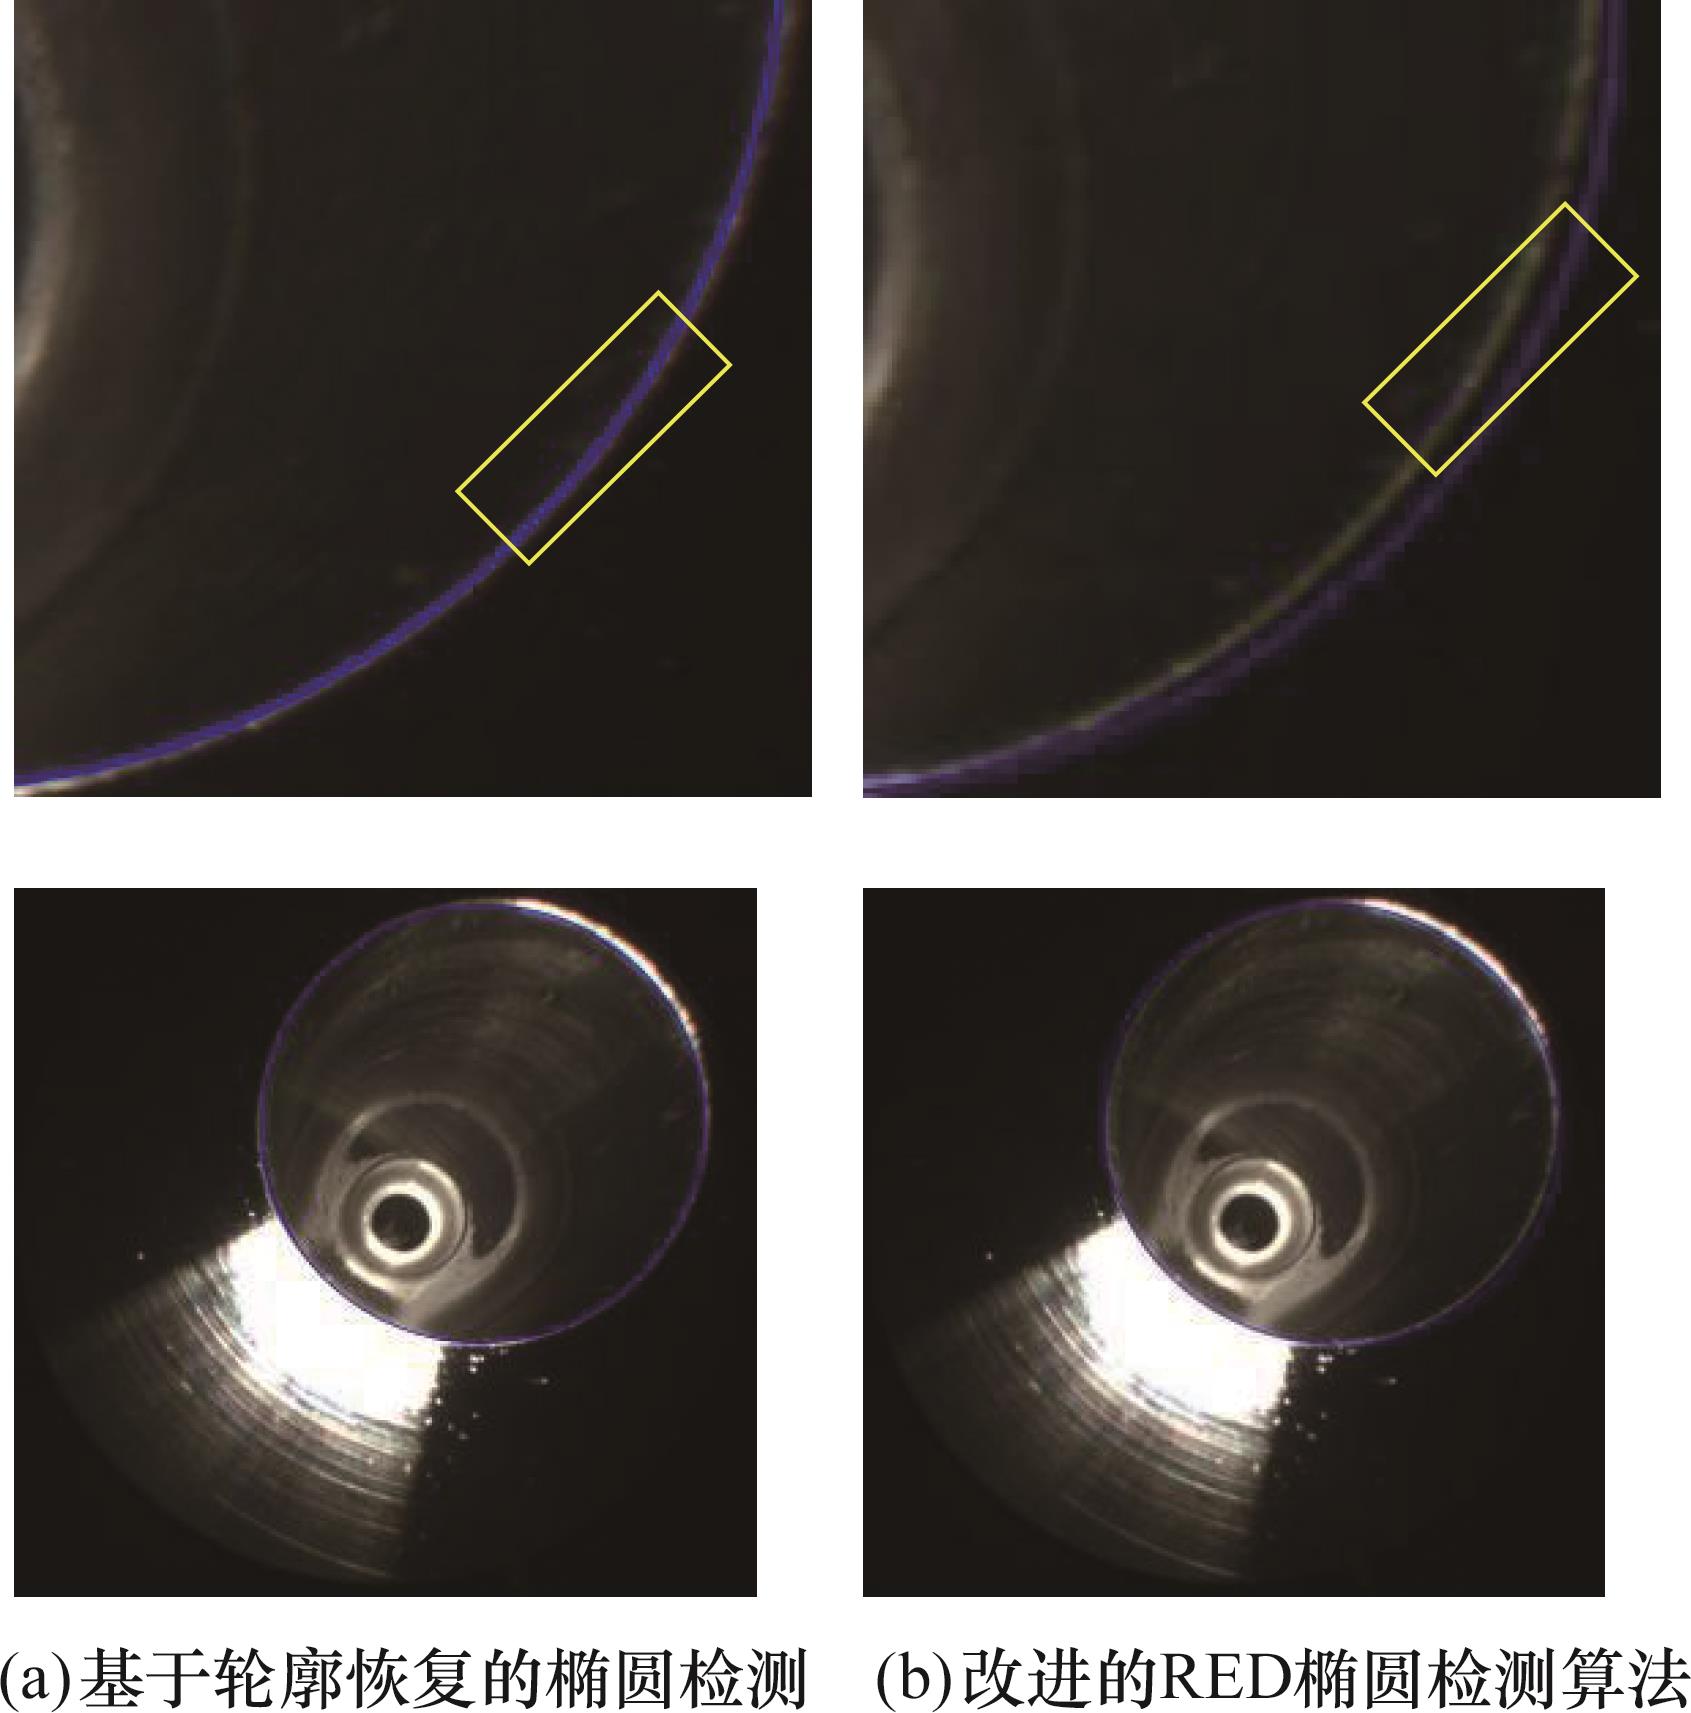
图15 基于轮廓恢复的椭圆检测效果图
Fig. 15 Ellipse detection result based on contour restoration
| 椭圆检测方法 | 每张图片耗时/s | 未正确检出图片数 | 准确率/% |
|---|---|---|---|
| 基于最小二乘法椭圆检测算法[ | 0.698 | 30 | 93.724 |
| 基于弧段椭圆检测算法[ | 12.817 | 19 | 96.025 |
| 无尺寸约束的本文改进的RED椭圆检测算法 | 0.729 | 4 | 99.163 |
| 本文提出的基于轮廓恢复的椭圆检测算法 | 0.719 | 0 | 100 |
表3 不同椭圆检测方法性能对比
Tab.3 Performance comparison of different ellipse detection methods
| 椭圆检测方法 | 每张图片耗时/s | 未正确检出图片数 | 准确率/% |
|---|---|---|---|
| 基于最小二乘法椭圆检测算法[ | 0.698 | 30 | 93.724 |
| 基于弧段椭圆检测算法[ | 12.817 | 19 | 96.025 |
| 无尺寸约束的本文改进的RED椭圆检测算法 | 0.729 | 4 | 99.163 |
| 本文提出的基于轮廓恢复的椭圆检测算法 | 0.719 | 0 | 100 |
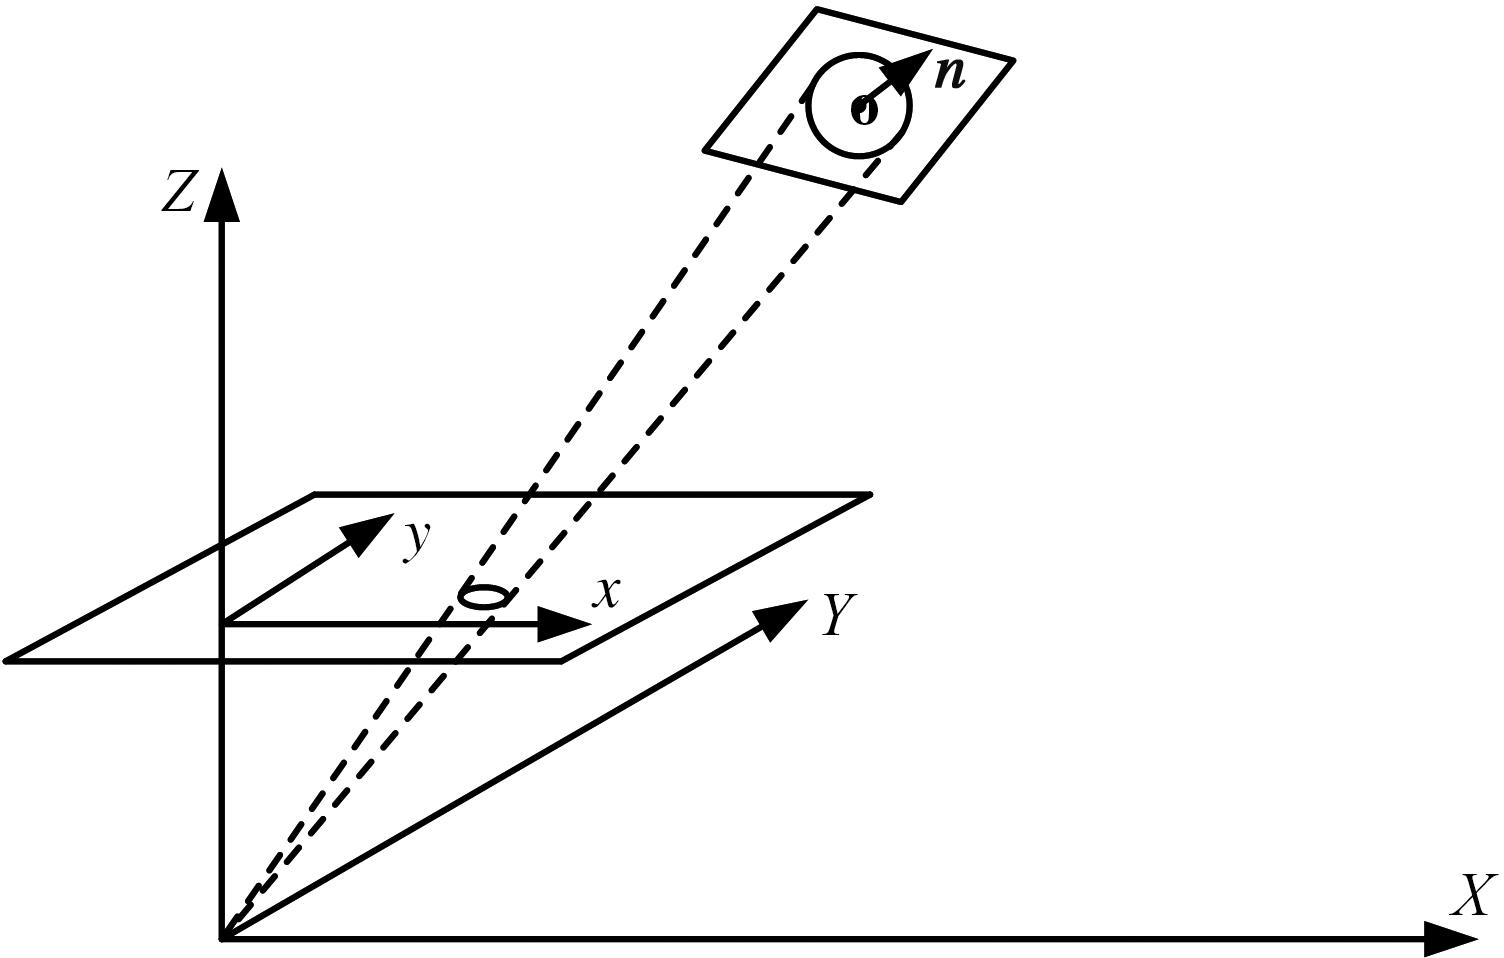
图16 空间圆投影示意图
Fig.16 Space circle projection diagram
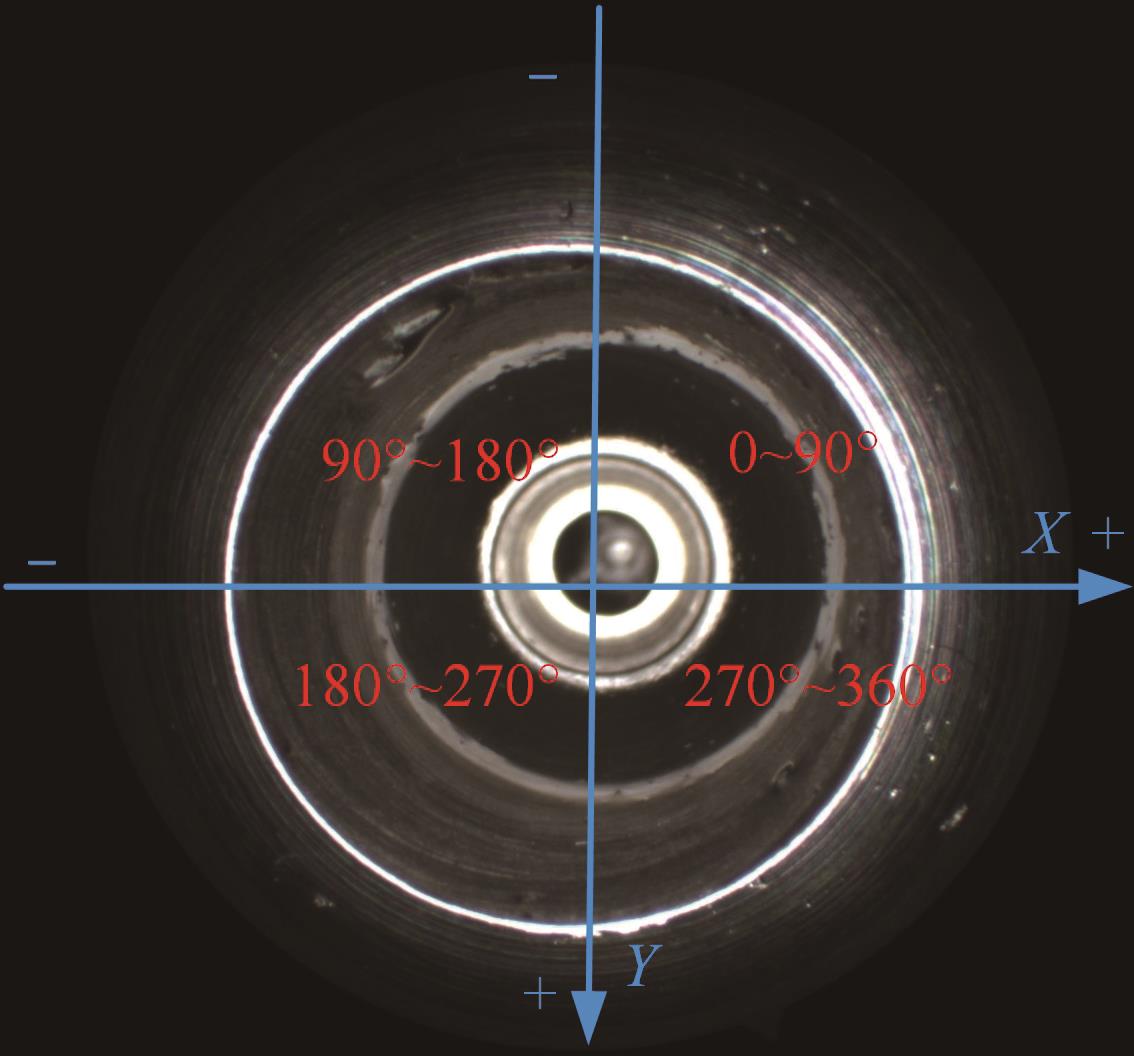
图17 角度范围对应区域示意图
Fig.17 Schematic of the region corresponding to the angle range
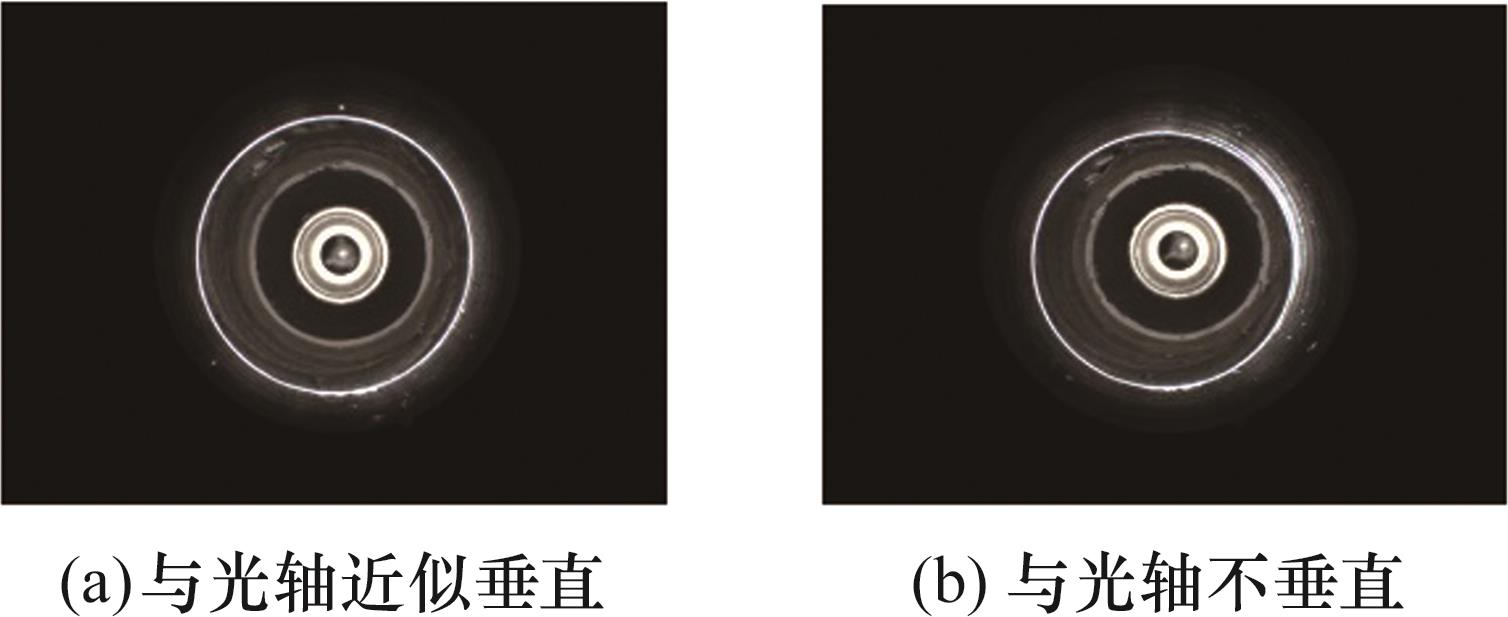
图18 零件不同位姿的端面灰度图
Fig.18 Gray-scale images of end-face with different postures of part
| 真实法向量 | 虚假法向量 | |
|---|---|---|
( 0.009 684 58, | (0.037 875 11, | |
( 0.034 254 27, | (0.073 214 31, |
表4 基于角度约束的二义性判断表
Tab. 4 Ambiguity judgment table based on angle constraint
| 真实法向量 | 虚假法向量 | |
|---|---|---|
( 0.009 684 58, | (0.037 875 11, | |
( 0.034 254 27, | (0.073 214 31, |
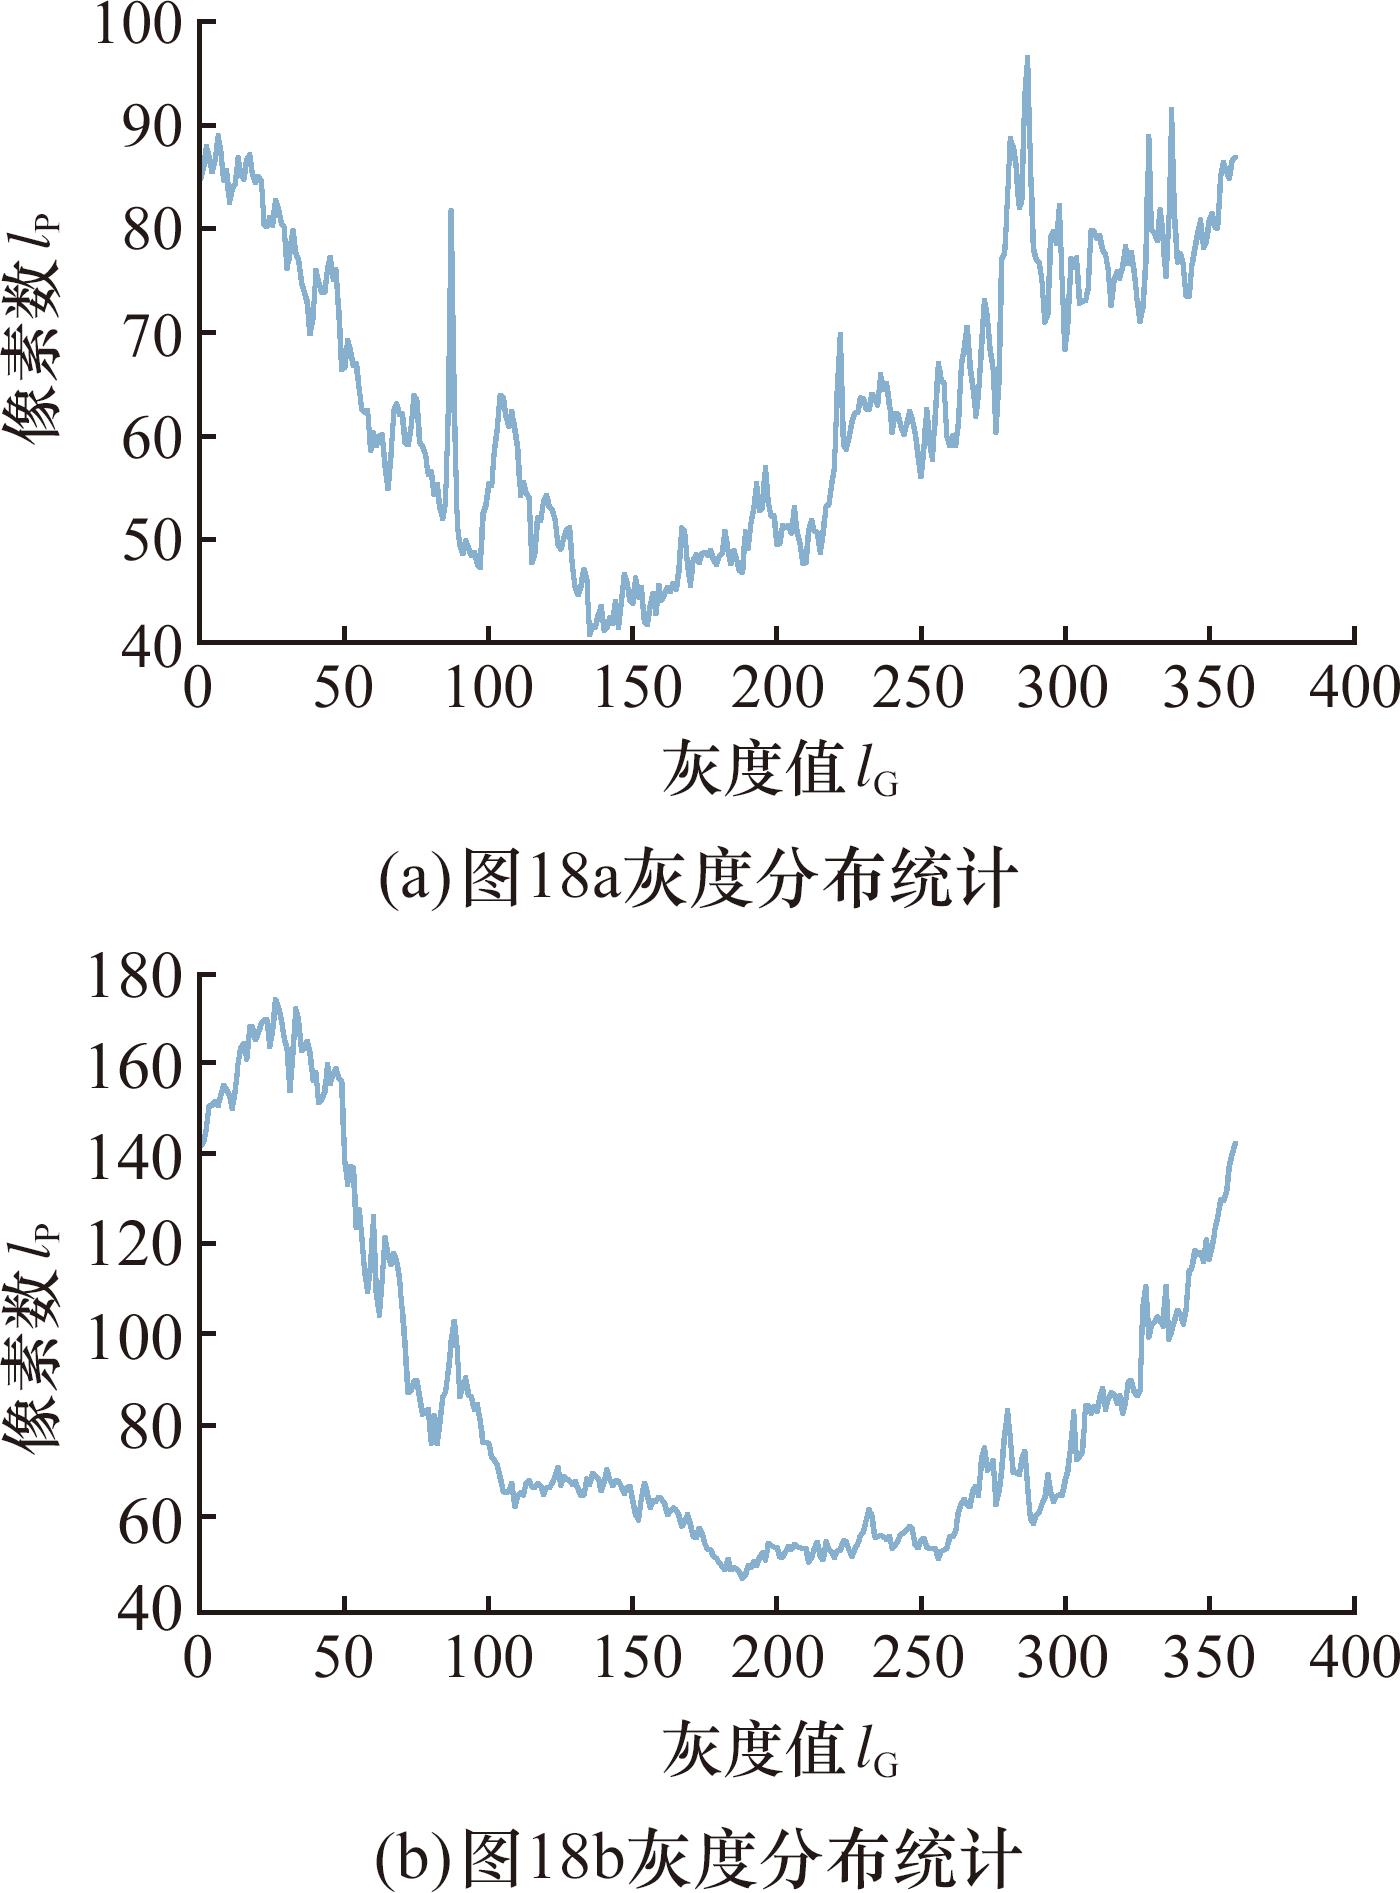
图19 灰度分布图
Fig.19 Gray-scale diagram
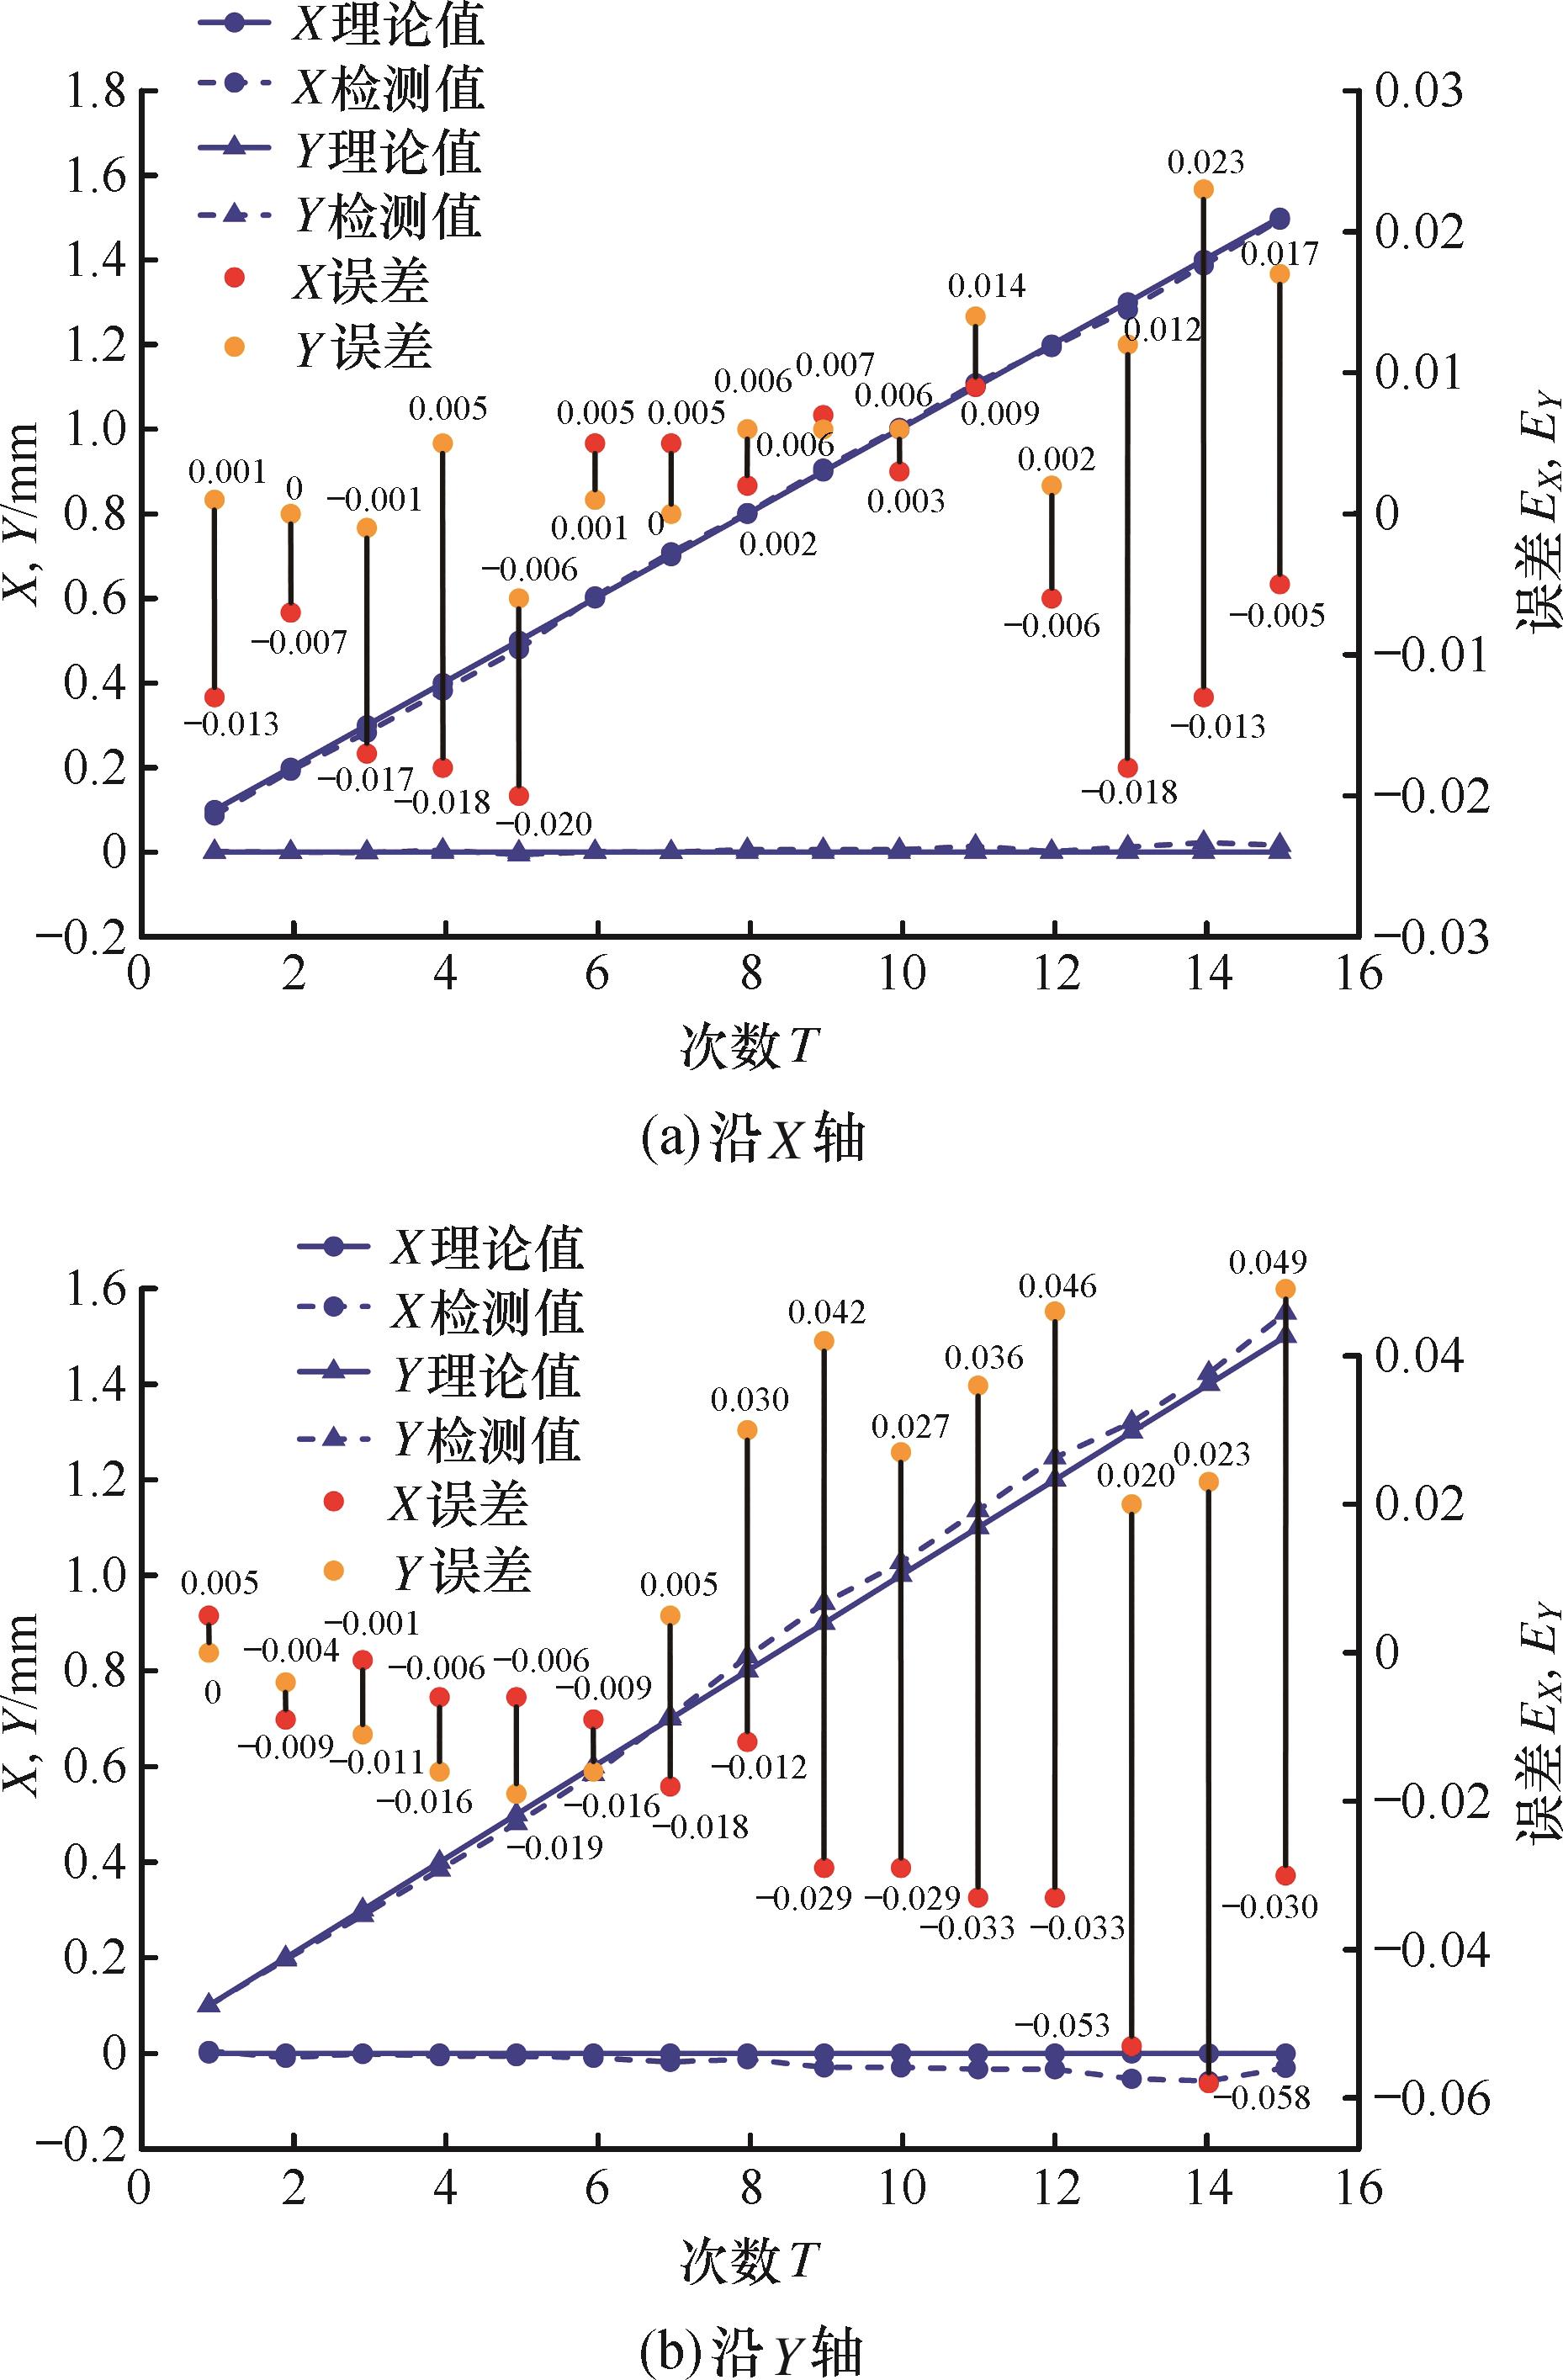
图20 沿XY轴平移时的位姿理论值与检测值
Fig.20 Theoretical and measured values of posture with different translation along XY axis
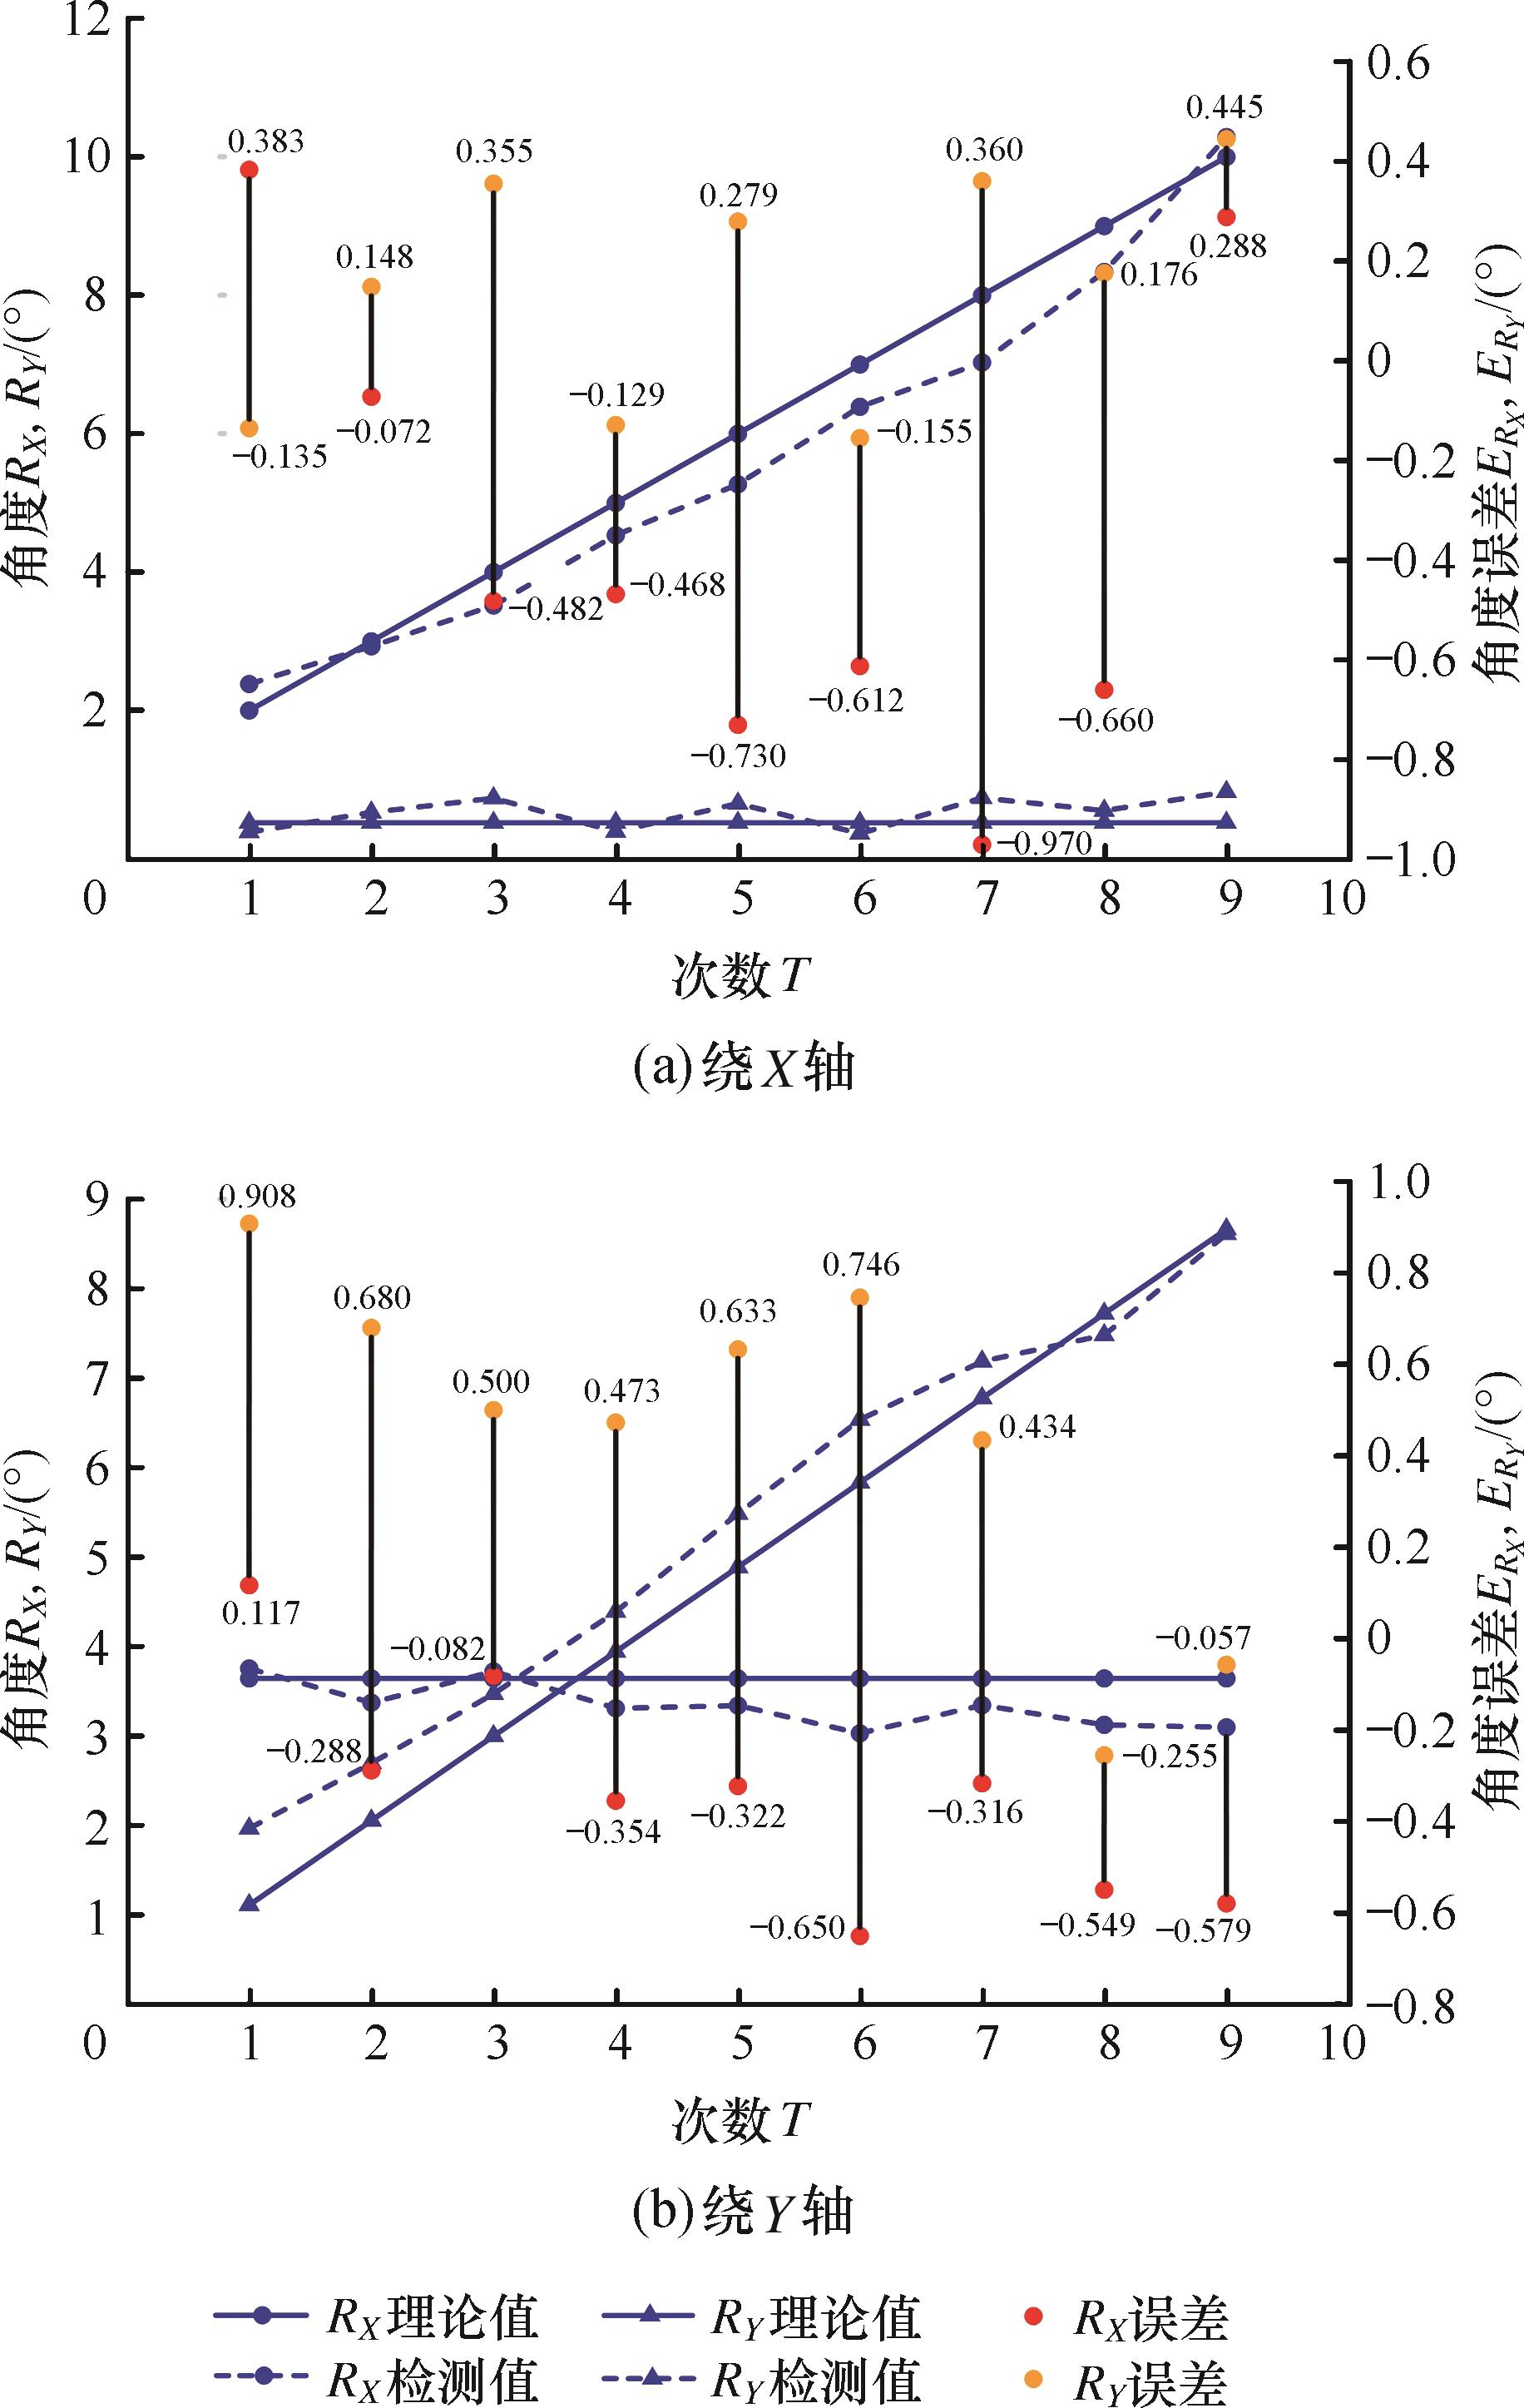
图21 绕轴旋转角度的位姿理论值与检测值
Fig.21 Theoretical and measured values of posture with rotation angles around the axis
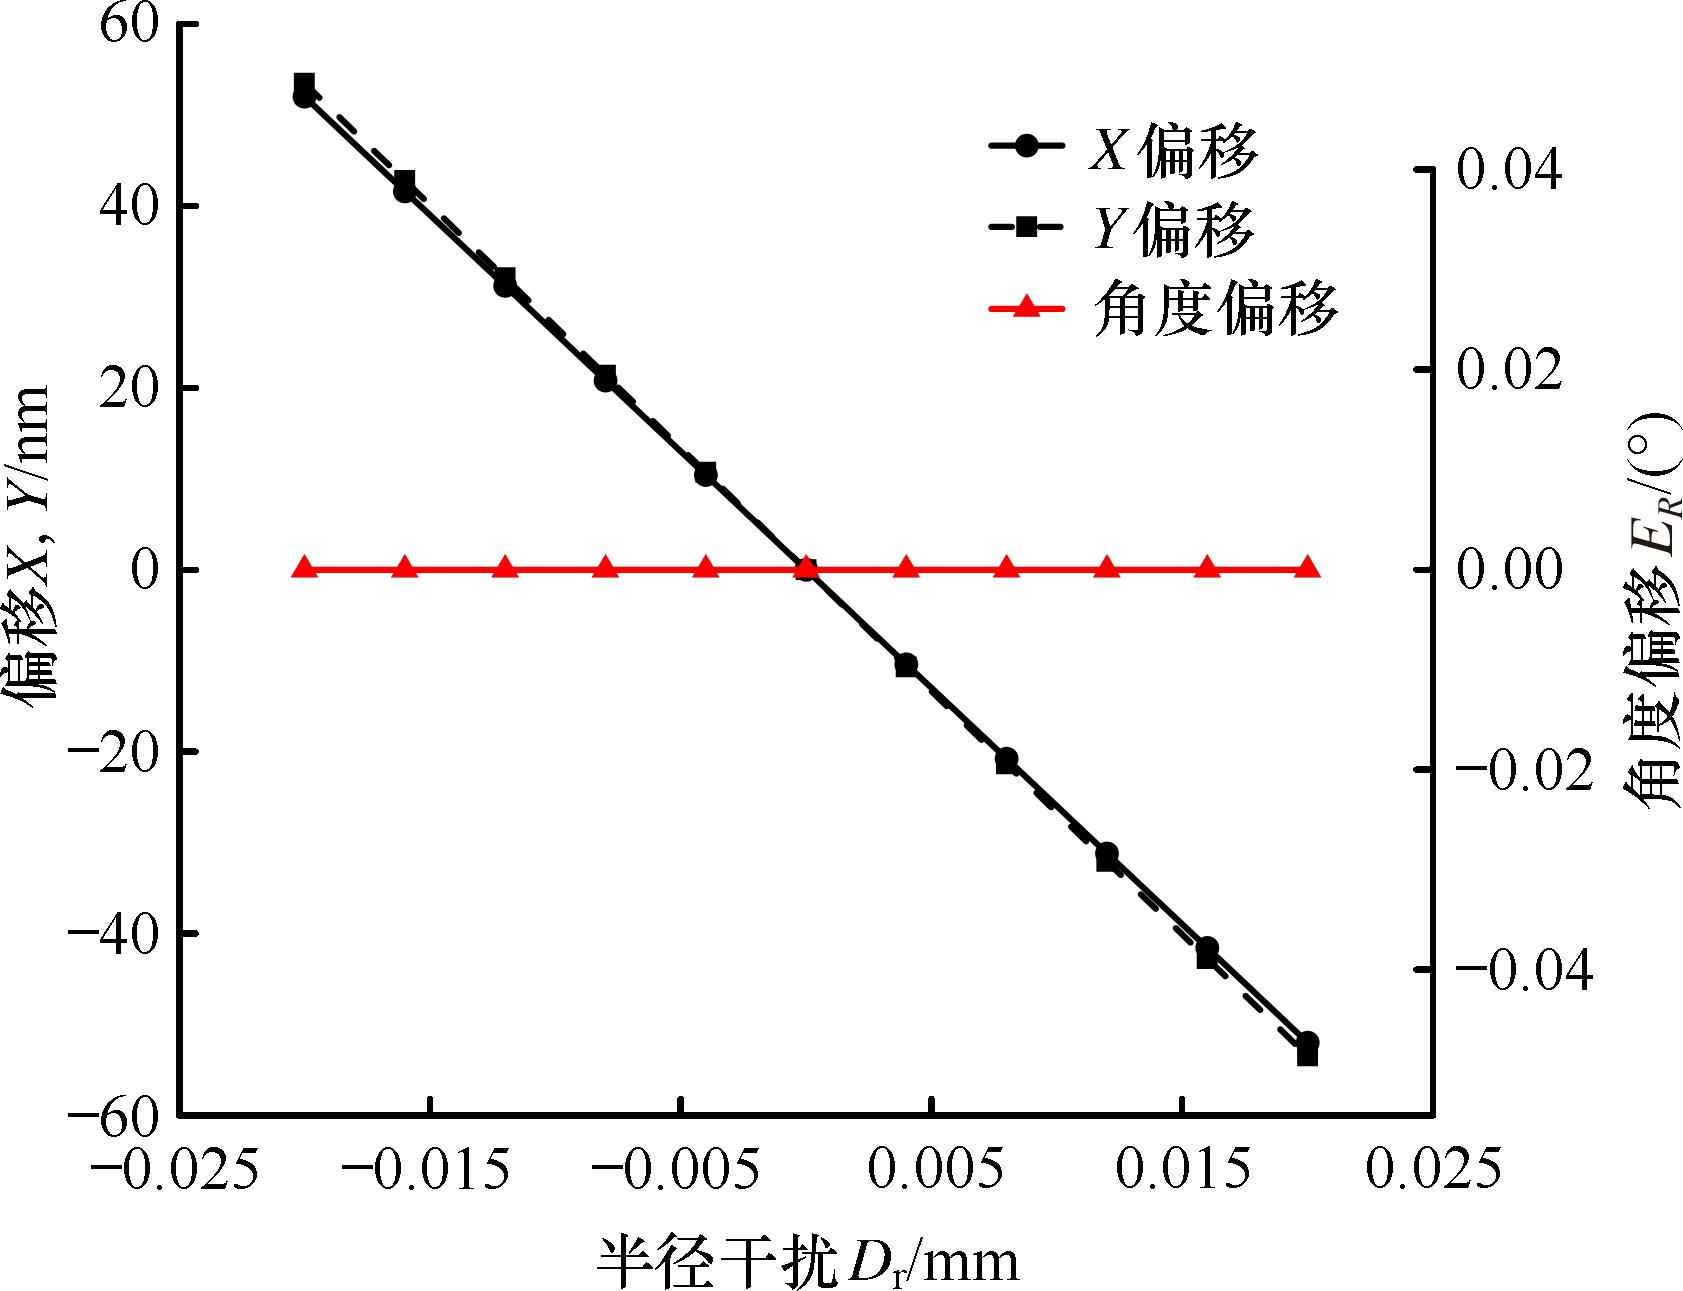
图22 半径的干扰影响
Fig.22 Influence of radius disturbance
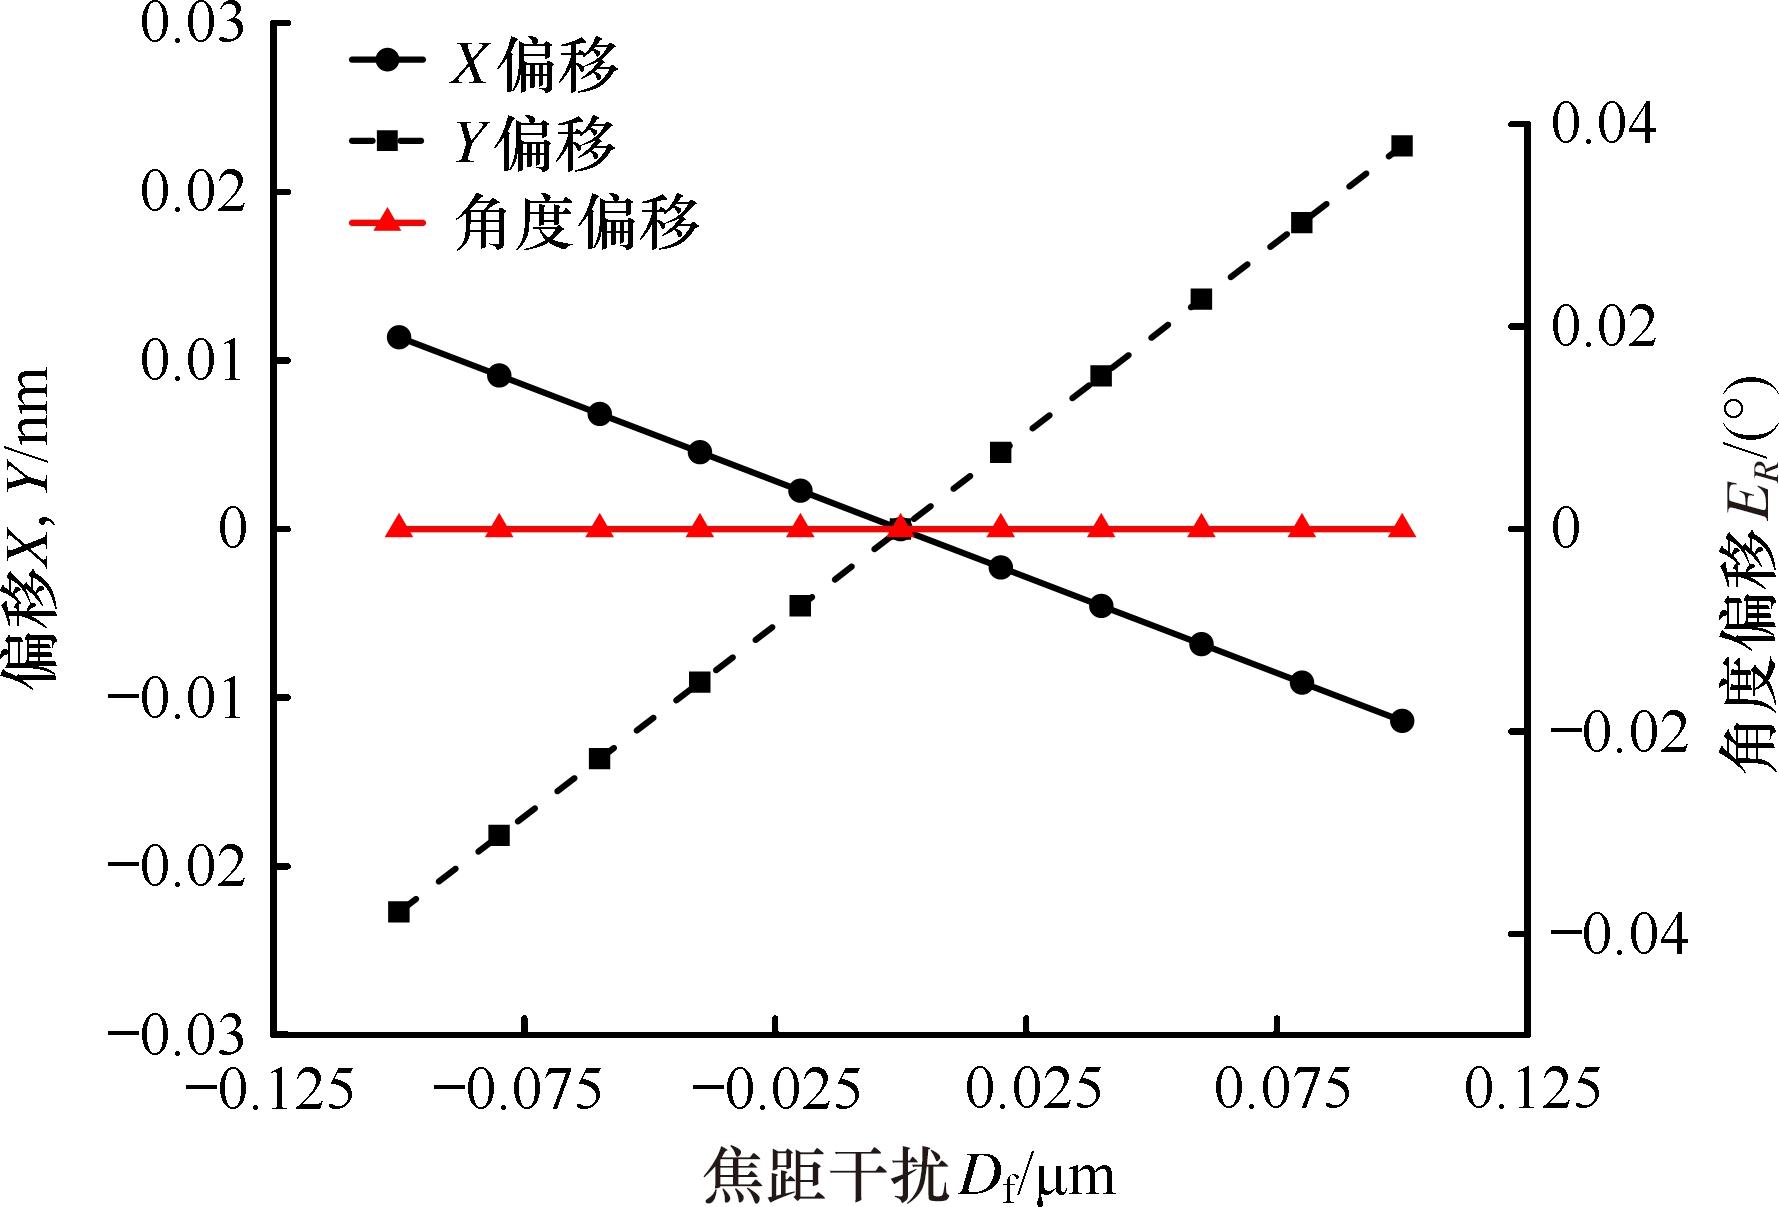
图23 焦距的干扰影响
Fig.23 Influence of focal disturbance
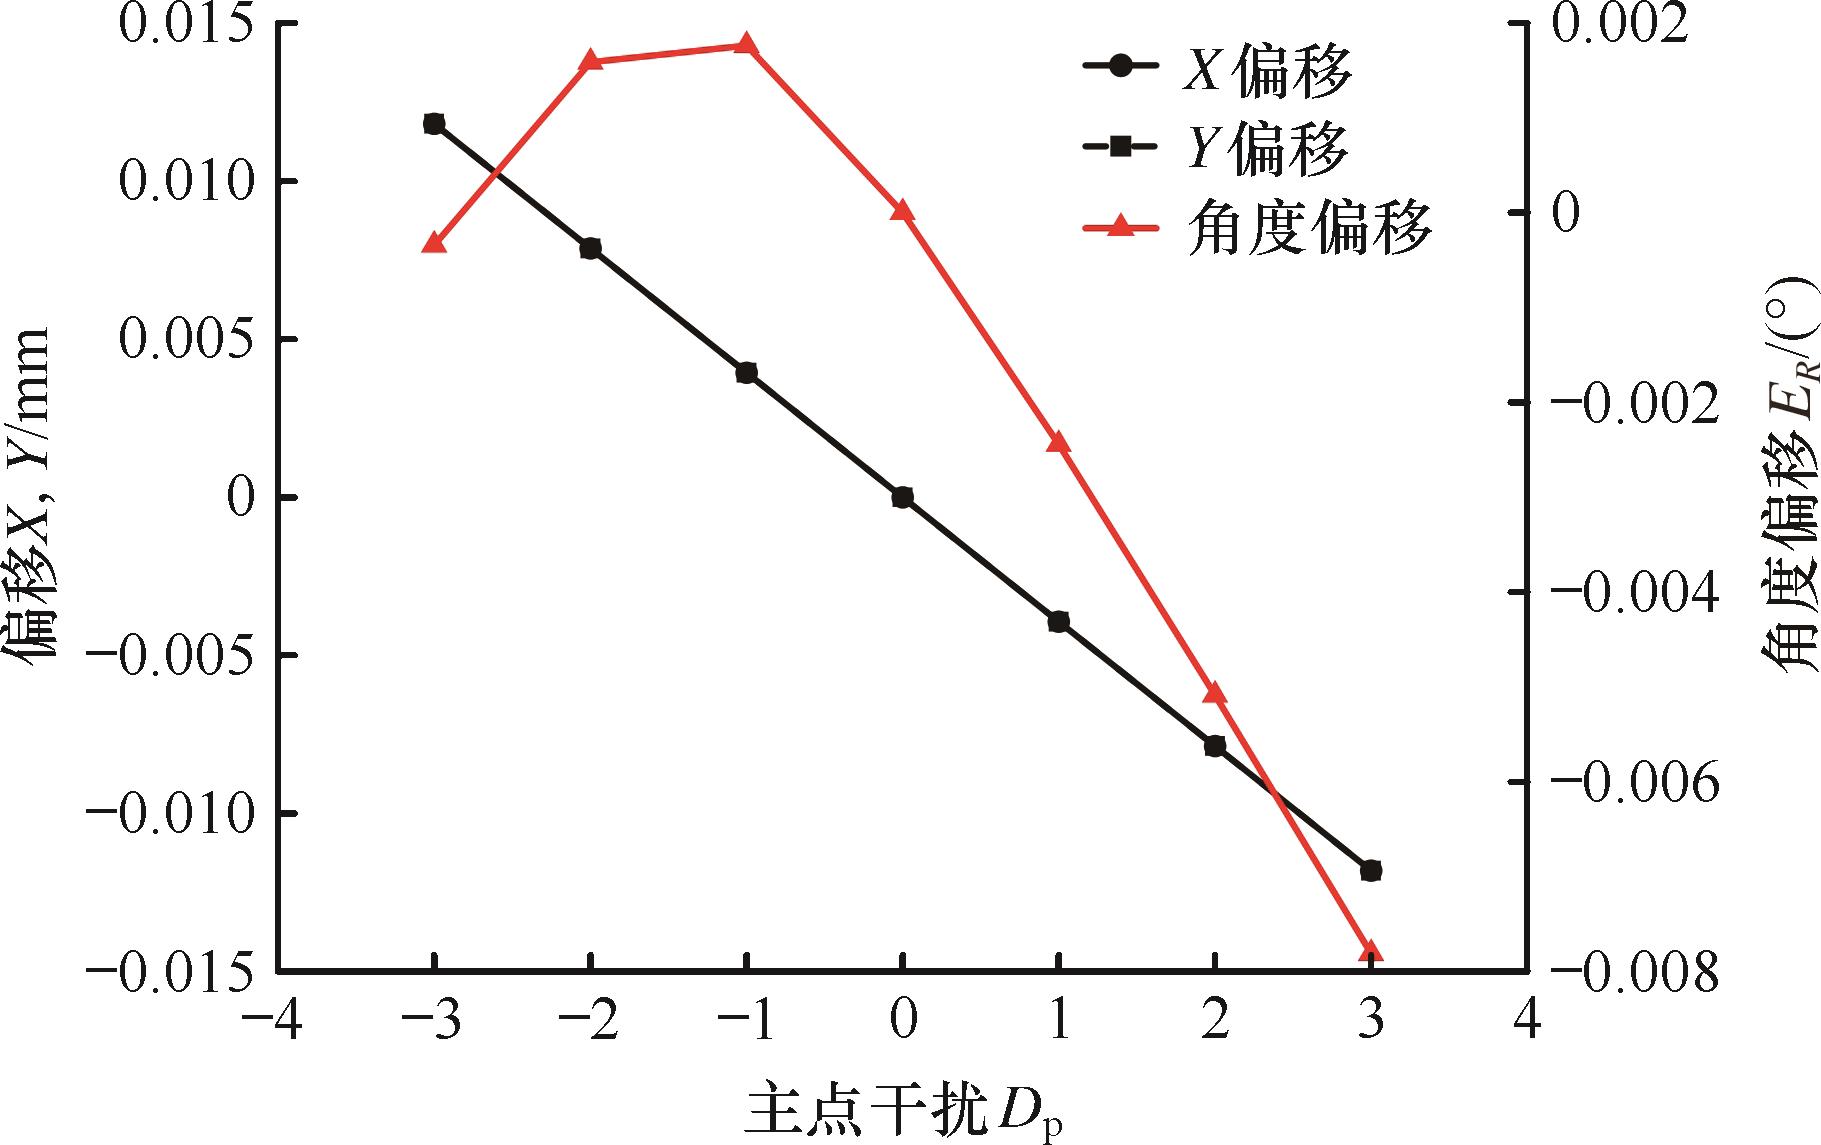
图 24 主点的干扰影响
Fig.24 Influence of principal disturbance
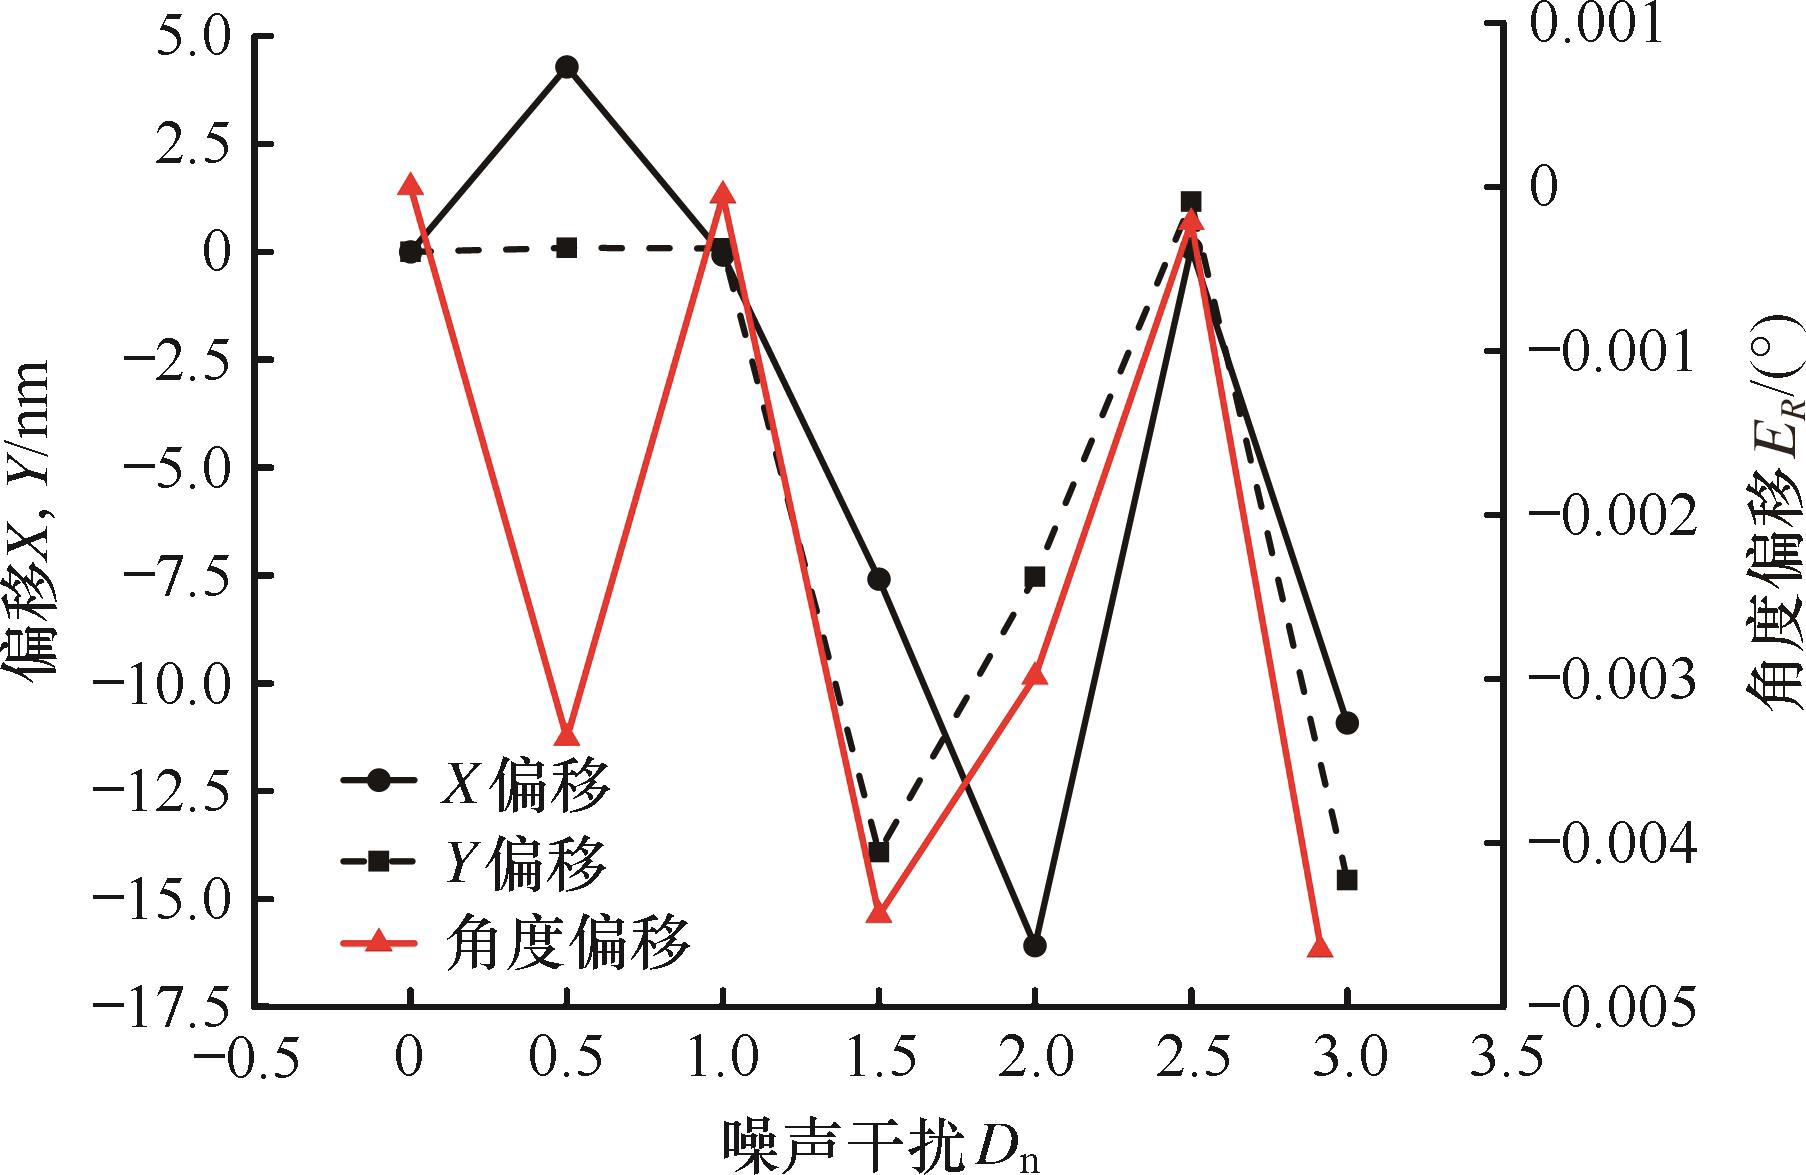
图25 噪声的干扰影响
Fig.25 Influence of noise disturbance
| [1] | 孙露萍, 张文昌, 王志华, 等. 基于2D激光位移传感器的舱段自动对接测量方法[J]. 中国机械工程, 2023, 34(9): 1120-1125. |
| SUN Luping, ZHANG Wenchang, WANG Zhihua, et al. Measurement Method of Cabin Automatic Docking Based on 2D Laser Displacement Sensor[J]. China Mechanical Engineering, 2023, 34(9): 1120-1125. | |
| [2] | 陈栋, 李世其, 王峻峰, 等. 一种以测量关键特征拟合舱段位姿的方法[J]. 中国机械工程, 2019, 30(18): 2250-2256. |
| CHEN Dong, LI Shiqi, WANG Junfeng, et al. A Method for Fitting Pose of Cabins through Measured Key Features[J]. China Mechanical Engineering, 2019, 30(18): 2250-2256. | |
| [3] | 路恩会, 郭耀村, 李世雯, 等. 基于全参考彩色图像质量算法的磨削表面粗糙度测量[J]. 仪器仪表学报, 2023, 44(7): 252-259. |
| LU Enhui, GUO Yaocun, LI Shiwen, et al. Measurement of Grinding Surface Roughness Based on the Full-reference Color Image Quality Algorithm[J]. Chinese Journal of Scientific Instrument, 2023, 44(7): 252-259. | |
| [4] | ZHANG Hang, LI Rong, ZOU Dexiang, et al. An Automatic Defect Detection Method for TO56 Semiconductor Laser Using Deep Convolutional Neural Network[J]. Computers & Industrial Engineering, 2023, 179: 109148. |
| [5] | SUO Xinyu, ZHANG Jie, LIU Jian, et al. Anomaly Detection in Annular Metal Turning Surfaces Based on a Priori Information and a Multi-scale Self-referencing Template[J]. Sensors, 2023, 23(15): 6807. |
| [6] | LI Mengyuan, CHEN Ning, SUO Xinyu, et al. An Efficient Defect Detection Method for Nuclear-fuel Rod Grooves through Weakly Supervised Learning[J]. Measurement, 2023, 222: 113708. |
| [7] | 刘坚, 王媛媛. 一种面向球姿态检测的图像透视畸变校正方法[J]. 中国机械工程, 2019, 30(18): 2242-2249. |
| LIU Jian, WANG Yuanyuan. A Method of Image Perspective Distortion Correction in Ball Pose Detections[J]. China Mechanical Engineering, 2019, 30(18): 2242-2249. | |
| [8] | 房运涛, 王晓东, 徐松, 等. 万向支架微小螺纹副自动装配系统[J]. 中国机械工程, 2022, 33(6): 698-706. |
| FANG Yuntao, WANG Xiaodong, XU Song, et al. Miniature Thread Pairs Automatic Assembly System for Gimbals[J]. China Mechanical Engineering, 2022, 33(6): 698-706. | |
| [9] | 黄鹏, 郑淇, 梁超. 图像分割方法综述[J]. 武汉大学学报(理学版), 2020, 66(6): 519-531. |
| HUANG Peng, ZHENG Qi, LIANG Chao. Overview of Image Segmentation Methods[J]. Journal of Wuhan University (Natural Science Edition), 2020, 66(6): 519-531. | |
| [10] | GANDER W, GOLUB G H, STREBEL R. Least-squares Fitting of Circles and Ellipses[J]. BIT Numerical Mathematics, 1994, 34(4): 558-578. |
| [11] | LU Changsheng, XIA Siyu, SHAO Ming, et al. Arc-support Line Segments Revisited: an Efficient High-quality Ellipse Detection[J]. IEEE Transactions on Image Processing, 2020, 29: 768-781. |
| [12] | 李良福, 冯祖仁, 贺凯良. 一种基于随机Hough变换的椭圆检测算法研究[J]. 模式识别与人工智能, 2005, 18(4): 459-464. |
| LI Liangfu, FENG Zuren, HE Kailiang. An Improved Algorithm for Ellipses Detection Based on Randomized Hough Transform[J]. Pattern Recognition and Artificial Intelligence, 2005, 18(4): 459-464. | |
| [13] | 苗锡奎, 朱枫, 丁庆海, 等. 基于星箭对接环部件的飞行器单目视觉位姿测量方法[J]. 光学学报, 2013, 33(4): 412006. |
| MIAO Xikui, ZHU Feng, DING Qinghai, et al. Monocular Vision Pose Measurement Based on Docking Ring Component[J]. Acta Optica Sinica, 2013, 33(4): 412006. | |
| [14] | MENG Cai, LI Zhaoxi, SUN Hongchao, et al. Satellite Pose Estimation via Single Perspective Circle and Line[J]. IEEE Transactions on Aerospace and Electronic Systems, 2018, 54(6): 3084-3095. |
| [15] | ZHANG Dezhi, YANG Guocai, JI Junhong, et al. Pose Measurement and Motion Estimation of Non-cooperative Satellite Based on Spatial Circle Feature[J]. Advances in Space Research, 2023, 71(3): 1721-1734. |
| [16] | HUANG Bin, SUN Yongrong, ZHU Yunfeng, et al. Vision Pose Estimation from Planar Dual Circles in a Single Image[J]. Optik, 2016, 127(10): 4275-4280. |
| [17] | MA Xin, FENG Junbing, LI Yibin, et al. Active 6-D Position-pose Estimation of a Spatial Circle Using Monocular Eye-in-Hand System[J]. International Journal of Advanced Robotic Systems, 2018, 15: 1729881417753692. |
| [18] | 王斌, 吴丹, 盖宇航. 面向机器人精密装配的高精度圆片位姿视觉检测[J]. 机械工程学报, 2023, 59(8): 50-59. |
| WANG Bin, WU Dan, GAI Yuhang. High-precision Wafer Pose Visual Detection for Robot Precise Assembly[J]. Journal of Mechanical Engineering, 2023, 59(8): 50-59. | |
| [19] | 于长志, 张连新, 孙鹏飞, 等. 基于法向约束的背靠视觉端面对接定位方法[J]. 计算机工程, 2022, 48(9): 213-222. |
| YU Changzhi, ZHANG Lianxin, SUN Pengfei, et al. End-face Butt-joint Positioning Method with Back Against Vision Based on Normal Constraint[J]. Computer Engineering, 2022, 48(9): 213-222. | |
| [20] | LI Shunzhi, LIANG Bin, GAO Xuehai, et al. Pose Measurement Method of Non-cooperative Circular Feature Based on Line Structured Light[C]∥2016 IEEE International Conference on Information and Automation (ICIA).Changsha, 2016: 374-380. |
| [21] | MA Yanqin, LIU Xilong, XU De. Precision Pose Measurement of an Object with Flange Based on Shadow Distribution[J]. IEEE Transactions on Instrumentation and Measurement, 2020, 69(5): 2003-2015. |
| [22] | 余厚云, 王慧青, 张辉, 等. 产品表面质量视觉检测中的相机位姿自动校准[J]. 东南大学学报(自然科学版), 2020, 50(5): 942-949. |
| YU Houyun, WANG Huiqing, ZHANG Hui, et al. Automatic Calibration of Camera Pose in Visual Inspection of Product Surface Quality[J]. Journal of Southeast University (Natural Science Edition), 2020, 50(5): 942-949. | |
| [23] | 田光宝, 王见, 王博文. 单目相机非合作目标提取及位姿检测[J]. 红外与激光工程, 2021, 50(12): 20210166. |
| TIAN Guangbao, WANG Jian, WANG Bowen. Monocular Camera Non-cooperative Target Extraction and Pose Detection[J]. Infrared and Laser Engineering, 2021, 50(12): 20210166. | |
| [24] | LIU Yang, XIE Zongwu, LIU Hong. Fast and Robust Ellipse Detector Based on Edge Following Method[J]. IET Image Processing, 2019, 13(13): 2409-2419. |
| [25] | 闫蓓, 王斌, 李媛. 基于最小二乘法的椭圆拟合改进算法[J]. 北京航空航天大学学报, 2008, 34(3): 295-298. |
| YAN Bei, WANG Bin, LI Yuan. Optimal Ellipse Fitting Method Based on Least-square Principle[J]. Journal of Beijing University of Aeronautics and Astronautics, 2008, 34(3): 295-298. |
| [1] | 刘送永1, 吴洪状2, 程诚2, 宋明江1, 3, 崔玉明4. 煤矿掘进机自定位截割控制方法及试验研究[J]. 中国机械工程, 2024, 35(07): 1318-1329. |
| [2] | 王福斌1, 2;孙海洋1;TU Paul2. 边缘扩展的皮带撕裂支持向量机视觉检测[J]. 中国机械工程, 2019, 30(04): 455-460. |
| [3] | 洪波1,2;尹力1,2;李毅1,2;李湘文1,2. 基于激光位移传感器的角焊缝位姿检测[J]. 中国机械工程, 2017, 28(24): 3013-3016,3023. |
| [4] | 郭力, 江志顺, 尚振涛. 基于热像检测与分割技术的磨削砂轮堵塞检测研究[J]. 中国机械工程, 2016, 27(05): 577-583. |
| [5] | 邢丽冬1, 钱志余1, 钱露2, 殷威1, 高慧1, 王欢1. 基于图像跟踪的LED无影灯自动调光方法的研究[J]. 中国机械工程, 2012, 23(8): 923-927. |
| [6] | 刘凌云, 钱新恩, 罗敏. 确定对象单目视觉位姿检测算法的研究 [J]. 中国机械工程, 2010, 21(23): 2825-2829. |
| [7] | 李鹏阳;郝重阳;祝双武;王毅. 基于脉冲耦合神经网络的刀具磨损检测[J]. J4, 2008, 19(5): 0-629. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
