ISSN 1004-132X
CN 42-1294/TH
CN 42-1294/TH
中国机械工程 ›› 2026, Vol. 37 ›› Issue (8): 1865-1874.DOI: 10.3969/j.issn.1004-132X.2026.08.006
• 机械基础工程 • 上一篇
张洪昌1,2,3( ), 闫文博1,2,3, 邹奇展1,2,3, 曾娟1,2,3()
收稿日期:2025-05-21
出版日期:2026-08-25
发布日期:2026-09-17
通讯作者:
曾娟
作者简介:张洪昌,男,1980年生,副教授。研究方向为智能网联汽车关键技术。E-mail:zhc112@126.com
基金资助:
ZHANG Hongchang1,2,3(), YAN Wenbo1,2,3, ZOU Qizhan1,2,3, ZENG Juan1,2,3()
Received:2025-05-21
Online:2026-08-25
Published:2026-09-17
Contact:
ZENG Juan
摘要:
针对换道超车过程中的动态避障问题,提出一种基于单边-逐级引导势场的避障策略。结合三次准均匀B样条曲线构建障碍车单边斥力势场,以更准确地表征障碍车风险,在此基础上建立动态目标引力势场,实现逐级路径引导;提出一种路径点振荡识别与过滤方法,用于抑制因仿真步长偏大引起的路径振荡。为保障轨迹跟踪精度,基于二自由度车辆动力学模型和线性二次型调节器 (LQR)控制理论,设计了带有前馈控制量的LQR预测控制器。最后进行MATLAB/Simulink与CarSim联合仿真及硬件在环实验,结果表明:所提方法横向跟踪误差均值小于0.08 m,前轮转角与质心侧偏角等关键动力学指标的均值与峰值较传统人工势场法下降18% ~ 25%,超车完成距离平均缩短10.3%,验证了所提策略的有效性与安全性。
中图分类号:
张洪昌, 闫文博, 邹奇展, 曾娟. 基于单边-逐级引导势场的超车避障研究[J]. 中国机械工程, 2026, 37(8): 1865-1874.
ZHANG Hongchang, YAN Wenbo, ZOU Qizhan, ZENG Juan. Overtaking Obstacle Avoidance Study Based on Unilateral-phase-by-phase Guided Potential Field[J]. China Mechanical Engineering, 2026, 37(8): 1865-1874.
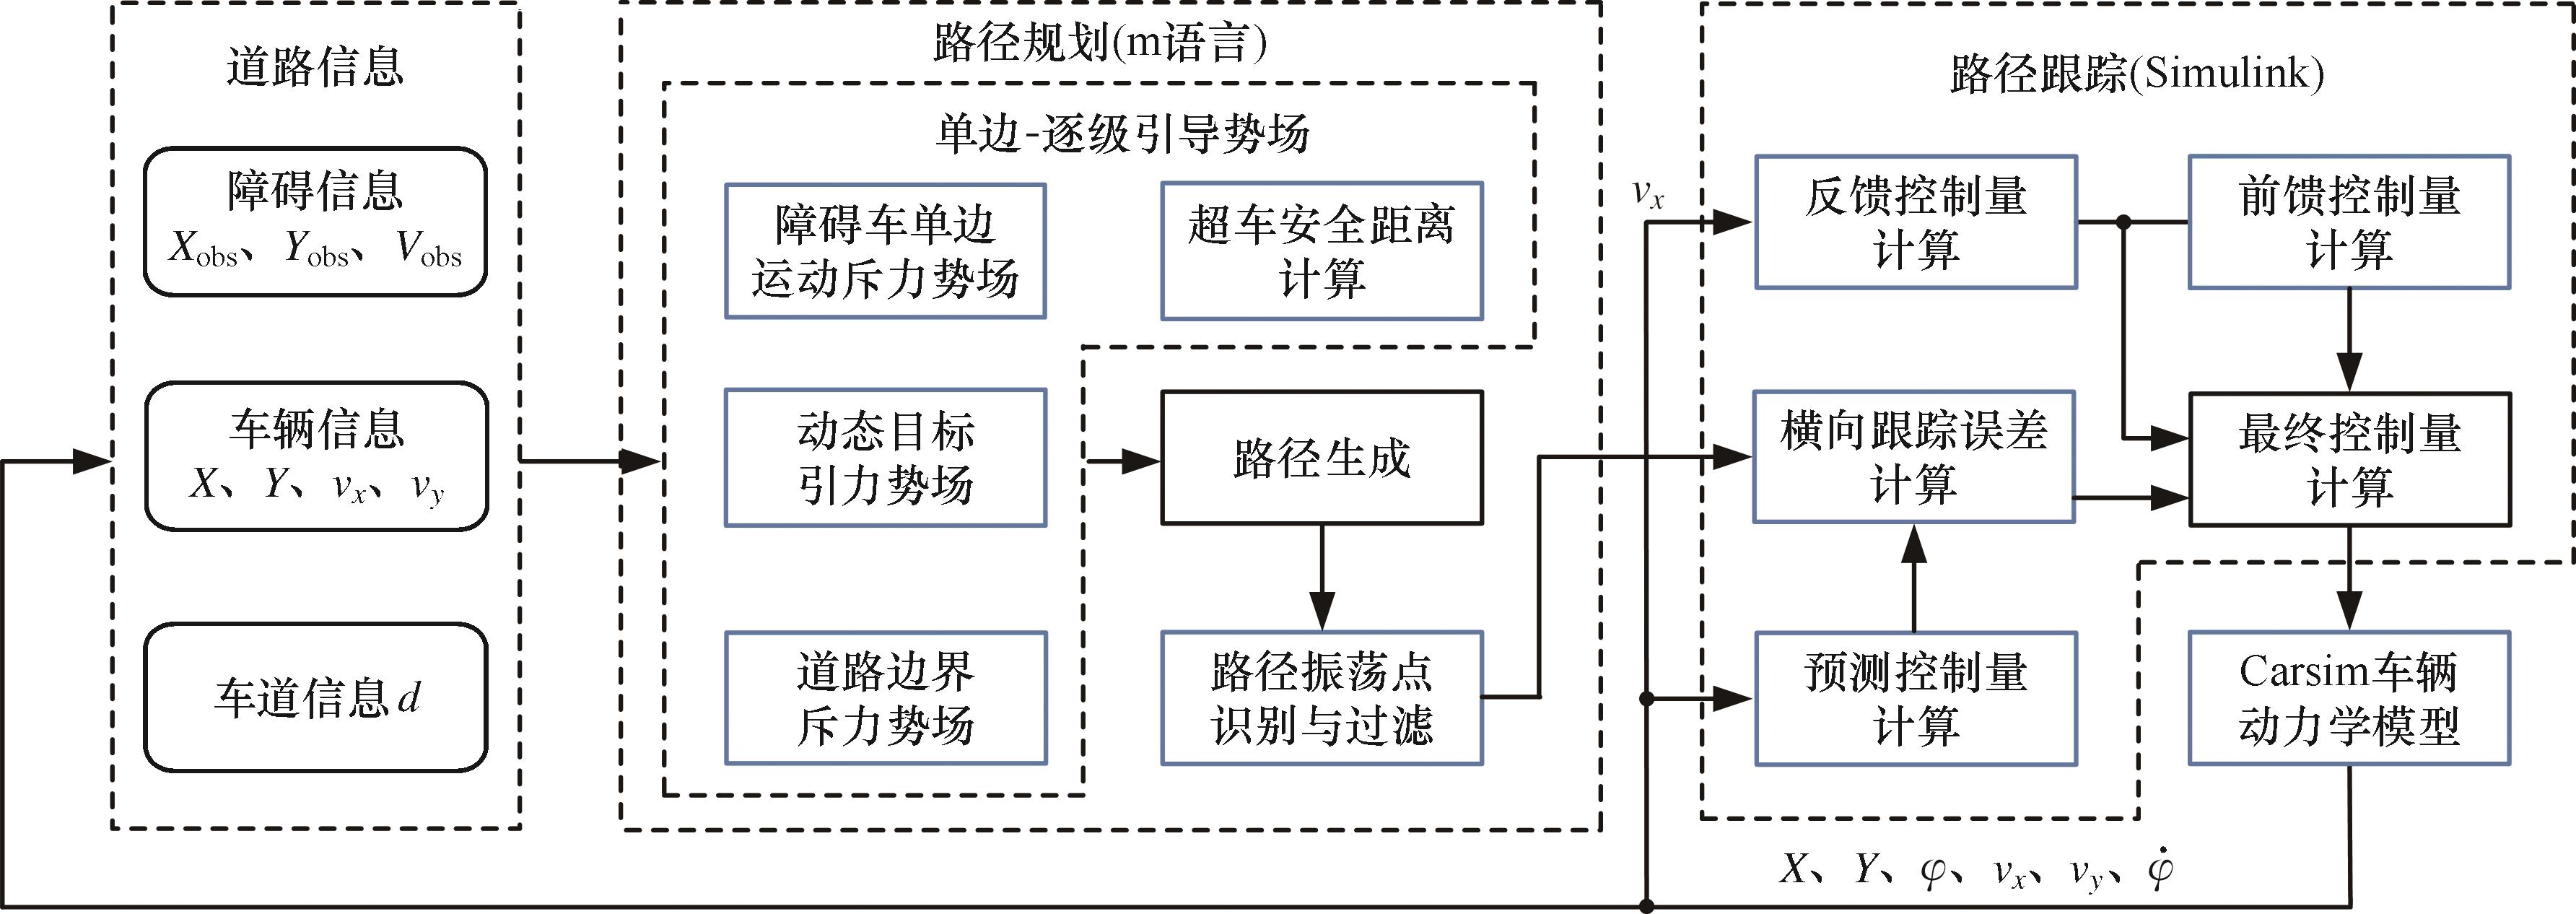
图1 动态避障策略结构框图
Fig.1 Structural block diagram of dynamic obstacle avoidance strategy
| tTC取值范围/s | 等级 |
|---|---|
| (5,+∞) | 一级(无危险) |
| (3,5] | 二级(紧急) |
| (1,3] | 三级(紧迫) |
| (-∞,1] | 四级(濒临碰撞) |
表1 按tTC划分的危险场景等级
Tab.1 Classification of hazard scenarios based on tTC
| tTC取值范围/s | 等级 |
|---|---|
| (5,+∞) | 一级(无危险) |
| (3,5] | 二级(紧急) |
| (1,3] | 三级(紧迫) |
| (-∞,1] | 四级(濒临碰撞) |
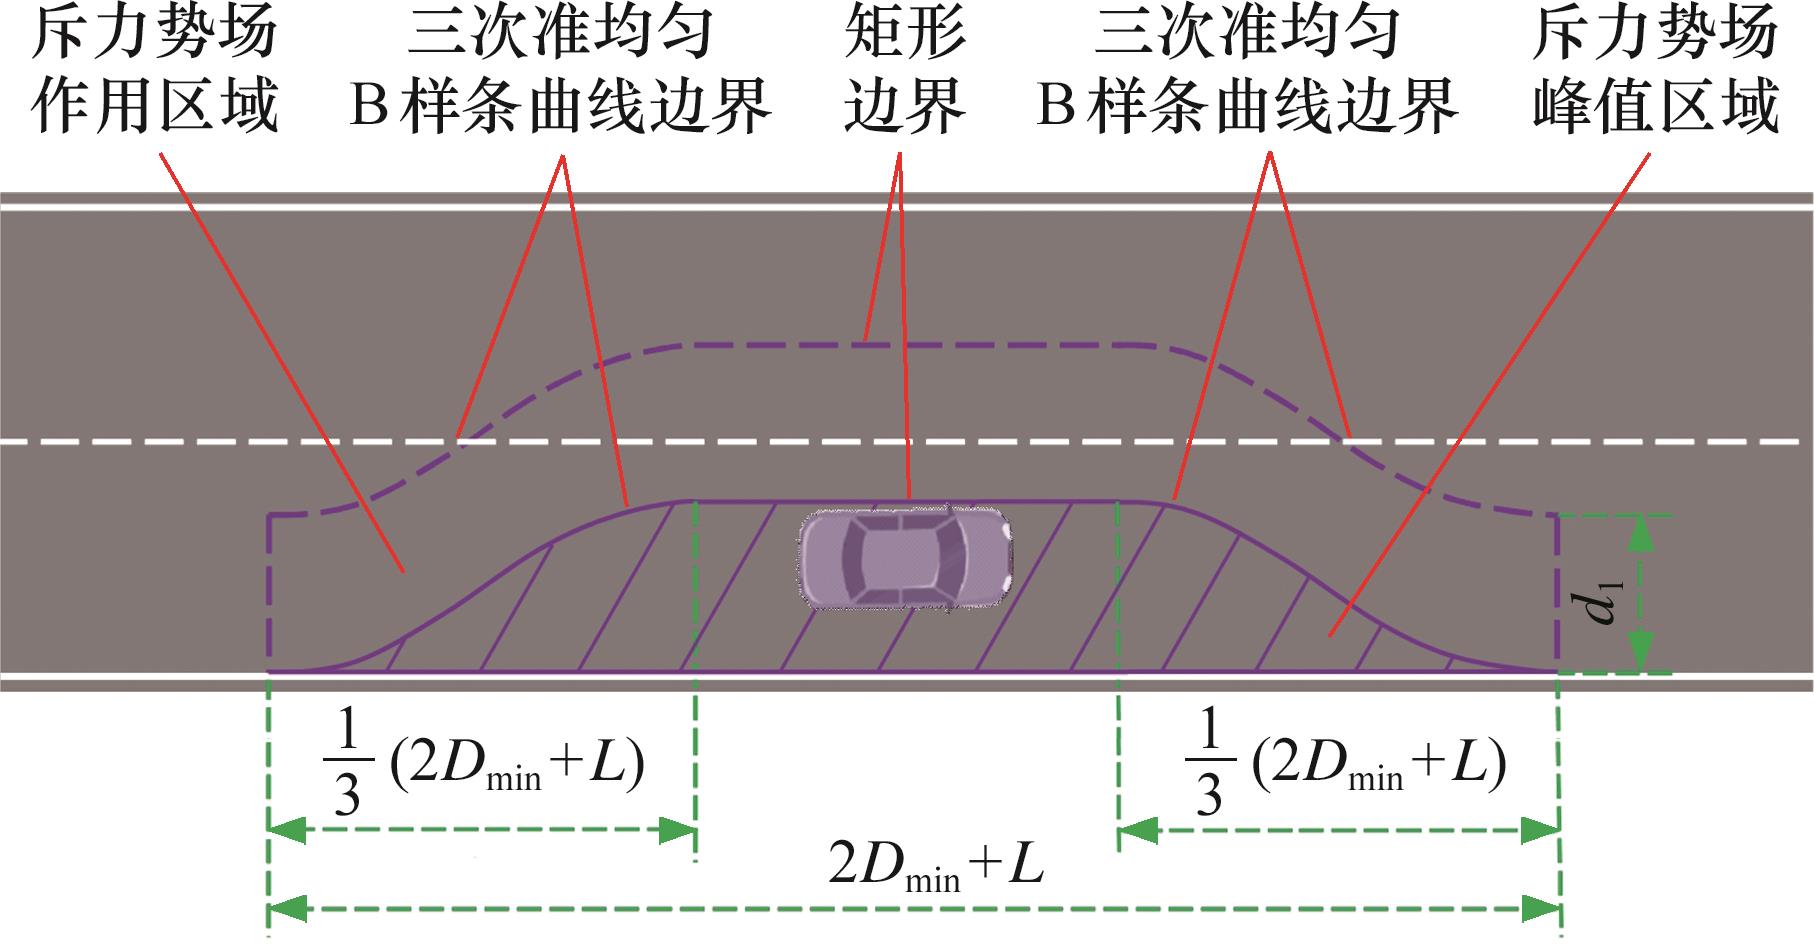
图2 单边运动斥力势场模型
Fig.2 The unilateral motion repulsive potential field model
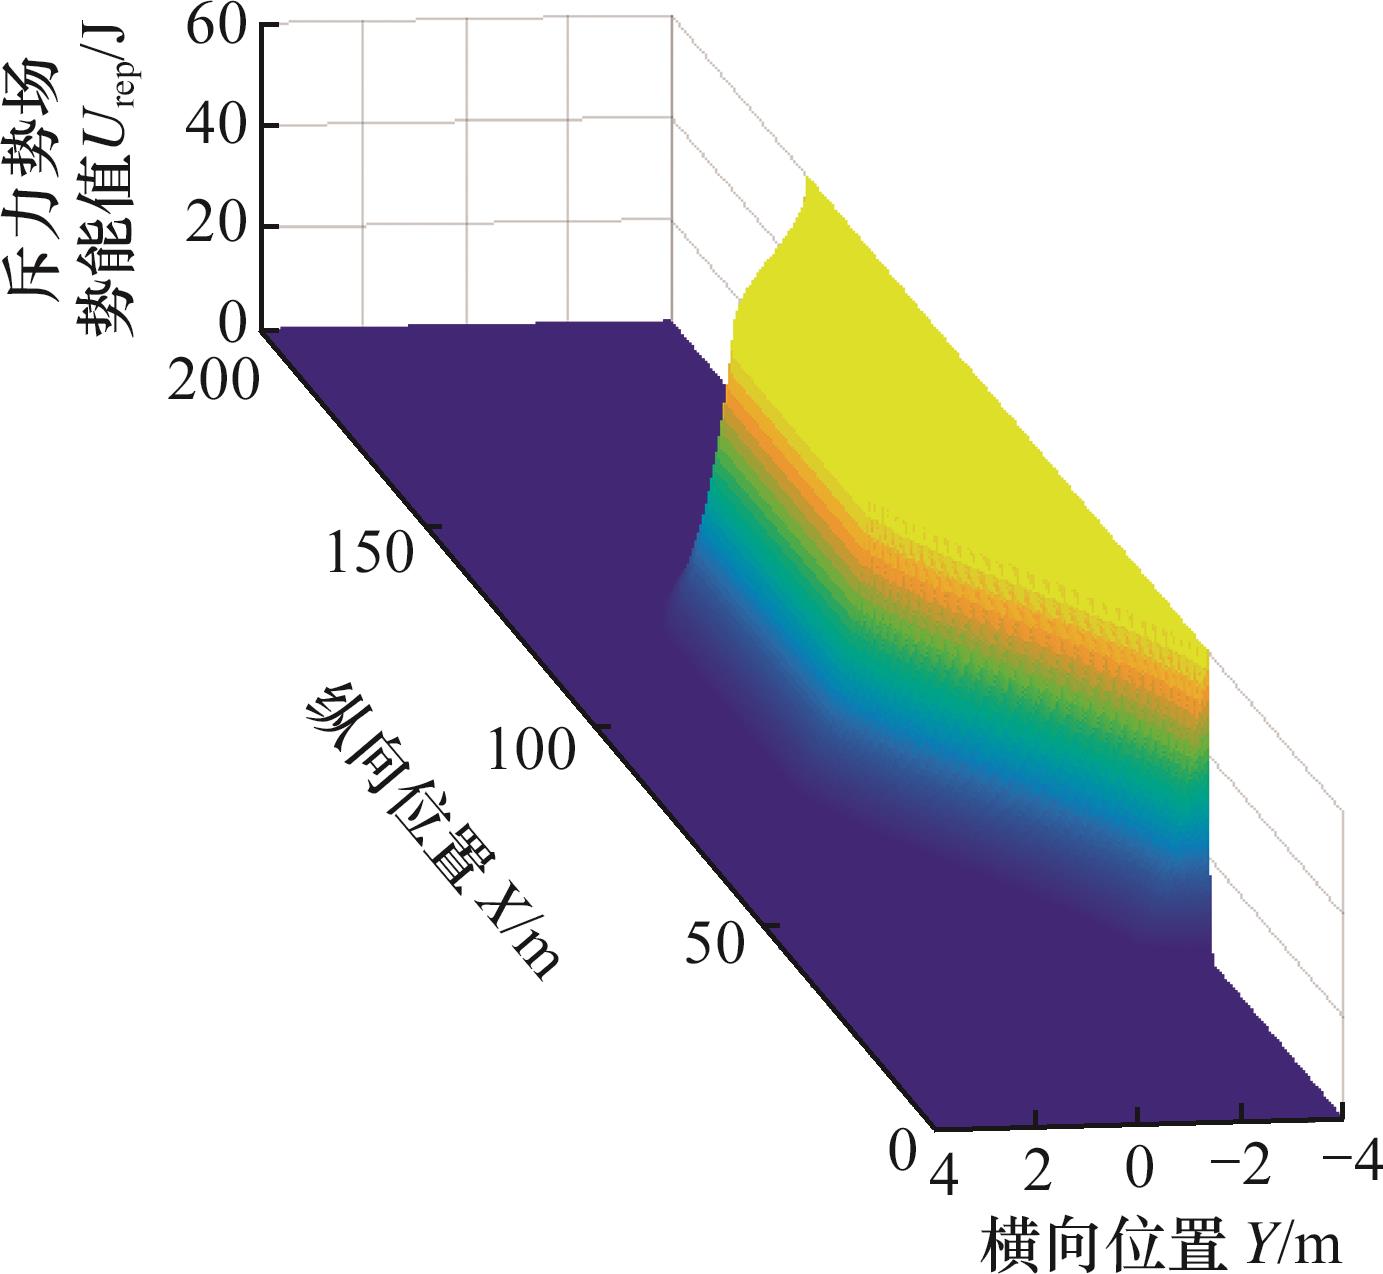
图3 斥力势场三维模型
Fig.3 Three-dimensional model of the repulsive potential field
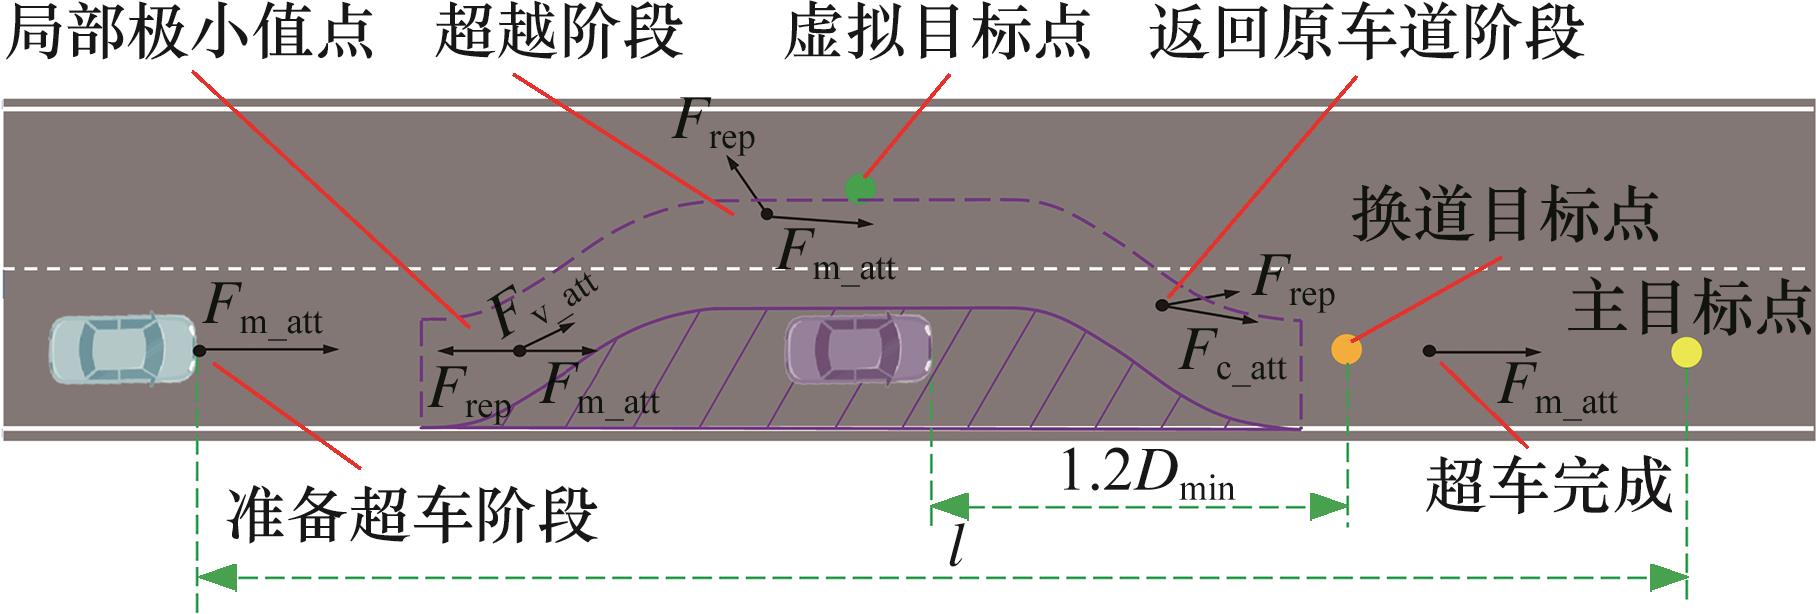
图4 动态目标引力势场模型
Fig.4 The dynamic target attractive potential field model
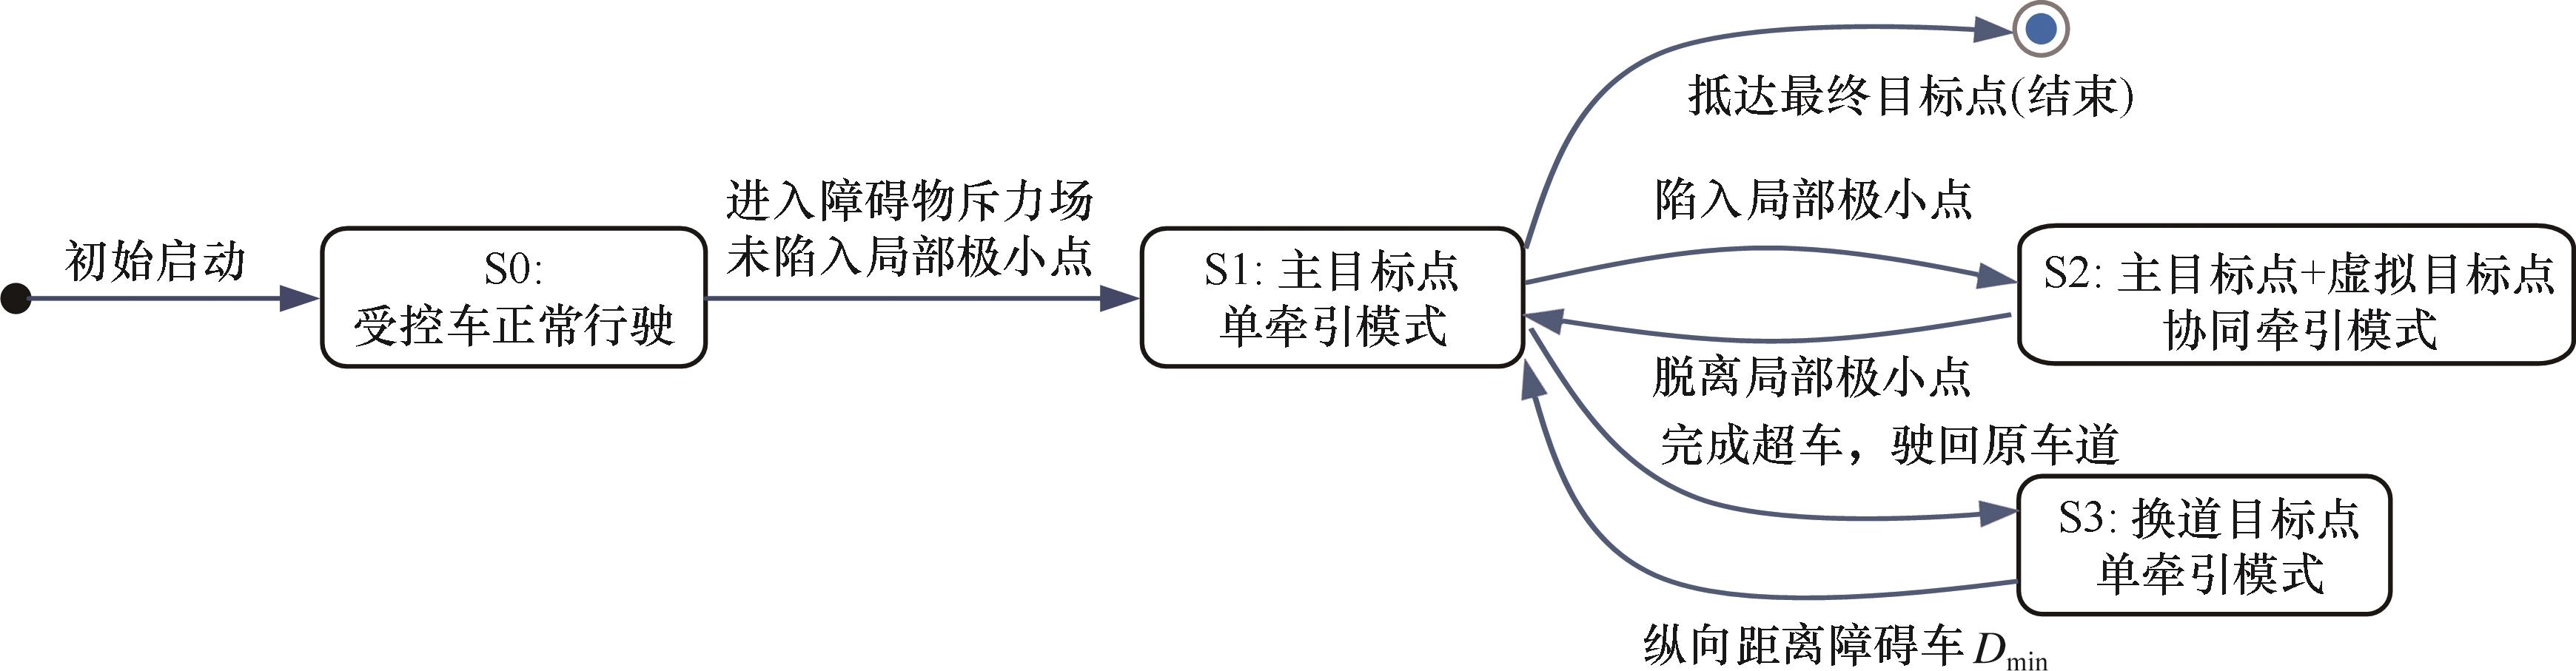
图5 受控车目标点切换示意图
Fig.5 Schematic diagram of target point switching for the controlled vehicle
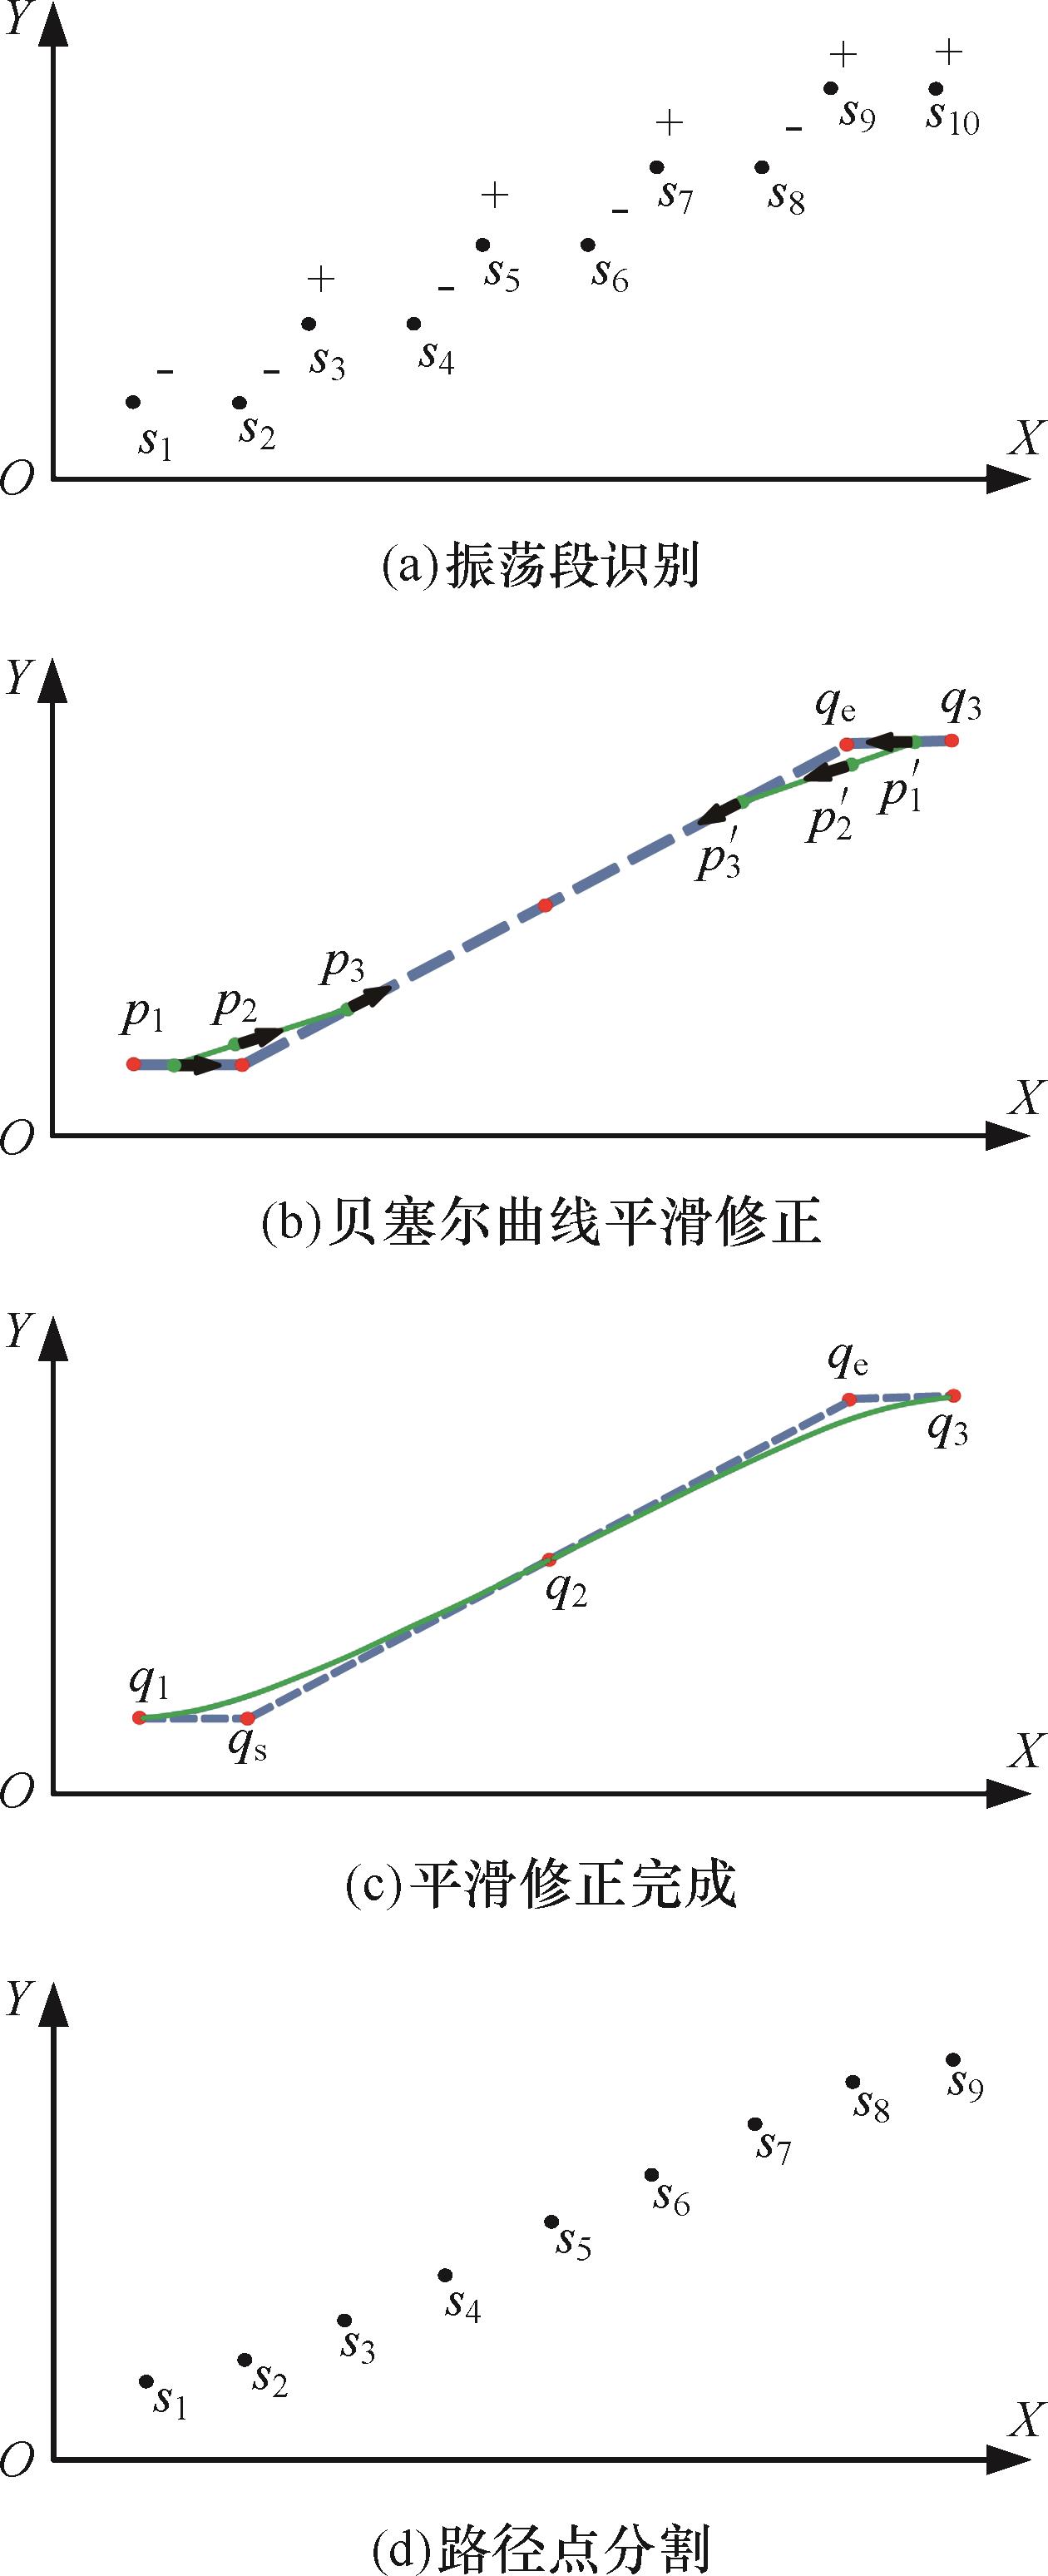
图6 振荡点过滤流程图
Fig.6 Flowchart of oscillation point filtering
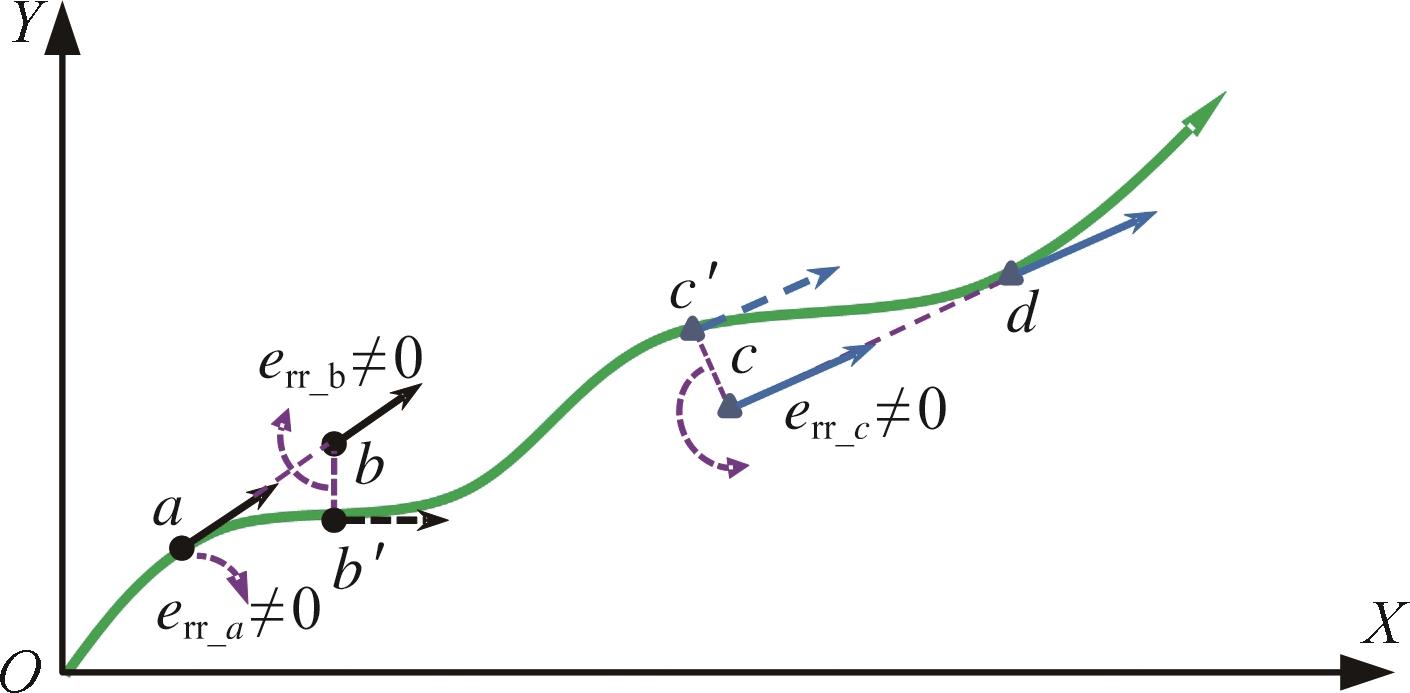
图7 曲线轨迹跟随
Fig.7 Curve trajectory following
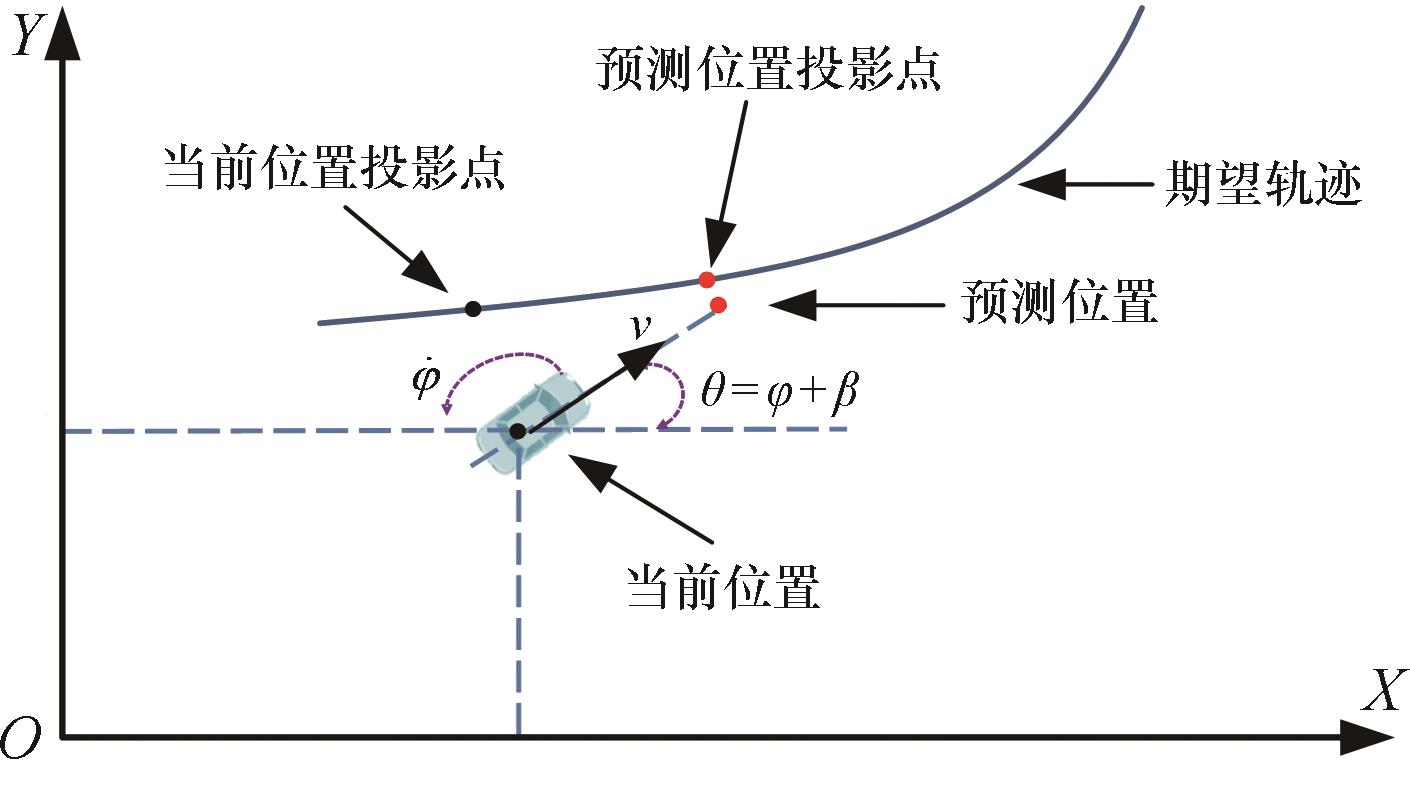
图8 预测模型示意图
Fig.8 Schematic diagram of the prediction model
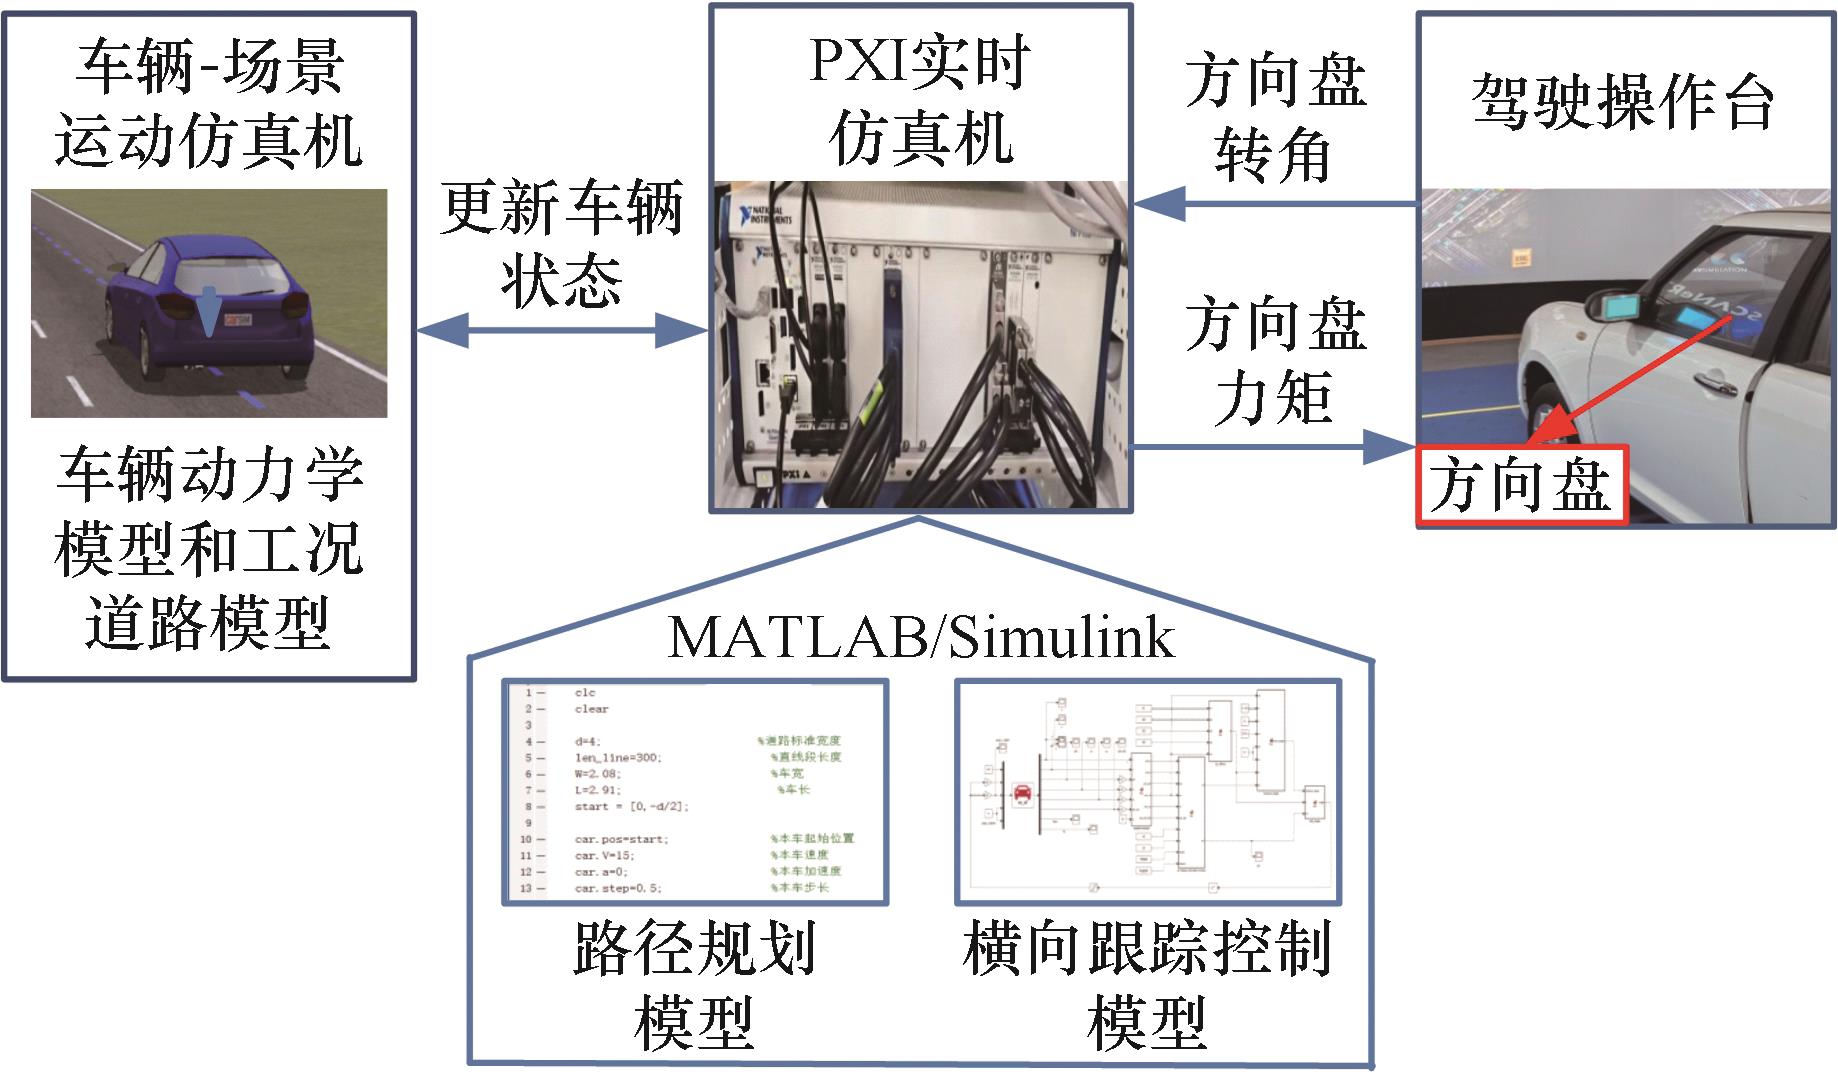
图9 硬件在环仿真实验平台及原理
Fig.9 Hardware-in-the-loop simulation platform and its principle
| 整车质量m/kg | 1413 |
|---|---|
| 车辆长度l/mm | 4670 |
| 车辆宽度w/mm | 2082 |
| 车辆高度h/mm | 1405 |
| 前轮侧偏刚度Cαf/(N·rad | |
| 后轮侧偏刚度Cαr/(N·rad | |
| 质心到前轴距离/mm | 1015 |
| 质心到后轴距离/mm | 1895 |
| Z轴转动惯量IZ /(kg·m | 1536.7 |
表2 车身模型主要参数
Tab.2 Main parameters of the vehicle body model
| 整车质量m/kg | 1413 |
|---|---|
| 车辆长度l/mm | 4670 |
| 车辆宽度w/mm | 2082 |
| 车辆高度h/mm | 1405 |
| 前轮侧偏刚度Cαf/(N·rad | |
| 后轮侧偏刚度Cαr/(N·rad | |
| 质心到前轴距离/mm | 1015 |
| 质心到后轴距离/mm | 1895 |
| Z轴转动惯量IZ /(kg·m | 1536.7 |
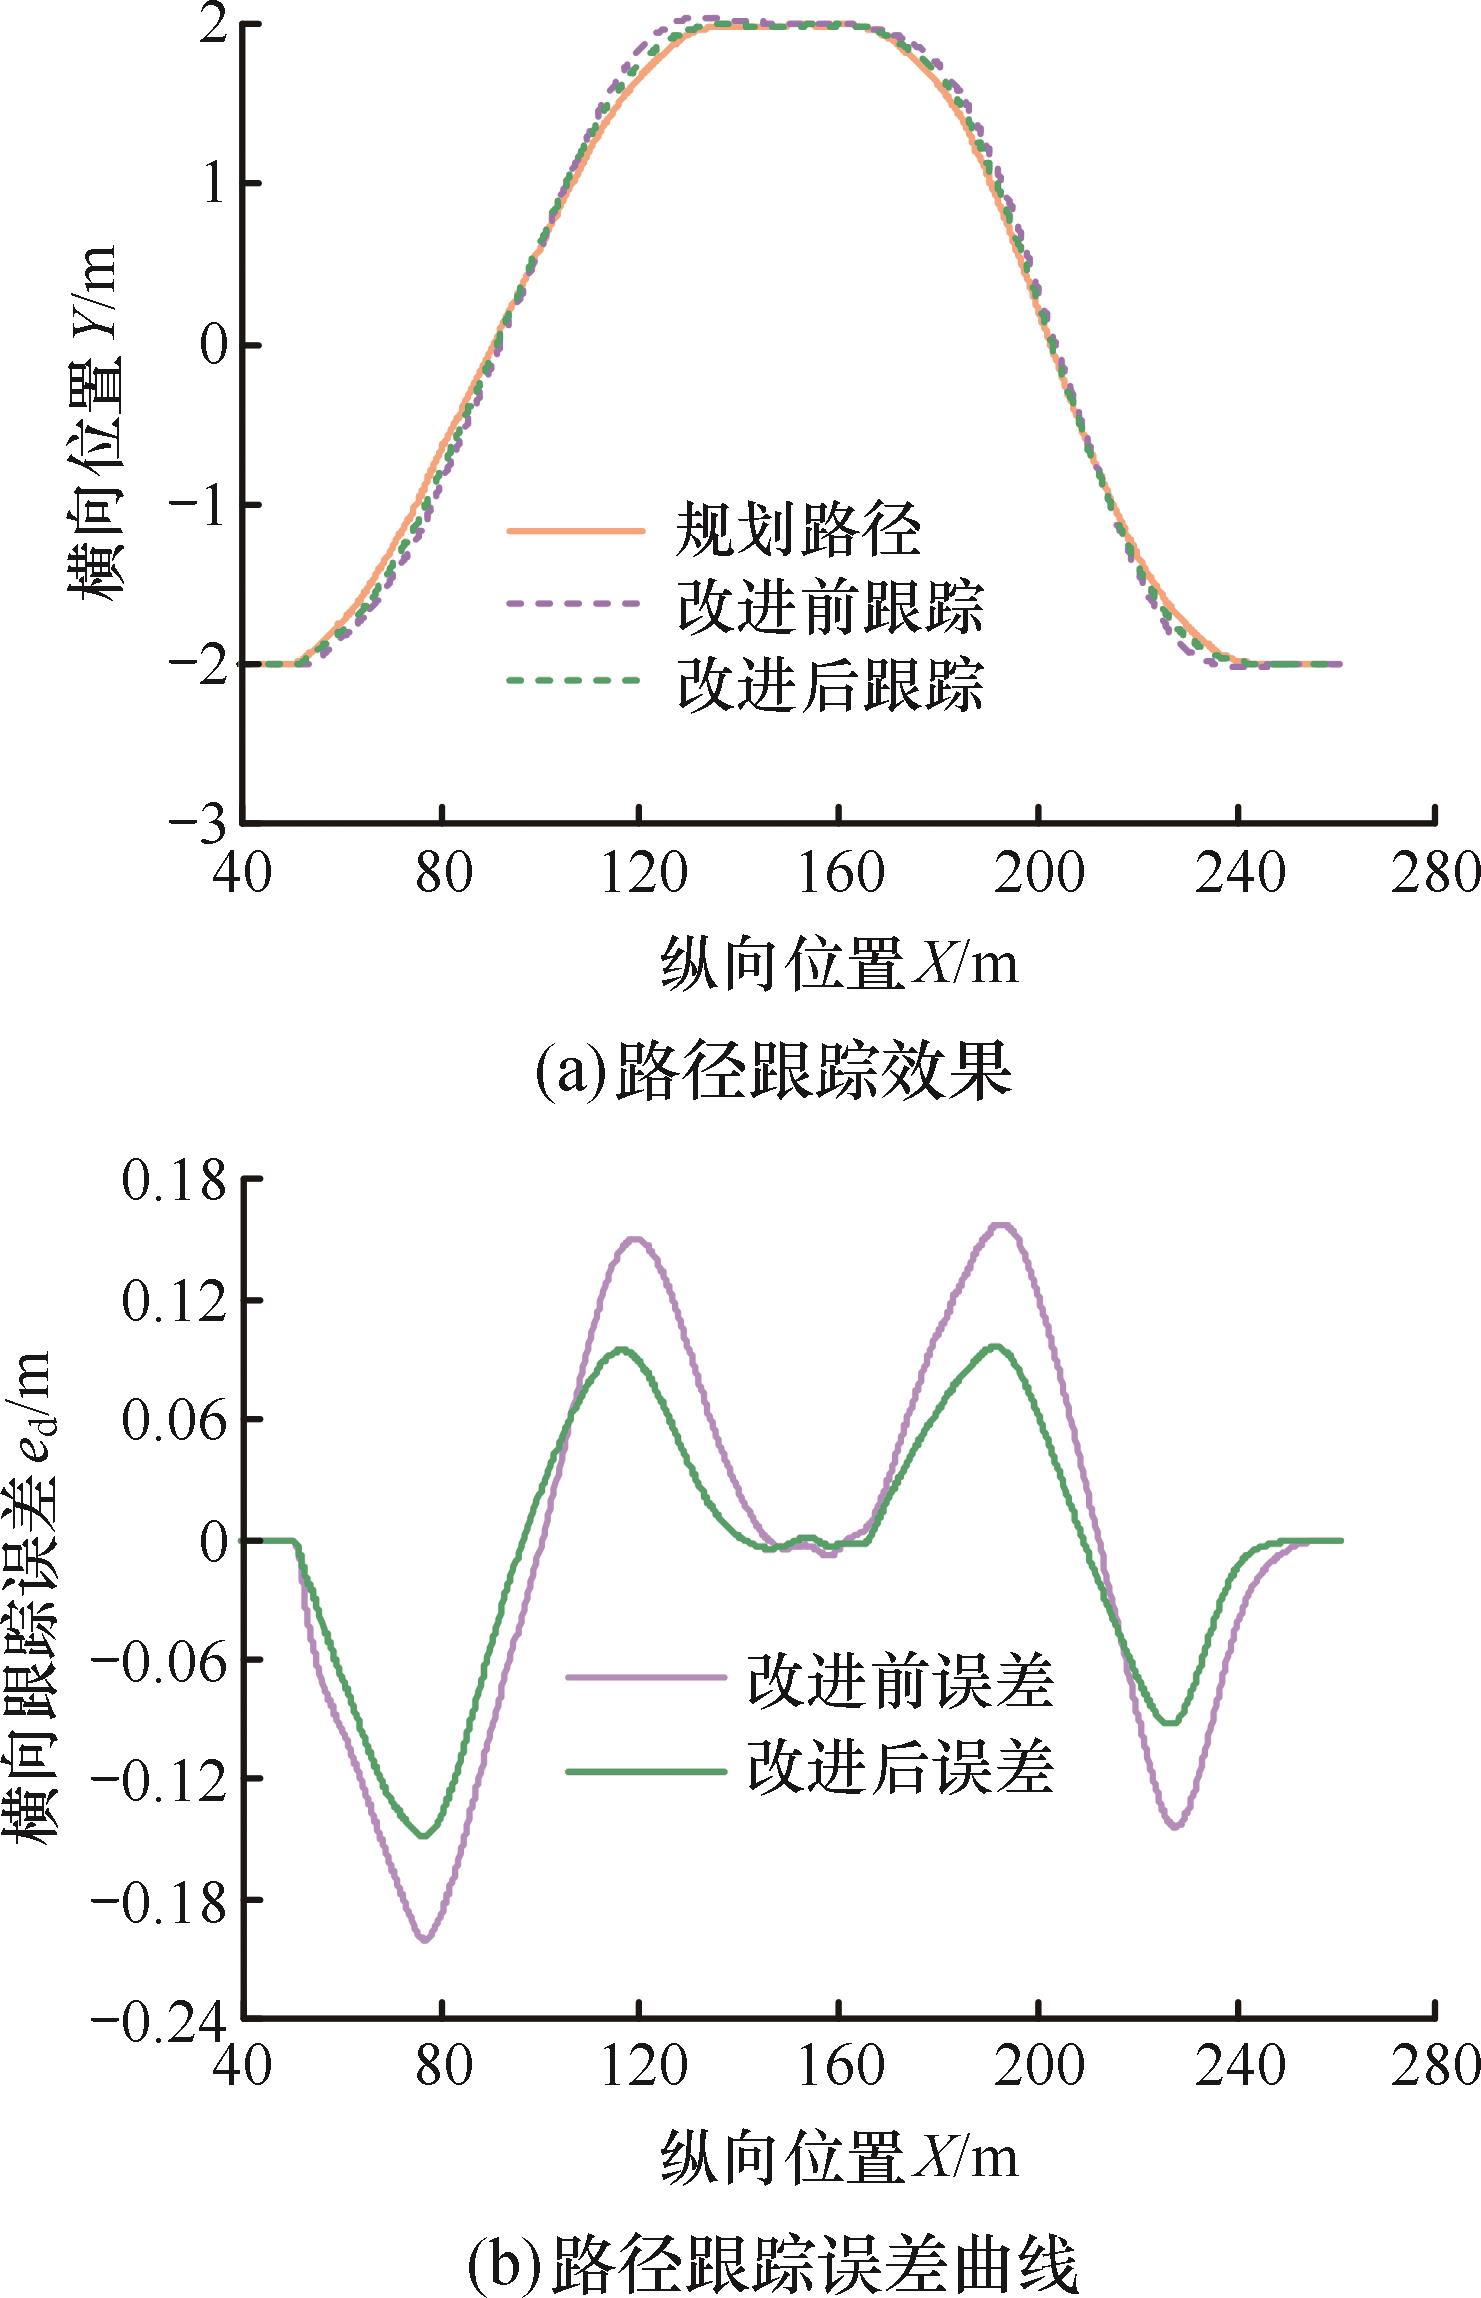
图10 改进前后路径跟踪对比
Fig.10 Comparison of path tracking before and after improvement
| 参数名称 | 均值 | 最大值 | 标准差 |
|---|---|---|---|
| 改进前误差/m | 0.098 | 0.202 | 0.072 |
| 改进后误差/m | 0.071 | 0.149 | 0.059 |
表3 路径跟踪误差数据对比
Tab.3 Path tracking error data comparison
| 参数名称 | 均值 | 最大值 | 标准差 |
|---|---|---|---|
| 改进前误差/m | 0.098 | 0.202 | 0.072 |
| 改进后误差/m | 0.071 | 0.149 | 0.059 |
| 受控车初速/(km·h | 障碍车初速/(km·h | 初始车距/m |
|---|---|---|
| 115 | 100 | 50 |
| 92 | 80 | 40 |
| 75 | 65 | 35 |
表4 仿真工况初始参数
Tab.4 Initial Parameters of Simulation Scenarios
| 受控车初速/(km·h | 障碍车初速/(km·h | 初始车距/m |
|---|---|---|
| 115 | 100 | 50 |
| 92 | 80 | 40 |
| 75 | 65 | 35 |
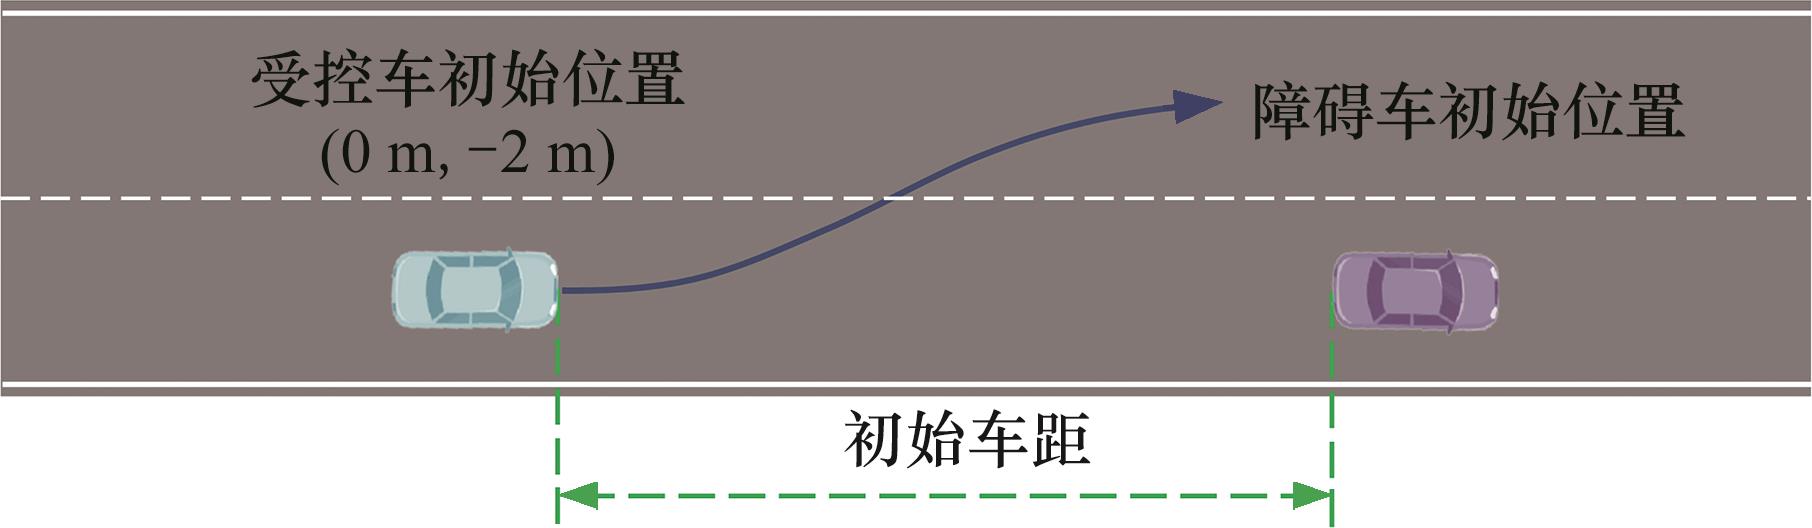
图11 障碍车匀速行驶场景
Fig.11 Constant-velocity moving obstacle vehicle scenario
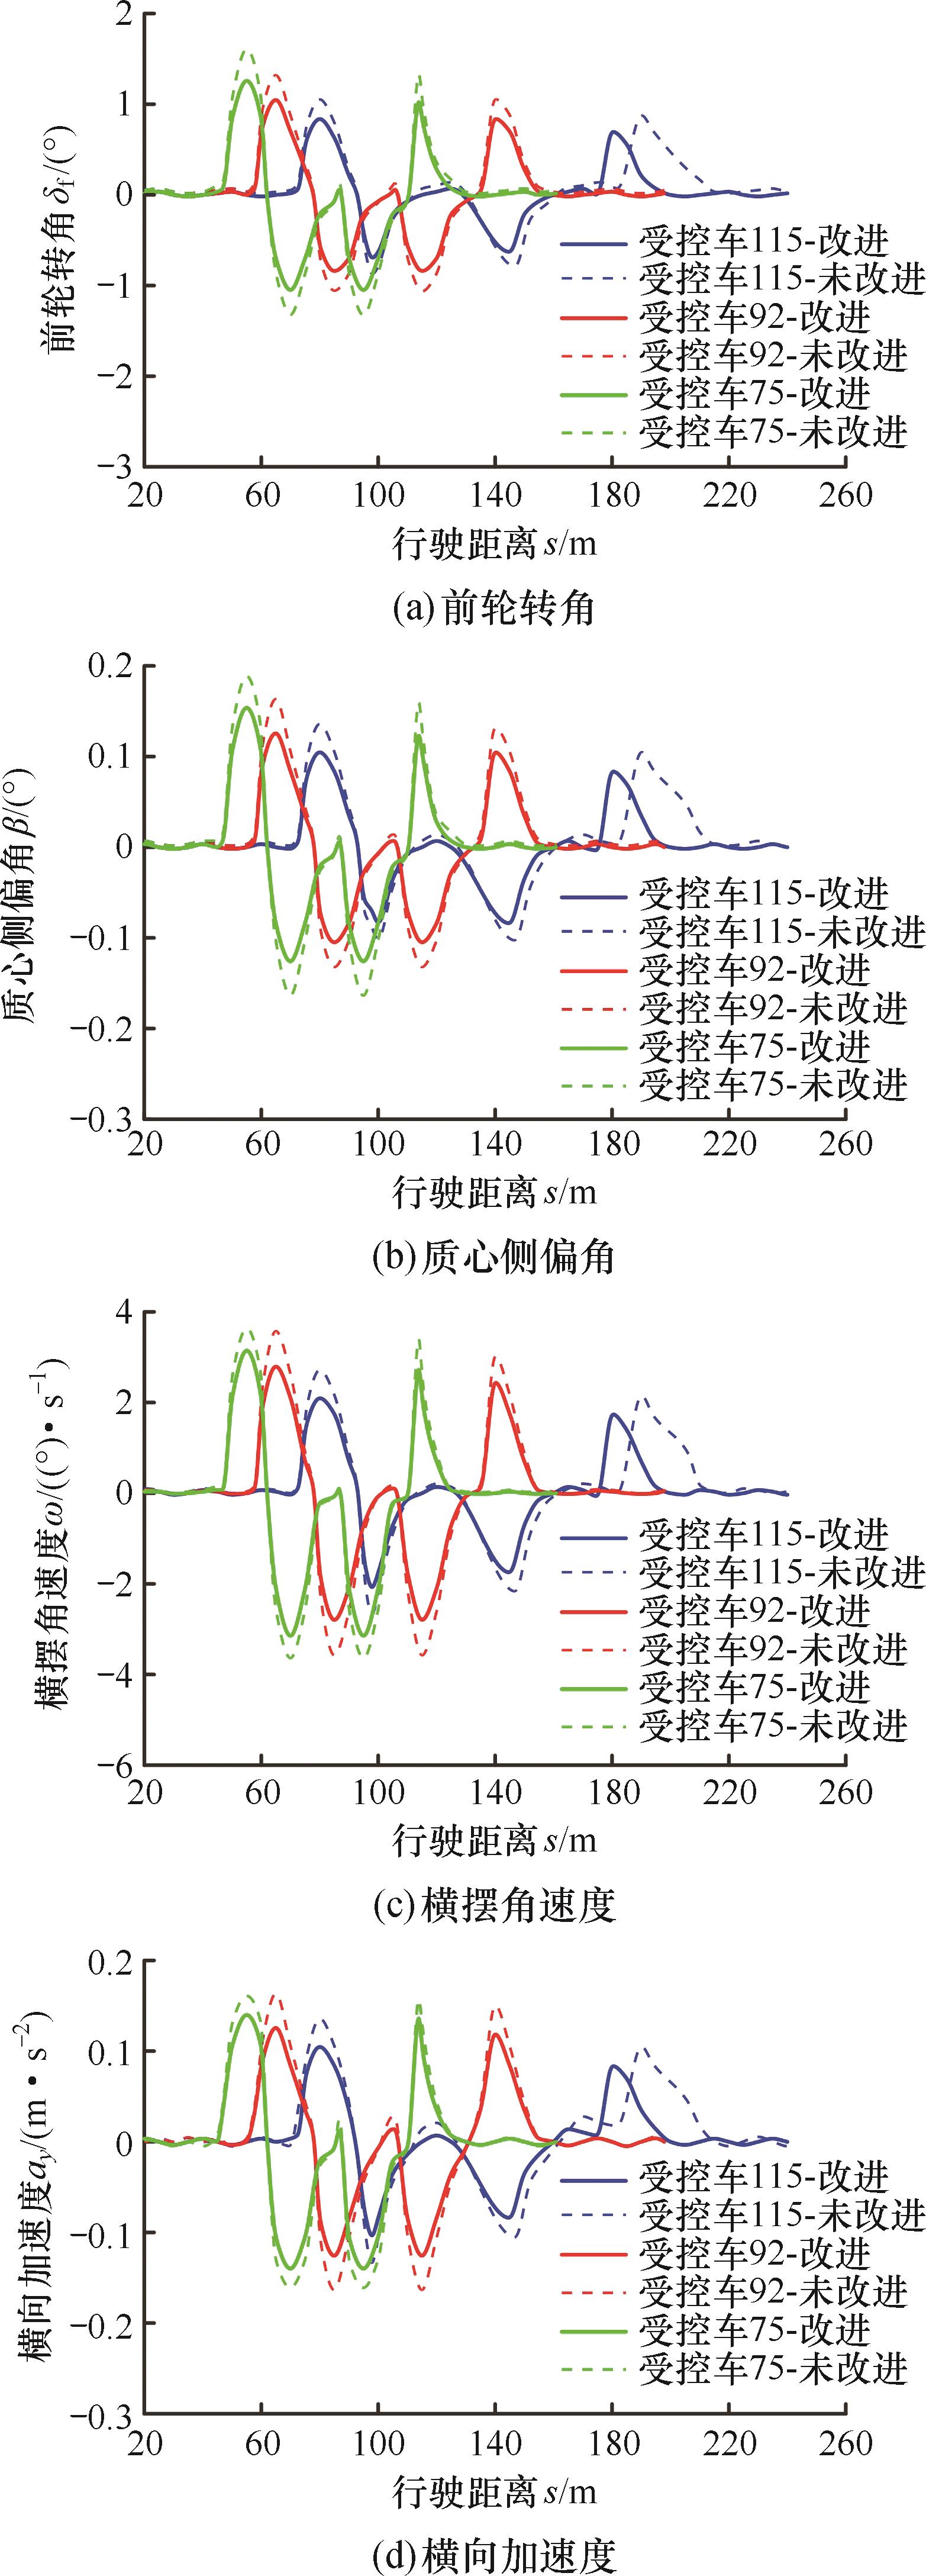
图12 场景一评价指标对比
Fig.12 Comparison of evaluation metrics for scenario 1
| 参数 | 均值 | 最大值 | ||
|---|---|---|---|---|
| 改进前 | 改进后 | 改进前 | 改进后 | |
| 前轮转角/(°) | 0.634 | 0.492 | 1.613 | 1.260 |
| 质心侧偏角/(°) | 0.075 | 0.059 | 0.189 | 0.154 |
| 横摆角速度/((°)·s | 1.572 | 1.298 | 3.647 | 3.152 |
| 横向加速度/(m·s | 0.080 | 0.066 | 0.161 | 0.143 |
表5 场景一仿真数据对比
Tab.5 Simulation data comparison for scenario 1
| 参数 | 均值 | 最大值 | ||
|---|---|---|---|---|
| 改进前 | 改进后 | 改进前 | 改进后 | |
| 前轮转角/(°) | 0.634 | 0.492 | 1.613 | 1.260 |
| 质心侧偏角/(°) | 0.075 | 0.059 | 0.189 | 0.154 |
| 横摆角速度/((°)·s | 1.572 | 1.298 | 3.647 | 3.152 |
| 横向加速度/(m·s | 0.080 | 0.066 | 0.161 | 0.143 |
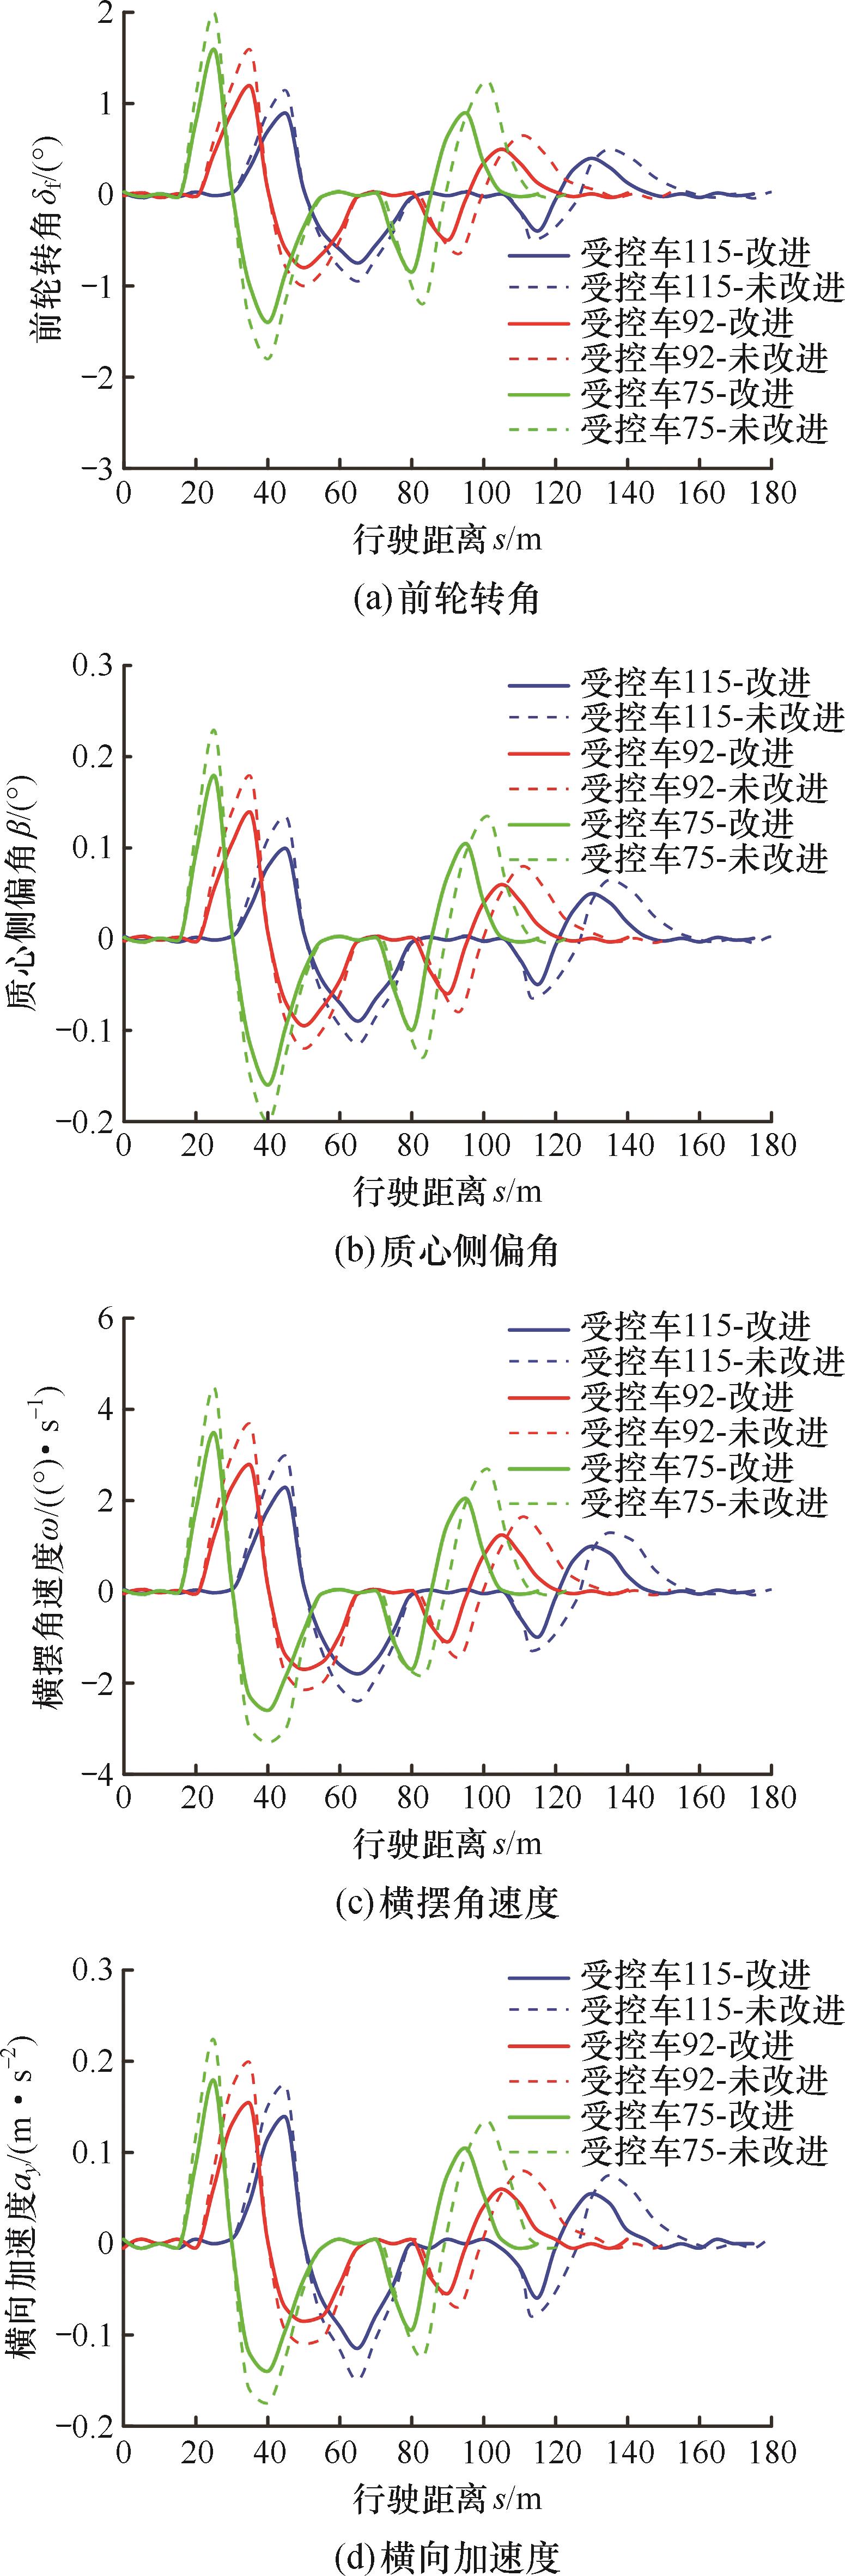
图13 场景二评价指标对比
Fig.13 Comparison of evaluation metrics for scenario 2
| 参数 | 均值 | 最大值 | ||
|---|---|---|---|---|
| 改进前 | 改进后 | 改进前 | 改进后 | |
| 前轮转角/(°) | 0.632 | 0.476 | 2.013 | 1.605 |
| 质心侧偏角/(°) | 0.070 | 0.054 | 0.231 | 0.187 |
| 横摆角速度/((°)·s | 1.353 | 1.036 | 4.511 | 3.536 |
| 横向加速度/(m·s | 0.070 | 0.054 | 0.225 | 0.184 |
表6 场景二仿真数据对比
Tab.6 Simulation data comparison for scenario 2
| 参数 | 均值 | 最大值 | ||
|---|---|---|---|---|
| 改进前 | 改进后 | 改进前 | 改进后 | |
| 前轮转角/(°) | 0.632 | 0.476 | 2.013 | 1.605 |
| 质心侧偏角/(°) | 0.070 | 0.054 | 0.231 | 0.187 |
| 横摆角速度/((°)·s | 1.353 | 1.036 | 4.511 | 3.536 |
| 横向加速度/(m·s | 0.070 | 0.054 | 0.225 | 0.184 |
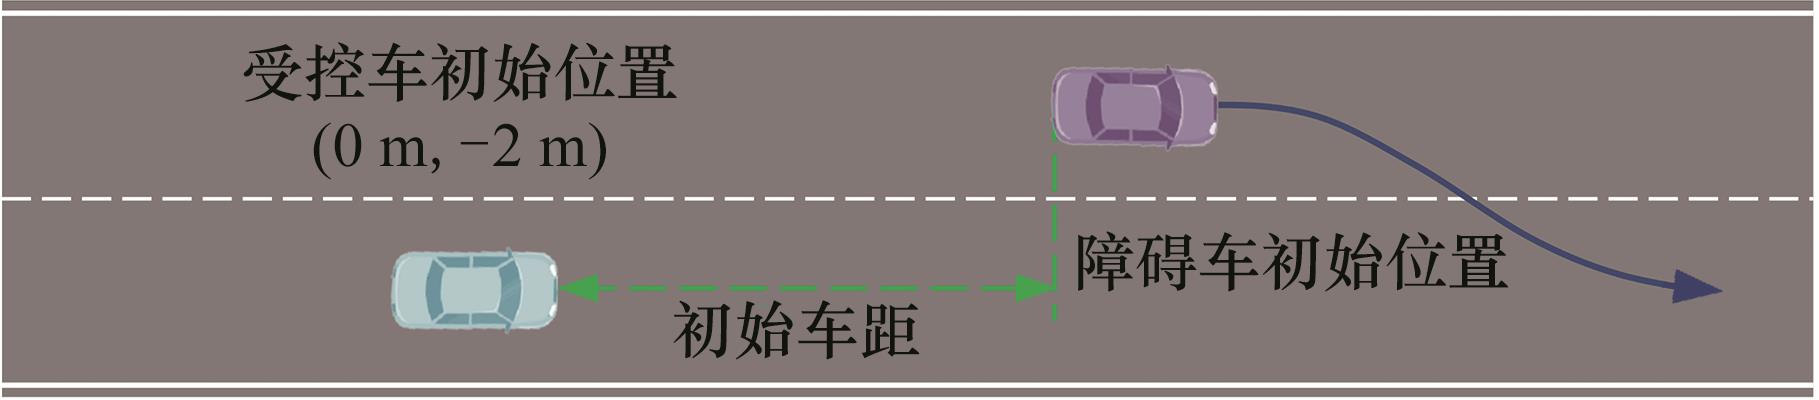
图14 障碍车变道行驶场景
Fig.14 Lane-changing moving obstacle vehicle scenario
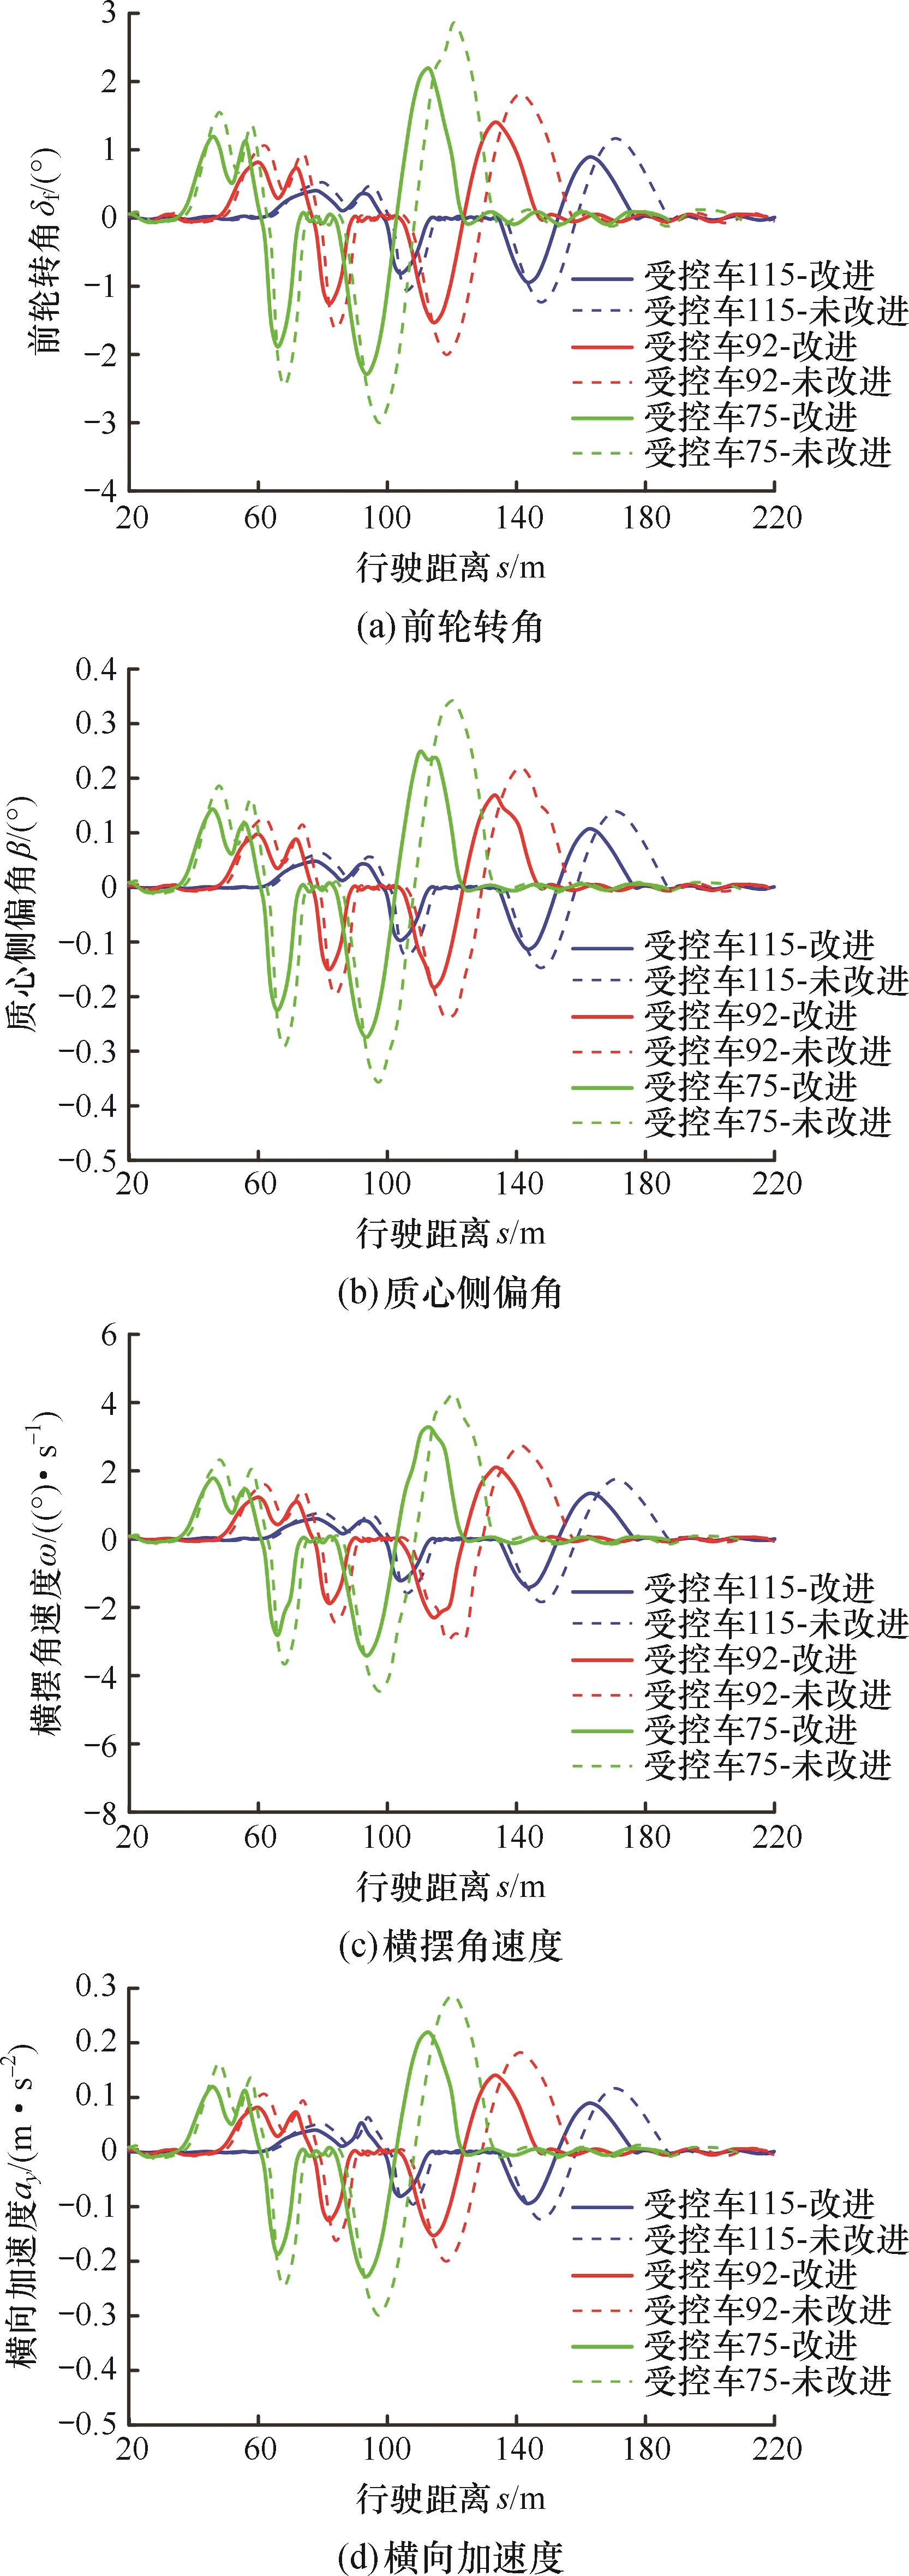
图15 场景三评价指标对比
Fig.15 Comparison of evaluation metrics for scenario 3
| 参数 | 均值 | 最大值 | ||
|---|---|---|---|---|
| 改进前 | 改进后 | 改进前 | 改进后 | |
| 前轮转角/(°) | 1.165 | 0.894 | 3.009 | 2.295 |
| 质心侧偏角/(°) | 0.139 | 0.107 | 0.358 | 0.275 |
| 横摆角速度/((°)·s | 1.746 | 1.327 | 4.468 | 3.427 |
| 横向加速度/(m·s | 0.117 | 0.090 | 0.301 | 0.229 |
表7 场景三仿真数据对比
Tab.7 Simulation data comparison for scenario 3
| 参数 | 均值 | 最大值 | ||
|---|---|---|---|---|
| 改进前 | 改进后 | 改进前 | 改进后 | |
| 前轮转角/(°) | 1.165 | 0.894 | 3.009 | 2.295 |
| 质心侧偏角/(°) | 0.139 | 0.107 | 0.358 | 0.275 |
| 横摆角速度/((°)·s | 1.746 | 1.327 | 4.468 | 3.427 |
| 横向加速度/(m·s | 0.117 | 0.090 | 0.301 | 0.229 |
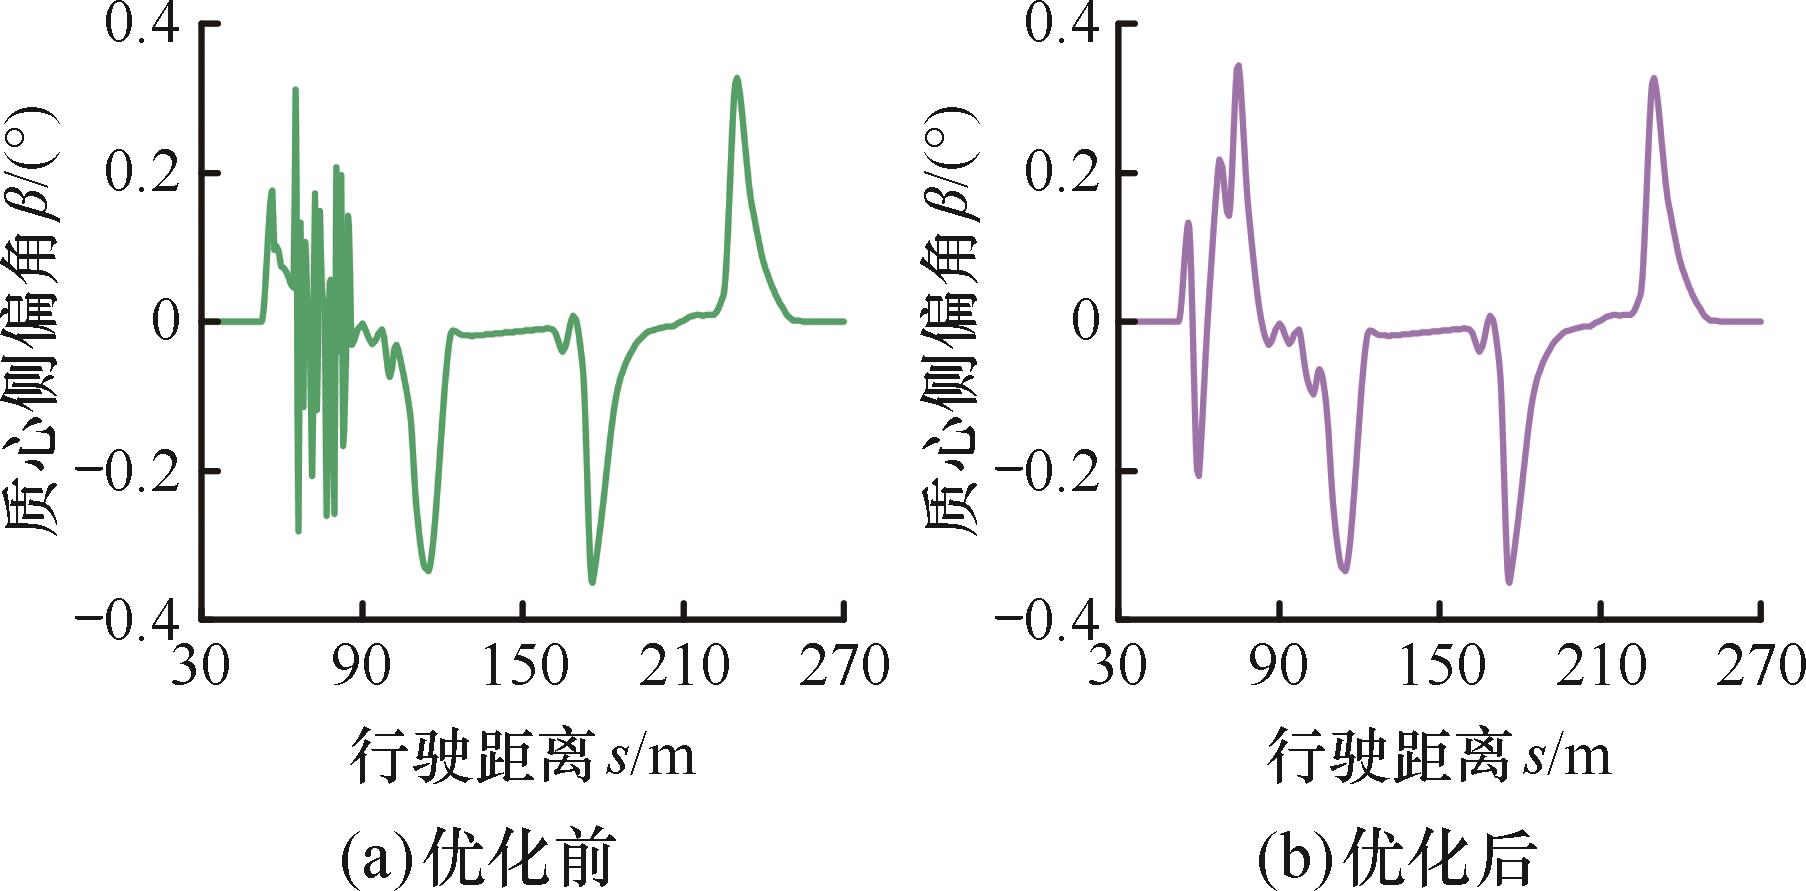
图16 优化前后车辆质心侧偏角对比
Fig.16 Comparison of vehicle yaw angle before and after optimization
| [1] | 张志文, 刘伯威, 张继园, 等. 麻雀搜索算法-粒子群算法与快速扩展随机树算法协同优化的智能车辆路径规划[J]. 中国机械工程, 2024, 35(6): 993-999. |
| ZHANG Zhiwen, LIU Bowei, ZHANG Jiyuan, et al. Cooperative Optimization of Intelligent Vehicle Path Planning Based on PSO-SSA and RRT[J]. China Mechanical Engineering, 2024, 35(6): 993-999. | |
| [2] | HUANG Guanghao, MA Qinglu. Research on Path Planning Algorithm of Autonomous Vehicles Based on Improved RRT Algorithm[J]. International Journal of Intelligent Transportation Systems Research, 2022, 20(1): 170-180. |
| [3] | WU Sifan, TIAN Daxin, DUAN Xuting, et al. Continuous Decision-making in Lane Changing and Overtaking Maneuvers for Unmanned Vehicles: a Risk-aware Reinforcement Learning Approach with Task Decomposition[J]. IEEE Transactions on Intelligent Vehicles, 2024, 9(4): 4657-4674. |
| [4] | HUANG Wenhui, LIU Haochen, HUANG Zhiyu, et al. Safety-aware Human-in-the-loop Reinforcement Learning with Shared Control for Autonomous Driving[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(11): 16181-16192. |
| [5] | HU Chuan, DU Baiyu, WANG Zhidong, et al. Perceptual Uncertainty-aware Motion Planning for Autonomous Driving Based on Adaptive Heuristic Reinforcement Learning[J]. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(8): 12676-12687. |
| [6] | YUAN Xiaofang, HUANG Guoming, SHI Ke. Improved Adaptive Path Following Control System for Autonomous Vehicle in Different Velocities[J]. IEEE Transactions on Intelligent Transportation Systems, 2020, 21(8): 3247-3256. |
| [7] | 崔凯晨, 高松, 王鹏伟, 等. 基于前馈+预测LQR的智能车循迹控制器设计[J]. 科学技术与工程, 2024, 24(10): 4287-4299. |
| CUI Kaichen, GAO Song, WANG Pengwei, et al. Intelligent Vehicle Tracking Controller Design Based on Feedforward+Prediction LQR[J]. Science Technology and Engineering, 2024, 24(10): 4287-4299. | |
| [8] | LENZO B, GOEL T, CHRISTIAN GERDES J. Autonomous Drifting Using Torque Vectoring: Innovating Active Safety[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(11): 17931-17939. |
| [9] | HUANG Zhenmin, SHEN Shaojie, MA Jun. Decentralized iLQR for Cooperative Trajectory Planning of Connected Autonomous Vehicles via Dual Consensus ADMM[J]. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(11): 12754-12766. |
| [10] | 王姝, 张海川, 赵轩, 等. 融合稳定性的分布式驱动电动汽车路径跟踪控制策略研究[J]. 中国机械工程, 2023, 34(9): 1035-1044. |
| WANG Shu, ZHANG Haichuan, ZHAO Xuan, et al. Research on Path Tracking Control Method of Distributed Drive Electric Vehicles with Integrated Stability[J]. China Mechanical Engineering, 2023, 34(9): 1035-1044. | |
| [11] | 王启明, 万璇, 方鸣, 等. 基于动态非合作博弈的智能网联汽车超车行为决策研究[J]. 控制与决策, 2025, 40(7): 2300-2312. |
| WANG Qiming, WAN Xuan, FANG Ming, et al. Decision-making Research on Overtaking Behavior of Connected and Automated Vehicles Based on Dynamic Non-cooperative Game[J]. Control and Decision, 2025, 40(7): 2300-2312. | |
| [12] | 交通运输部规划研究院. 2023年全国干线公路交通情况报告[M]. 北京: 人民交通出版社, 2024: 5-9. |
| Planning and Research Institute of the Ministry of Transport. Report on National Trunk Highway Traffic in 2023[M]. Beijing: China Communications Press, 2024: 5-9. | |
| [13] | 戢晓峰, 徐迎豪, 郝京京, 等. 双车道公路超车行为风险演化时间协变量建模[J]. 西南交通大学学报, 2025, 60(5): 1240-1249. |
| JI Xiaofeng, XU Yinghao, HAO Jingjing, et al. Time Covariate Modeling of Overtaking Risk Evolution on Two-lane Highways[J]. Journal of Southwest Jiaotong University, 2025, 60(5): 1240-1249. | |
| [14] | 张志勇, 龙凯, 杜荣华, 等. 自动驾驶汽车高速超车轨迹跟踪协调控制[J]. 汽车工程, 2021, 43(7): 995-1004. |
| ZHANG Zhiyong, LONG Kai, DU Ronghua, et al. Trajectory Tracking Coordinated Control for Autonomous Vehicle in High-speed Overtaking[J]. Automotive Engineering, 2021, 43(7): 995-1004. | |
| [15] | 安泰. 前车切入场景下的自动驾驶汽车局部避障研究[D]. 兰州: 兰州交通大学, 2021. |
| AN Tai. Research on Local Obstacle Avoidance of Self-driving Vehicles in the Scene of Front Vehicle Cutting-in[D]. Lanzhou: Lanzhou Jiaotong University, 2021. | |
| [16] | 赵林峰, 张丁之, 王慧然, 等. 基于改进安全距离模型的人机协同纵向避撞研究[J]. 汽车工程, 2021(4): 588-600. |
| ZHAO Linfeng, ZHANG Dingzhi, WANG Huiran, et al. Study on Longitudinal Collision Avoidance with Human-machine Cooperation Based on Improved Safety Distance Model[J]. Automotive Engineering, 2021(4): 588-600. | |
| [17] | 张兴龙. 汽车纵横向运动安全和操控中的逆动力学研究[D]. 南京: 南京航空航天大学, 2020. |
| ZHANG Xinglong. Research on the Vehicle Longitudinal/lateral Driving Safety and Motion Control Based on Inverse Dynamics [D]. Nanjing: Nanjing University of Aeronautics and Astronautics, 2020. | |
| [18] | 郭靖, 李响, 鲜勇. 基于强化学习的自适应人工势场航迹规划方法[J]. 兵器装备工程学报, 2024, 45(11): 25-33. |
| GUO Jing, LI Xiang, XIAN Yong. Adaptive Artificial Potential Track Planning Method Based on Reinforcement Learning[J]. Journal of Ordnance Equipment Engineering, 2024, 45(11): 25-33. | |
| [19] | 郑雪莲, 李显生, 任园园, 等. 基于视觉特性的驾驶人预瞄时间建模[J]. 中国公路学报, 2018, 31(5): 160-166. |
| ZHENG Xuelian, LI Xiansheng, REN Yuanyuan, et al. Modelling of Driver’s Preview Time Based on Visual Characteristics[J]. China Journal of Highway and Transport, 2018, 31(5): 160-166. |
| [1] | 孙东, 汪若尘, 丁仁凯, 陈轶杰. 基于灰狼算法的矿用自卸车油气悬架半主动控制[J]. 中国机械工程, 2023, 34(04): 490-497. |
| [2] | 丁镇涛, 邓涛, 李志飞, 尹燕莉. 基于安时积分和无迹卡尔曼滤波的锂离子电池SOC估算方法研究[J]. 中国机械工程, 2020, 31(15): 1823-1830. |
| [3] | 凤鹏飞1,2;金会庆1,2;王慧然3;刘法勇4. 考虑路面附着和自适应时间系数影响的车道保持控制[J]. 中国机械工程, 2019, 30(07): 804-811. |
| [4] | 隗寒冰1;曹旭1;赖锋2. 智能汽车环境感知算法测试评价系统开发[J]. 中国机械工程, 2018, 29(19): 2298-2305,2311. |
| [5] | 赵林峰, 徐磊, 陈无畏. 基于自抗扰控制的自动泊车路径跟踪[J]. 中国机械工程, 2017, 28(08): 966-973. |
| [6] | 阚萍, 邱利宏, 钱立军, 王金波. 基于Willans Line的双轴驱动混合动力越野车实时能量管理[J]. 中国机械工程, 2016, 27(11): 1546-1553. |
| [7] | 张荣芸, 赵林峰, 陈无畏, 黄鹤. 基于LPV/H∞控制的EPS系统及其硬件在环研究[J]. 中国机械工程, 2015, 26(4): 545-552. |
| [8] | 钱立军, 邱利宏, 陈朋. 基于模糊PID扭矩识别的混合动力汽车优化控制[J]. 中国机械工程, 2015, 26(13): 1752-1759. |
| [9] | 黄智, 刘剑, 胡凯, 刘李盼. 气压ABS关键技术研究与试验[J]. 中国机械工程, 2014, 25(8): 1126-1130. |
| [10] | 刘永刚, 秦大同, 彭志远, 叶明. 新型混合动力系统硬件在环试验研究[J]. 中国机械工程, 2014, 25(17): 2374-2380. |
| [11] | 赵治国, 王琪, 刁威振, 陈海军. 双离合器变速汽车坡道模糊修正换挡研究[J]. 中国机械工程, 2013, 24(15): 2122-2129. |
| [12] | 周兵1, 杨静1, 习纲2, 陈鹏2. 发动机传感器故障硬件在环仿真平台研究[J]. 中国机械工程, 2013, 24(09): 1181-1185. |
| [13] | 张炳力1, 董彦文1, 胡福建1, 刘宗其1, 2. 某型叉车自动变速器控制系统的快速原型和硬件在环试验研究
|
| [14] | 周斯加1, 龙江启1, 储军1, 张荫先2. 电动车用对转双转子电机驱动及防滑试验研究 [J]. 中国机械工程, 2012, 23(3): 343-346. |
| [15] | 皮大伟1, 游辉敏2, 张丙军3, 钟国华1, 3. 汽车动力学稳定性控制系统开发平台研究[J]. 中国机械工程, 2012, 23(24): 3020-3023. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
